SfMLearner
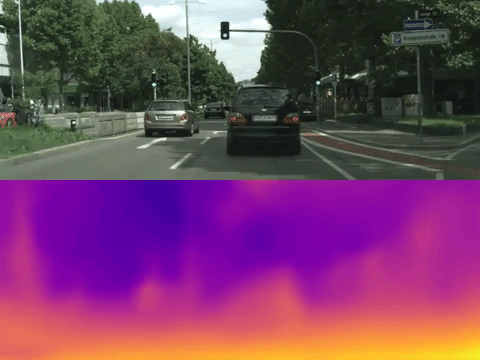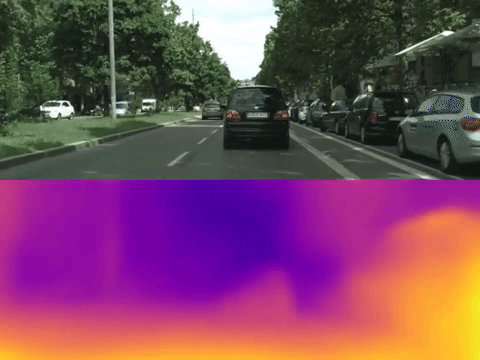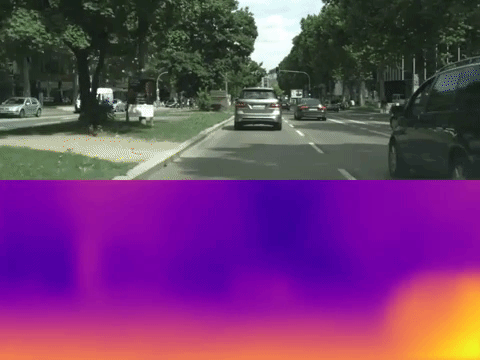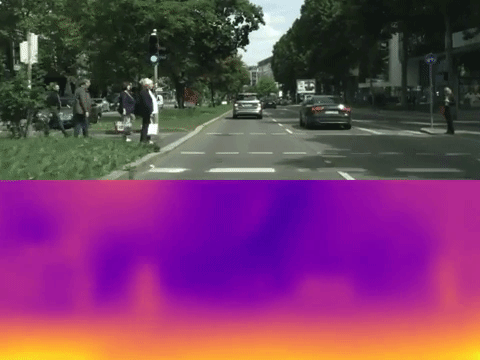
An unsupervised learning framework for depth and ego-motion estimation from monocular videos
- 2k
- Jupyter Notebook
- MIT
- 5 y ago
An unsupervised learning framework for depth and ego-motion estimation from monocular videos
pySLAM is a hybrid Python/C++ Visual SLAM pipeline supporting monocular, stereo, and RGB-D cameras. It provides a broad set of modern local and global feature extractors, multiple loop-closure strategies, a volumetric reconstruction module, integrated depth-prediction models, and semantic segmentation capabilities for enhanced scene understanding.