ASAP
[RSS 2025] "ASAP: Aligning Simulation and Real-World Physics for Learning Agile Humanoid Whole-Body Skills"
- 2.1k
- Python
- MIT
- 11 mo ago
The maintainer has not written a description at the source.
Repo LeCAR-Lab/LeCAR-Lab.github.io, read from GitHub 10 min ago. LeCAR-Lab has not joined Take My Repo.
LeCAR-Lab/LeCAR-Lab.github.io is a public repo on GitHub by LeCAR-Lab. It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it. It is written mainly in HTML, has 9 stars and last changed on 2026-10-21. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-21.
LeCAR-Lab/LeCAR-Lab.github.io is a public repo on GitHub by LeCAR-Lab. Its maker has not written a description.
It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it.
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Its last change on GitHub was on 2026-10-21. Take My Repo does not judge from that whether it is maintained.
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.
[RSS 2025] "ASAP: Aligning Simulation and Real-World Physics for Learning Agile Humanoid Whole-Body Skills"
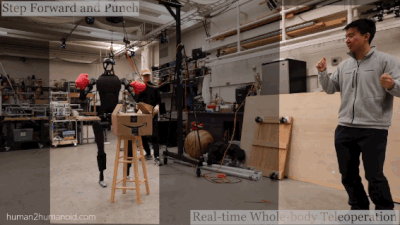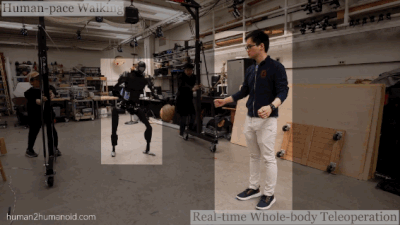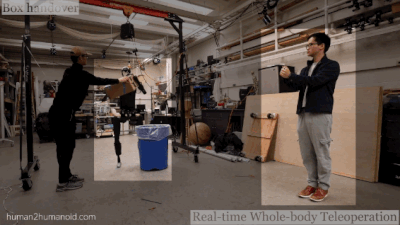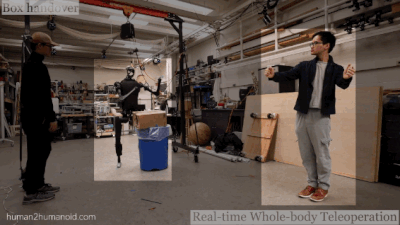
[IROS 2024] Learning Human-to-Humanoid Real-Time Whole-Body Teleoperation. [CoRL 2024] OmniH2O: Universal and Dexterous Human-to-Humanoid Whole-Body Teleoperation and Learning
Official implementation for the paper "Full-Order Sampling-Based MPC for Torque-Level Locomotion Control via Diffusion-Style Annealing". DIAL-MPC is a novel sampling-based MPC framework for legged robot full-order torque-level control with both precision and agility in a training-free manner.
BFM_Zero: A Promptable Behavioral Foundation Model for Humanoid Control Using Unsupervised Reinforcement Learning