

BundleTrack
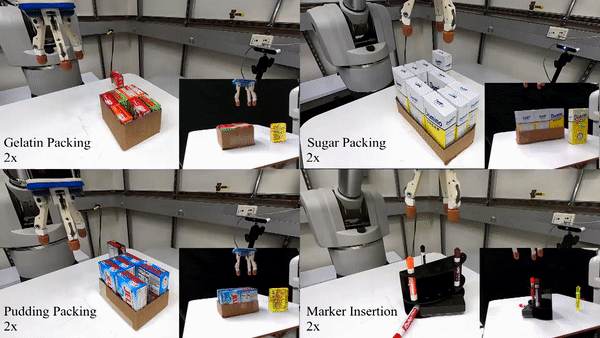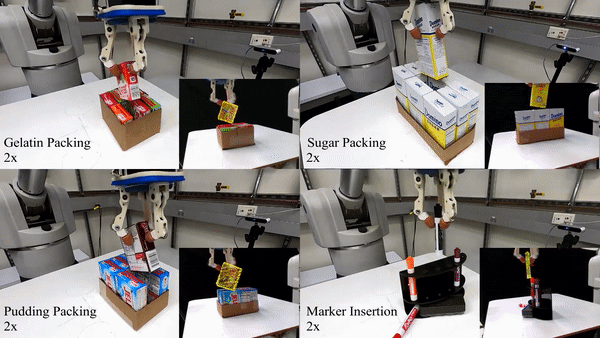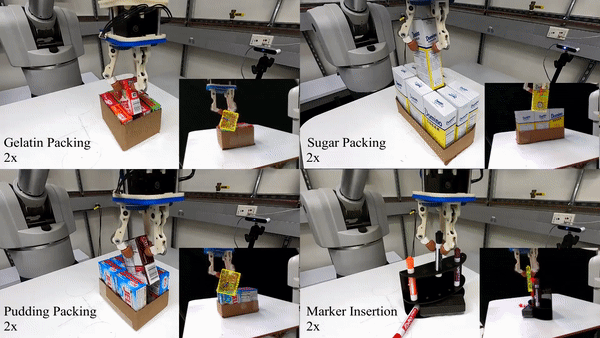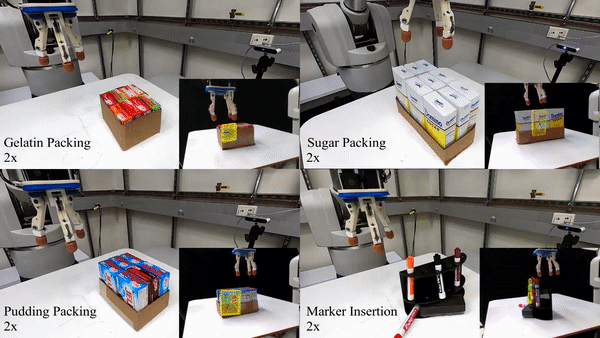
[IROS 2021] BundleTrack: 6D Pose Tracking for Novel Objects without Instance or Category-Level 3D Models
- 688
- C++
- Apache-2.0
- 7 mo ago
6DOF Sensor Fusion Algorithm for Mobile Sensor
Repo cuixing158/6DOF-Sensor-Fusion-Algorithm, read from GitHub 1 min ago. cuixing158 has not joined Take My Repo.
cuixing158/6DOF-Sensor-Fusion-Algorithm is a public repo on GitHub by cuixing158. 6DOF Sensor Fusion Algorithm for Mobile Sensor. It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it. It is written mainly in HTML, has 1 stars and last changed on 2025-02-08. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-22.
本仓库利用手机6轴(3轴加速度+3轴陀螺仪)来实时解算手机方位角!AHRS(Attitude and Heading Reference System)算法在MATLAB中实现非常广泛,参考了一些C/C++和MATLAB开源代码1,2。
imufilter内置函数,因为其融合了间接卡尔曼滤波器算法,而ahrsfilter则是对9轴传感器数据做姿态解算,根据参考文献3的PDF文档SensorFusionDatasheet.pdf如下所述:| Feature | Accel Only | Accel + Gyro | Accel + Mag | Accel + Mag + Gyro |
|---|---|---|---|---|
| Filter type | Low pass | Indirect Kalman | Low pass(1) | Indirect Kalman |
| Roll / Pitch / Tilt in degrees | Yes | Yes | Yes | Yes |
| Yaw in degrees | No | No | Yes | Yes |
| Angular rate in degrees/second | virtual 2 axis | Yes | virtual 3 axis | Yes |
| Compass heading (magnetic north) | No | No | Yes | Yes |
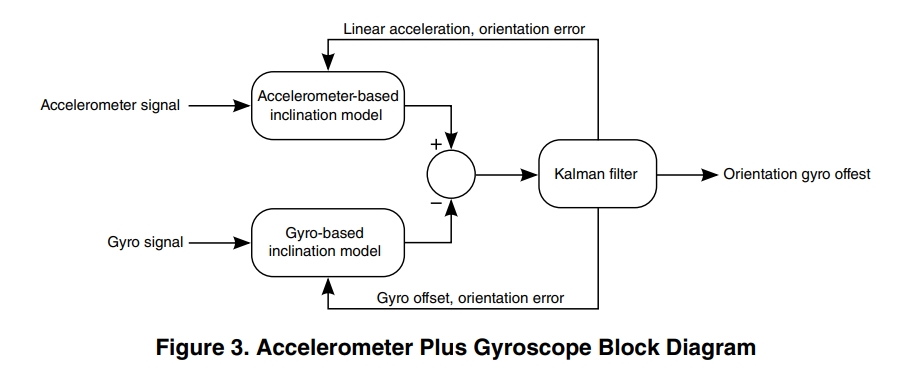
Accelerometer Plus Gyroscope3
Using a gyroscope in addition to an accelerometer yields the ability to smoothly measure rotation in 3D space, although the system can only yield orientation to some random horizontal global frame of reference. That is, the system has no sense of magnetic north. Computation of yaw is not supported by this configuration.This configuration is commonly known as an Inertial Measurement Unit (IMU).

官方示例“Estimate Phone Orientation Using Sensor Fusion”较好,已经修改使用imufilter,初步也可以估计位姿,待继续调查使用。
Note
cuixing158/6DOF-Sensor-Fusion-Algorithm is a public repo on GitHub by cuixing158. 6DOF Sensor Fusion Algorithm for Mobile Sensor.
It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it.
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Its last change on GitHub was on 2025-02-08. GitHub counts 0 open issues and pull requests. Take My Repo does not judge from that whether it is maintained.
[IROS 2021] BundleTrack: 6D Pose Tracking for Novel Objects without Instance or Category-Level 3D Models
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.

Open-source, fully 3D-printable 6-DOF controller for CAD and slicer navigation, powered by an Arduino Pro Micro and Hall-effect joysticks.
[IROS 2020] se(3)-TrackNet: Data-driven 6D Pose Tracking by Calibrating Image Residuals in Synthetic Domains
A Robust, Real-time, RGB-colored, LiDAR-Inertial-Visual tightly-coupled state Estimation and mapping package
:fire: :fire: :fire: A paper list of some recent Computer Vision(CV) works
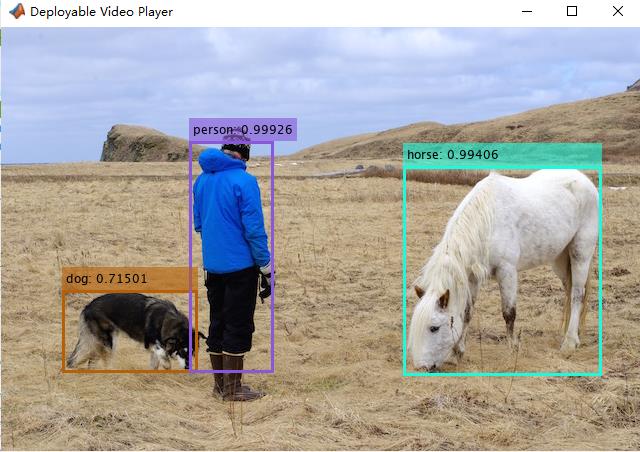
Import and export Darknet™ models within MATLAB deep learning networks.
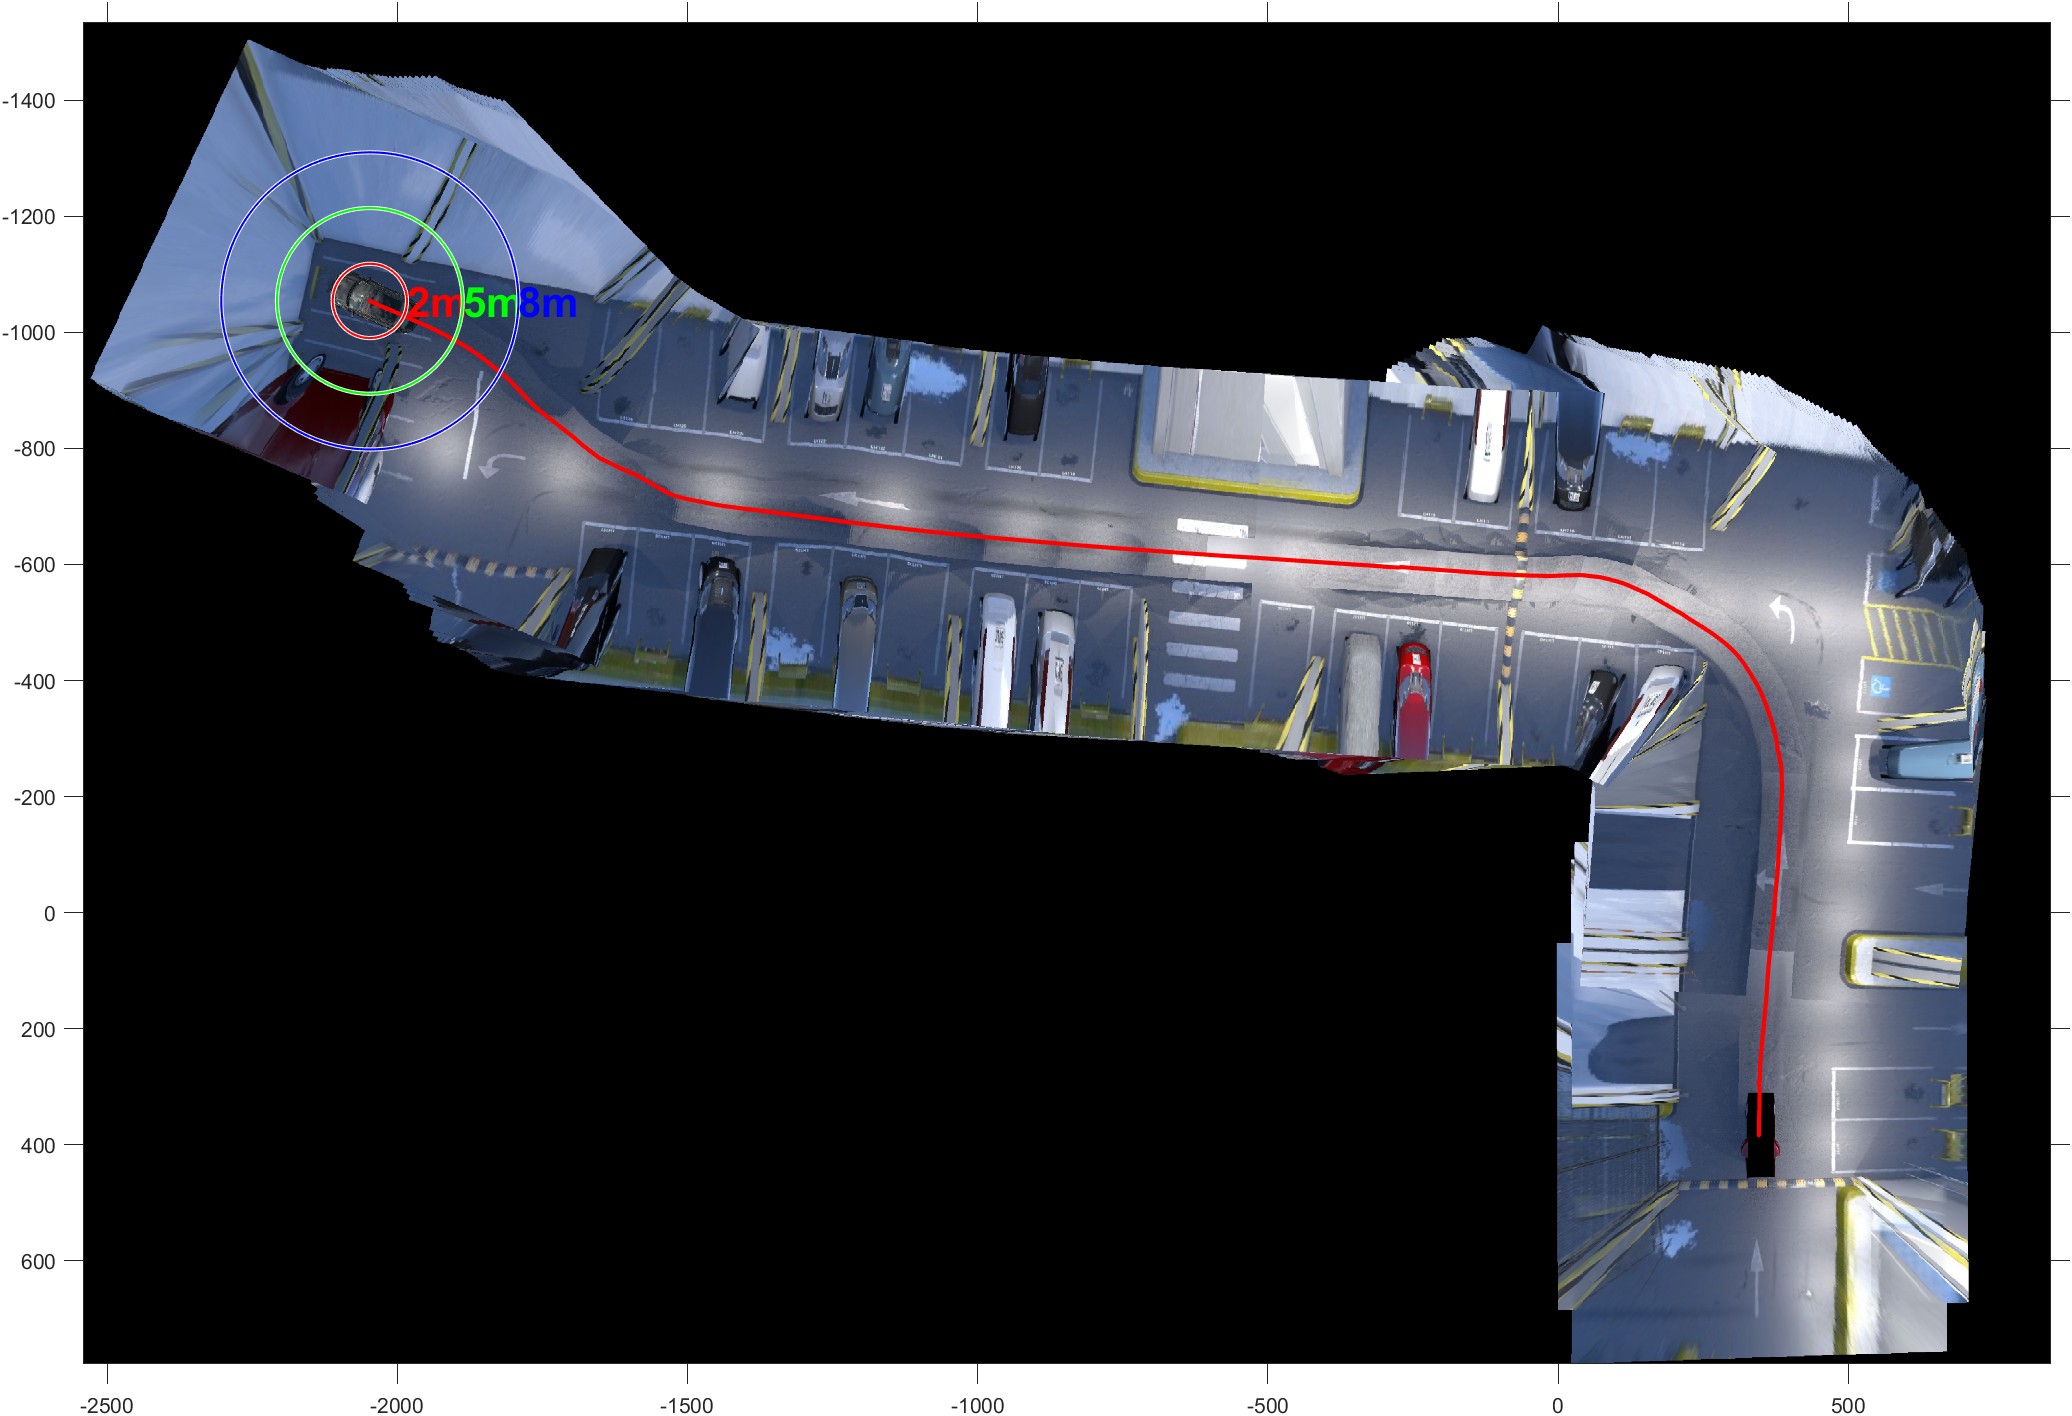
Stitching and fusion of 4 pairs of on-board surround view fisheye image sequences, odometer estimation and output of large pixel maps.
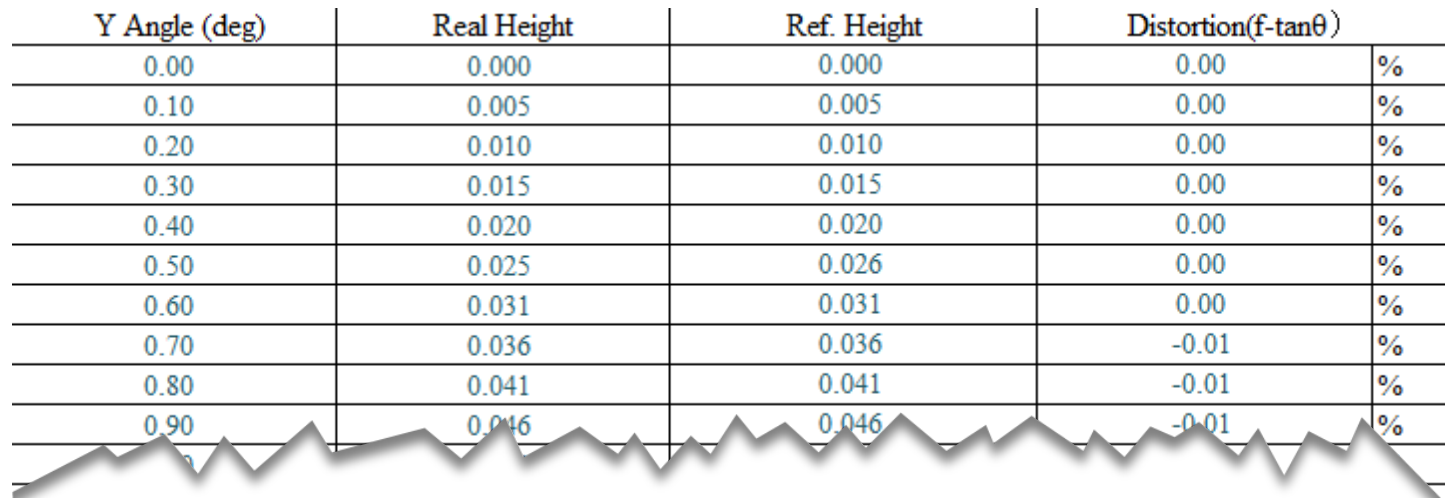
Fisheye image correction and distortion table conversion.
Implementation and visualisation of multiple classical linear calibration methods for a single image