
DiffHand
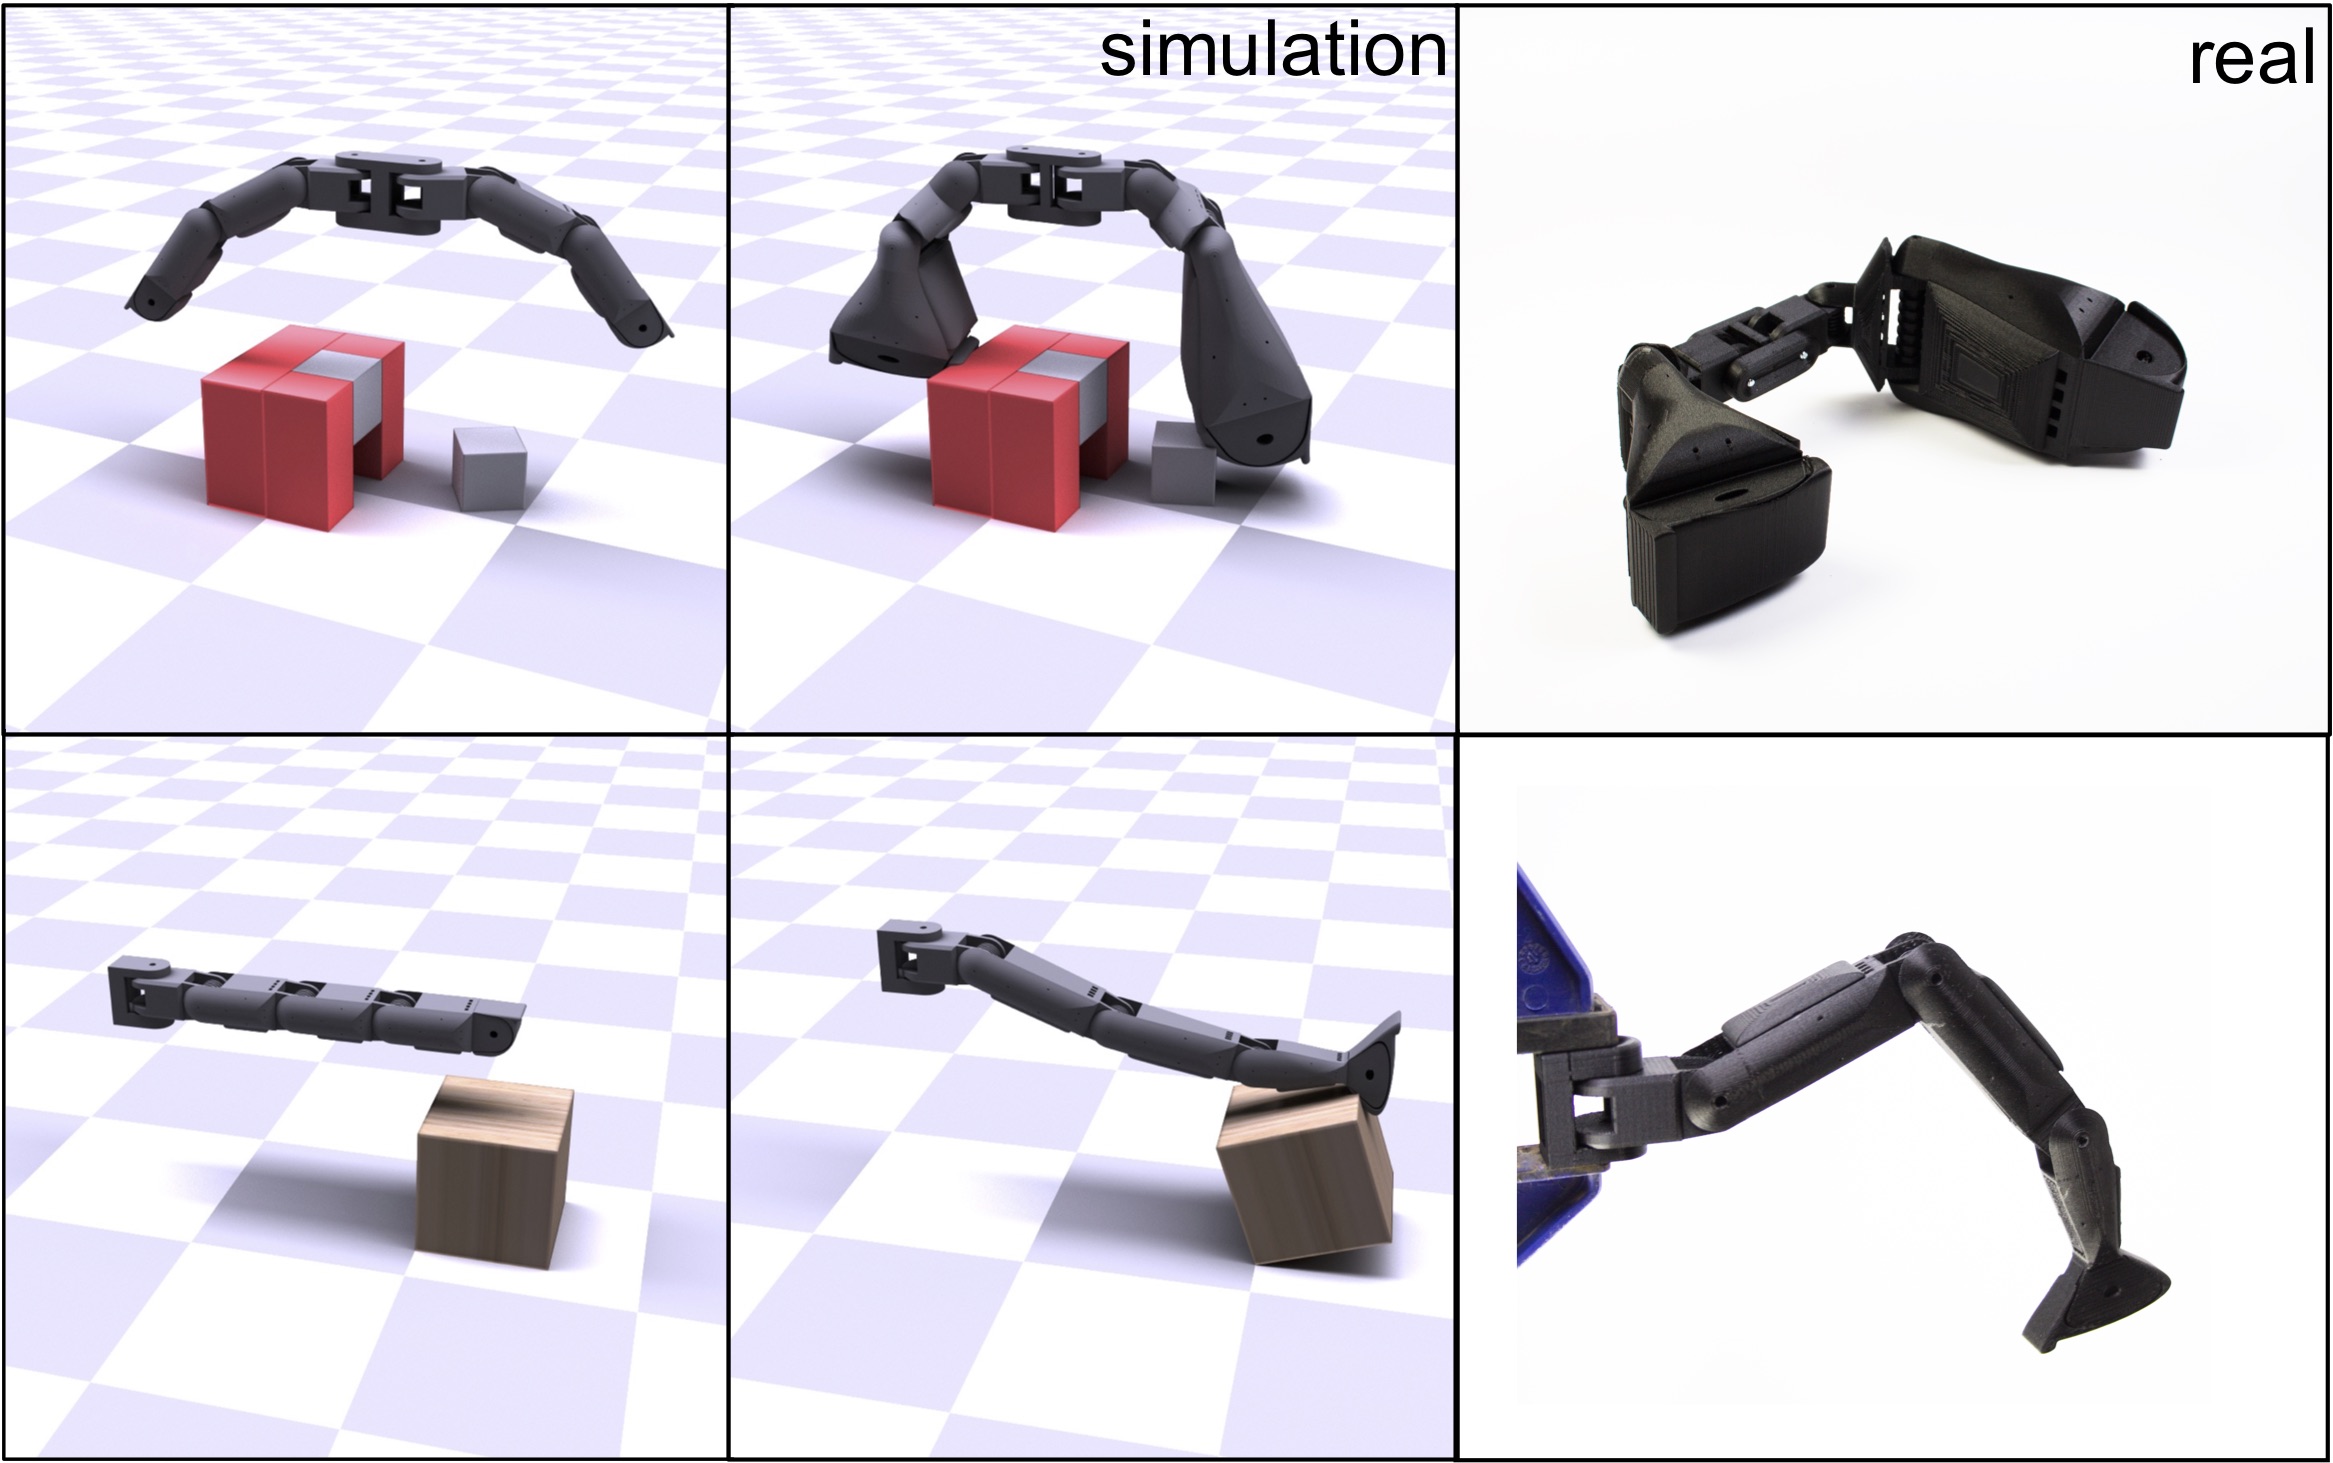
[RSS 2021] An End-to-End Differentiable Framework for Contact-Aware Robot Design
- 164
- MIT
- 4 y ago
Repo eanswer/DiffHand, read from GitHub 1 min ago. eanswer has not joined Take My Repo.
- DiffHandRelease
DiffHand version
The version of code for the DiffHand paper.