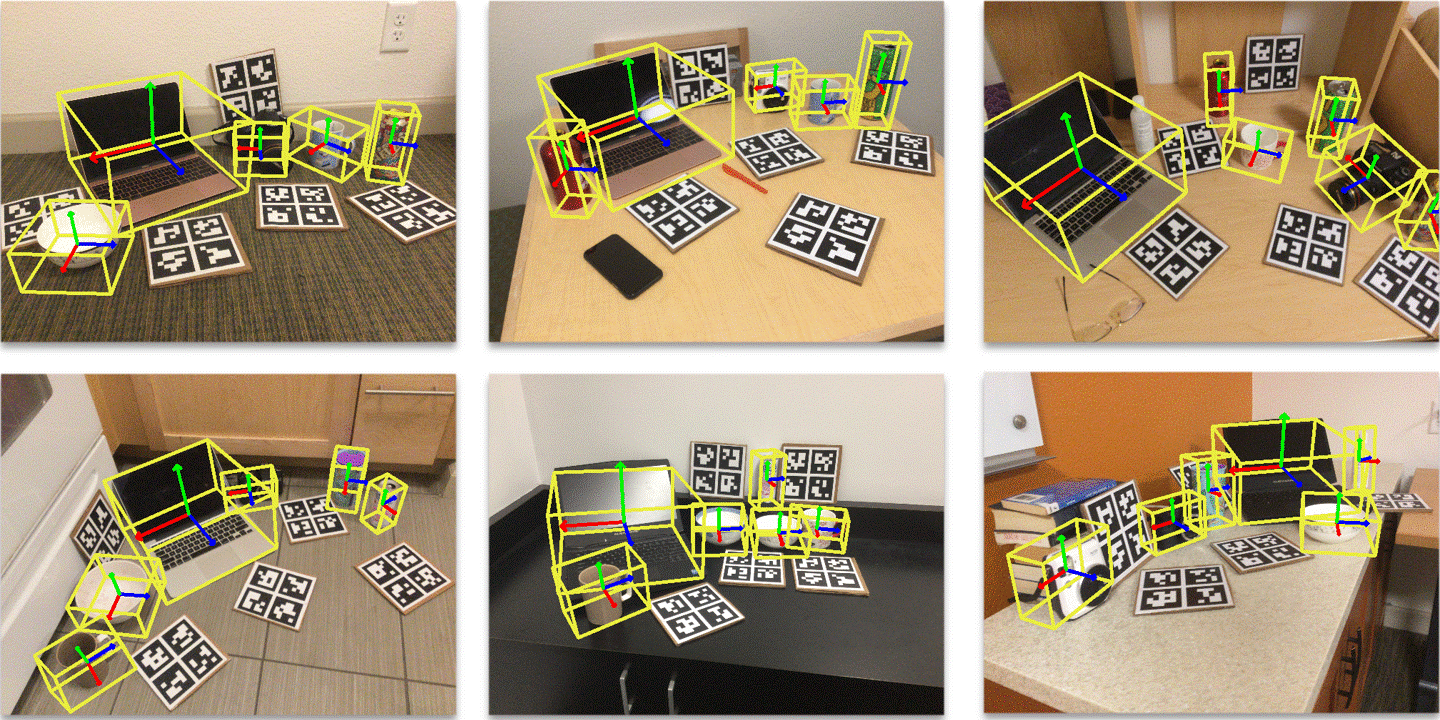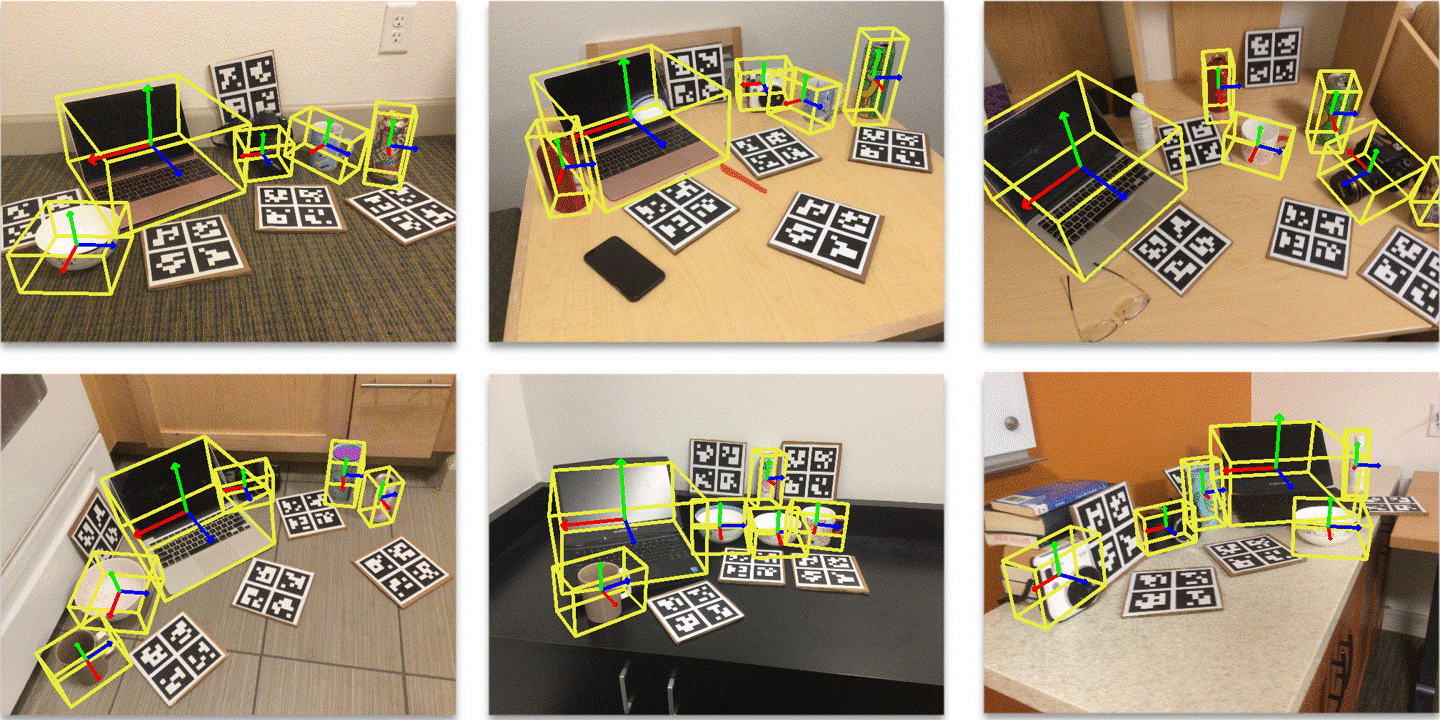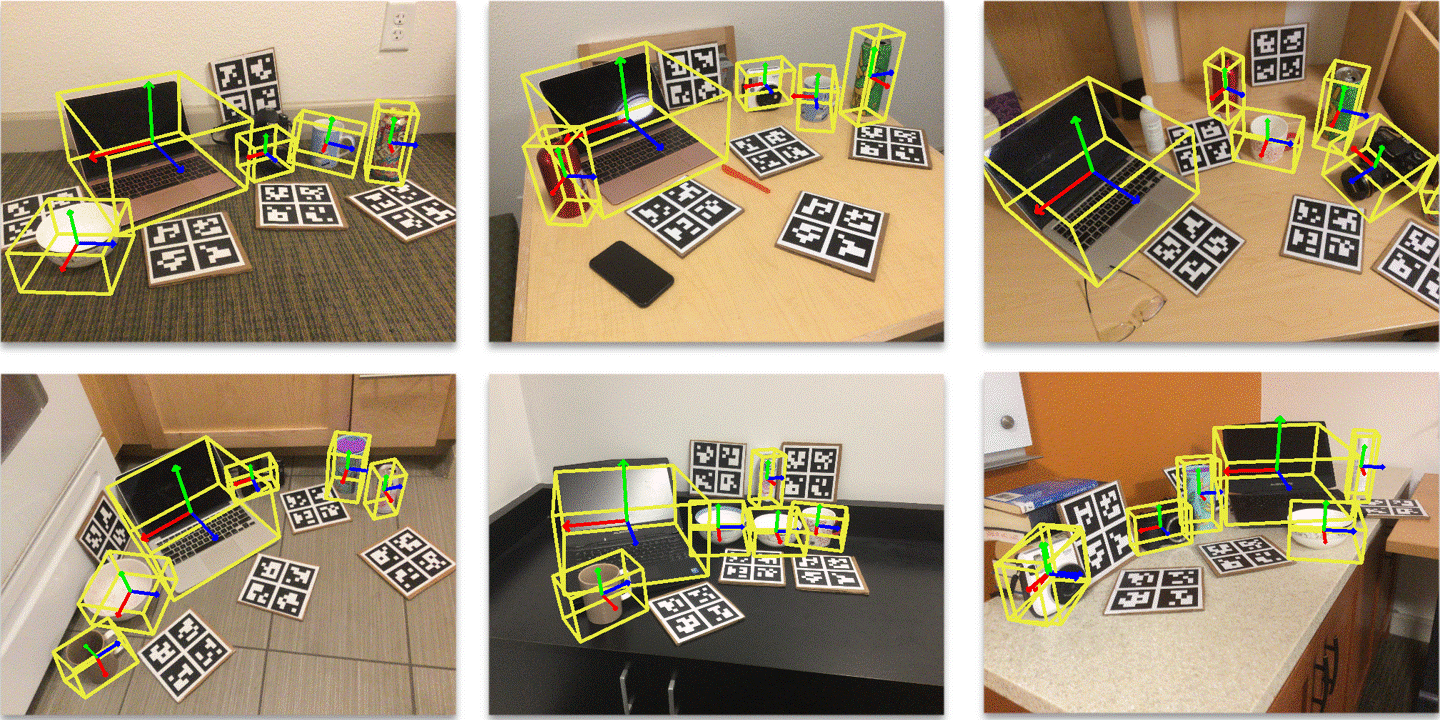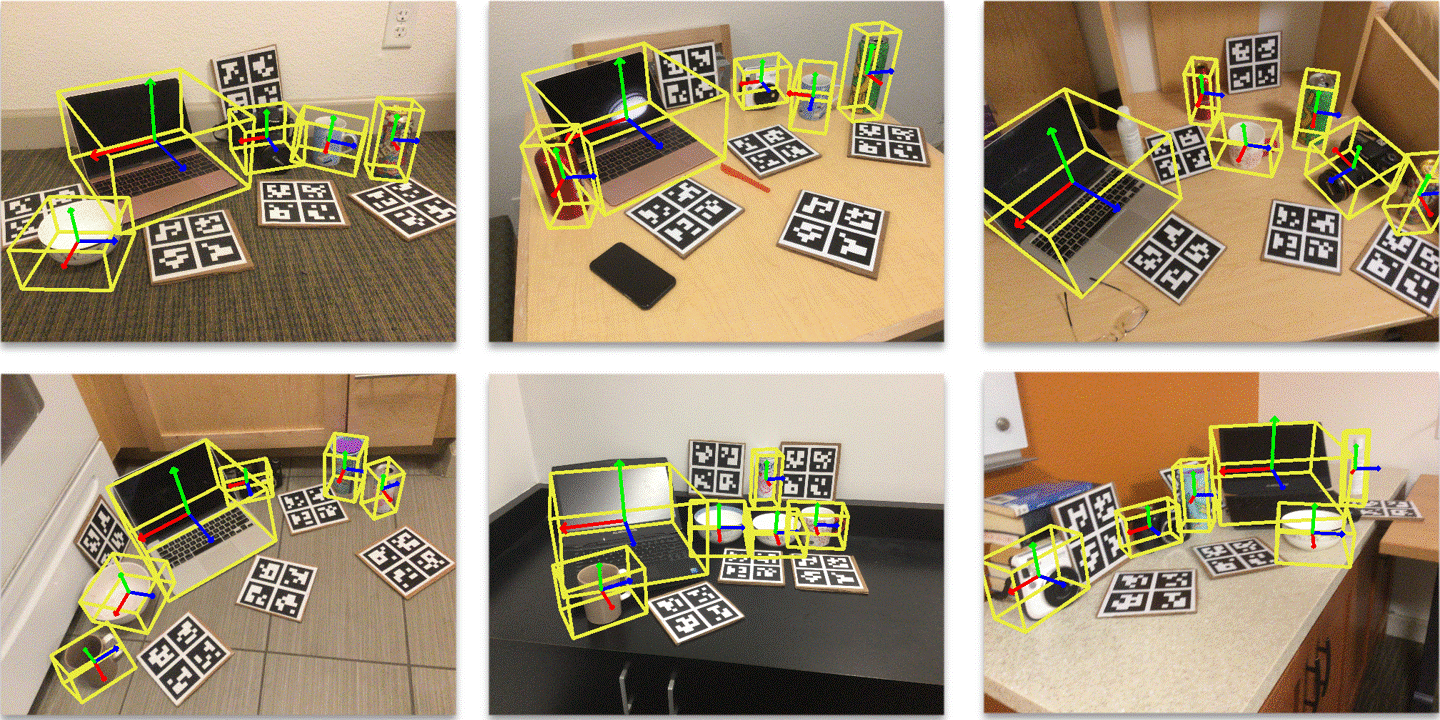
BundleTrack
[IROS 2021] BundleTrack: 6D Pose Tracking for Novel Objects without Instance or Category-Level 3D Models
- 688
- C++
- Apache-2.0
- 7 mo ago
A TensorRT and C++ based deployment of FoundationPose, which makes integration lightweight and efficient. Supports Jetson Orin. Adapted from nvidia_isaac_pose_esitimation.
Repo zz990099/foundationpose_cpp, read from GitHub 23 h ago. zz990099 has not joined Take My Repo.
zz990099/foundationpose_cpp is a public repo on GitHub by zz990099. A TensorRT and C++ based deployment of FoundationPose, which makes integration lightweight and efficient. Supports Jetson Orin. Adapted from nvidia_isaac_pose_esitimation. It declares the Apache-2.0 license on GitHub. It is written mainly in C++, has 135 stars and last changed on 2025-09-26. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-21.
This project is adapted from nvidia-issac-pose-estimation, with simplified dependencies. It enables inference using ONNX models exported from the Python implementation of FoundationPose, making deployment and application highly convenient.
Notes: This repository only contains the code for the FoundationPose component. The complete 6D pose estimation pipeline also relies on object masks, which can be generated by algorithms like SAM. For reference implementations and optimized inference of MobileSAM and NanoSAM, please visit EasyDeploy.
[2025.04] Decoupled Register and Track processes; Output poses under mesh coordinates, providing mesh_loader interfaces for external extension. Related PR.
[2025.03] Aligned rendering process with the original Python implementation, supporting rendering without texture input. Related PR.
[2025.03] Added support for Jetson Orin platform with one-click Docker environment setup. See link.
Removed complex environment setup and dependency issues from the original project, enabling easy integration with other projects.
Implemented encapsulation of the FoundationPose algorithm, supporting dynamic-sized image input for flexible usage.
Provided tutorial scripts for generating 3D object models using BundleSDF.
:fire: Supports Jetson Orin development boards (Orin-NX-16GB).
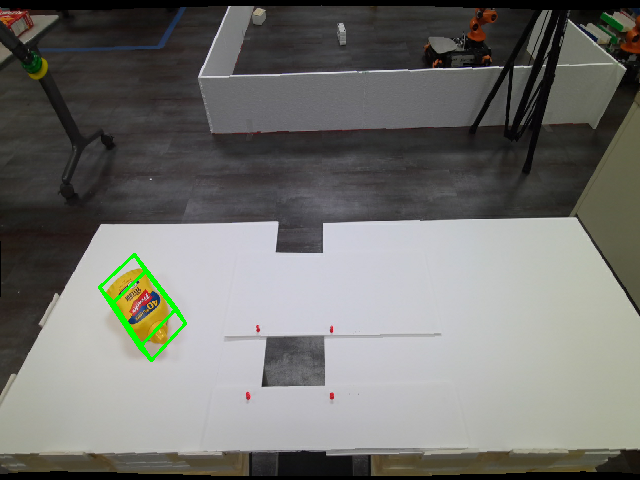
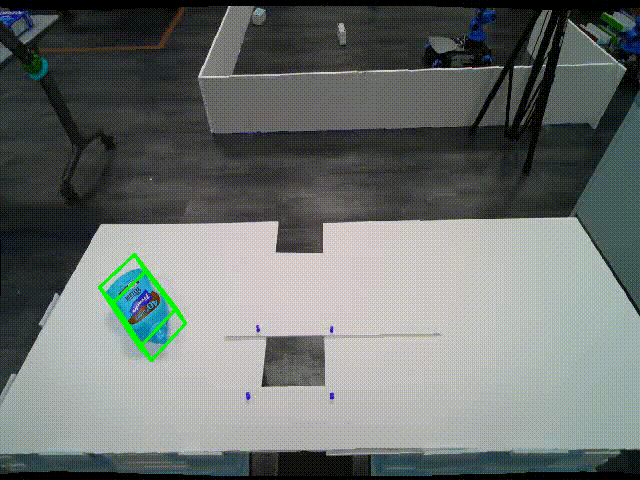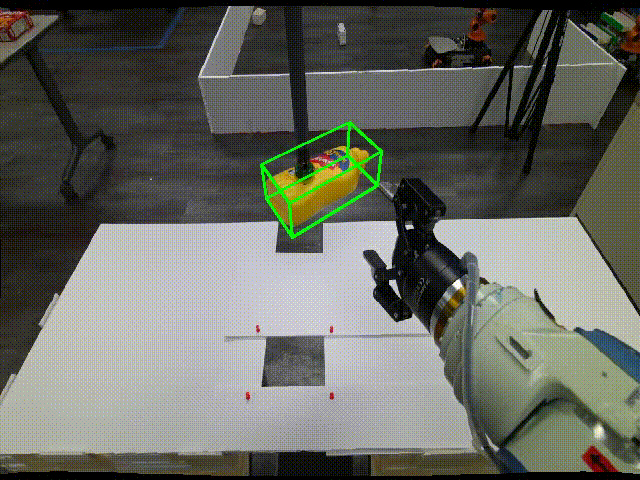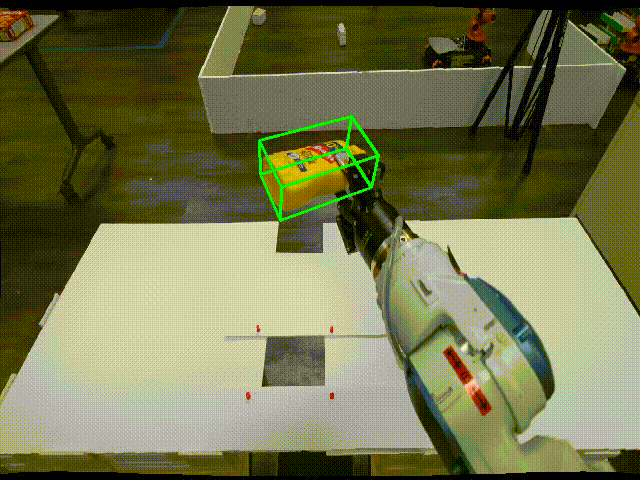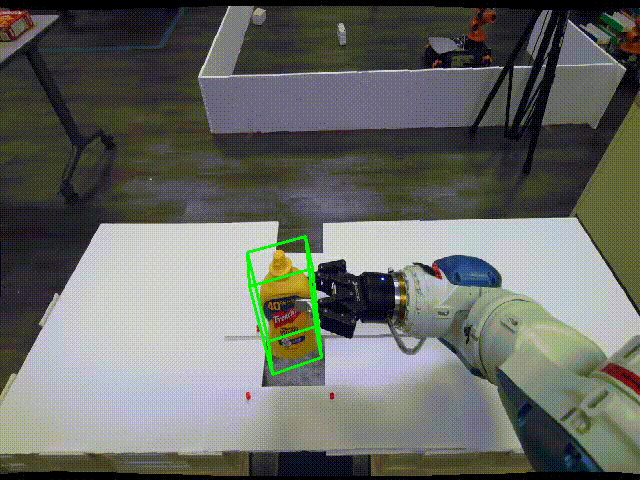
Test results on public mustard dataset:
 |
|---|
| foundationpose(fp16) Register test result |
 |
|---|
| foundationpose(fp16) Track test result |
Performance on nvidia-4060-8G and i5-12600kf:
| nvidia-4060-8G | fps | cpu | gpu |
|---|---|---|---|
| foundationpose(fp16)-Register | 2.8 | 100% | 6.5GB |
| foundationpose(fp16)-Track | 220 | 100% | 5.8GB |
Performance on jetson-orin-nx-16GB:
| jetson-orin-nx-16GB | fps | cpu | mem_total |
|---|---|---|---|
| foundationpose(fp16)-Register | 0.6 | 15% | 5.6GB(5.5GB on gpu) |
| foundationpose(fp16)-Track | 100 | 60% | 5.1GB(5.0GB on gpu) |
Clone the repository:
git clone git@github.com:zz990099/foundationpose_cpp.git
cd foundationpose_cpp
git submodule init
git submodule update
Build using Docker:
cd ${foundationpose_cpp}
bash easy_deploy_tool/docker/easy_deploy_startup.sh
# Select `jetson` -> `trt10_u2204`/`trt8_u2204` (`trt8_u2004` not supported)
bash easy_deploy_tool/docker/into_docker.sh
Download ONNX models from google drive and place them in /workspace/models/.
Convert models:
cd /workspace
bash tools/cvt_onnx2trt.bash
  cd /workspace
  mkdir build && cd build
  cmake -DENABLE_TENSORRT=ON ..
  make -j
Download and extract the dataset to /workspace/test_data/ from here.
Run tests:
cd /workspace/build
./bin/simple_tests --gtest_filter=foundationpose_test.test
Refer to Generating 3D Models with BundleSDF.
Modify paths in /workspace/simple_tests/src/test_foundationpose.cpp for your data and rebuild.
Run tests:
cd /workspace/build
./bin/simple_tests --gtest_filter=foundationpose_test.test
Results for Register and Track processes will be saved in /workspace/test_data/.
For any questions, feel free to raise a issue or contact 771647586@qq.com.
zz990099/foundationpose_cpp is a public repo on GitHub by zz990099. A TensorRT and C++ based deployment of FoundationPose, which makes integration lightweight and efficient. Supports Jetson Orin. Adapted from nvidia_isaac_pose_esitimation.
It declares the Apache-2.0 license on GitHub.
Its maker tagged it for macOS, Windows and Linux, or as Docker or cross-platform. That is declared by the maker; Take My Repo has not tested it.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Its last change on GitHub was on 2025-09-26. GitHub counts 7 open issues and pull requests. Take My Repo does not judge from that whether it is maintained.
[IROS 2021] BundleTrack: 6D Pose Tracking for Novel Objects without Instance or Category-Level 3D Models
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.
Reverse engineer anything with agents, from app behavior down to native binaries.
[IROS 2020] se(3)-TrackNet: Data-driven 6D Pose Tracking by Calibrating Image Residuals in Synthetic Domains
Pytorch code for ICRA'22 paper: "Single-Shot Multi-Object 3D Shape Reconstruction and Categorical 6D Pose and Size Estimation"
C++ implementations of YOLOv8/YOLO26, RT-DETR-V2(RTDETR), MobileSAM, and NanoSAM on TensorRT, ONNX Runtime, and RKNN.