ODYX-VISUAL-SLAM
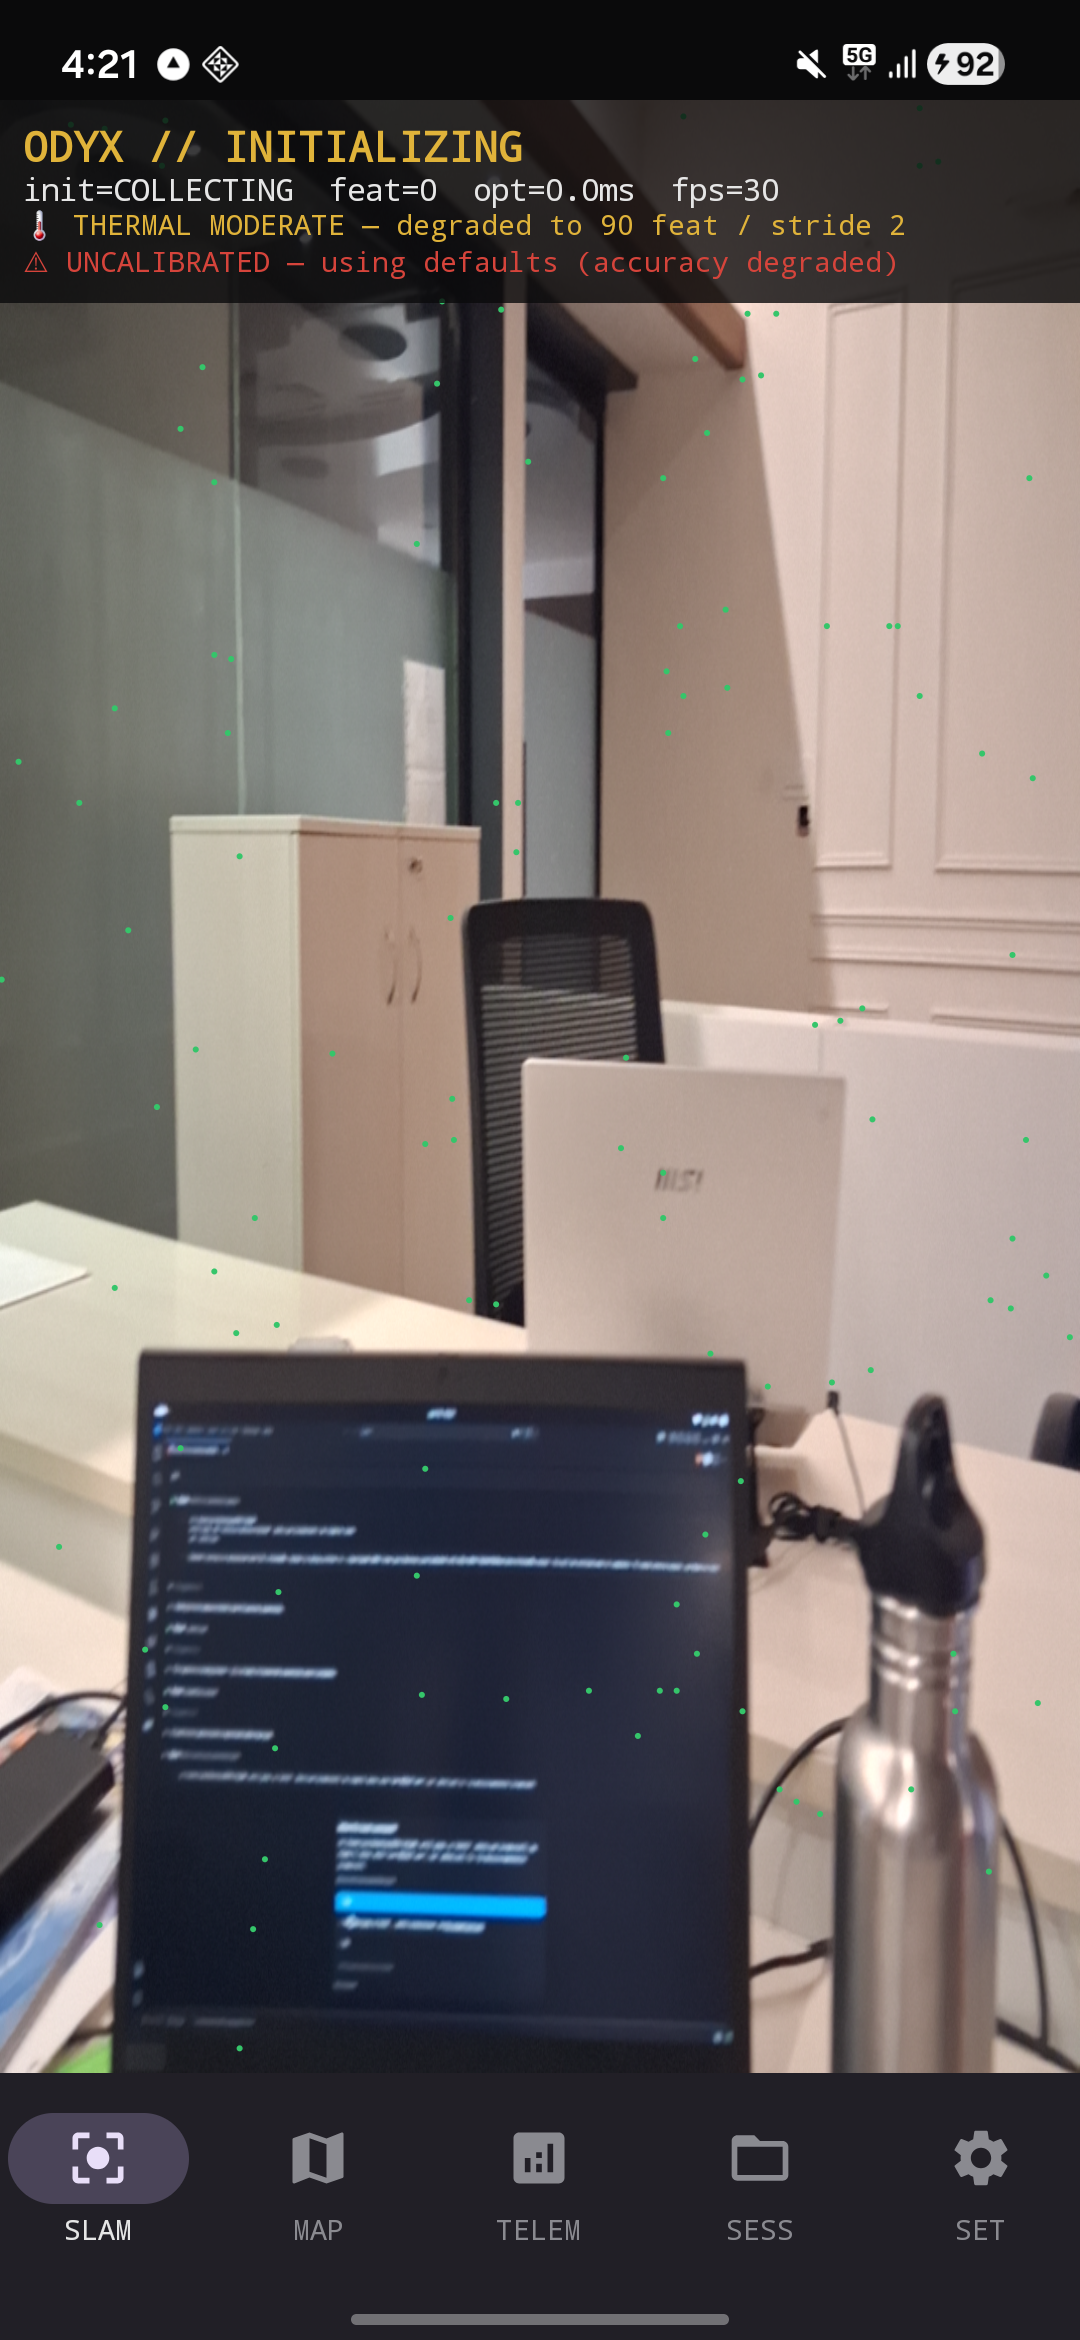
On-device visual-inertial SLAM with GNSS fusion for Android. A from-scratch GTSAM factor-graph VIO (camera + IMU + raw GNSS) that replaces ARCore for georeferenced 6-DoF pose.
- 6
- C++
- MIT
- 6 mo ago
On-device visual-inertial SLAM with GNSS fusion for Android. A from-scratch GTSAM factor-graph VIO (camera + IMU + raw GNSS) that replaces ARCore for georeferenced 6-DoF pose.
