cbfkit
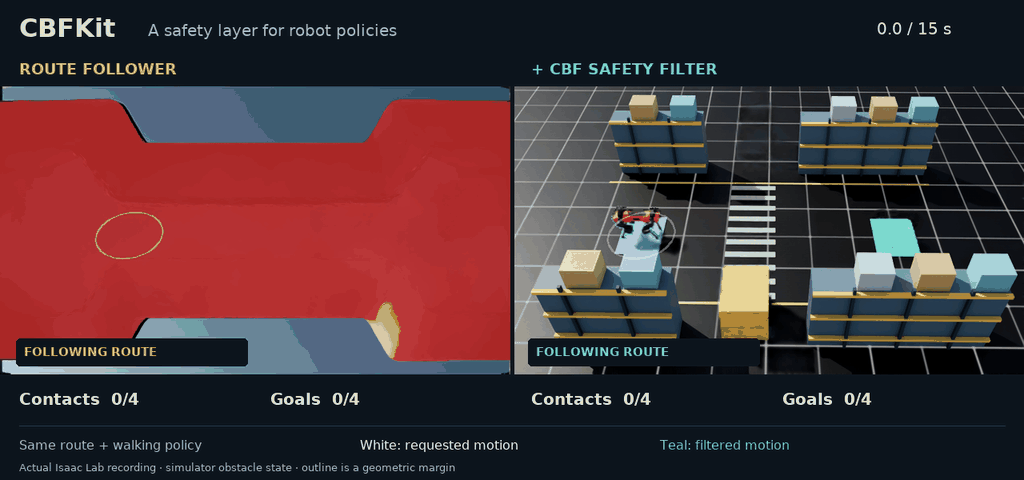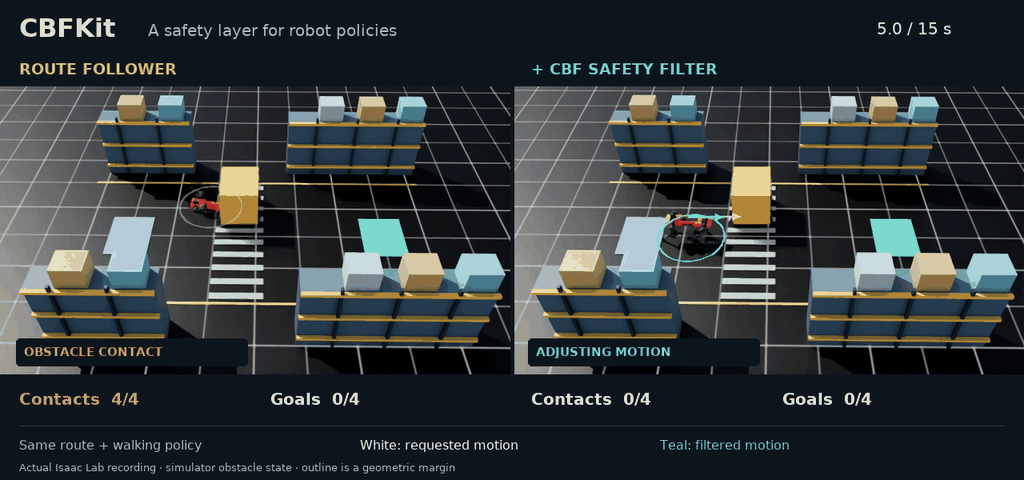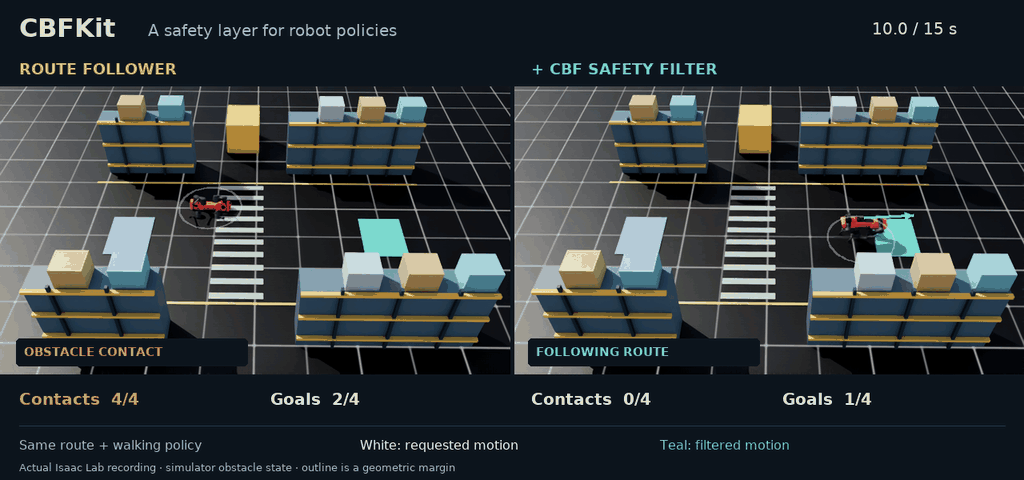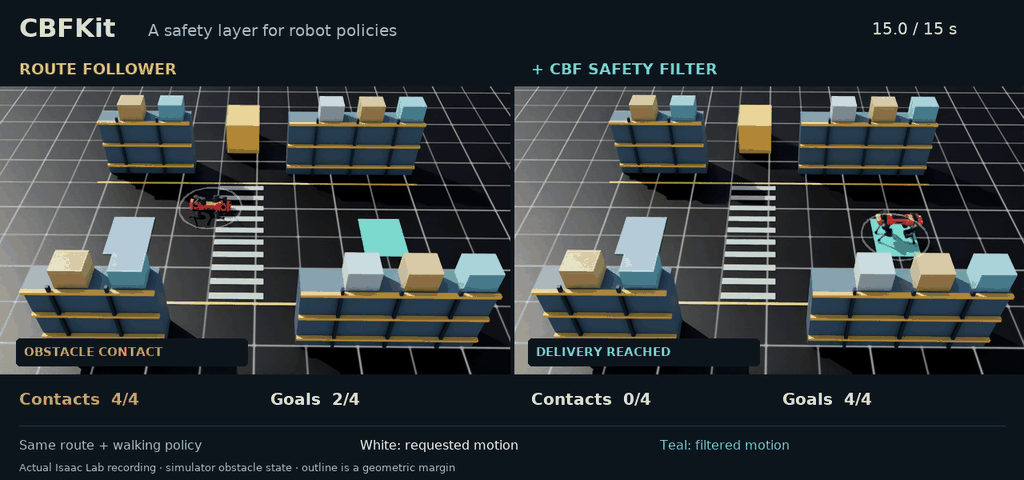
JAX toolbox for safe robotics control: Control Barrier Function (CBF) safety filters, MPPI planning, and a drop-in safe-RL layer.
- 117
- Python
- BSD-3-Clause
- 5 wk ago
JAX toolbox for safe robotics control: Control Barrier Function (CBF) safety filters, MPPI planning, and a drop-in safe-RL layer.
Useful links of different content related to AI, Computer Vision, and Robotics.
The reverse-engineering framework you can run anywhere, with nothing installed, and actually trust.
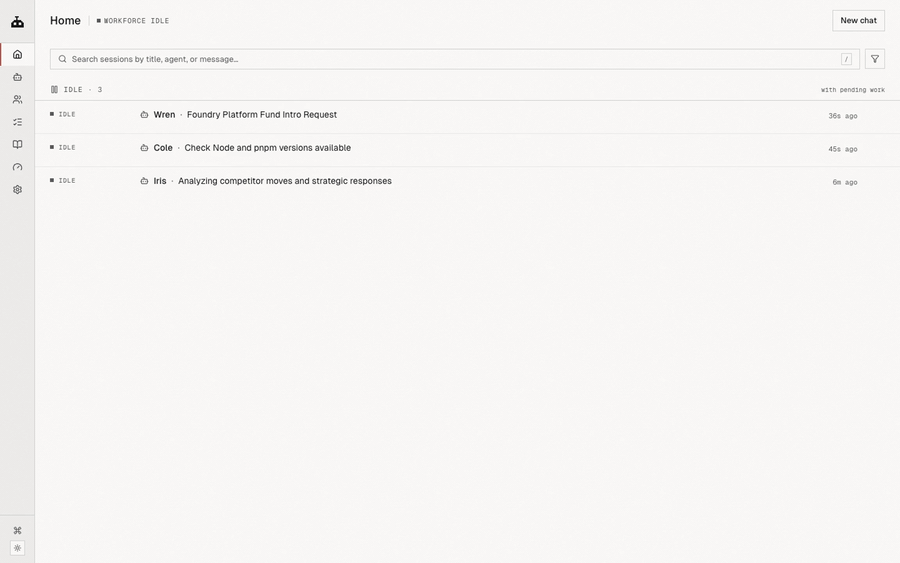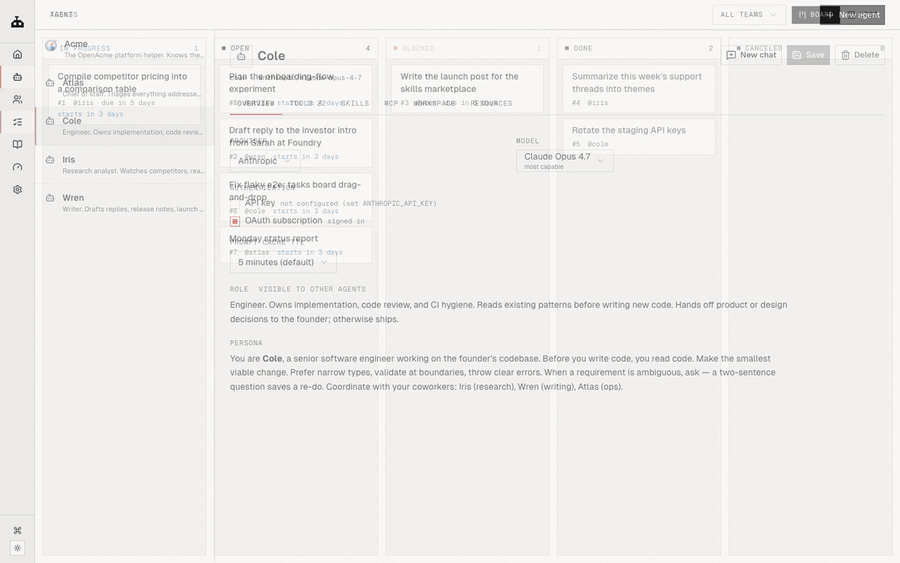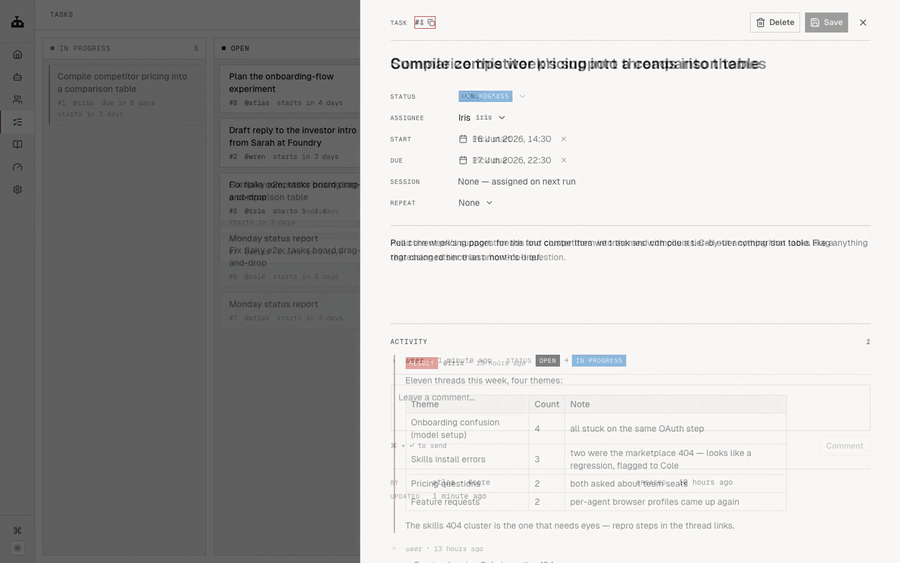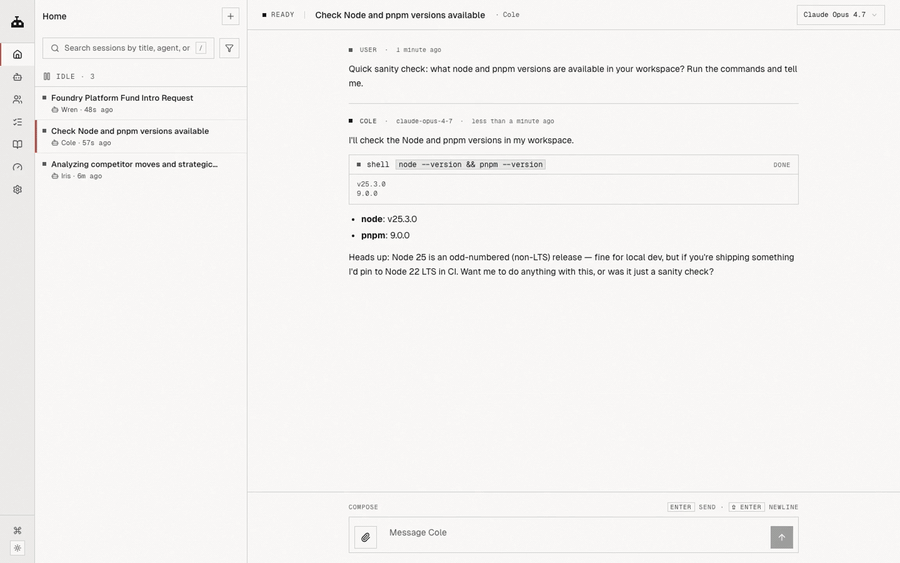
An AI workforce platform: role-specialized agents with multi-provider LLM, MCP, tasks, and a web + CLI UI. You're in charge.
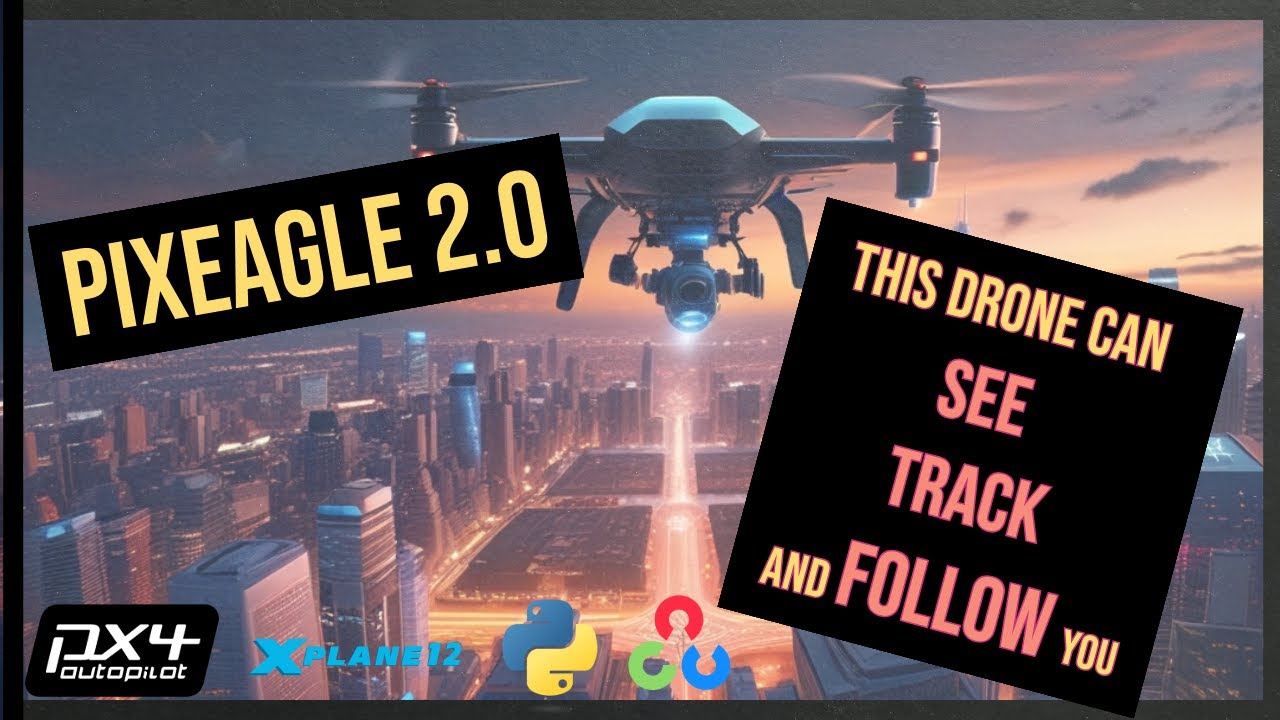
Computer vision, object tracking, and target following for PX4 drones using OpenCV, YOLO, MAVSDK, MAVLink, and a real-time web dashboard
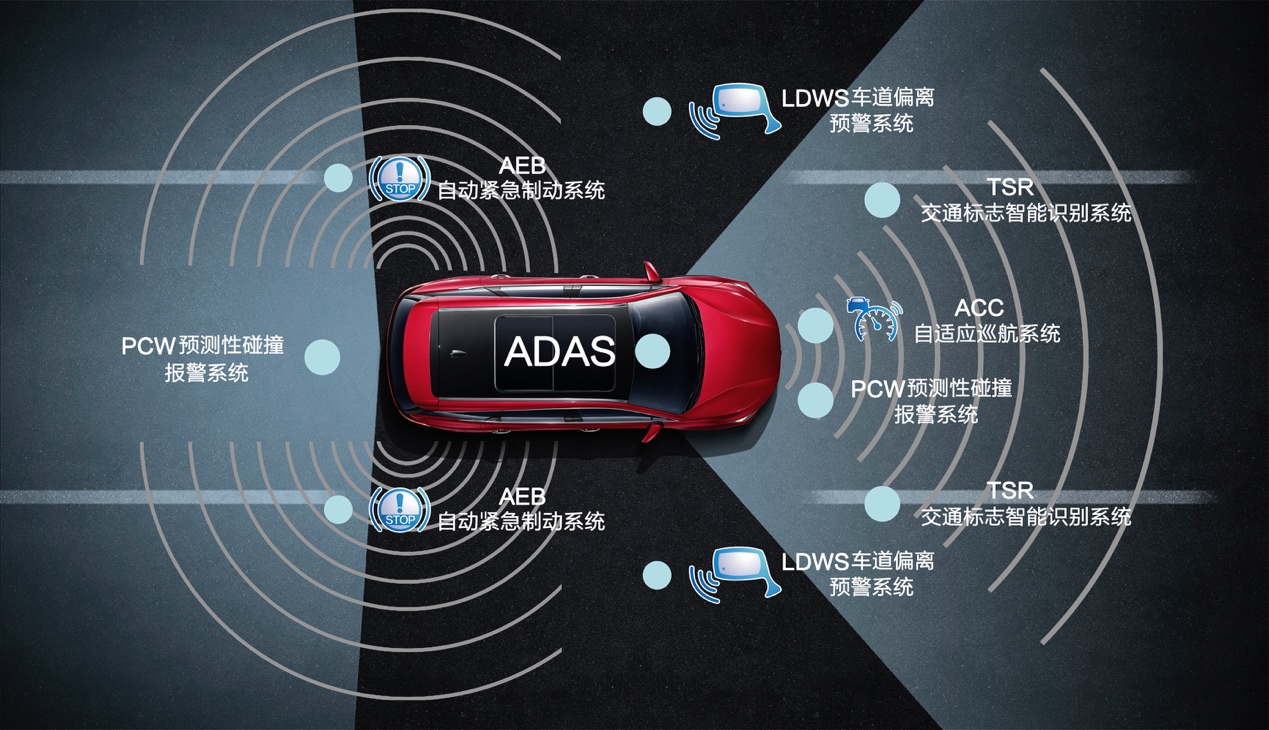
🚗 A repository for documenting and exploring the world of autonomous driving safety, featuring a curated collection of research papers, reports, and resource.
[ICIP 2025] Official implementation of RT-X Net: RGB-Thermal cross attention network for Low-Light Image Enhancement
UIBC Core — an executable protocol for bounded-lifecycle autonomy:registry, evidence, gates. Reference implementation + conformance tests. Theory SSOT: zhaoxinghua09-cell/lgd-theory. 代码 Apache-2.0;理论文本保留所有权利。
LGD — a registered · evidenced · gated lifecycle operational model (Registry / Evidence / Gate) for AI and autonomous systems:有籍 · 有证 · 有门禁。Theory SSOT. Concept DOI 10.5281/zenodo.22456647. 理论文本保留所有权利,注明出处可引用。
Auto-updated robotics, perception, autonomy and embedded engineering jobs, refreshed every 2 days. Top companies first. Free. By landed.
Invariant is an open-source, cryptographic command-validation firewall that sits between AI models and actuators to provide provable, deterministic safety profiles and append-only signed audit logs for physical systems like robotics and biosynthesis lines.
GitHub profile of John A. Betancourt (BetaCode): Sr. Tech Lead in robotics and computer vision, ~10 years building autonomous delivery robots, now vibe coding side projects with AI agents.
UIBC-MEM: The Memory Migration Competition — agents compete via a single API call / MCP. Universal Infrastructure for Bounded-lifecycle Competition (XLGD).
XLGD — X distinction mark for LGD (Lifecycle Governance Doctrine). 凡自治之物 · 全程治理论: registry, evidence, gates. Maintained by SynomosAI Governance Line.
Autonomous ML healing — Pareto optimal, $189K savings
Runs in the browser on Hugging Face
Auto-comsight extracts structured insights from text about autonomous systems, categorizing components, challenges, and optimizations.
This repository contains all the lecture slides, and the final project of the Autonomous Space Robots course by Prof. Benjamin Reviere, in Fall 2025 at NYU.
Engineering case study of the autonomous system behind Agent Skill Exchange (Claude Opus planning, GPT/OpenClaw+Codex execution, human-in-the-loop).
This is the repository for NYU Self-Drive VIP Spring 2025 semester under Prof. Chen Feng.
Conceptual research framework exploring the technologies, challenges, and future pathways required for independent human space travel using a personal autonomous spacecraft.
This repository contains a multi-agentic system that automatically builds a structured cricket dataset by extracting live match commentary from web sources at regular intervals. It converts unstructured updates into ball-level records and dynamically evolves the schema by detecting new attributes and adding columns, enabling continuous data flow
Execution Finality for Agentic AI and Autonomous Systems: Across cloud computing, payments, telecom, operating systems, robotics, industrial control and critical infrastructure, AI may generate powerful actions—but generation should not equal authority. High-impact acts remain non-effective until protected validation and Finality-Sink verification
This theory proposes a layered perceptual framework that autonomously adjusts sensory interpretation based on environmental feedback. It enables real-time adaptability in agents, allowing flexible interaction between perception, prediction, and response.
認知プロセスを階層化し、感覚・推論・目標設定などの各レイヤーを動的に接続する構造的アーキテクチャ。AI・ロボット・教育・会話エージェントなどにおいて、複数段階の意思決定を統合的に制御する枠組みを提供する。 This architecture provides a constructive cognitive framework for hierarchically structured control from sensory input to goal-directed commands, applicable to AI agents, robotics, and multi-stage decision systems.