jaxrl
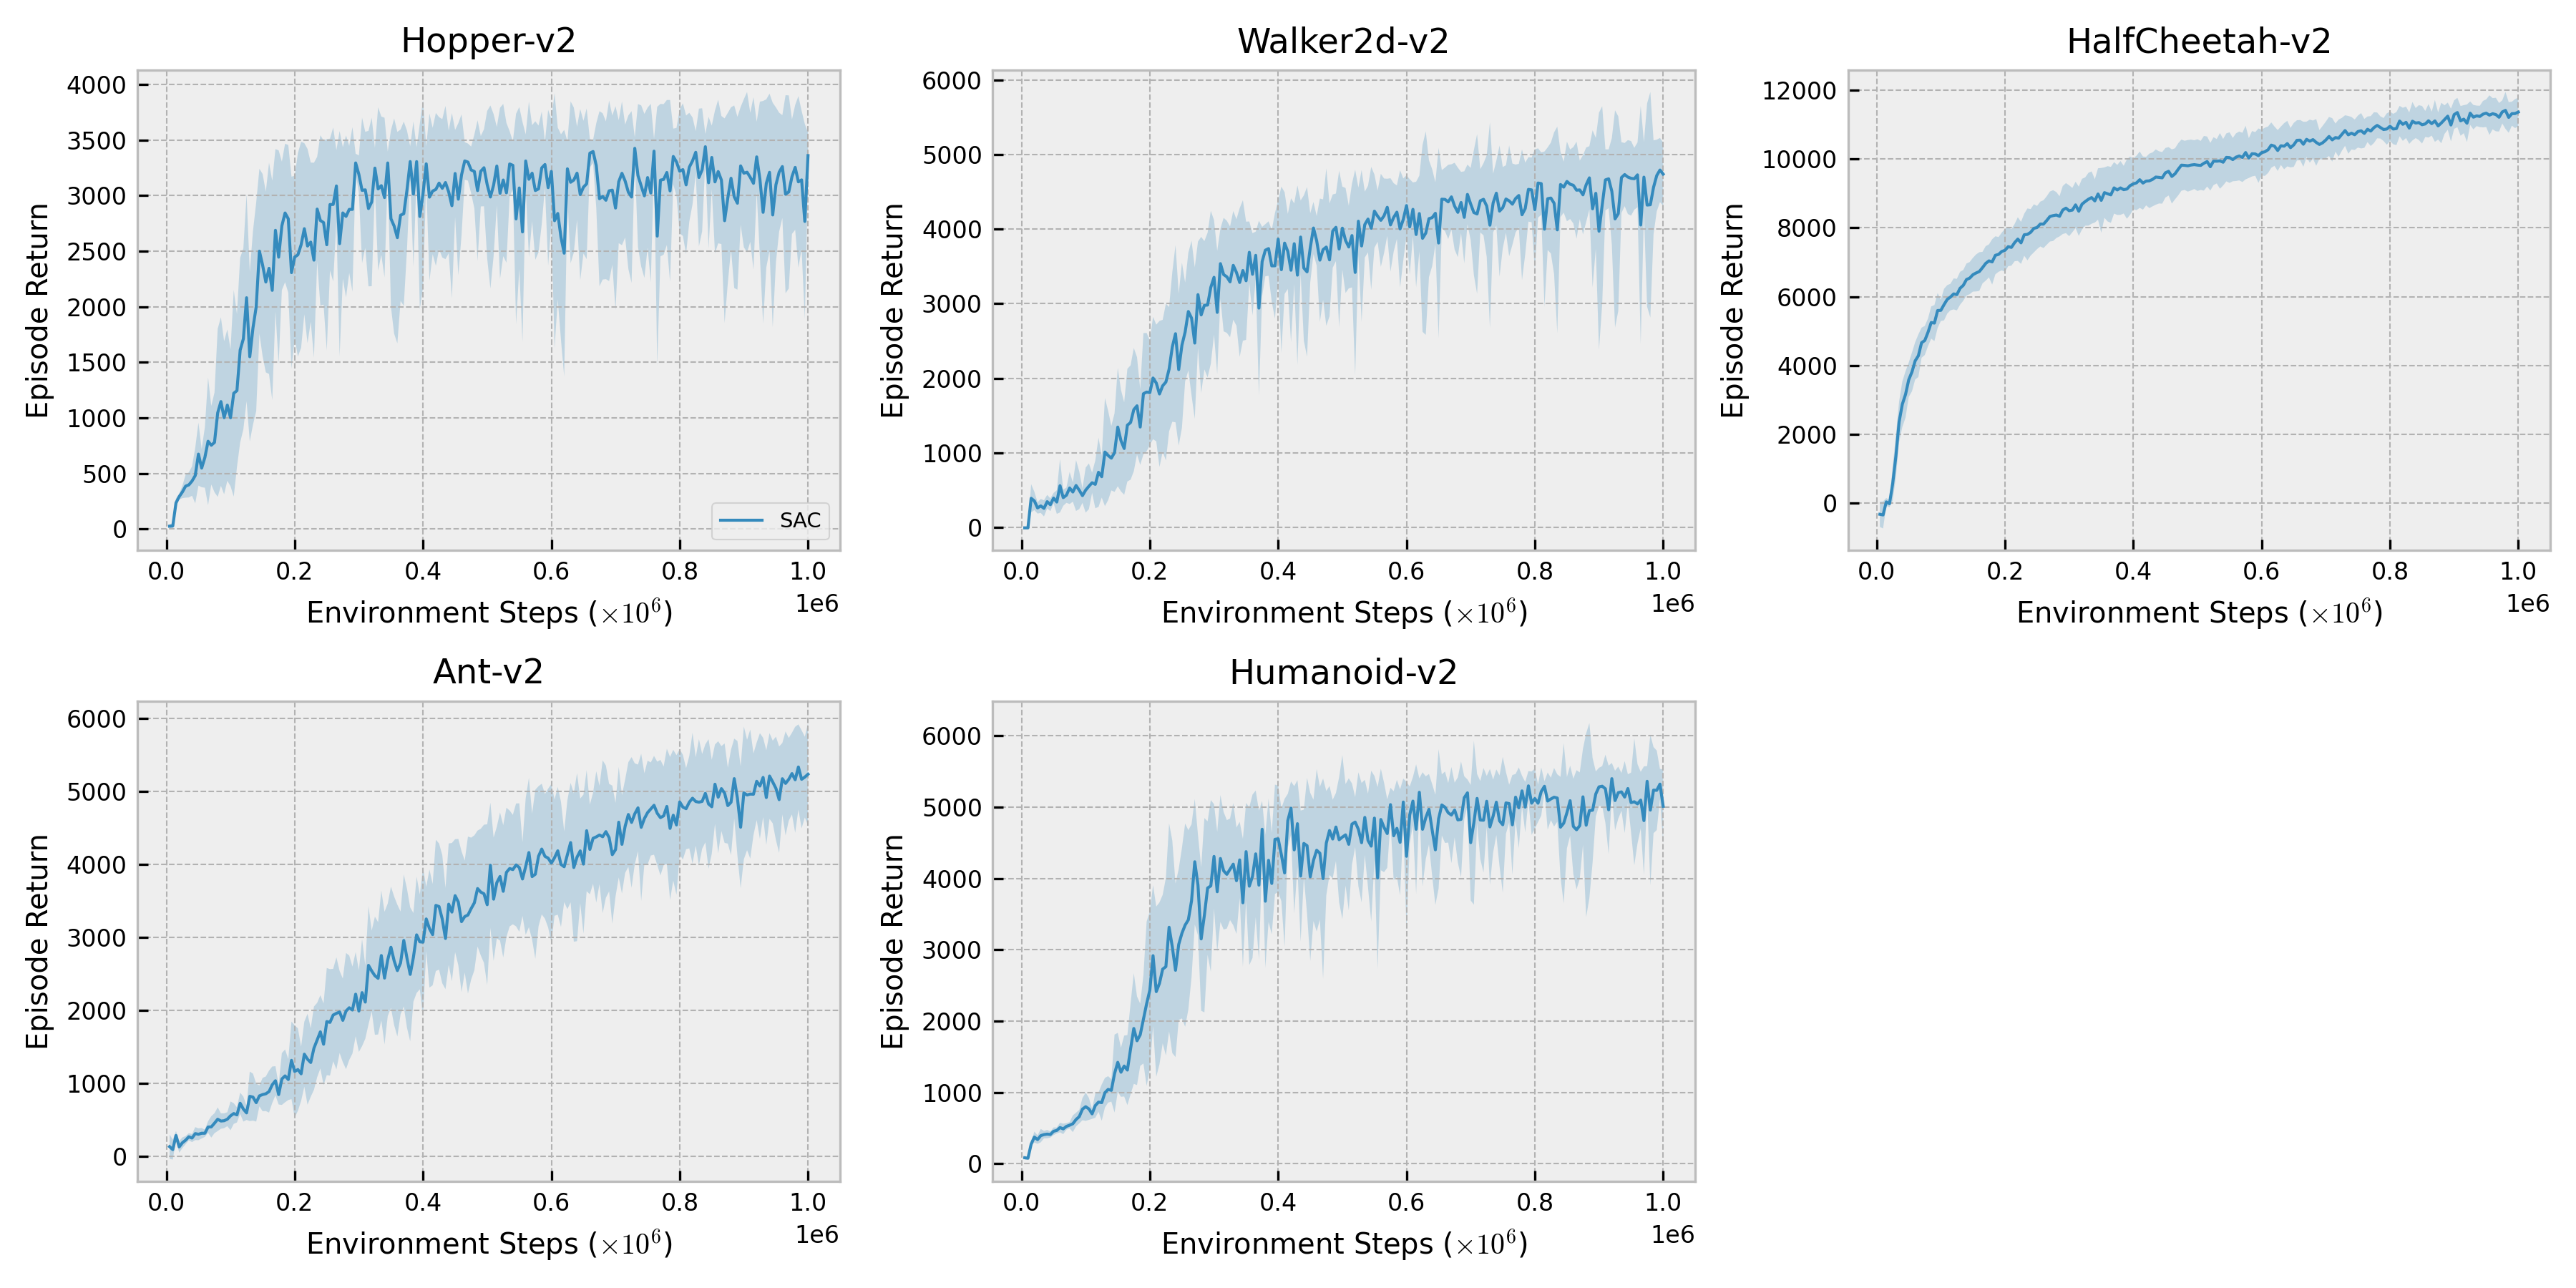
JAX (Flax) implementation of algorithms for Deep Reinforcement Learning with continuous action spaces.
- 760
- Jupyter Notebook
- MIT
- 4 y ago
JAX (Flax) implementation of algorithms for Deep Reinforcement Learning with continuous action spaces.
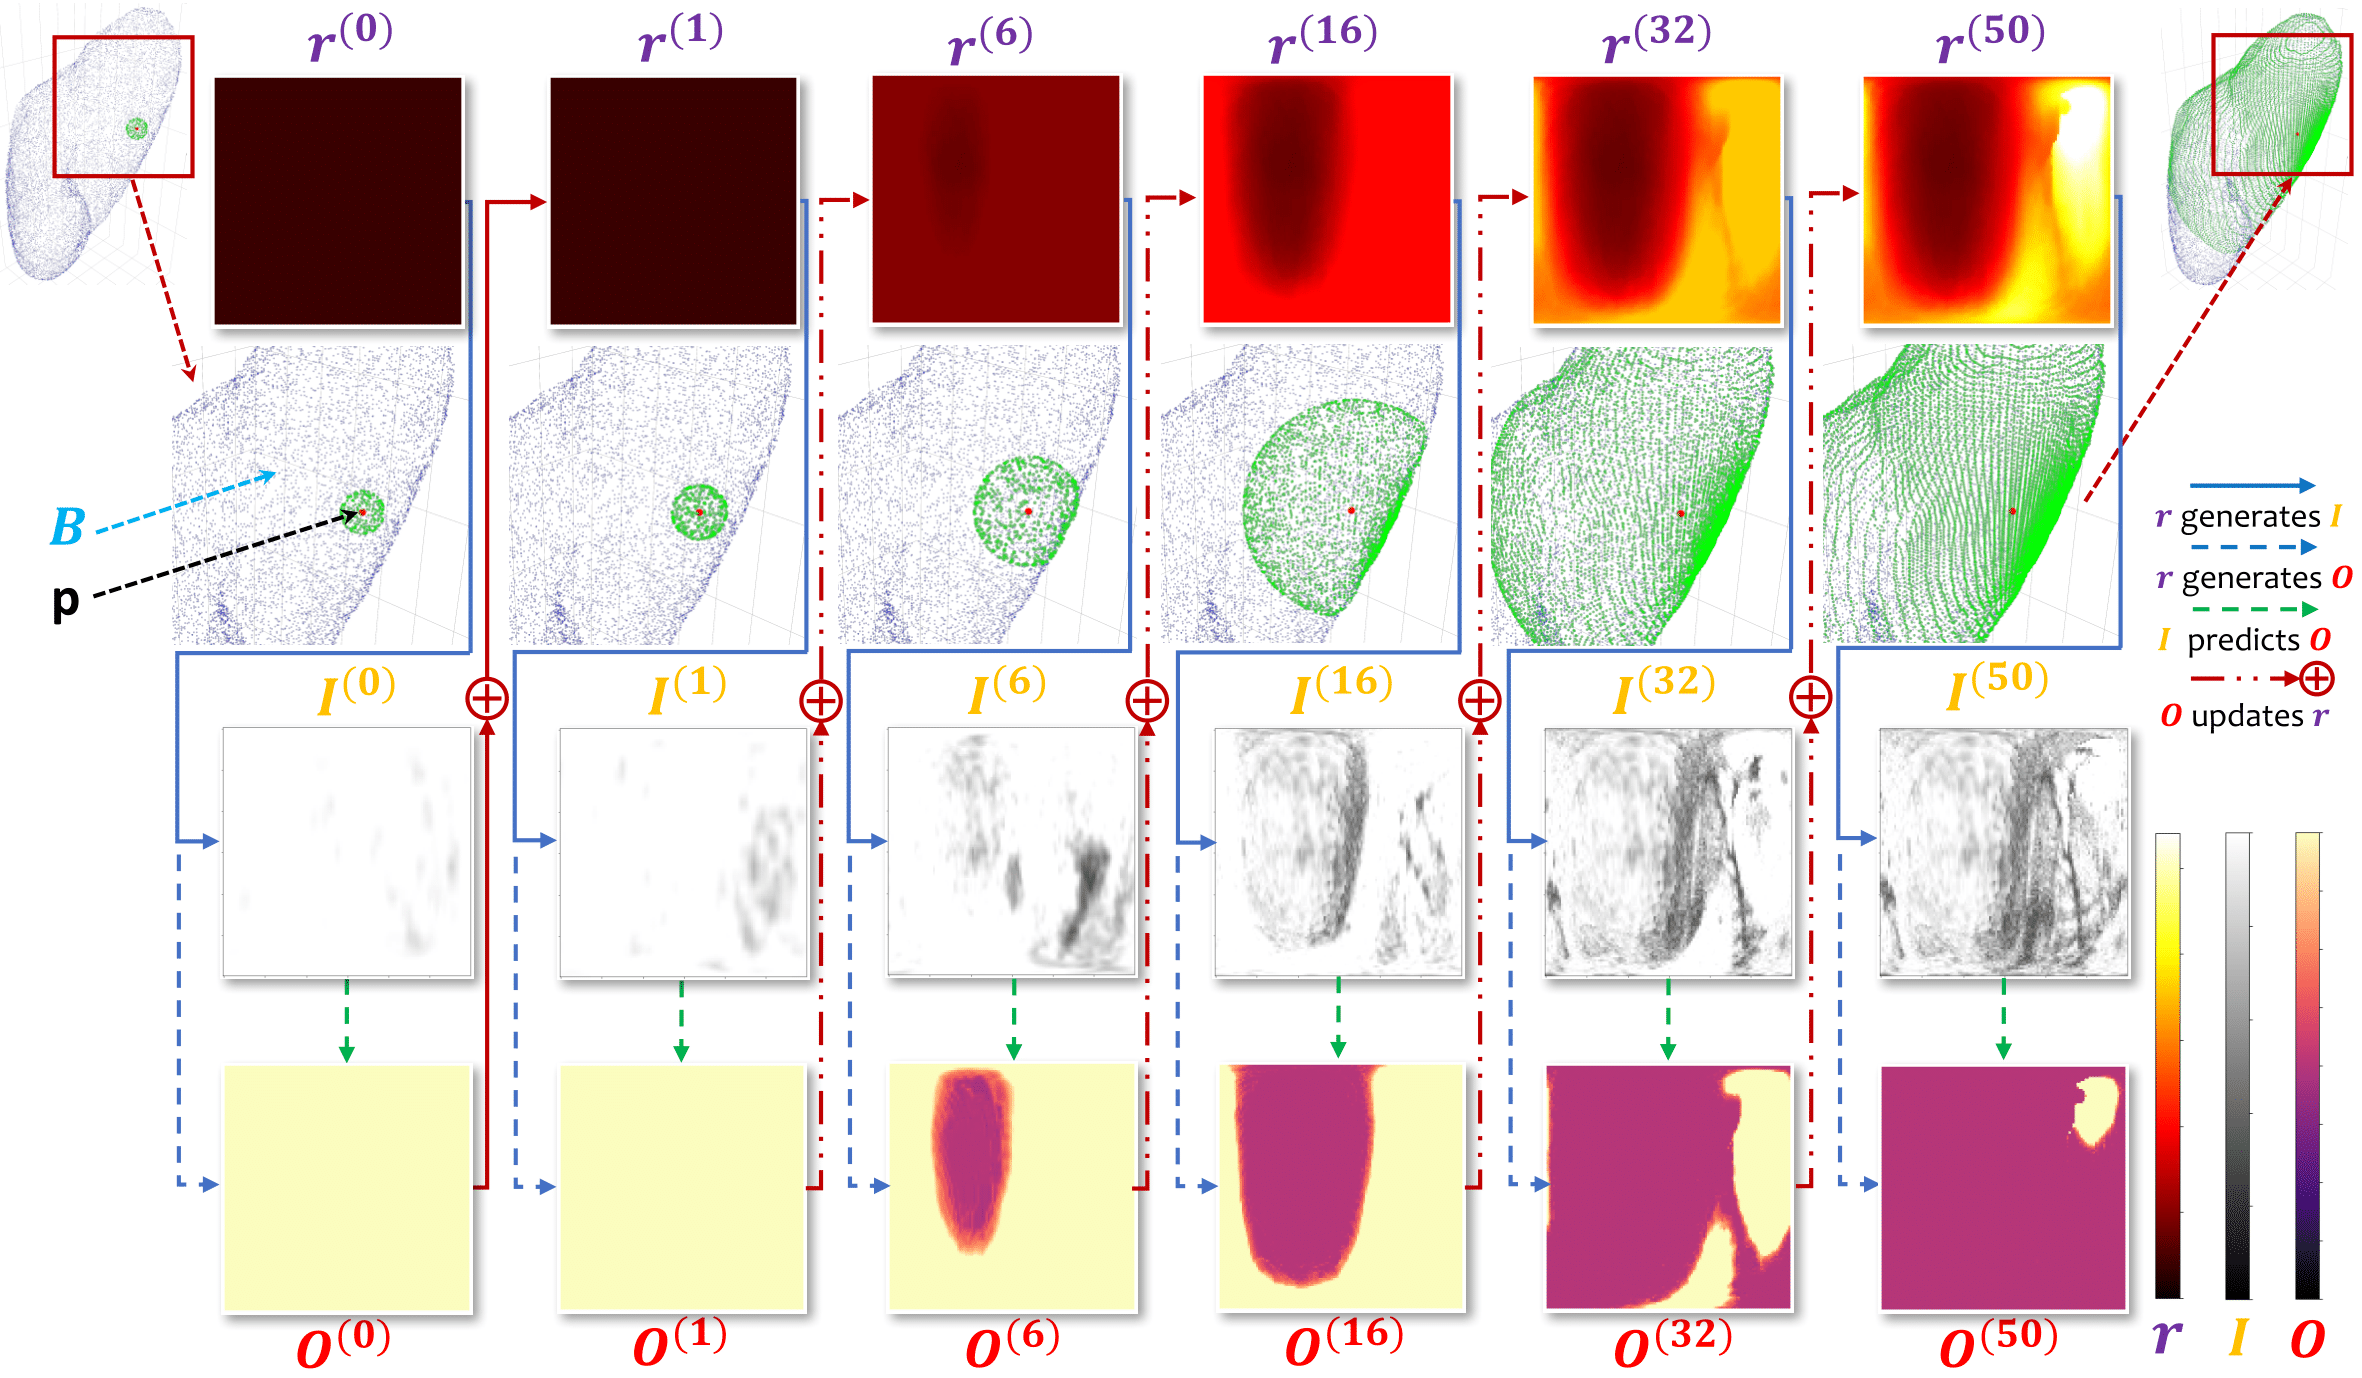
Elastic Boundary Projection for 3D Medical Image Segmentation - CVPR 2019
Deep Learning based pipeline for alignment of a robot with stairs
Udacity Self Driving Car ND projects - including lane detection, Traffic sign classifier, behaviour cloning
Construction of controllers for Shadow-Hand in Mujoco environment, using Deep Learning. 2 Different methods were used to create the controllers: a) Behavioral Cloning b) Deep Reinforcement Learning
Behavioral Cloning Project for Self-Driving Car Nano Degree Term 1. The project includes designing a neural network and then training the car on the road in unity simulator. The CNN learns and clones the driving behavior.
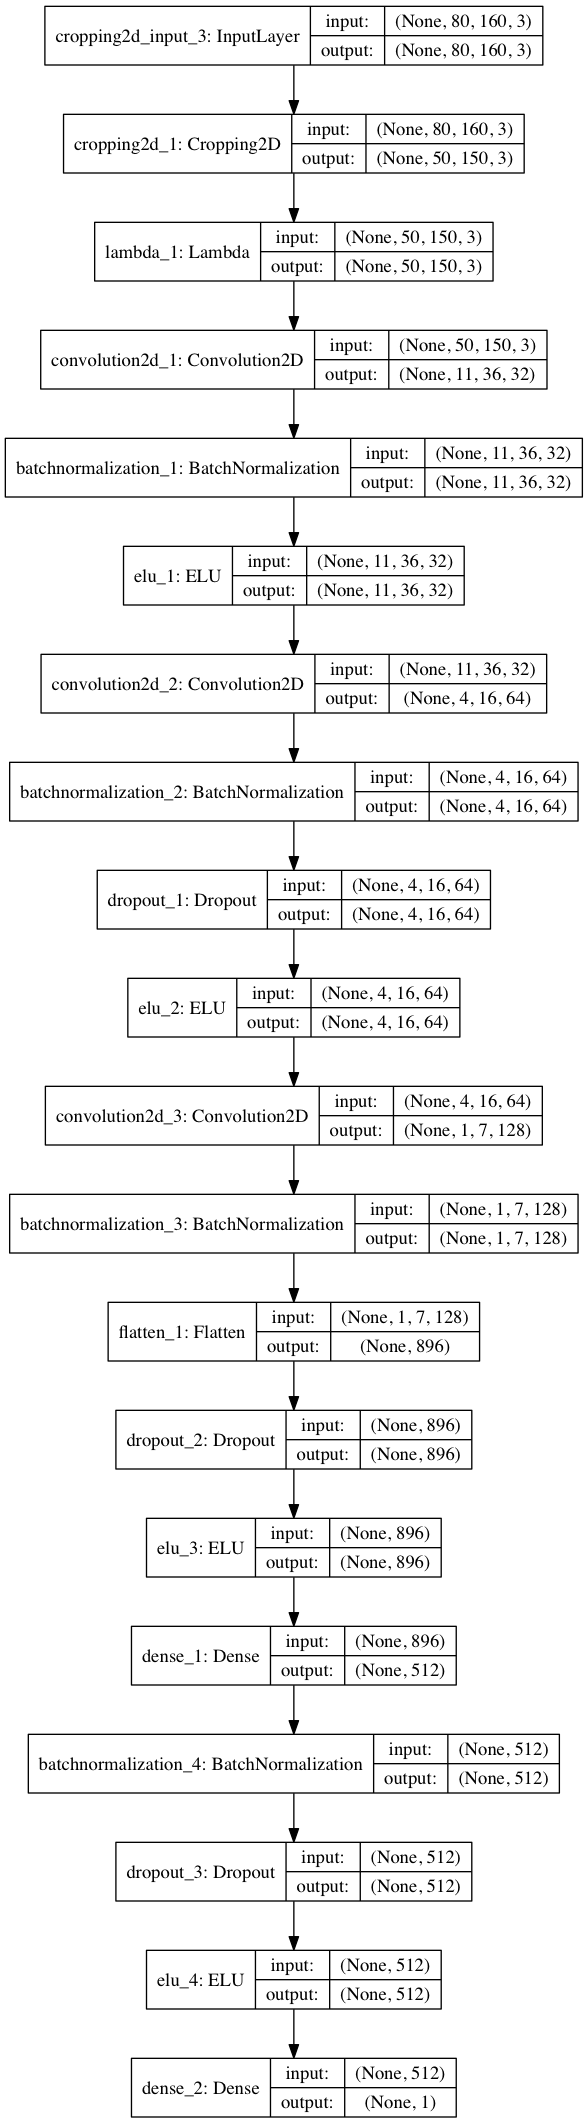
A CNN built with Keras and trained to predict steering angles from camera input
Code from "How useful is quantilization for mitigating specification-gaming?"
A modern PyTorch reimplementation of MAVNet, fixing the architectural and methodological issues in the original 2018 imitation-learning navigation paper, validated end-to-end on a public driving dataset. No drone/UAV hardware claims.
Deep Learning, Computer Vision and Machine Learning techniques for Autonomous Car.
Repository for Behavioral Cloning Project of Udacity Self Driving Car Engineer Nanodegree on Track 2
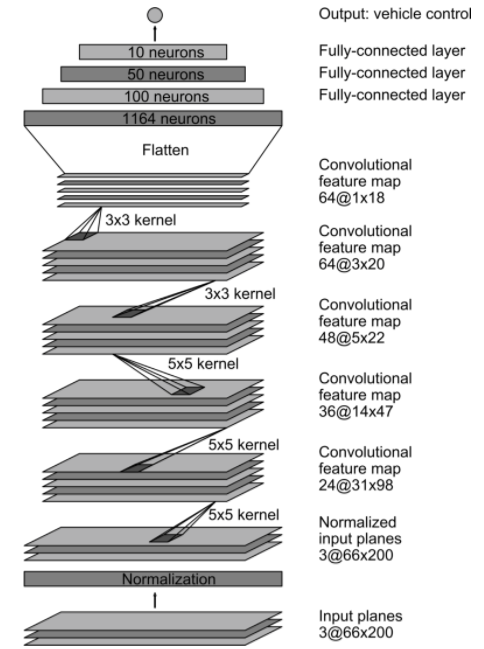
Teach a convolutional neural network (NVIDIA architecture) how to drive using the Udacity self-driving car simulator
I have used deep convolutional neural networks to clone driving behavior of humans... I have implemented end-to-end learning model for self-driving cars that mimics human driving behavior
🏎️ Behavioral Cloning Project using NN with Keras for the Self-Driving Car Nanodegree at Udacity