RTM3D
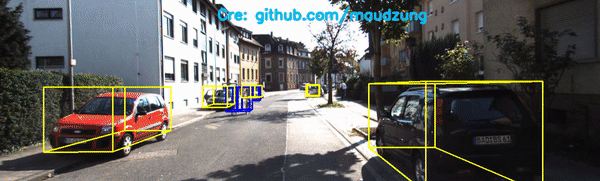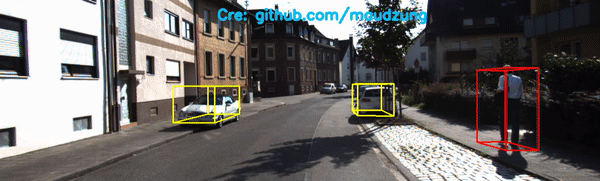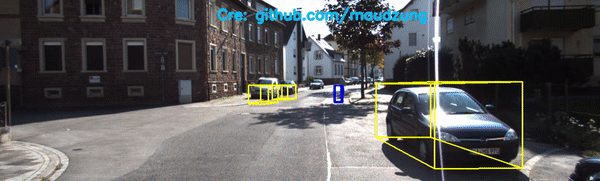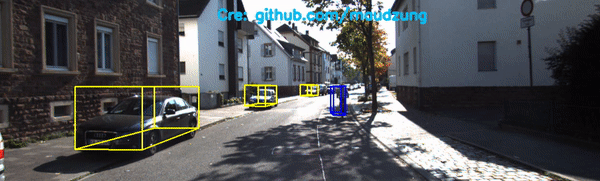
Unofficial PyTorch implementation of "RTM3D: Real-time Monocular 3D Detection from Object Keypoints for Autonomous Driving" (ECCV 2020)
- 300
- Python
- MIT
- 6 y ago
Unofficial PyTorch implementation of "RTM3D: Real-time Monocular 3D Detection from Object Keypoints for Autonomous Driving" (ECCV 2020)
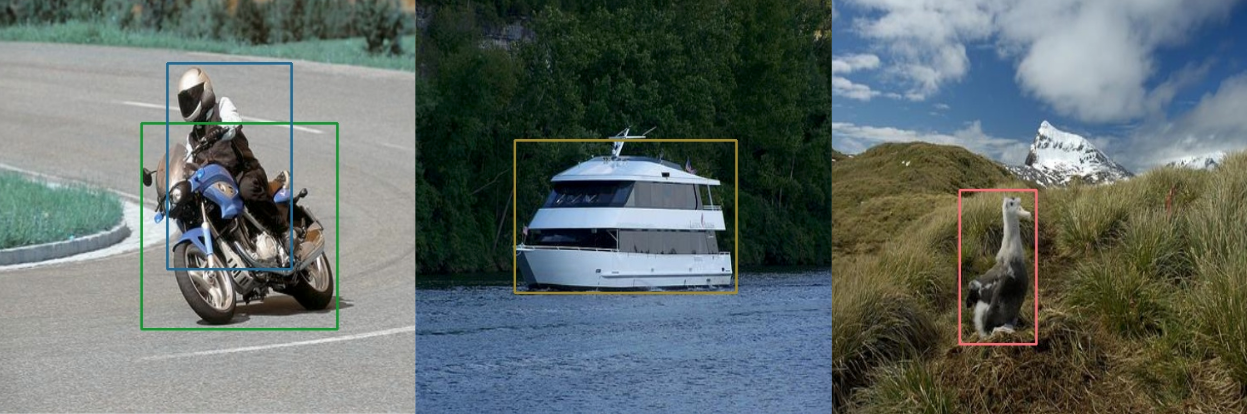
Fast anchor free Object Detection based on CenterNet (Objects As Points) and TTFNet (Training-Time-Friendly Network). Implemented in TensorFlow 2.4+.
A High Level Python Library to empower students, developers to build applications and systems enabled with computer vision capabilities.
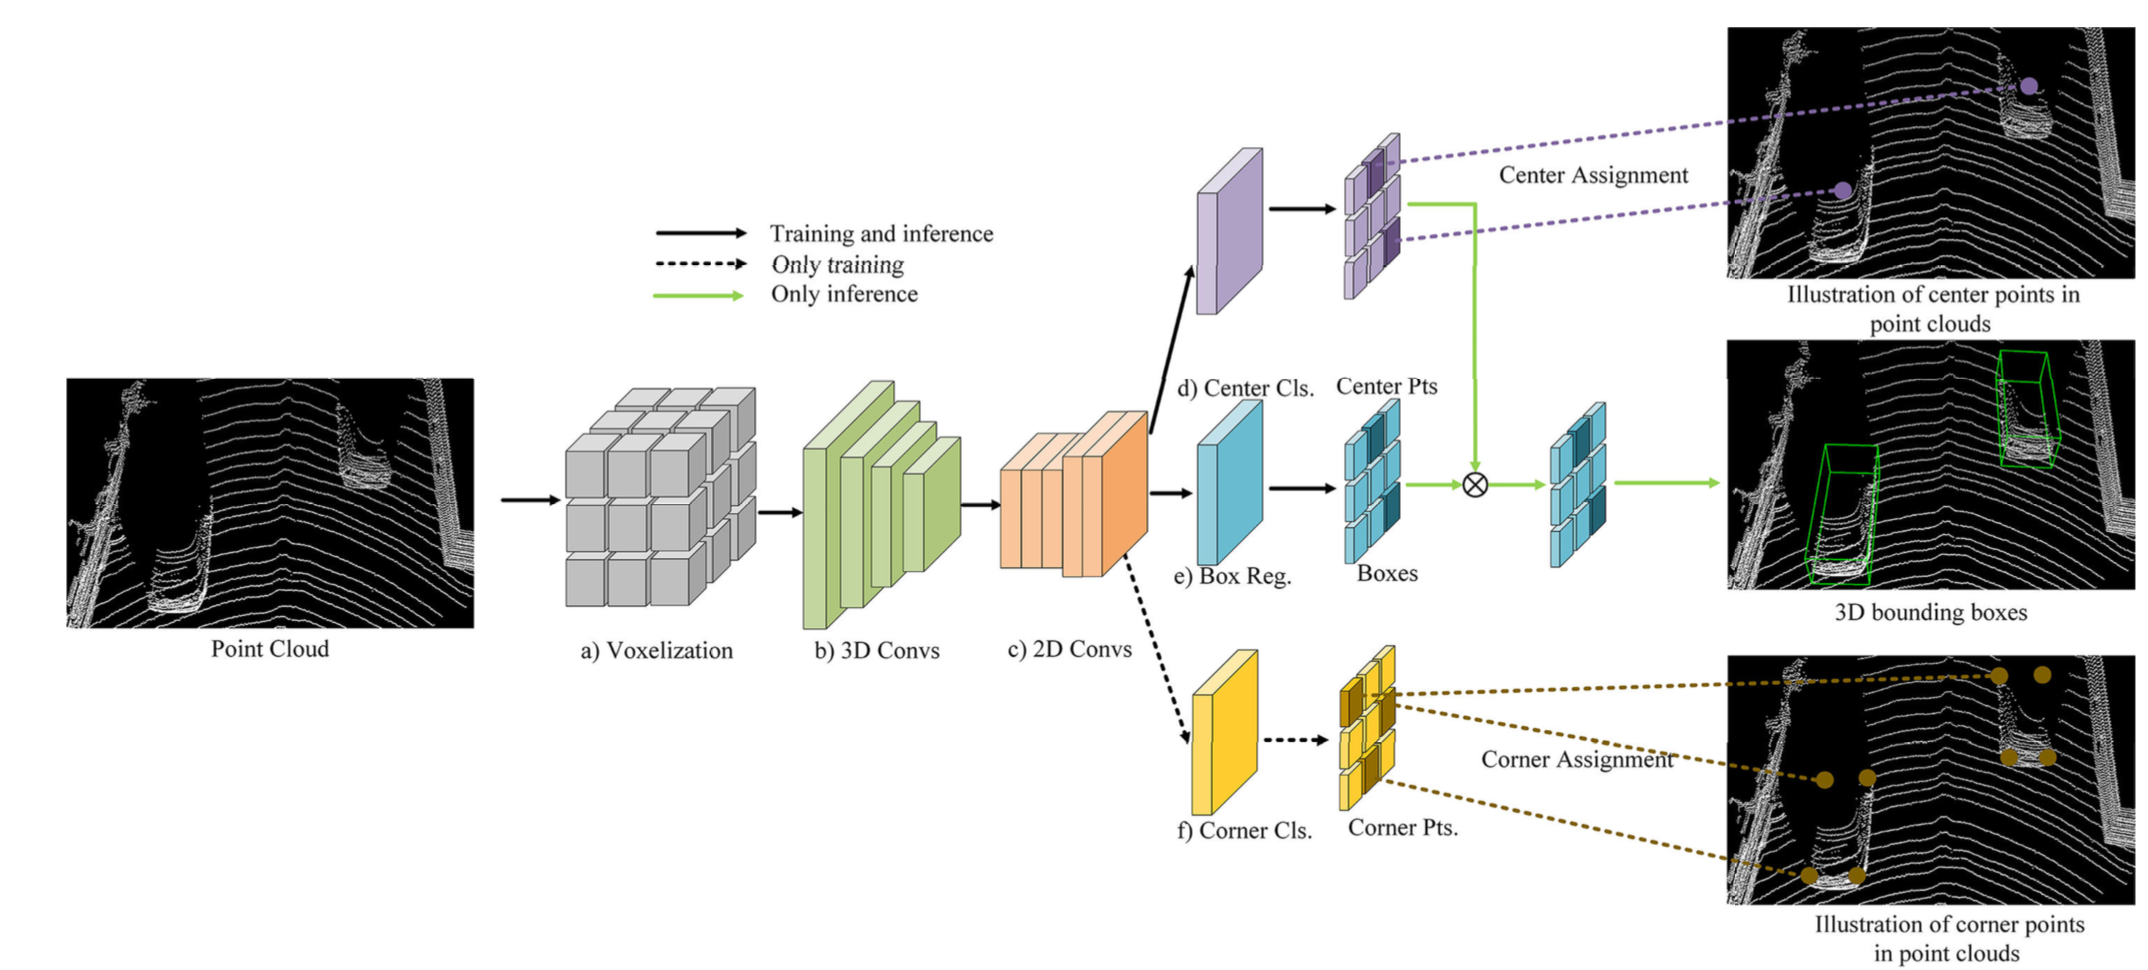
Unofficial PyTorch implementation of the paper: "CenterNet3D: An Anchor free Object Detector for Autonomous Driving"
Centroid-UNet is deep neural network model to detect centroids from satellite images.
Kuzushiji Recognition Kaggle 2019. Build a DL model to transcribe ancient Kuzushiji into contemporary Japanese characters. Opening the door to a thousand years of Japanese culture.
[FPGA'21] CoDeNet is an efficient object detection model on PyTorch, with SOTA performance on VOC and COCO based on CenterNet and Co-Designed deformable convolution.
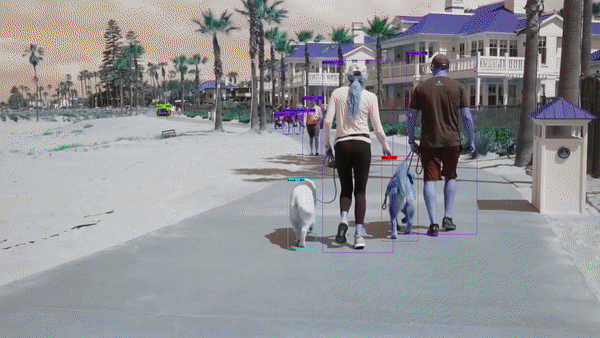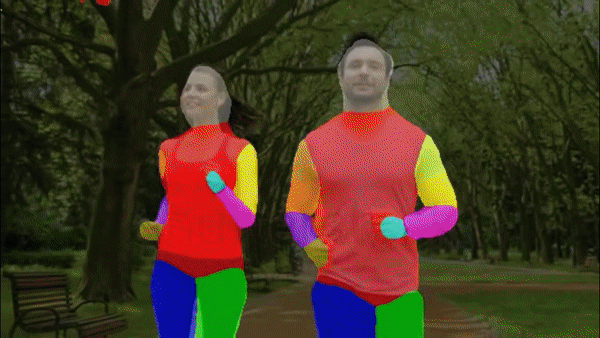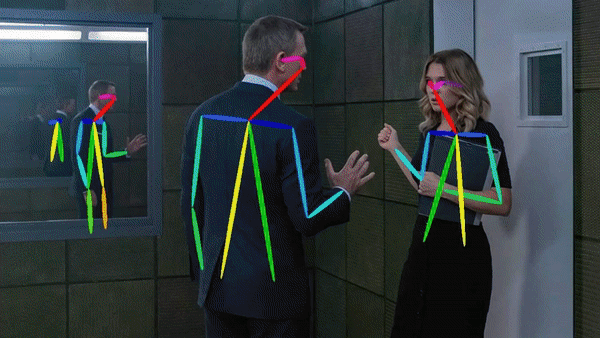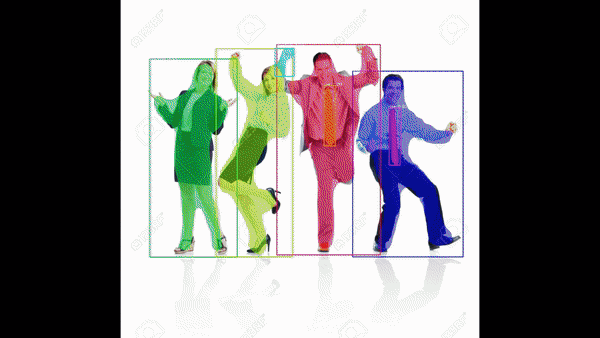
A real-time multi-person human pose estimation system using TensorFlow MoveNet Multipose (Lightning). Built with OpenCV for video and webcam inference, it detects and visualizes keypoints and skeletal connections with confidence-based filtering, optimized for speed and multi-person scenarios.