cadrl_ros
ROS package for dynamic obstacle avoidance for ground robots trained with deep RL
- 726
- Python
- 5 y ago
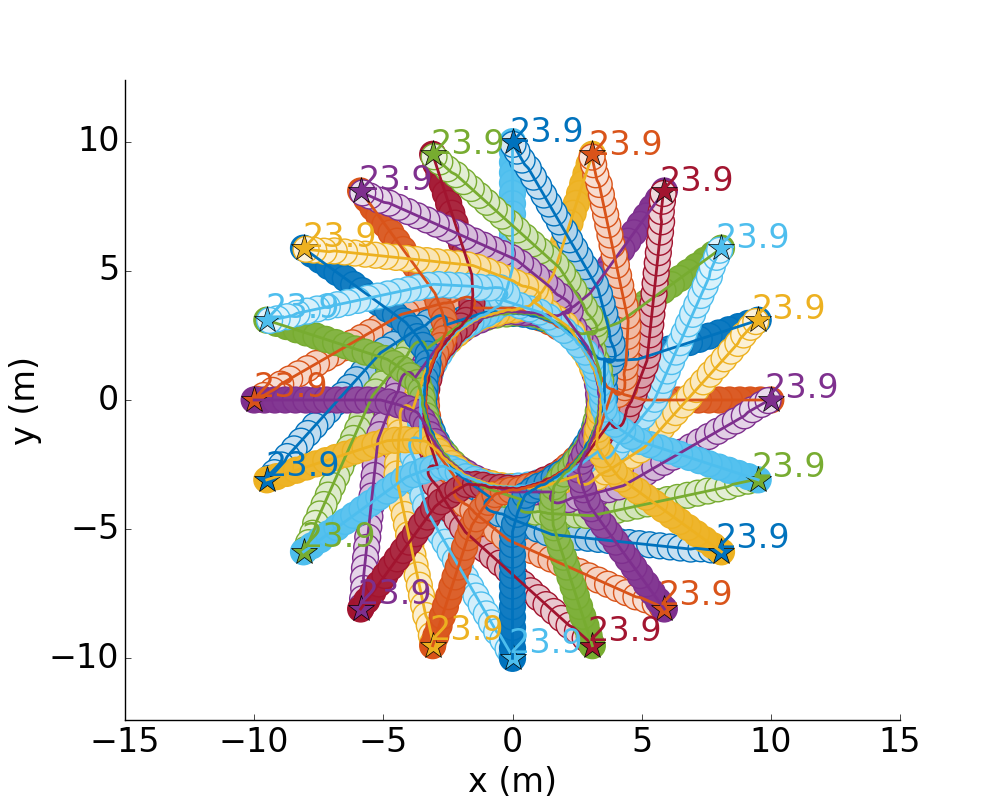
ROS package for dynamic obstacle avoidance for ground robots trained with deep RL
Training code for GA3C-CADRL algorithm (collision avoidance with deep RL)
Real-time monocular depth estimation for DJI Tello drone collision avoidance. Modern TF2.x implementation with webcam support, comprehensive tests, and autonomous navigation. PyDNet-based with MiDaS support.
Industrial cooperative-UAV fleet coordination in Rust — formation keeping, Raft consensus, cooperative task allocation, RRT-APF collision avoidance & MAPPO navigation for civilian SAR / inspection / agriculture