lidar_camera_calibration
ROS package to find a rigid-body transformation between a LiDAR and a camera for "LiDAR-Camera Calibration using 3D-3D Point correspondences"
- 1.8k
- C++
- GPL-3.0
- 13 mo ago
ROS package to find a rigid-body transformation between a LiDAR and a camera for "LiDAR-Camera Calibration using 3D-3D Point correspondences"
Multimodal sentiment analysis using hierarchical fusion with context modeling
causal-falsify: A Python library with algorithms for falsifying the unconfoundedness assumption in a composite dataset from multiple sources.
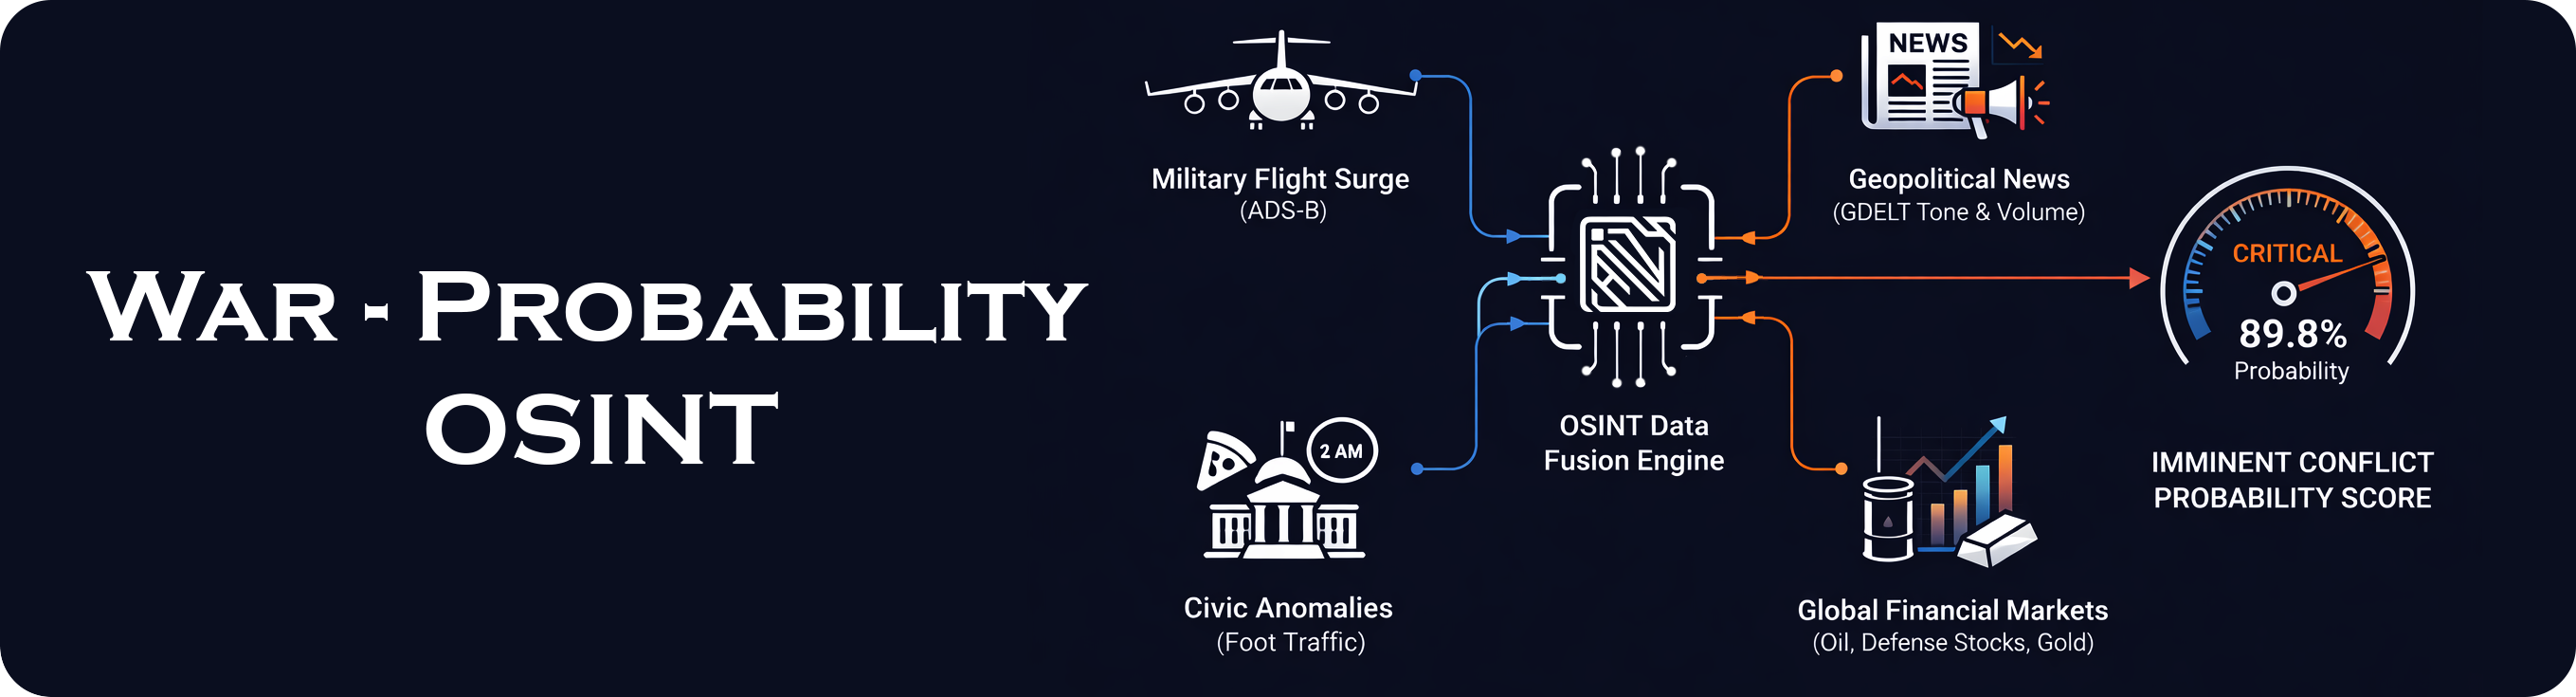
A machine-learning pipeline that fuses real-time signals from military aviation, civic anomalies, geopolitical news sentiment, and global financial markets to output a continuously updated probability of imminent military conflict.
Adversarially resilient vulnerability detection via heterogeneous multi-source data fusion and LLM-augmented reasoning. IEEE ICETCI 2026.