ROS
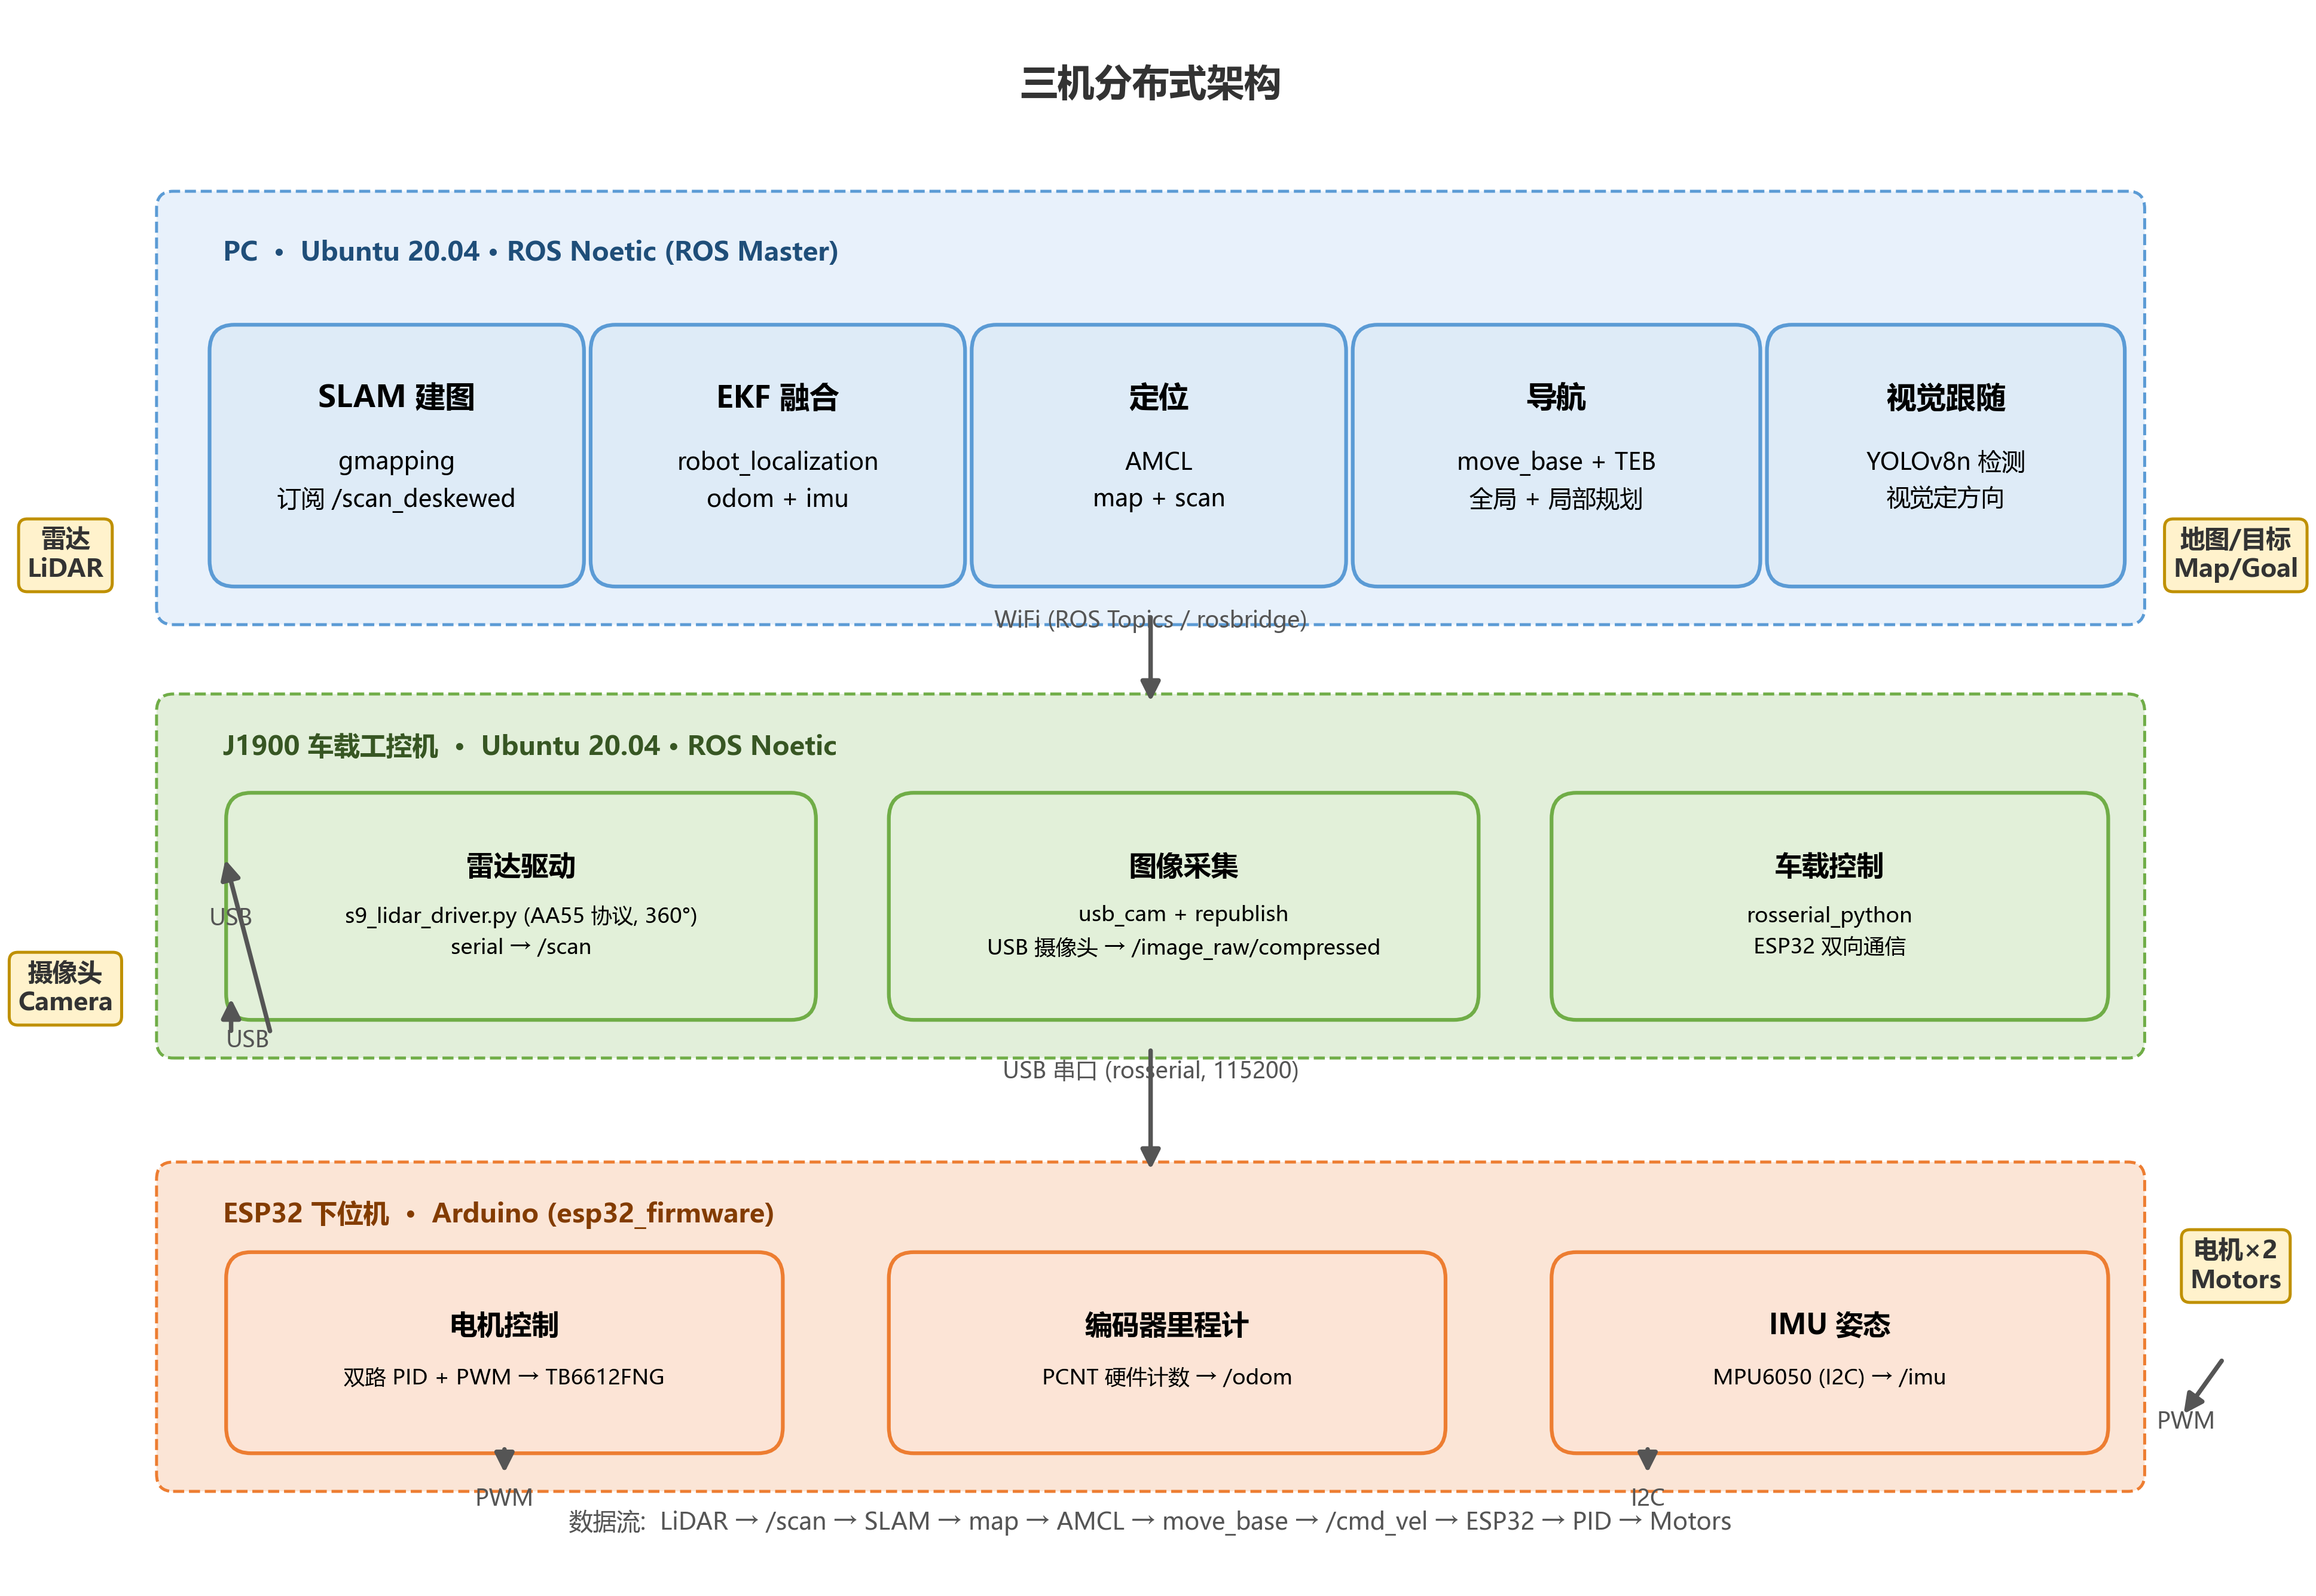
ROS Noetic 两轮差速自主移动机器人:ESP32 底盘(PID/编码器/IMU) + J1900 车载(LiDAR/相机) + PC(SLAM/导航/人体跟随),三机分布式全链路开源实现
- 106
- C++
- MIT
- 6 wk ago
ROS Noetic 两轮差速自主移动机器人:ESP32 底盘(PID/编码器/IMU) + J1900 车载(LiDAR/相机) + PC(SLAM/导航/人体跟随),三机分布式全链路开源实现
A2R3: An open-source AI autonomous room rover robot, built with low-cost hardware and open-source software, designed as a versatile platform for learning and developing mobile robotics.
Robot Drive Systems repository featuring code and kinematics for 2-wheel differential drive, 3-wheel omni-directional drive, and 4-wheel omni-wheel drive robots. Enables linear, rotational, and omnidirectional motion for robotics applications.