TrajOpt-KneedWalker
Finding a stable limit cycle for a passive kneed walker using trajectory optimization.
- 4
- Jupyter Notebook
- 6 y ago
Finding a stable limit cycle for a passive kneed walker using trajectory optimization.
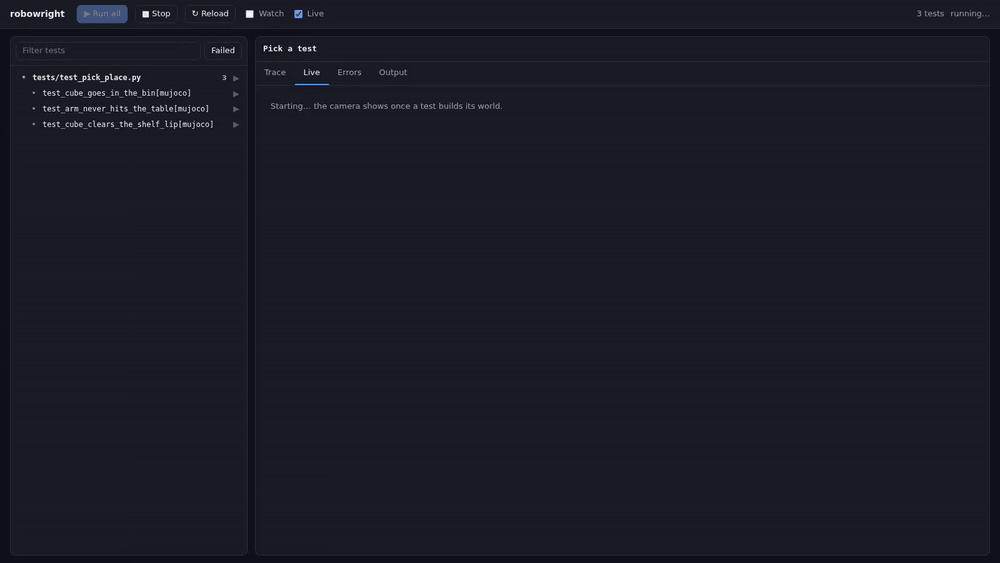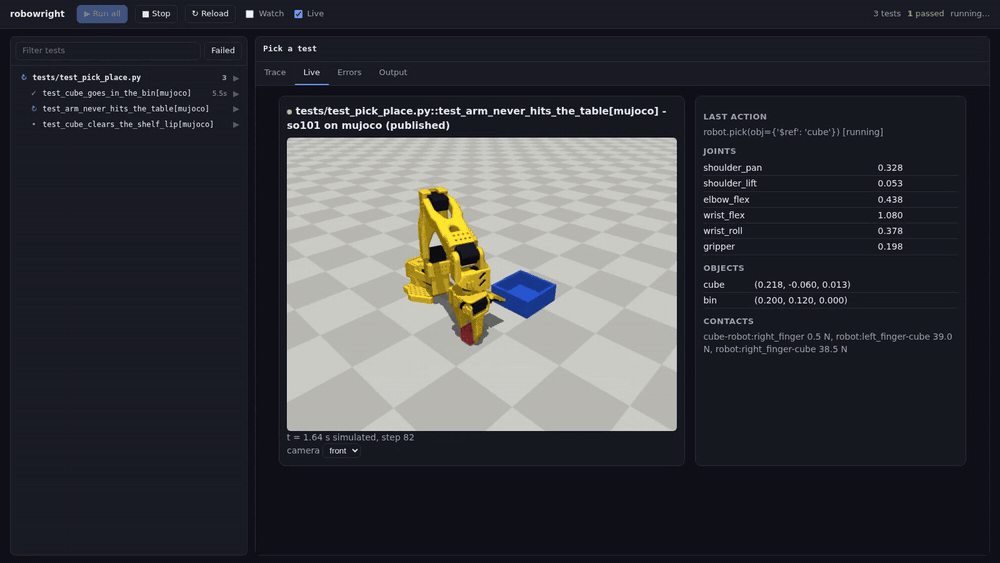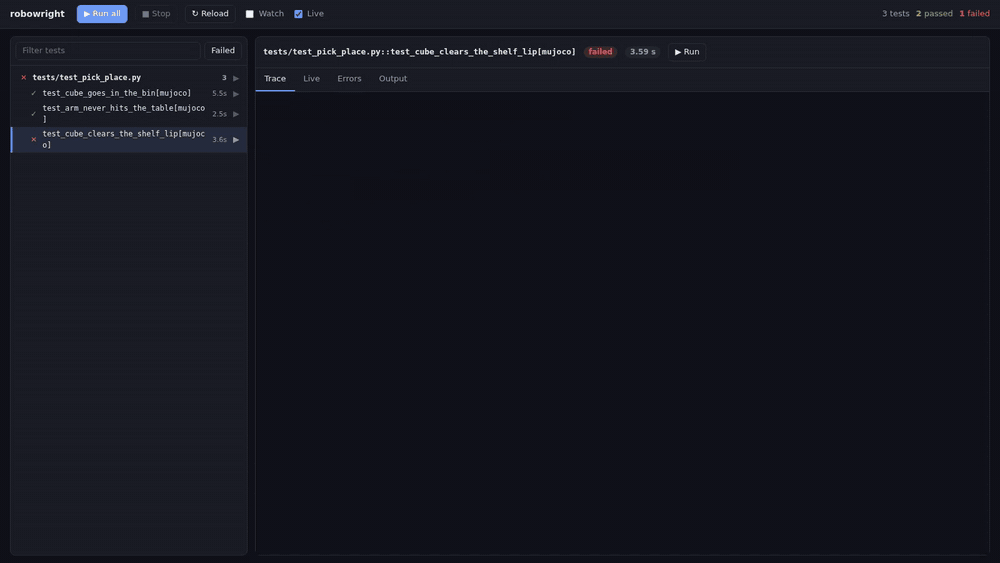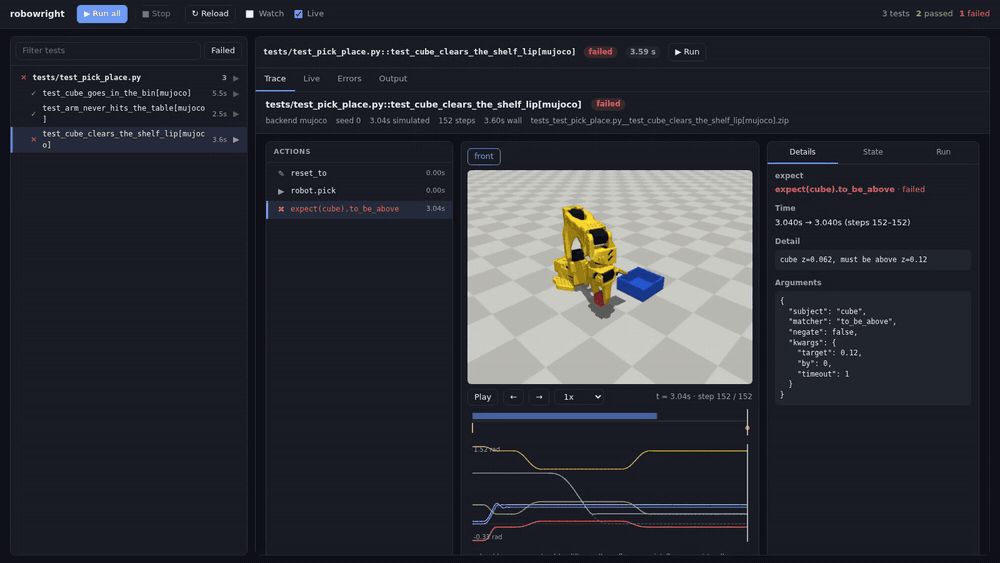
Playwright-style testing for robots: one pytest test, 19 robots (Franka, UR, Kinova, KUKA, xArm, ALOHA, Unitree, Spot...), five physics engines (MuJoCo, PyBullet, Drake, Genesis, Isaac Sim). Auto-waiting actions, expect() assertions, traces, deterministic replay, codegen.