habitat-gs
[ECCV 2026] Habitat-GS: A High-Fidelity Navigation Simulator with Dynamic Gaussian Splatting
- 343
- C++
- 8 d ago
[ECCV 2026] Habitat-GS: A High-Fidelity Navigation Simulator with Dynamic Gaussian Splatting
[CVPR2025] CityWalker: Learning Embodied Urban Navigation from Web-Scale Videos
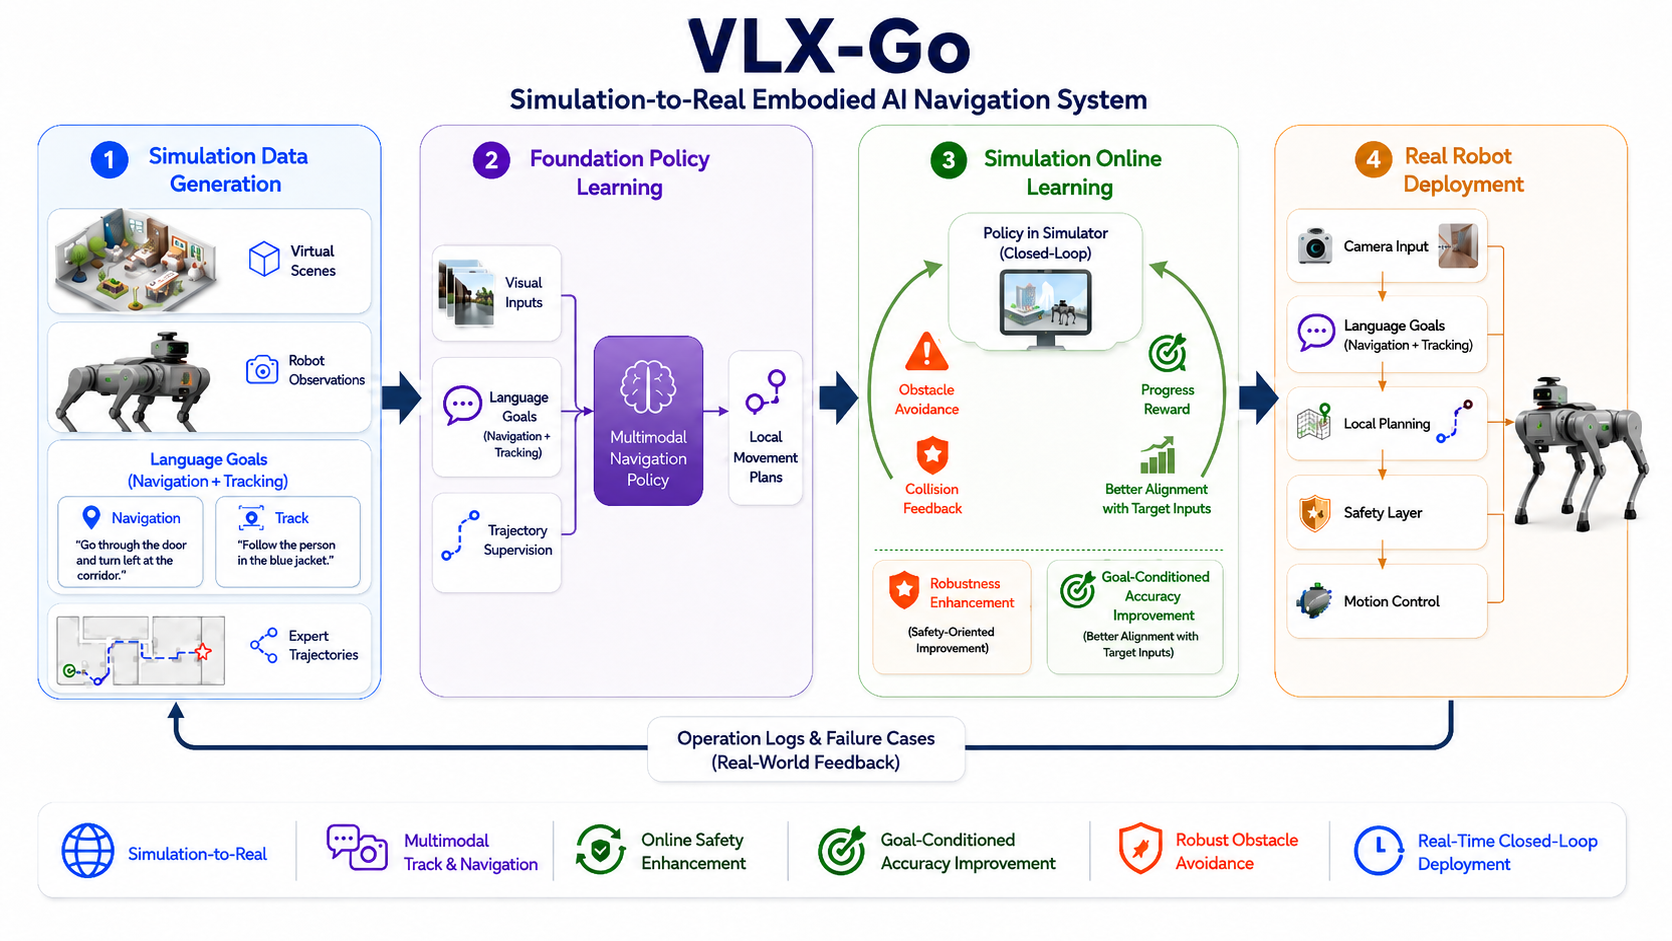
VLX-Go is a lightweight vision-language waypoint planner that enables robots to perceive their surroundings, track targets, and navigate the physical world in real time.
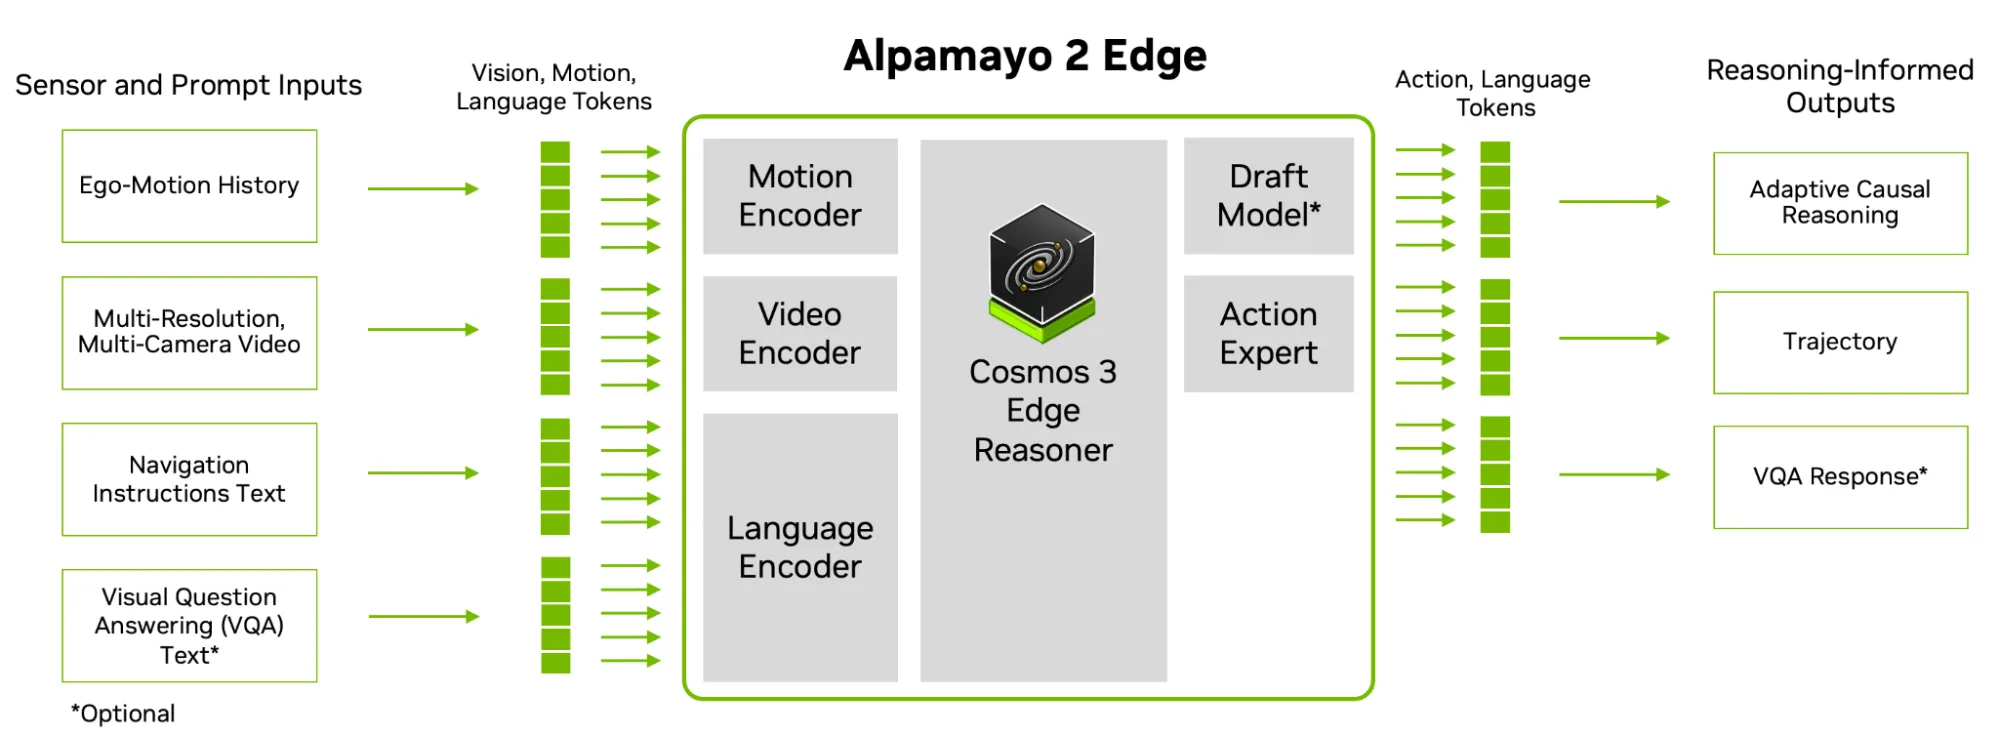
NVIDIA Alpamayo 2 Edge is a 2B-parameter in-vehicle reasoning vision-language-action model using adaptive reasoning to generate trajectories and causal explanations for fine-tuning and efficient deployment.