CppRobotics
Header-only C++ library for robotics, control, and path planning algorithms. Work in progress, contributions are welcome!
- 504
- C++
- MIT
- 3 y ago
Header-only C++ library for robotics, control, and path planning algorithms. Work in progress, contributions are welcome!
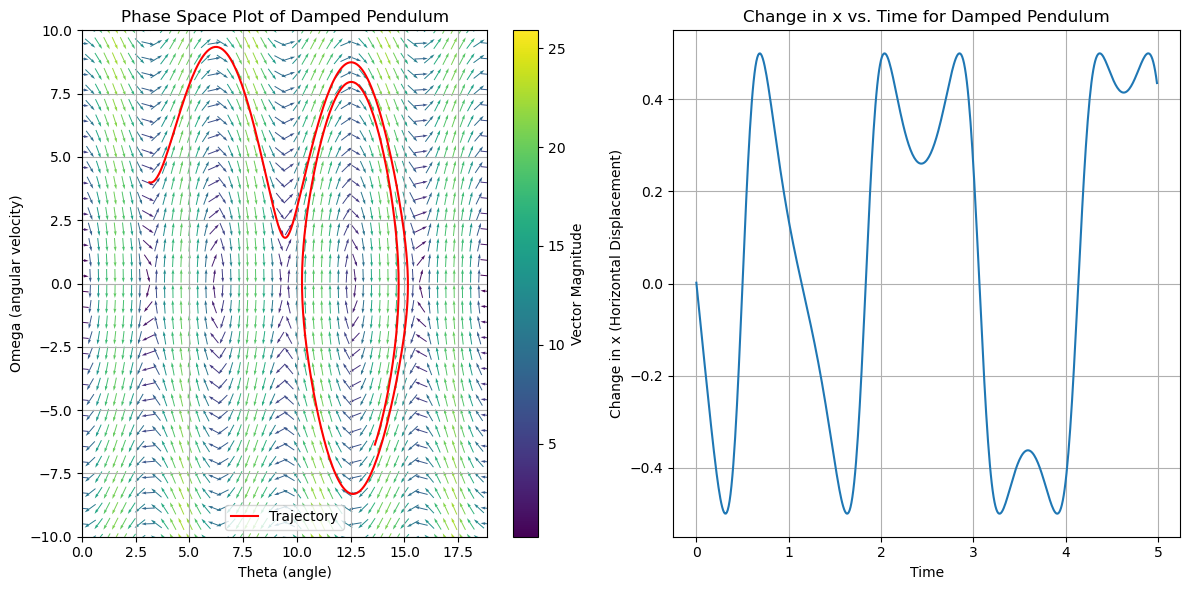
LQR-RRT* method is used for random motion planning of a simple pendulum in it's phase plot
Question answering model, used with control-systems-ai999x.
Experimenting with different dynamical systems and simple control techniques