openarm
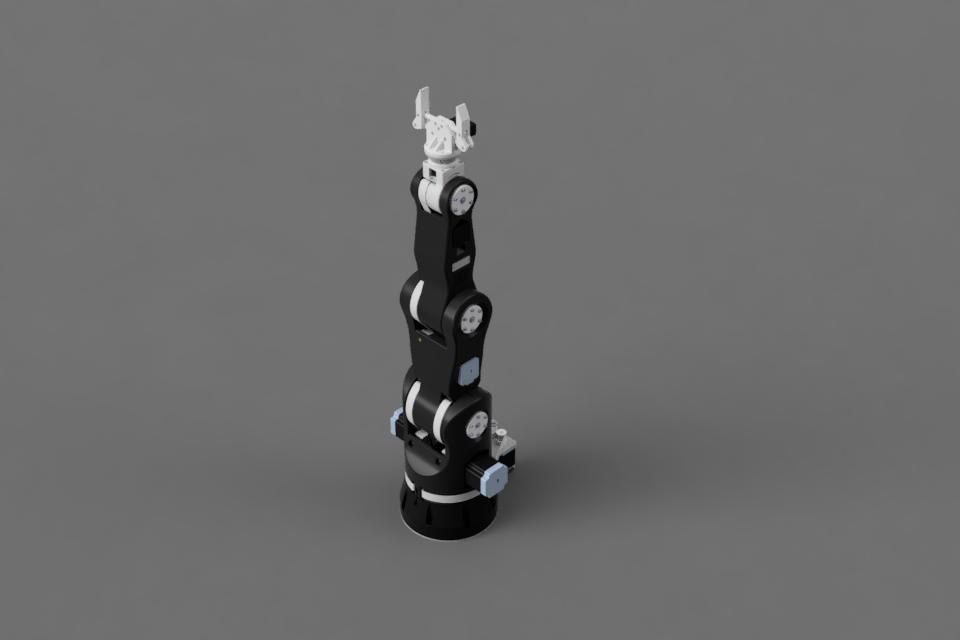
A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.
- 3.7k
- MDX
- Apache-2.0
- 4 d ago
A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.
UR3 robotic arm pick-and-place stack for ROS2 Humble: MoveIt 2 + MoveIt Task Constructor, Gazebo Harmonic simulation, Robotiq/OnRobot grippers, dual-arm support, BehaviorTree.CPP task planning, perception, LLM-driven commands, and RL policies.
Igus Rebel controller with ROS2 and MoveIt2: hardware interfaces and commander demos
6DOF Robot Arm | ROS 2 Foxy based | 3D printed | open-source | designed for learning
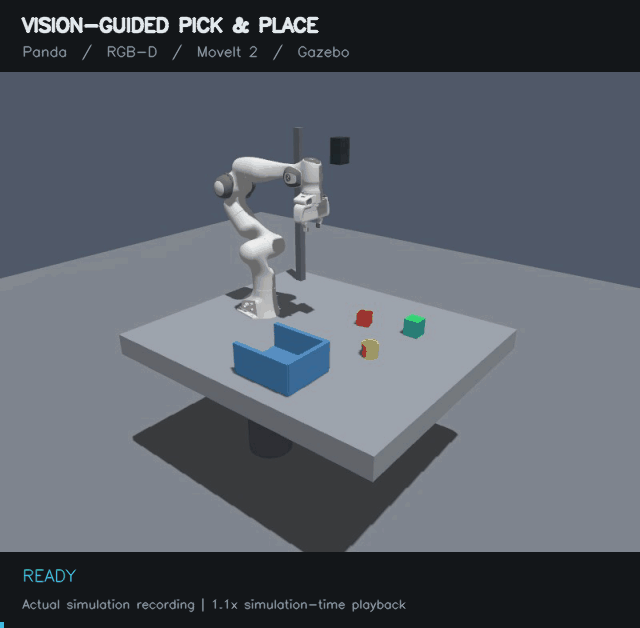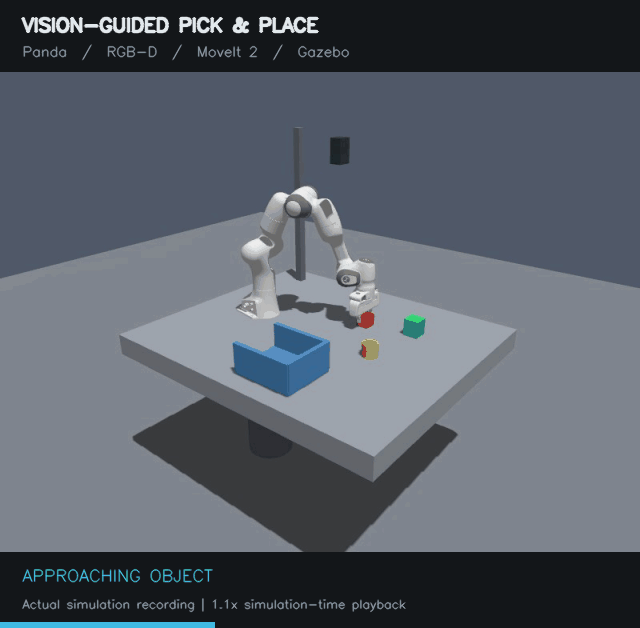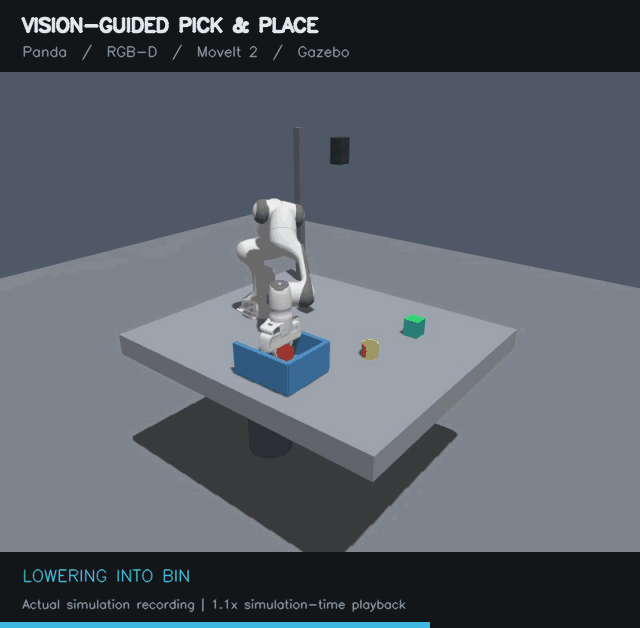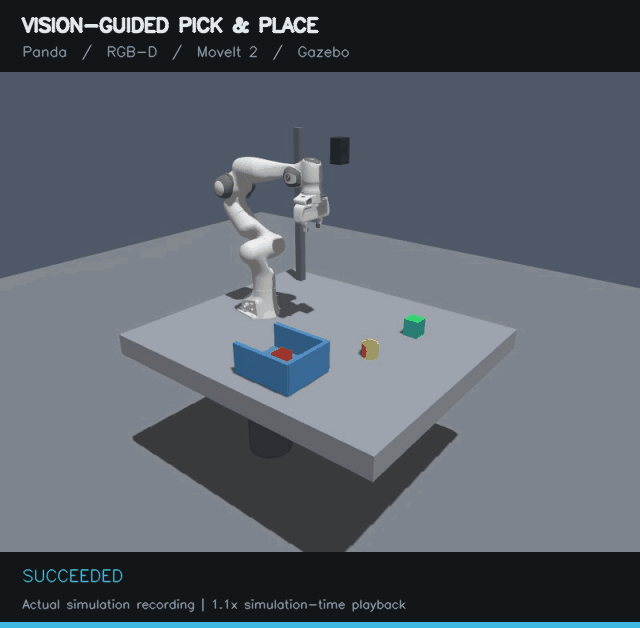
ROS 2 vision-guided pick-and-place simulation with a Panda arm, RGB-D perception, MoveIt 2, and Gazebo.