mujoco
Multi-Joint dynamics with Contact. A general purpose physics simulator.
- 18k
- C++
- Apache-2.0
- 4 h ago
Multi-Joint dynamics with Contact. A general purpose physics simulator.
Google DeepMind's software stack for physics-based simulation and Reinforcement Learning environments, using MuJoCo.
A collection of high-quality models for the MuJoCo physics engine, curated by Google DeepMind.
Synapsa Commons: free, hands-on AI courses that run anywhere (Colab, Kaggle, Binder, Codespaces, Jupyter). EU AI Act conformity evidence, model validation, predictive maintenance, document extraction, retrieval and RAG, AI agents and MCP, a simulated humanoid. Every lesson autograded. From the team building Synapsa.
A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.
OpenDILab Decision AI Engine. The Most Comprehensive Reinforcement Learning Framework B.P.
Collections of robotics environments geared towards benchmarking multi-task and meta reinforcement learning
Real-time behaviour synthesis with MuJoCo, using Predictive Control
This repository contains model-free deep reinforcement learning algorithms implemented in Pytorch
A curated list of fruit fly connectome projects: MaleCNS, FlyWire, brain simulations, embodied models, games, and research tools.
Reproducible Microduck RL experiments, policies, simulation assets, and hardware add-ons
A Repository with C++ implementations of Reinforcement Learning Algorithms (Pytorch)
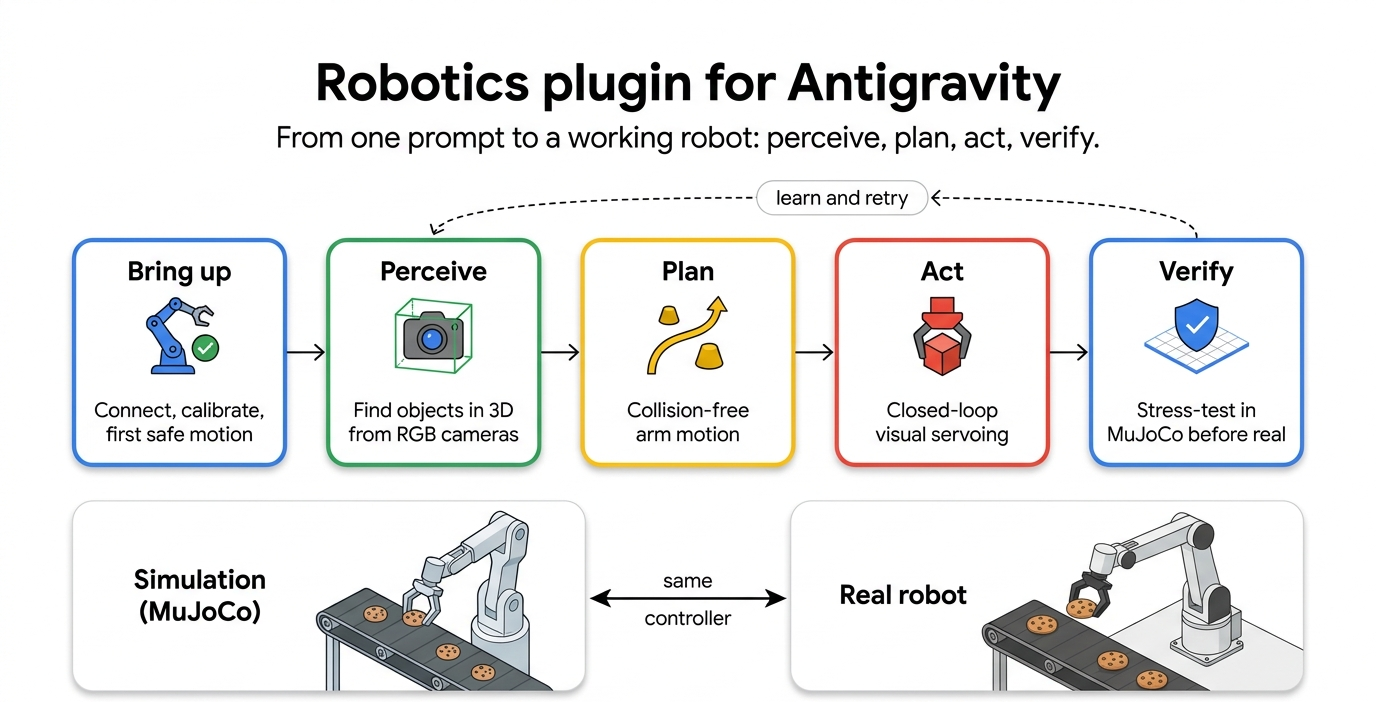
GDM Robotics Skills for agentic robotics workflows across simulation and real robots.
This repository contains the implementation for the paper - Exploration via Hierarchical Meta Reinforcement Learning.
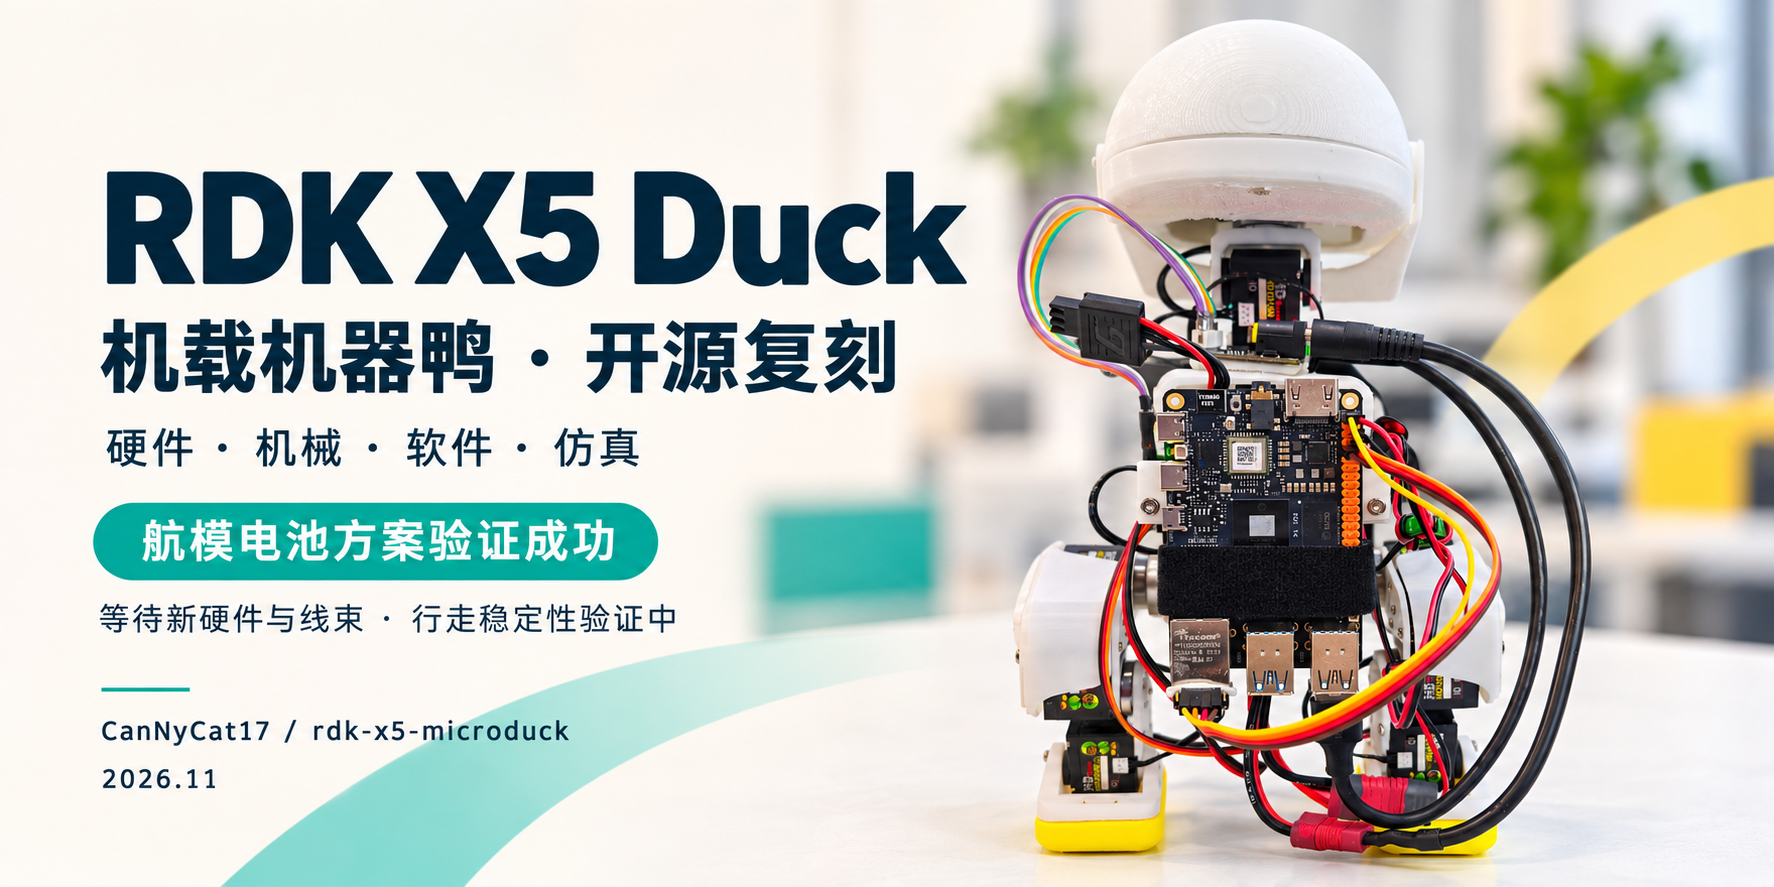
RDK X5机器鸭完整复刻案例:硬件采购、FT打印装配、机载控制、IMU配置、MuJoCo仿真与短距离前进,附源码、模型、教程和实机视频。
CLI and skills to prototype custom scenes with coding agents like Codex and Claude Code.
50 Hz 3D MuJoCo apartment & .ONNX bipedal skill hub
Runs in the browser on Hugging Face