ROS
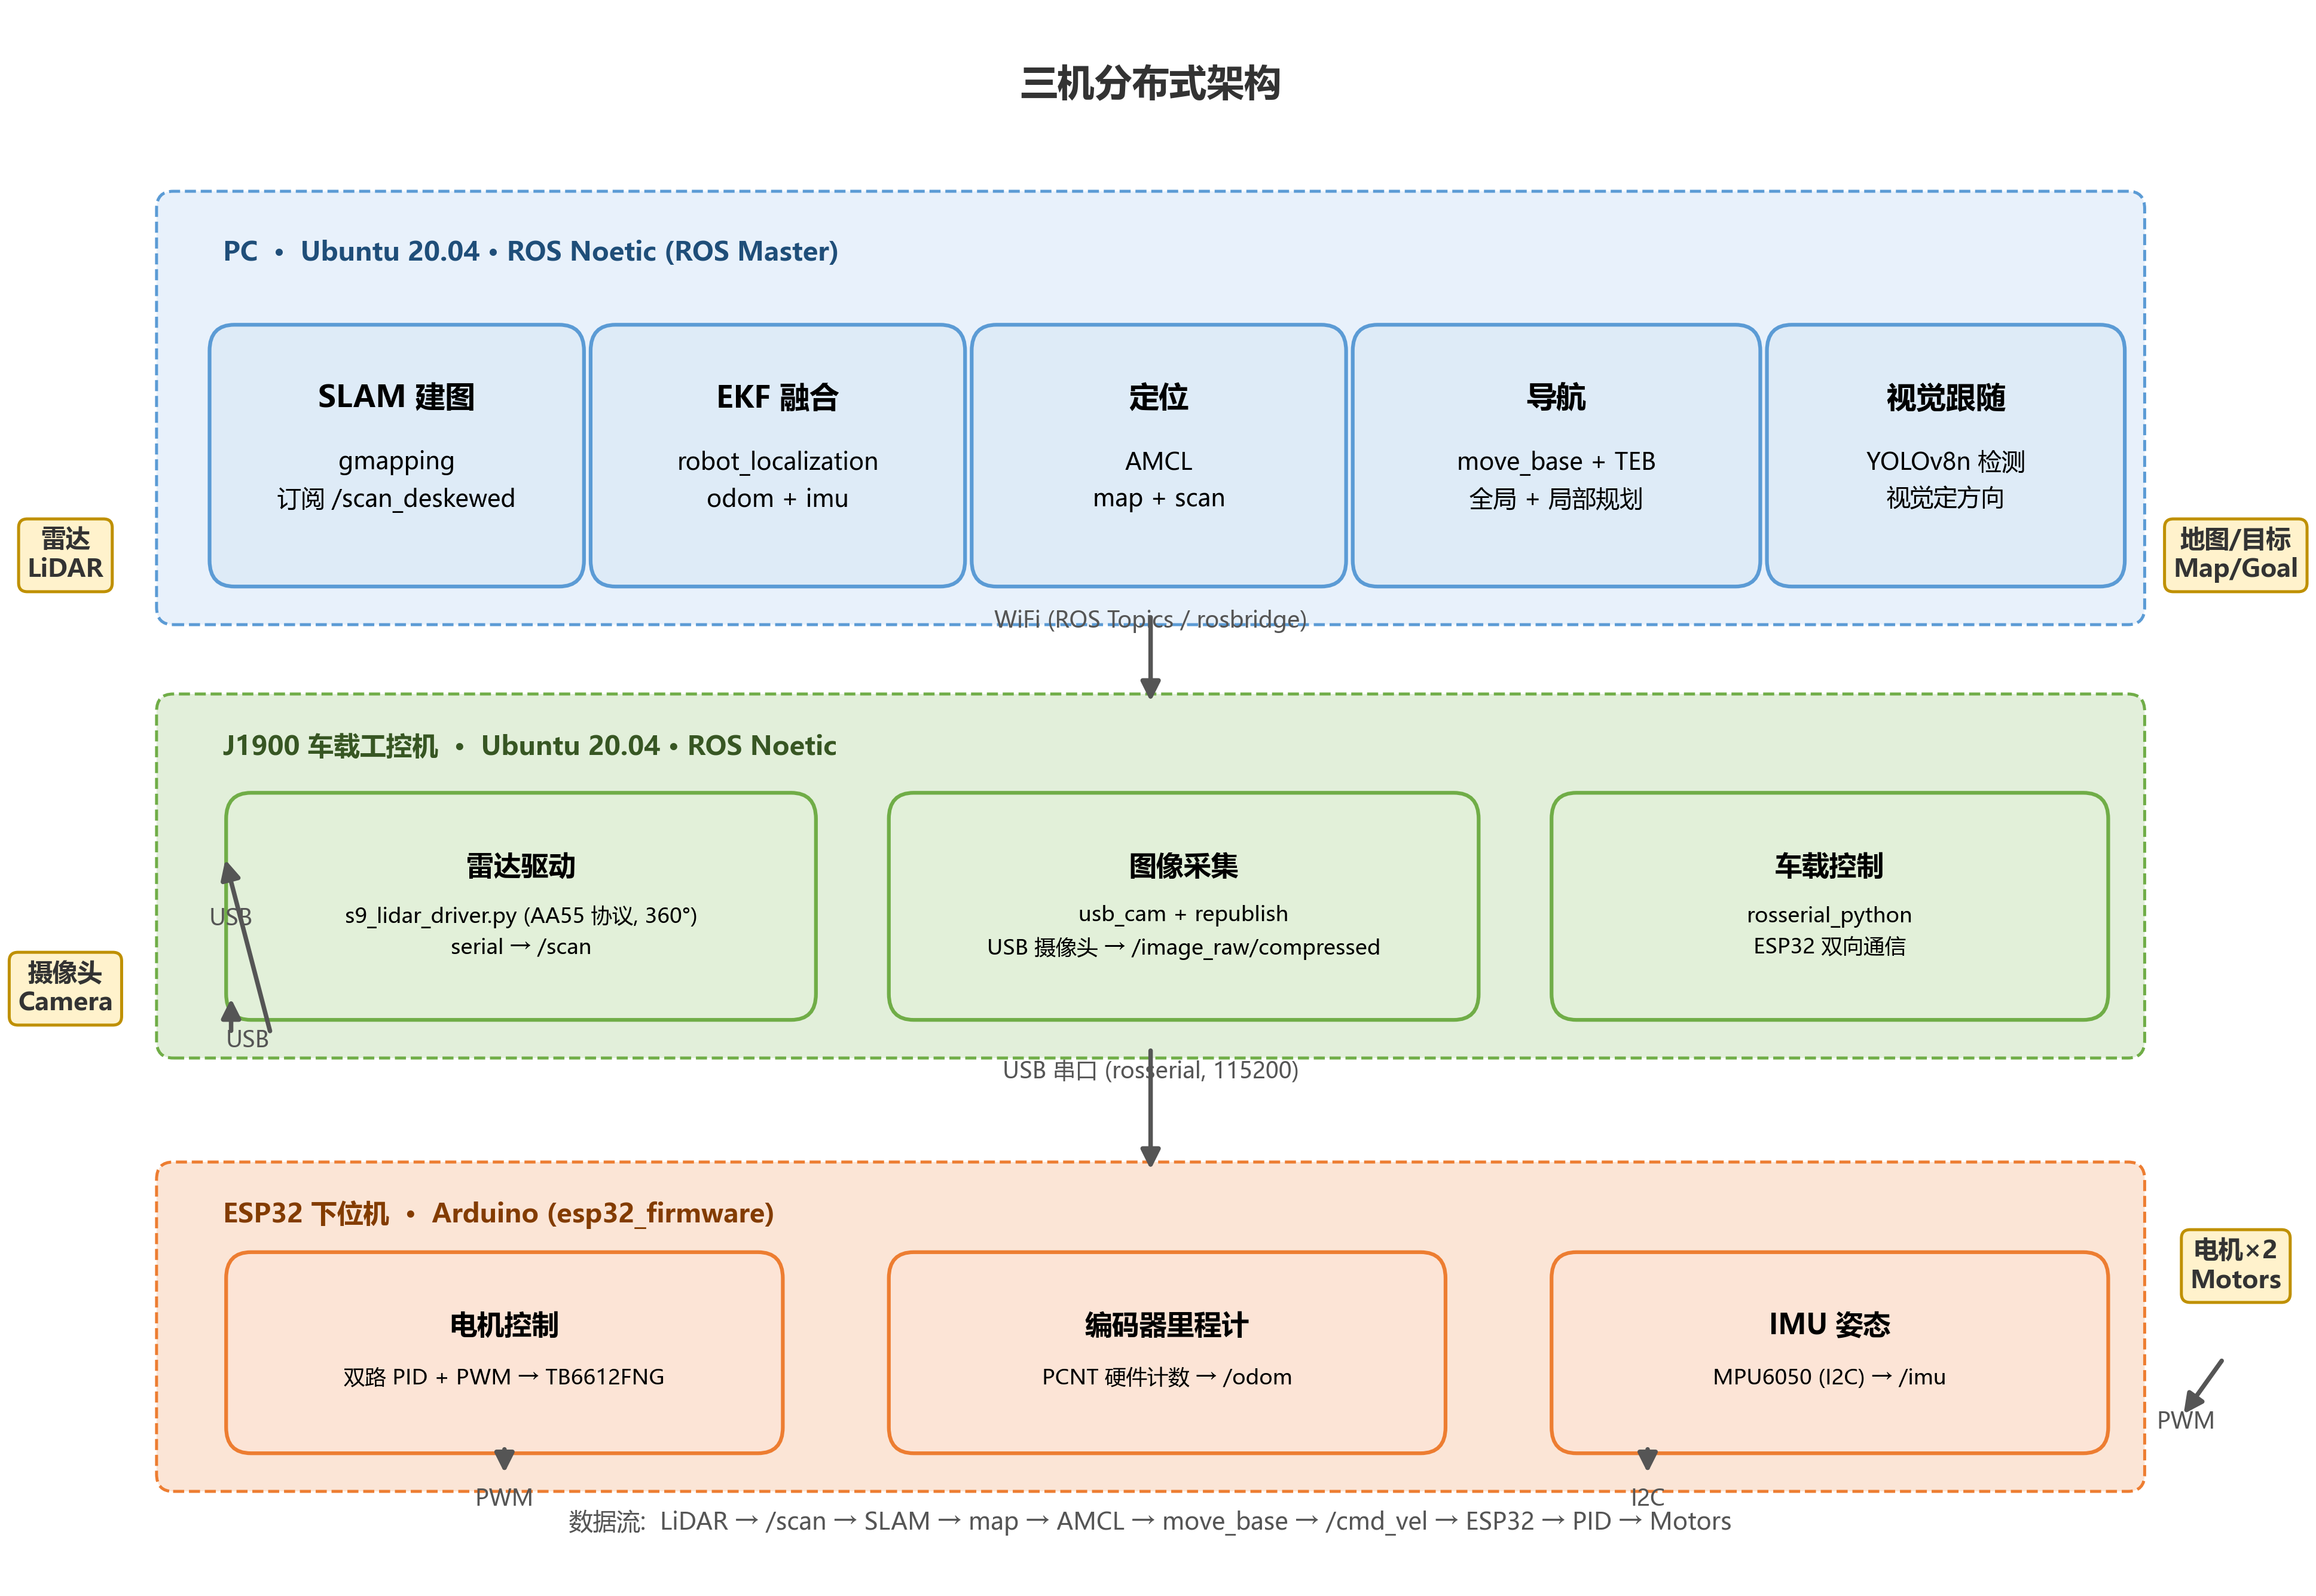
ROS Noetic 两轮差速自主移动机器人:ESP32 底盘(PID/编码器/IMU) + J1900 车载(LiDAR/相机) + PC(SLAM/导航/人体跟随),三机分布式全链路开源实现
- 106
- C++
- MIT
- 6 wk ago
ROS Noetic 两轮差速自主移动机器人:ESP32 底盘(PID/编码器/IMU) + J1900 车载(LiDAR/相机) + PC(SLAM/导航/人体跟随),三机分布式全链路开源实现
A code for implementing autonomous car software, including environment perception, lanes detection, identifying traffic signs, and controlling the vehicle with digital PID.
A lightweight fixed-point PID controller for embedded systems with integer arithmetic and low computational overhead.
Remote temperature control system for professional pizza ovens using Raspberry Pi with dual-zone PID control.
This is a PID implemented line follower using an Arduino UNO, IR sensors, l293d motor driver.
Using a PID controller to drive a car around the track on the Udacity Simulator