probreg
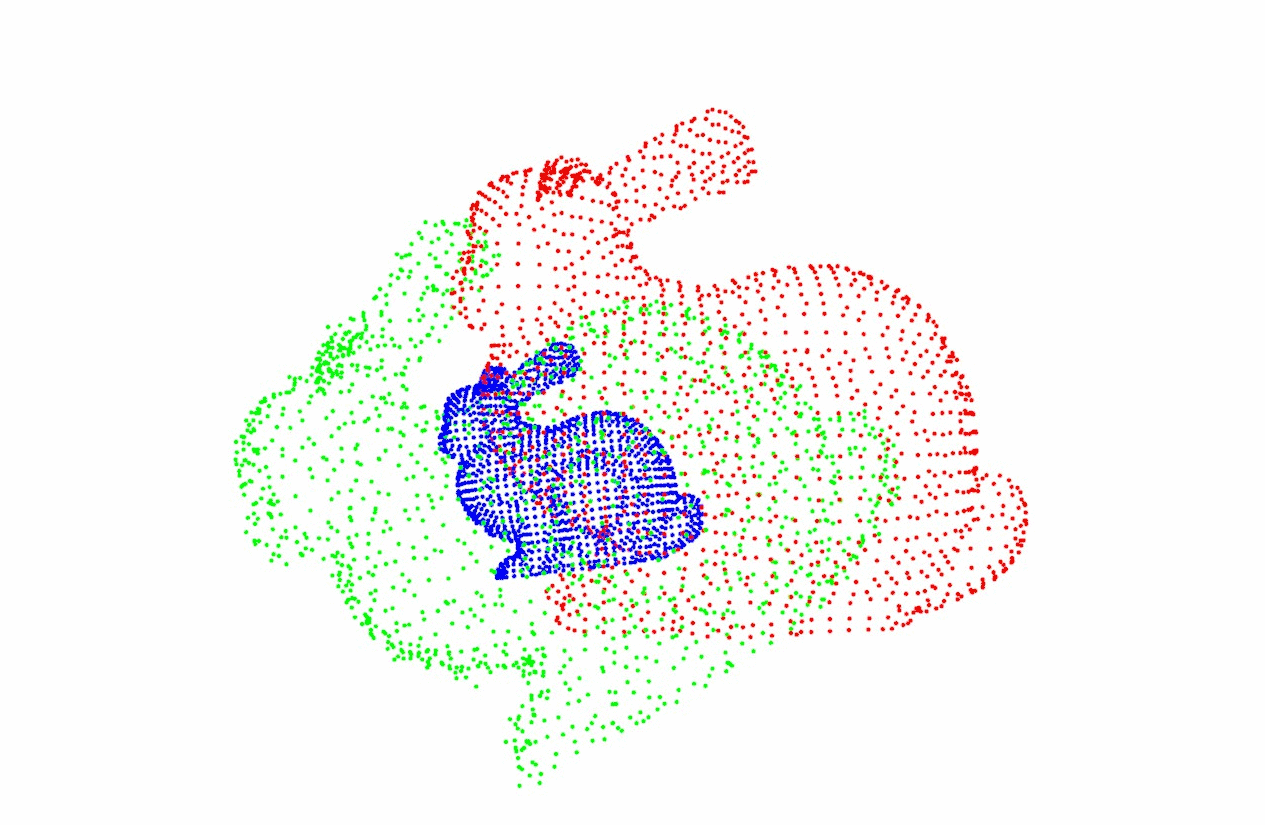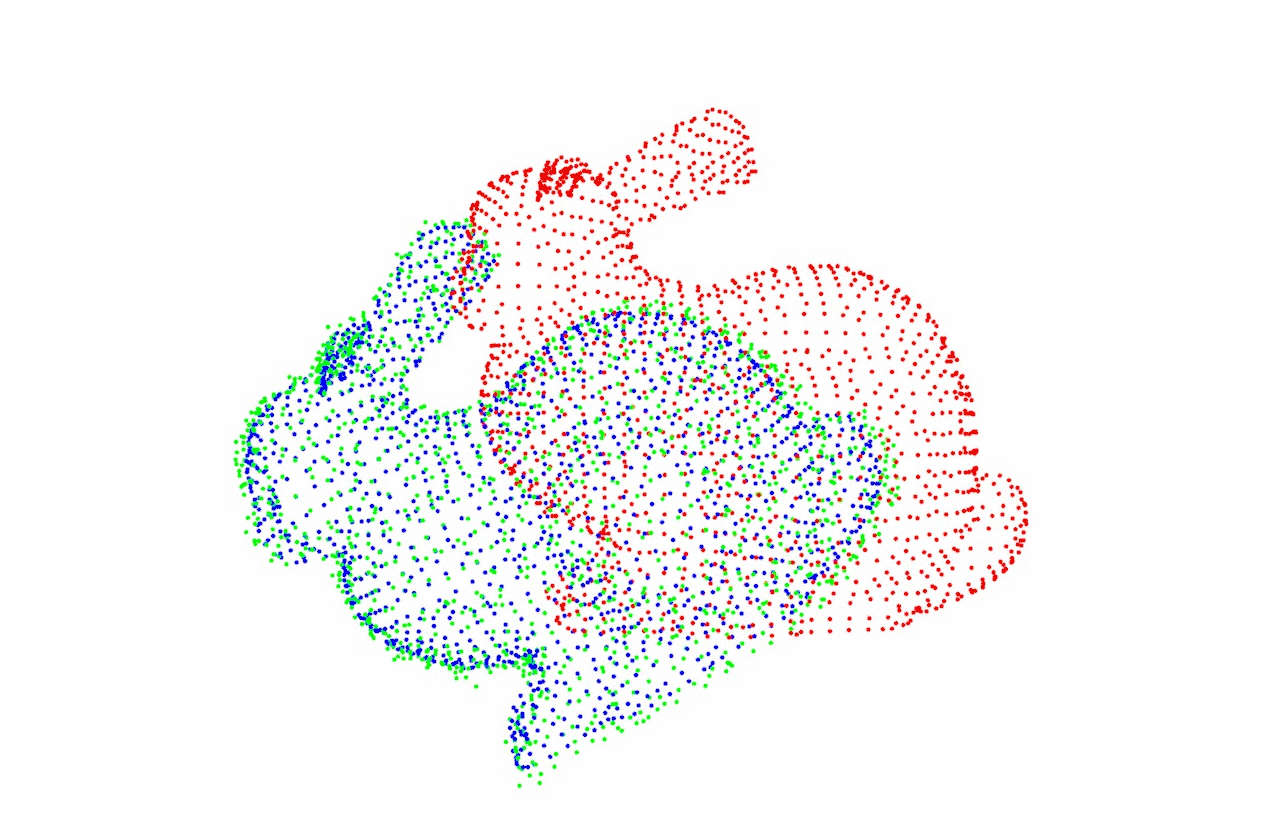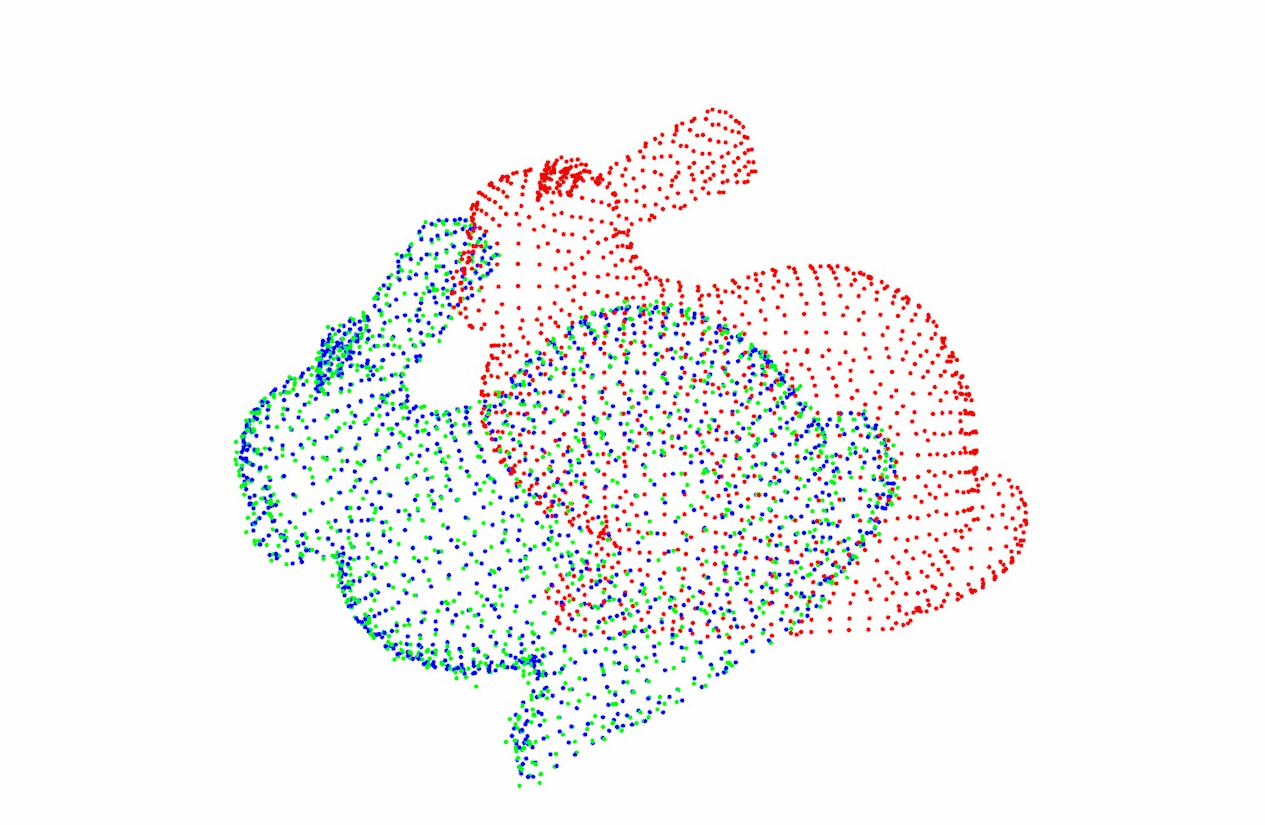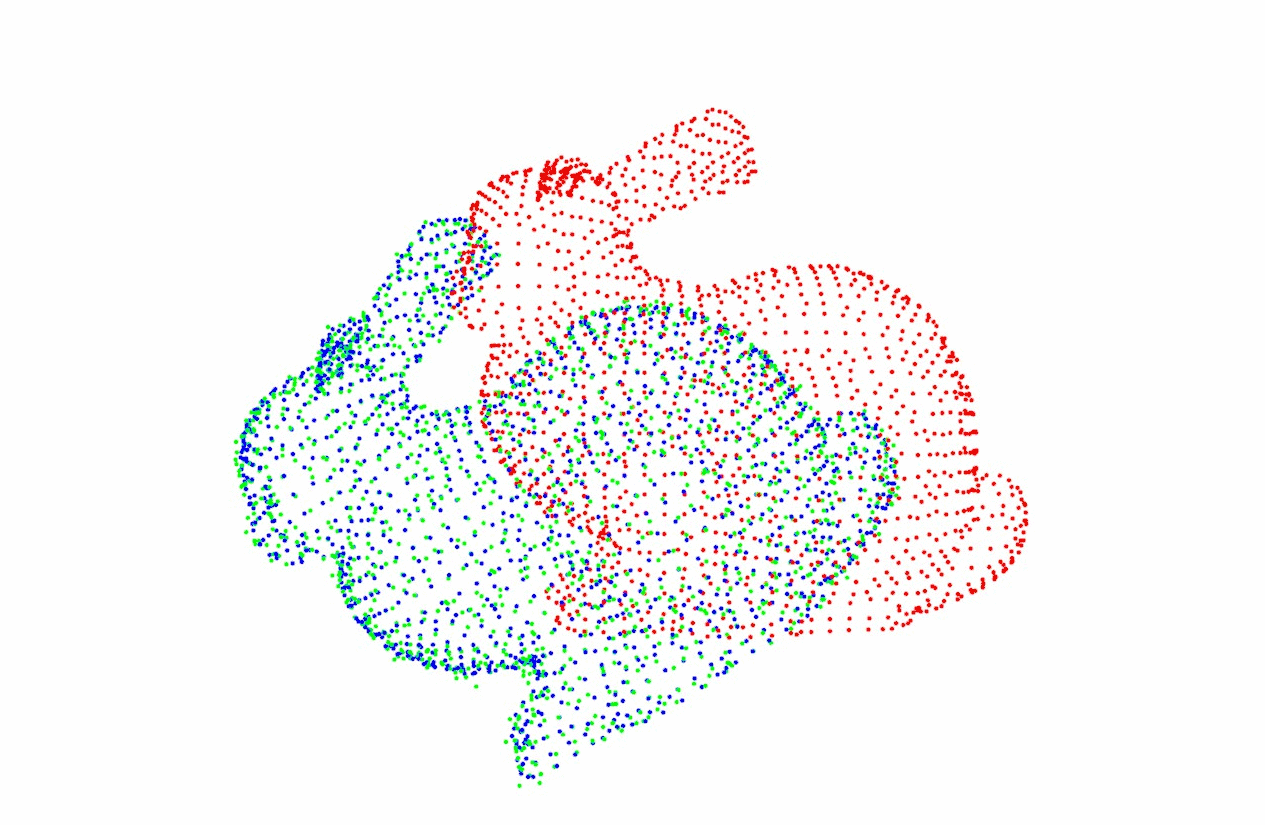
Python package for point cloud registration using probabilistic model (Coherent Point Drift, GMMReg, SVR, GMMTree, FilterReg, Bayesian CPD)
- 1k
- Python
- MIT
- 4 mo ago
Python package for point cloud registration using probabilistic model (Coherent Point Drift, GMMReg, SVR, GMMTree, FilterReg, Bayesian CPD)
A list of papers and datasets about point cloud analysis (processing)
[CVPR2022] Geometric Transformer for Fast and Robust Point Cloud Registration
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
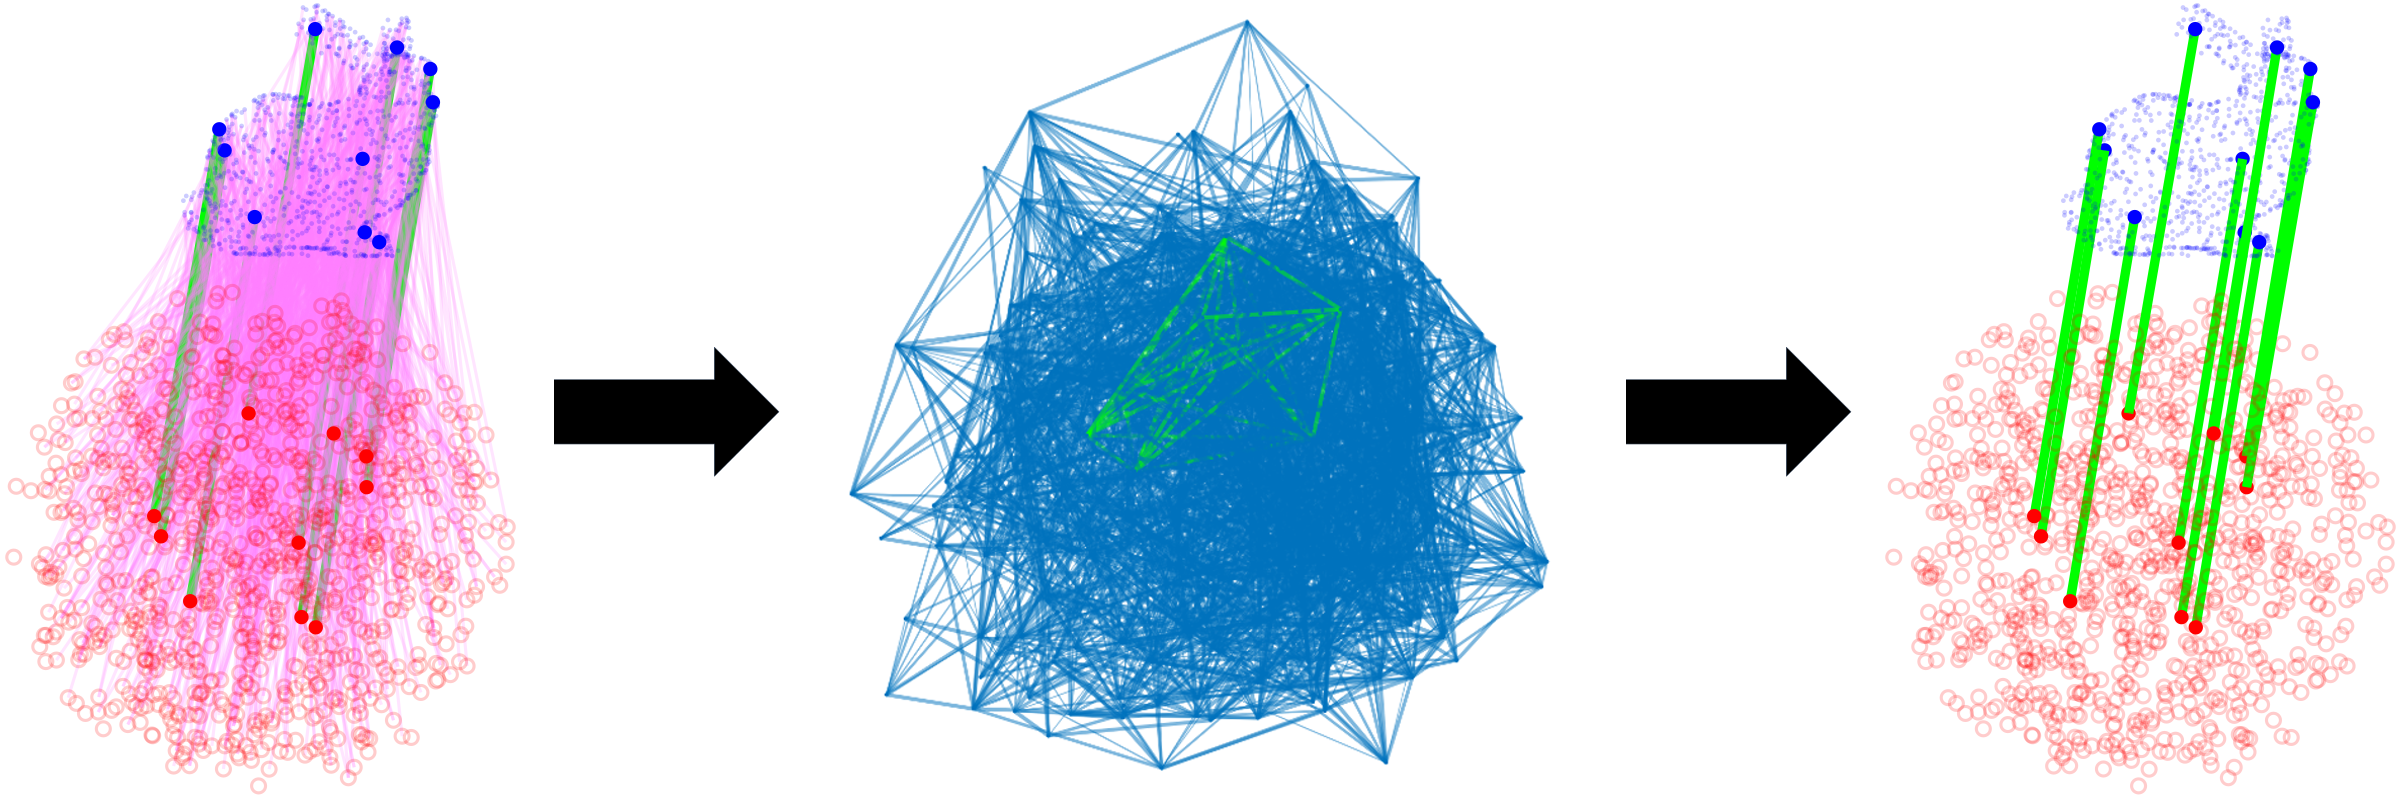
K-Closest Points and Maximum Clique Pruning for Efficient and Effective 3-D Laser Scan Matching (RA-L 2022)
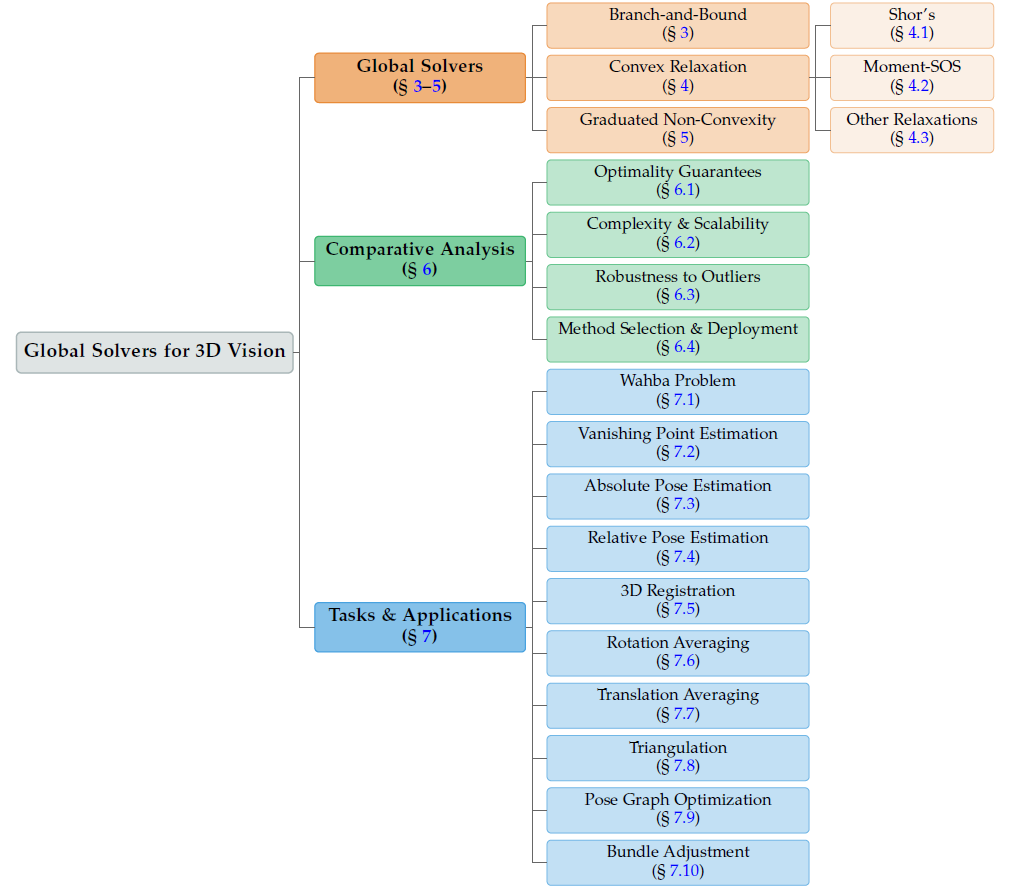
A curated survey and paper list for global solvers in 3D vision: certifiable optimization, convex relaxation, Branch-and-Bound, and robust estimation.
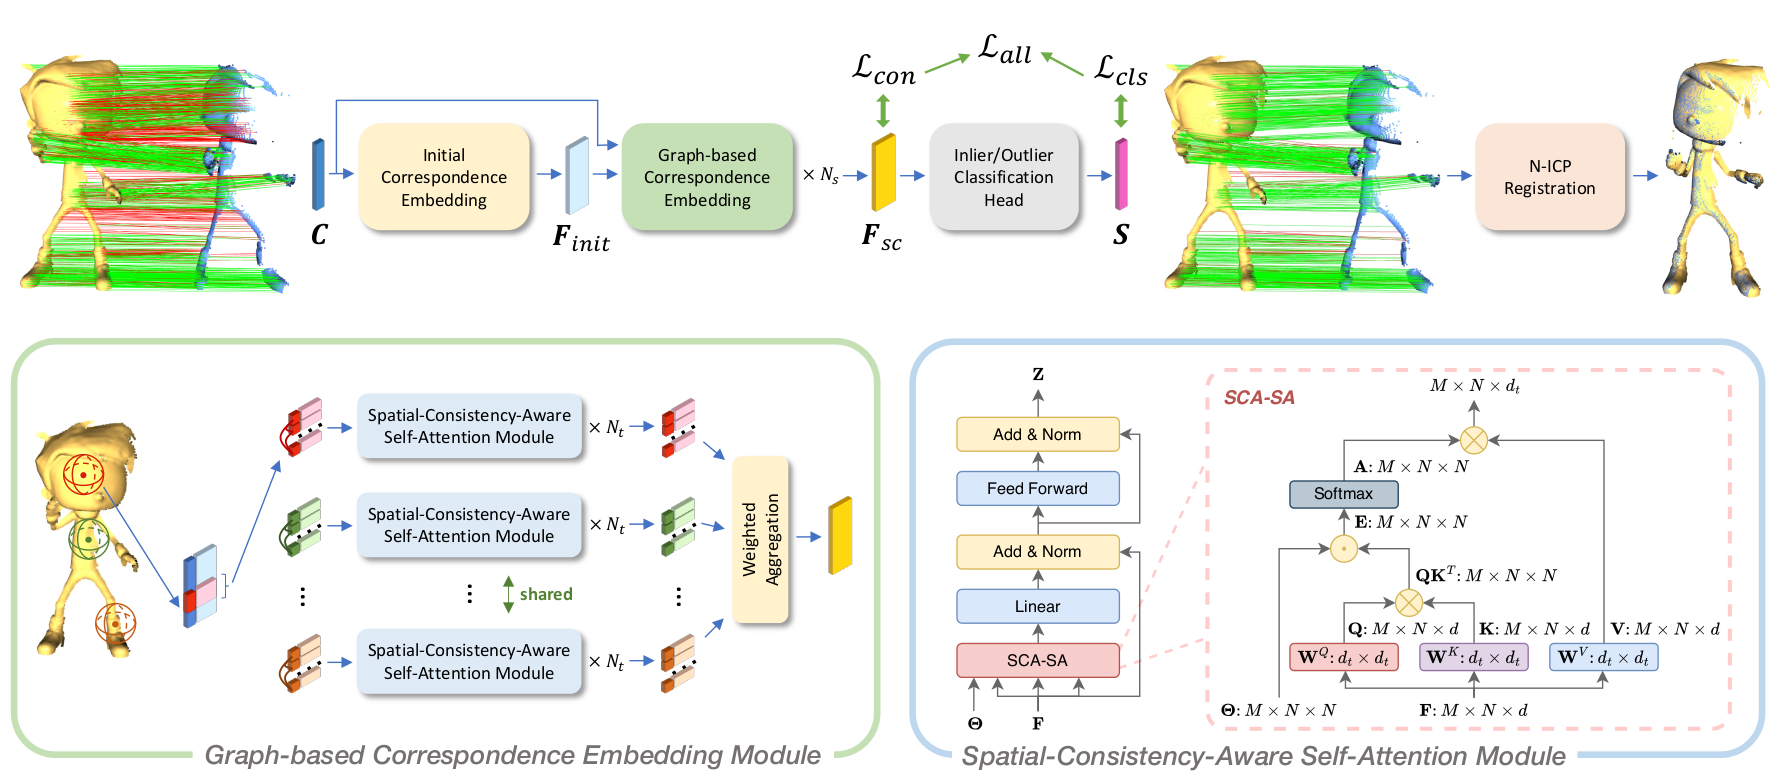
[CVPR2023] Deep Graph-based Spatial Consistency for Robust Non-rigid Point Cloud Registration
register 3D point clouds using rotation, translation, and scale transformations.
Single-Header Reference Implementation of Rigid Coherent Point Drift in C++ / Eigen3 in < 80 LOC
header-only C++ library for registering 3D point clouds using rotation, translation, and scale transformations
🚀 Implement drifting models in PyTorch for one-step generation, learning to generate samples that resemble real data without iterative sampling.