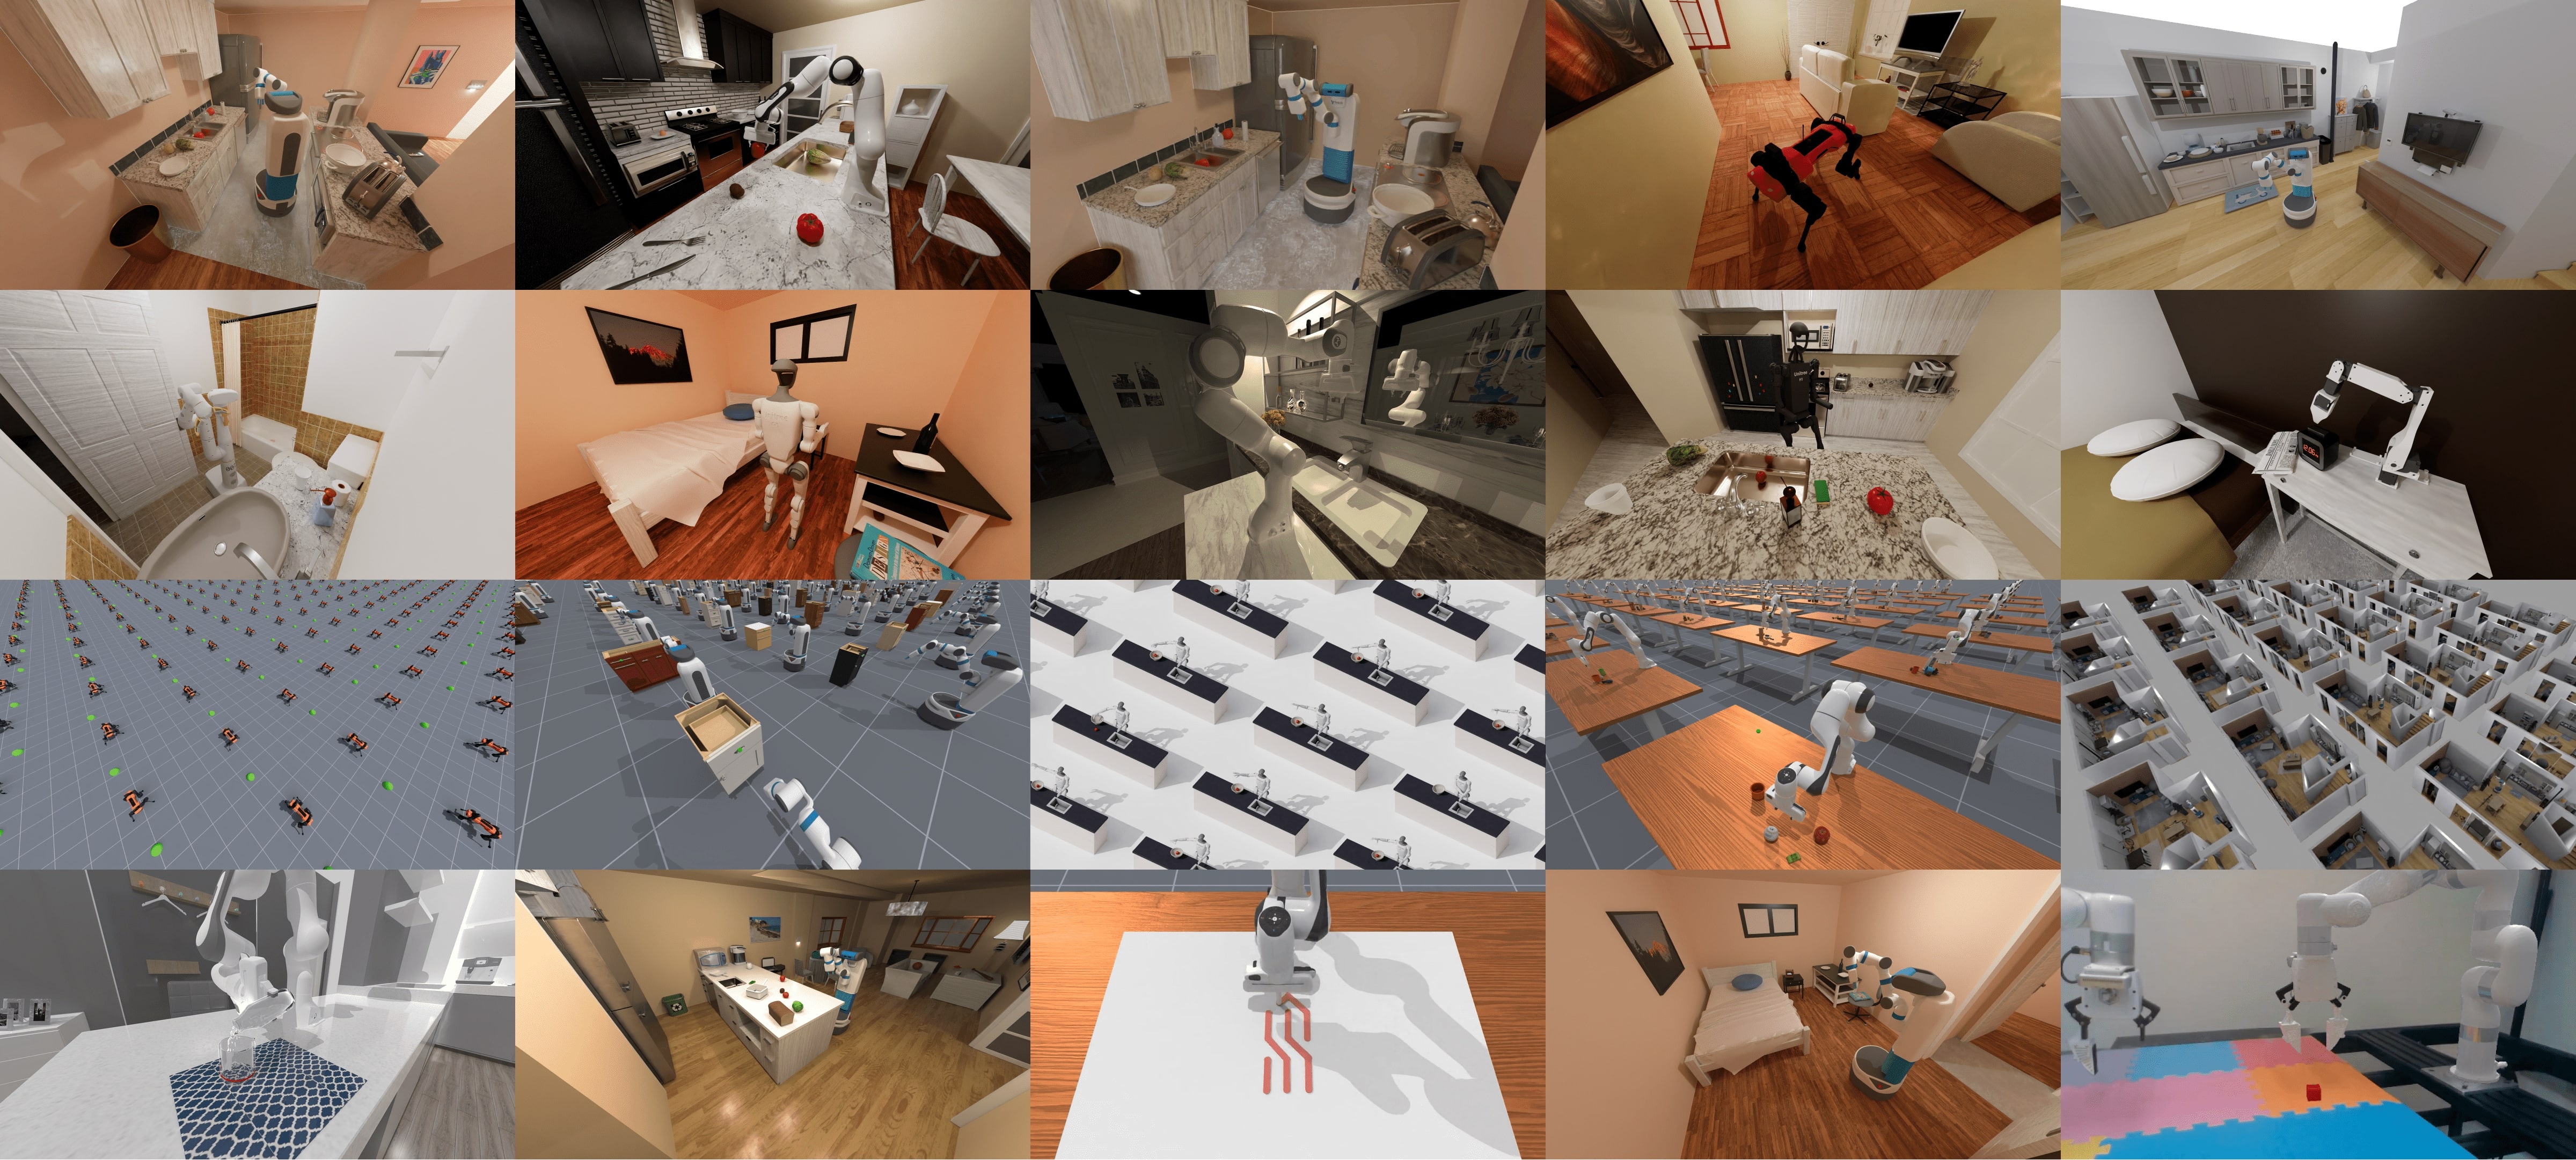
ManiSkill
Manipulation Skill Framework, an open source GPU parallelized robotics simulator and benchmark
- 3.5k
- Python
- Apache-2.0
- 4 mo ago
Manipulation Skill Framework, an open source GPU parallelized robotics simulator and benchmark
robosuite: A Modular Simulation Framework and Benchmark for Robot Learning
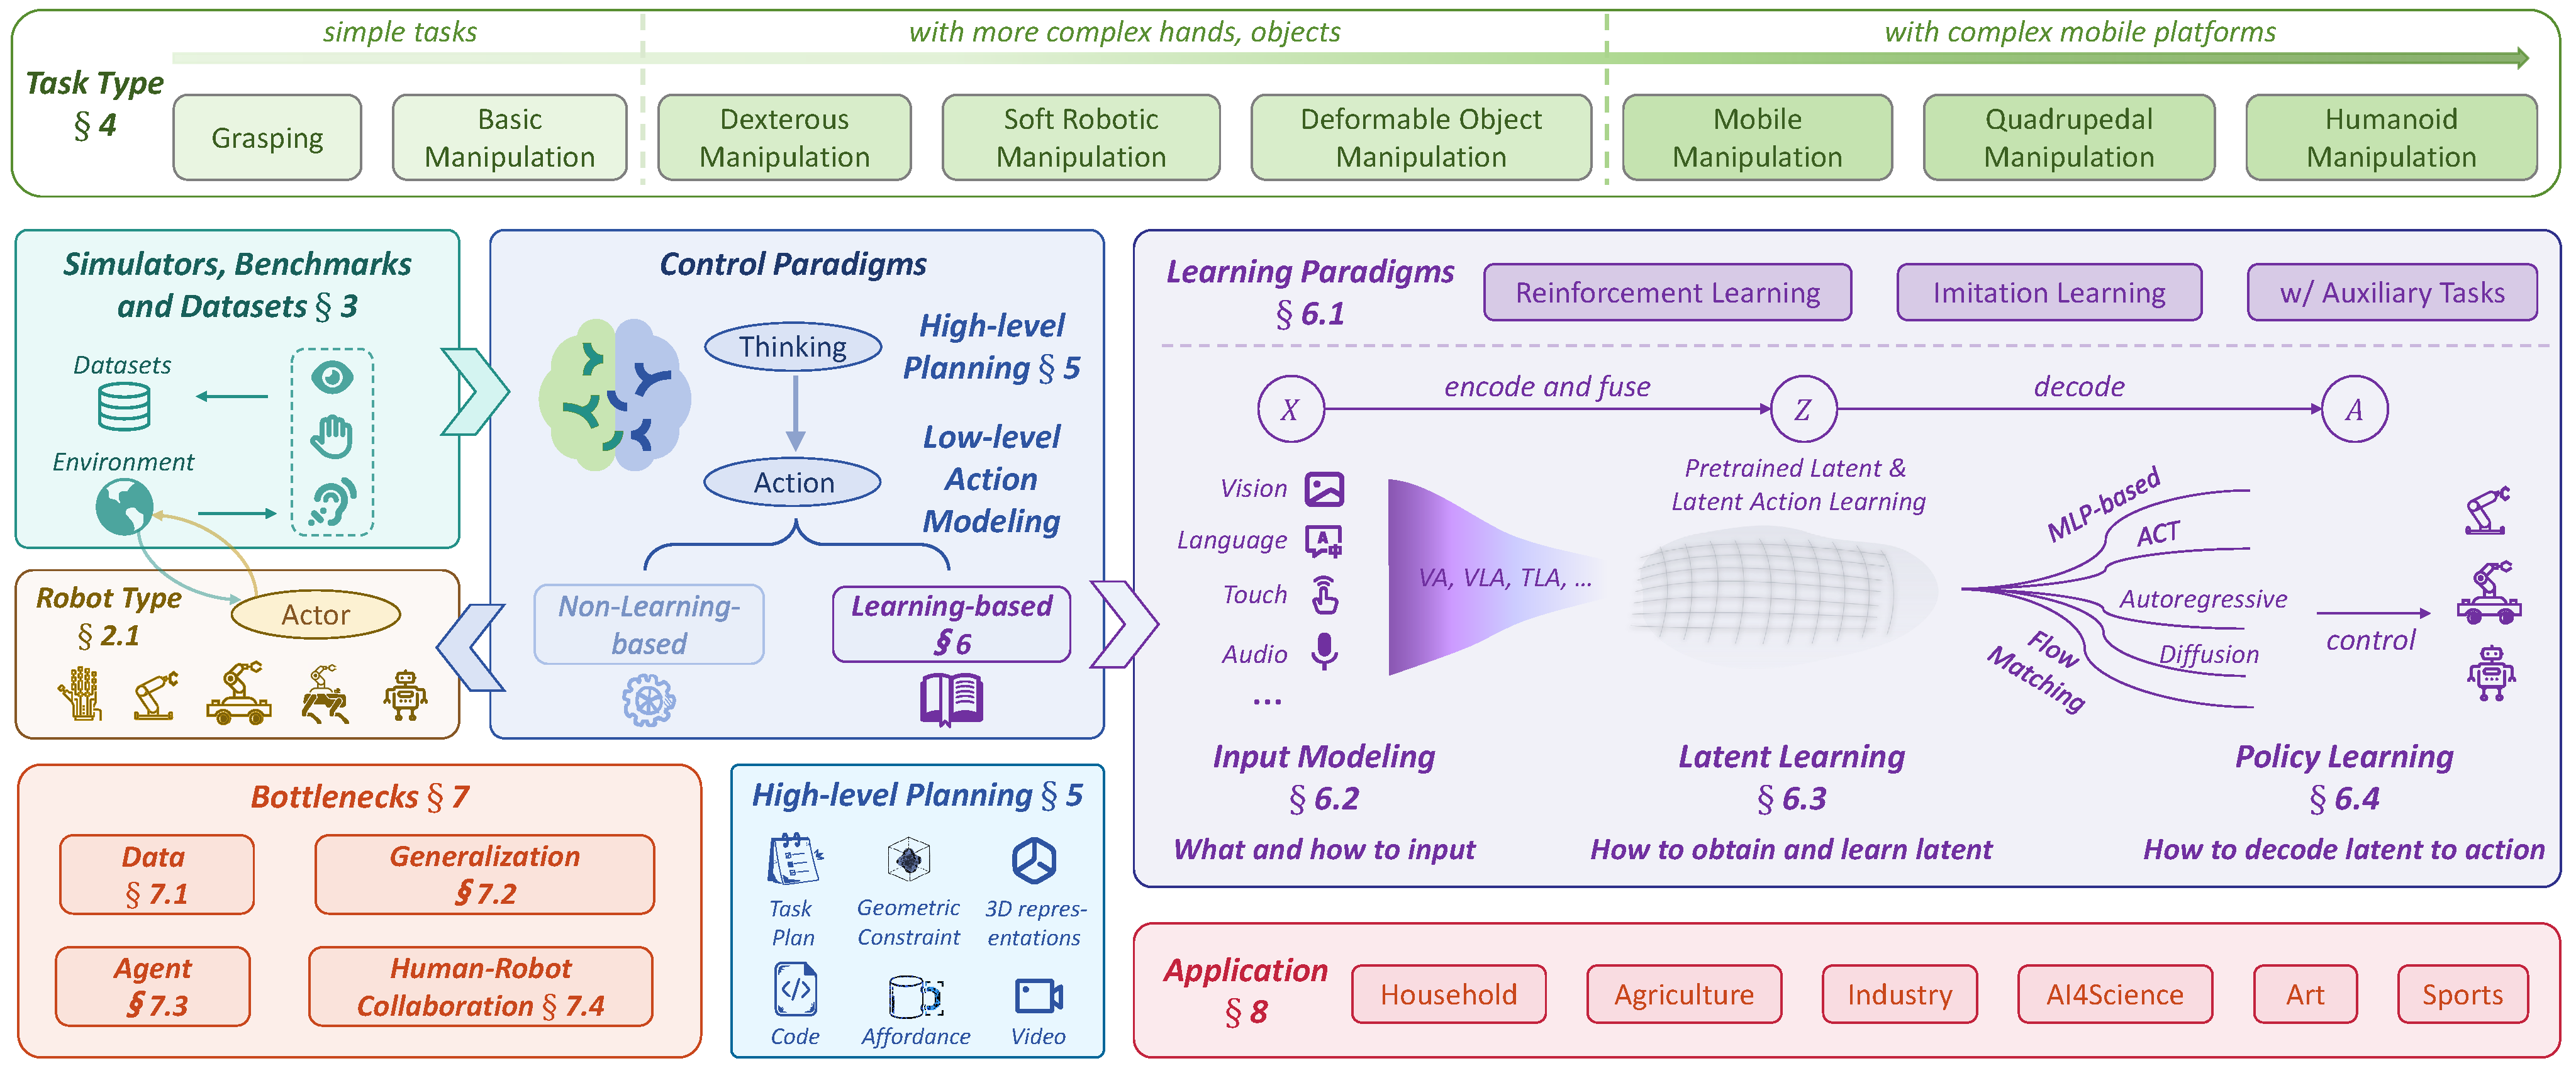
A comprehensive list of papers about Robot Manipulation, including papers, codes, and related websites.
CRISP – Compliant ROS2 Controllers for Learning-Based Manipulation Policies
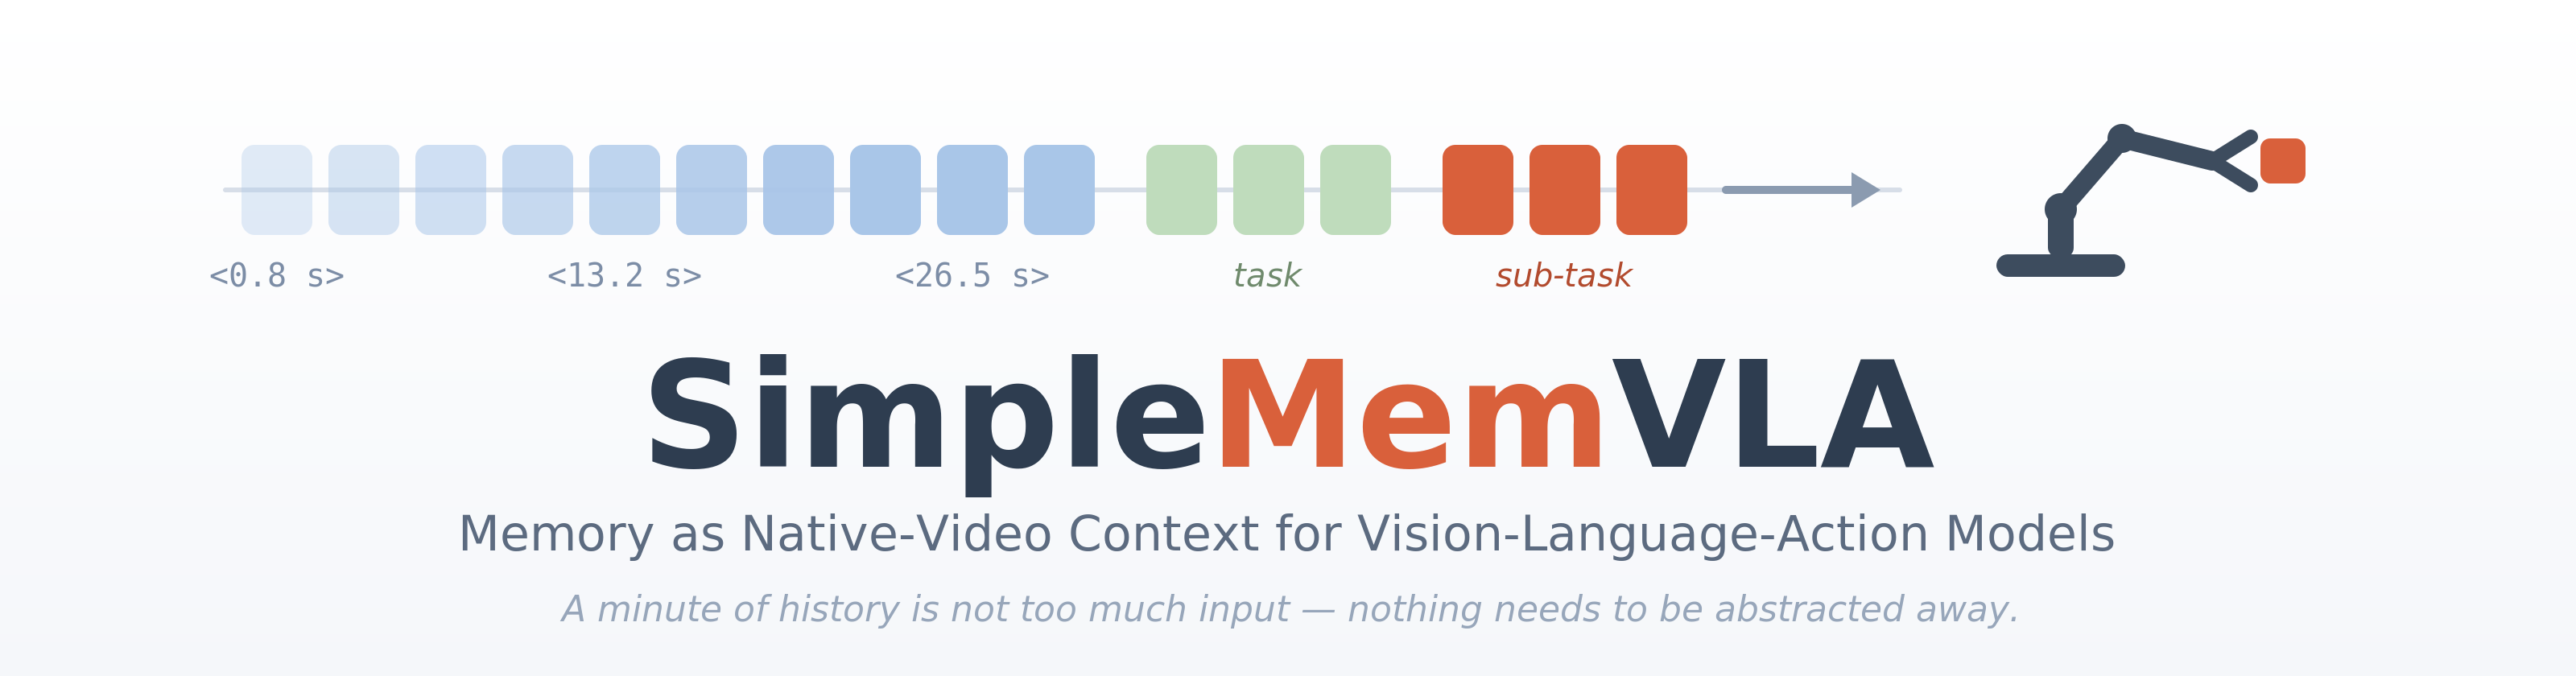
Native-video memory for vision-language-action models, using timestamped visual history and exact streaming inference for long-horizon robot manipulation.
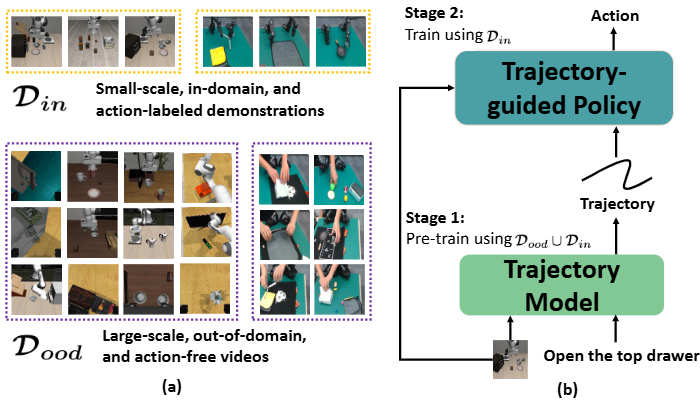
[CVPR 2025] Tra-MoE: Learning Trajectory Prediction Model from Multiple Domains for Adaptive Policy Conditioning
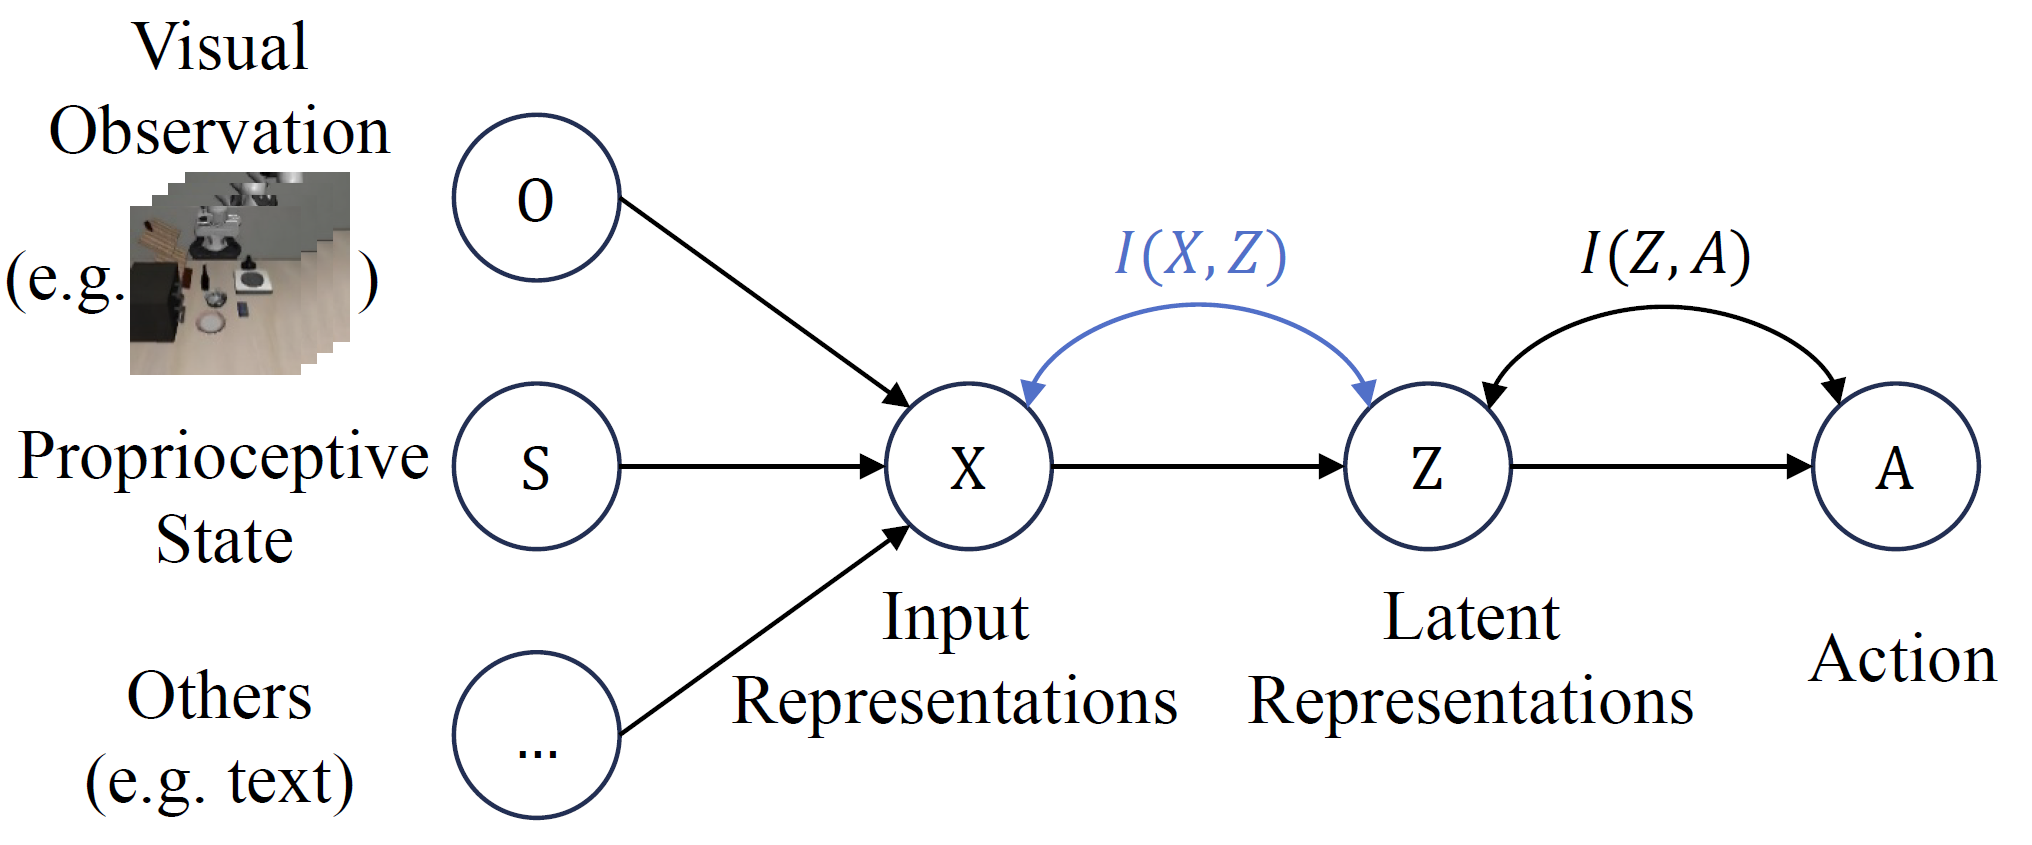
[ICML 2025] Rethinking Latent Redundancy in Behavior Cloning: An Information Bottleneck Approach for Robot Manipulation
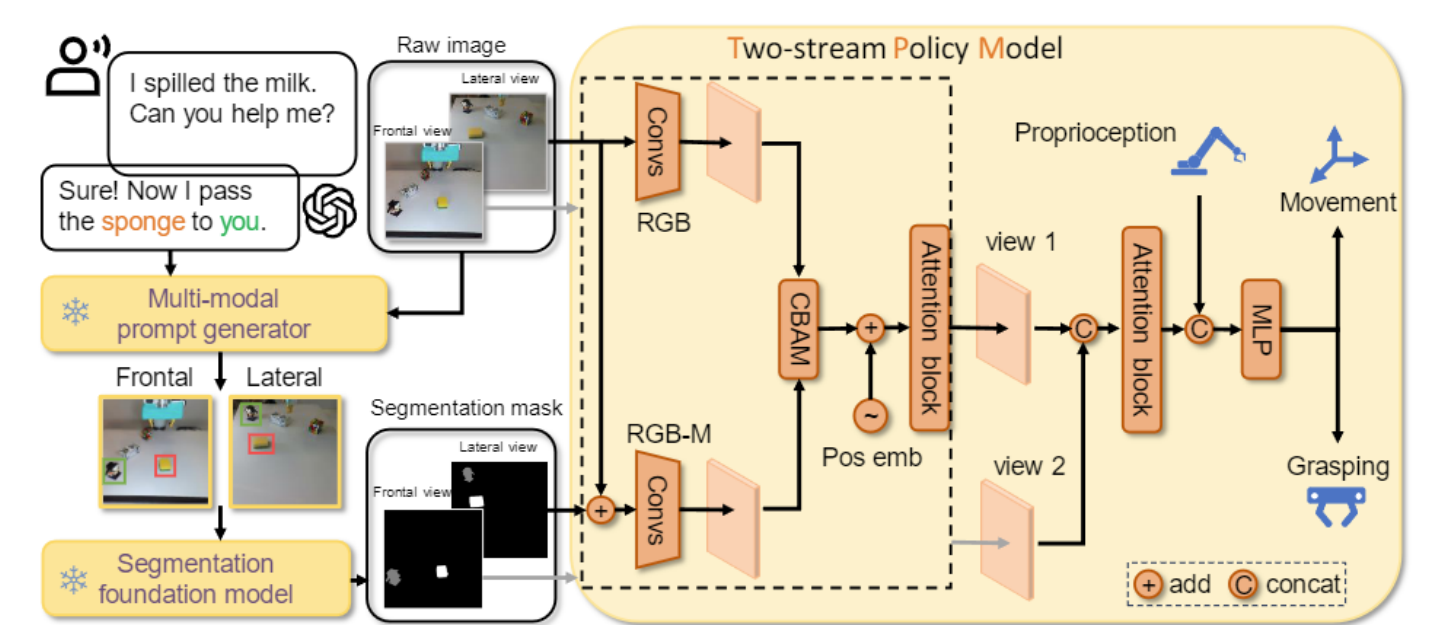
[WACV 2025 Oral] Transferring Foundation Models for Generalizable Robotic Manipulation
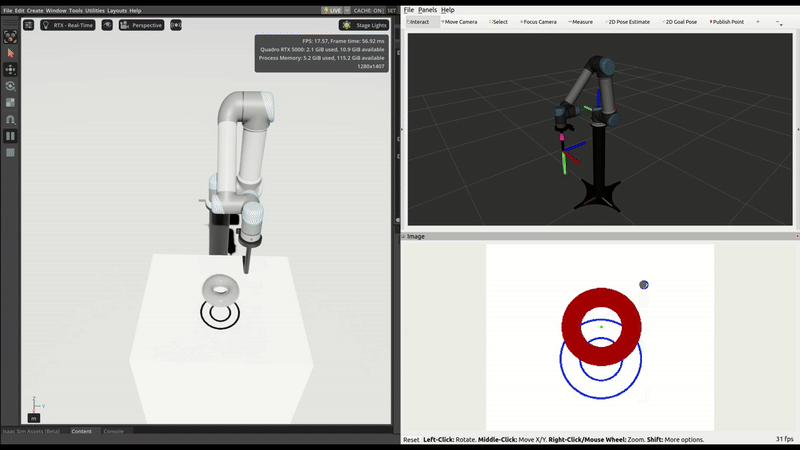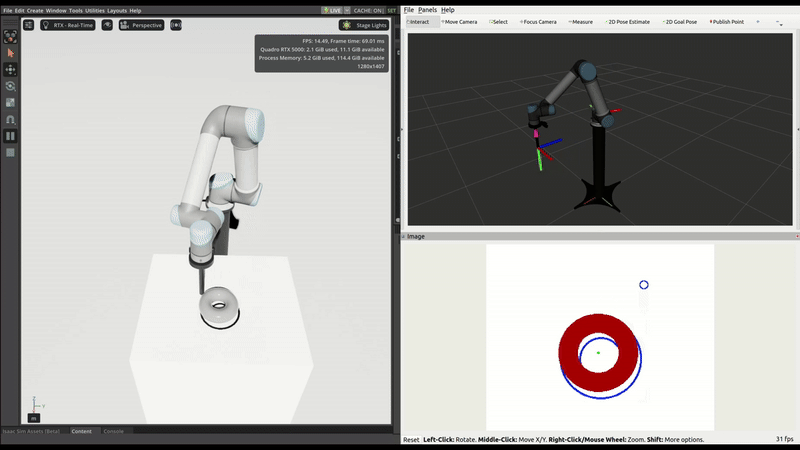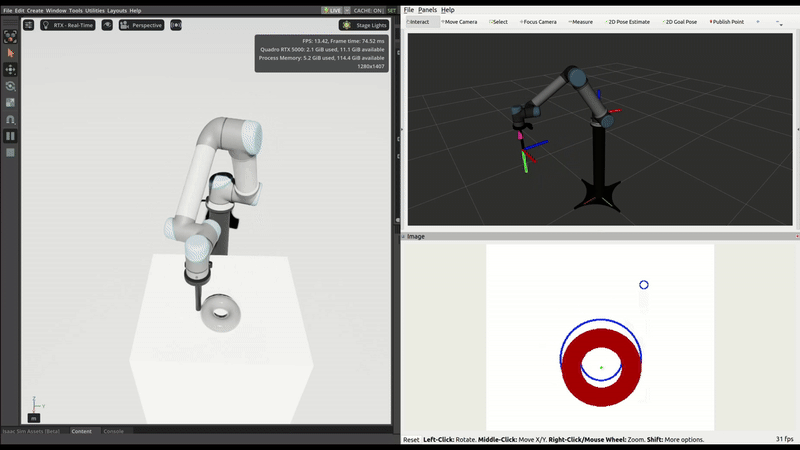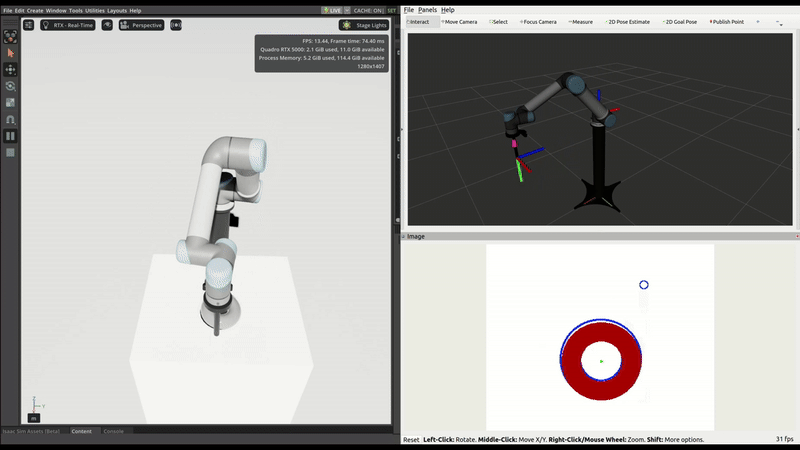
A complete imitation learning pipeline for bar alignment using the UR5 robot in NVIDIA Isaac Sim. Includes manual data collection with a game controller, dataset organization for LeRobot, diffusion policy training, and policy deployment through ROS2.
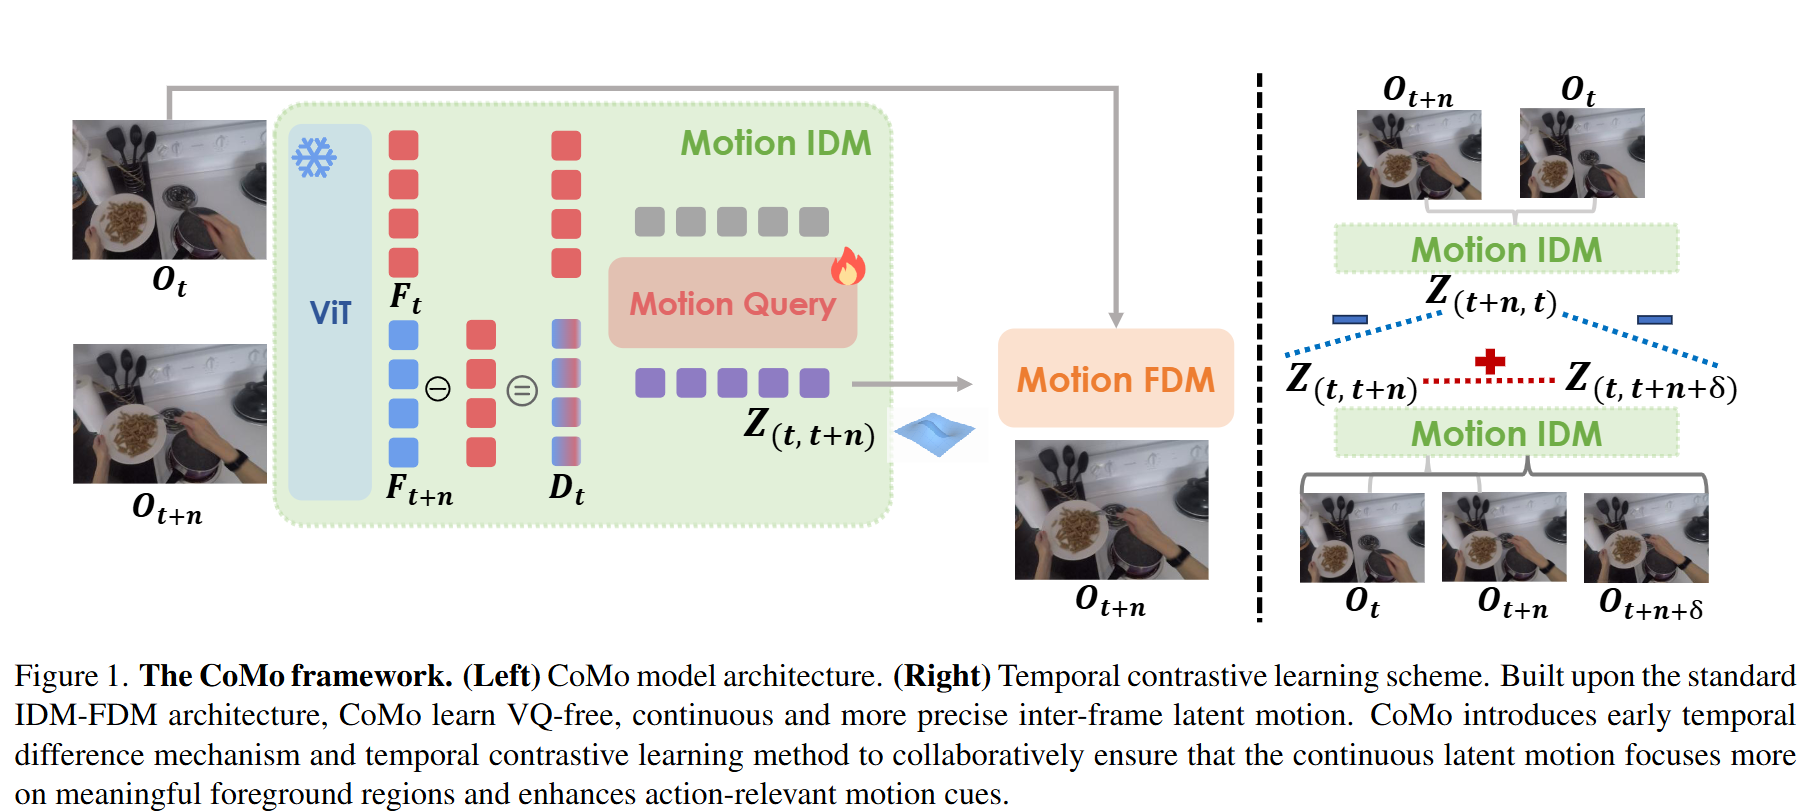
[CVPR 2026] CoMo: Learning Continuous Latent Motion from Internet Videos for Scalable Robot Learning
6DOF Robot Arm | ROS 2 Foxy based | 3D printed | open-source | designed for learning
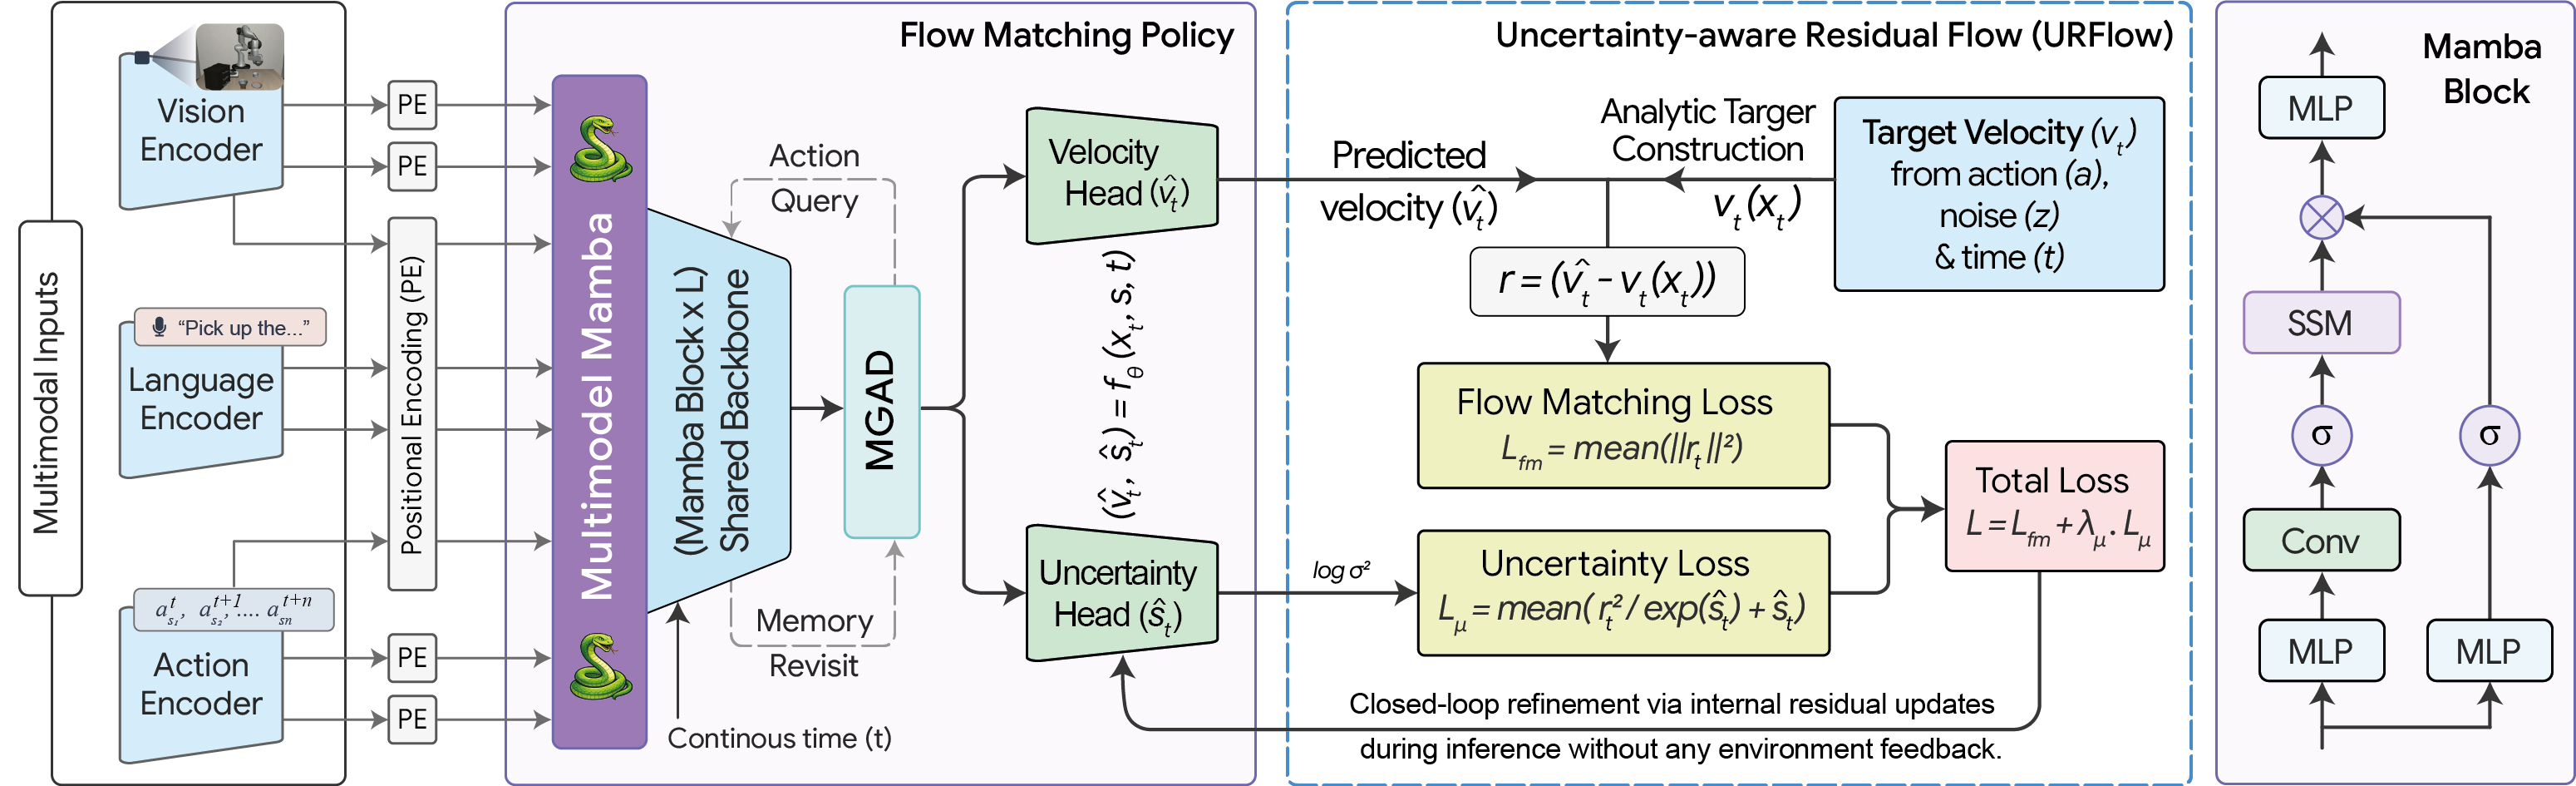
SUREFlow is a lightweight, Mamba-based vision-language-action model with 179M parameters for robot manipulation. Paper: https://arxiv.org/pdf/2607.10504
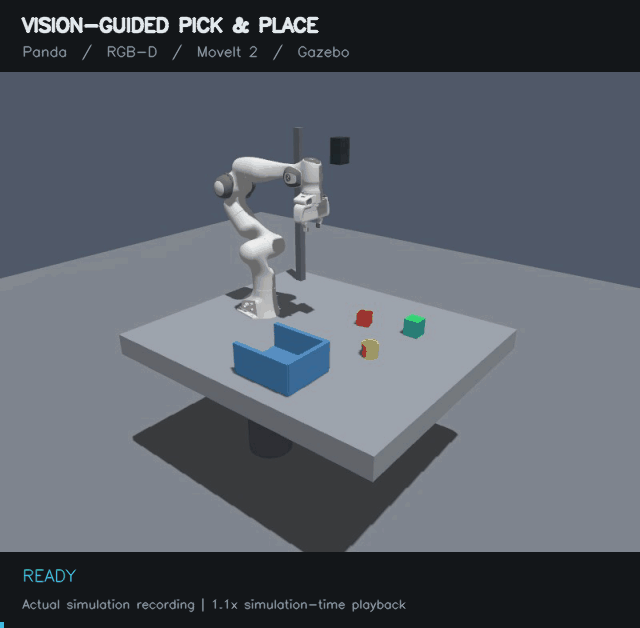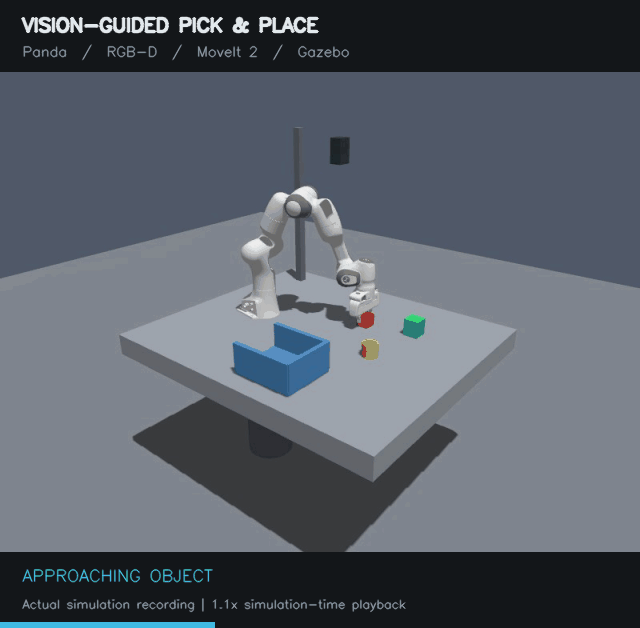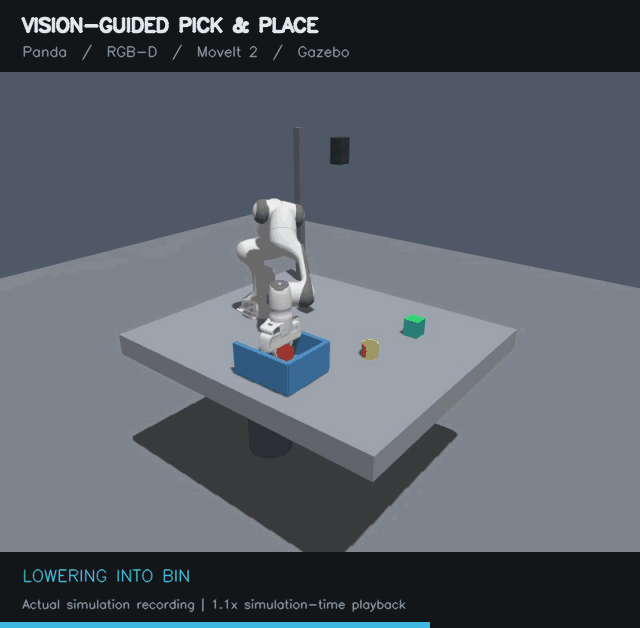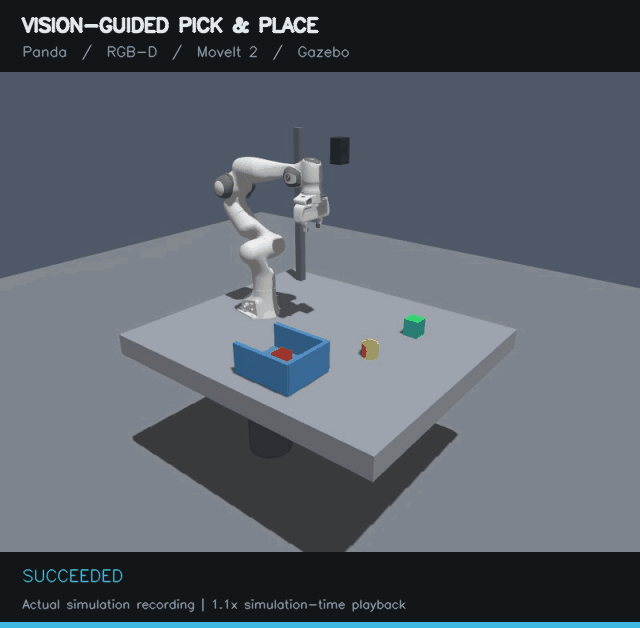
ROS 2 vision-guided pick-and-place simulation with a Panda arm, RGB-D perception, MoveIt 2, and Gazebo.
WFM-Eval: An Evaluation Framework for Video World Models in Robotic Manipulation (VWM & FMEA @ CVPR 2026)