GVINS-Dataset
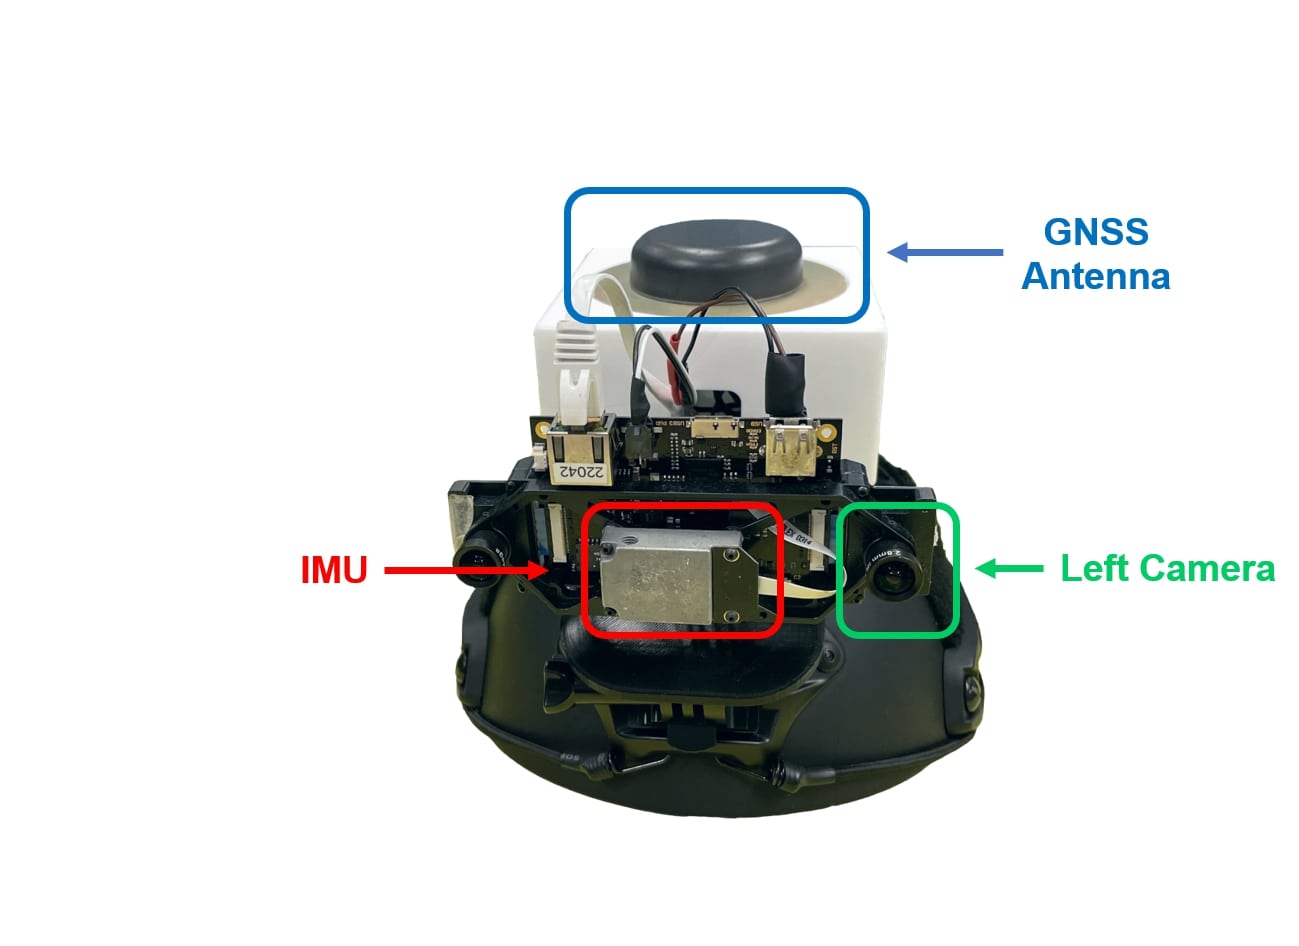
A dataset containing synchronized visual, inertial and GNSS raw measurements.
- 268
- C++
- 3 mo ago
A dataset containing synchronized visual, inertial and GNSS raw measurements.
NVIDIA-accelerated, deep learned stereo disparity estimation
ROS 2 packages based on NVIDIA libArgus library for NVIDIA-accelerated CSI camera support.
NVIDIA-accelerated, deep learned depth segmentation and obstacle field ranging using Bi3D
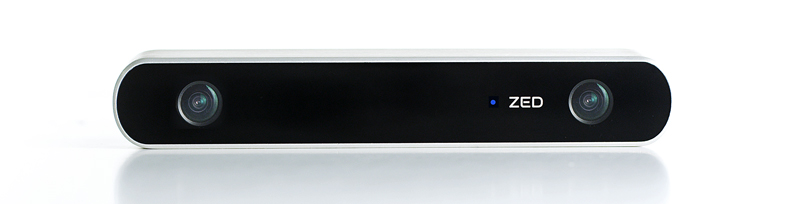
Native stereo capture from the StereoLabs ZED USB 3 series of stereo cameras with OpenCV in Python
Code for "Unsupervised Domain Adaptation for Depth Prediction from Images" - Coming Soon...