Alternatives to BehaviorTree/BehaviorTree.ROS




pinocchio
A fast and flexible implementation of Rigid Body Dynamics algorithms and their analytical derivatives
- 3.9k
- C++
- BSD-2-Clause
- 8 d ago

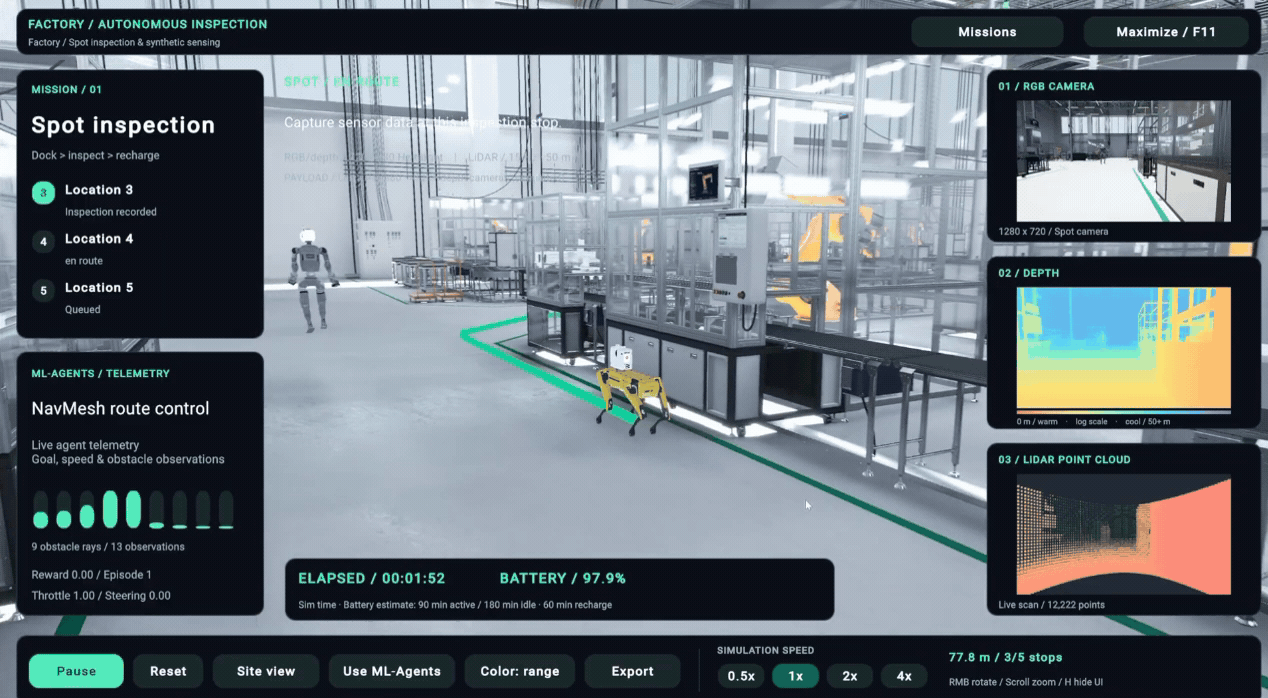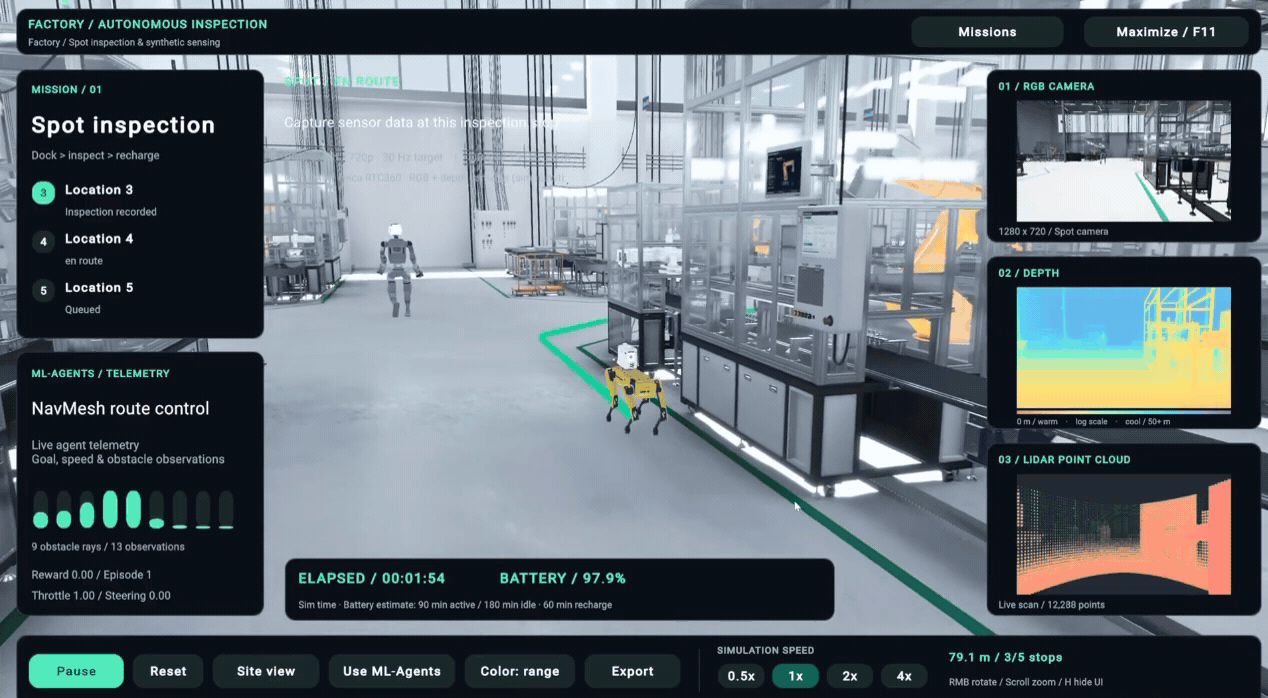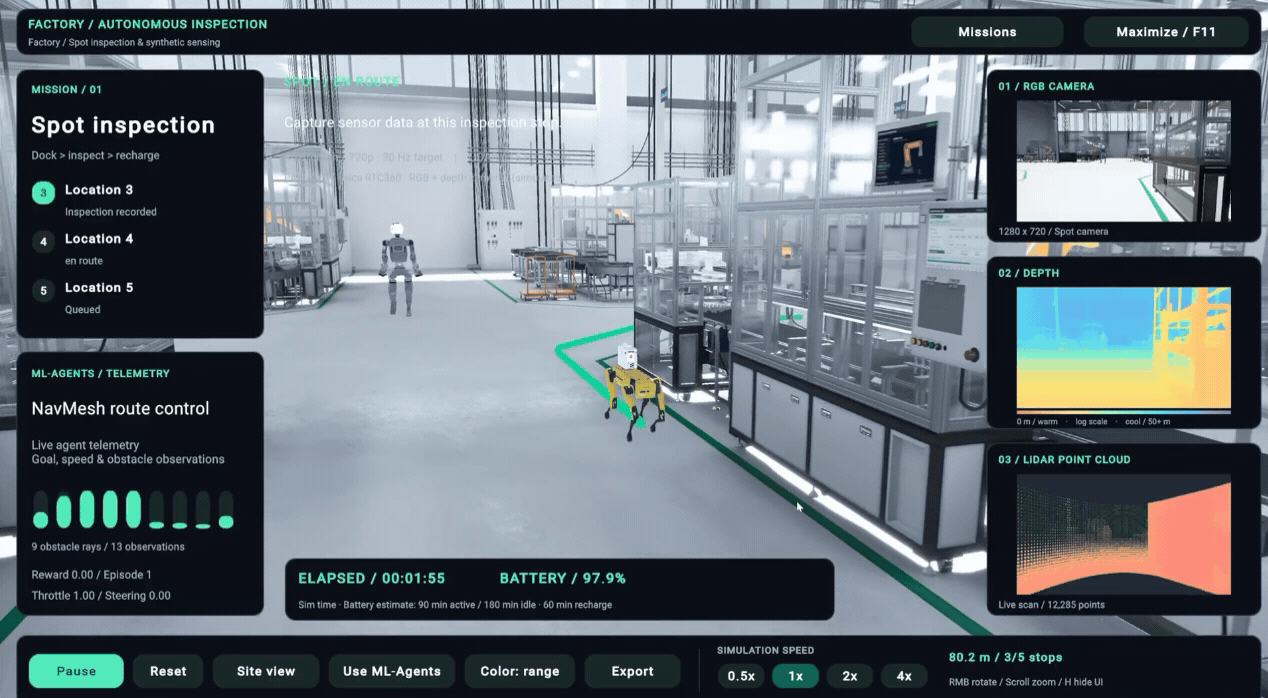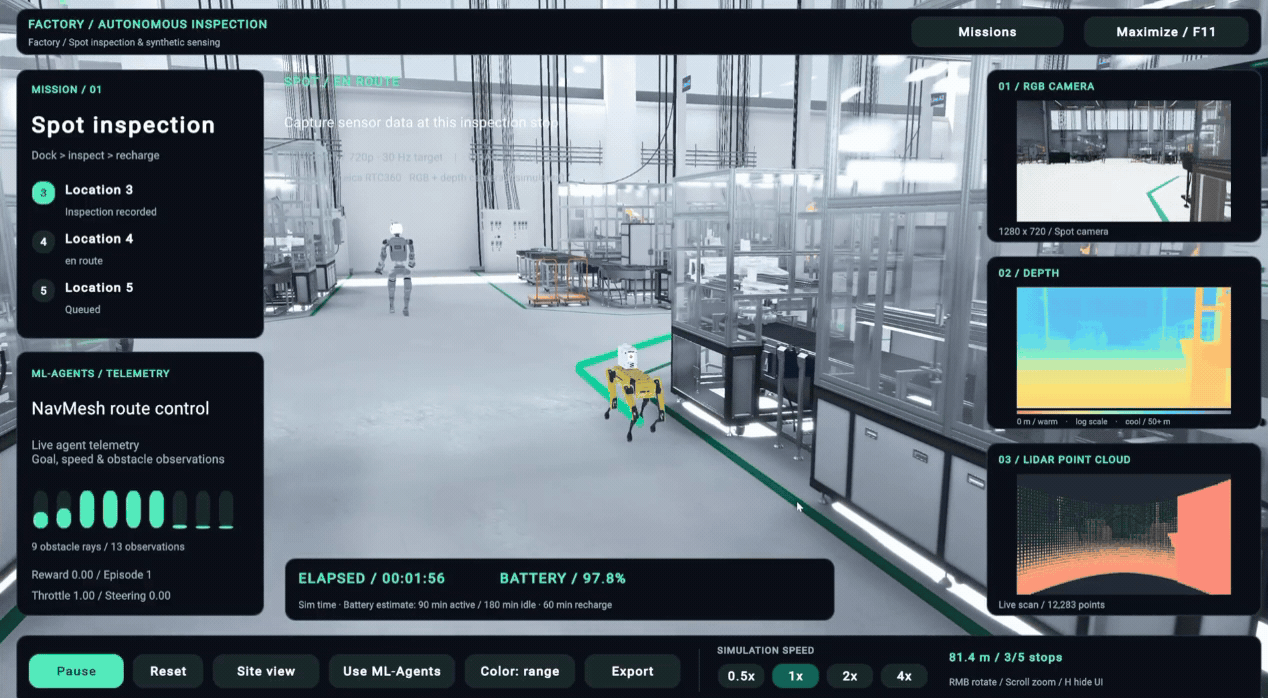
Unity-Robotics-Hub
Central repository for tools, tutorials, resources, and documentation for robotics simulation in Unity.
- 2.6k
- C#
- 2 mo ago

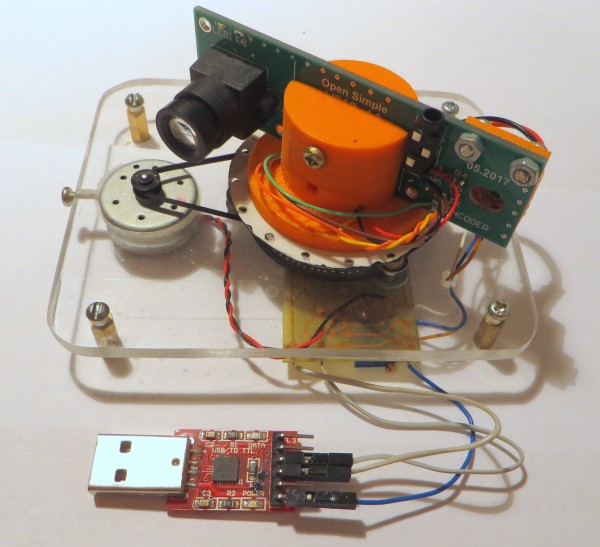


Side by side
| Name | Stars | License | Language | Last change | In common | Compare |
|---|---|---|---|---|---|---|
| BehaviorTree/BehaviorTree.ROS | 154 | MIT | C++ | 3 y ago | ||
| ArduPilot/ardupilot | 16k | GPL-3.0 | C++ | 1 d ago | ros | Compare |
| carla-simulator/carla | 15k | MIT | C++ | 4 h ago | ros | Compare |
| cyberbotics/webots | 4.8k | Apache-2.0 | C++ | 14 h ago | ros | Compare |
| MichaelGrupp/evo | 4.4k | GPL-3.0 | Python | 5 d ago | ros | Compare |
| BehaviorTree/BehaviorTree.CPP | 4.3k | MIT | C++ | 8 d ago | ros | Compare |
| introlab/rtabmap | 4.1k | None declared | C++ | 4 d ago | ros | Compare |
| stack-of-tasks/pinocchio | 3.9k | BSD-2-Clause | C++ | 8 d ago | ros | Compare |
| Unity-Technologies/Unity-Robotics-Hub | 2.6k | None declared | C# | 2 mo ago | ros | Compare |
| iliasam/OpenSimpleLidar | 2.6k | MIT | C | 16 mo ago | ros | Compare |
| lgsvl/simulator | 2.5k | None declared | C# | 4 y ago | ros | Compare |
| leggedrobotics/darknet_ros | 2.4k | BSD-3-Clause | C++ | 2 y ago | ros | Compare |
| ArduPilot/MissionPlanner | 2.4k | GPL-3.0 | C# | 2 d ago | ros | Compare |