ros



pinocchio
A fast and flexible implementation of Rigid Body Dynamics algorithms and their analytical derivatives
- 3.9k
- C++
- BSD-2-Clause
- 5 d ago

Unity-Robotics-Hub
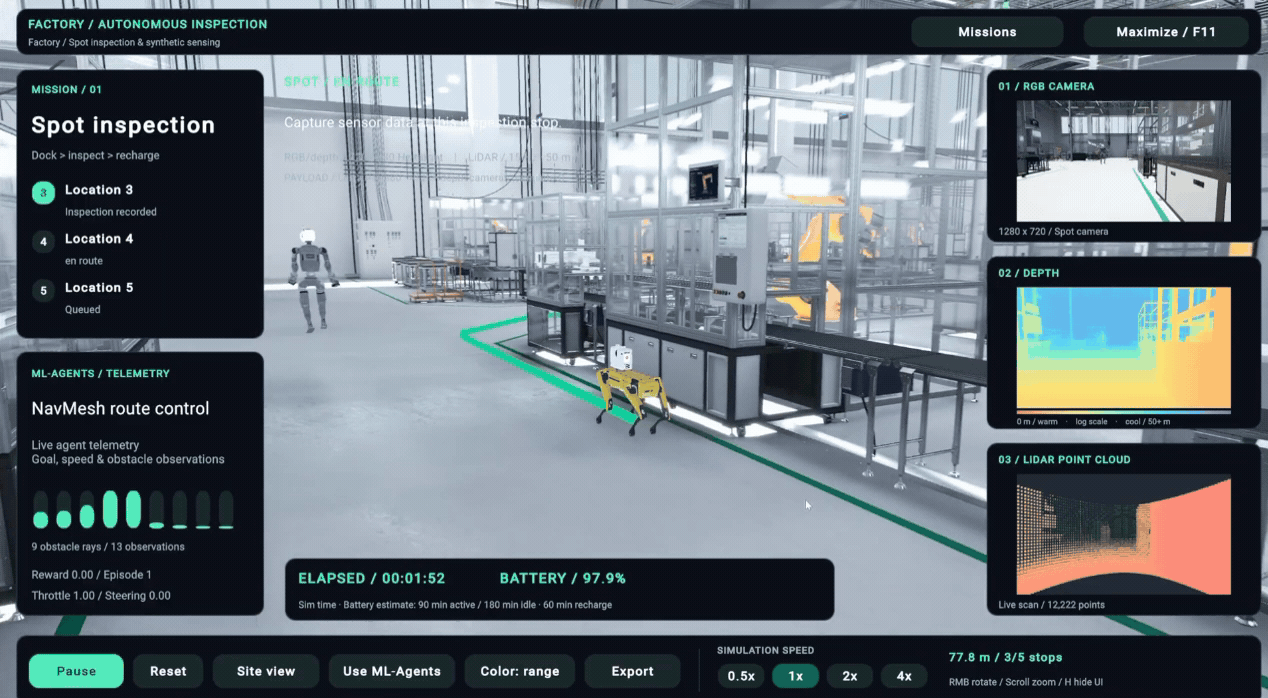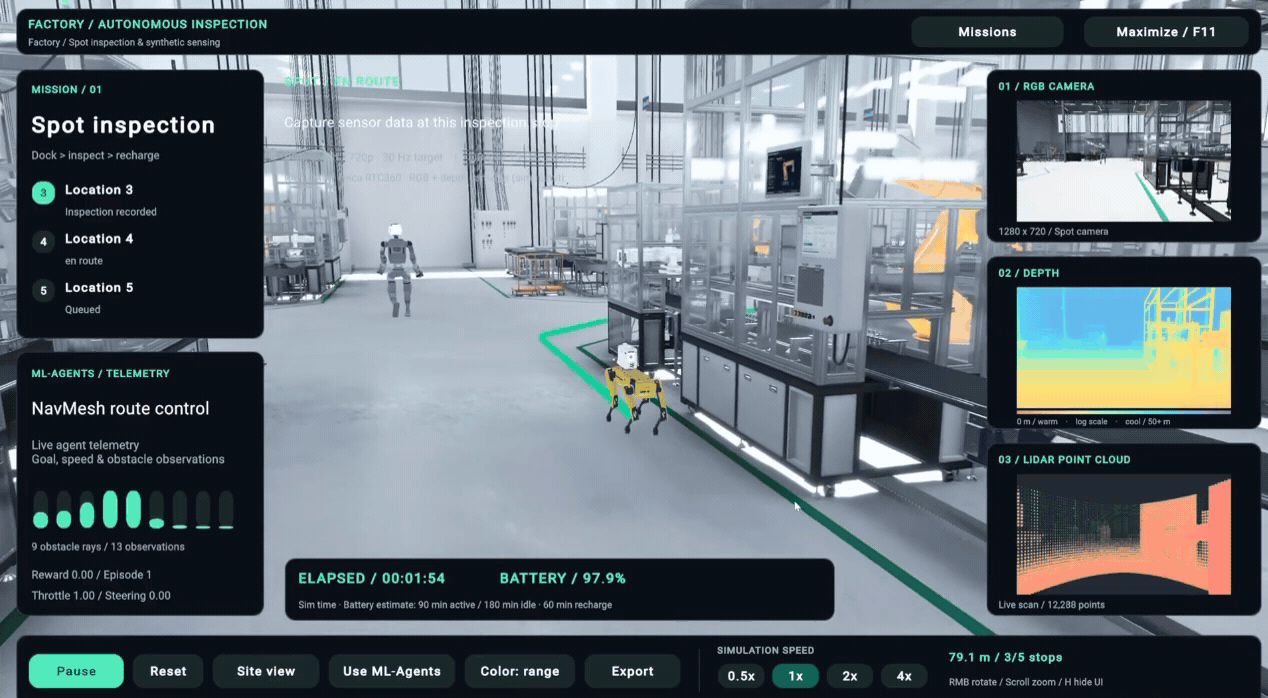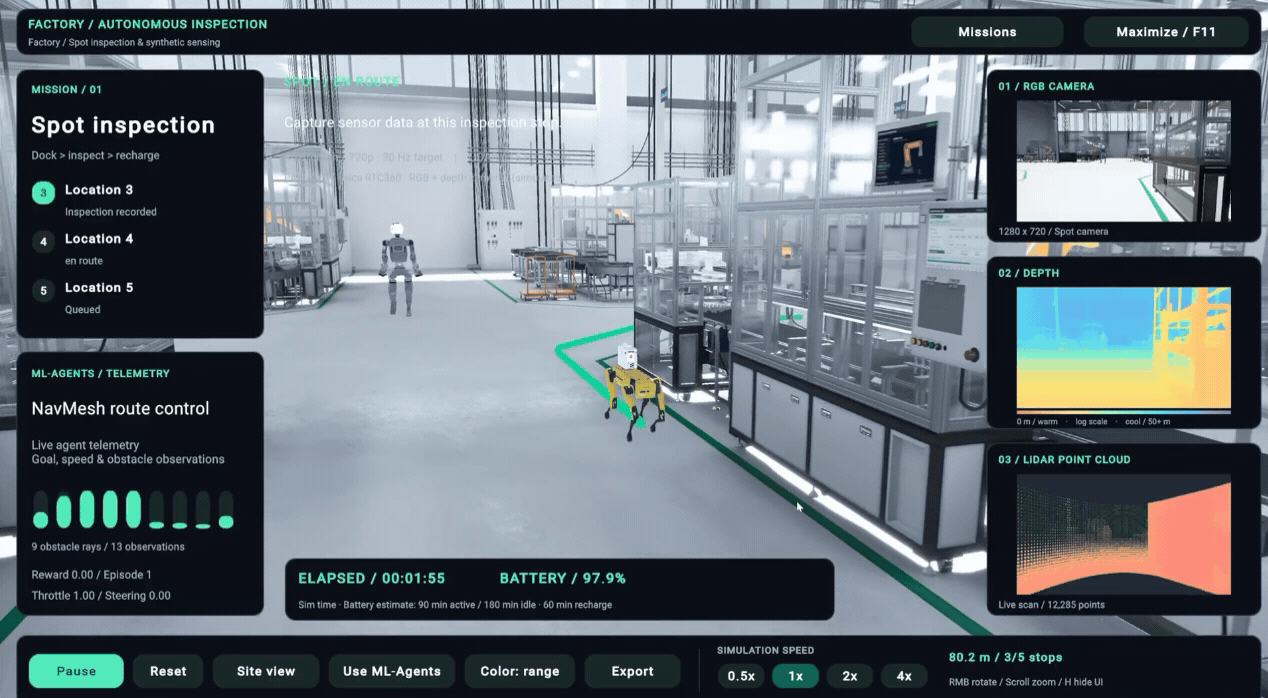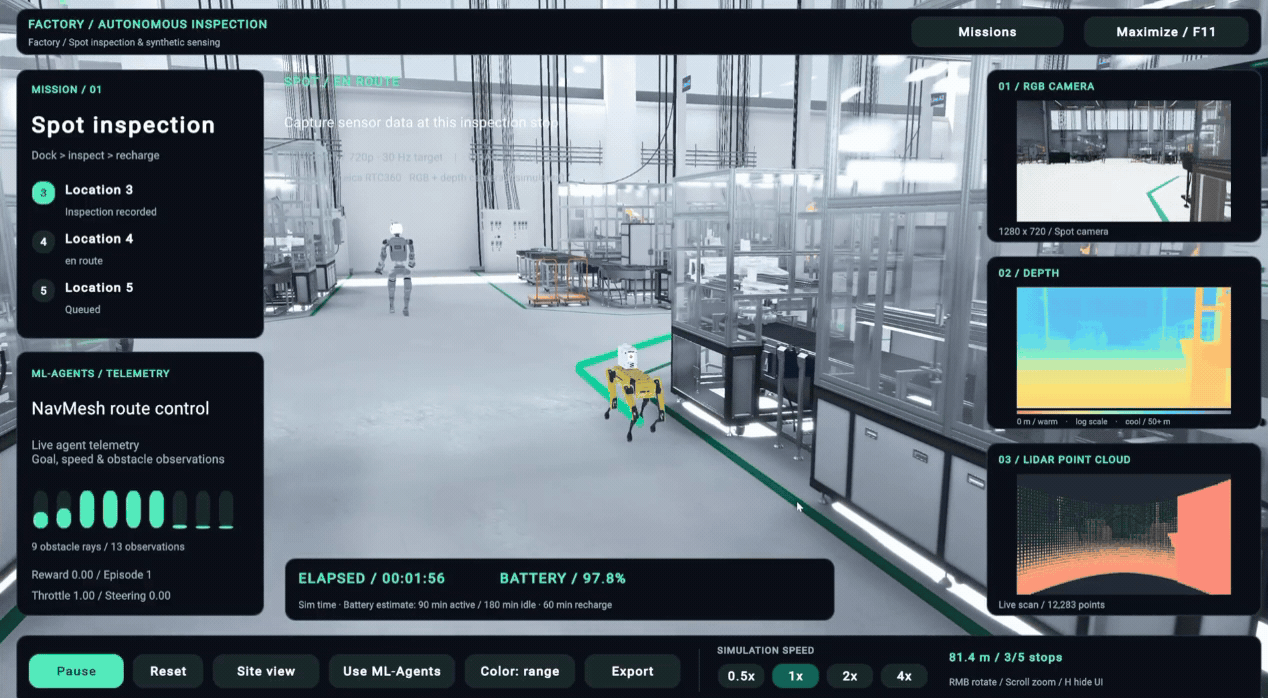
Central repository for tools, tutorials, resources, and documentation for robotics simulation in Unity.
- 2.6k
- C#
- 8 wk ago

copper-rs
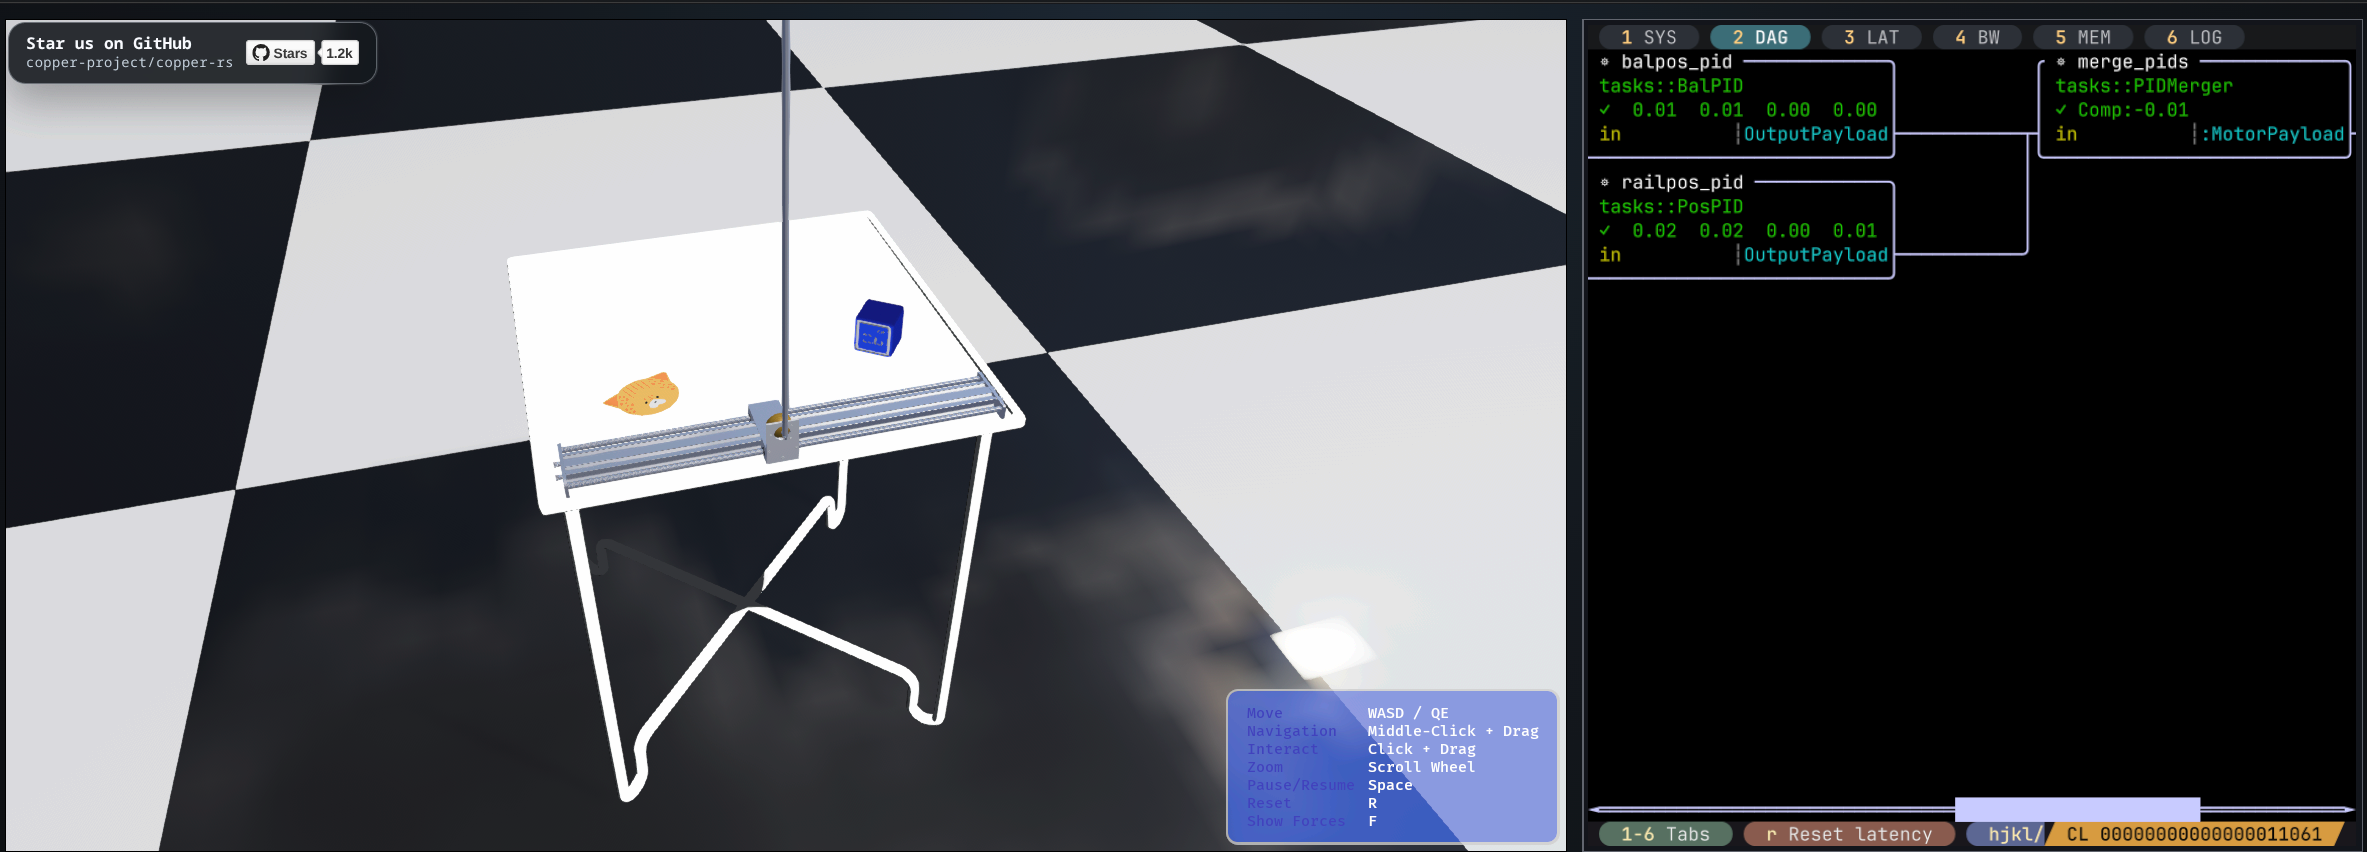
Copper is an operating system for robots - build, run, and replay your entire robot deterministically.
- 1.6k
- Rust
- Apache-2.0
- 1 d ago

crocoddyl
Crocoddyl is an optimal control library for robot control under contact sequence. Its solver is based on various efficient Differential Dynamic Programming (DDP)-like algorithms
- 1.3k
- C++
- BSD-3-Clause
- 2 d ago


bonsai
Rust implementation of behavior trees for deterministic AI (now with Python bindings)
- 1.1k
- Rust
- MIT
- 8 wk ago


awesome-weekly-robotics
A list of projects that were or will be featured in Weekly Robotics newsletter
- 1.1k
- 6 mo ago


ifopt
An Eigen-based, light-weight C++ Interface to Nonlinear Programming Solvers (Ipopt, Snopt)
- 871
- C++
- BSD-3-Clause
- 13 mo ago


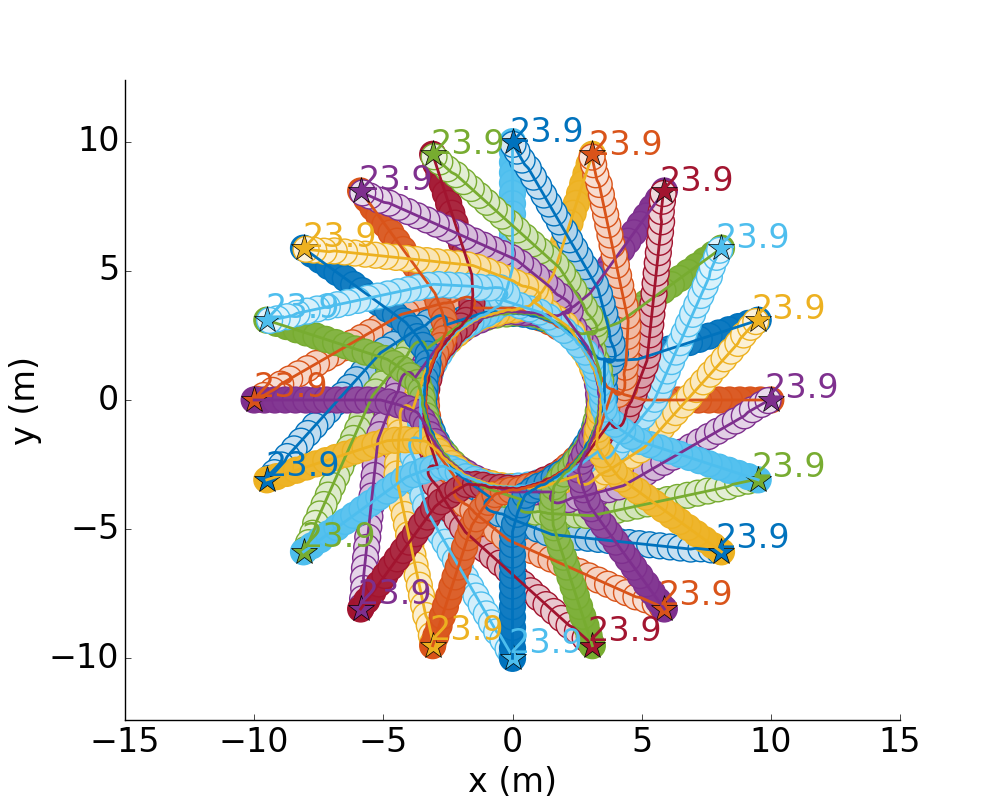
cadrl_ros
ROS package for dynamic obstacle avoidance for ground robots trained with deep RL
- 726
- Python
- 5 y ago

ros-sensor-fusion-tutorial
An in-depth step-by-step tutorial for implementing sensor fusion with robot_localization! 🛰
- 719
- MIT
- 8 y ago


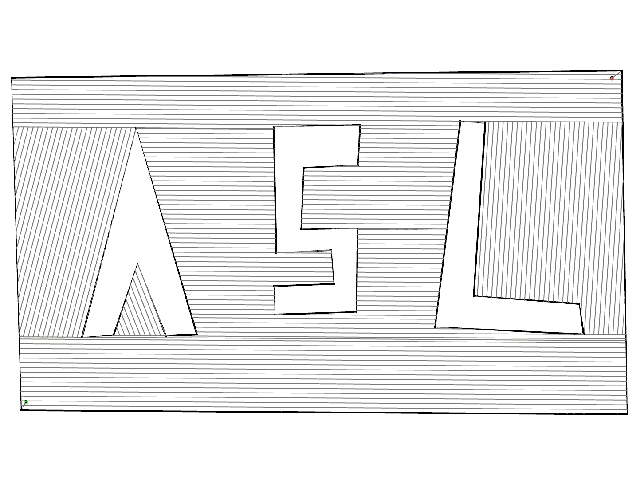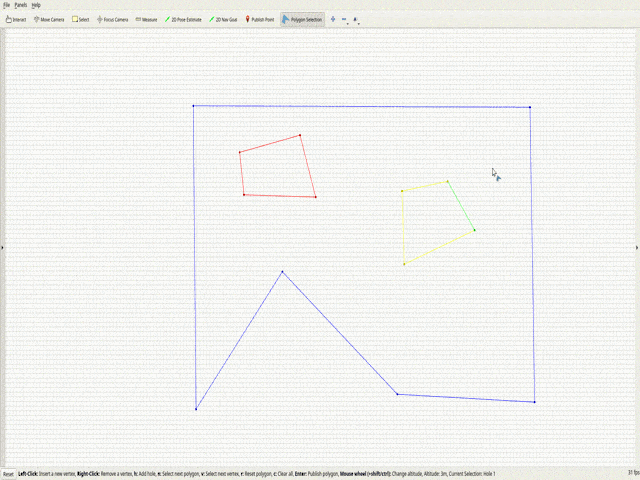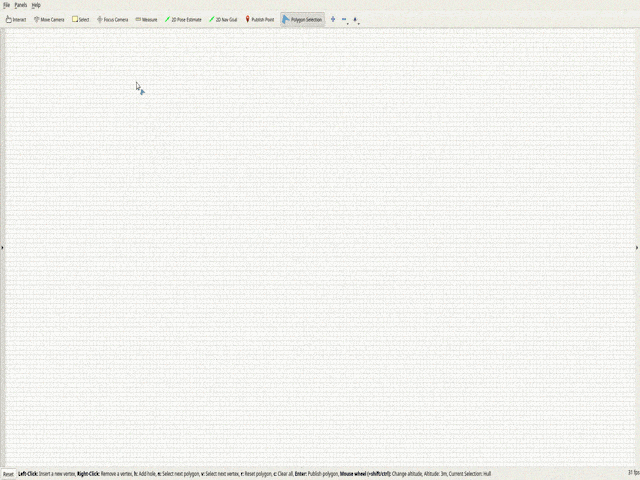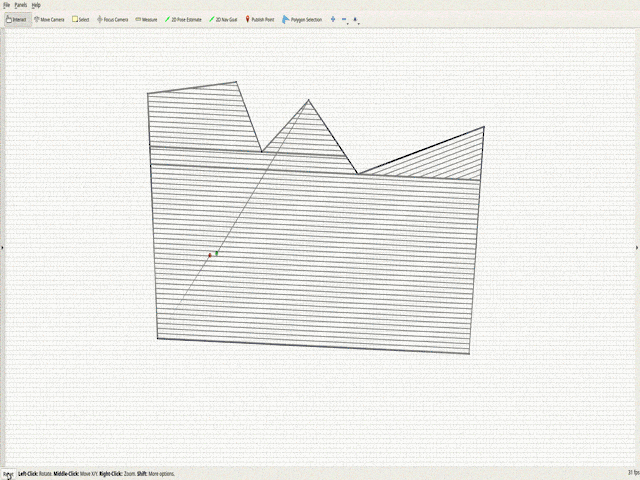


luos_engine
Open-source and real-time orchestrator for cyber-physical-systems, to easily design, test and deploy embedded applications and digital twins.
- 547
- C
- MIT
- 7 wk ago



lidar_obstacle_detector
Real-time 3D LiDAR obstacle detection, tracking & trajectory prediction for ROS 1 / ROS 2: ground segmentation, clustering, 2.5D occupancy, optional GPU CenterPoint (TensorRT). ~10 ms/scan on one CPU core.
- 424
- C++
- MIT
- 4 wk ago


isaac_ros_object_detection
NVIDIA-accelerated, deep learned model support for image space object detection
- 205
- C++
- Apache-2.0
- 17 h ago

fiss_planner
FISS & FISS+: Fast Iterative Search and Sampling trajectory planners for autonomous driving (with FOP baselines). C++17 core, Python, ROS 2 / ROS 1, Lanelet2, CARLA, MPC
- 177
- C++
- Apache-2.0
- 2 wk ago
rmader
Decentralized Multiagent Trajectory Planner Robust to Communication Delay
- 130
- C++
- BSD-3-Clause
- 2 y ago
deep-reinforcement-learning-drone-control
A drone control system based on deep reinforcement learning with Tensorflow and ROS
- 126
- Python
- 9 y ago

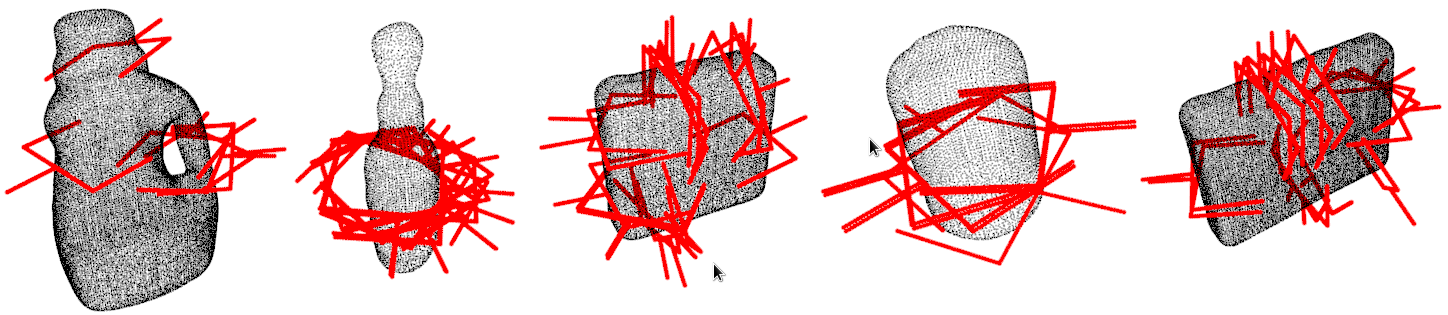

maps
Inspect, compare and align multiple grid maps in an intuitive & fast GUI
- 120
- Rust
- Apache-2.0
- 4 wk ago
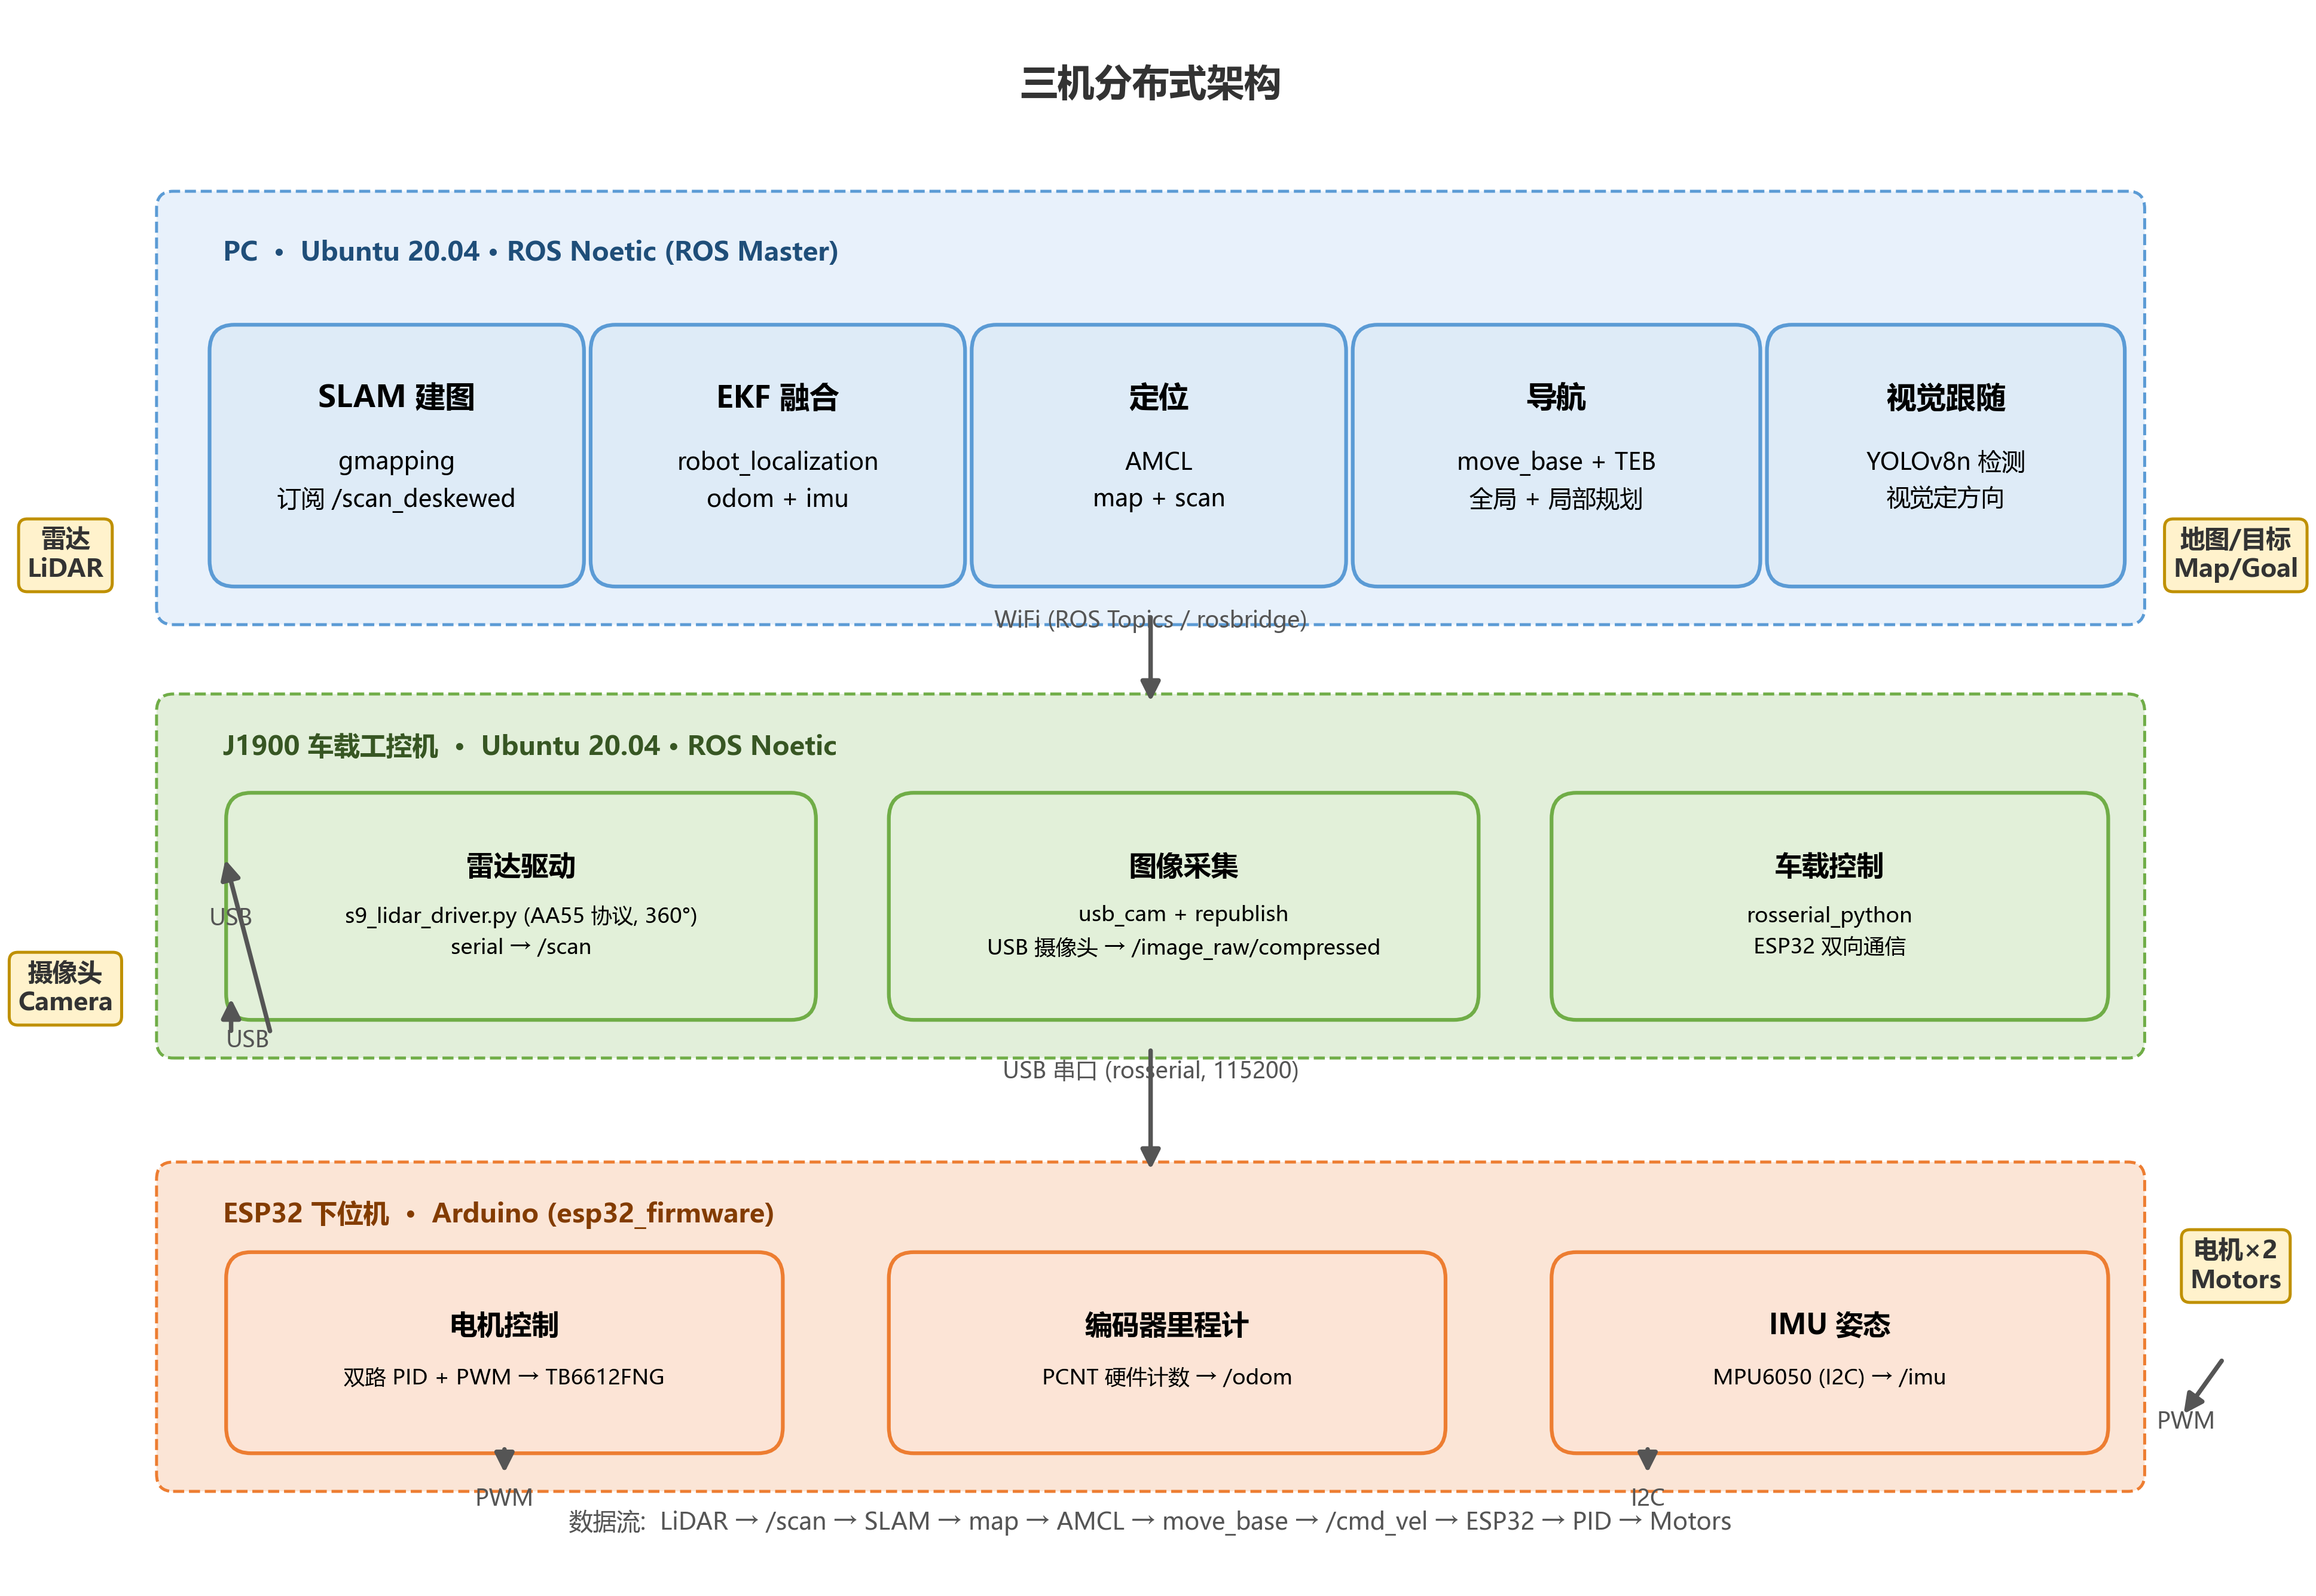
ROS
ROS Noetic 两轮差速自主移动机器人:ESP32 底盘(PID/编码器/IMU) + J1900 车载(LiDAR/相机) + PC(SLAM/导航/人体跟随),三机分布式全链路开源实现
- 106
- C++
- MIT
- 5 wk ago