lidar


awesome-robotic-tooling
Tooling for professional robotic development in C++ and Python with a touch of ROS, autonomous driving and aerospace.
- 3.9k
- CC0-1.0
- 3 y ago




glim
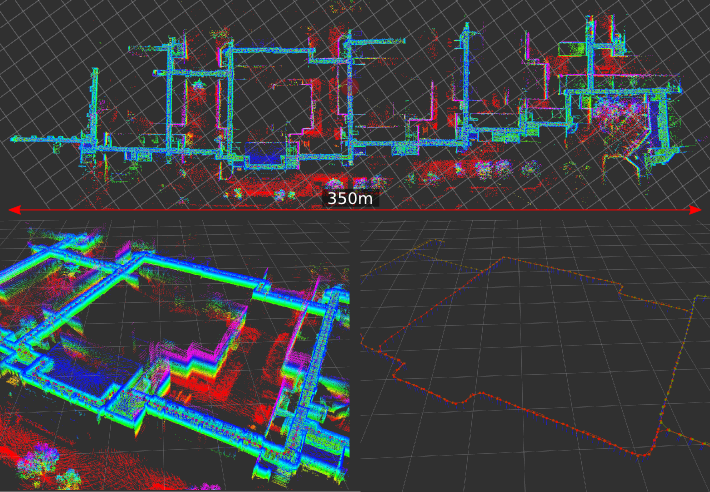
GLIM: versatile and extensible point cloud-based 3D localization and mapping framework
- 1.9k
- C++
- MIT
- 6 wk ago

lidar_camera_calibration
ROS package to find a rigid-body transformation between a LiDAR and a camera for "LiDAR-Camera Calibration using 3D-3D Point correspondences"
- 1.8k
- C++
- GPL-3.0
- 13 mo ago


direct_visual_lidar_calibration
A toolbox for target-less LiDAR-camera calibration [ROS1/ROS2]
- 1.6k
- C++
- 4 mo ago
Photogrammetry-Guide
Photogrammetry Guide. Photogrammetry is widely used for Aerial surveying, Agriculture, Architecture, 3D Games, Robotics, Archaeology, Construction, Emergency management, and Medical.
- 1.5k
- Python
- 17 mo ago


awesome-lidar
😎 Awesome LIDAR list. The list includes LIDAR manufacturers, datasets, point cloud-processing algorithms, point cloud frameworks and simulators.
- 1.4k
- CC0-1.0
- 2 wk ago


Complex-YOLOv4-Pytorch
The PyTorch Implementation based on YOLOv4 of the paper: "Complex-YOLO: Real-time 3D Object Detection on Point Clouds"
- 1.3k
- Python
- GPL-3.0
- 2 y ago


direct_lidar_inertial_odometry
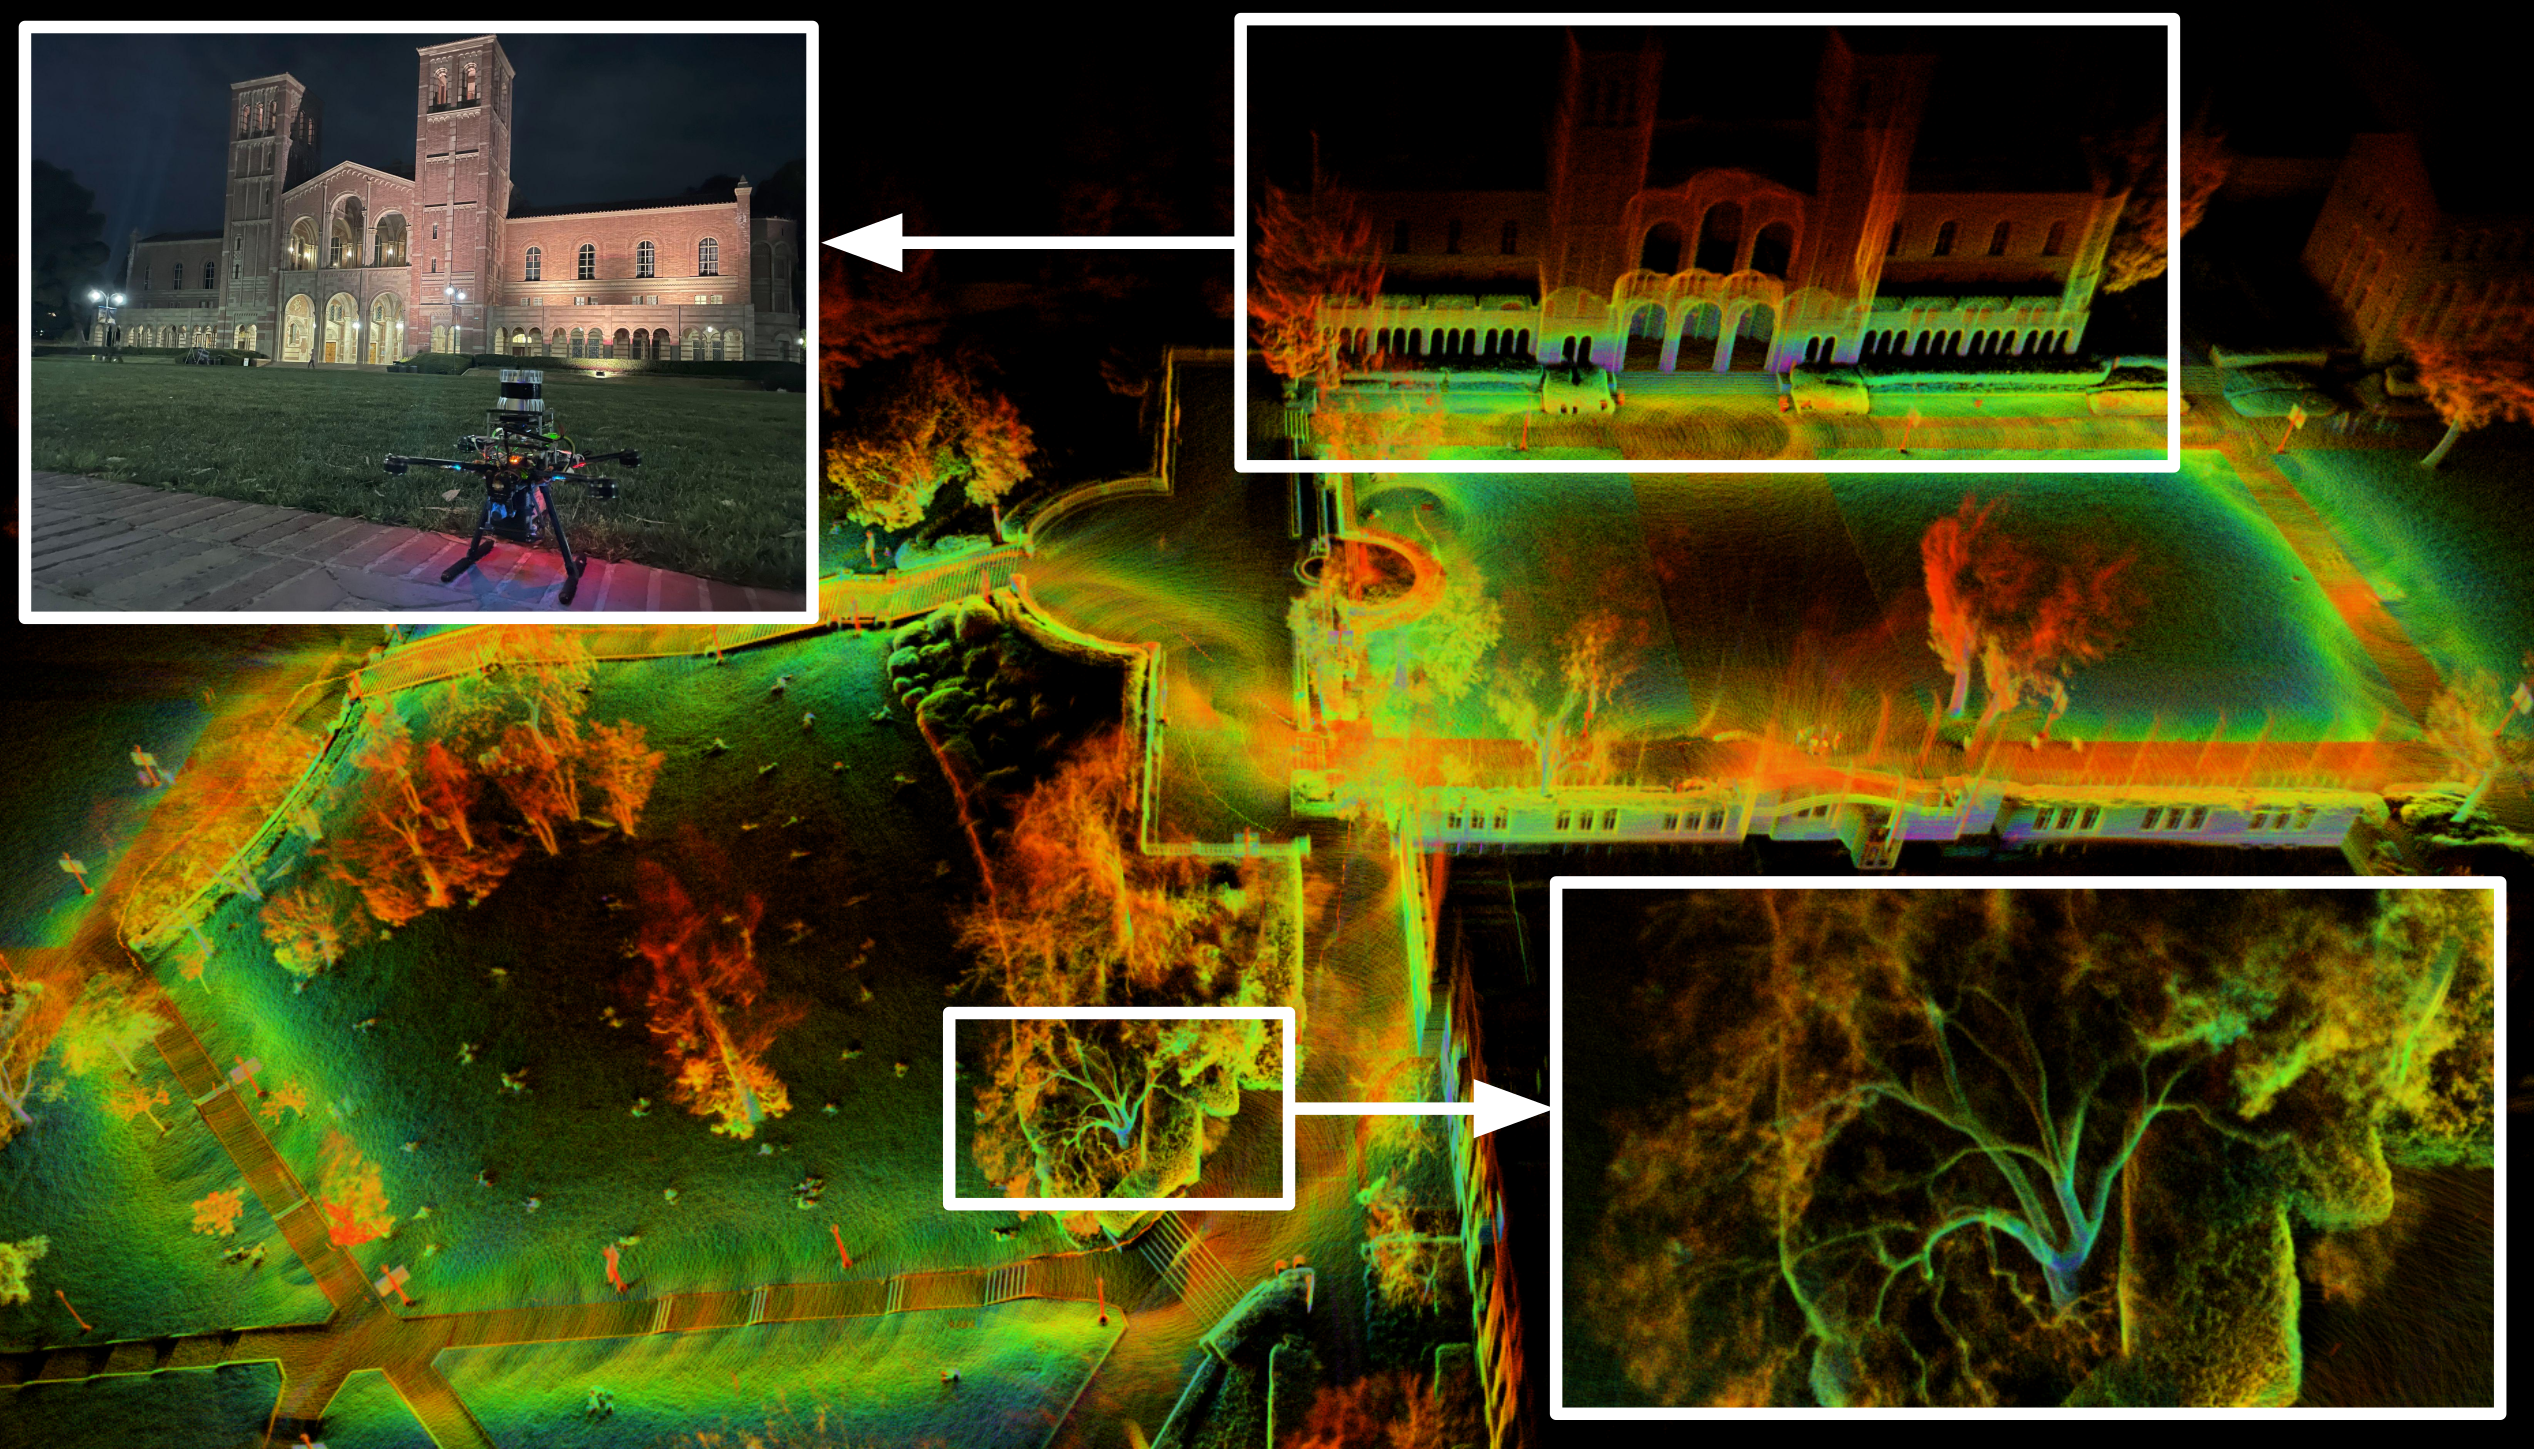
[IEEE ICRA'23] A new lightweight LiDAR-inertial odometry algorithm with a novel coarse-to-fine approach in constructing continuous-time trajectories for precise motion correction.
- 1.1k
- C++
- MIT
- 8 mo ago


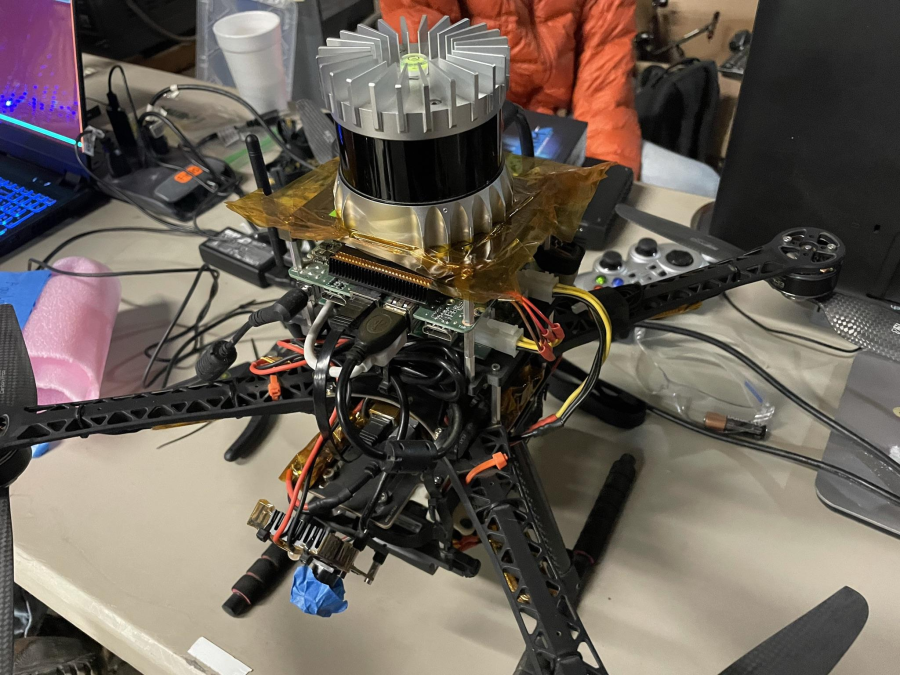
direct_lidar_odometry
[IEEE RA-L & ICRA'22] A lightweight and computationally-efficient frontend LiDAR odometry solution with consistent and accurate localization.
- 1.1k
- C++
- MIT
- 2 y ago


openglobus
TypeScript/JavaScript 3D maps and geospatial data visualization engine library
- 959
- TypeScript
- Apache-2.0
- 13 h ago

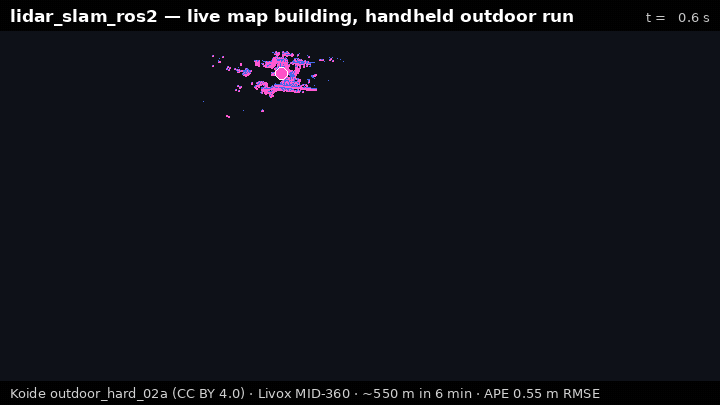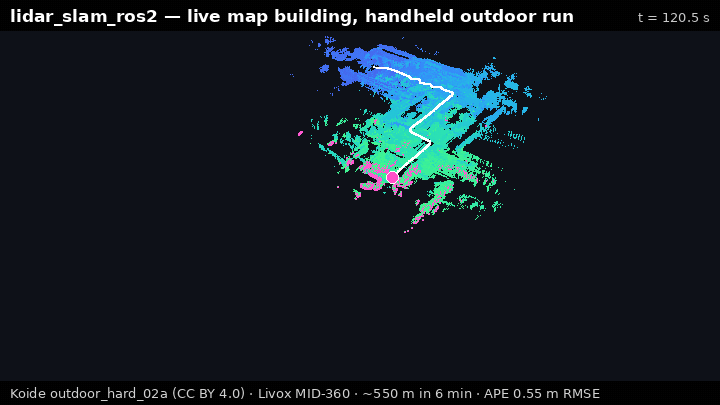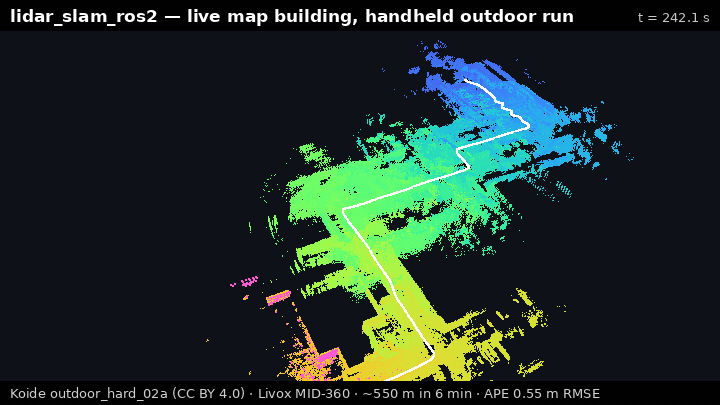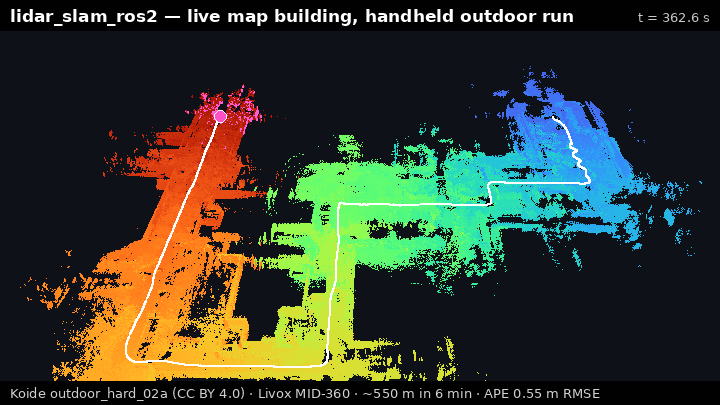
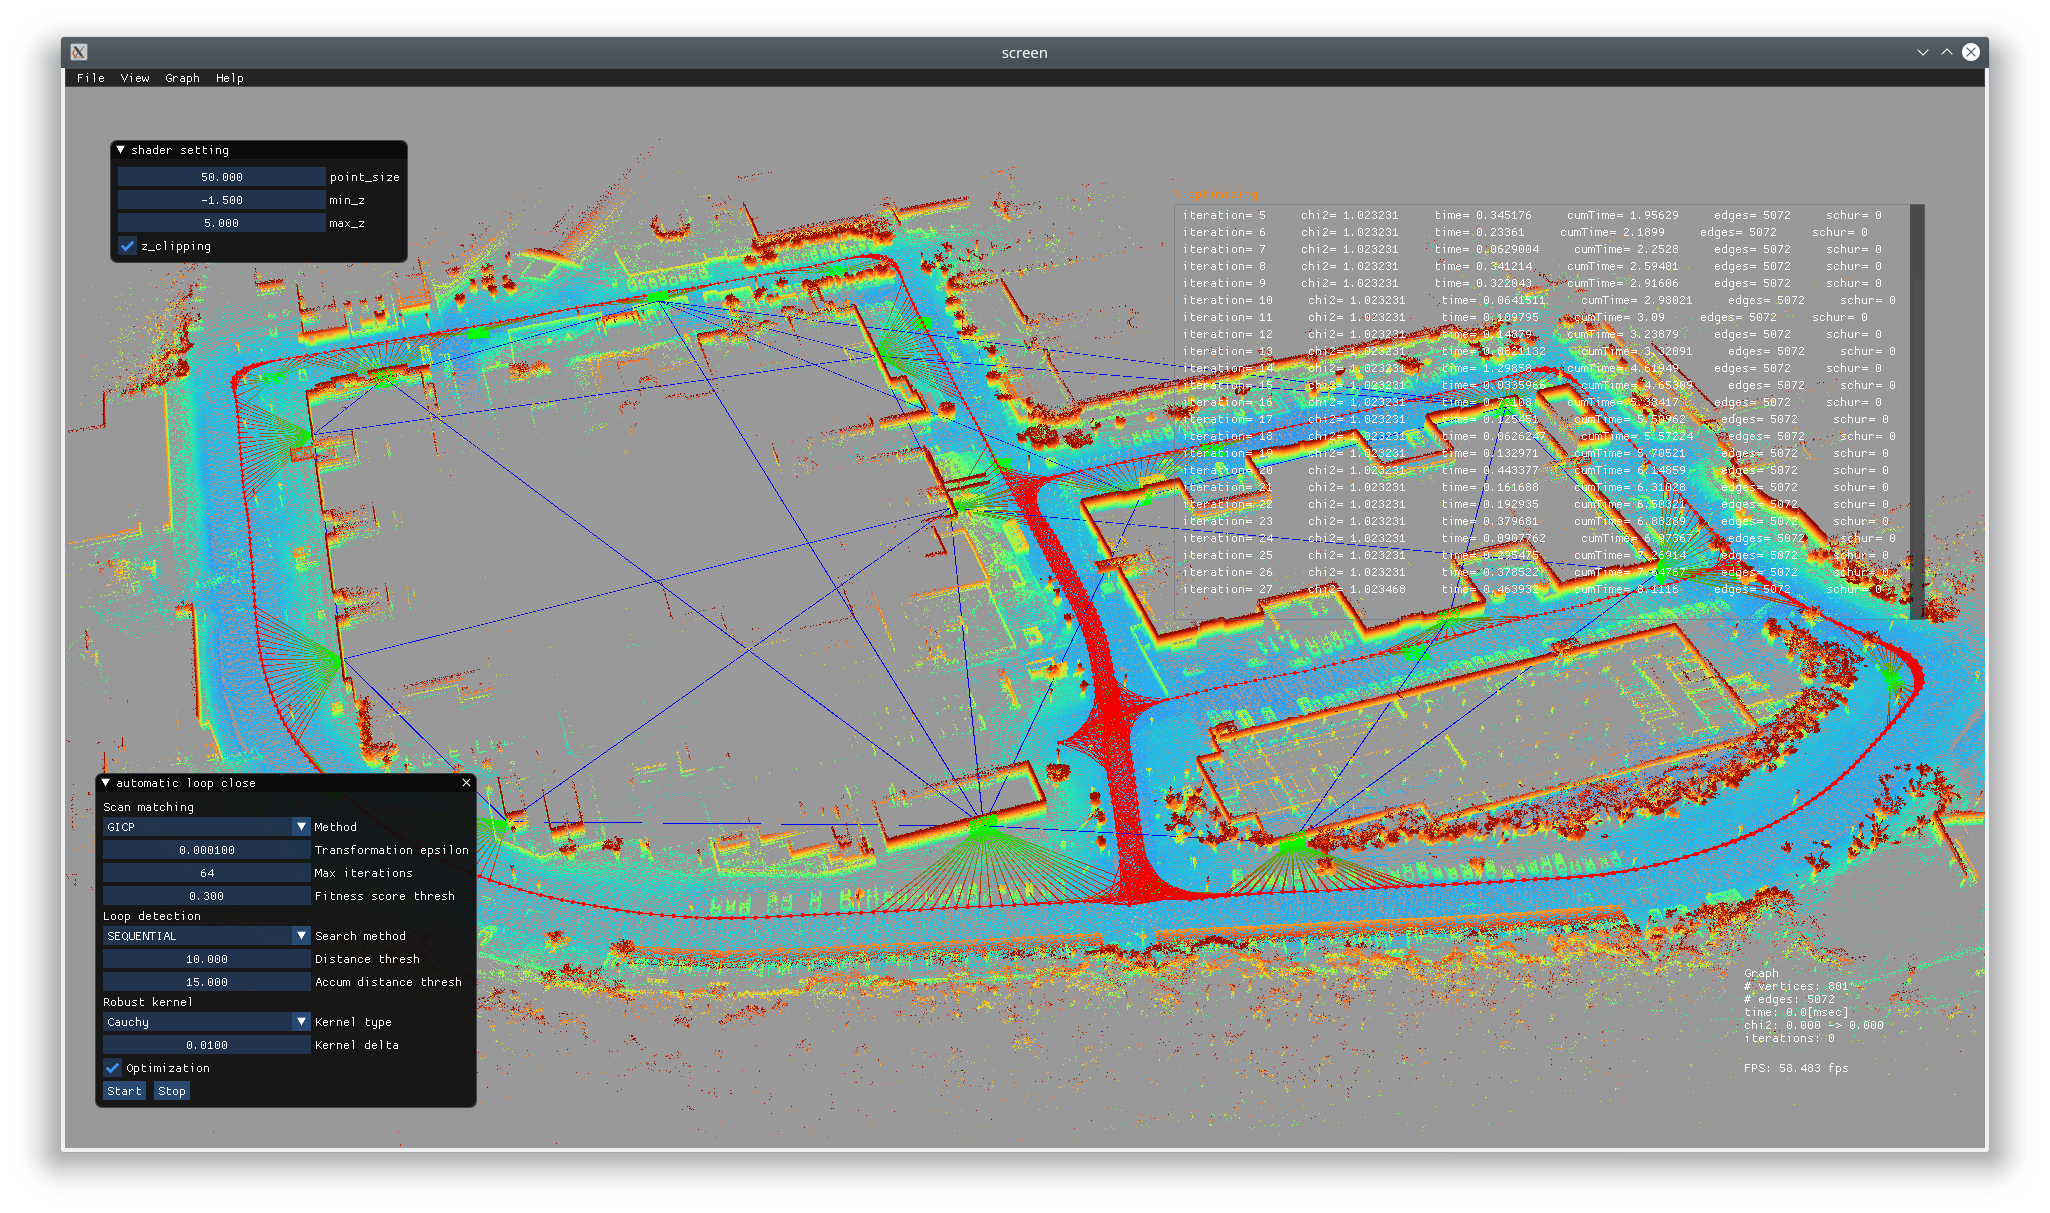
lidar_slam
3D LiDAR SLAM for pointcloud-map authoring, benchmarking, and Autoware-compatible map workflows.
- 958
- Python
- BSD-2-Clause
- 3 d ago



KISS-Matcher
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
- 824
- C++
- MIT
- 8 wk ago

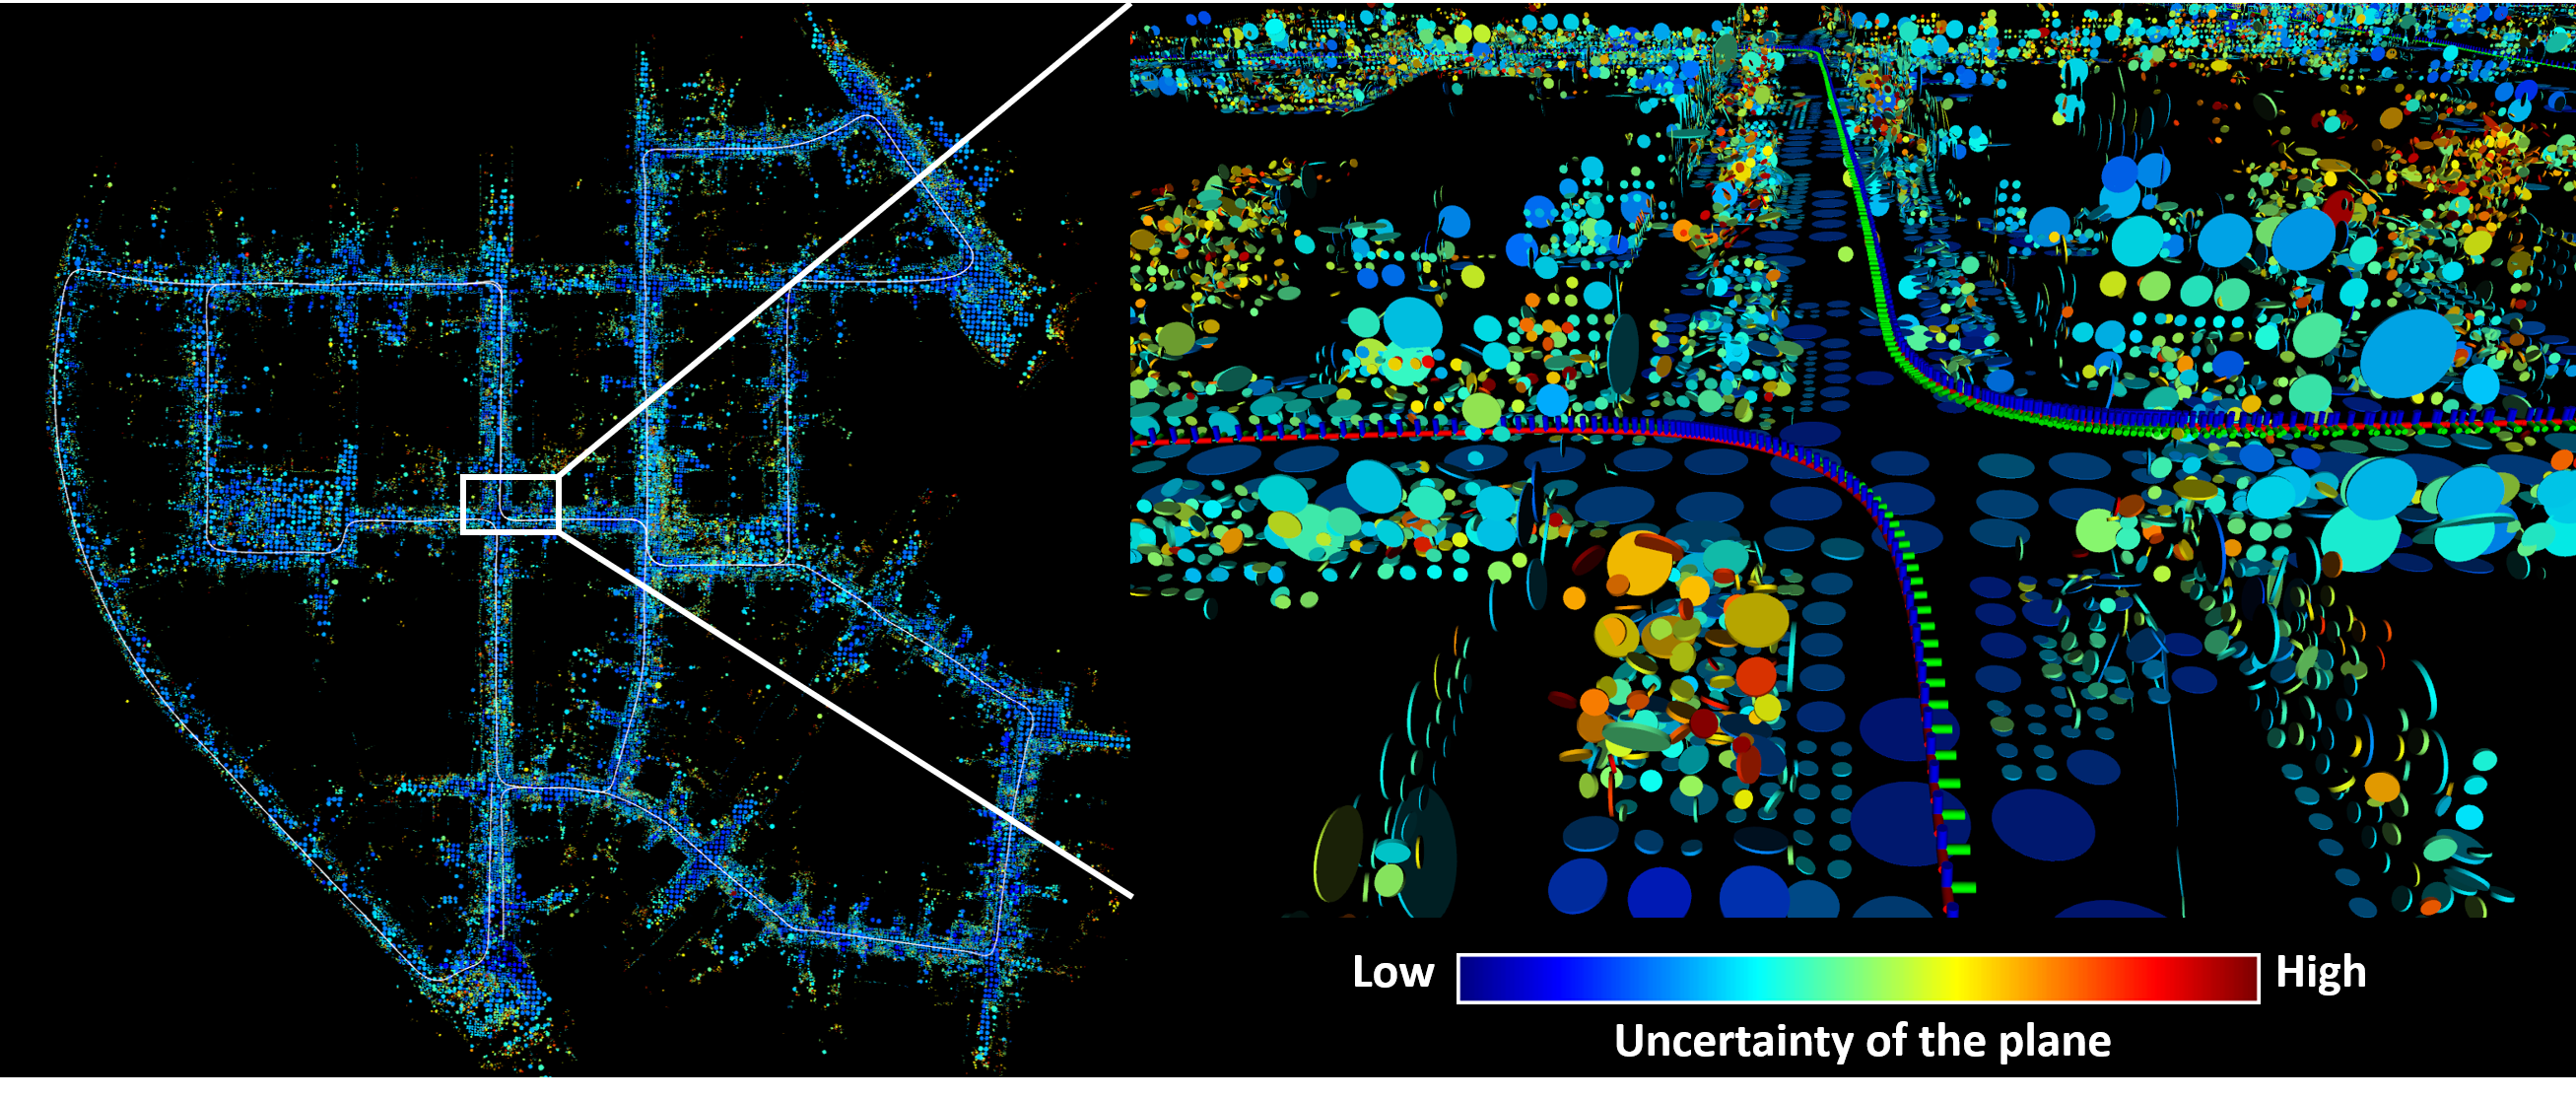
VoxelMap
[RA-L 2022] An efficient and probabilistic adaptive voxel mapping method for LiDAR odometry
- 736
- C++
- 3 y ago



rko_lio
A Robust Approach for LiDAR-Inertial Odometry Without Sensor-Specific Modelling
- 695
- C++
- MIT
- 1 d ago

LiDAR-MOS
(LMNet) Moving Object Segmentation in 3D LiDAR Data: A Learning-based Approach Exploiting Sequential Data (RAL/IROS 2021)
- 694
- Python
- MIT
- 4 y ago
self-supervised-depth-completion
ICRA 2019 "Self-supervised Sparse-to-Dense: Self-supervised Depth Completion from LiDAR and Monocular Camera"
- 654
- Python
- MIT
- 6 y ago


pptk
The Point Processing Toolkit (pptk) is a Python package for visualizing and processing 2-d/3-d point clouds.
- 636
- C++
- MIT
- 6 y ago


Autonomous-Ai-drone-scripts
State of the art autonomous navigation scripts using Ai, Computer Vision, Lidar and GPS to control an arducopter based quad copter.
- 636
- Python
- 5 y ago
