
RoboNever
A High-Quality Real-World Dataset for Continual Robot Learning
- 5
- MIT
- 5 mo ago
Repo Agentic-Intelligence-Lab/RoboNever, read from GitHub 1 min ago. Agentic-Intelligence-Lab has not joined Take My Repo.
In short
Agentic-Intelligence-Lab/RoboNever is a public repo on GitHub by Agentic-Intelligence-Lab. A High-Quality Real-World Dataset for Continual Robot Learning. It declares the MIT license on GitHub. It has 5 stars and last changed on 2026-06-12. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-21.
RoboNever
A Real-World Robotic Dataset for Continual Learning
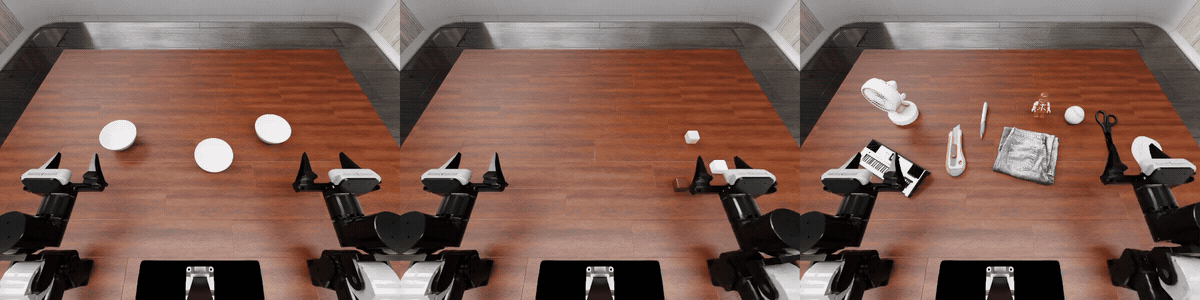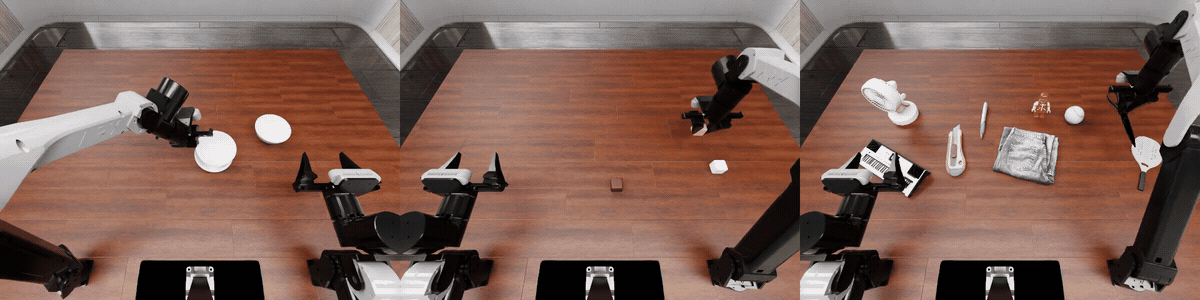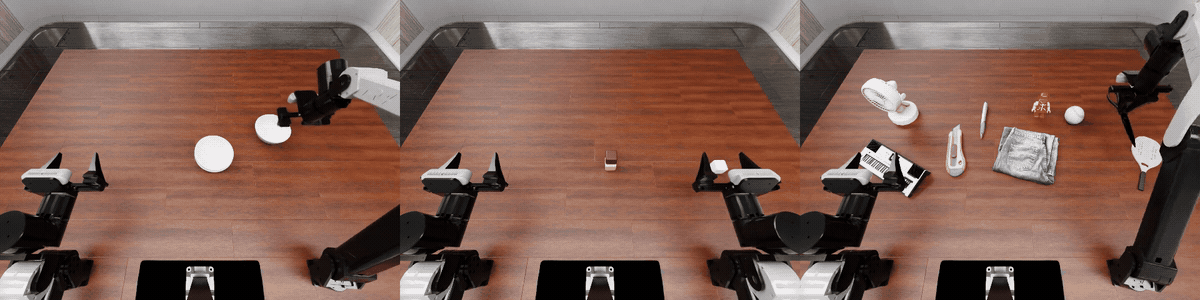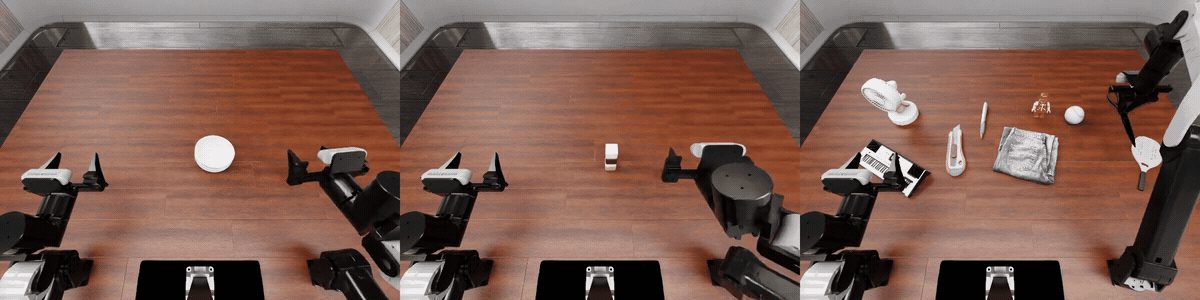
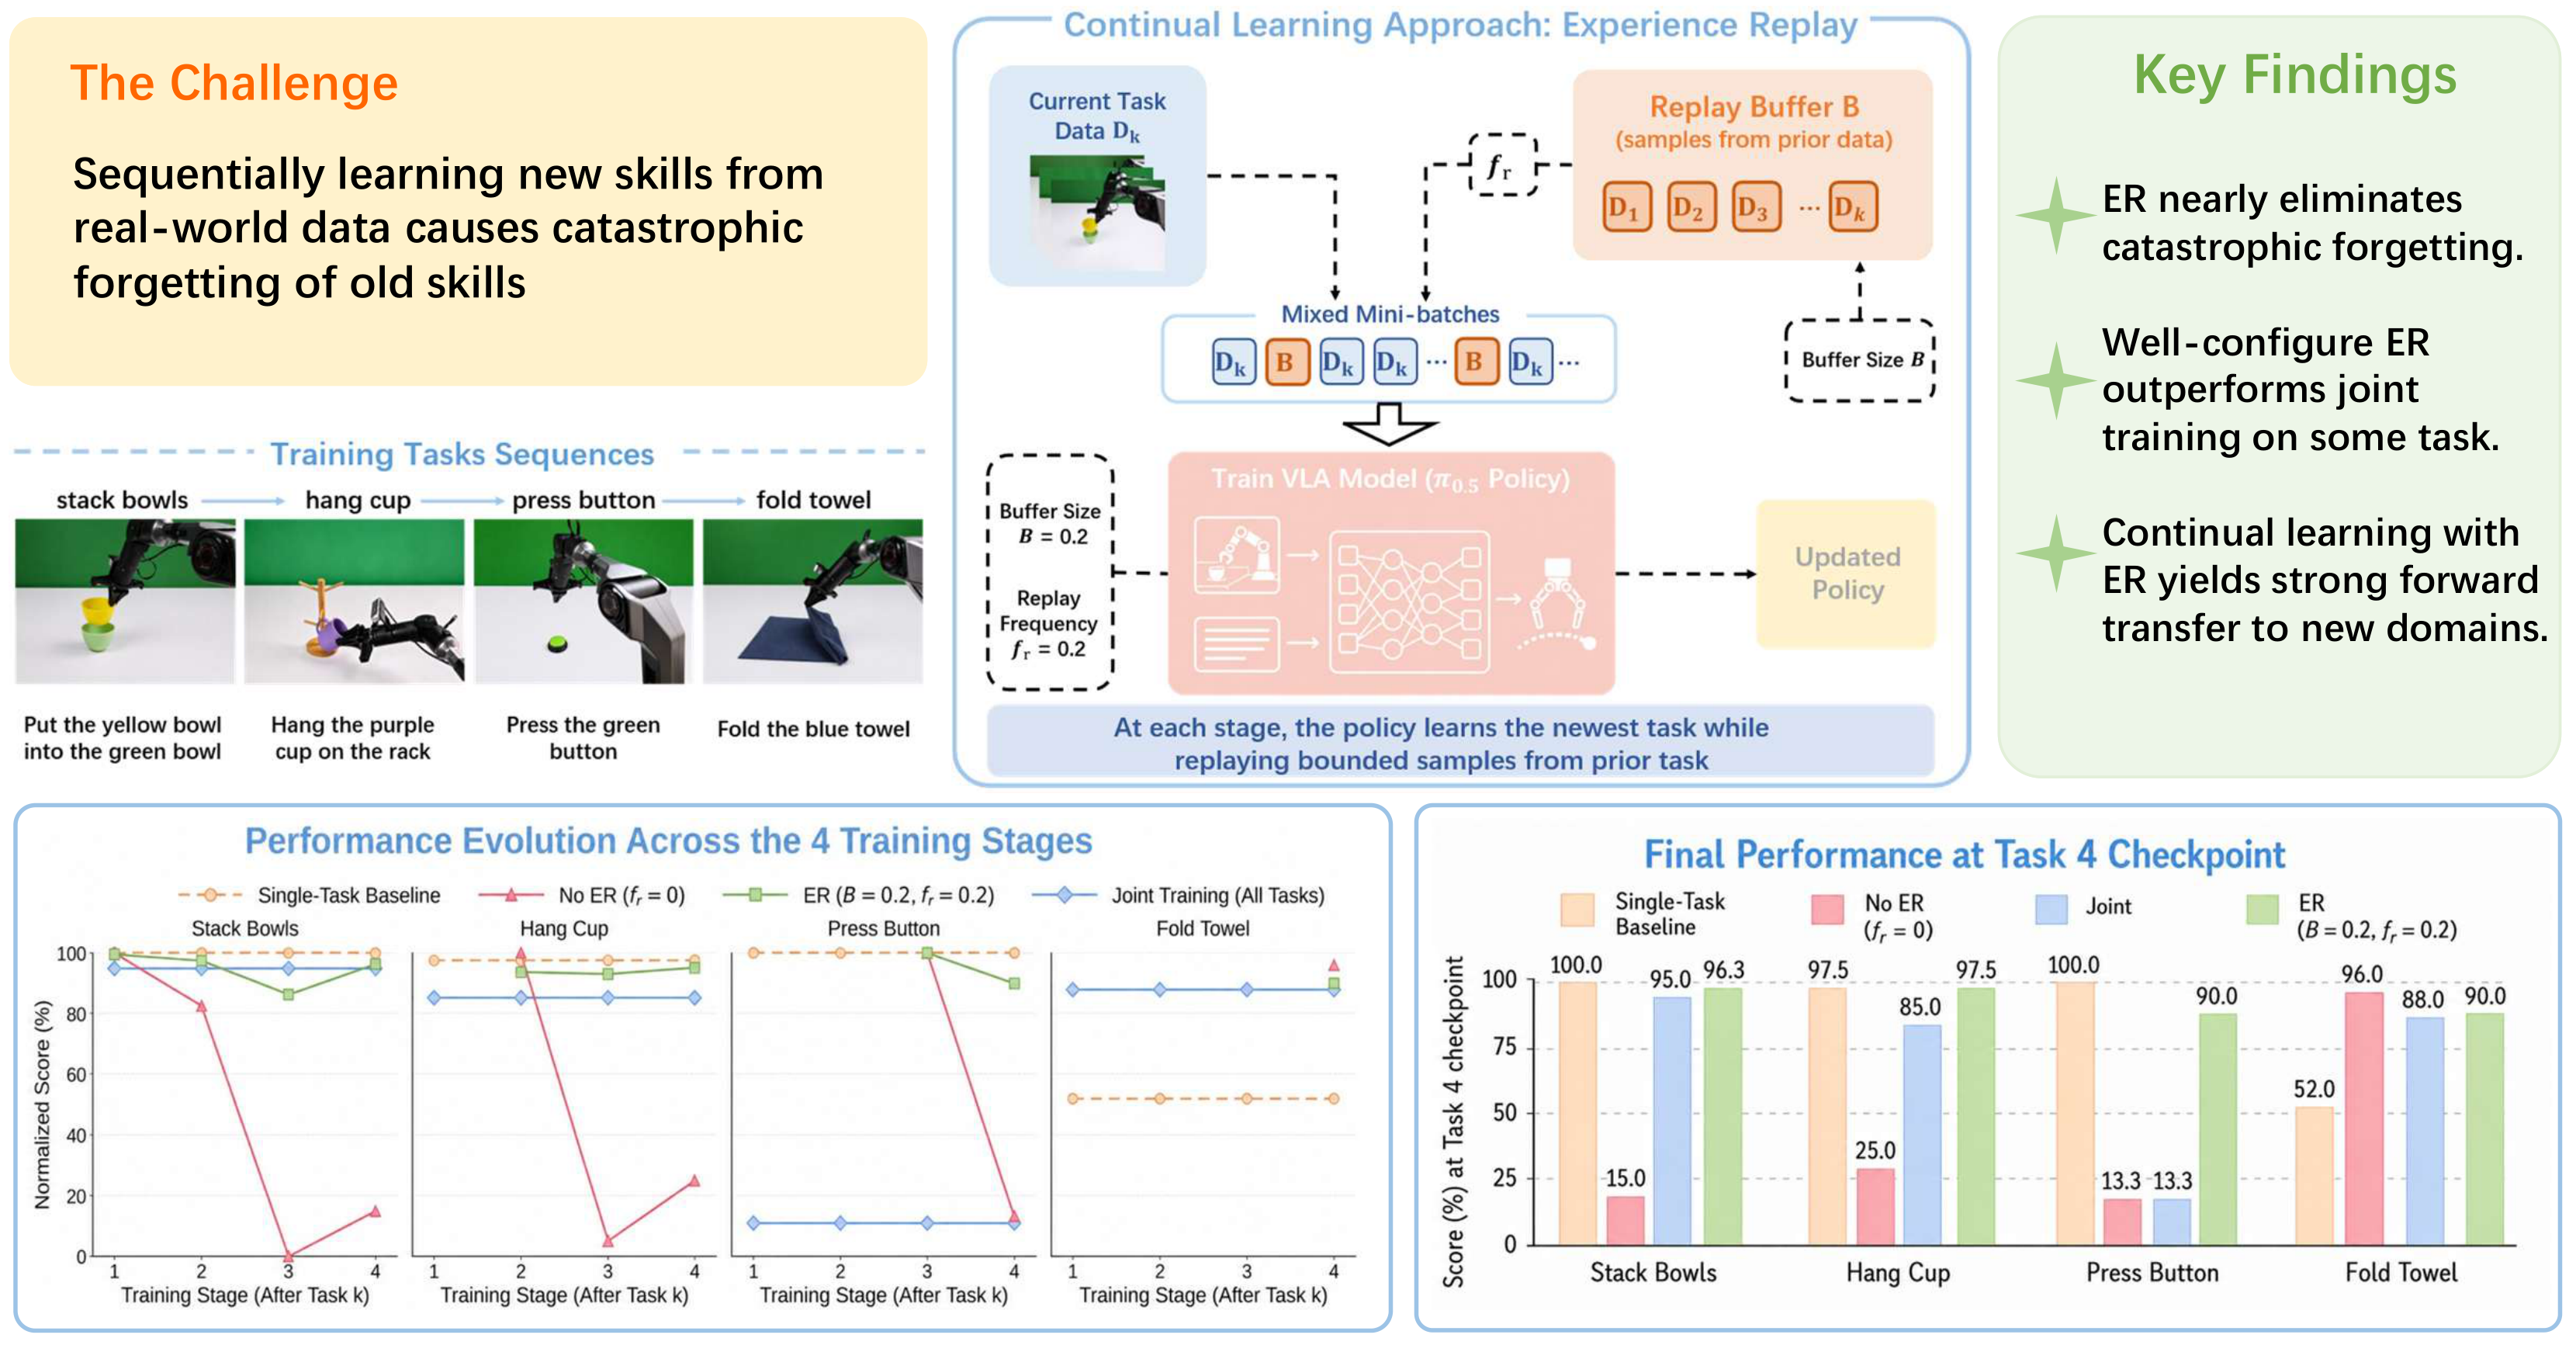
RoboNever is a high-quality real-world robotic dataset designed for studying continual learning in vision-language-action (VLA) models.

Paper: Can VLA Models Learn from Real-World Data Continually without Forgetting?
Highlights
- Real Robot Data: 2,000 episodes collected on a Piper dual-arm robot
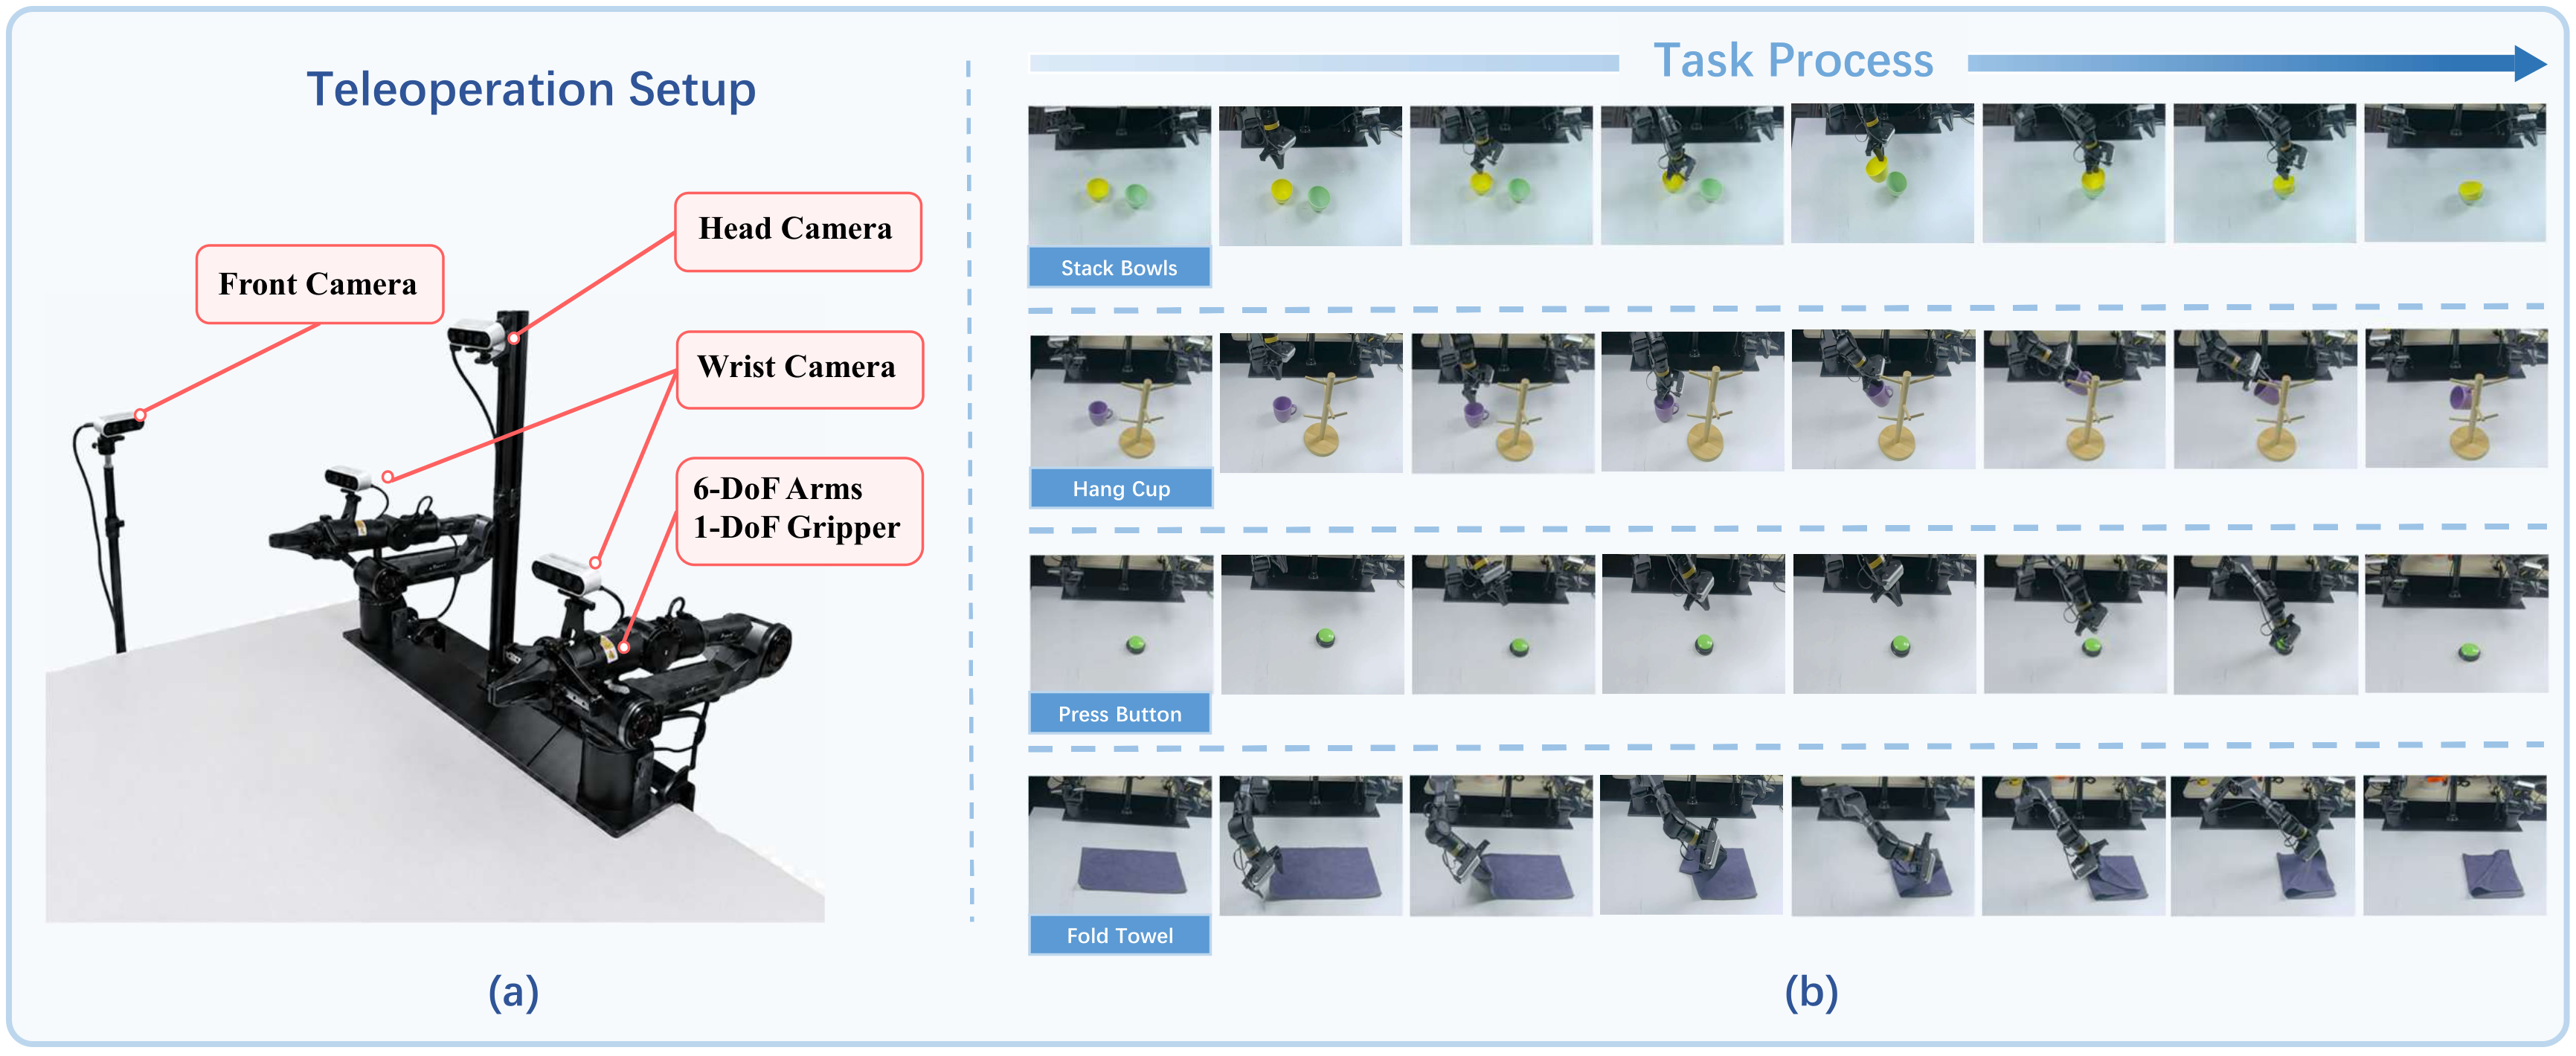
- 4 Diverse Tasks: Rigid manipulation, articulated objects, deformable objects, contact-rich tasks
- Multi-View Cameras: 4 synchronized camera views per episode
- LeRobot Format: Ready-to-use with the HuggingFace LeRobot library
- Continual Learning: Specifically designed for studying catastrophic forgetting
Dataset Overview
| Task | Episodes | Frames | Description | Type | Download |
|---|---|---|---|---|---|
| Stack Bowls | 500 | 129,612 | Pick and stack bowls | Rigid | Download |
| Hang Cup | 500 | 149,372 | Hang a cup on a rack | Articulated | Download |
| Fold Towel | 500 | 213,047 | Fold a deformable towel | Deformable | Download |
| Press Button | 500 | 67,955 | Press a button with precision | Contact-rich | Download |
Quick Start
1. Install Dependencies
pip install lerobot huggingface_hub
2. Load a Dataset
from lerobot.common.datasets.lerobot_dataset import LeRobotDataset

# Load any of the 4 tasks
ds = LeRobotDataset("Ray0v0/cl-piper-single-stack-bowls")

print(f"Episodes: {ds.num_episodes}")
print(f"Total Frames: {len(ds)}")
print(f"Sample keys: {ds[0].keys()}")
3. Download All Datasets
# Login to HuggingFace (required for download)
huggingface-cli login

# Download all 4 tasks
for task in stack-bowls hang-cup fold-towel press-button; do
    huggingface-cli download "Ray0v0/cl-piper-single-${task}" \
        --repo-type dataset \
        --local-dir "./data/cl-piper-single-${task}"
done
Data Specifications
- Robot: Piper Dual-Arm, 14-DOF (6 joints + 1 gripper per arm)
- Cameras: 4 synchronized views (head, left_wrist, right_wrist, front_view), 480x640 resolution
- FPS: 30
- Format: H.264 video, Parquet for state/action, MP4 for videos
Dataset Structure
cl-piper-single-<task>/
|-- data/
|   +-- chunk-000/
|       |-- episode_000000.parquet
|       |-- episode_000001.parquet
|       +-- ... (500 episodes)
|-- meta/
|   |-- info.json              # Dataset metadata
|   |-- episodes.jsonl         # Episode-level info
|   |-- episodes_stats.jsonl   # Per-episode statistics
|   |-- tasks.jsonl            # Task descriptions
|   +-- modality.json          # Feature mappings
+-- videos/
    +-- chunk-000/
        |-- observation.images.head/
        |-- observation.images.left_wrist/
        |-- observation.images.right_wrist/
        +-- observation.images.front_view/
Task Instructions
Each task comes with a natural language instruction for the robot:
| Task | Language Instruction |
|---|---|
| Stack Bowls | "stack the yellow bowl on the green bowl" |
| Hang Cup | "hang the purple cup on the mug rack" |
| Fold Towel | "fold the grey towel" |
| Press Button | "press the green button" |
Integration with ContinualVLA
This dataset is designed to work seamlessly with the ContinualVLA codebase for continual learning experiments:
# Clone ContinualVLA
git clone https://github.com/Agentic-Intelligence-Lab/ContinualVLA.git
cd ContinualVLA

# Download datasets
export OPENPI_DATA_ROOT="./data"
bash scripts/download_dataset.sh

# Run continual learning training
bash scripts/train_cl.sh
Citation
If you find this dataset useful for your research, please cite:
@article{zhu2026continualvla,
  title={Can VLA Models Learn from Real-World Data Continually without Forgetting?},
  author={Zhu, Jiarun and Hong, Yijun and Sun, Xiaoquan and Xu, Zetian and
          Yuan, Mingqi and Wang, Zhiyong and Zeng, Wenjun and Chen, Jiayu},
  journal={arXiv preprint arXiv:2605.26820},
  year={2026}
}
License
This dataset is released under the MIT License.
Related Projects
| Project | Description |
|---|---|
| ContinualVLA | Official implementation for continual learning experiments |
| openpi | Base codebase by Physical Intelligence |
| LeRobot | HuggingFace's robot learning library |
Built by Agentic Intelligence Lab at The University of Hong Kong
Questions
What is RoboNever?
Agentic-Intelligence-Lab/RoboNever is a public repo on GitHub by Agentic-Intelligence-Lab. A High-Quality Real-World Dataset for Continual Robot Learning.
Is RoboNever open source?
It declares the MIT license on GitHub.
Does RoboNever run on macOS, Windows or Linux?
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
How do I install RoboNever?
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Is RoboNever still maintained?
Its last change on GitHub was on 2026-06-12. Take My Repo does not judge from that whether it is maintained.
What do people who ran RoboNever say?
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.