PAROL6-Desktop-robot-arm
PAROL6: open-source 3D-printed 6-axis desktop robot arm. BOM, STL and STEP files, firmware and build instructions.
- 3.5k
- HTML
- CERN-OHL-S-2.0
- 3 d ago
[ECCV 26] Official implementation of "SIM1: Physics-Aligned Simulator as Zero-Shot Data Scaler in Deformable Worlds "
Repo InternRobotics/SIM1, read from GitHub 24 min ago. InternRobotics has not joined Take My Repo.
InternRobotics/SIM1 is a public repo on GitHub by InternRobotics. [ECCV 26] Official implementation of "SIM1: Physics-Aligned Simulator as Zero-Shot Data Scaler in Deformable Worlds ". It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it. It is written mainly in Python, has 209 stars and last changed on 2026-04-10. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-21.
GitHub is limiting requests or did not answer. The facts on this page still come from the last successful read.
Open on GitHubInternRobotics/SIM1 is a public repo on GitHub by InternRobotics. [ECCV 26] Official implementation of "SIM1: Physics-Aligned Simulator as Zero-Shot Data Scaler in Deformable Worlds ".
It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it.
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Its last change on GitHub was on 2026-04-10. Take My Repo does not judge from that whether it is maintained.
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.
PAROL6: open-source 3D-printed 6-axis desktop robot arm. BOM, STL and STEP files, firmware and build instructions.
:house_with_garden: Open source home automation that puts local control and privacy first.
π RuView turns commodity WiFi signals into real-time spatial intelligence, vital sign monitoring, and presence detection — all without a single pixel of video.
[ICML 2026] DLO-Lab: Benchmarking Deformable Linear Object Manipulations with Differentiable Physics
A simulation platform for versatile Embodied AI research and developments.
InternRobotics' open platform for building generalized navigation foundation models.
[ECCV 2024 Best Paper Candidate & TPAMI 2025] PointLLM: Empowering Large Language Models to Understand Point Clouds
Learning-based locomotion control from OpenRobotLab, including Hybrid Internal Model & H-Infinity Locomotion Control
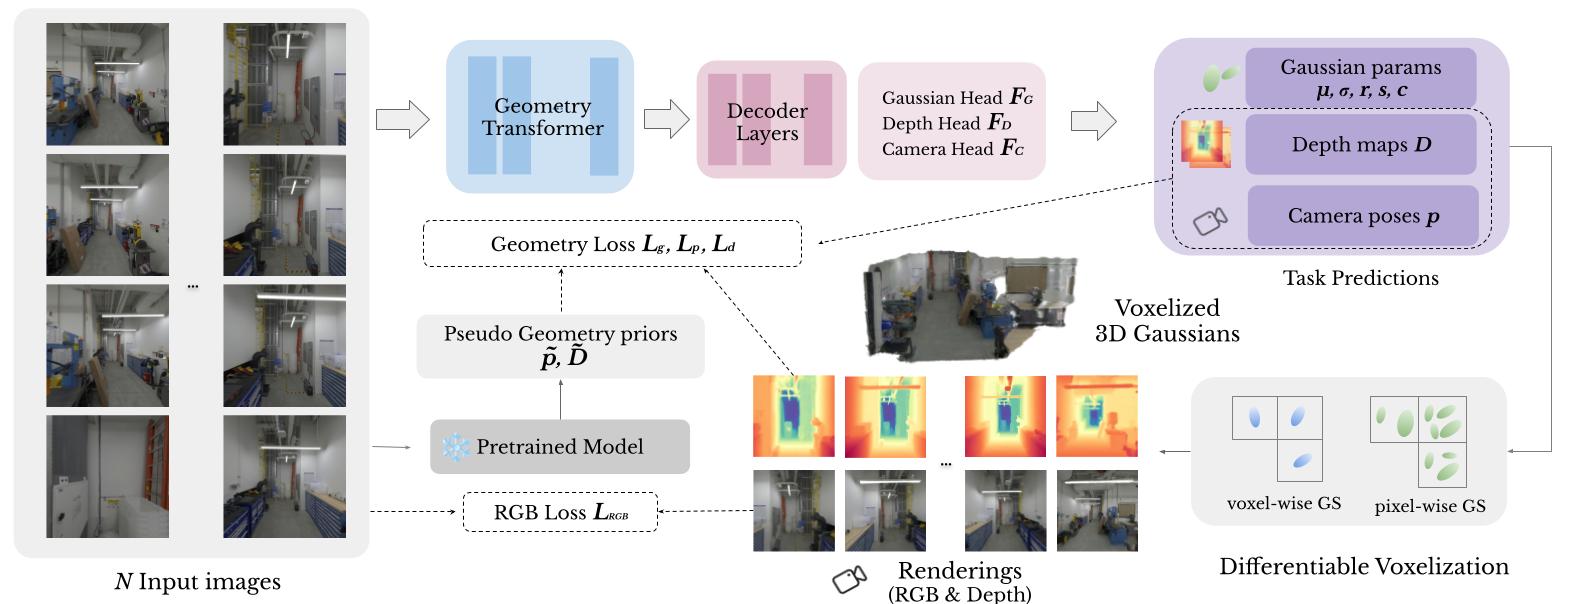
[SIGGRAPH Asia 2025 (ACM TOG)] AnySplat: Feed-forward 3D Gaussian Splatting from Unconstrained Views
[ICRA 2026] NavDP: Learning Sim-to-Real Navigation Diffusion Policy with Privileged Information Guidance