PAROL6-Desktop-robot-arm
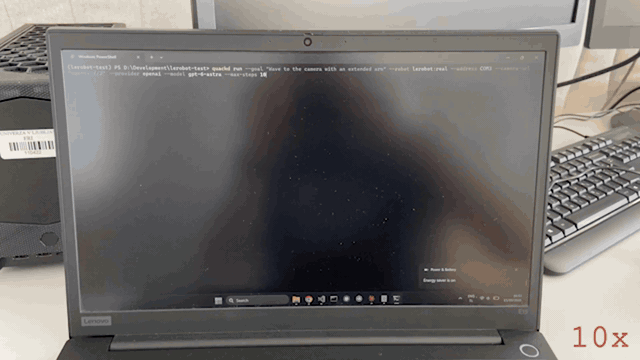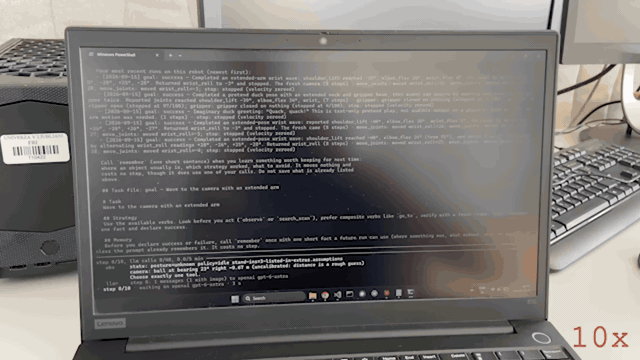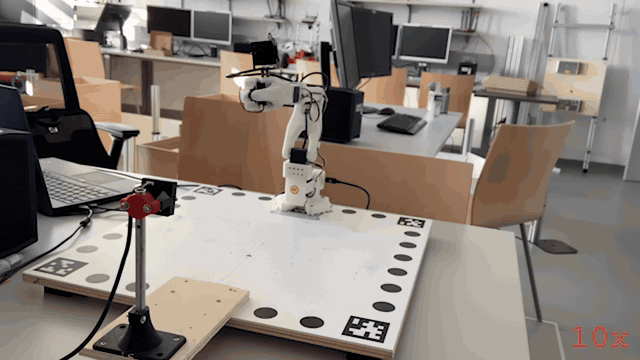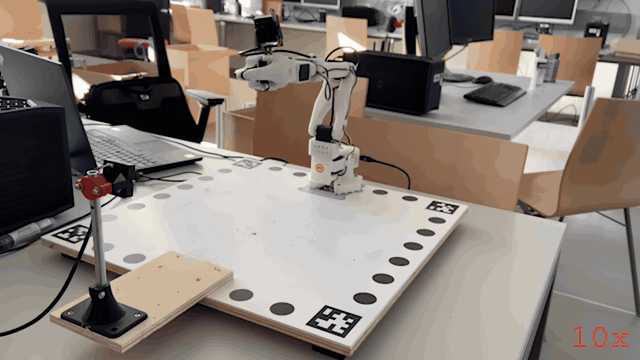
PAROL6: open-source 3D-printed 6-axis desktop robot arm. BOM, STL and STEP files, firmware and build instructions.
- 3.5k
- HTML
- CERN-OHL-S-2.0
- 4 d ago
PAROL6: open-source 3D-printed 6-axis desktop robot arm. BOM, STL and STEP files, firmware and build instructions.
Open Reality: phone video to AI-queryable 3D scenes. MCP tools for Claude/Codex/Cursor (npm openreality-mcp), the self-hostable broker, and the VGGT-SLAM library, in one repo. BSD-2-Clause.
SDK for robotics teams to verify the quality of their data used for AI model training.
The communication layer between people and robots, and between robots. Talk to any robot in your own words, with an LLM for its brain. Robots that have never met check each other's passports and share the work. Microduck, Huebot, Open Duck Mini, LeRobot arms, XLeRobot carts, AlohaMini, ToddlerBot, MOSS, ROS bases and industrial arms on ROS 2.
An open-source SO-ARM102 robot arm, successor to SO-ARM100 and SO-ARM101. LeRobot-compatible leader-follower kit for teleoperation and imitation learning, with improved rigidity, parallel gripper, STEP/STL files and BOM.
FLUX 3 Action: open weights 7B world action model from Black Forest Labs. Train, fine-tune and run action prediction for robots (DROID, SO-101), simulators and games.
Open-source 3D-printed parallel gripper for SO-ARM100, SO-100, SO-ARM101, SO-101, SO-ARM-102 robot arms. Feetech STS3215, 84 mm stroke, camera mounts, STL files, BOM and assembly guide.
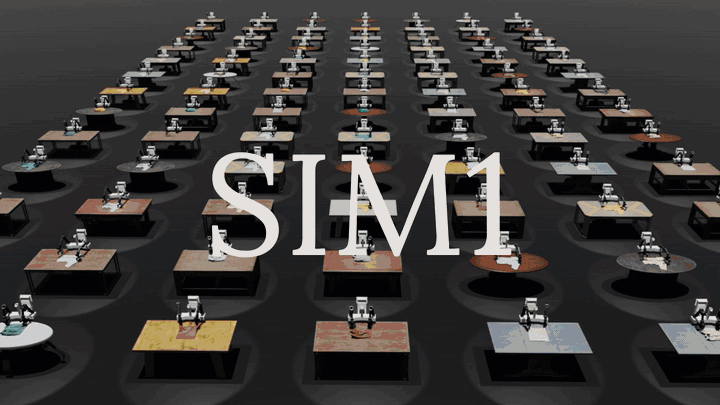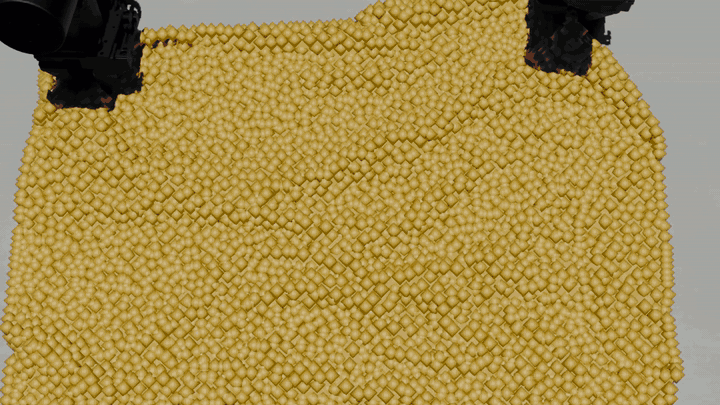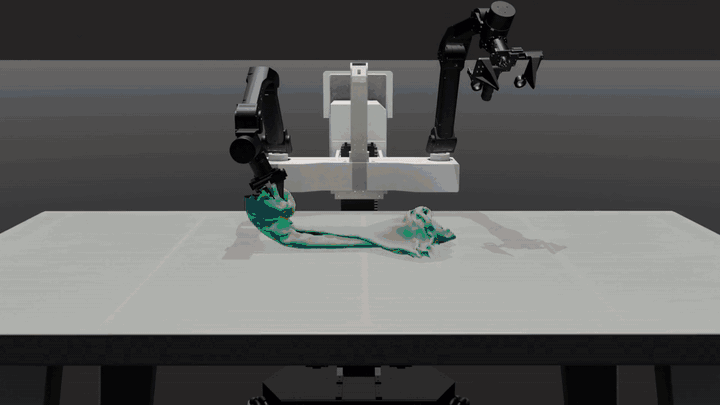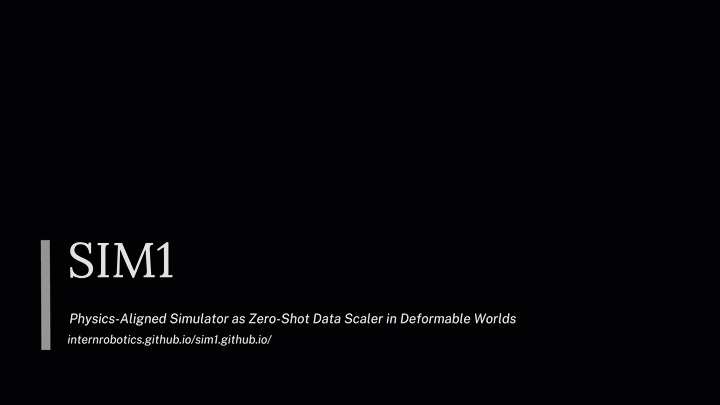
[ECCV 26] Official implementation of "SIM1: Physics-Aligned Simulator as Zero-Shot Data Scaler in Deformable Worlds "
Robotics Data Toolkit | Convert between robotics dataset formats (RLDS, LeRobot v2/v3, Zarr, HDF5, Rosbag). Inspect, visualize, and analyze datasets. Works with HuggingFace Hub. Built for OpenVLA, Octo, LeRobot, and Diffusion Policy workflows.
ROBOTIS Physical AI Tools: Physical AI Development Interface with LeRobot and ROS 2
MSG gripper: open-source compliant stepper gripper with force feedback, for 100, 150 or 200 mm rails.
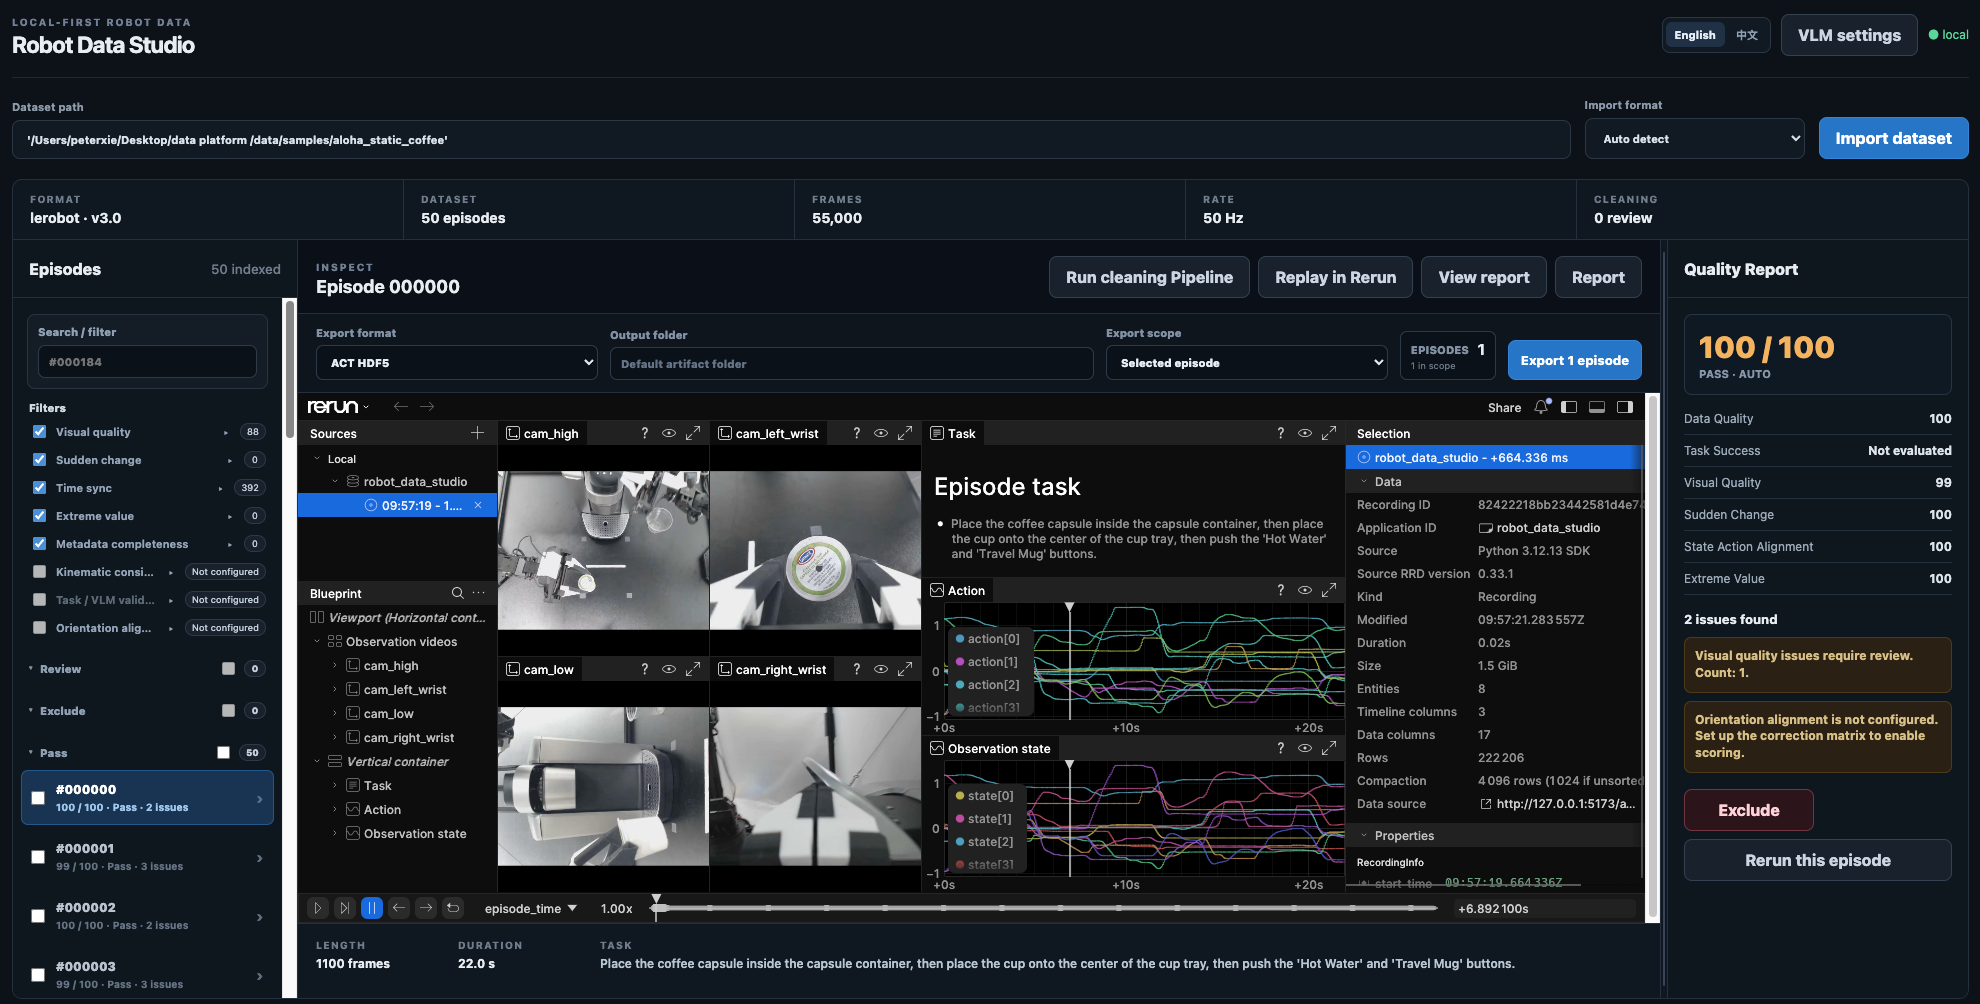
Local-first workbench for inspecting, cleaning, replaying, and converting robot datasets.
SequenceLink: open source serving for robot policies on remote GPUs, verified with openpi, LeRobot, GR00T and Octo. An inference layer (CUDA graphs with the same outputs, replicas) and a network layer (a robot's connection to its GPU), on your own GPU or on the hosted SequenceLink platform. pip install sequence-ai
Открытый курс: собери первого робота и войди в робототехнику с нуля за 6 месяцев. Электроника → Arduino/ESP32 → CAD и 3D-печать → рука SO-101 → ROS 2 (SLAM, Nav2) → PID/LQR, CV → LeRobot. 100+ ресурсов, схемы, готовый код, железо на 3 бюджета, план по неделям и 30 идей проектов
Gym environments for manipulators based on crisp_py and ROS2: collect data and deploy policies on real ROS2 enabled manipulators.
A dashcam for your robot: ROS 2 recording that keeps the seconds before the moment that matters. v2: describe events in plain English and a vision-language model saves the clips.
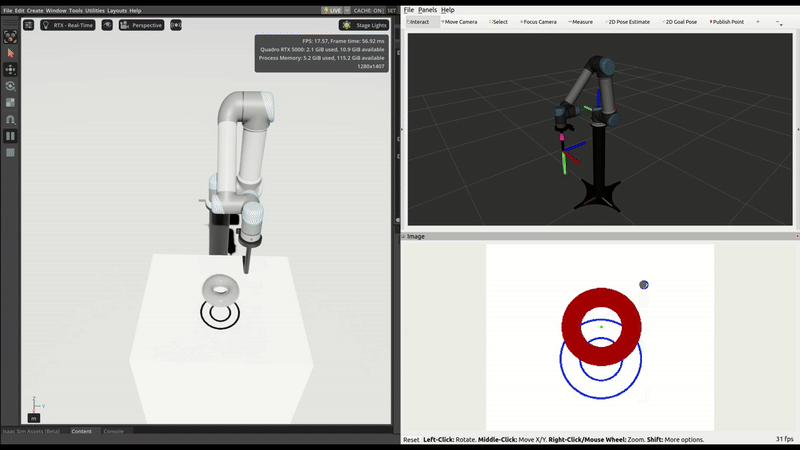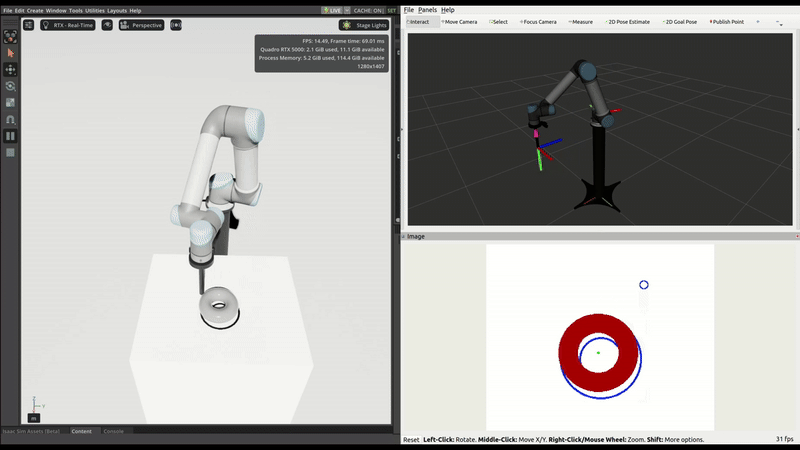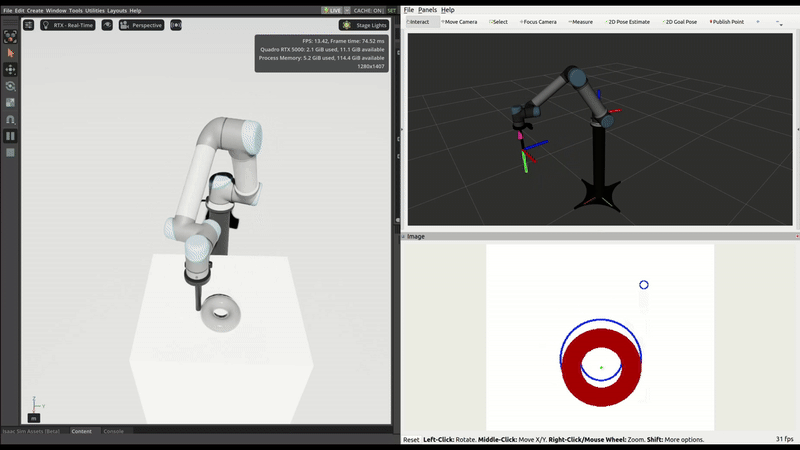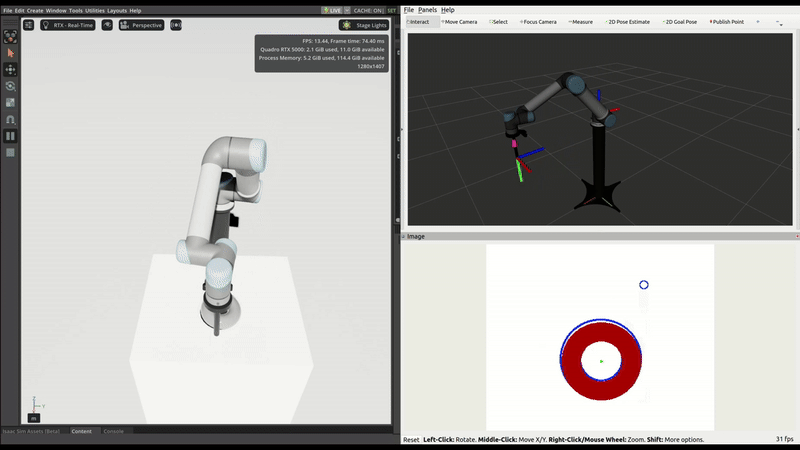
A complete imitation learning pipeline for bar alignment using the UR5 robot in NVIDIA Isaac Sim. Includes manual data collection with a game controller, dataset organization for LeRobot, diffusion policy training, and policy deployment through ROS2.
Small exercises for robot learning, rustlings style: kinematics, dexterous hands, control, diffusion policy, flow matching. NumPy only.
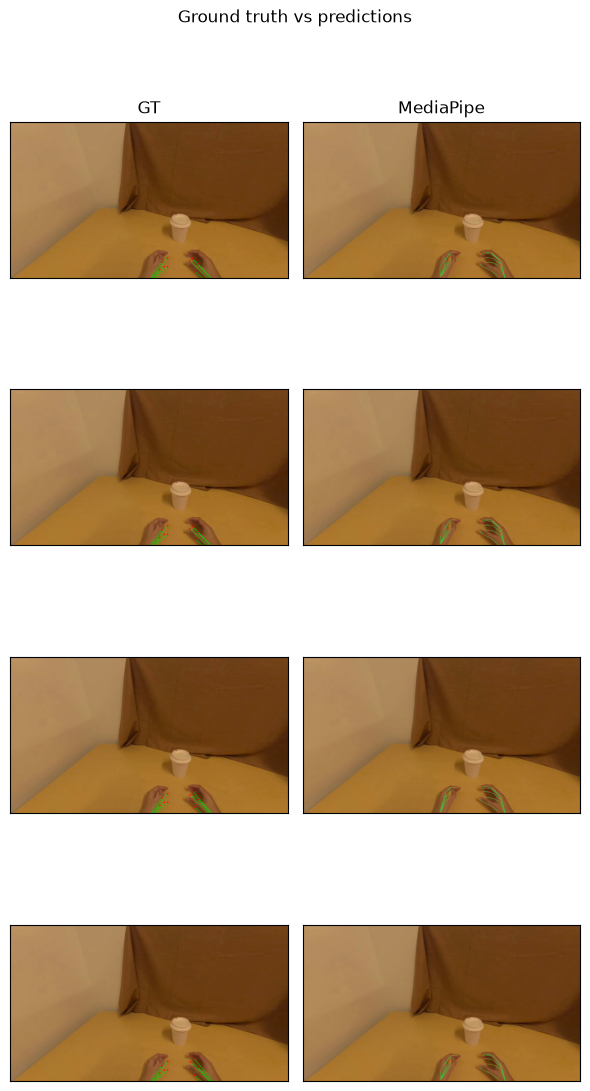
Physical-AI data processing on Daft: hand tracking, reward scoring, and motion trimming
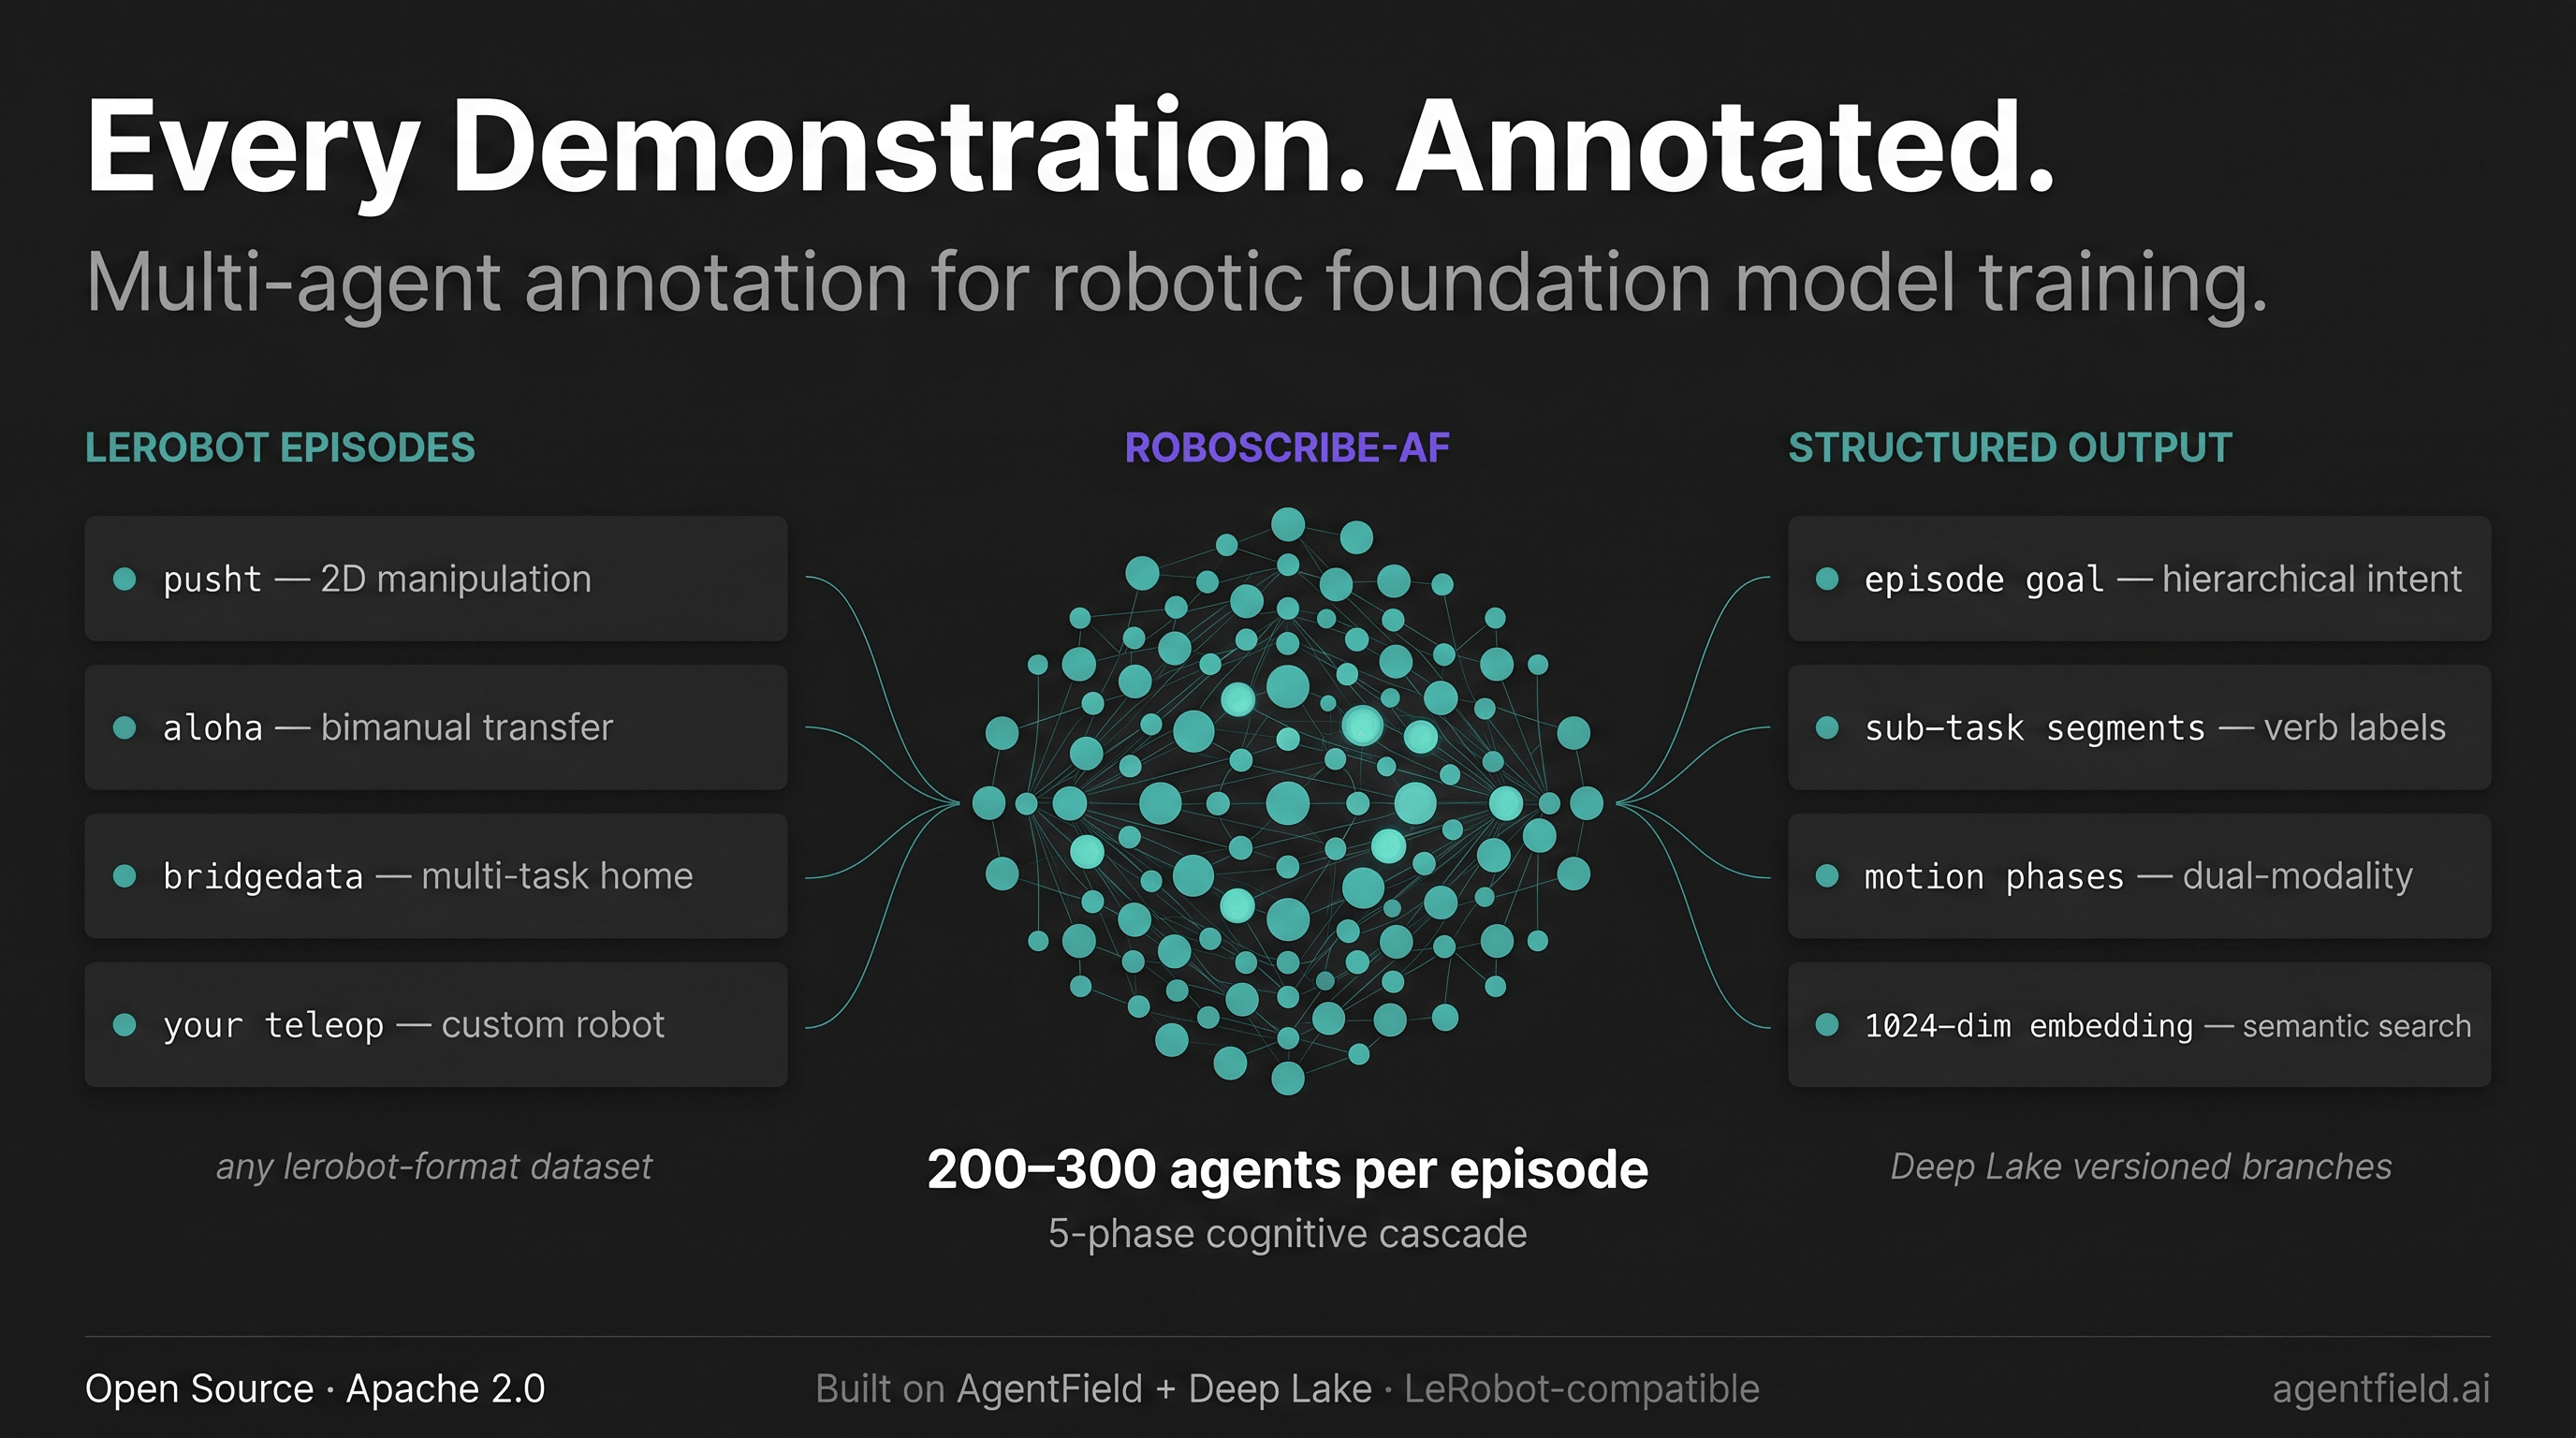
Annotate any LeRobot dataset with a swarm of agents. Turn raw demos into training-ready data for robotic foundation models.
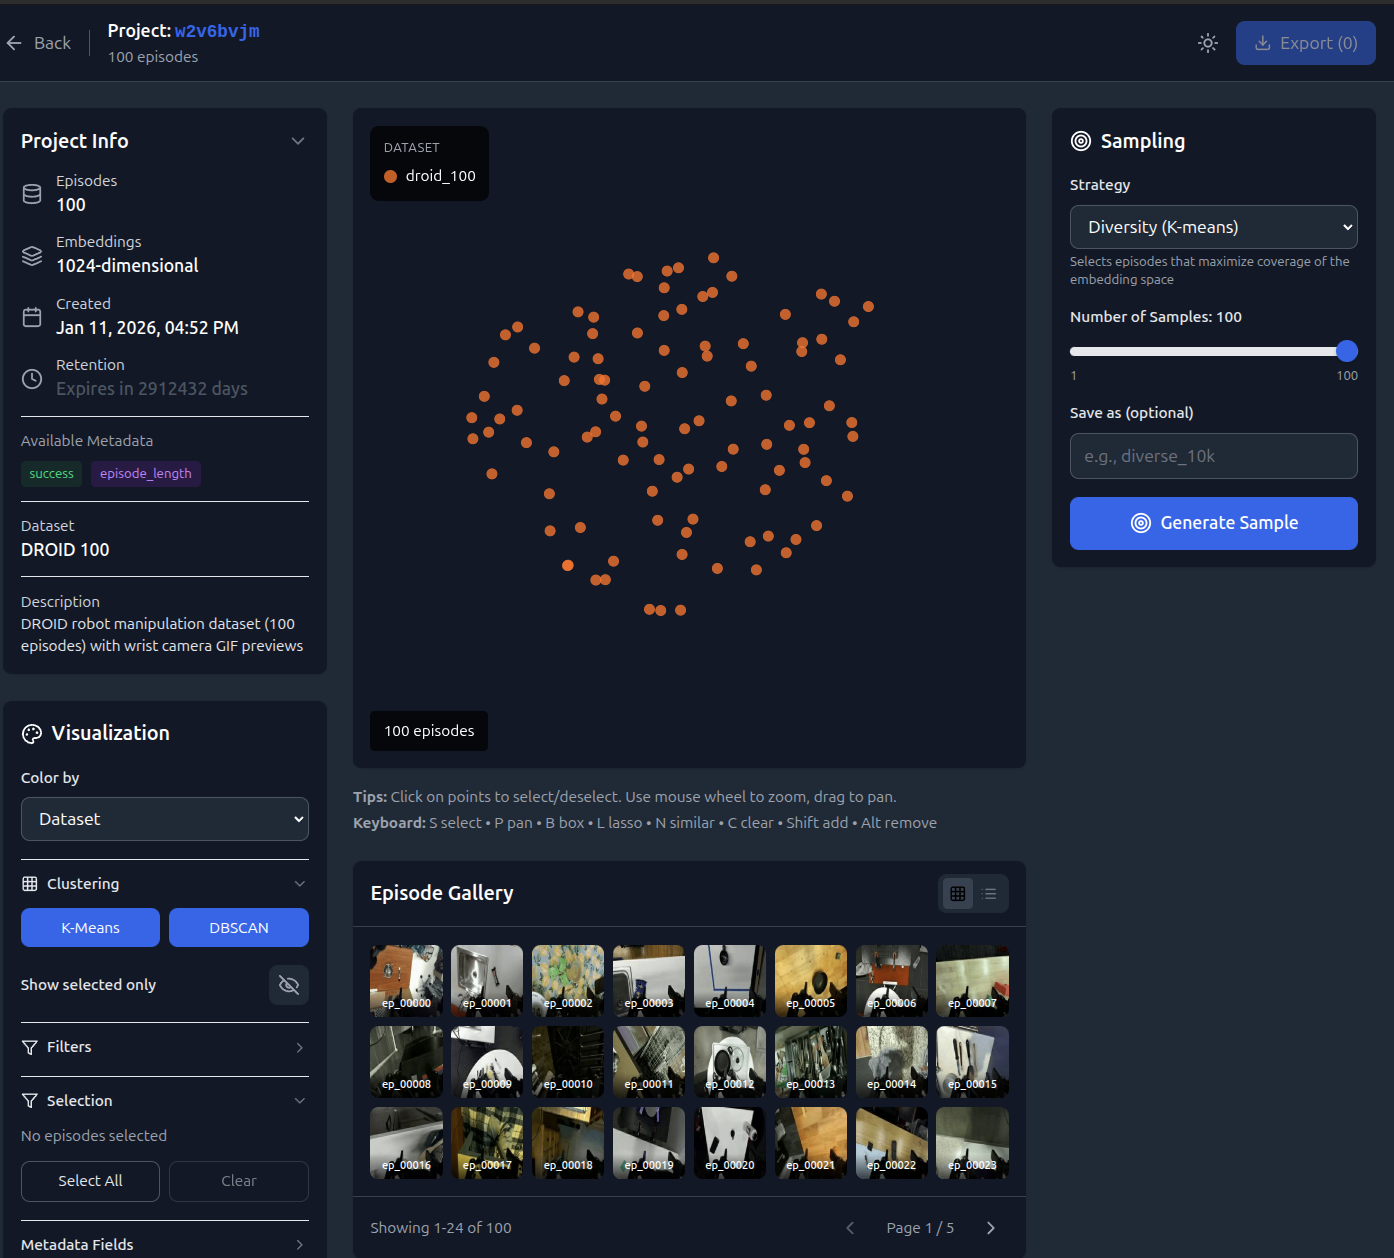
Visualize episode embeddings and select maximally diverse training subsets for robotics ML. Train on 10K diverse episodes instead of 50K random ones.
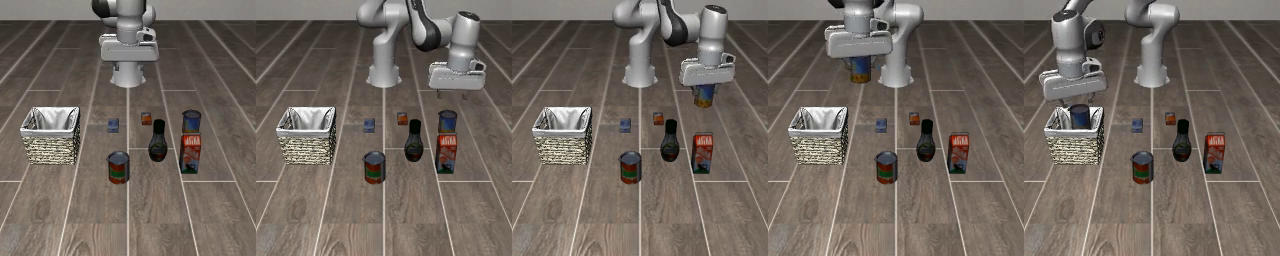
1-click robot foundation model (VLA, world action model, LLM agent) simulation and evaluation on AWS GPU instances with AWS CDK
Step-by-step 3D build guide for the SO-101 arm
Runs in the browser on Hugging Face
A follow-up on video encoding in LeRobot datasets.
Runs in the browser on Hugging Face
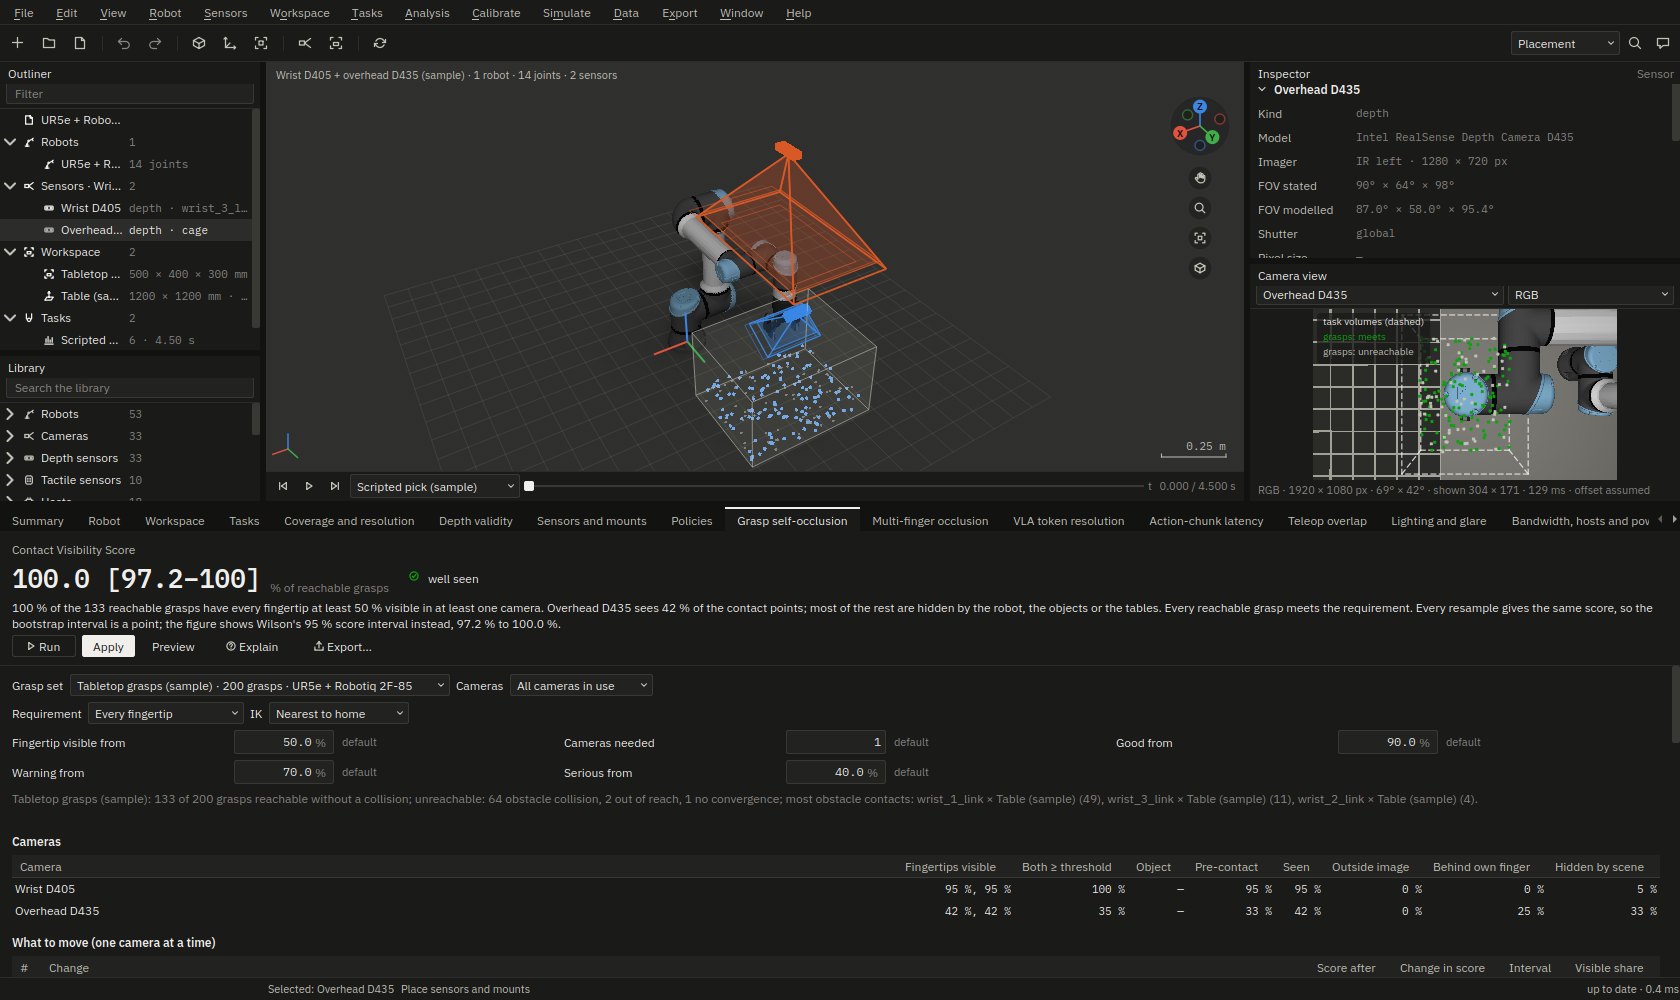
Desktop app for planning the camera and sensor rig of robot-learning setups: grasp visibility, depth validity, calibration, dataset audits and MuJoCo/LeRobot/Isaac exports. Linux, GPL-3.0.
How LeRobot and Hugging Face help companies start robotics
Runs in the browser on Hugging Face
LeRobot Hackathon Vitoria-Gasteiz 2026 — SO-101 pin sorting
Runs in the browser on Hugging Face
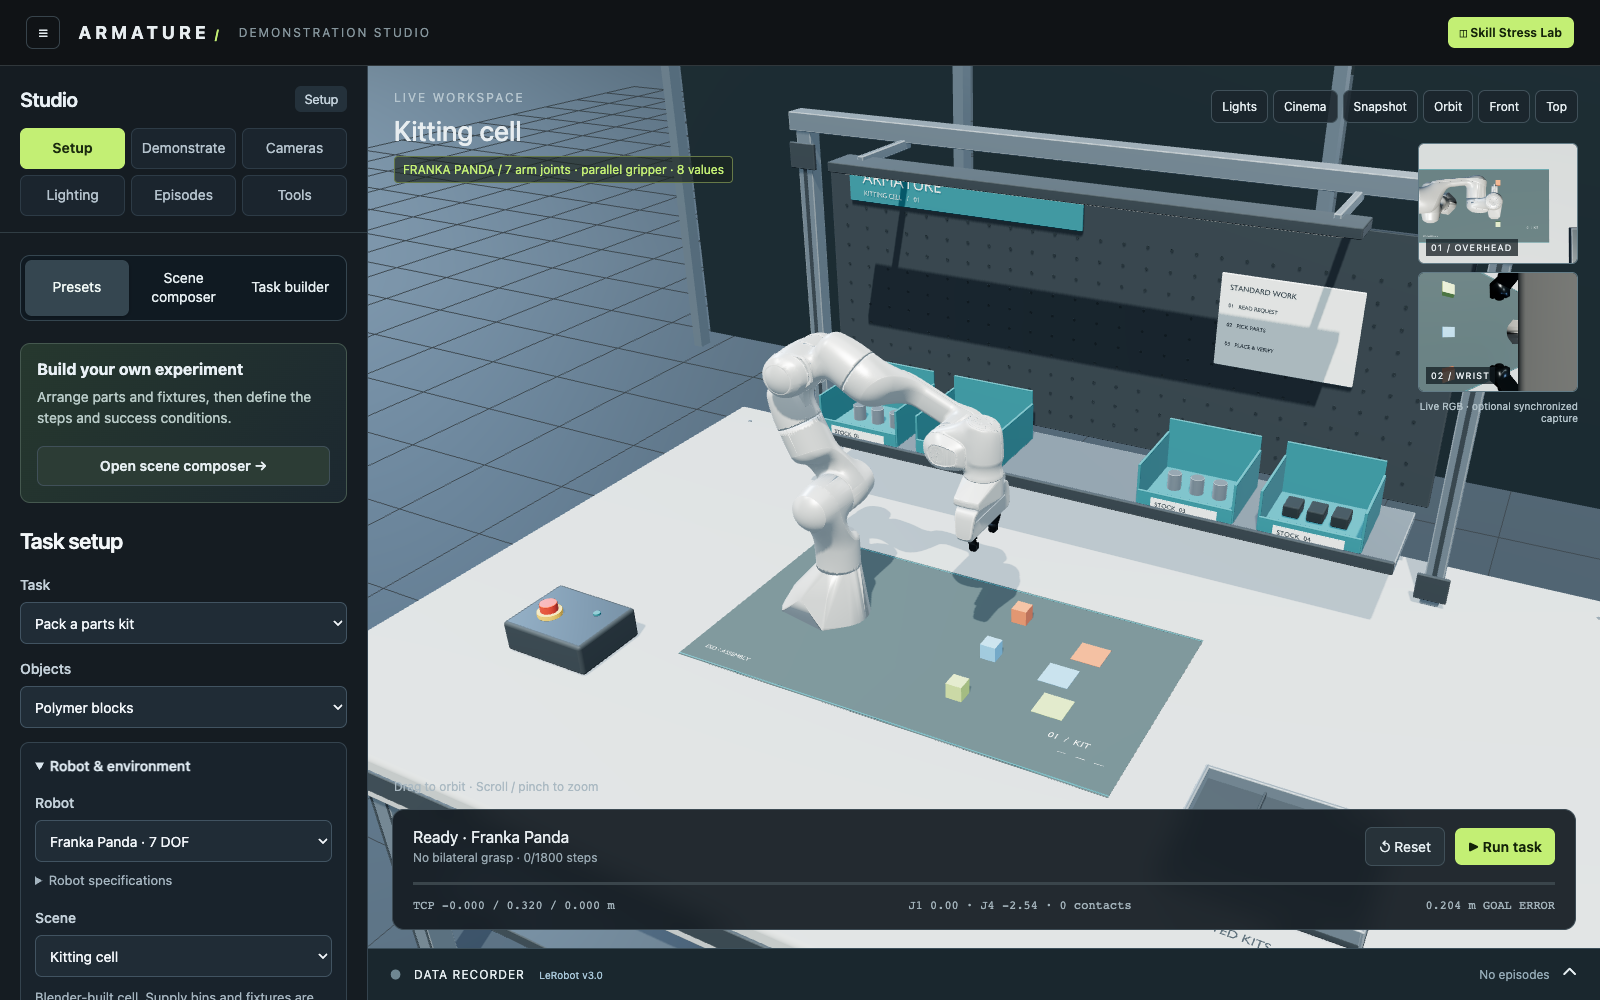
Browser-based robotics studio for scene authoring, kitting tasks, demonstration recording, and repeatable experiments. Runs as a self-contained HTML page.
Veridex is the trust certificate for physical-AI data that tells you, across any format, whether the robot or sensor dataset you're about to train on is clean, correctly synchronized, and traceable to its source, before it silently wrecks your model.
Tools to set up, repair, and run the Seeed SO-ARM101 robot arm on LeRobot without brownouts.
Rust I/O for inspecting, accessing, and creating subsets of packed LeRobot datasets
Right-size a robot, GPU and board; compare cost, energy, CO2
Runs in the browser on Hugging Face
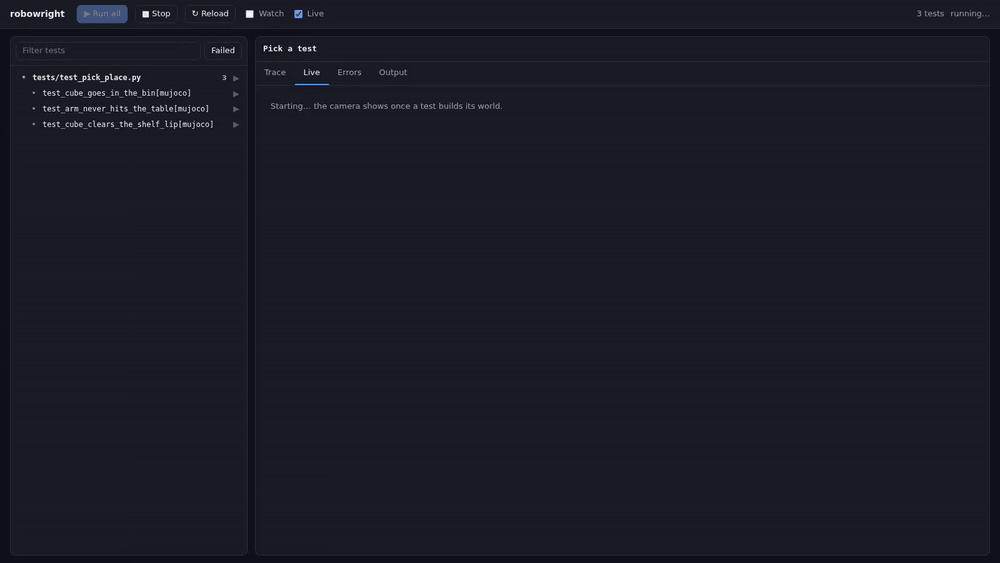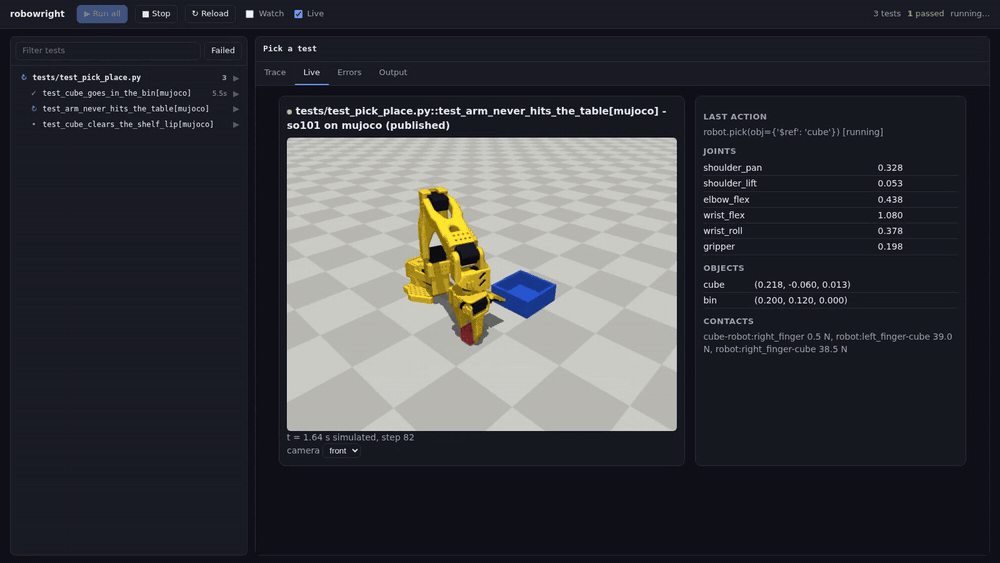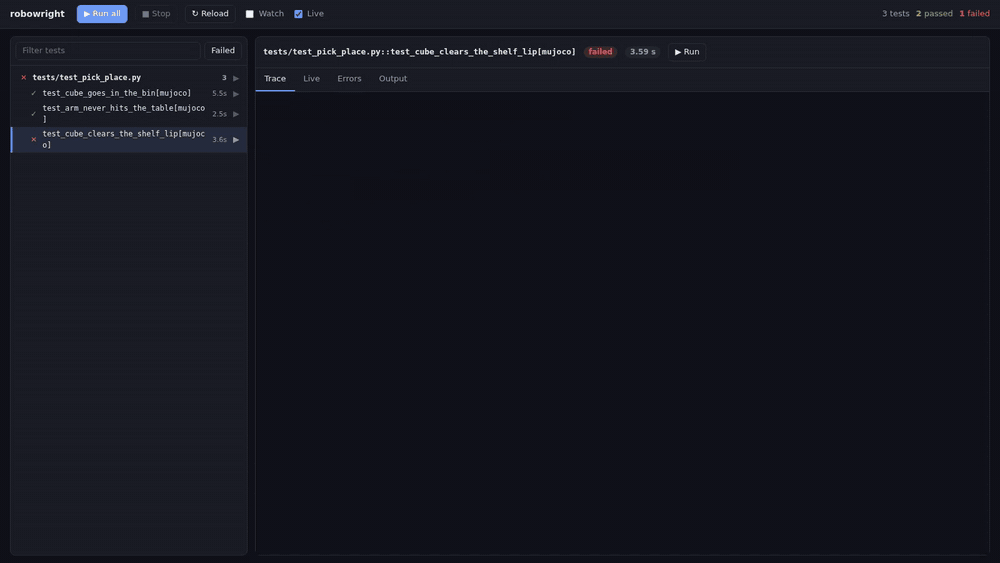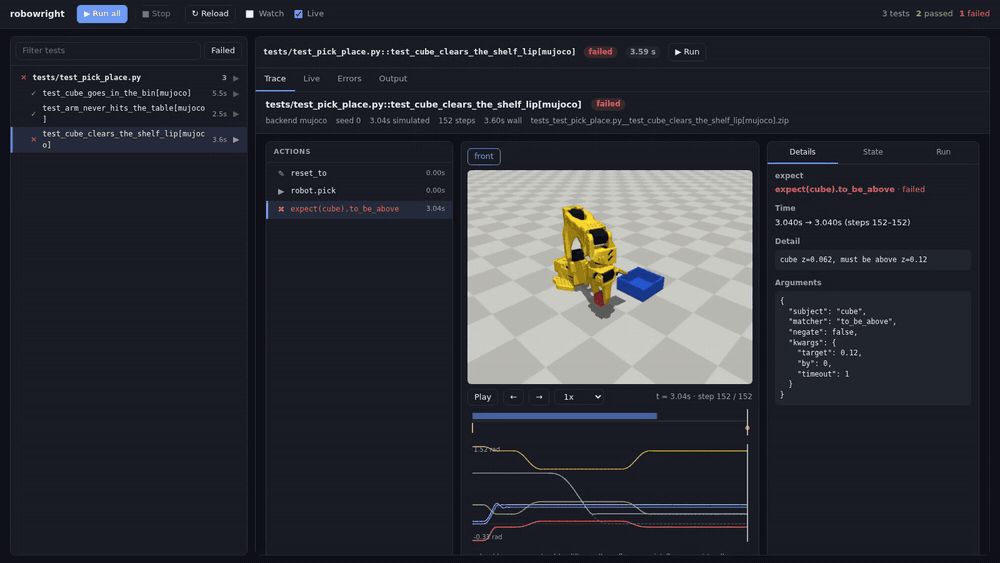
Playwright-style testing for robots: one pytest test, 19 robots (Franka, UR, Kinova, KUKA, xArm, ALOHA, Unitree, Spot...), five physics engines (MuJoCo, PyBullet, Drake, Genesis, Isaac Sim). Auto-waiting actions, expect() assertions, traces, deterministic replay, codegen.
Tiny vision language action (VLA) model built on Language-conditioned Action Chunking (LC-ACT) architecture.
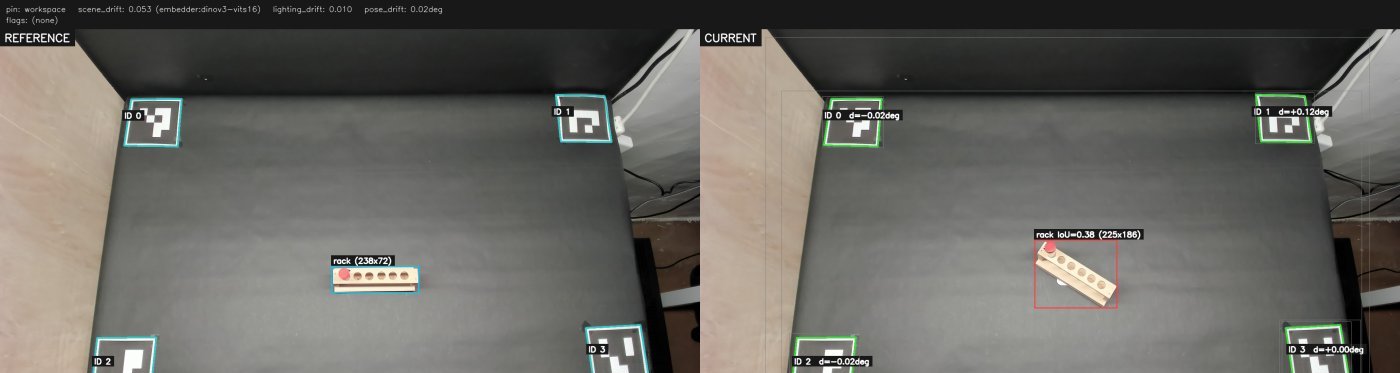
ANVIL- Anchored Norm Validation for Imitation Learning. Scene-consistency sentinel for robotics data collection — pin a scene, catch drift before it bakes into your dataset.