ProtoMotions
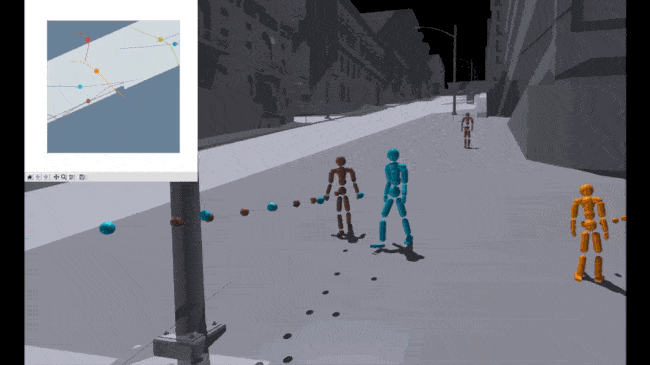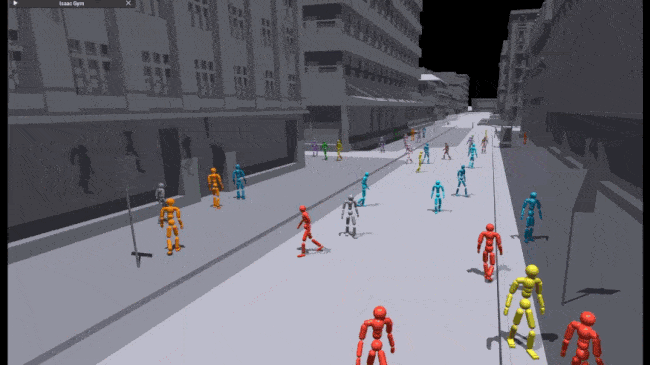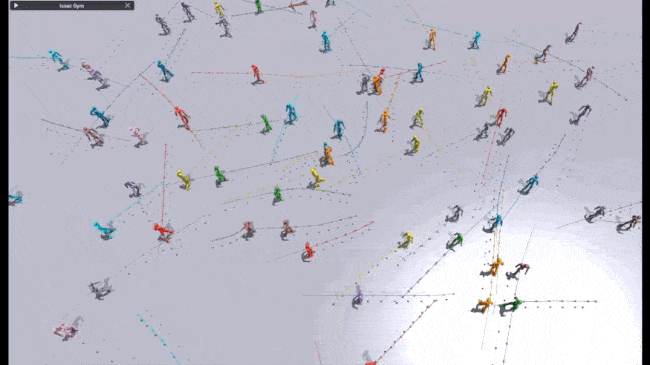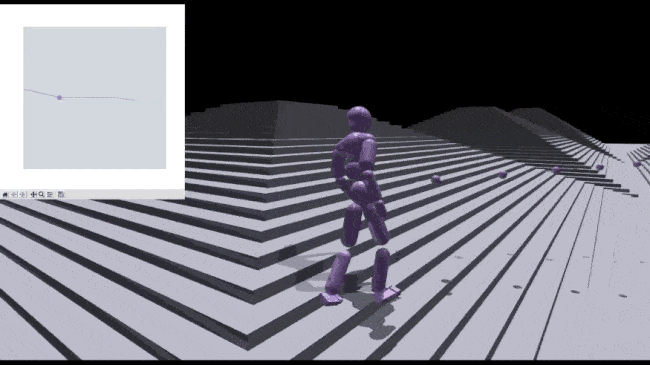
ProtoMotions is a GPU-accelerated simulation and learning framework for training physically simulated digital humans and humanoid robots.
- 2.5k
- Python
- Apache-2.0
- 11 d ago
[NeurIPS 2023] InsActor: Instruction-driven Physics-based Characters
Repo MotrixLab/insactor, read from GitHub 16 min ago. MotrixLab has not joined Take My Repo.
MotrixLab/insactor is a public repo on GitHub by MotrixLab. [NeurIPS 2023] InsActor: Instruction-driven Physics-based Characters. It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it. It is written mainly in Python, has 139 stars and last changed on 2026-02-12. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-21.
GitHub is limiting requests or did not answer. The facts on this page still come from the last successful read.
Open on GitHubMotrixLab/insactor is a public repo on GitHub by MotrixLab. [NeurIPS 2023] InsActor: Instruction-driven Physics-based Characters.
It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it.
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Its last change on GitHub was on 2026-02-12. Take My Repo does not judge from that whether it is maintained.
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.
ProtoMotions is a GPU-accelerated simulation and learning framework for training physically simulated digital humans and humanoid robots.
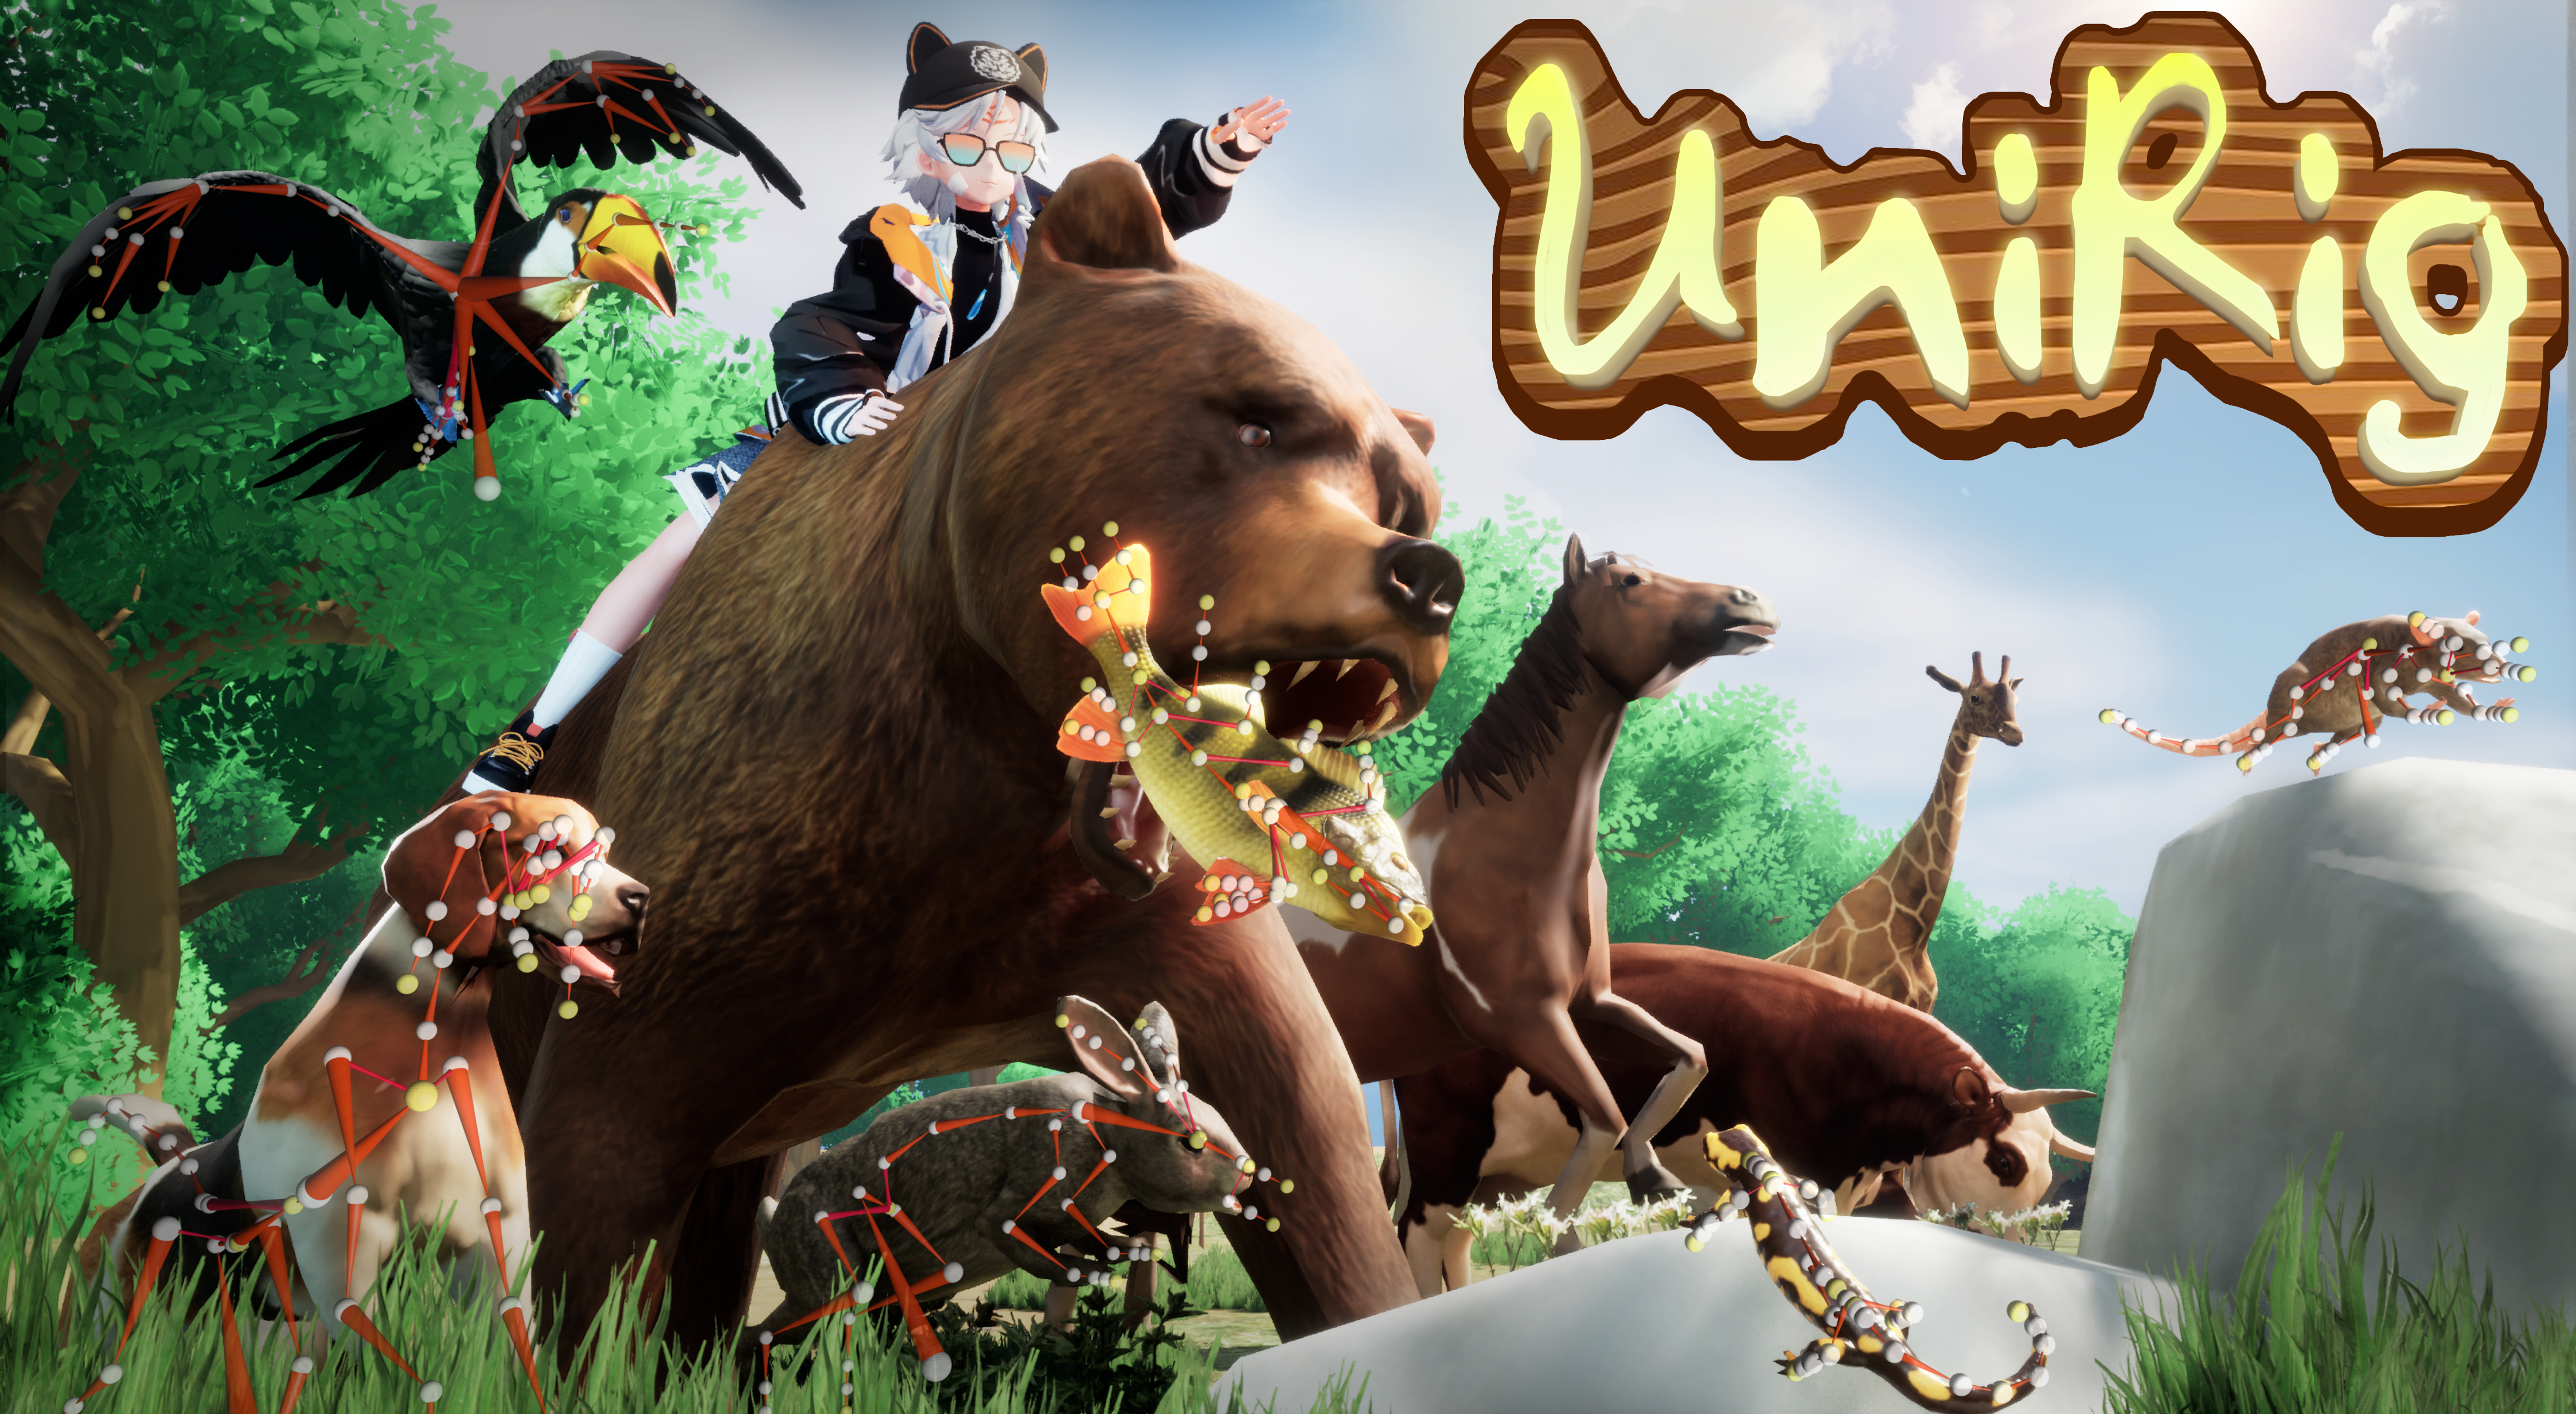
[SIGGRAPH 2025] One Model to Rig Them All: Diverse Skeleton Rigging with UniRig
Official implementation of TRACE, the TRAjectory Diffusion Model for Controllable PEdestrians, from the CVPR 2023 paper: "Trace and Pace: Controllable Pedestrian Animation via Guided Trajectory Diffusion".
An end-to-end library for editing and rendering motion of 3D characters with deep learning [SIGGRAPH 2020]
Official implementation of TeSMo, a method for text-controlled scene-aware motion generation, from the ECCV 2024 paper: "Generating Human Interaction Motions in Scenes with Text Control".
Official implementation of "MIMO: Controllable Character Video Synthesis with Spatial Decomposed Modeling"
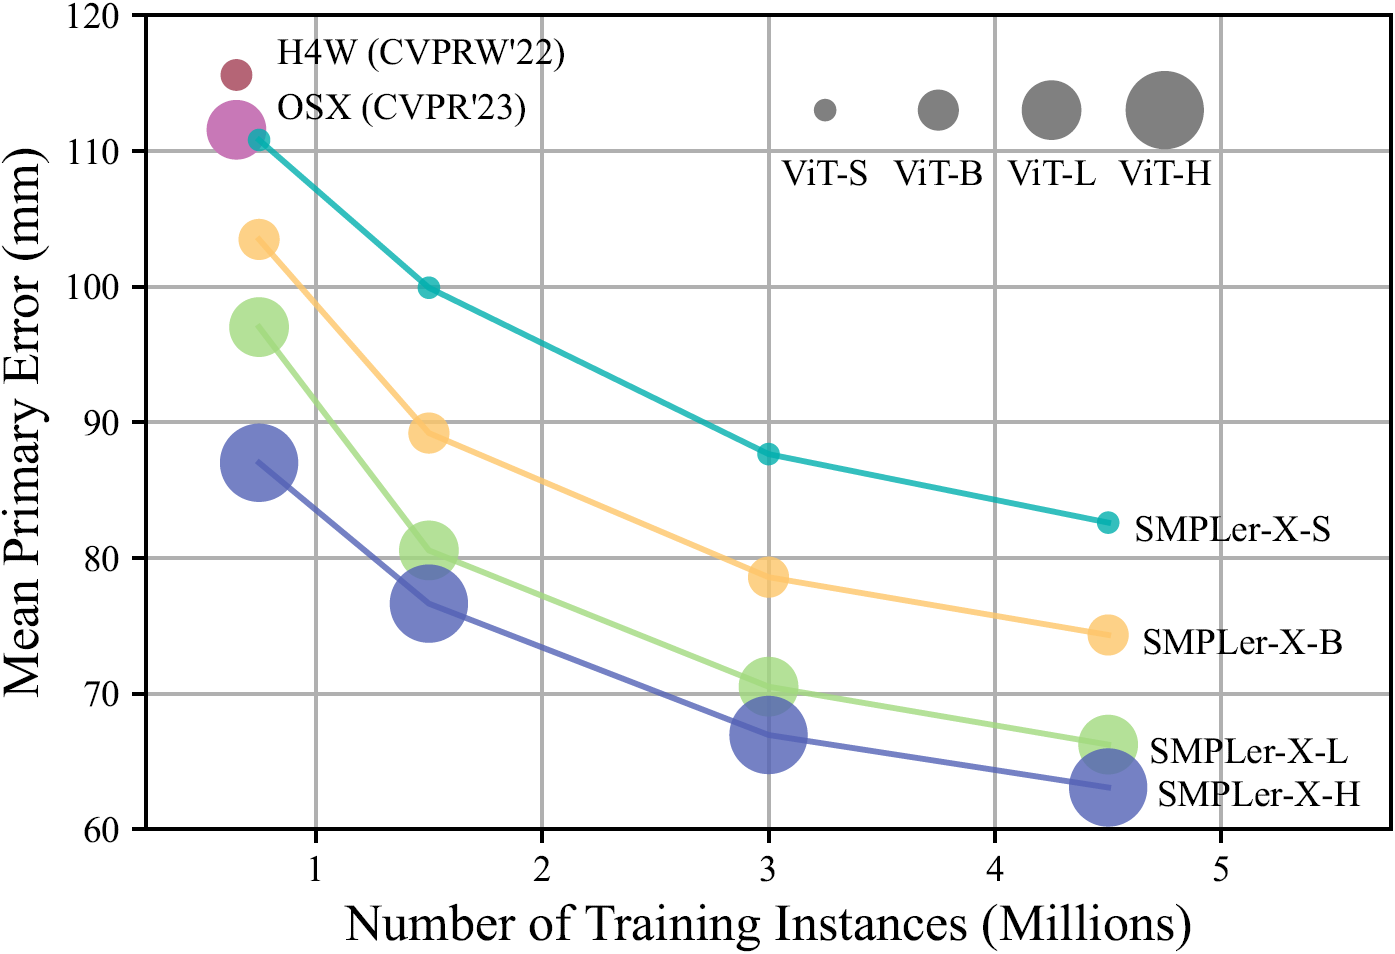
[NeurIPS 2023] Official Code for "SMPLer-X: Scaling Up Expressive Human Pose and Shape Estimation"
MotionDiffuse: Text-Driven Human Motion Generation with Diffusion Model
[CVPR 2024] Official Code for "AiOS: All-in-One-Stage Expressive Human Pose and Shape Estimation
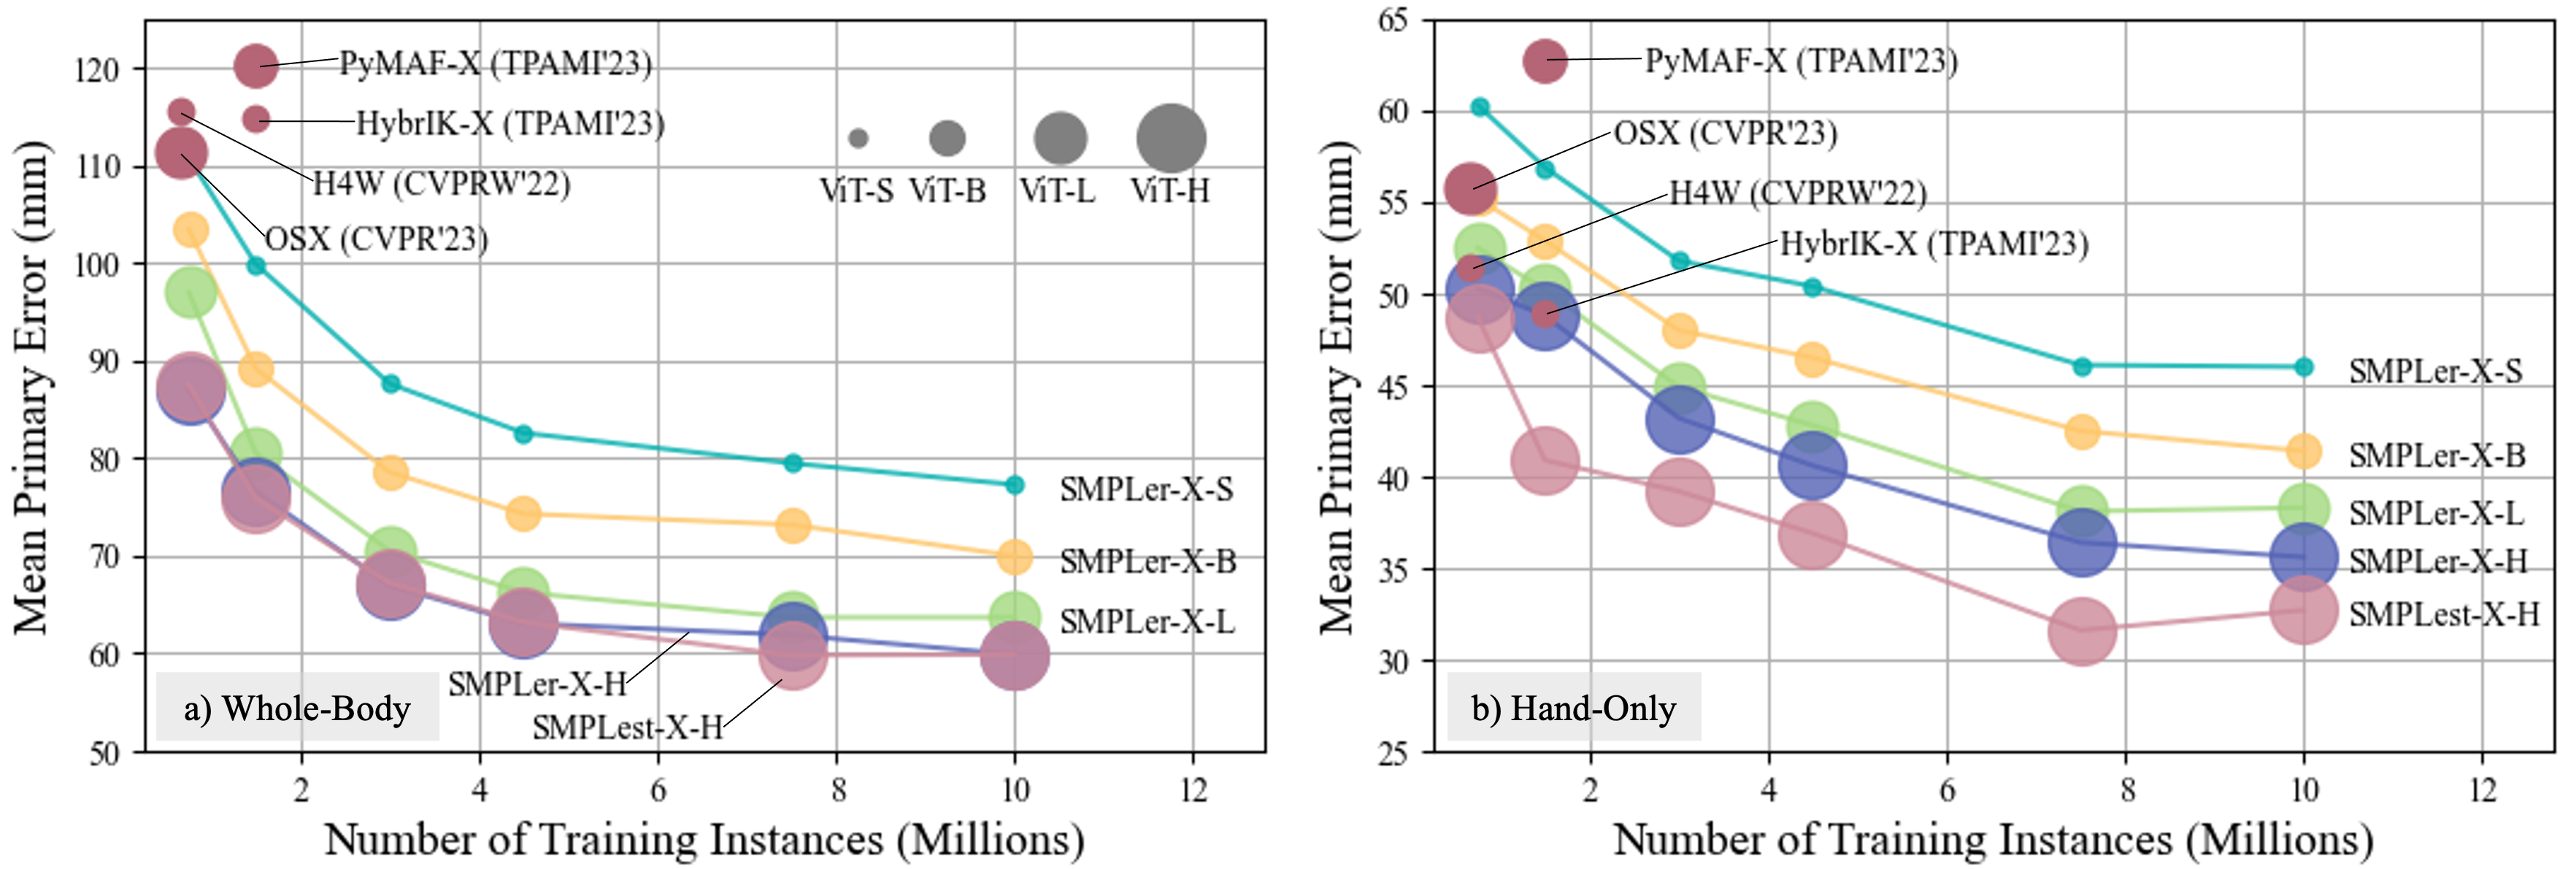
[TPAMI 2025] Official Code for "SMPLest-X: Ultimate Scaling for Expressive Human Pose and Shape Estimation"