Unity-Robotics-Hub
Central repository for tools, tutorials, resources, and documentation for robotics simulation in Unity.
- 2.6k
- C#
- 8 wk ago
Central repository for tools, tutorials, resources, and documentation for robotics simulation in Unity.
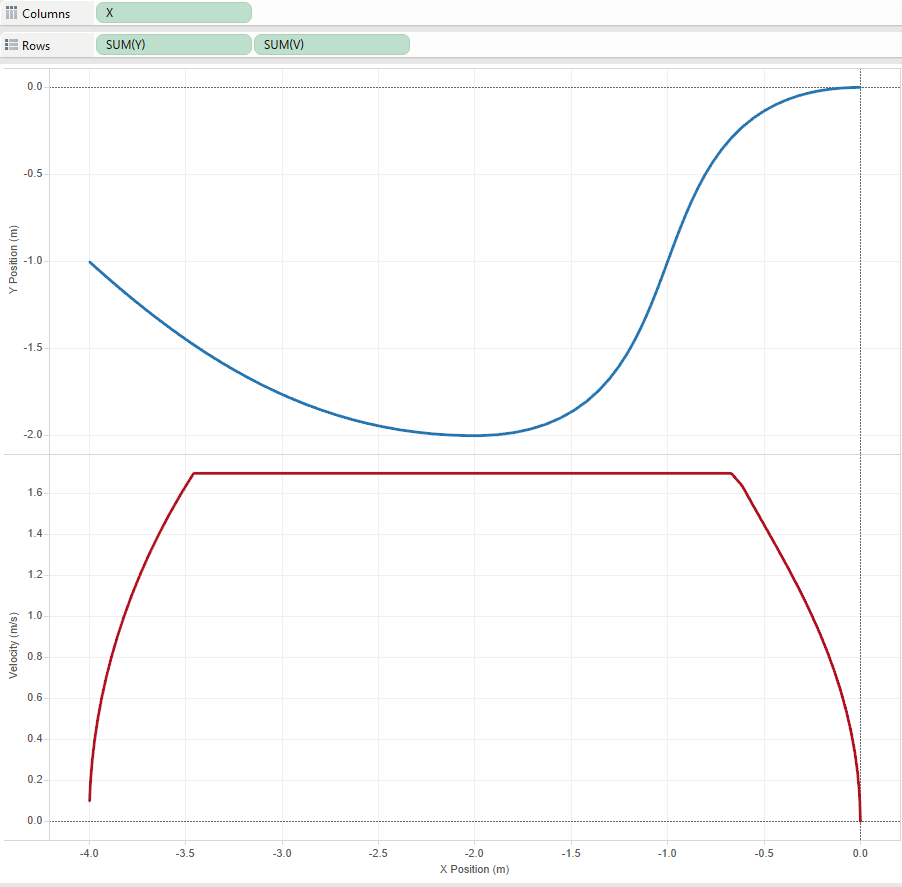
Motion Generation for Robots and Machines. Real-time. Jerk-constrained. Time-optimal.
FISS & FISS+: Fast Iterative Search and Sampling trajectory planners for autonomous driving (with FOP baselines). C++17 core, Python, ROS 2 / ROS 1, Lanelet2, CARLA, MPC
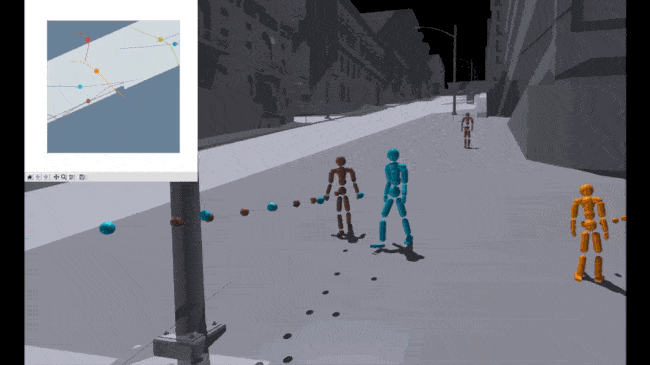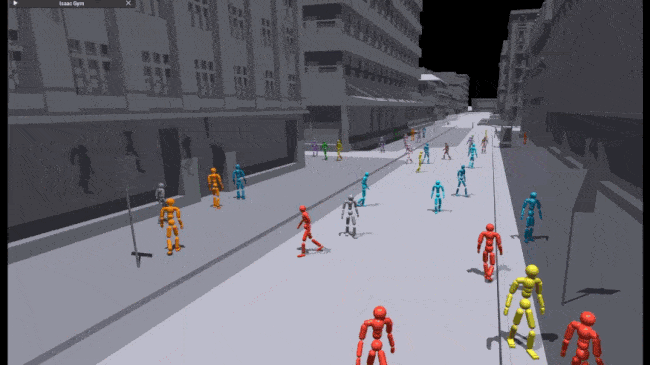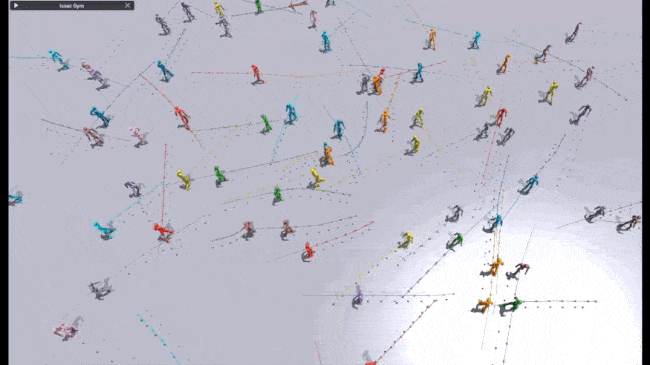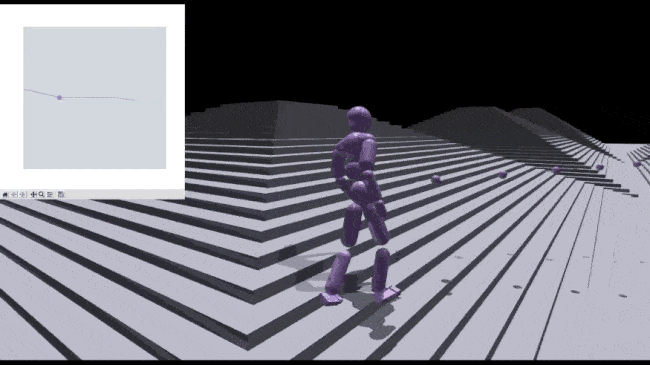
Official implementation of TRACE, the TRAjectory Diffusion Model for Controllable PEdestrians, from the CVPR 2023 paper: "Trace and Pace: Controllable Pedestrian Animation via Guided Trajectory Diffusion".
LQR-RRT* method is used for random motion planning of a simple pendulum in it's phase plot
Code accompanying the RA-L / ICRA 2020 paper: "Online Trajectory Generation with Distributed Model Predictive Control for Multi-Robot Motion Planning"
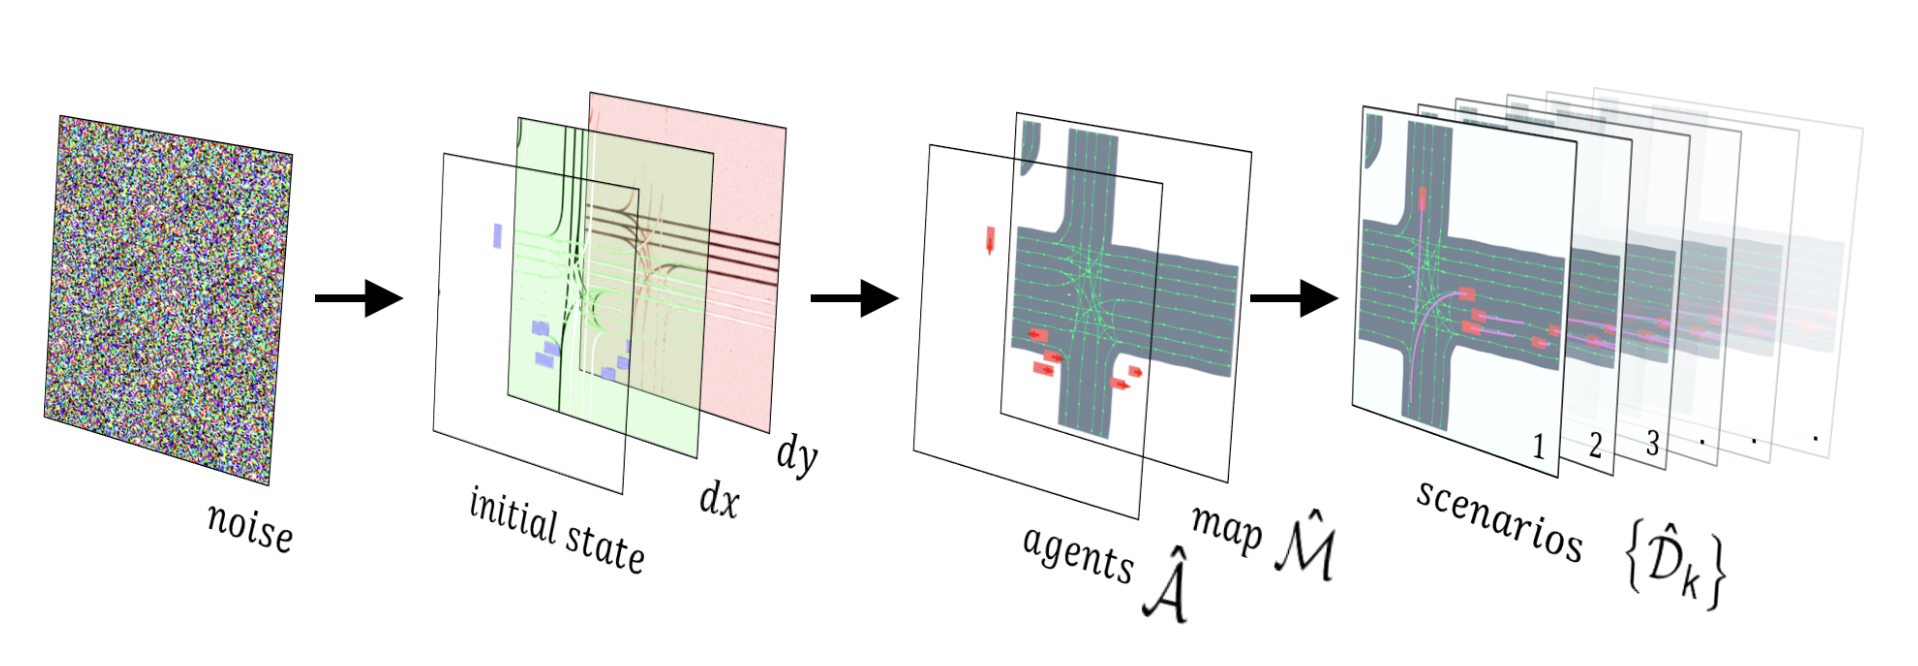
[RA-L 2024] DriveSceneGen: Generating Diverse and Realistic Driving Scenarios from Scratch
Ruckig and nonlinear filters to create dynamically feasible reference trajectories
Udacity Self-Driving Car Nanodegree - Path Planning Project
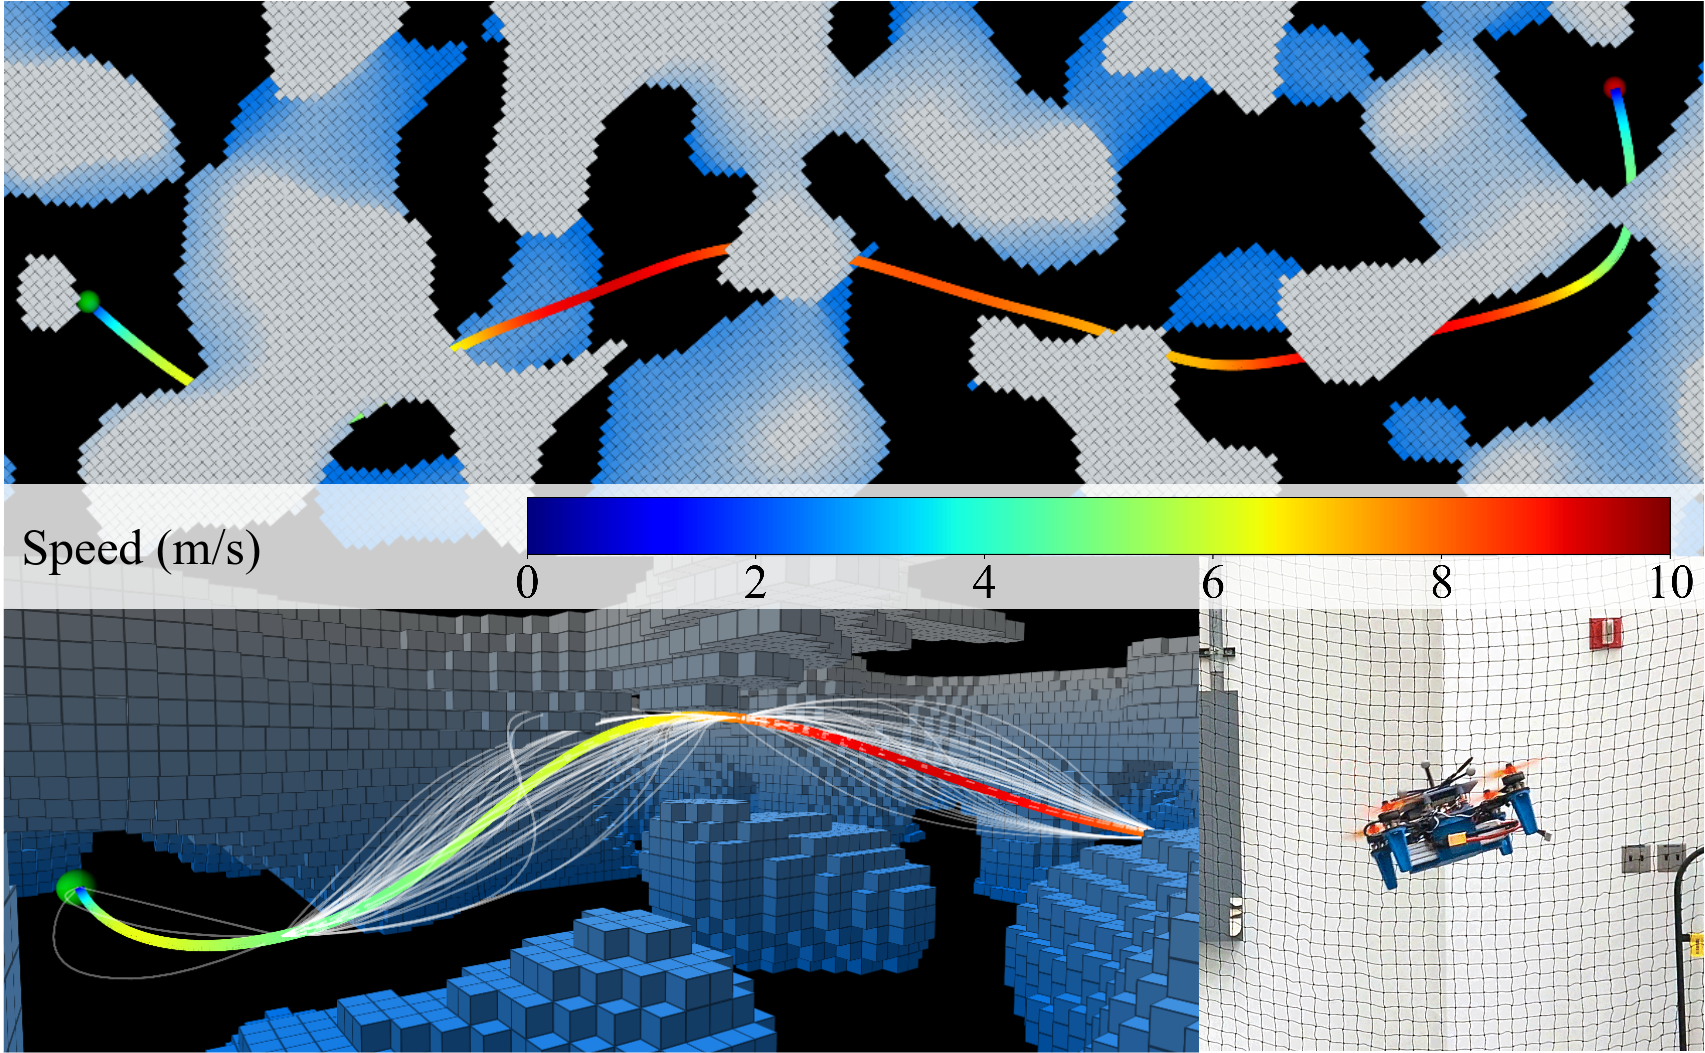
A real-time trajectory planning framework leveraging motion primitive search for mobile robots
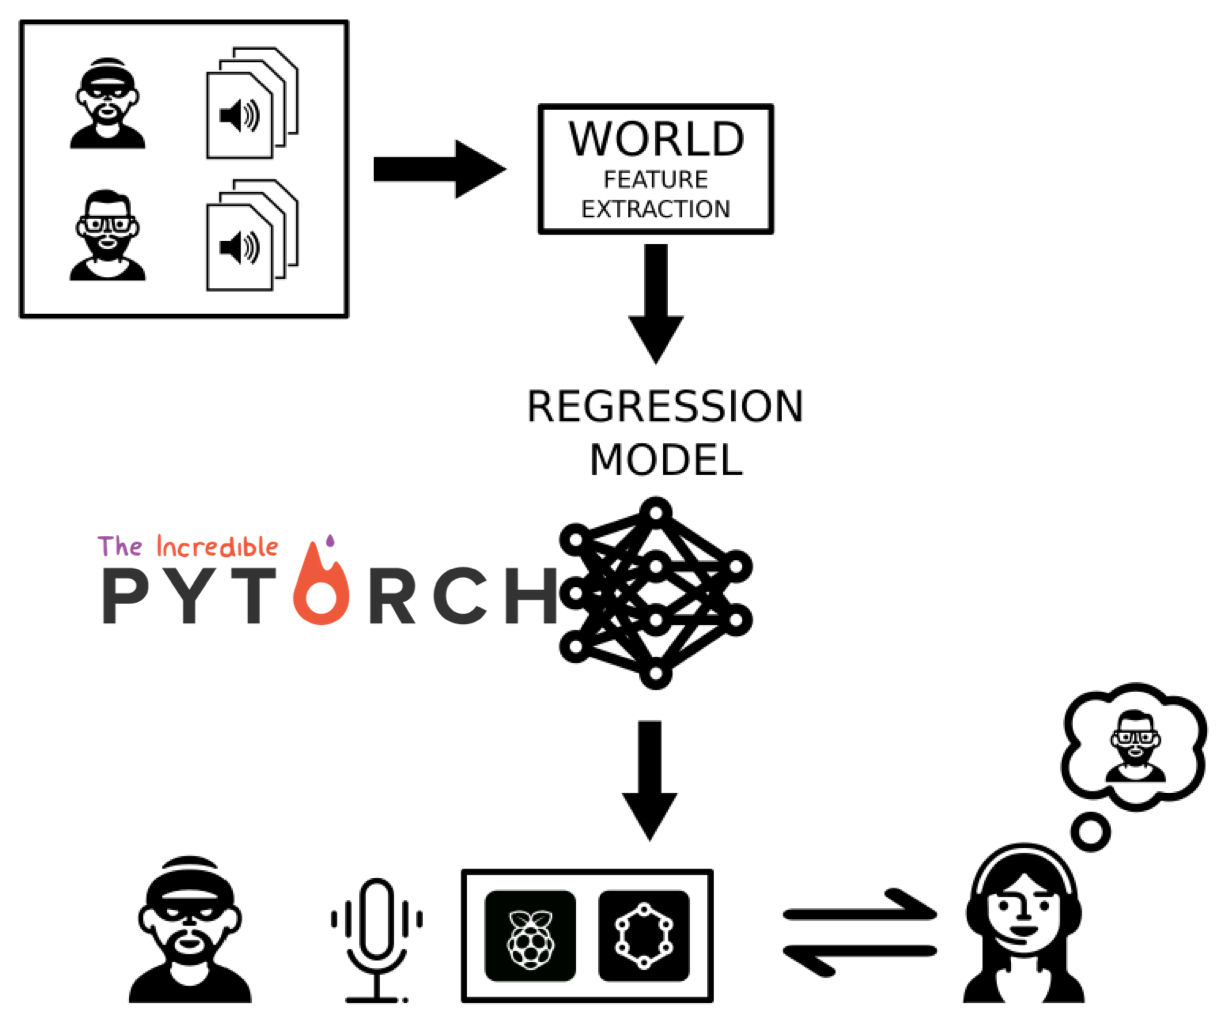
Voice Alignment and Conversion with Neural Networks and the WORLD codec.
An unofficial interface from Julia to Acados going through Casadi using PyCall
DMOC method for a simple pendulum swing-up control