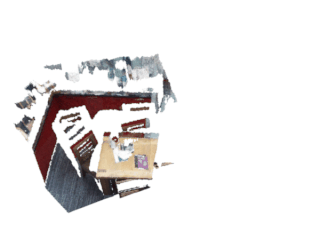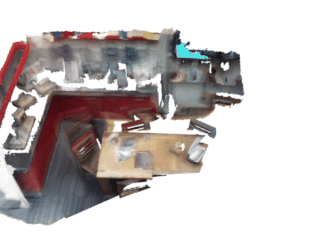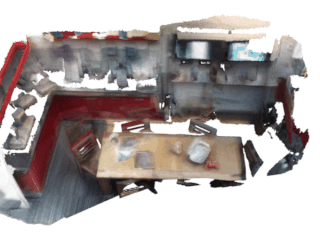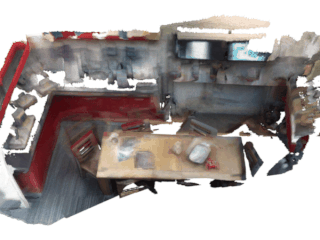
tsdf-fusion-python
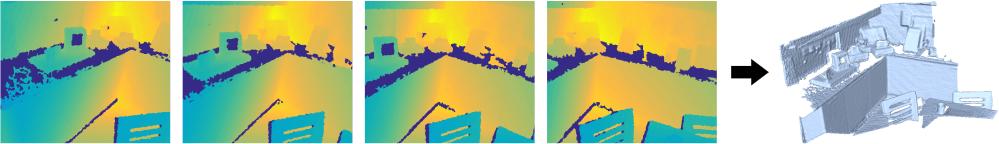
Python code to fuse multiple RGB-D images into a TSDF voxel volume.
- 1.4k
- Python
- BSD-2-Clause
- 4 y ago
The maintainer has not written a description at the source.
Repo andyzeng/andyzeng.github.io, read from GitHub 17 h ago. andyzeng has not joined Take My Repo.
andyzeng/andyzeng.github.io is a public repo on GitHub by andyzeng. It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it. It is written mainly in HTML, has 59 stars and last changed on 2026-09-13. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-22.
andyzeng/andyzeng.github.io is a public repo on GitHub by andyzeng. Its maker has not written a description.
It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it.
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Its last change on GitHub was on 2026-09-13. Take My Repo does not judge from that whether it is maintained.
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.
Python code to fuse multiple RGB-D images into a TSDF voxel volume.
Train robotic agents to learn to plan pushing and grasping actions for manipulation with deep reinforcement learning.
3DMatch - a 3D ConvNet-based local geometric descriptor for aligning 3D meshes and point clouds.
MIT-Princeton Vision Toolbox for Robotic Pick-and-Place at the Amazon Robotics Challenge 2017 - Robotic Grasping and One-shot Recognition of Novel Objects with Deep Learning.
MIT-Princeton Vision Toolbox for the Amazon Picking Challenge 2016 - RGB-D ConvNet-based object segmentation and 6D object pose estimation.