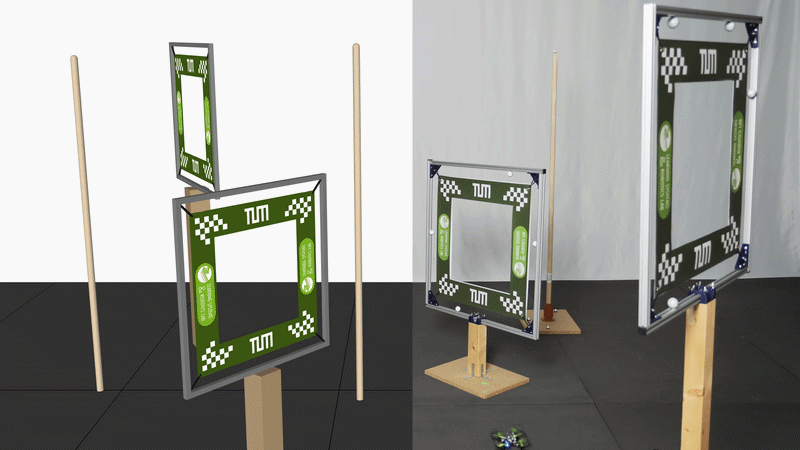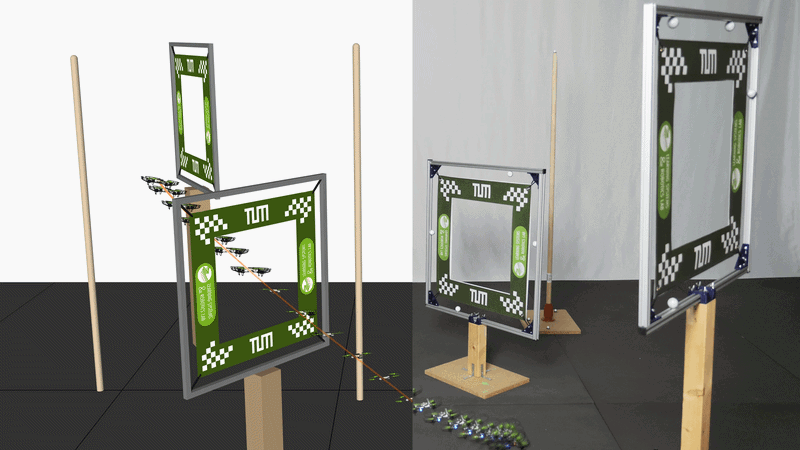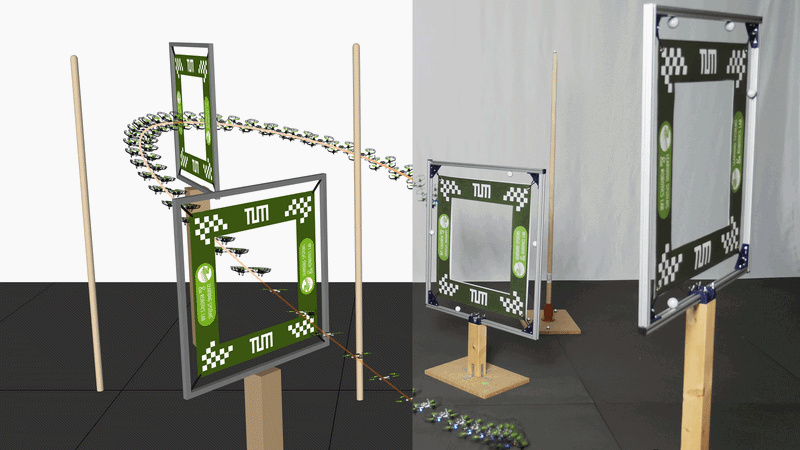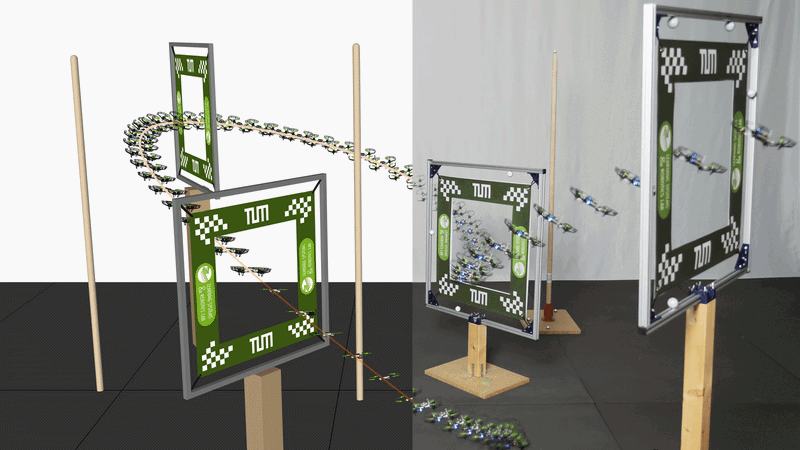
gym-pybullet-drones
PyBullet Gymnasium environments for single and multi-agent reinforcement learning of quadcopter control
- 2.2k
- Python
- MIT
- 8 d ago
Scalable drone simulation using JAX.
Repo learnsyslab/crazyflow, read from GitHub 18 h ago. learnsyslab has not joined Take My Repo.
learnsyslab/crazyflow is a public repo on GitHub by learnsyslab. Scalable drone simulation using JAX. It declares the MIT license on GitHub. It is written mainly in Python, has 208 stars and last changed on 2026-11-19. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-20.
GitHub is limiting requests or did not answer. The facts on this page still come from the last successful read.
Open on GitHublearnsyslab/crazyflow is a public repo on GitHub by learnsyslab. Scalable drone simulation using JAX.
It declares the MIT license on GitHub.
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Its last change on GitHub was on 2026-11-19. Take My Repo does not judge from that whether it is maintained.
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.
PyBullet Gymnasium environments for single and multi-agent reinforcement learning of quadcopter control
PyBullet CartPole and Quadrotor environments—with CasADi symbolic a priori dynamics—for learning-based control and RL
CRISP – Compliant ROS2 Controllers for Learning-Based Manipulation Policies
[RA-L 2023, 2025] Model predictive control and trajectory optimization for fast nonprehensile object transportation with a mobile manipulator.