upright
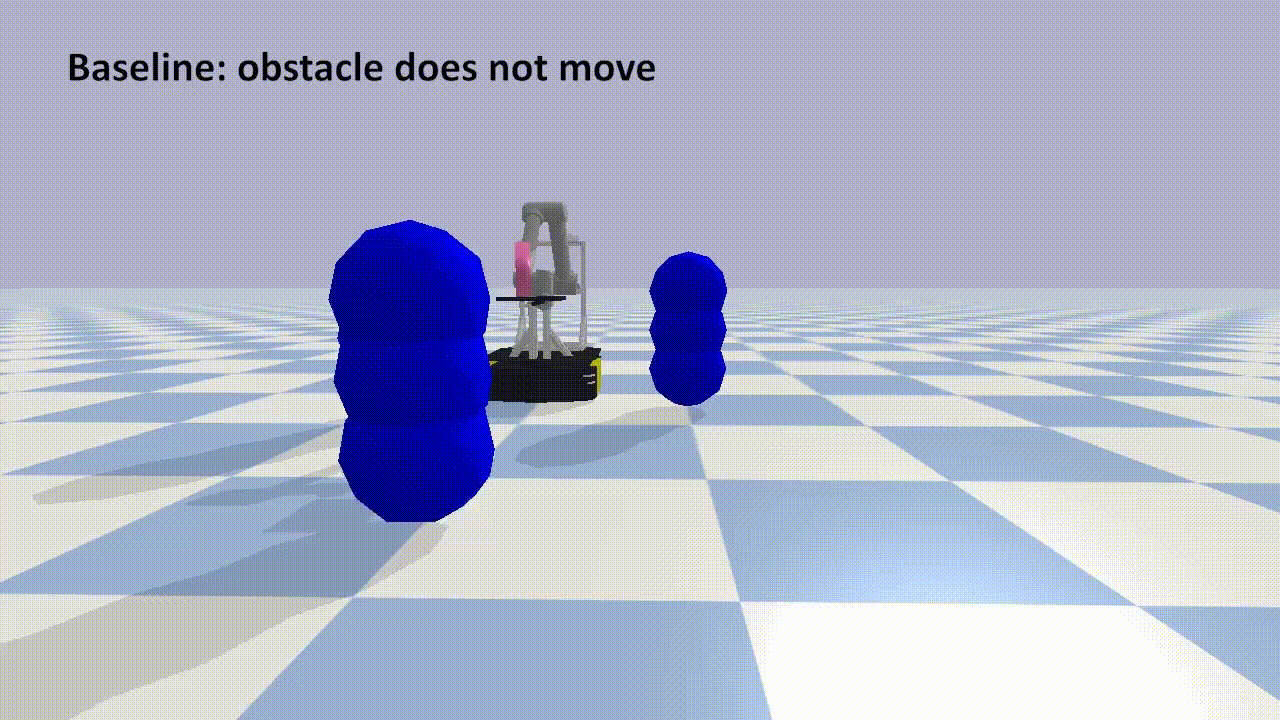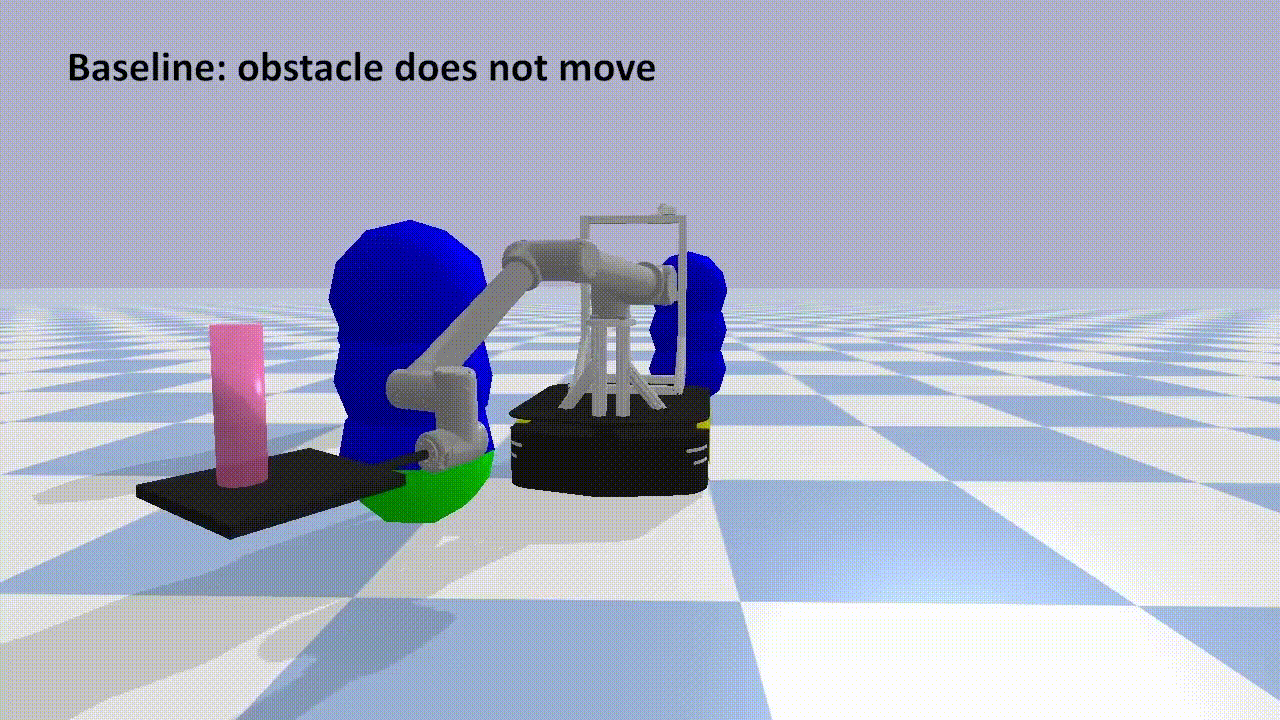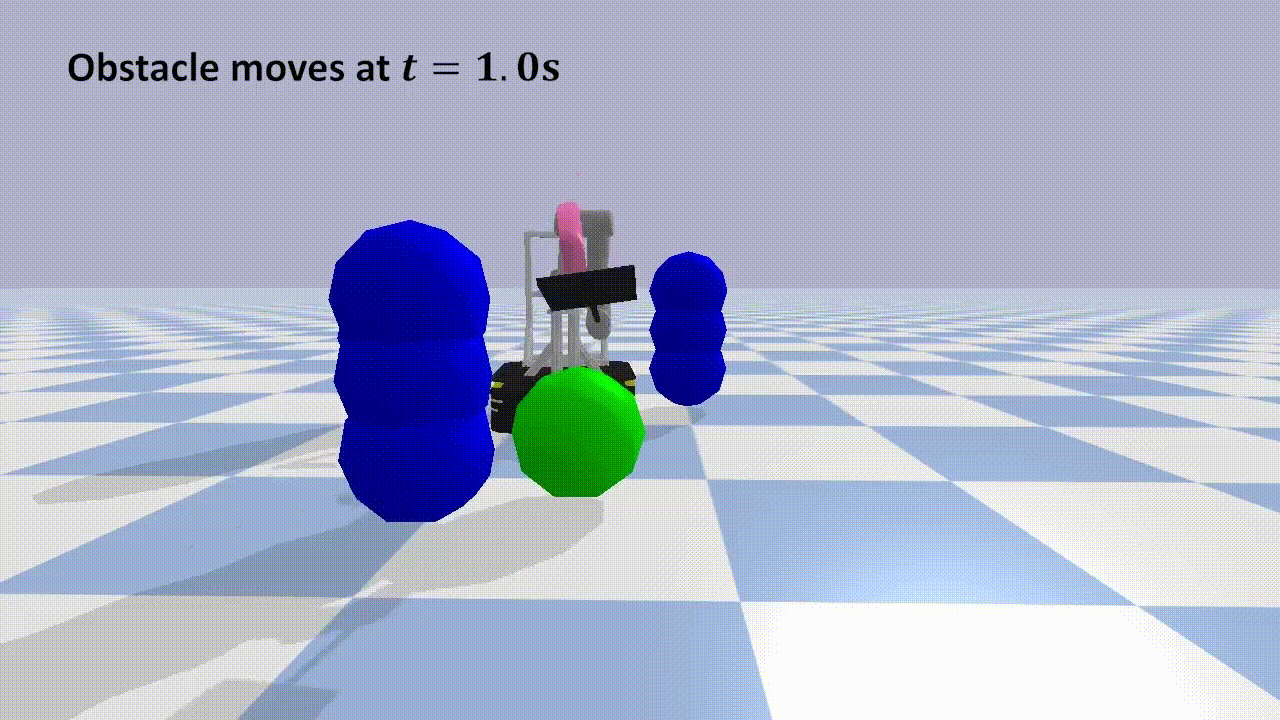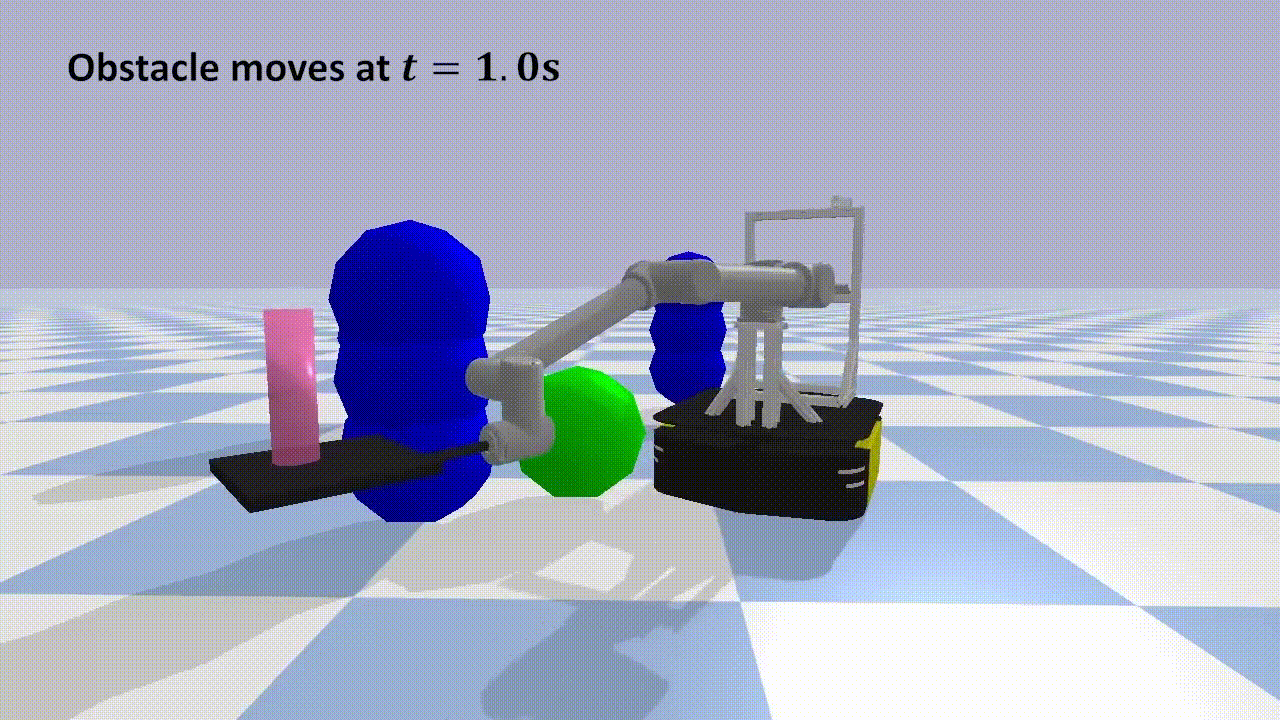
[RA-L 2023, 2025] Model predictive control and trajectory optimization for fast nonprehensile object transportation with a mobile manipulator.
- 156
- Python
- MIT
- 4 mo ago
[RA-L 2023, 2025] Model predictive control and trajectory optimization for fast nonprehensile object transportation with a mobile manipulator.
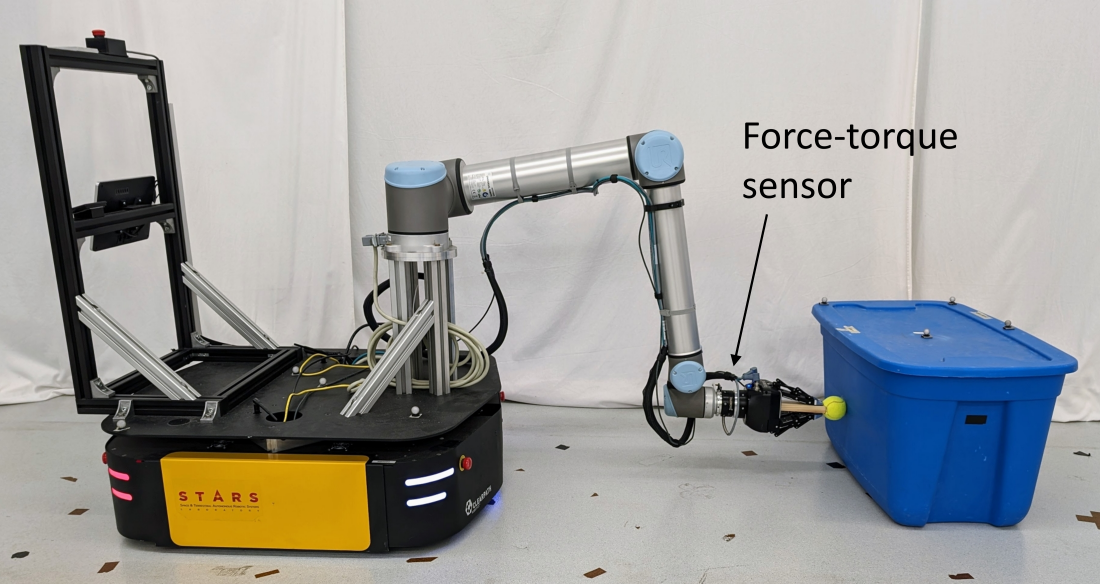
[RA-L 2024] Quasistatic robotic planar pushing with single-point contact using force feedback.
Visual grasping manipulation demo for LimX TRON2 — detect, approach, kneel and grasp with a wrist D405; ships with an OpenCV tennis-ball detector.