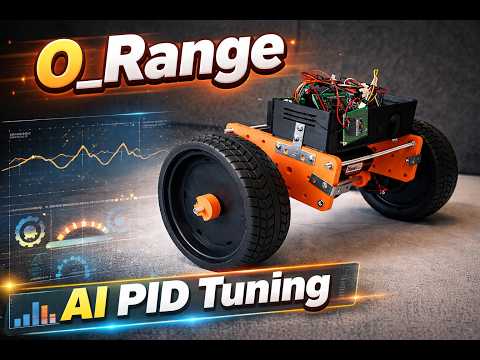
O_Range
O_range is built to explore control theory and IoT on a budget. Initially, manual PID tuning via sliders was effective but time-consuming. The real breakthrough was AI-based tuning: I modeled the robot as an inverted pendulum in Python, using SciPy's Differential Evolution to find optimal PID vals.
- 3
- Processing
- MIT
- 6 mo ago
