ROS
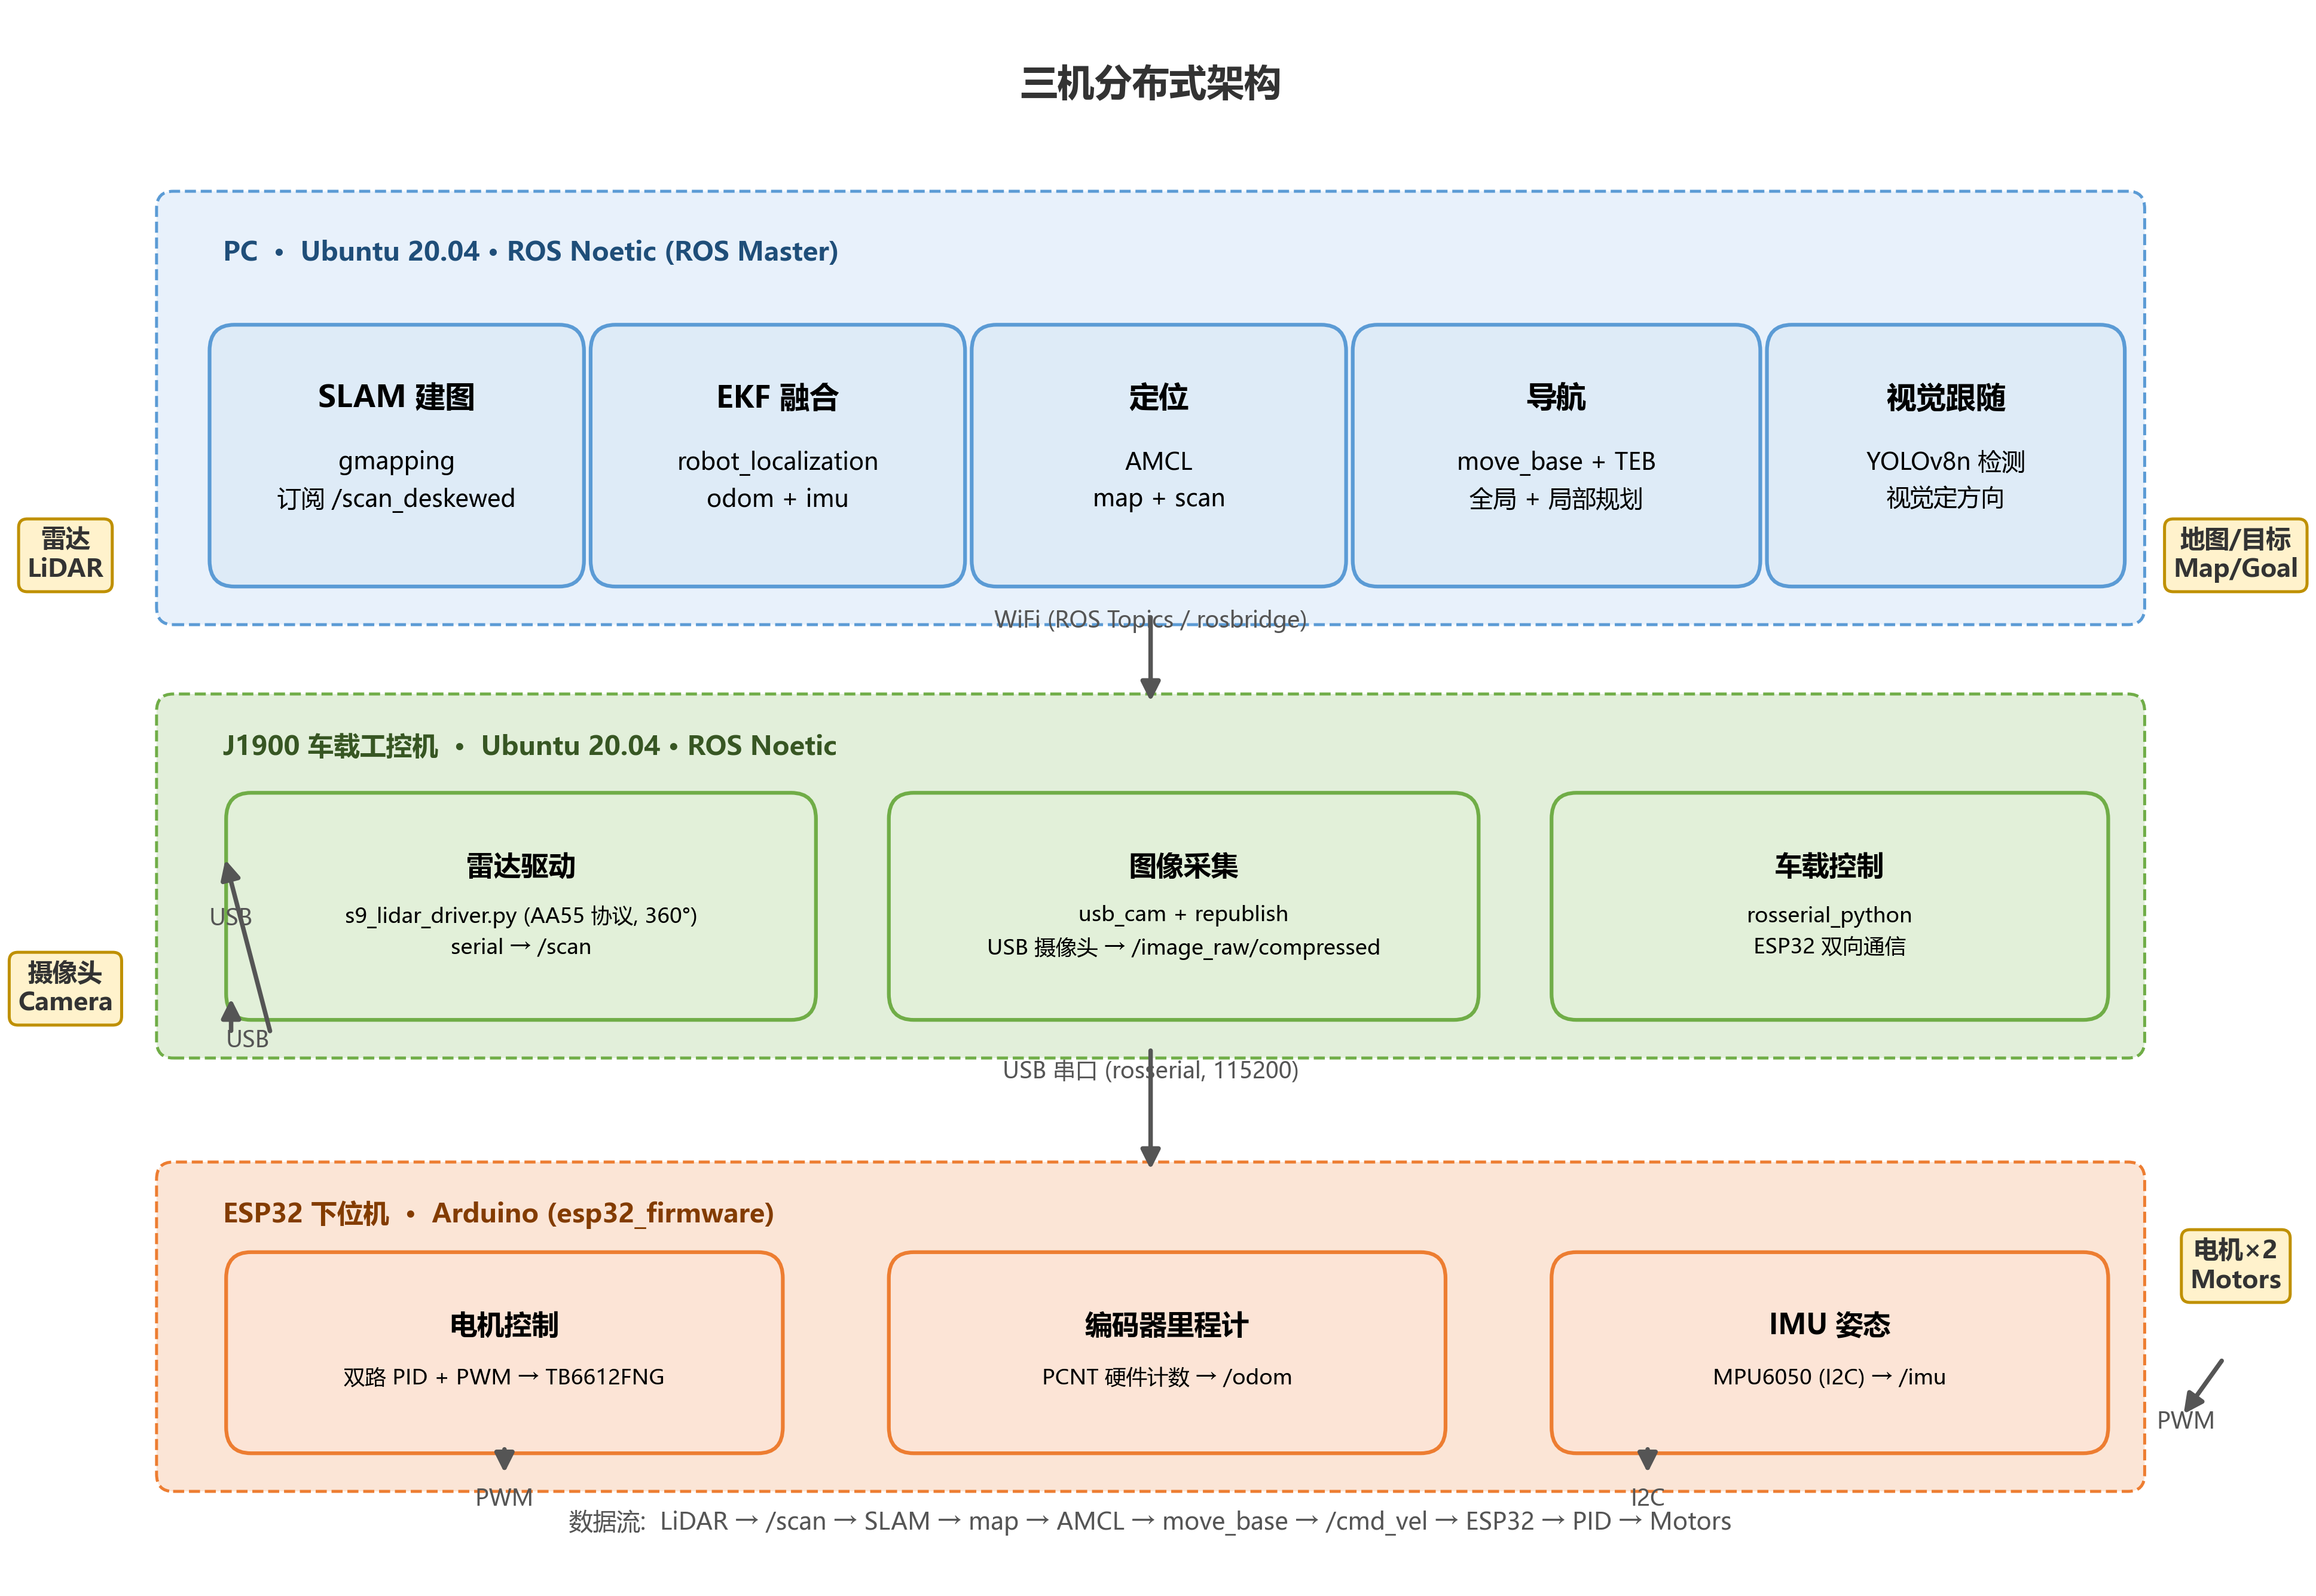
ROS Noetic 两轮差速自主移动机器人:ESP32 底盘(PID/编码器/IMU) + J1900 车载(LiDAR/相机) + PC(SLAM/导航/人体跟随),三机分布式全链路开源实现
- 106
- C++
- MIT
- 6 wk ago
ROS Noetic 两轮差速自主移动机器人:ESP32 底盘(PID/编码器/IMU) + J1900 车载(LiDAR/相机) + PC(SLAM/导航/人体跟随),三机分布式全链路开源实现
ROS 2 software stack for an upgraded LeKiwi 3-wheel omnidirectional mobile robot
Convolutional Channel Features + Online boosting-based person identification for mobile robots
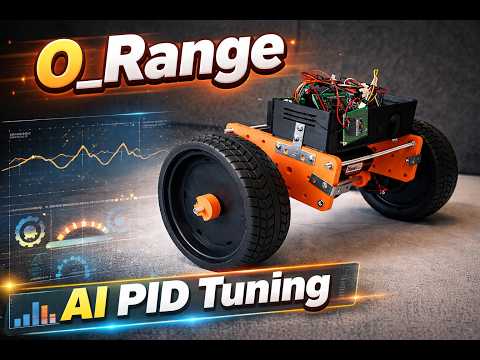
O_range is built to explore control theory and IoT on a budget. Initially, manual PID tuning via sliders was effective but time-consuming. The real breakthrough was AI-based tuning: I modeled the robot as an inverted pendulum in Python, using SciPy's Differential Evolution to find optimal PID vals.
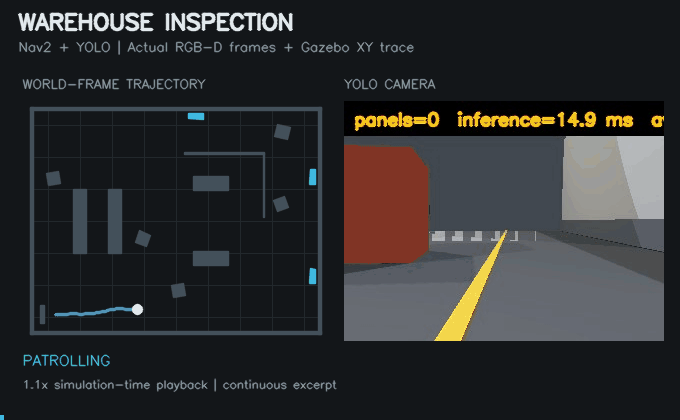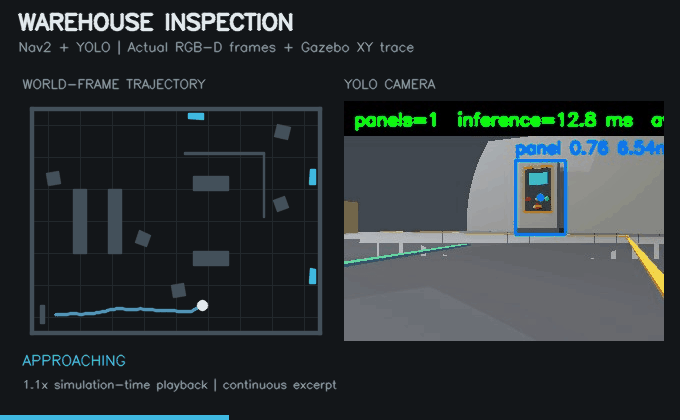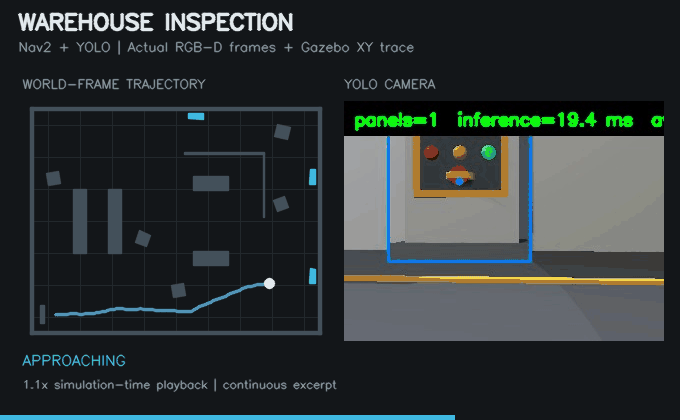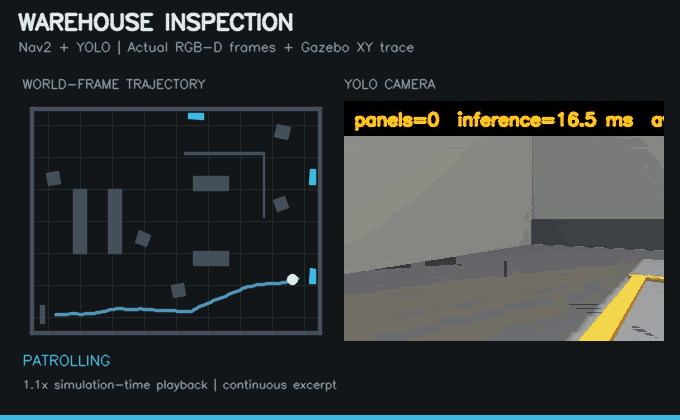
ROS 2 warehouse inspection robot with Gazebo, Nav2, RGB-D and YOLO
- Provided the MIRTO robot, designed and built by a team led by Dr. Franco Raimondi (F.Raimondi@mdx.ac.uk) at Middlesex University London, with autonomous navigation planning capabilities. - Wrote a library of high-level odometrical functionalities (i.e. Java methods) to allow MIRTO to perform actions such as rotating, translating and moving towards a specific point in space while avoiding all obs
Swerve drive system for a 4-wheel mobile robot using ATmega2560. Controlled via Bluetooth PS2 joystick. Power window motors and encoders handle steering via gear-belt mechanism.