Swerve-Drive-System
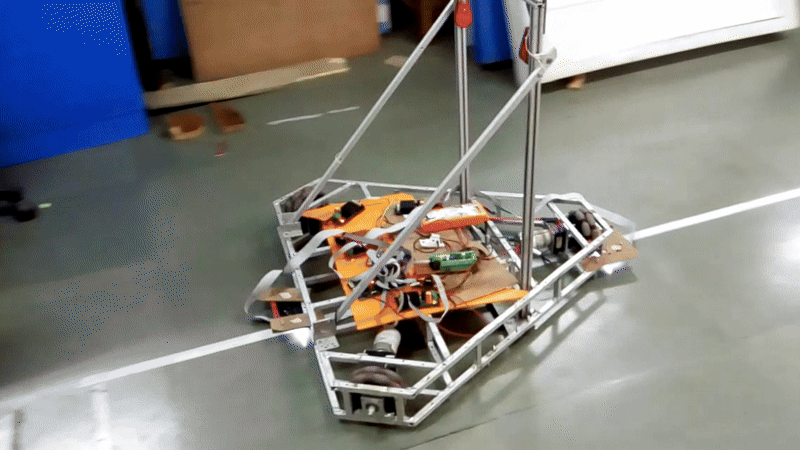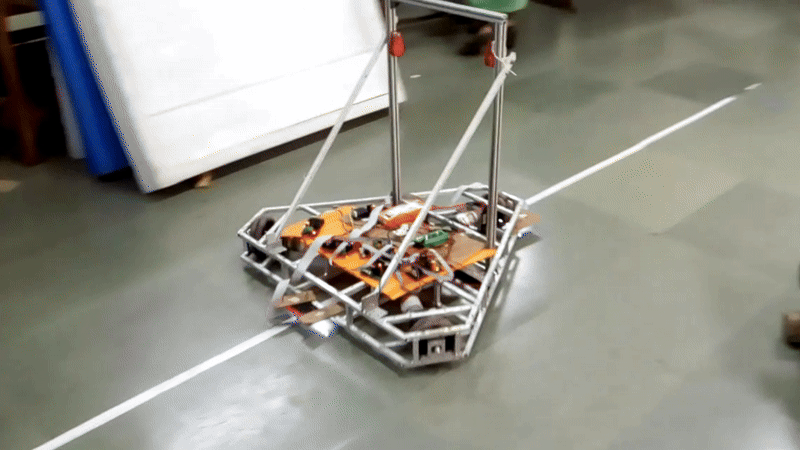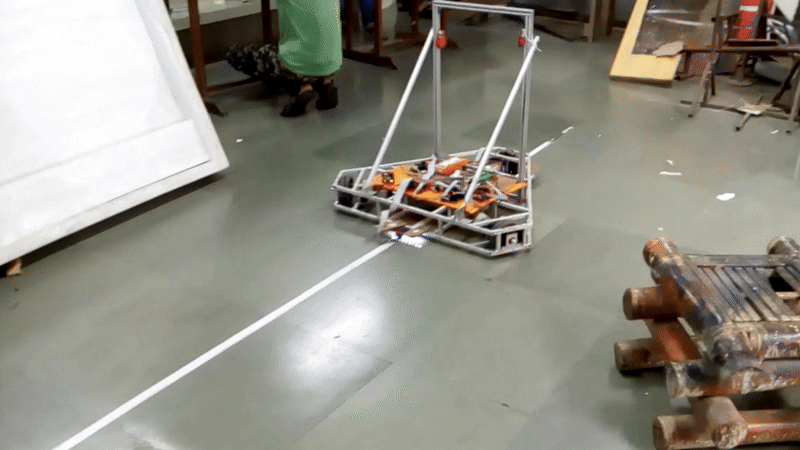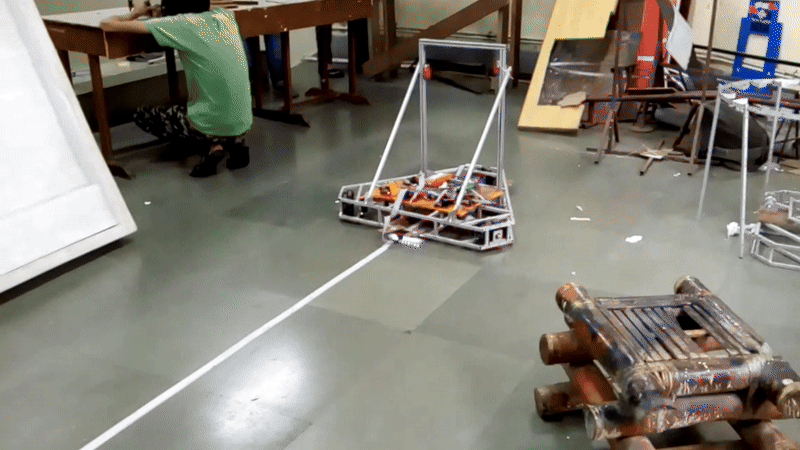
Swerve drive system for a 4-wheel mobile robot using ATmega2560. Controlled via Bluetooth PS2 joystick. Power window motors and encoders handle steering via gear-belt mechanism.
- 0
- C
- MIT
- 16 mo ago
Swerve drive system for a 4-wheel mobile robot using ATmega2560. Controlled via Bluetooth PS2 joystick. Power window motors and encoders handle steering via gear-belt mechanism.
wokwi sim for ATMega2560 Altair880-duino - local work by wa1tnr - port of dhansel's work here. May 2022
Three-wheel omni-directional robot that follows a line using an OPT101 sensor array. Built with an AVR ATmega2560, featuring PID control, EEPROM calibration, and Bluetooth manual override.
ATmega2560-based Fire Bird V robot project for line following and obstacle avoidance using IR sensors, PWM motor control, and ADC with LCD display.
AVR ATmega2560 example codes for interfacing peripherals including ADC, push button, LCD 16x2, motor drivers (A4988, TB6612, Cytron), SPI master/slave, UART, rotary encoder, timers, and more. Ideal for embedded systems projects and learning.