humanoid-description
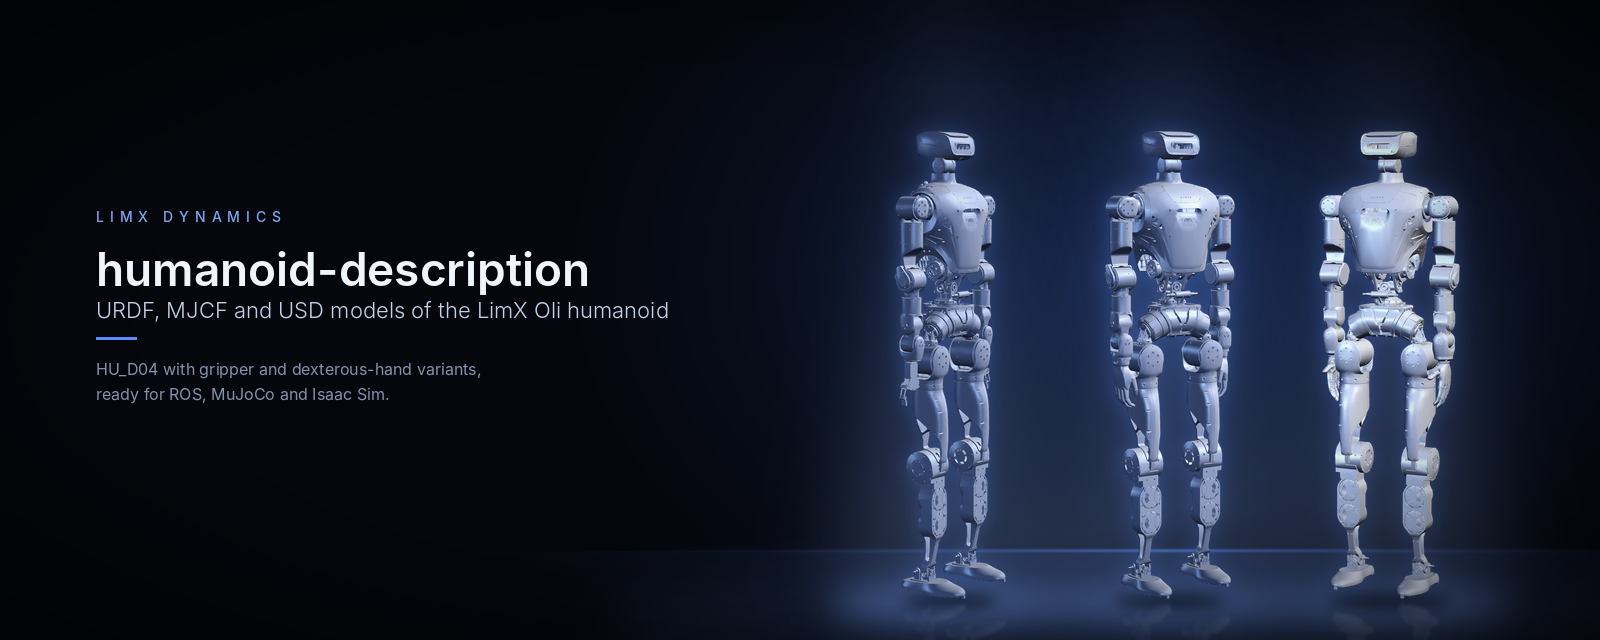
URDF, MuJoCo MJCF & USD models for the LimX Oli humanoid (HU_D04, plus legacy HU_D03). Includes gripper and dexterous-hand variants. ROS 1/2, Isaac Sim & MuJoCo ready.
- 14
- CMake
- Apache-2.0
- 2 wk ago
URDF, MuJoCo MJCF & USD models for the LimX Oli humanoid (HU_D04, plus legacy HU_D03). Includes gripper and dexterous-hand variants. ROS 1/2, Isaac Sim & MuJoCo ready.
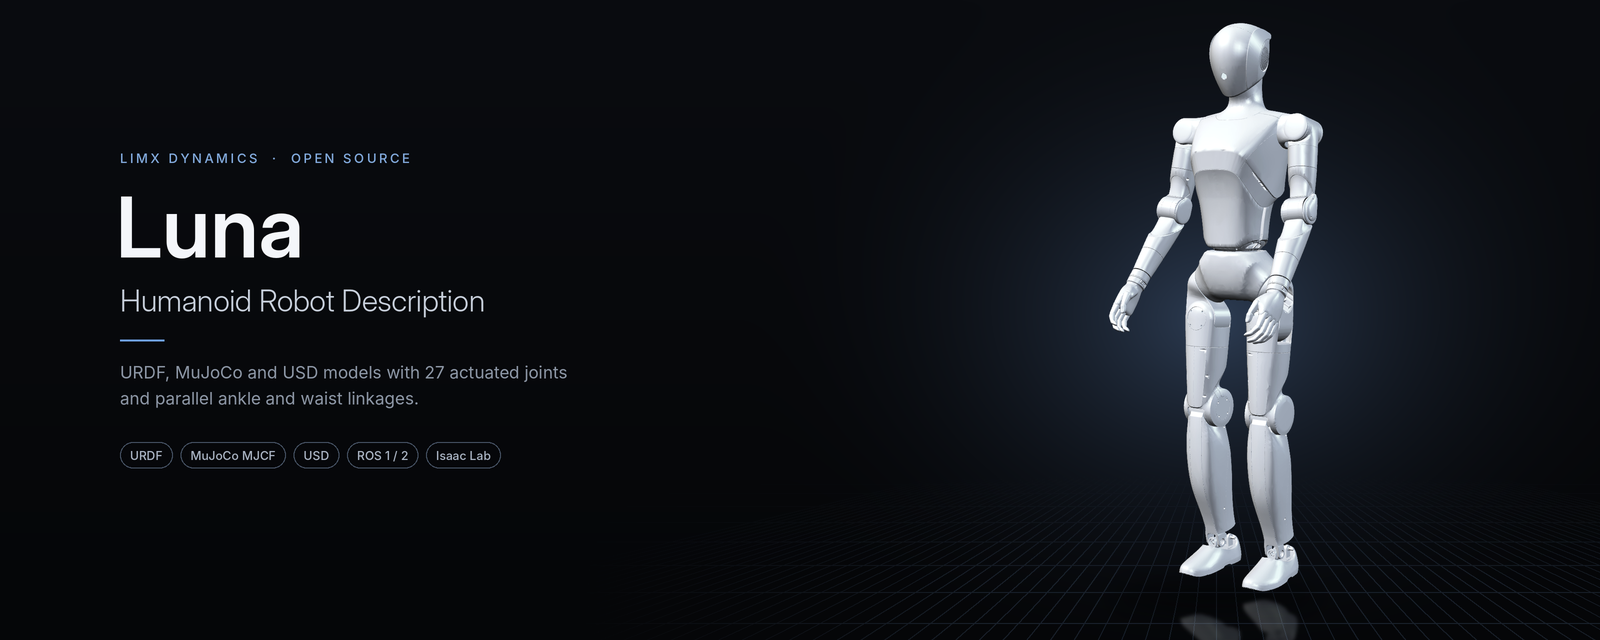
URDF, MuJoCo MJCF & USD models for the LimX Luna humanoid robot — 27 actuated joints, with ankle/waist parallel linkages modeled in the MJCF and the closed-loop USD. ROS, MuJoCo & Isaac Sim ready.