synthetic_data_generation_training_workflow
Workflow for generating synthetic data and training CV models.
- 120
- Jupyter Notebook
- 17 mo ago
Workflow for generating synthetic data and training CV models.
SPARC is an intelligent ROS2 Humble-based pick-and-place robotic system integrating MoveIt, YOLOv8-OBB, and Isaac Sim. It enables real-time object detection, motion planning for Franka Panda and UR5 arms, and natural language control via an Ollama-powered chatbot—making robotic manipulation smart, interactive, and human-friendly.
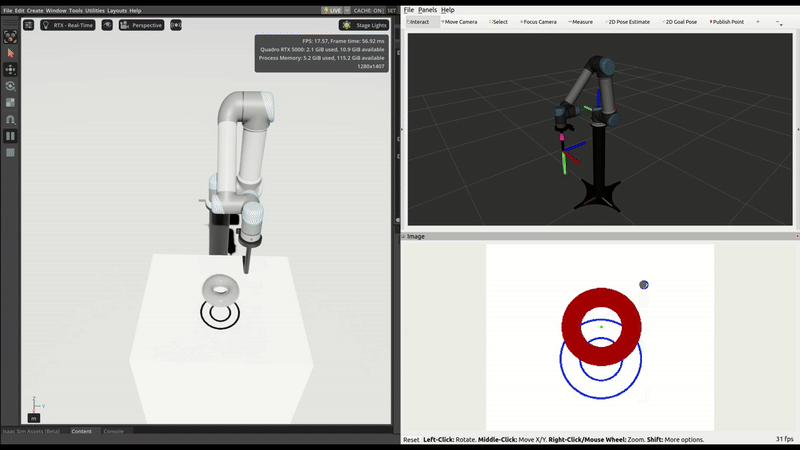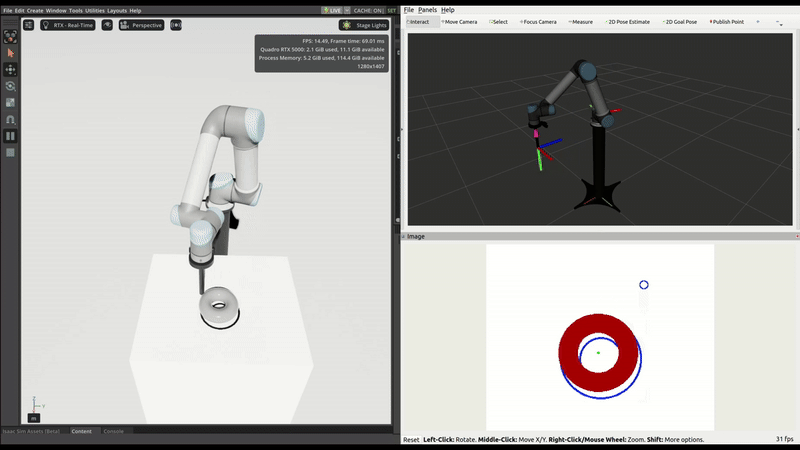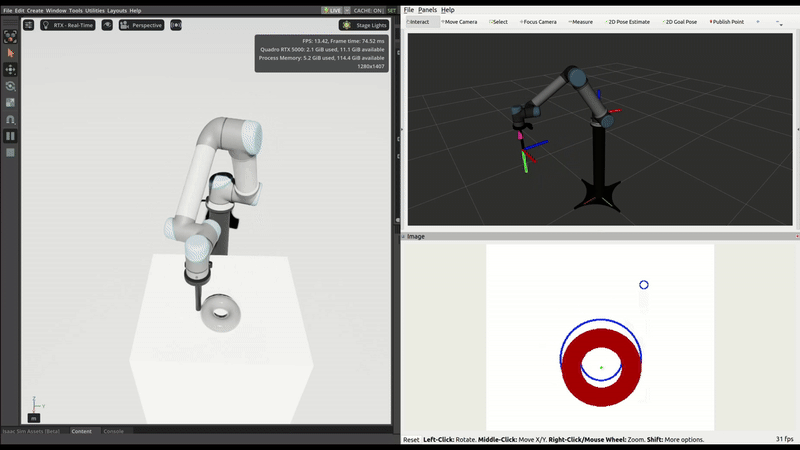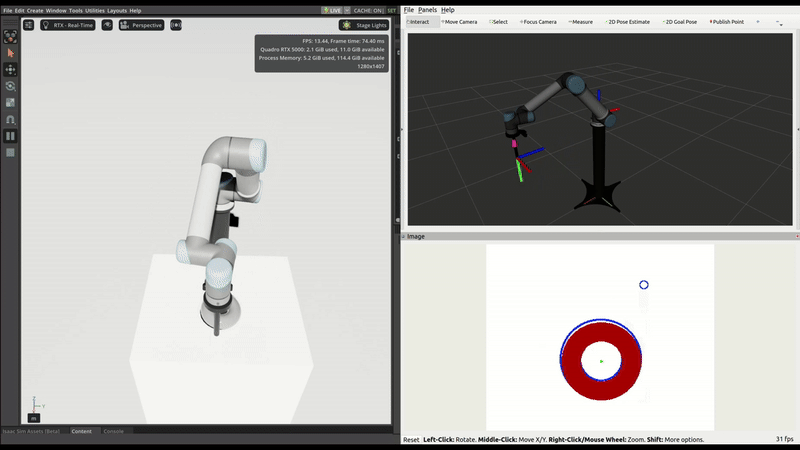
A complete imitation learning pipeline for bar alignment using the UR5 robot in NVIDIA Isaac Sim. Includes manual data collection with a game controller, dataset organization for LeRobot, diffusion policy training, and policy deployment through ROS2.
URDF/xacro, MuJoCo XML, mesh & USD models for LimX TRON2A & TRON2B — 16 variants (dual-arm, bipedal, wheeled-leg), ROS 1/2 & simulation ready.
RL training pipeline for LimX TRON2A humanoid — Isaac Lab + PPO (rsl_rl); sole-foot, wheel-foot and whole-body dual-arm DASF variants.
URDF, MuJoCo MJCF & USD models for the LimX Oli humanoid (HU_D04, plus legacy HU_D03). Includes gripper and dexterous-hand variants. ROS 1/2, Isaac Sim & MuJoCo ready.
Isaac Lab RL training stack for TRON2A with 6-DoF arm and gripper — PPO-based locomotion policy training supporting SF/WF (foot variants) and SFYG/WFYG (arm+gripper locked variants). Built for the ATEC challenge.
Isaac Lab RL training for LimX Oli humanoid — Isaac Sim 4.5, sim-to-real locomotion
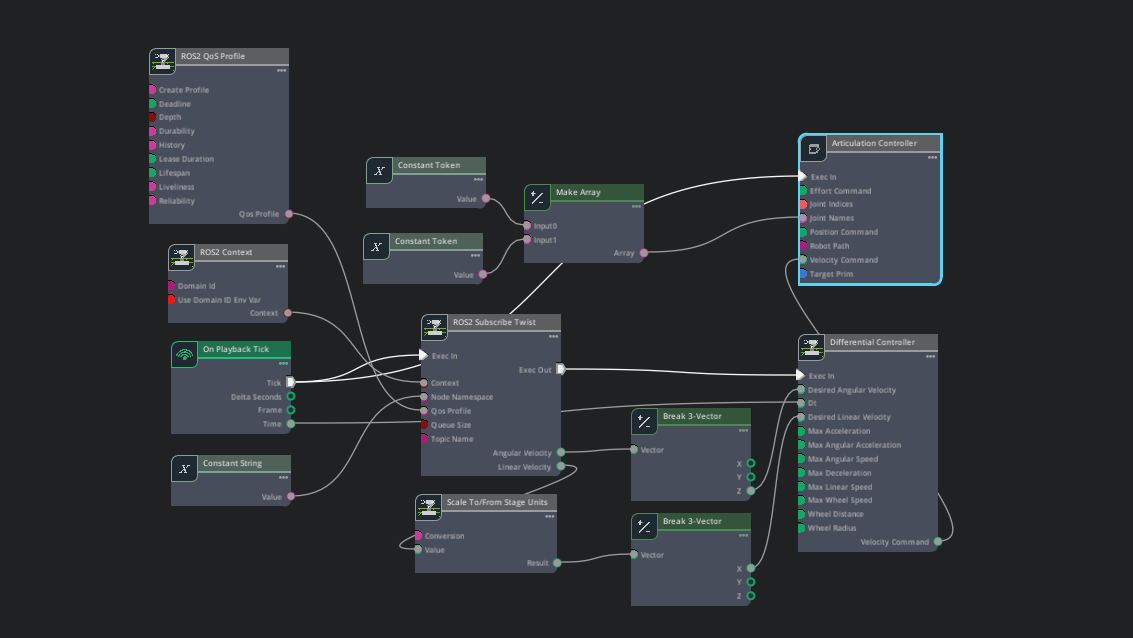
A collection of Action Graphs built with NVIDIA Isaac Sim — a powerful robotics simulation platform based on Omniverse. This repository demonstrates visual scripting for robot control, sensor integration, simulation logic, and interactive behavior creation — all without traditional coding.
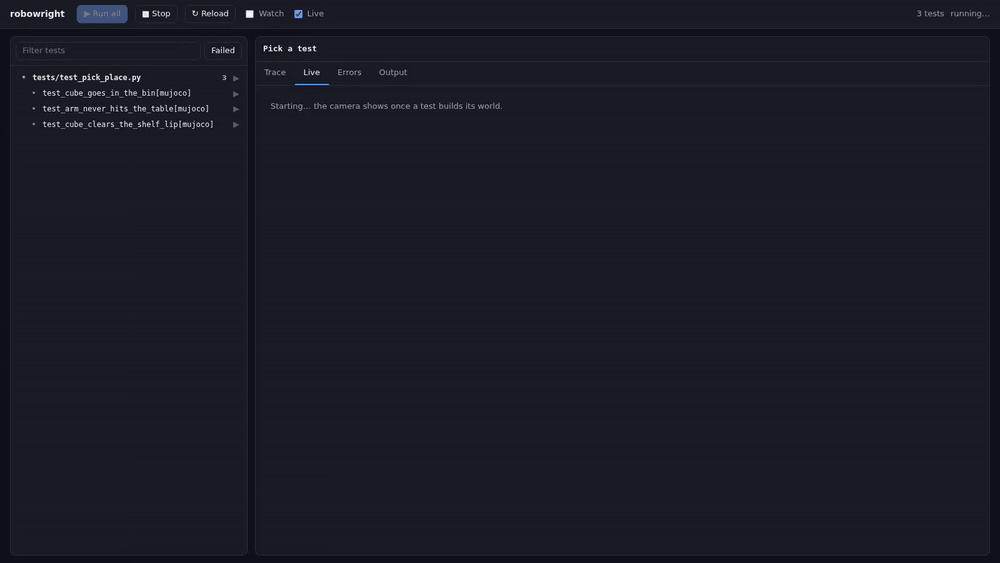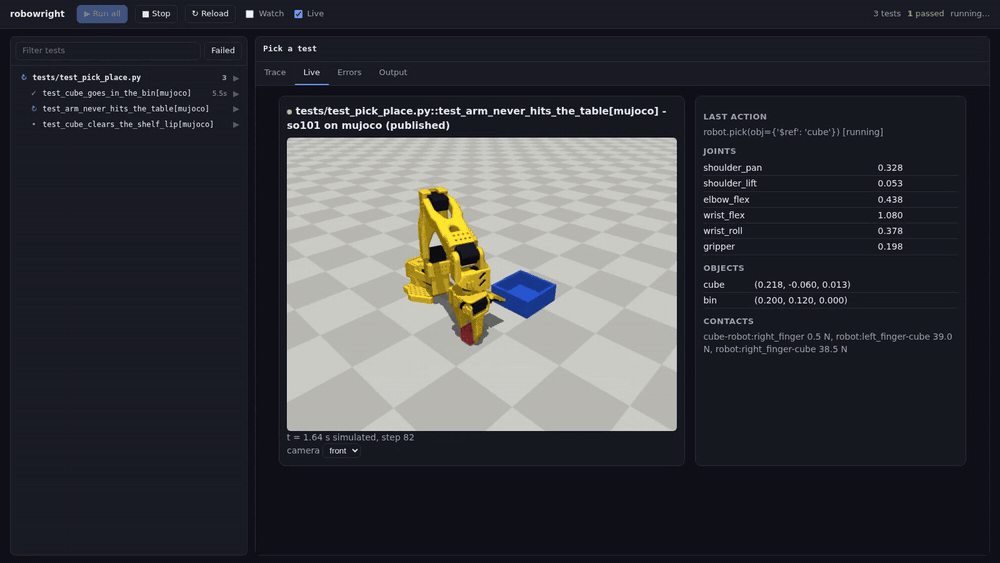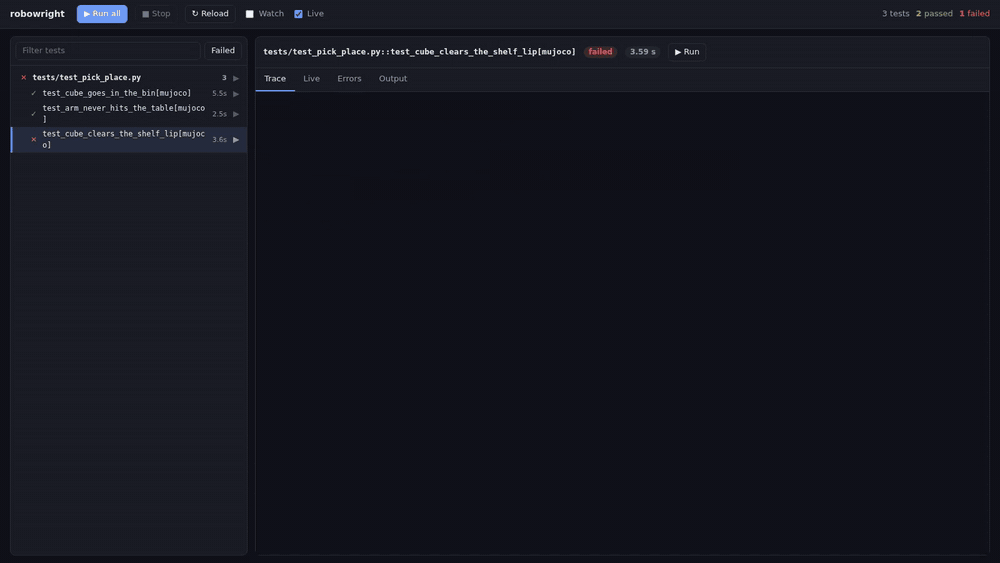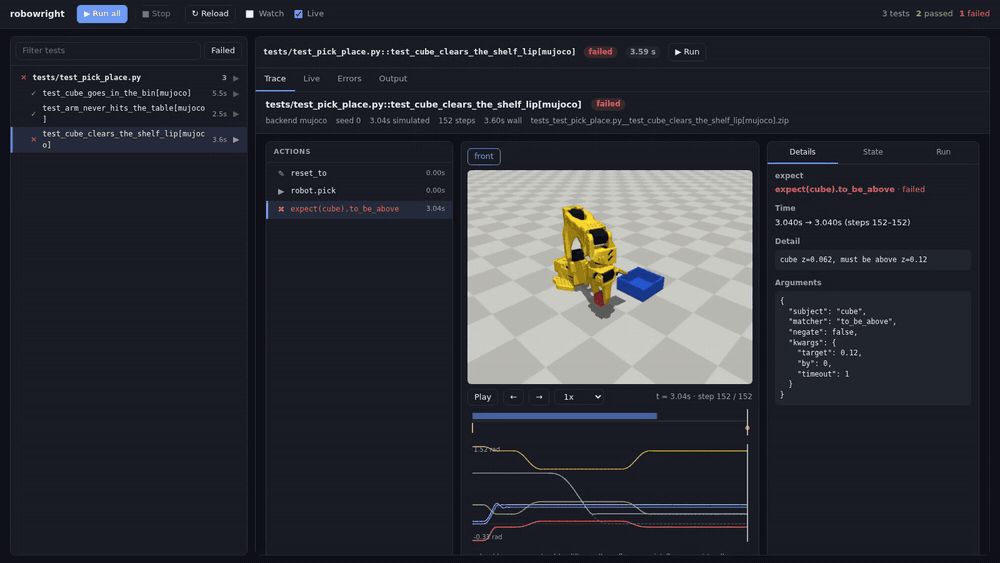
Playwright-style testing for robots: one pytest test, 19 robots (Franka, UR, Kinova, KUKA, xArm, ALOHA, Unitree, Spot...), five physics engines (MuJoCo, PyBullet, Drake, Genesis, Isaac Sim). Auto-waiting actions, expect() assertions, traces, deterministic replay, codegen.
NVIDIA Isaac Sim-to-Real Physical AI workflow demo
Runs in the browser on Hugging Face
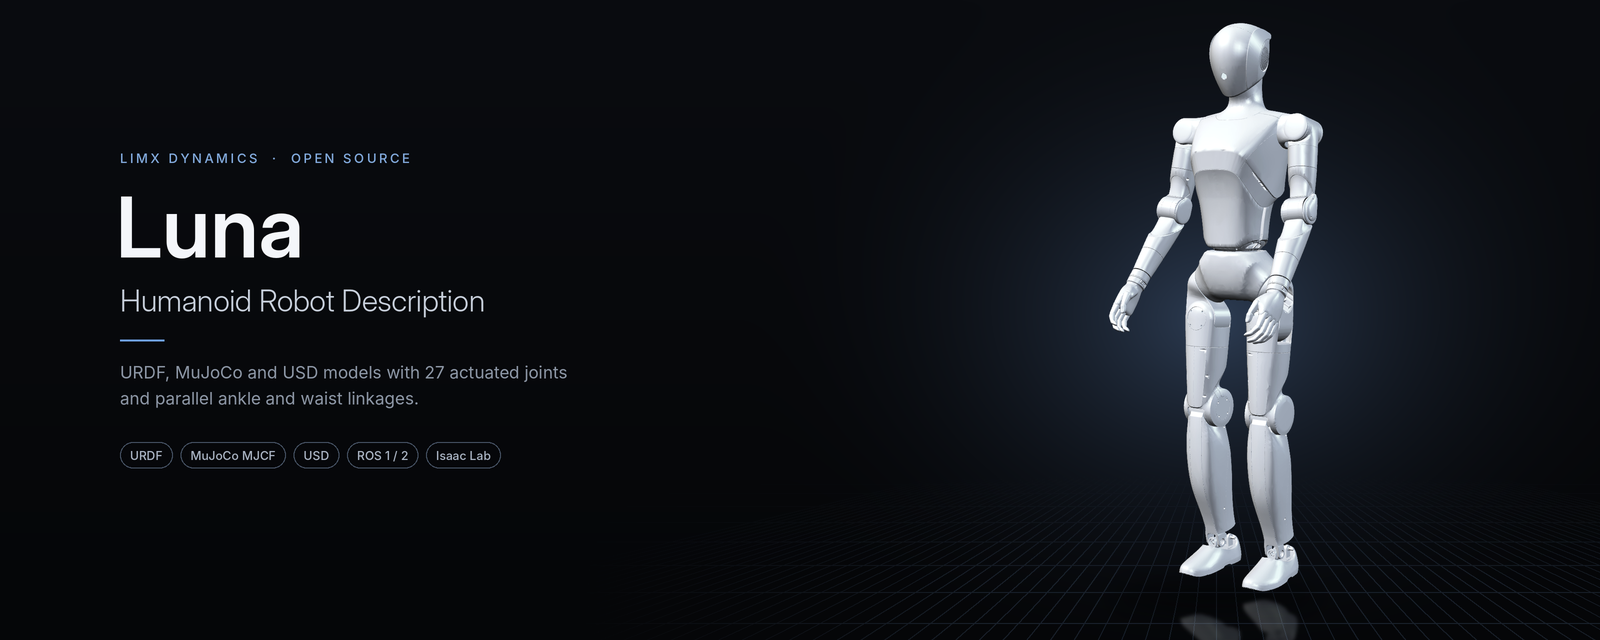
URDF, MuJoCo MJCF & USD models for the LimX Luna humanoid robot — 27 actuated joints, with ankle/waist parallel linkages modeled in the MJCF and the closed-loop USD. ROS, MuJoCo & Isaac Sim ready.
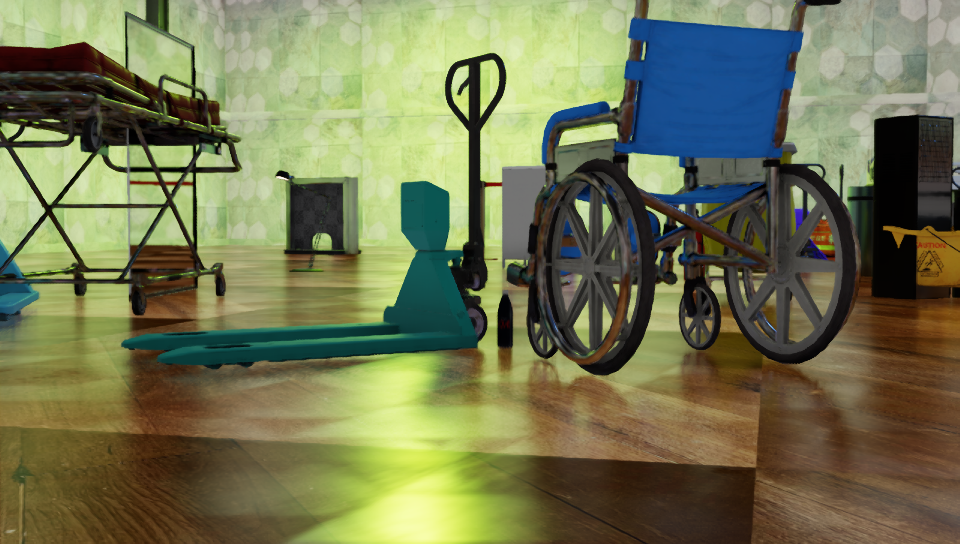
Physical AI scenarios for Cosmos and Isaac validation
Runs in the browser on Hugging Face