oriented_field_localization
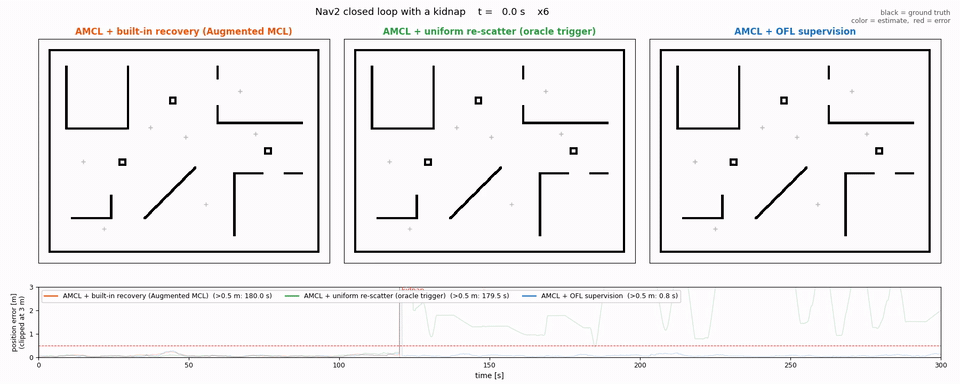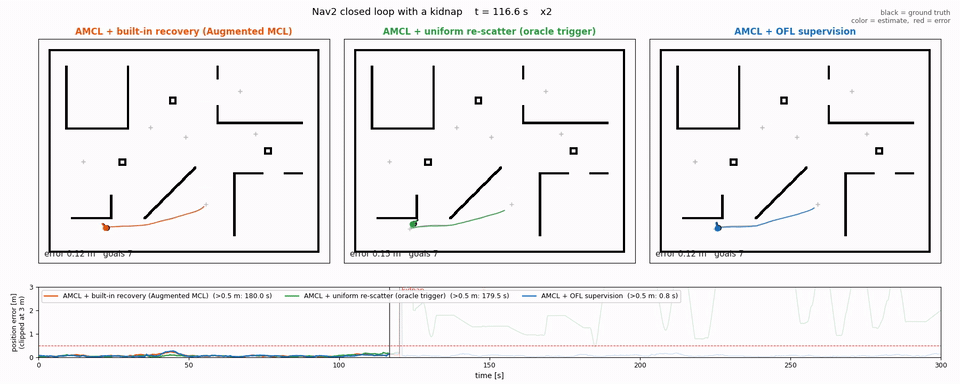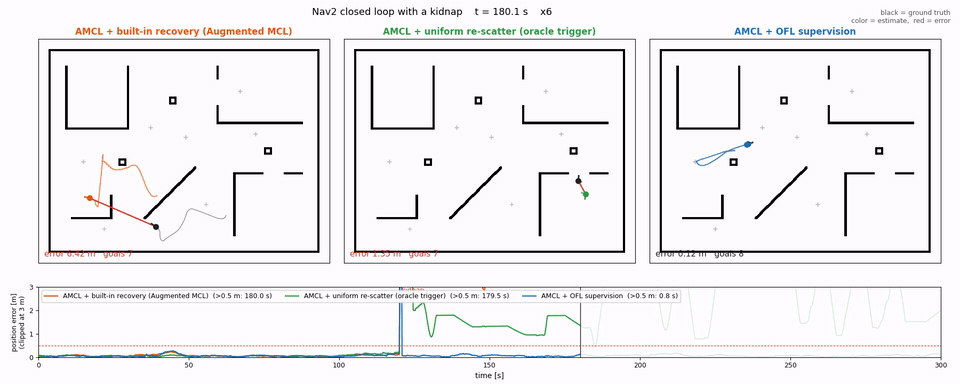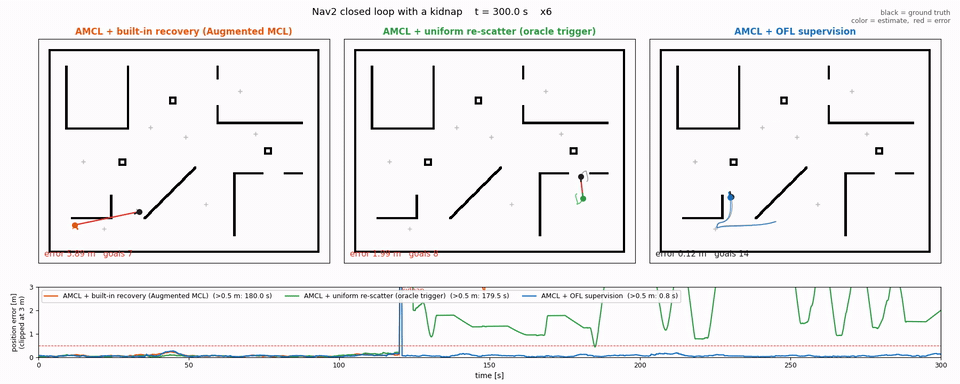
3-DoF pose from a single 2D LiDAR scan with no initial guess — ROS 2 global localization by FFT correlation of oriented (wall-normal) fields in image space
- 4
- C++
- MIT
- 3 mo ago
3-DoF pose from a single 2D LiDAR scan with no initial guess — ROS 2 global localization by FFT correlation of oriented (wall-normal) fields in image space
