GALATEA
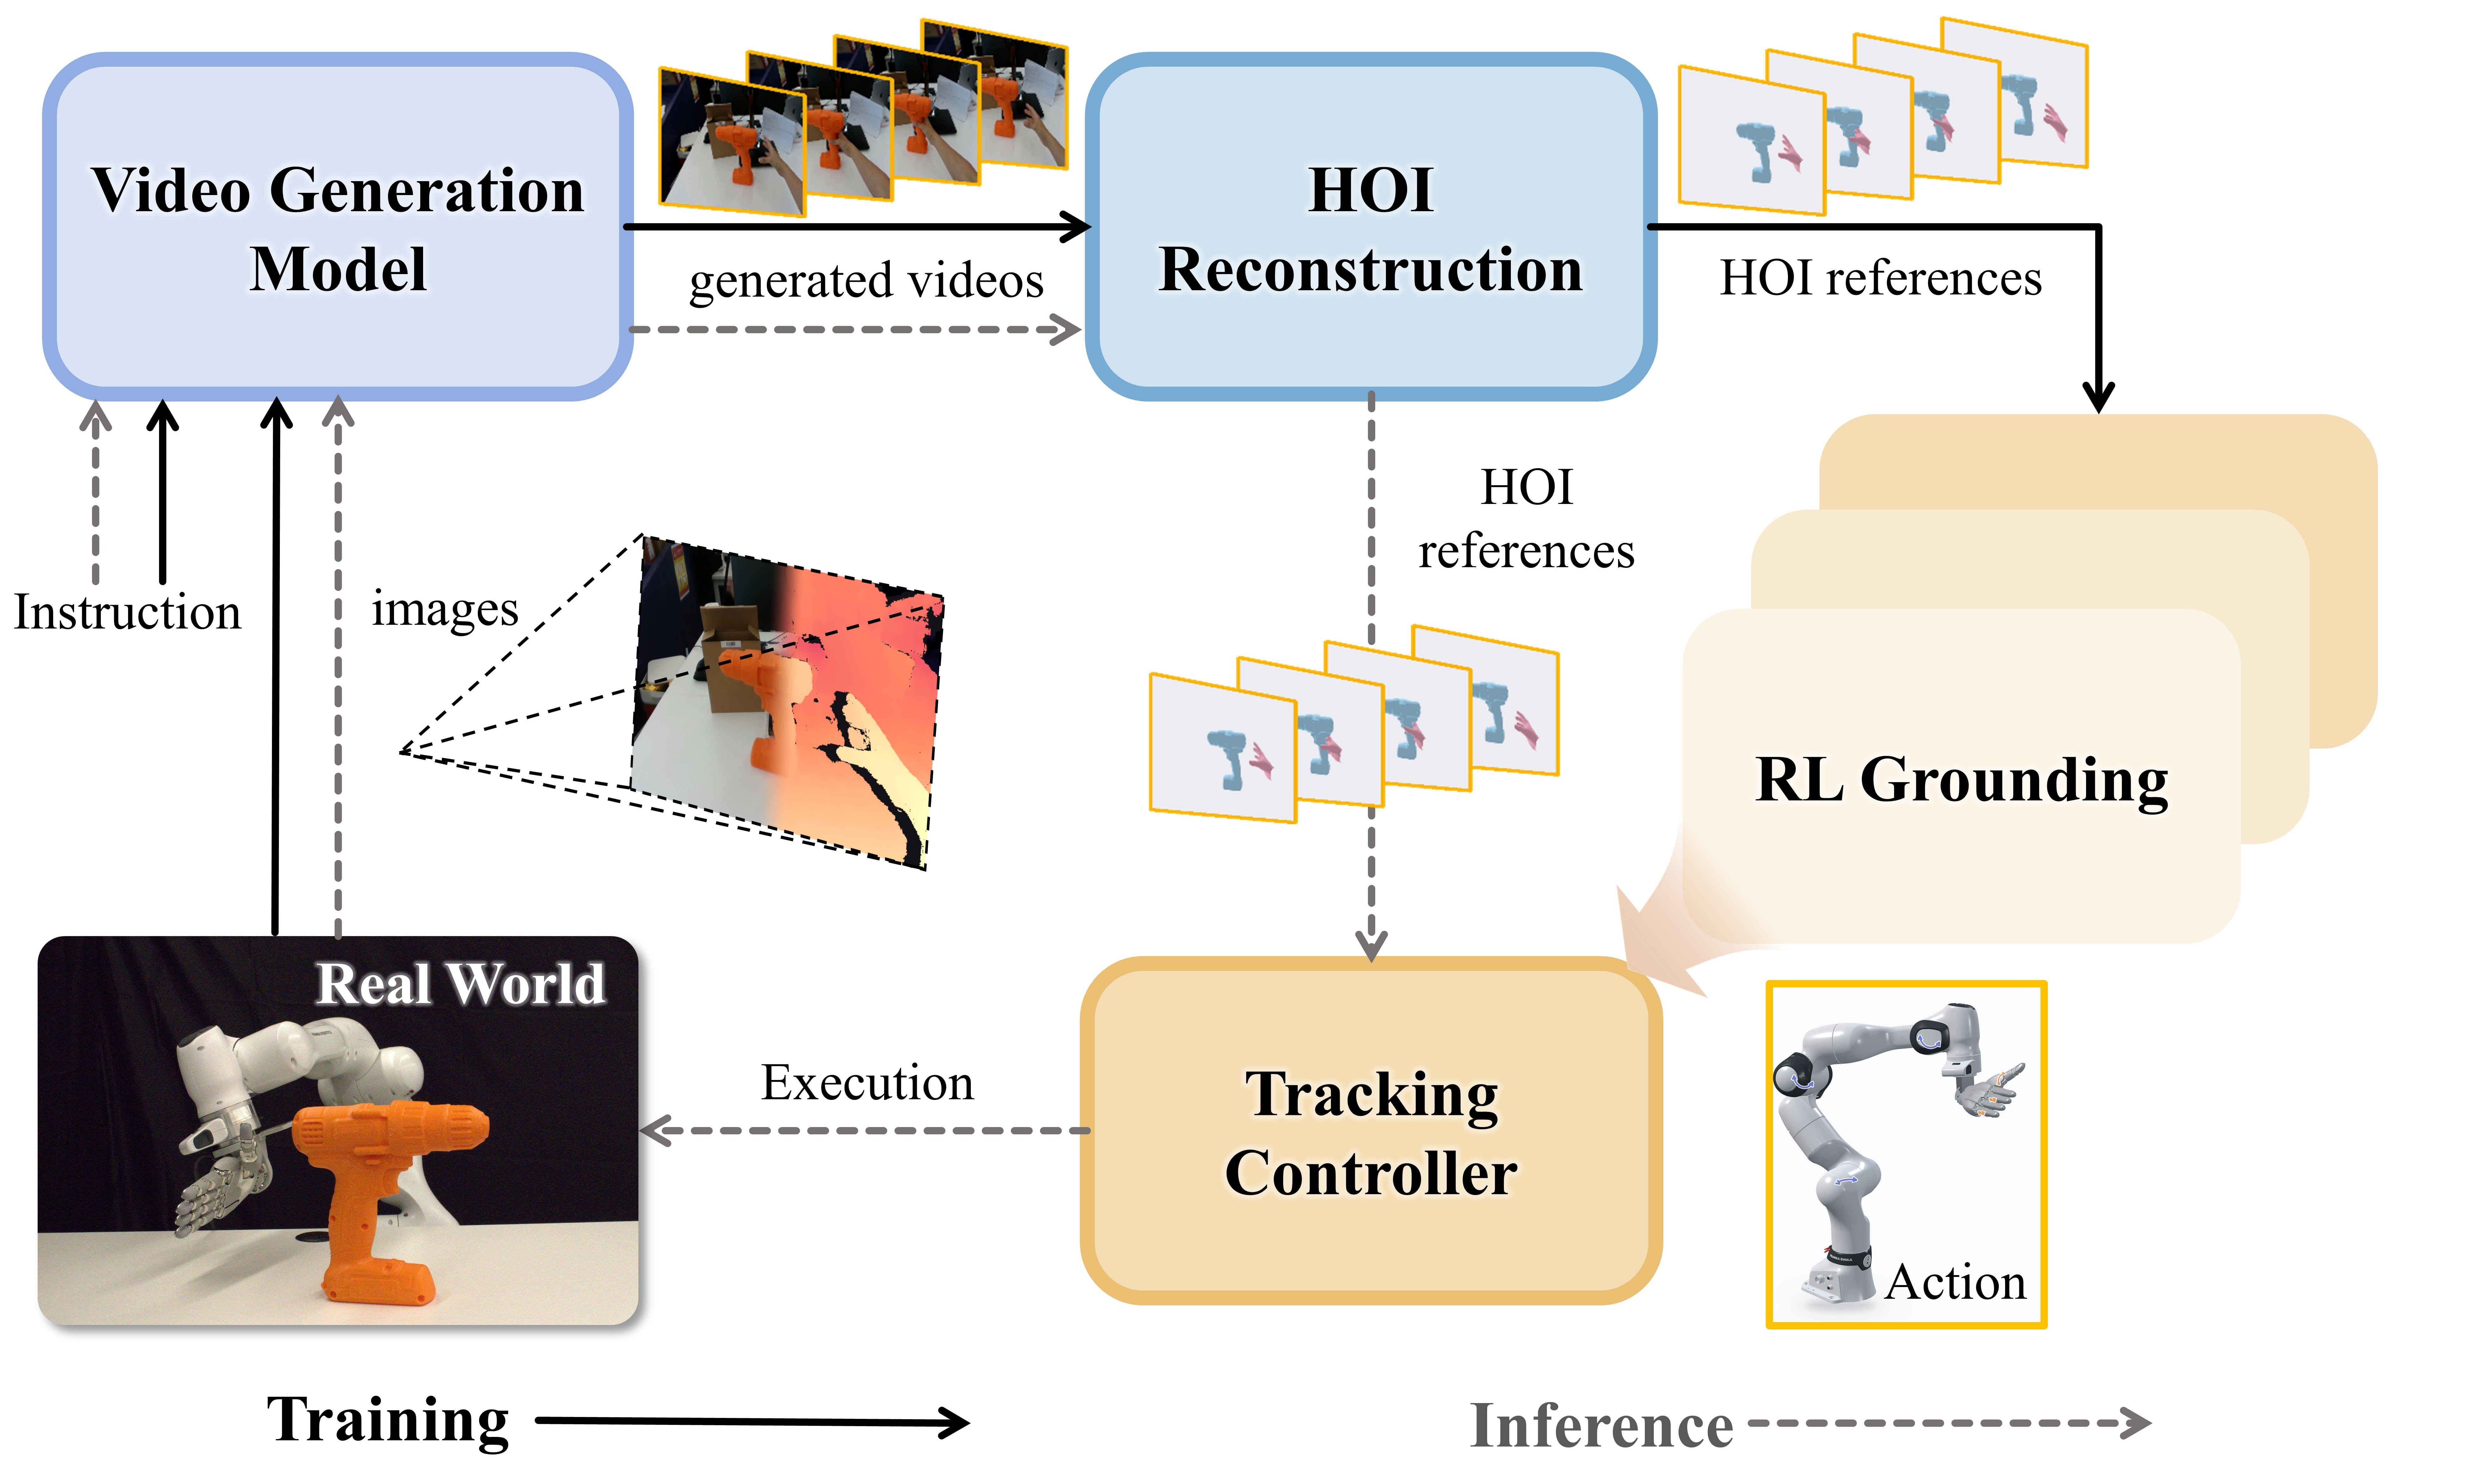
Reconstruct 3D hand-object trajectories from generated videos, and train one general RL tracking policy for a dexterous robot hand.
- 100
- Python
- 3 wk ago
Reconstruct 3D hand-object trajectories from generated videos, and train one general RL tracking policy for a dexterous robot hand.
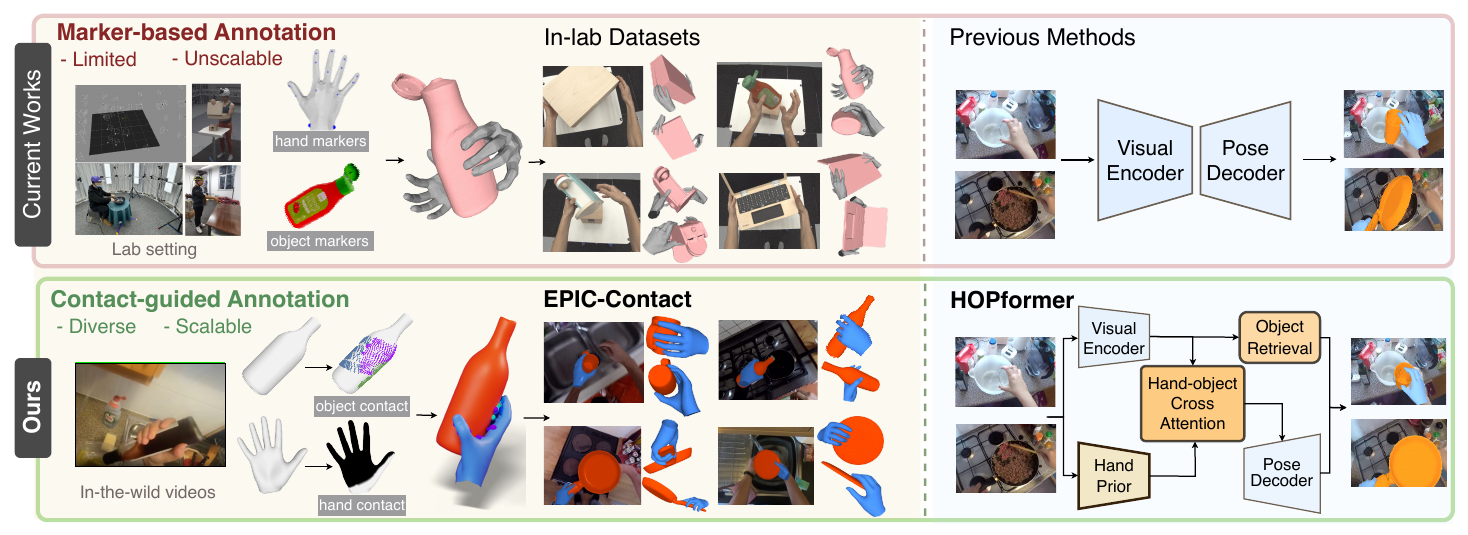
Code for HOPformer released in ECCV 2026 Paper "Towards in-the-wild Egocentric 3D Hand-Object Pose Estimation"
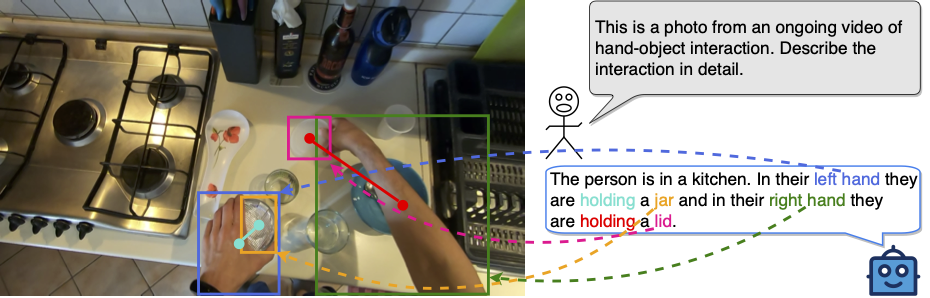
Code implementation for paper titled "HOI-Ref: Hand-Object Interaction Referral in Egocentric Vision"
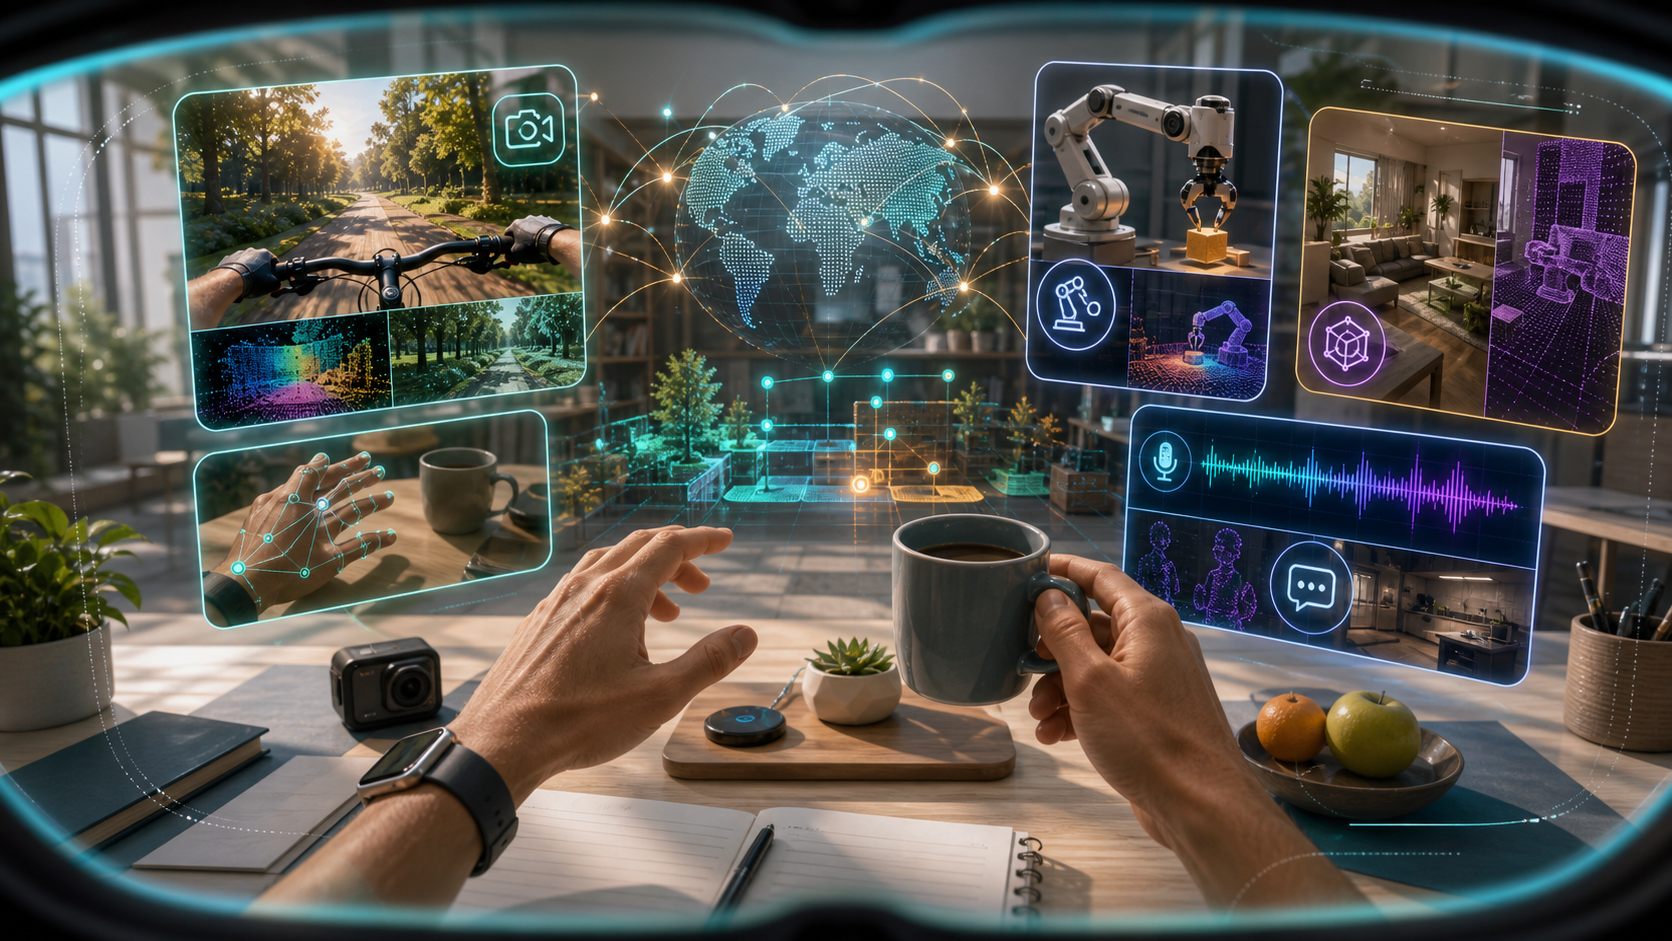
Curated datasets, benchmarks, models, and tools for egocentric AI, embodied intelligence, VLA, world models, robotics, and wearable vision.
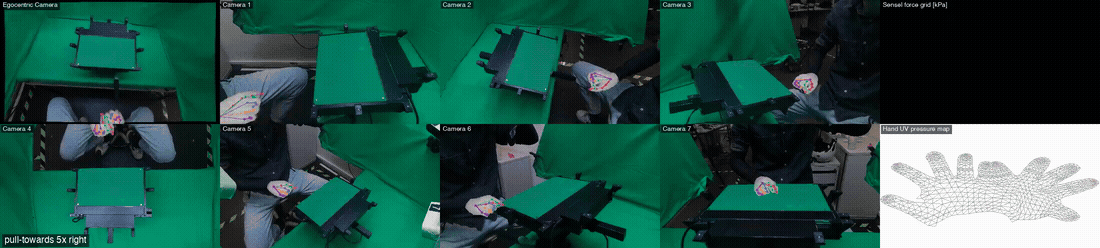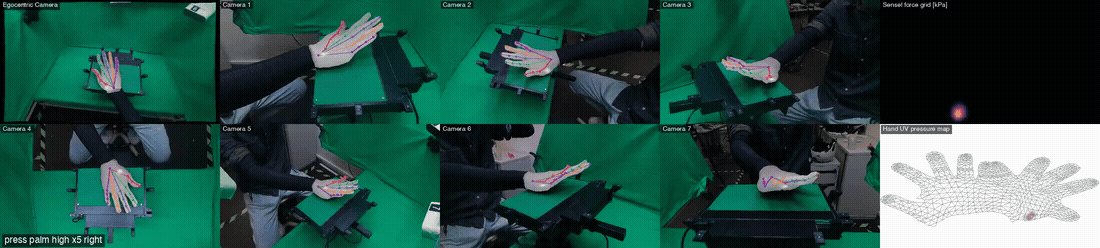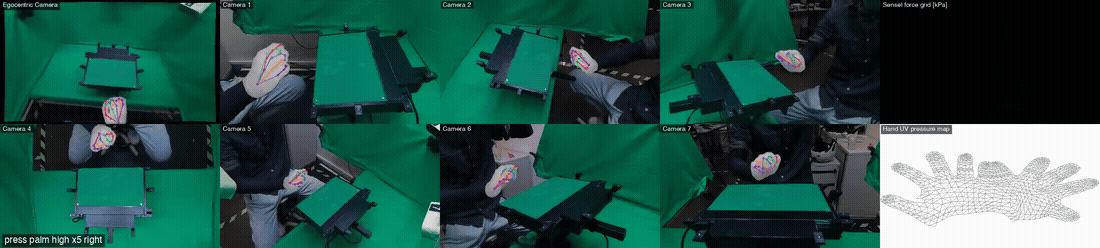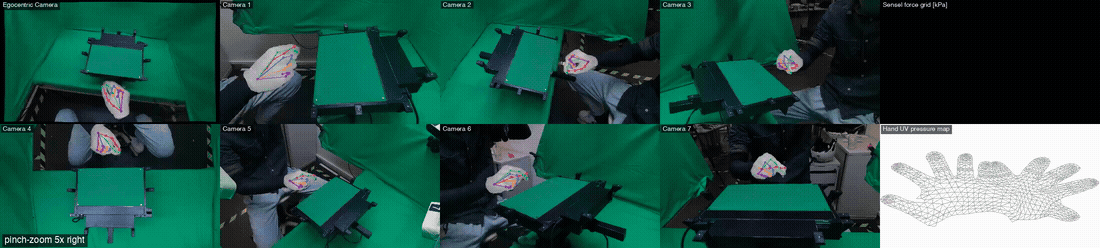
Dataset Toolkit for for CVPR 2025 paper "EgoPressure: A Dataset for Hand Pressure and Pose Estimation in Egocentric Vision"