iros20-6d-pose-tracking
[IROS 2020] se(3)-TrackNet: Data-driven 6D Pose Tracking by Calibrating Image Residuals in Synthetic Domains
- 425
- Python
- 3 y ago
[IROS 2020] se(3)-TrackNet: Data-driven 6D Pose Tracking by Calibrating Image Residuals in Synthetic Domains
The communication layer between people and robots, and between robots. Talk to any robot in your own words, with an LLM for its brain. Robots that have never met check each other's passports and share the work. Microduck, Huebot, Open Duck Mini, LeRobot arms, XLeRobot carts, AlohaMini, ToddlerBot, MOSS, ROS bases and industrial arms on ROS 2.
PaddleRobotics is an open-source algorithm library for robots based on Paddle, including open-source parts such as human-robot interaction, complex motion control, environment perception, SLAM positioning, and navigation.
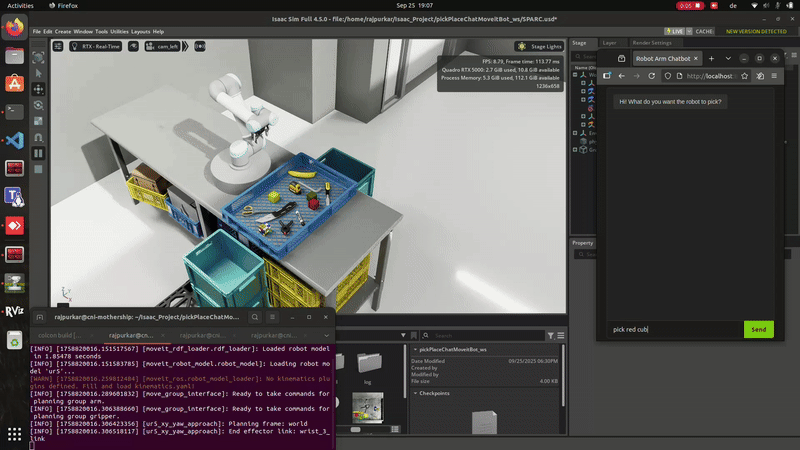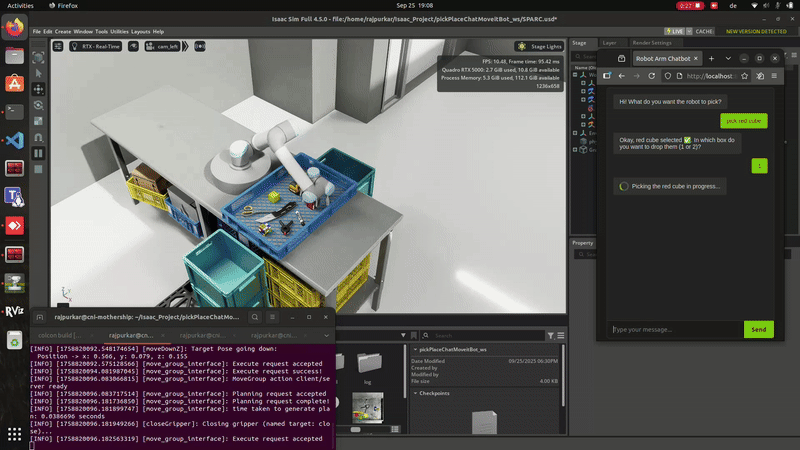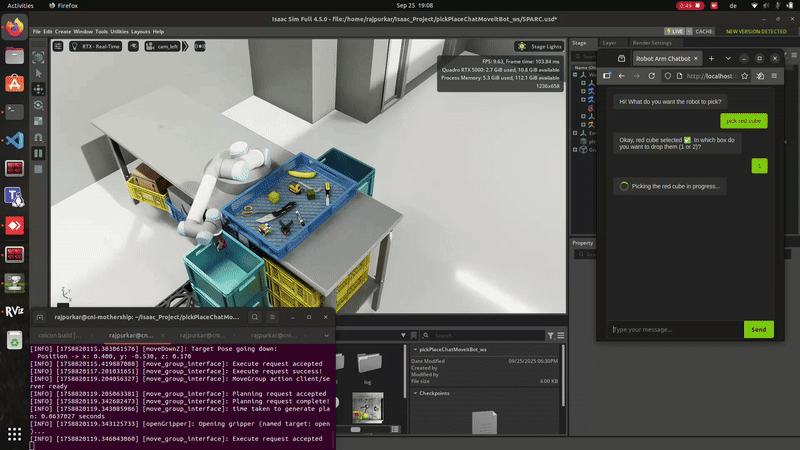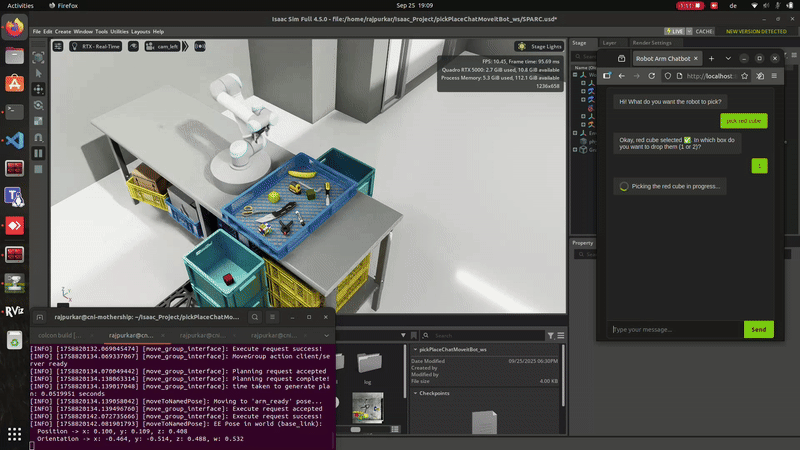
SPARC is an intelligent ROS2 Humble-based pick-and-place robotic system integrating MoveIt, YOLOv8-OBB, and Isaac Sim. It enables real-time object detection, motion planning for Franka Panda and UR5 arms, and natural language control via an Ollama-powered chatbot—making robotic manipulation smart, interactive, and human-friendly.
A framework and method to jointly learn a (neural) control objective function and a time-warping function only from sparse demonstrations or waypoints.
REFLEX Dataset: A Multimodal Dataset of Human Reactions to Robot Failures and Explanations
GitHub profile of John A. Betancourt (BetaCode): Sr. Tech Lead in robotics and computer vision, ~10 years building autonomous delivery robots, now vibe coding side projects with AI agents.