tron1-mujoco-sim
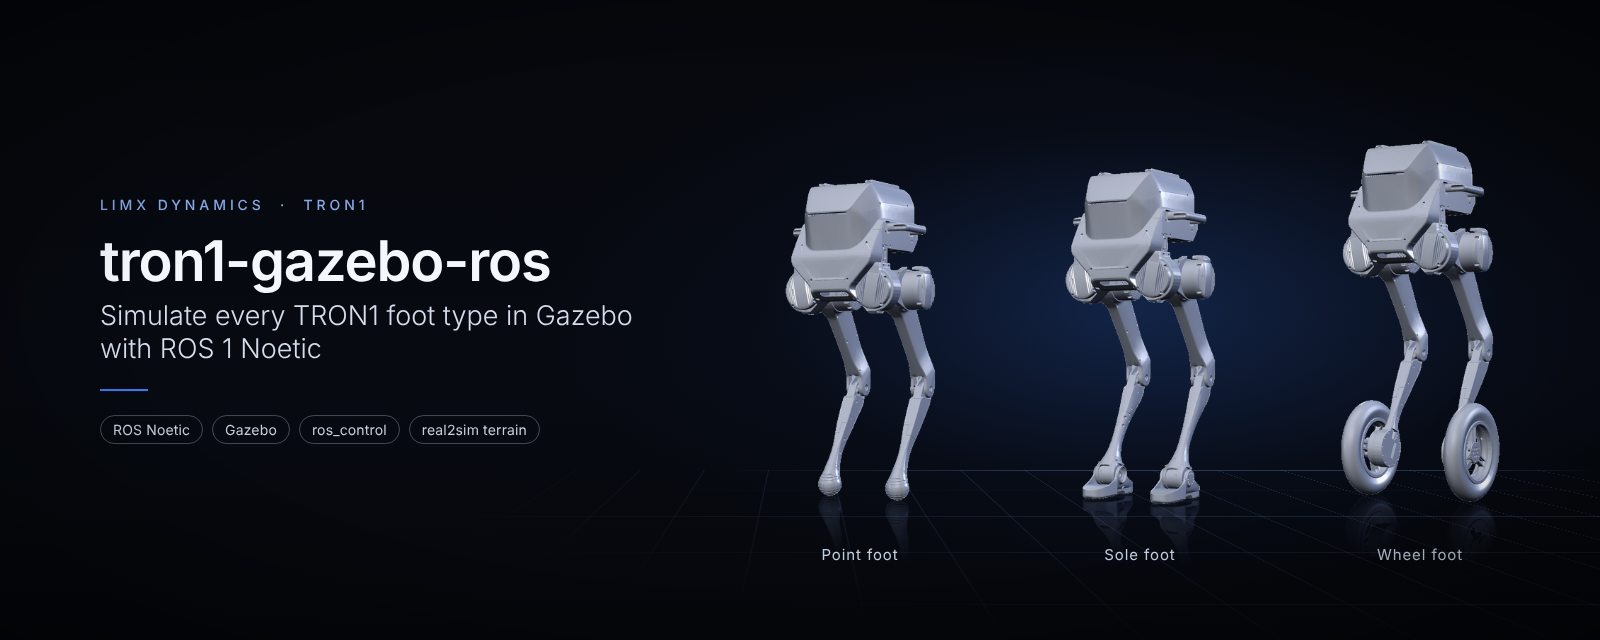
MuJoCo simulation environment for TRON1 point-foot, sole-foot and wheel-foot robots — Sim-to-Real validation and RL policy evaluation
- 34
- Python
- Apache-2.0
- 2 wk ago
MuJoCo simulation environment for TRON1 point-foot, sole-foot and wheel-foot robots — Sim-to-Real validation and RL policy evaluation
Python-based RL deployment for TRON1 robots — ONNX runtime inference, MuJoCo simulation, and real-robot deployment
Deployment-focused fork of OpenPI for LimX TRON2 manipulation — pi0.5 policy serving, task fine-tuning, TRON2 transforms, and real-robot client examples.
Official home of the LimX Dynamics open-source ecosystem — humanoid robots, legged robots, locomotion & manipulation, and embodied AI.
ROS Noetic RL deployment workspace for TRON1 robots — ONNX runtime, real-robot control, and sim-to-real transfer
URDF/Xacro robot models for TRON1 — ROS 1/2, MuJoCo & simulation ready
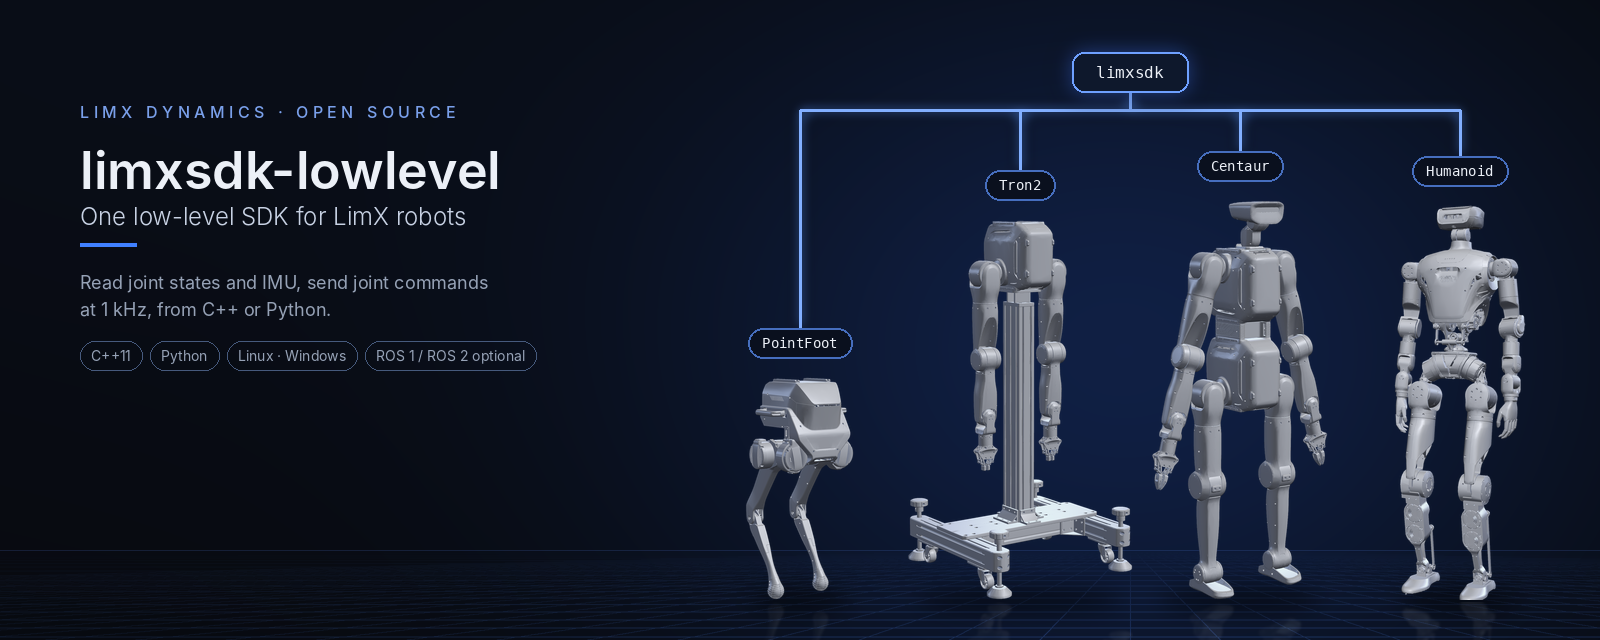
Dependency-free C++11 & Python SDK for low-level motion control of LimX robots — cross-platform (Linux x86_64/aarch64, Windows), integrates with ROS/Gazebo and RL-based sim-to-real deployment.
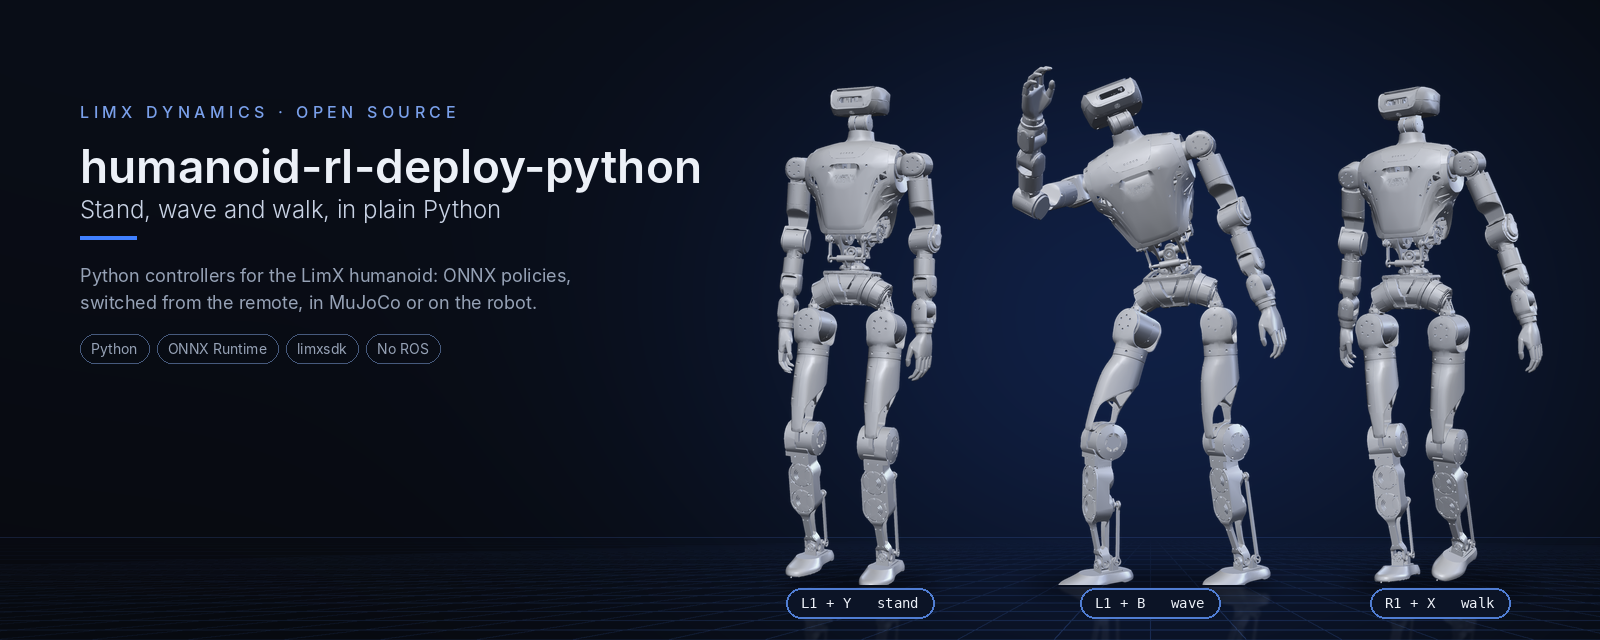
Python RL deployment for LimX humanoid — ONNX runtime, MuJoCo sim & real-robot
URDF/xacro, MuJoCo XML, mesh & USD models for LimX TRON2A & TRON2B — 16 variants (dual-arm, bipedal, wheeled-leg), ROS 1/2 & simulation ready.
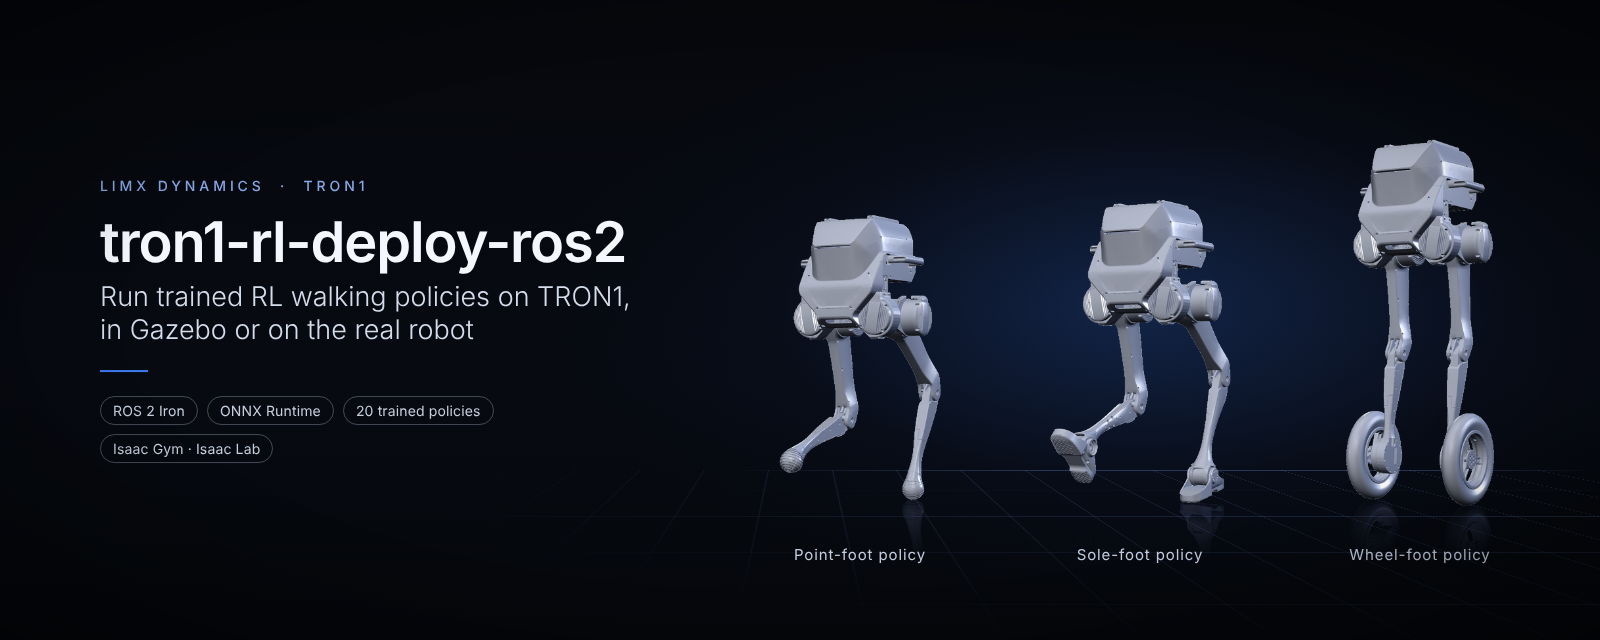
ROS 2 Iron RL deployment for TRON1 — ONNX inference & real-robot control
RL training pipeline for LimX TRON2A humanoid — Isaac Lab + PPO (rsl_rl); sole-foot, wheel-foot and whole-body dual-arm DASF variants.
URDF, MuJoCo MJCF & USD models for the LimX Oli humanoid (HU_D04, plus legacy HU_D03). Includes gripper and dexterous-hand variants. ROS 1/2, Isaac Sim & MuJoCo ready.
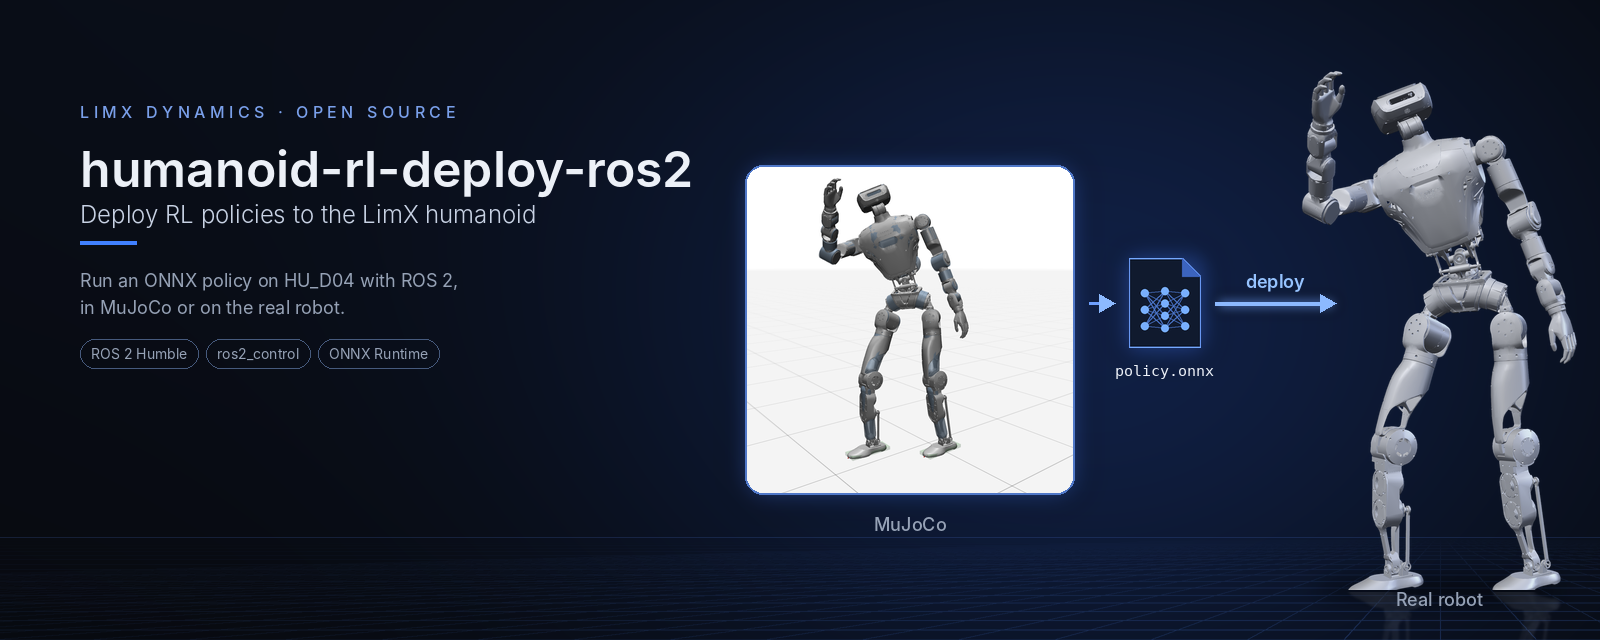
ROS 2 Humble RL deployment for LimX humanoid — ONNX inference & motion control
MuJoCo simulation for LimX humanoid — controller testing & sim2real policy validation
TronCamp ACT manipulation hackathon kit — LimX Tron2 dual-arm, RoboTwin, single-GPU ACT training, 4-task graded leaderboard (T4 stack_bowls_three).
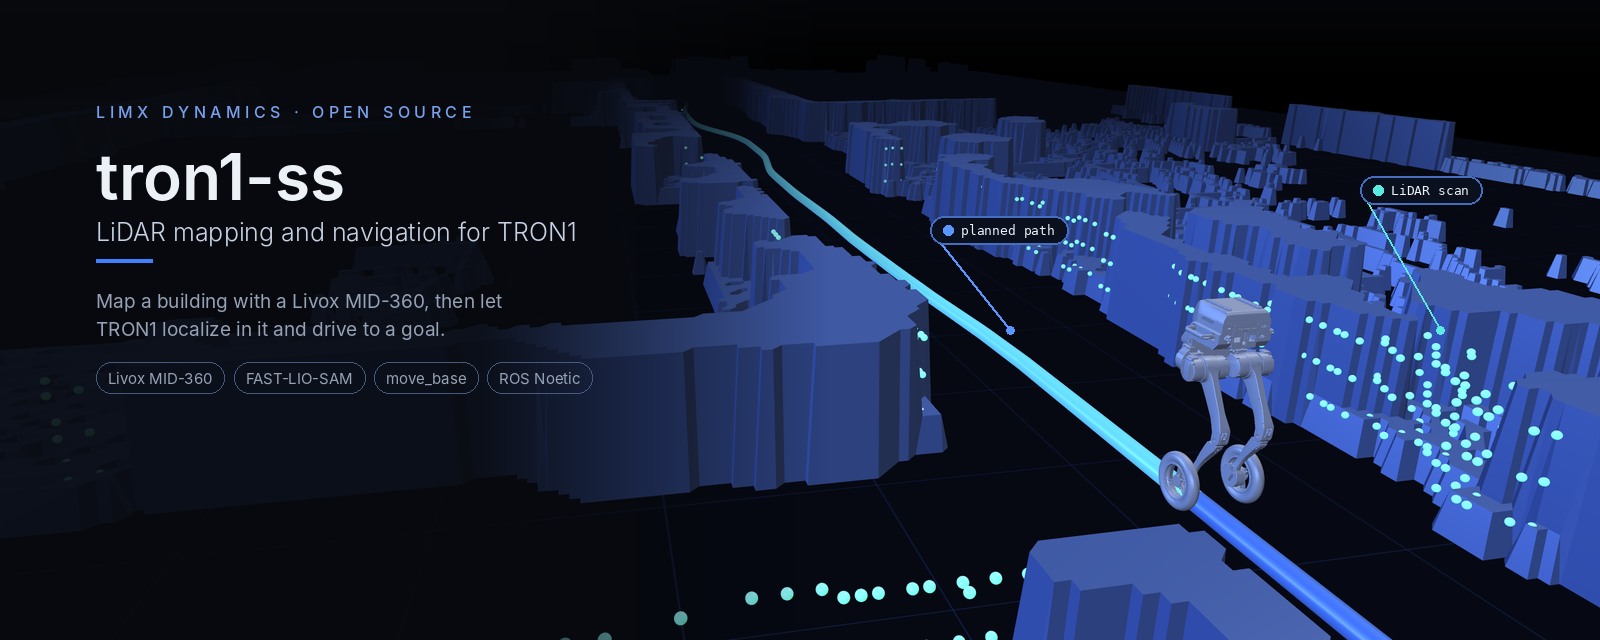
LiDAR SLAM & navigation for TRON1 — FAST-LIO-SAM mapping, localization & path planning
Papers, code, competition results and partner deployments built on LimX robots (TRON1, TRON2, Oli, Luna, P1, W1). Browse the gallery or read the full list.
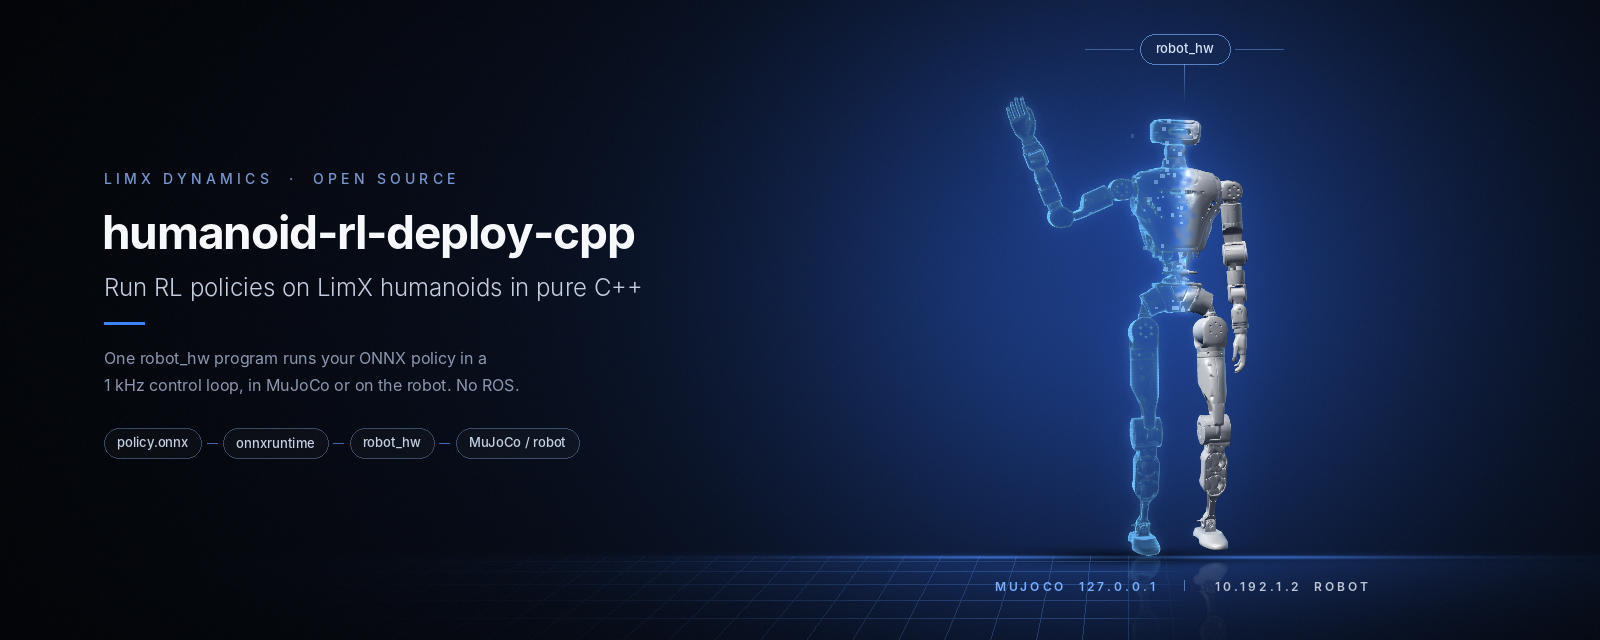
ROS-free C++ RL deployment for LimX humanoid — ONNX inference & motion control
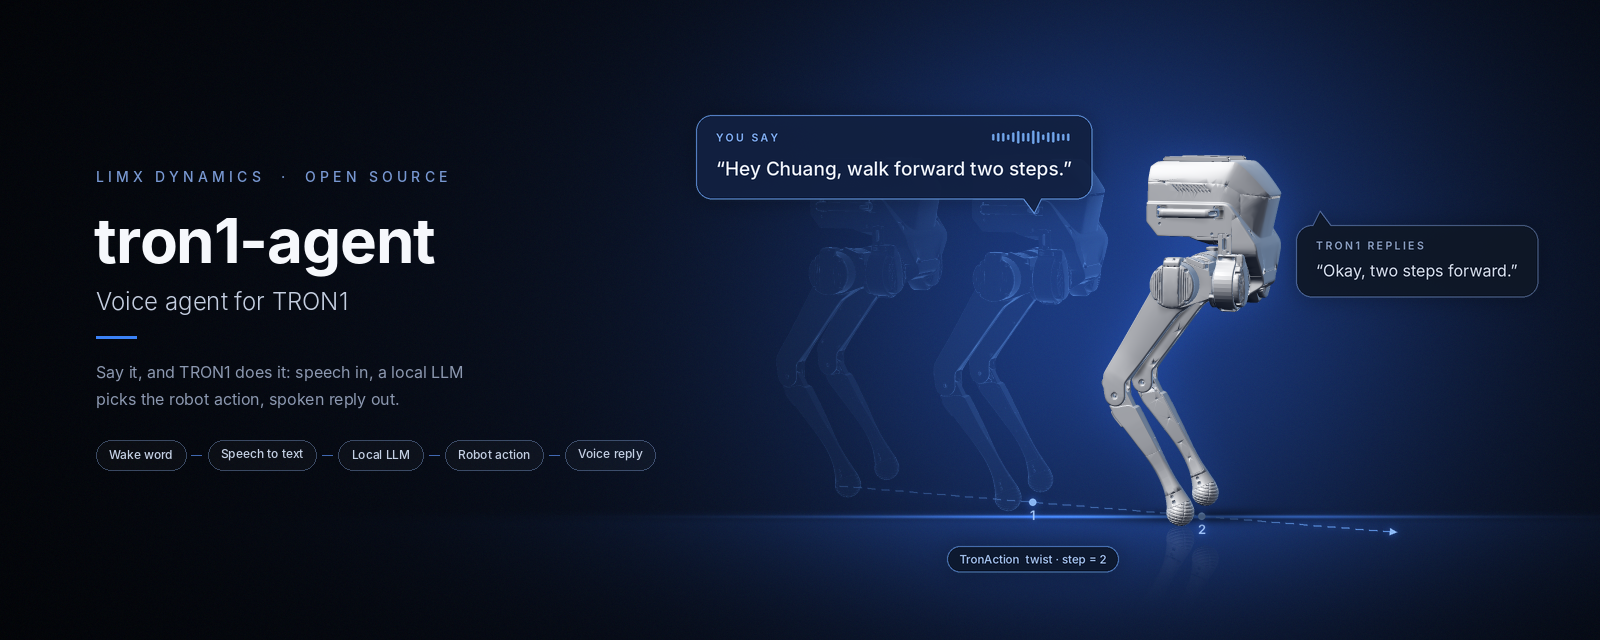
Voice-interactive AI agent for TRON1 — speech commands, LLM dialogue & robot action
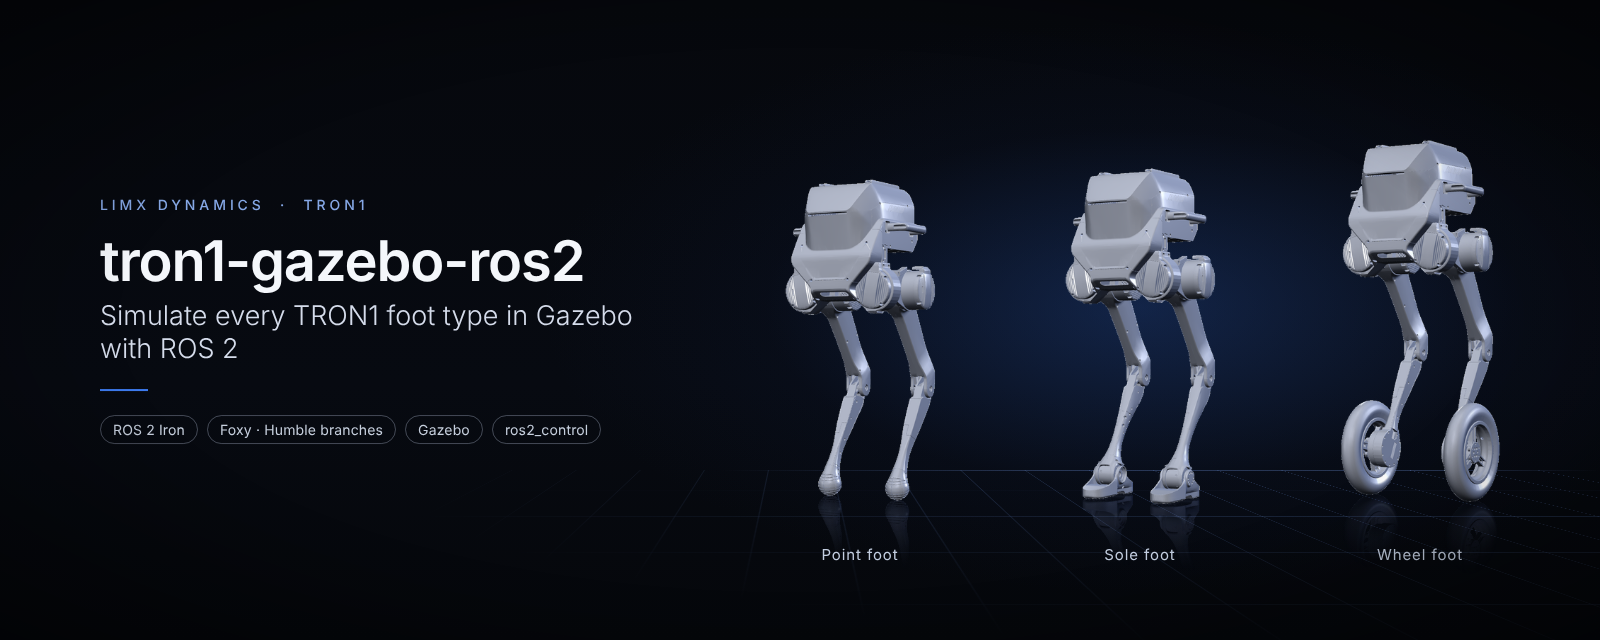
Gazebo simulation for TRON1 with ROS 2 Iron — physics sim & sensor models
MuJoCo simulator for the LimX TRON2 family — bridges SDK RobotCmd/RobotState to physics for controller testing and Sim-to-Real verification. Covers SF, WF, DA, DACH and DASF as TRON2A and TRON2B.
Isaac Lab RL training stack for TRON2A with 6-DoF arm and gripper — PPO-based locomotion policy training supporting SF/WF (foot variants) and SFYG/WFYG (arm+gripper locked variants). Built for the ATEC challenge.
Isaac Lab RL training for LimX Oli humanoid — Isaac Sim 4.5, sim-to-real locomotion
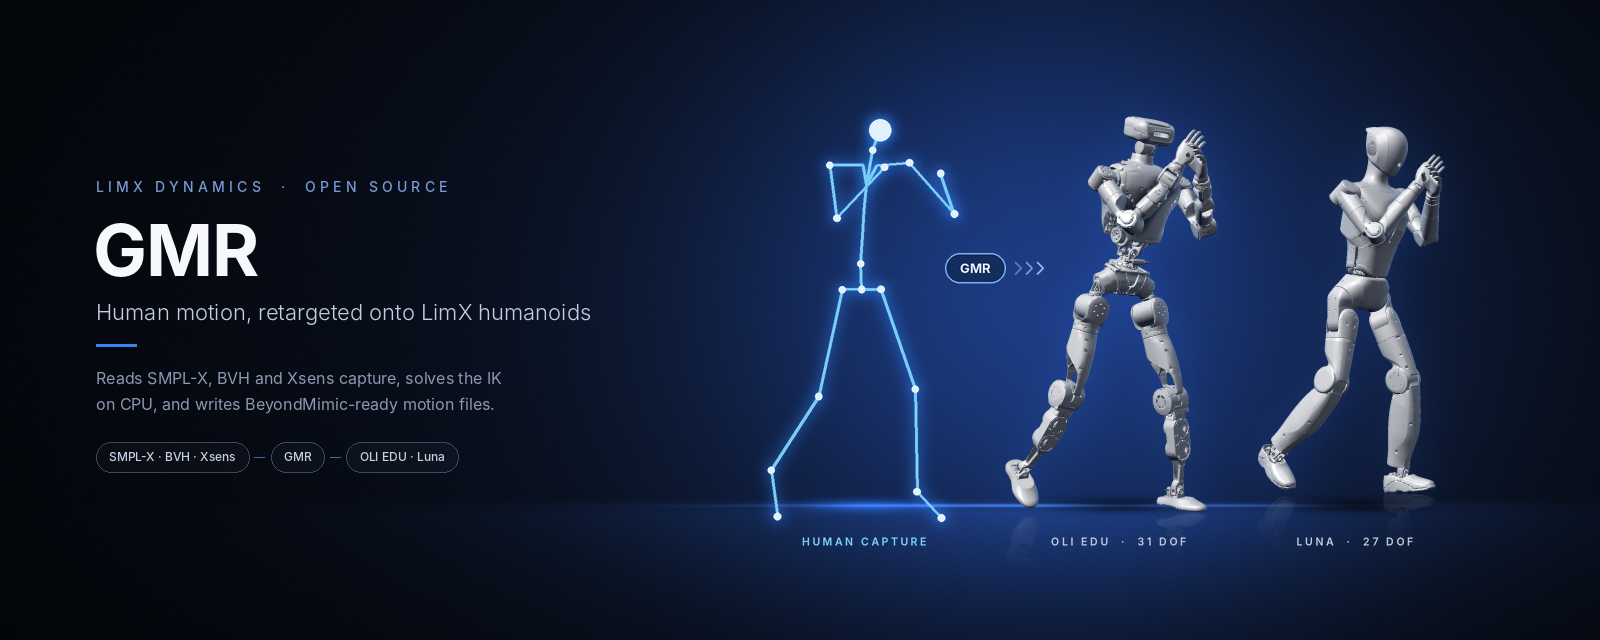
LimX Dynamics fork of GMR (General Motion Retargeting): retarget human motion (SMPL-X/BVH/Xsens/OptiTrack) into LimX humanoids (OLI EDU, Luna) and 17+ other robots in real time on CPU.
Insights into the embodied AI open-source ecosystem by LimX Dynamics, built from public GitHub data. 具身智能开源生态观察:月报与行业趋势。
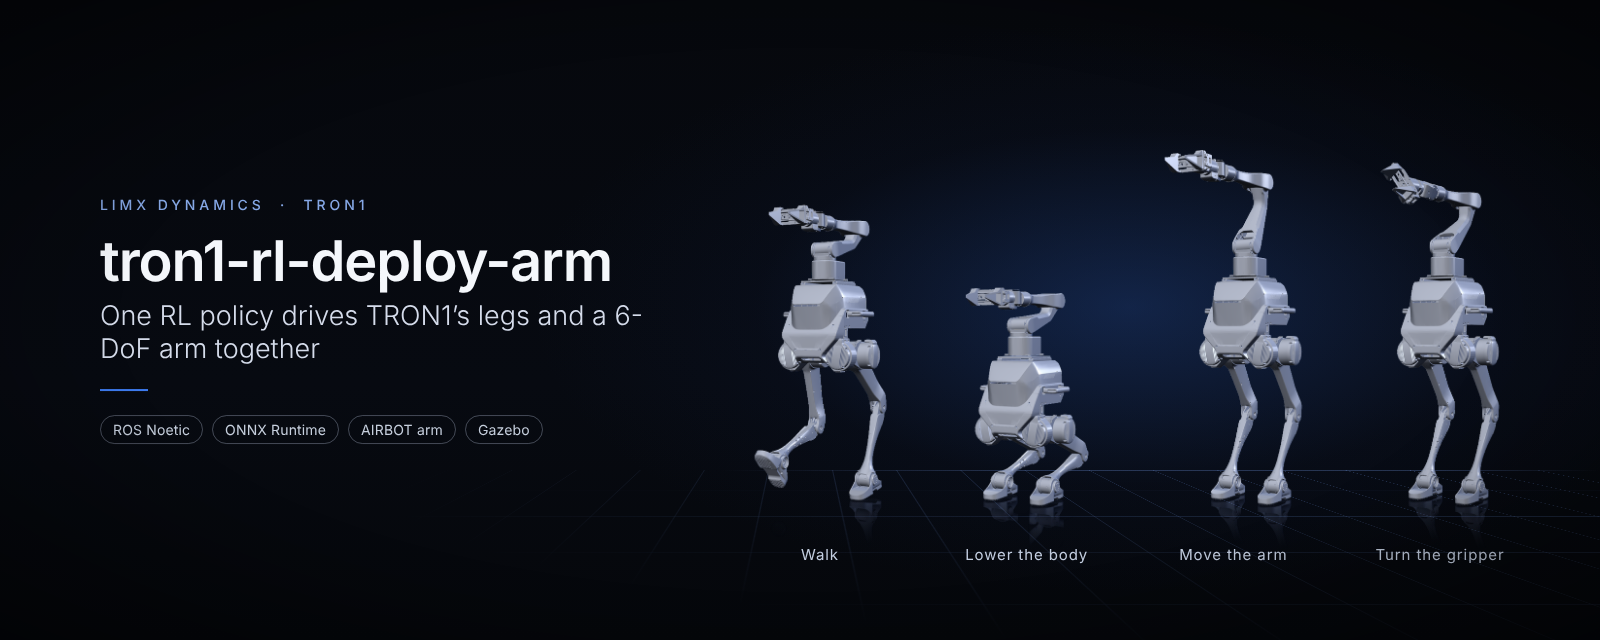
RL deployment for TRON1 arm — ONNX inference & real-robot manipulation
Gazebo simulation for TRON1 with ROS Noetic — physics sim & sensor models
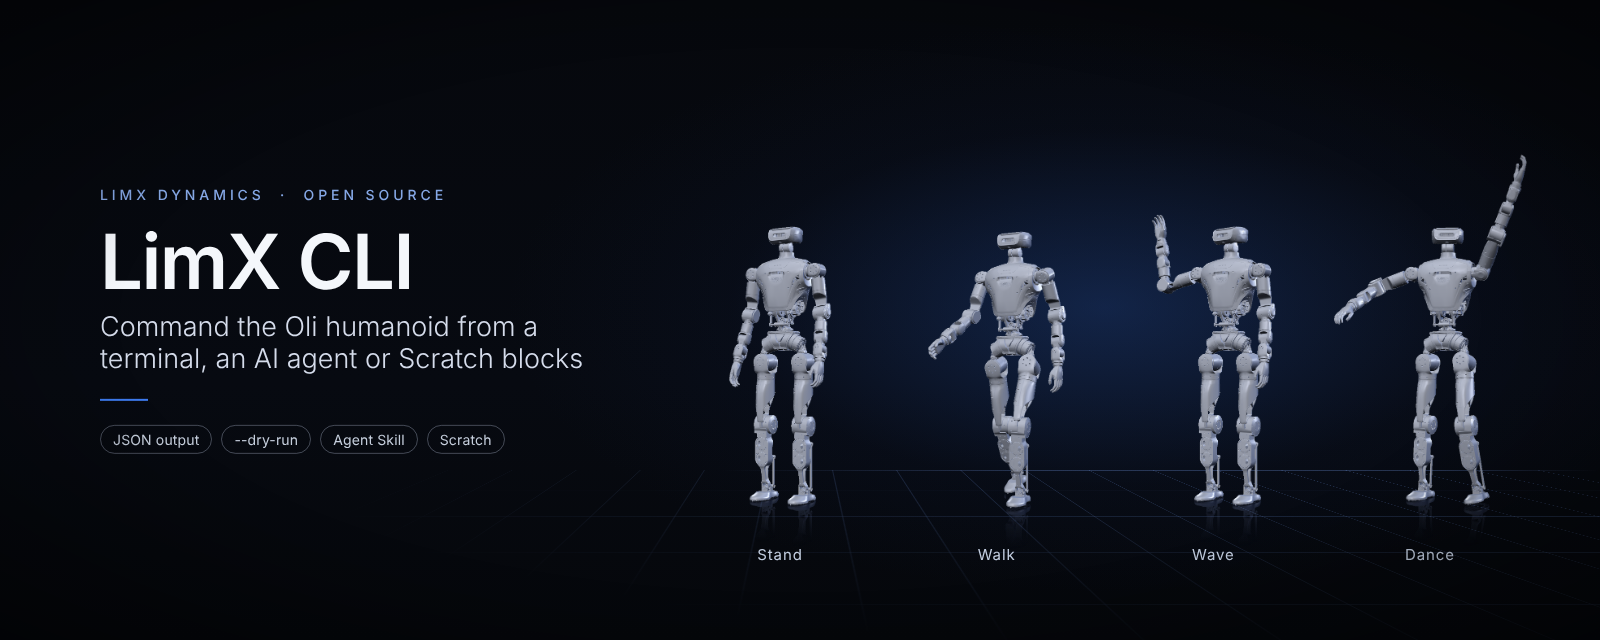
Skill control CLI for LimX robots — AI Agent orchestration & Scratch visual programming
ROS Noetic RL deployment workspace for TRON2 robots — unified ONNX inference pipeline with Gazebo simulation and real-hardware control. Supports SF (biped) and WF (wheel-foot) variants.
RL deployment/inference for LimX TRON2A humanoid — sole-foot, wheel-foot and dual-arm DASF ONNX policies via ONNX Runtime, on MuJoCo sim and real hardware.
Gazebo Classic 11 simulation workspace for TRON2 robots (ROS Noetic) — provides physics simulation with Tron2HWSim plugin bridging to LimX SDK. Supports SF (biped) and WF (wheel-foot) variants.
Manipulation controller runtime for the LimX TRON2A dual-arm robot (DACH_TRON2A) — QP-based motion planning & PD control over the WebSocket SDK, with a local MuJoCo simulation workspace.
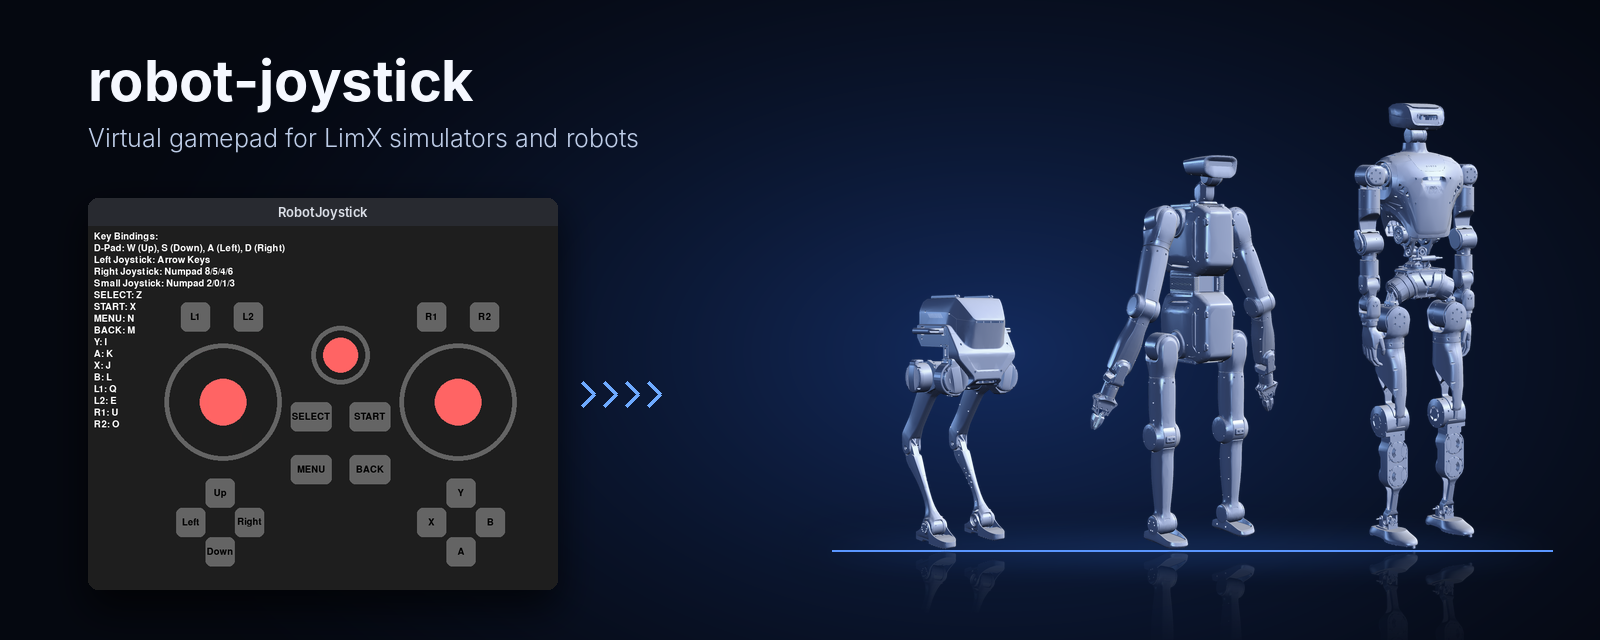
Virtual joystick for LimX robots — teleoperation & simulation control
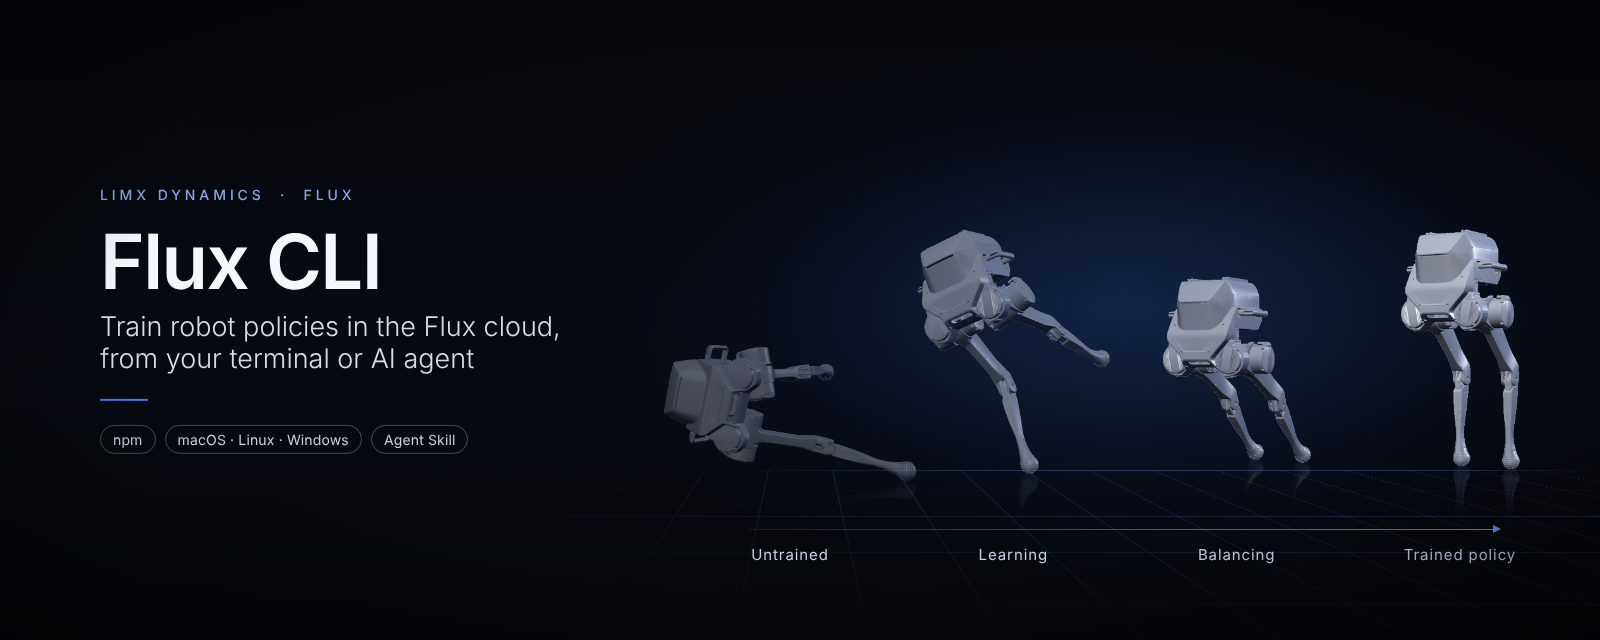
Cross-platform CLI for managing training tasks/projects — npm-distributed, JSON output for AI Agent automation
Gym-style runtime environment for LimX TRON2 manipulation — WebSocket robot transport, motion control & multi-camera observation.
GPL-2.0-or-later complete corresponding source for the PCT global planner used by LimX TRON2 ROS 2 navigation (tron2-navigation-ros2) — ROS 2 Humble/aarch64, Python wrapper, pybind11 extensions, retained GTSAM/OSQP sources.