mujoco_warp
GPU-optimized version of the MuJoCo physics simulator, designed for NVIDIA hardware.
- 1.6k
- Python
- Apache-2.0
- 2 d ago
GPU-optimized version of the MuJoCo physics simulator, designed for NVIDIA hardware.
One policy. Any motion. Train universal whole-body tracking in mjlab—swap clips, not checkpoints.
Reproducible Microduck RL experiments, policies, simulation assets, and hardware add-ons
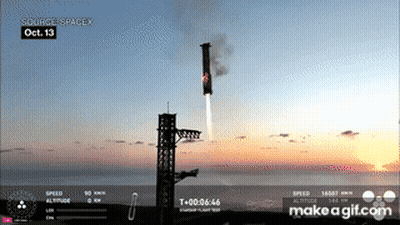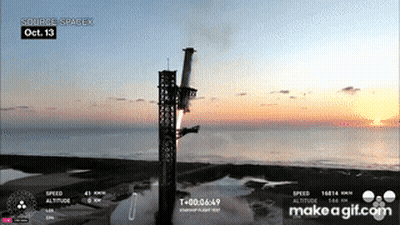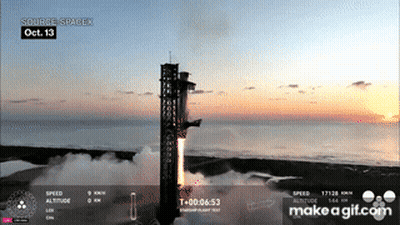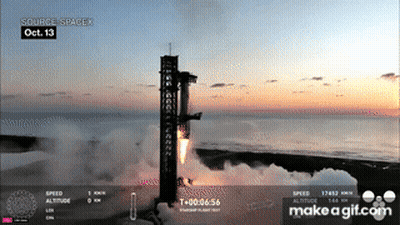
Train an RL agent to catch a descending rocket with mechanical chopstick arms, Mechazilla style.