bullet3
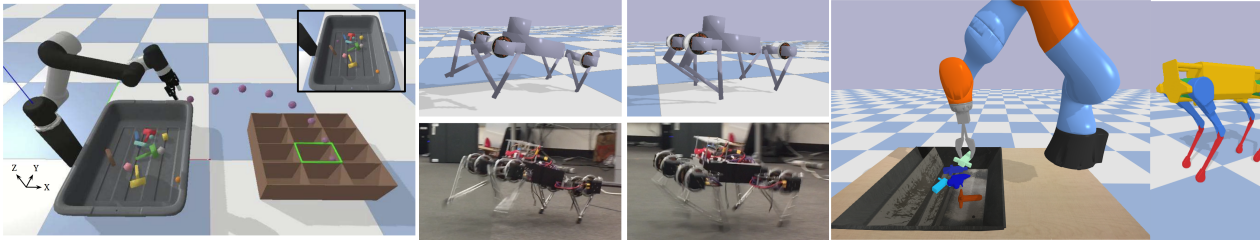
Bullet Physics SDK: real-time collision detection and multi-physics simulation for VR, games, visual effects, robotics, machine learning etc.
- 15k
- C++
- 6 wk ago
Bullet Physics SDK: real-time collision detection and multi-physics simulation for VR, games, visual effects, robotics, machine learning etc.
A training framework for Stable Baselines3 reinforcement learning agents, with hyperparameter optimization and pre-trained agents included.
PyBullet Gymnasium environments for single and multi-agent reinforcement learning of quadcopter control
OpenAI Gym environments for an open-source quadruped robot (SpotMicro)
Dynamics and Domain Randomized Gait Modulation with Bezier Curves for Sim-to-Real Legged Locomotion.
PyBullet CartPole and Quadrotor environments—with CasADi symbolic a priori dynamics—for learning-based control and RL
Representing robots as graphs for reinforcement-learning in PyBullet locomotion environments.
Open-source implementations of OpenAI Gym MuJoCo environments for use with the OpenAI Gym Reinforcement Learning Research Platform.
Bullet Physics SDK: real-time collision detection and multi-physics simulation for VR, games, visual effects, robotics, machine learning etc.
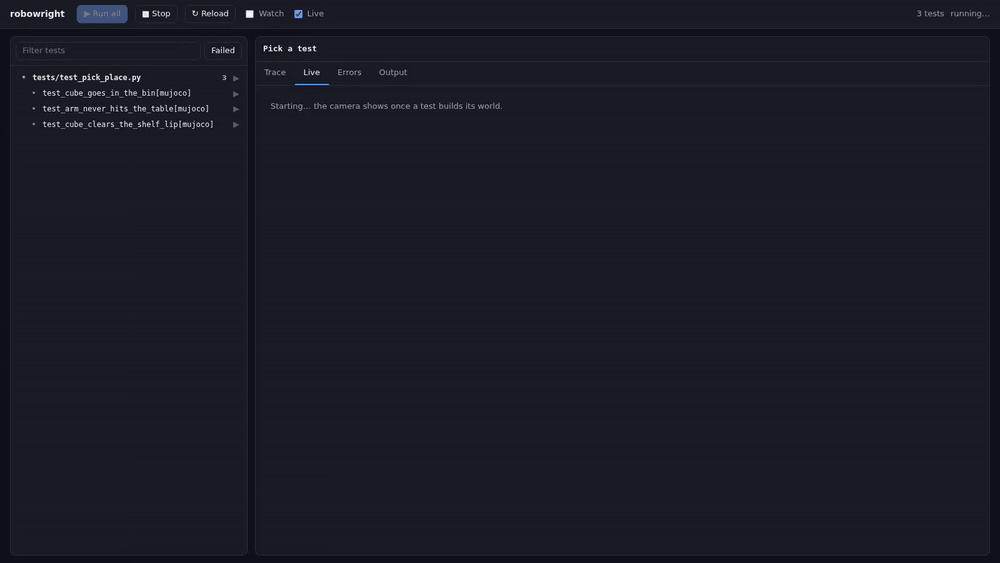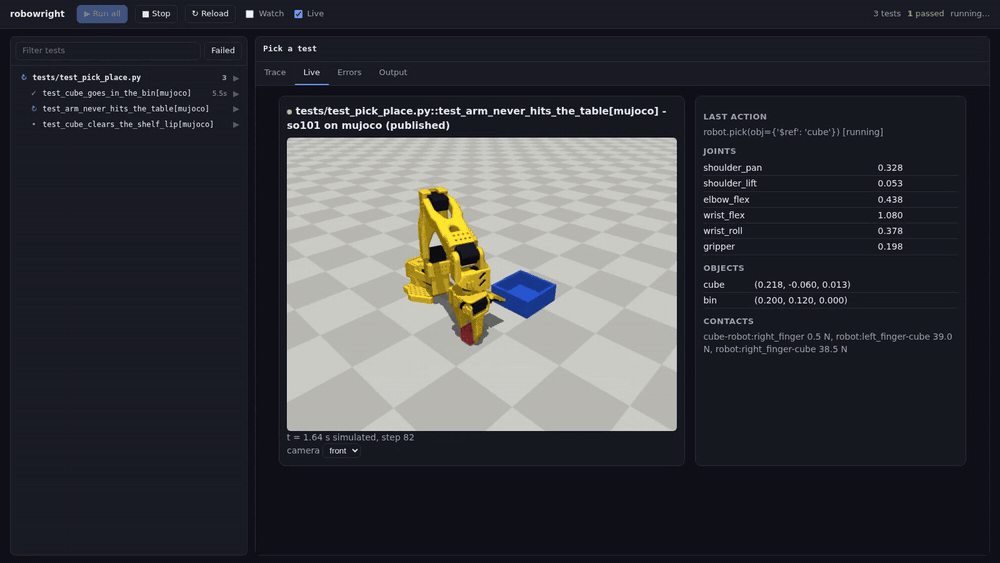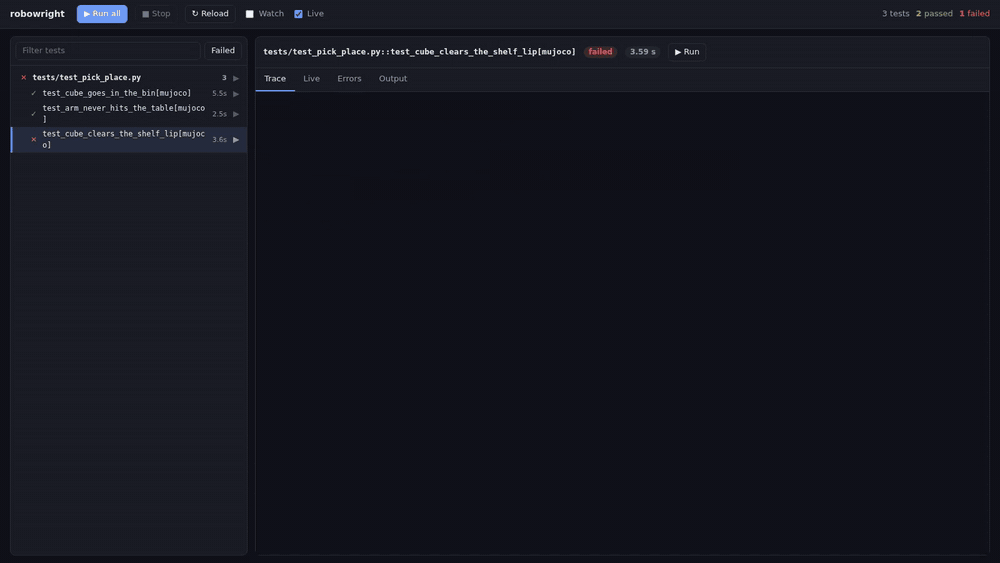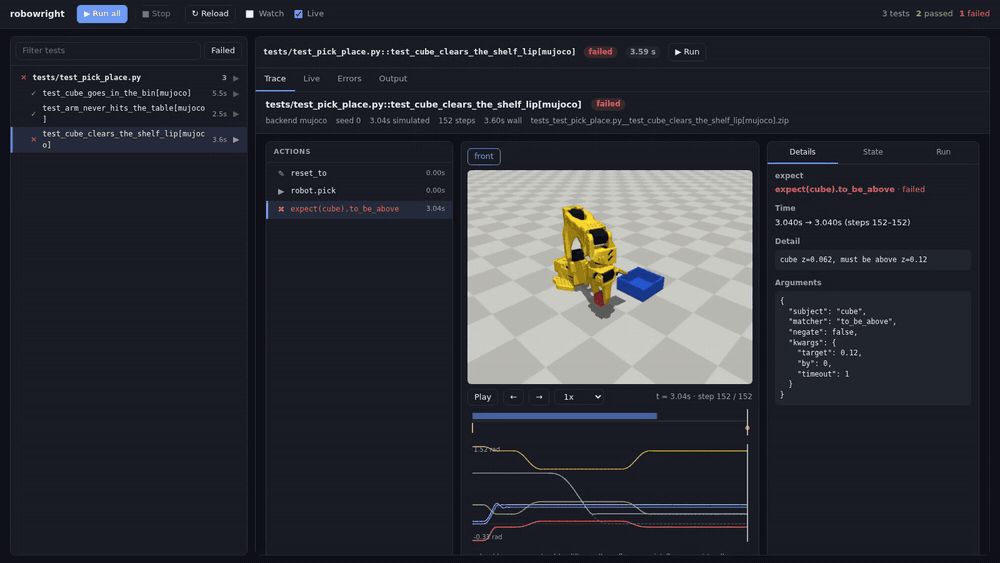
Playwright-style testing for robots: one pytest test, 19 robots (Franka, UR, Kinova, KUKA, xArm, ALOHA, Unitree, Spot...), five physics engines (MuJoCo, PyBullet, Drake, Genesis, Isaac Sim). Auto-waiting actions, expect() assertions, traces, deterministic replay, codegen.