Dstar-lite-pathplanner
Implementation of the D* lite algorithm in Python for "Improved Fast Replanning for Robot Navigation in Unknown Terrain"
- 198
- Python
- MIT
- 3 y ago
Implementation of the D* lite algorithm in Python for "Improved Fast Replanning for Robot Navigation in Unknown Terrain"
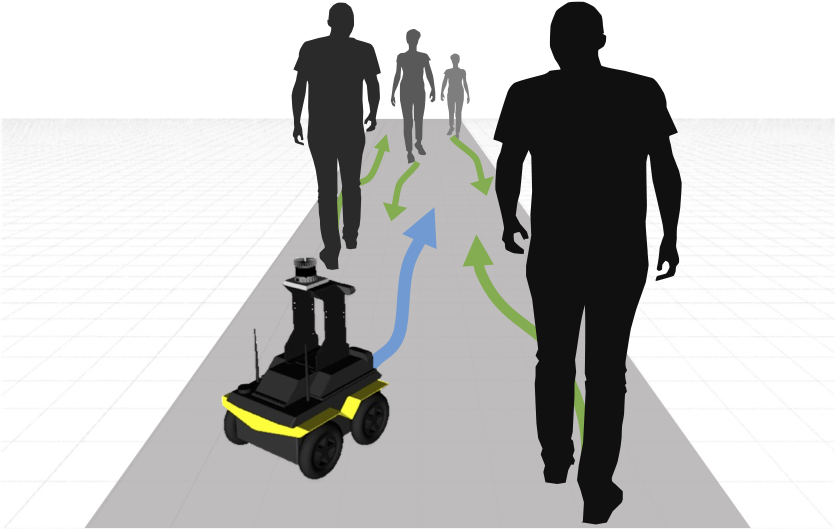
Code base for SICNav T-RO paper and SICNav-Diffusion RA-L paper
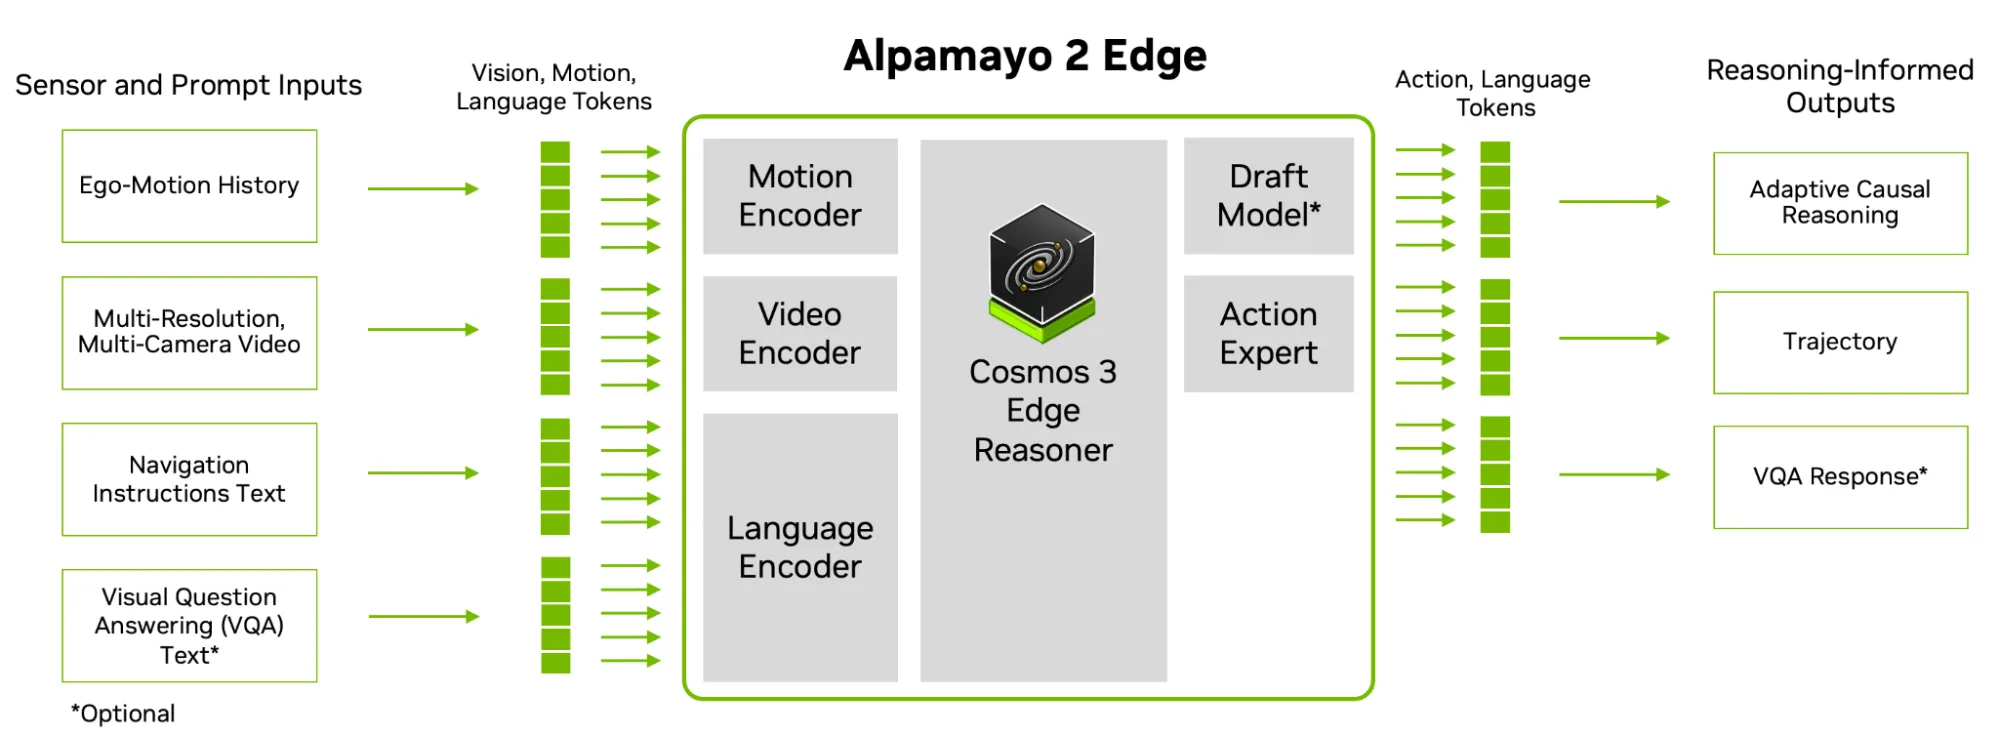
NVIDIA Alpamayo 2 Edge is a 2B-parameter in-vehicle reasoning vision-language-action model using adaptive reasoning to generate trajectories and causal explanations for fine-tuning and efficient deployment.
Simple differential drive robot for indoor environments simulated using ROS and Gazebo.