AgiBot-World
[IROS 2025 Best Paper Award Finalist & IEEE TRO 2026] The Large-scale Manipulation Platform for Scalable and Intelligent Embodied Systems
- 3.2k
- Python
- 6 mo ago
[IROS 2025 Best Paper Award Finalist & IEEE TRO 2026] The Large-scale Manipulation Platform for Scalable and Intelligent Embodied Systems
Official repository for "RLVR-World: Training World Models with Reinforcement Learning" (NeurIPS 2025), https://arxiv.org/abs/2505.13934
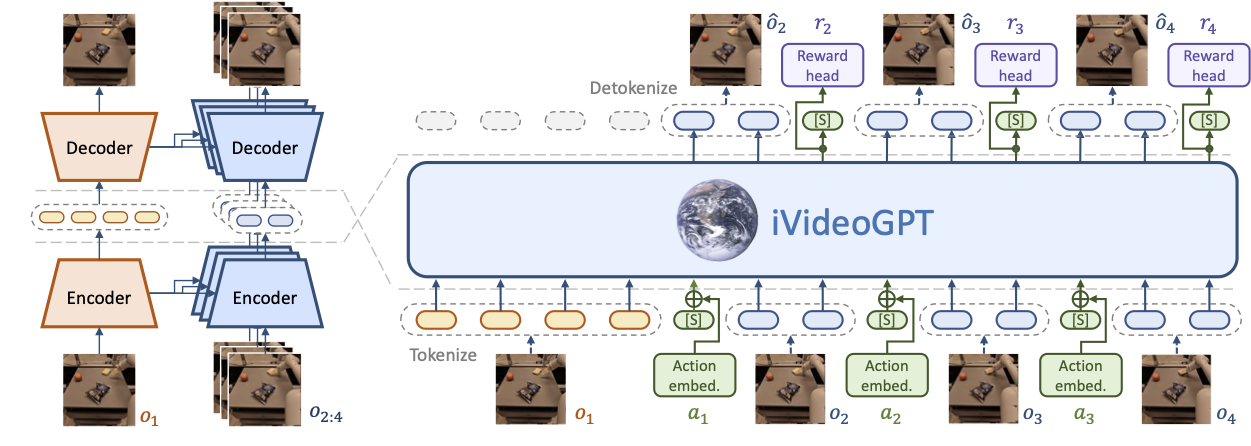
Official repository for "iVideoGPT: Interactive VideoGPTs are Scalable World Models" (NeurIPS 2024), https://arxiv.org/abs/2405.15223
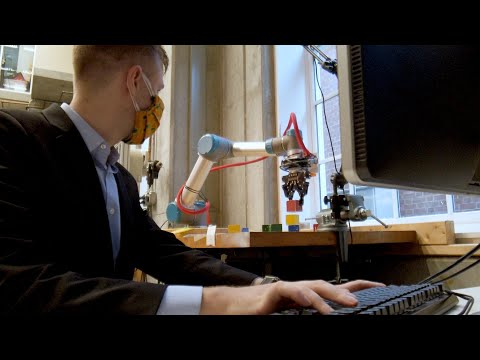
"Good Robot! Now Watch This!": Repurposing Reinforcement Learning for Task-to-Task Transfer; and “Good Robot!”: Efficient Reinforcement Learning for Multi-Step Visual Tasks with Sim to Real Transfer
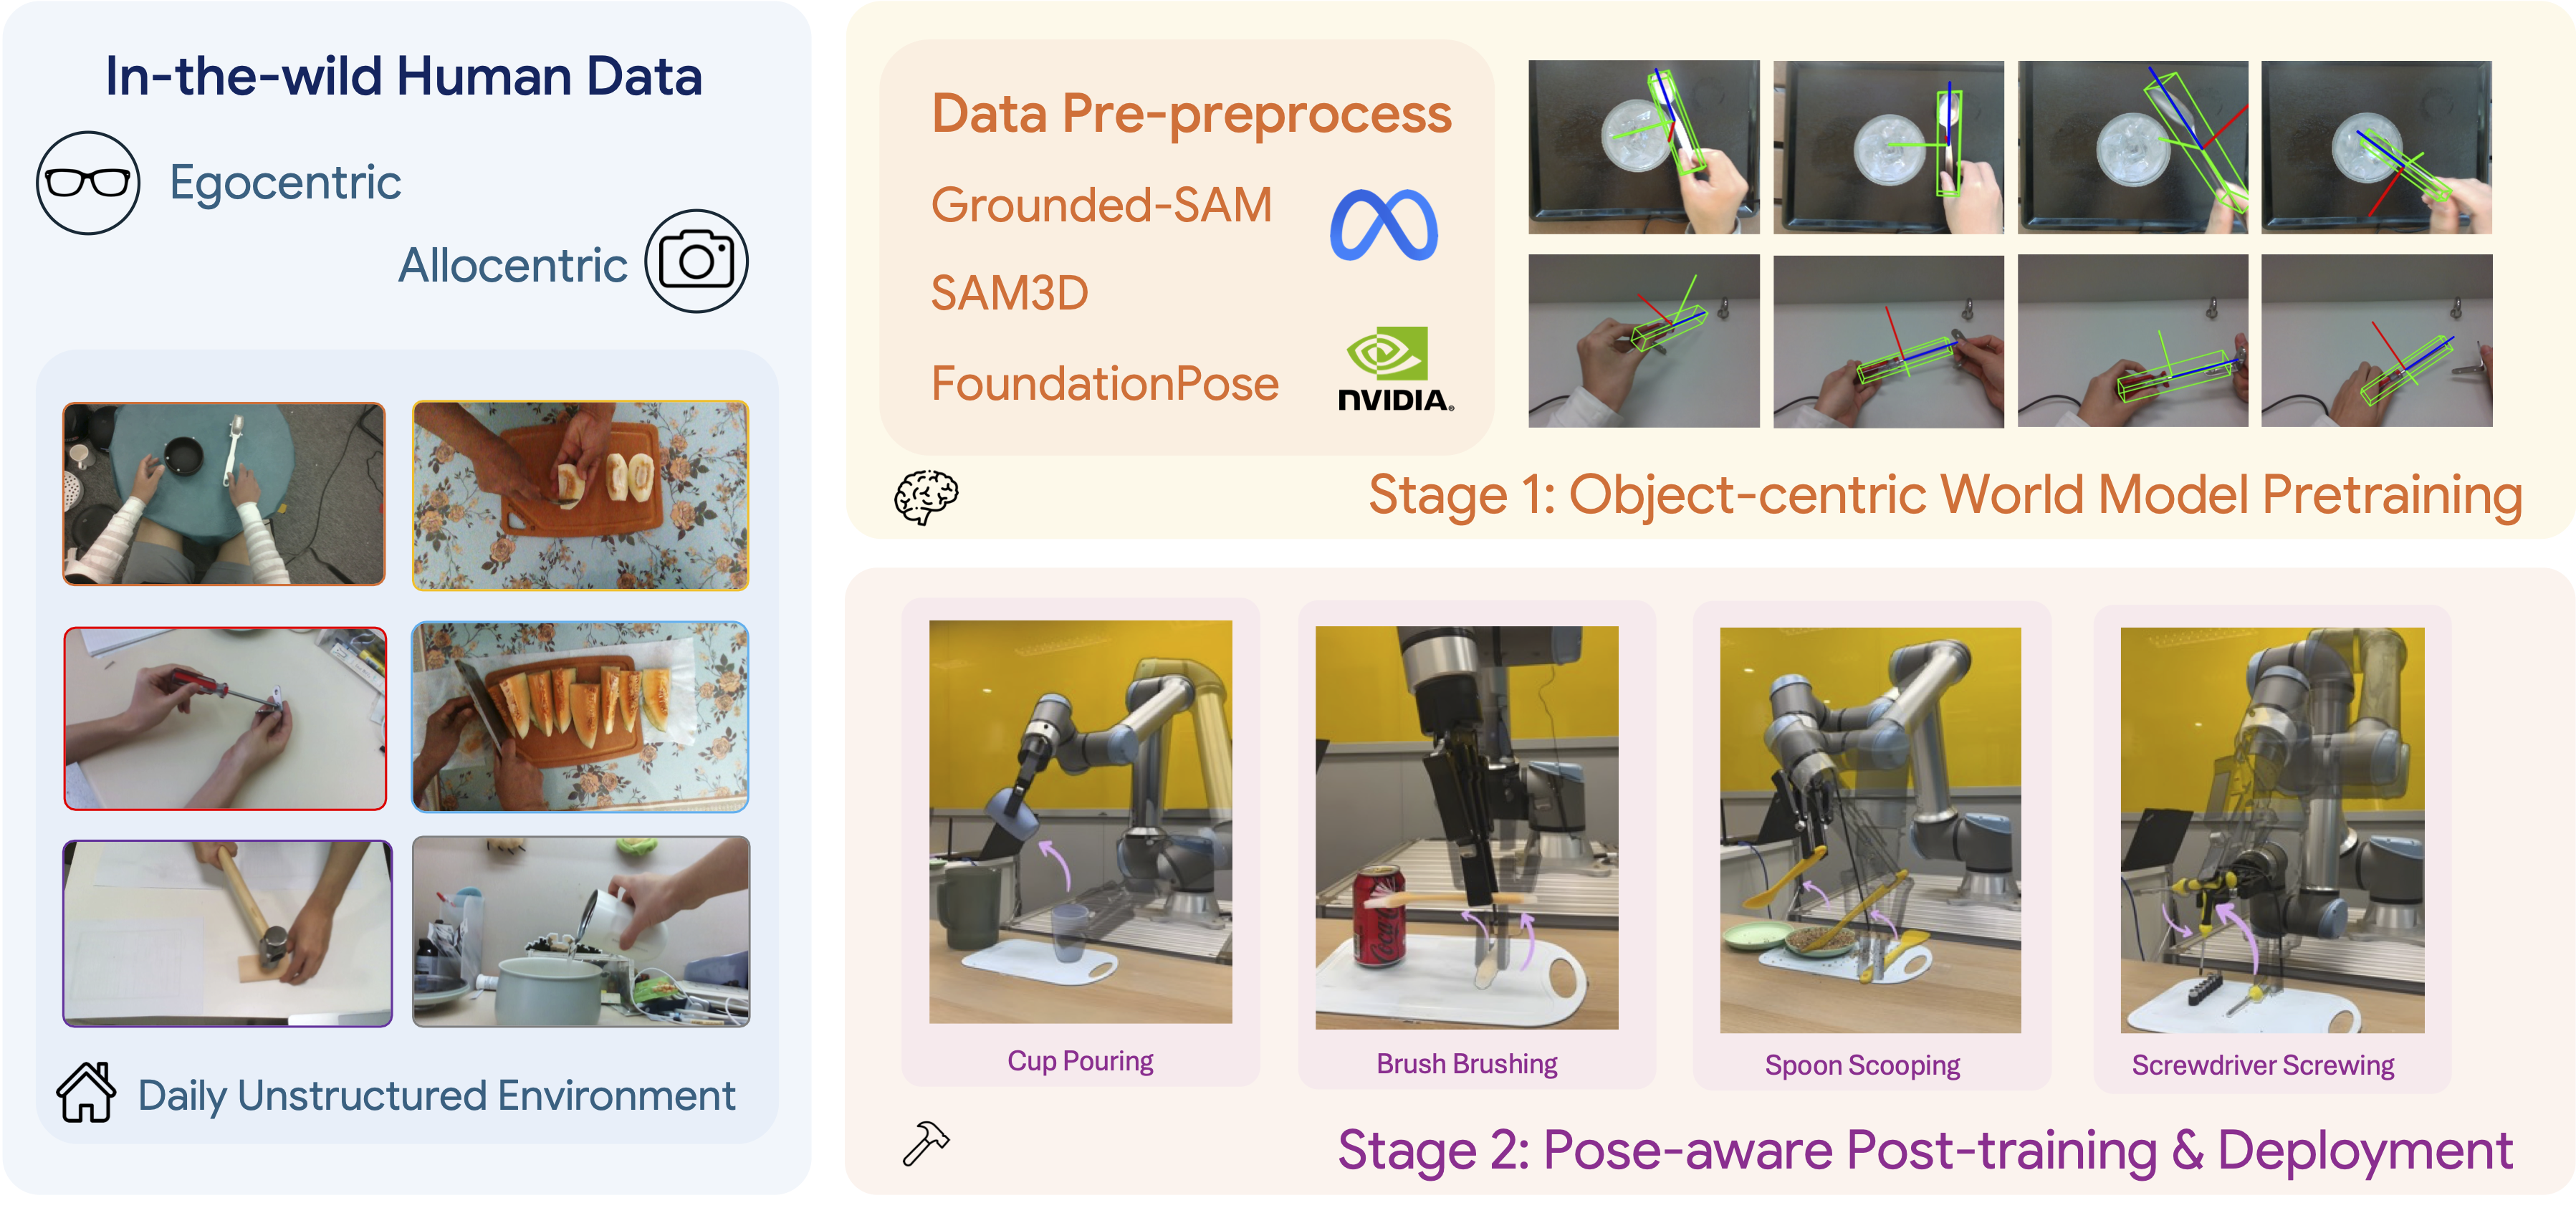
From Pixel to Poses: Object-centric Tool Manipulation Learning from Human Demonstrations
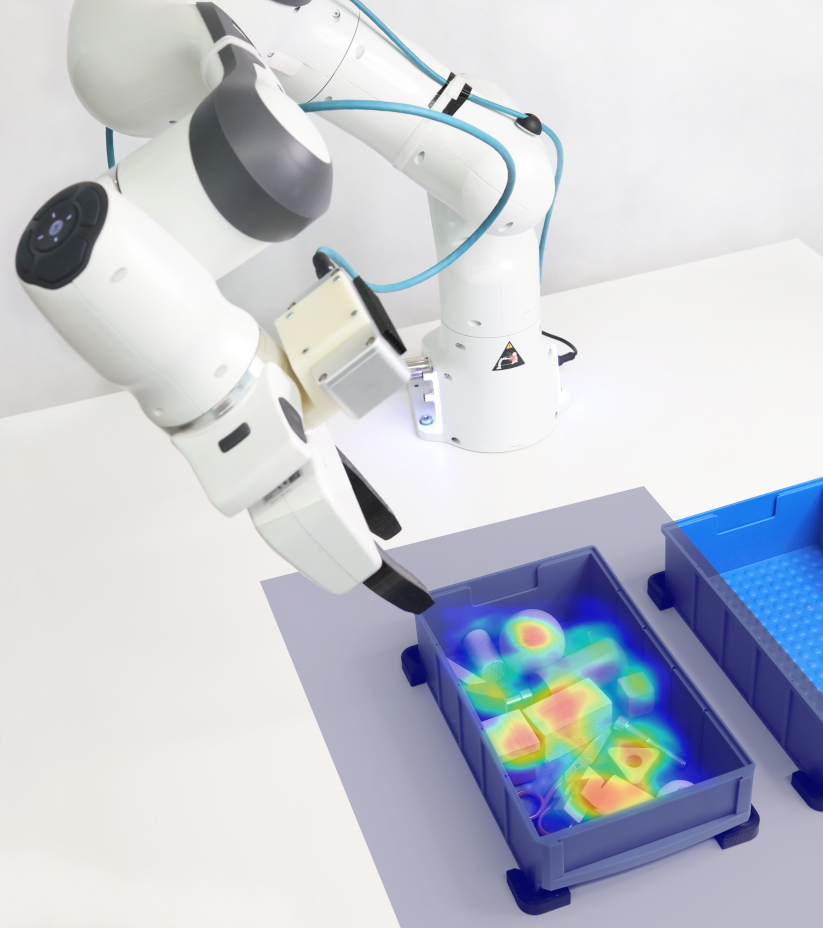
Learning a Generative Transition Model for Uncertainty-Aware Robotic Manipulation
🤖 A curated collection of robotics and embodied AI resources, covering VLA models, humanoid robots, robotic arms, SLAM, simulation, and embedded systems.
Iterative Compositional Data Generation for Robot Control
Anonymous manuscript draft on recursive task-policy improvement through autonomous experience feedback in simulated robotic manipulation.