rosbag


cerulion
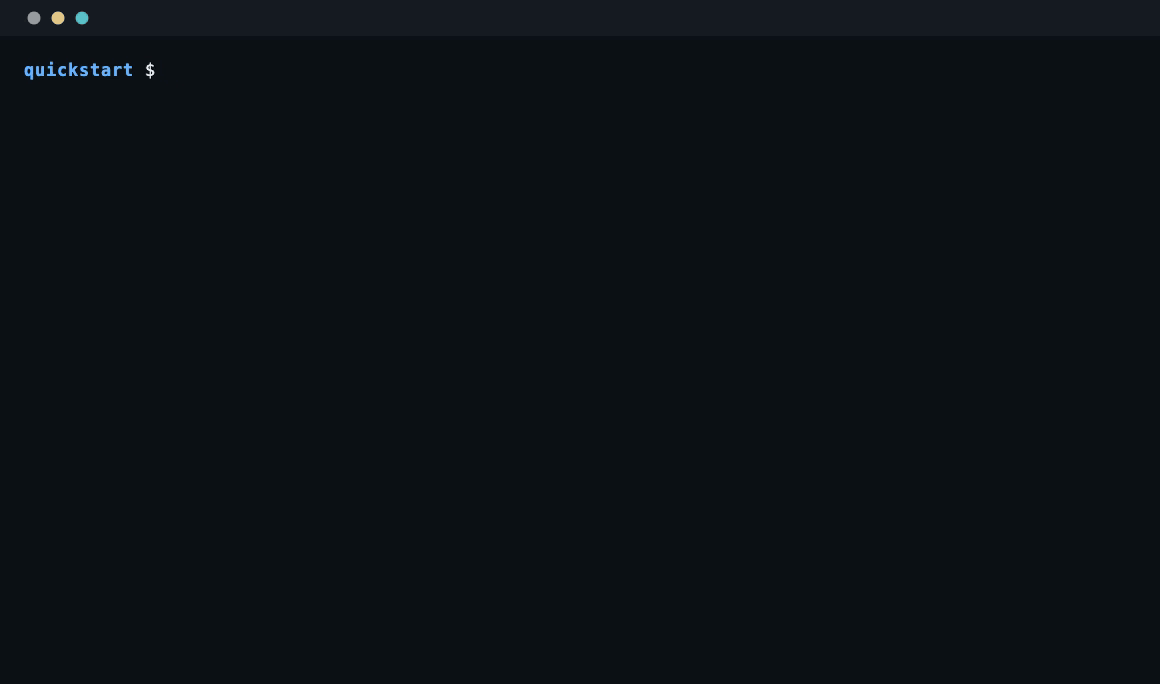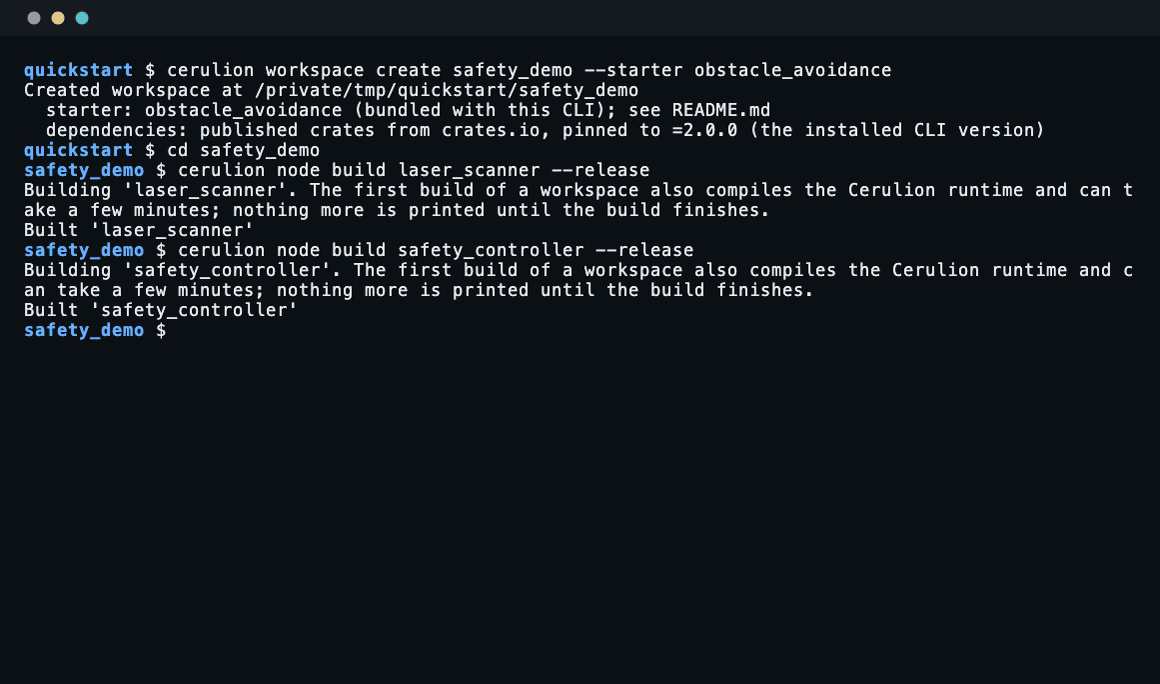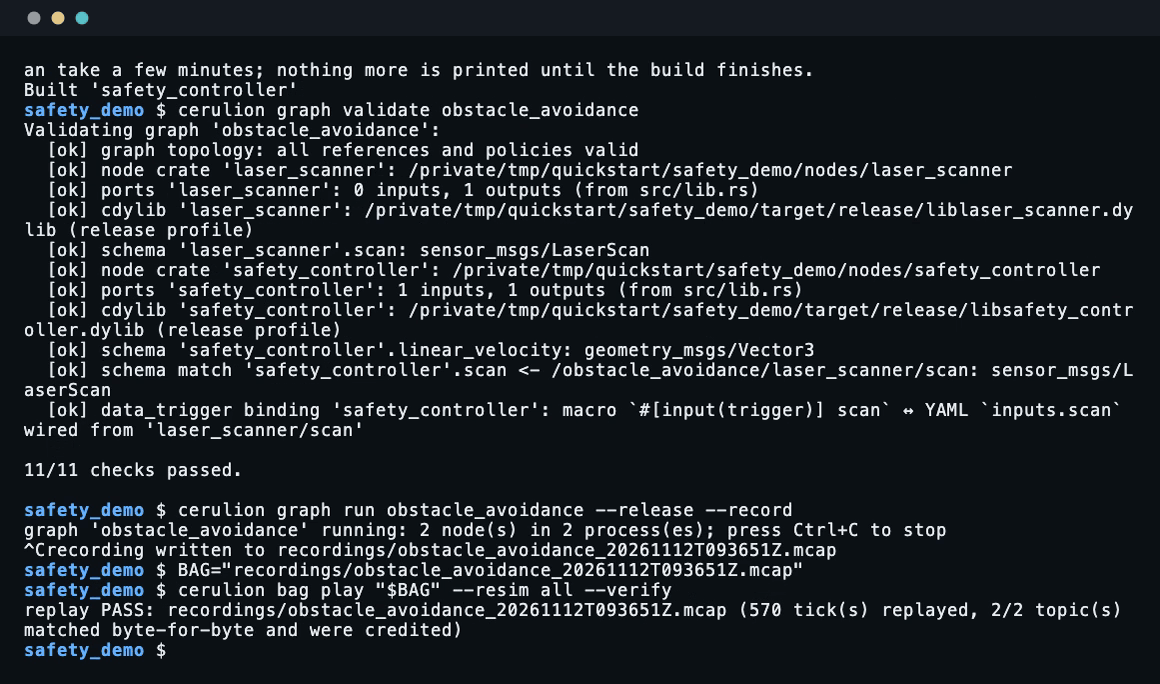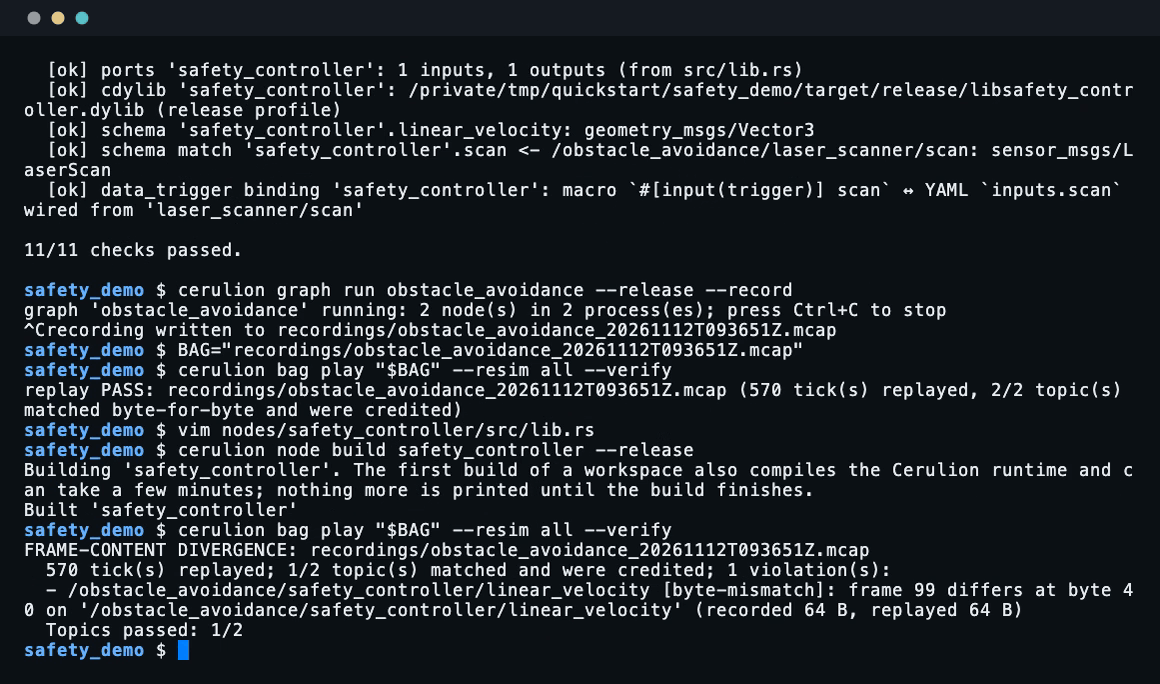
Cerulion (YC S24) gives AI agents a harness to control real robots. Our open-source runtime and harness give any AI agent a physical body, inside safety limits the robot enforces, and tools to autonomously debug recorded robot failures. It's ROS 2 compatible.
- 121
- Rust
- AGPL-3.0
- 6 h ago

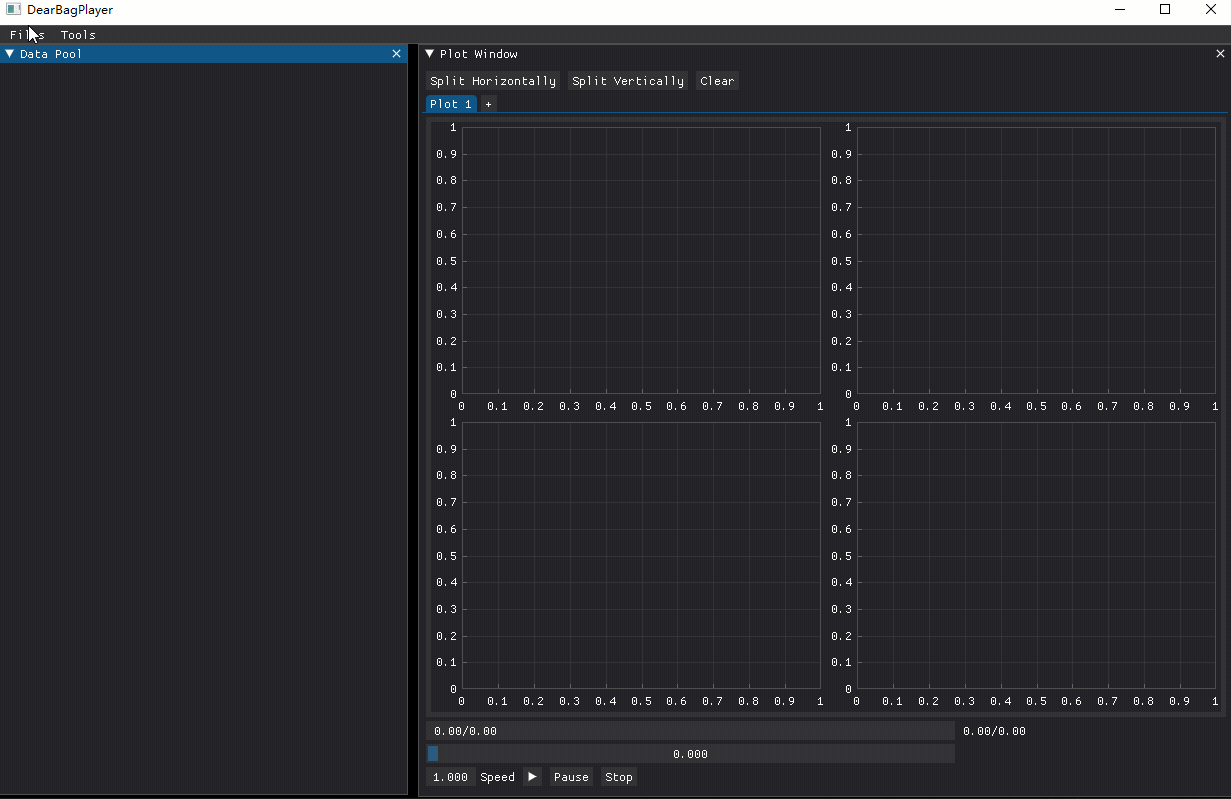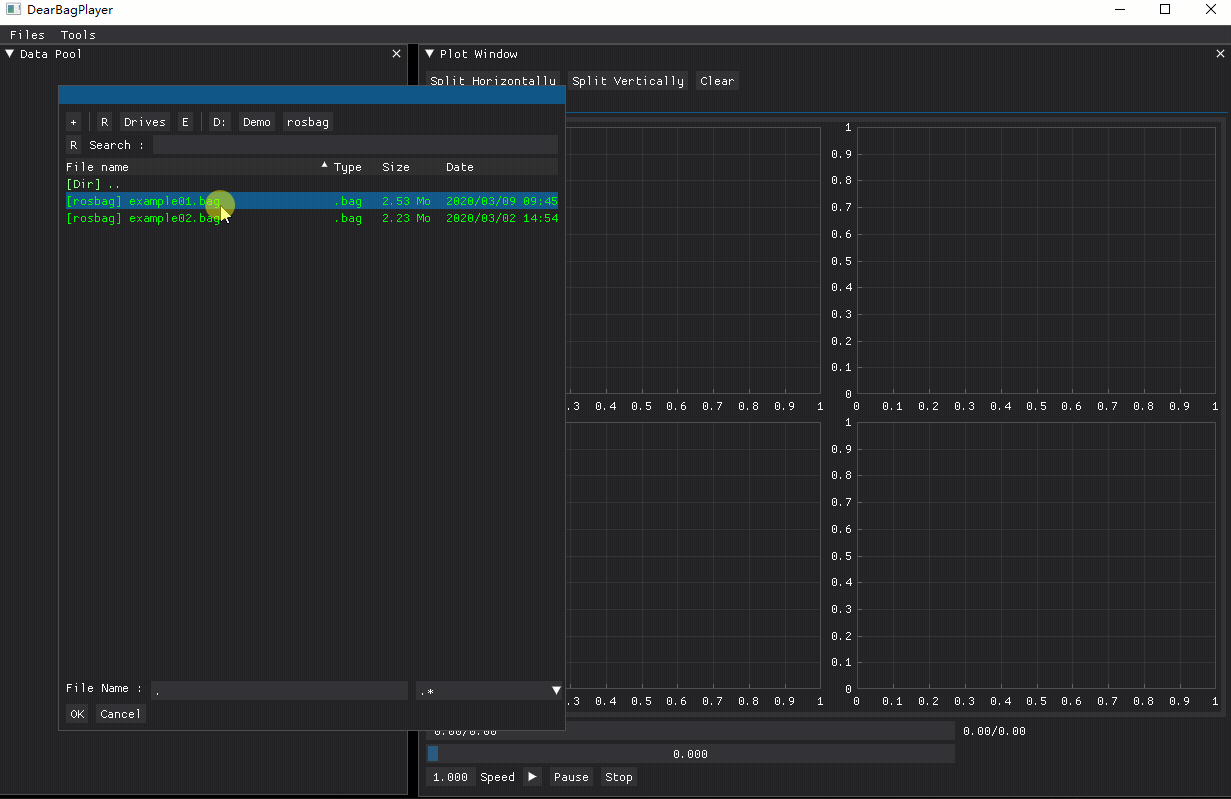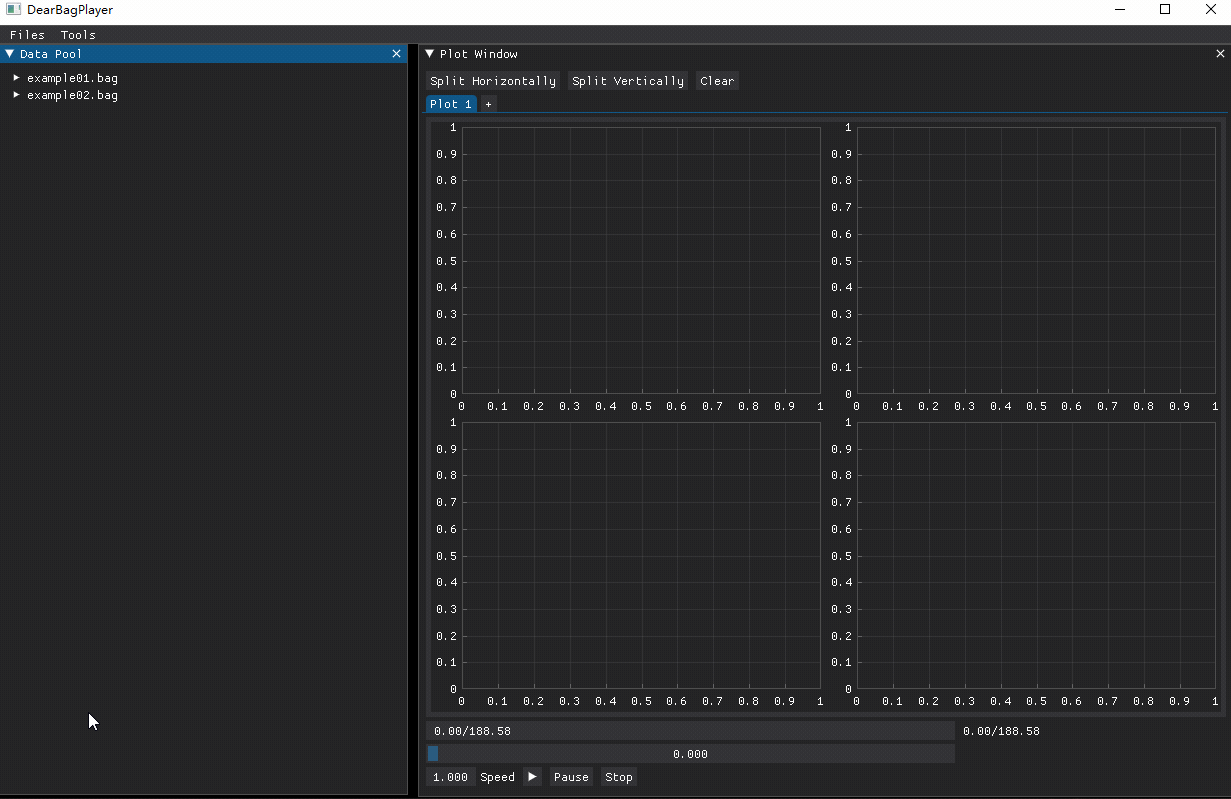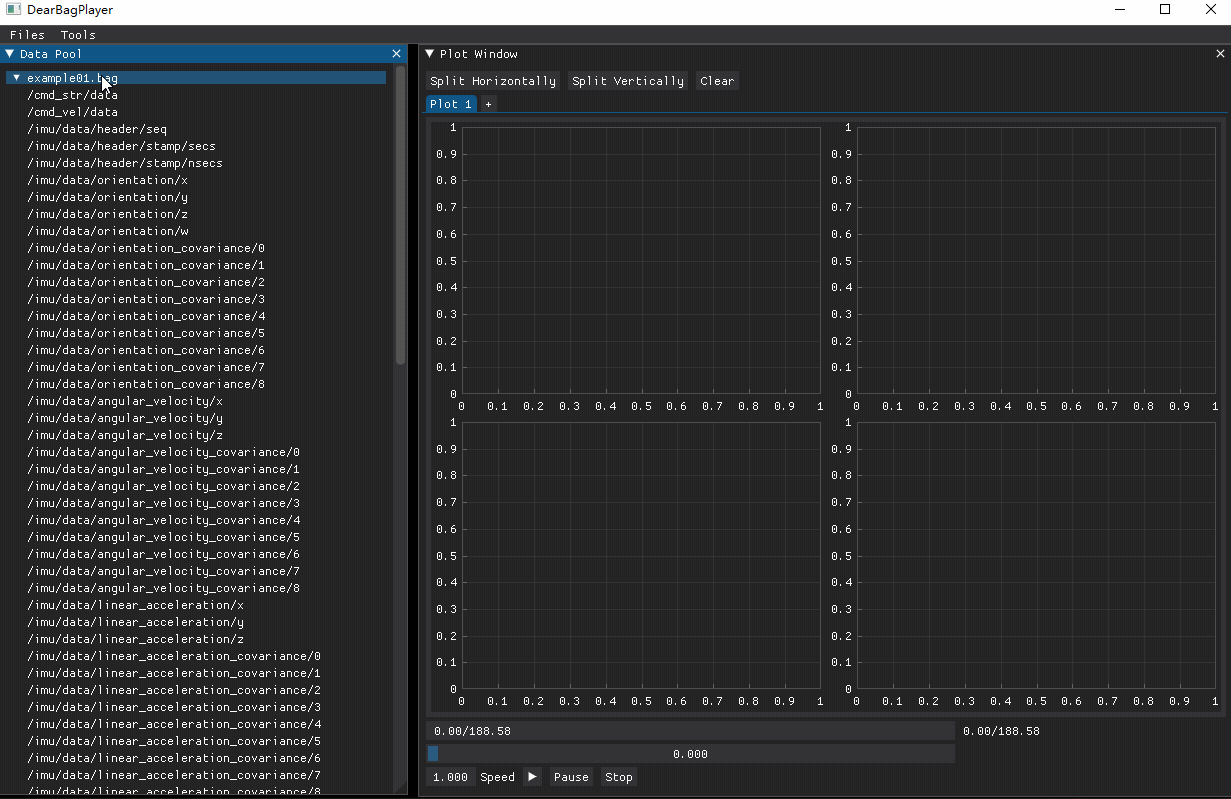
DearBagPlayer
DearBagPlayer is a flexible rosbag player based on Dear PyGui in Python.
- 73
- Python
- MIT
- 2 mo ago


ros-time-machine
A dashcam for your robot: ROS 2 recording that keeps the seconds before the moment that matters. v2: describe events in plain English and a vision-language model saves the clips.
- 23
- Python
- 3 wk ago


ros2bag_converter
Convert ROS 2 .db3 bags to CSV/JSON in your browser, no ROS install required
- 0
- Python
- Apache-2.0
- 5 mo ago


docker-rosbag-to-image
Simple Docker setup to create images from a ROS 1 rosbag to JPEG files using image_view
- 0
- Dockerfile
- BSD-3-Clause
- 4 y ago
