
ETA
[ICCV 2025] ETA: Efficiency through Thinking Ahead, A Dual Approach to Self-Driving with Large Models
- 47
- MIT
- 17 mo ago
Repo OpenDriveLab/ETA, read from GitHub 45 min ago. OpenDriveLab has not joined Take My Repo.
In short
OpenDriveLab/ETA is a public repo on GitHub by OpenDriveLab. [ICCV 2025] ETA: Efficiency through Thinking Ahead, A Dual Approach to Self-Driving with Large Models. It declares the MIT license on GitHub. It is written mainly in Python, has 47 stars and last changed on 2025-07-02. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-22.
[!IMPORTANT] 🌟 Stay up to date at opendrivelab.com!
🤔 ETA
Highlight
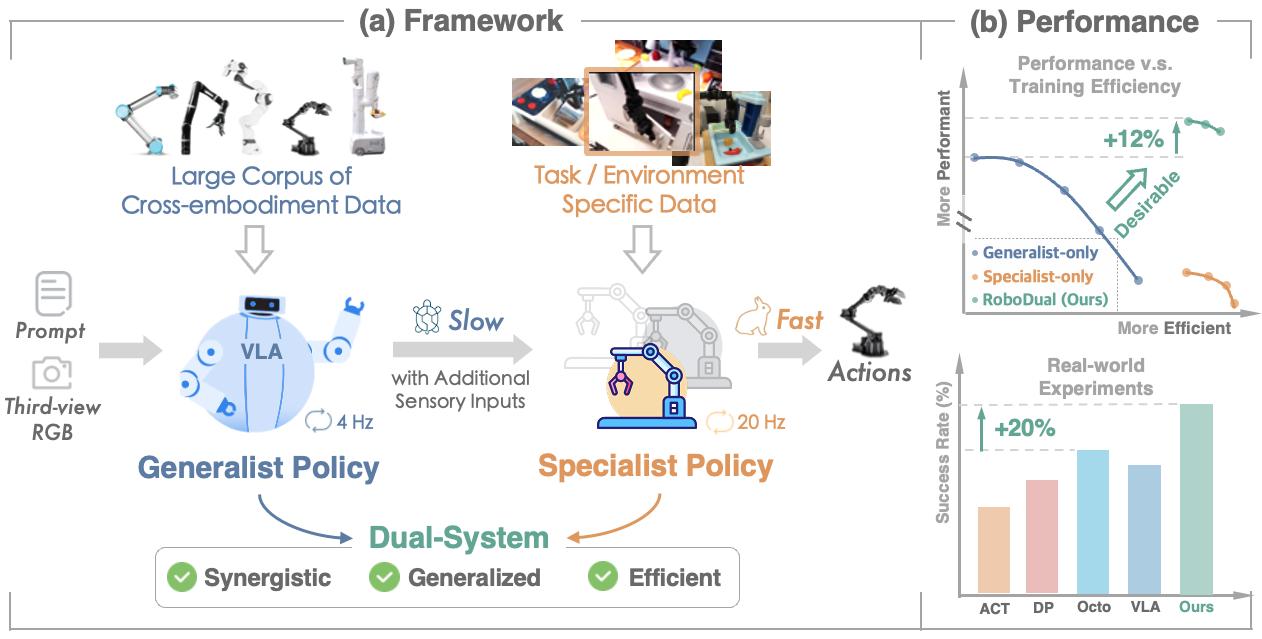
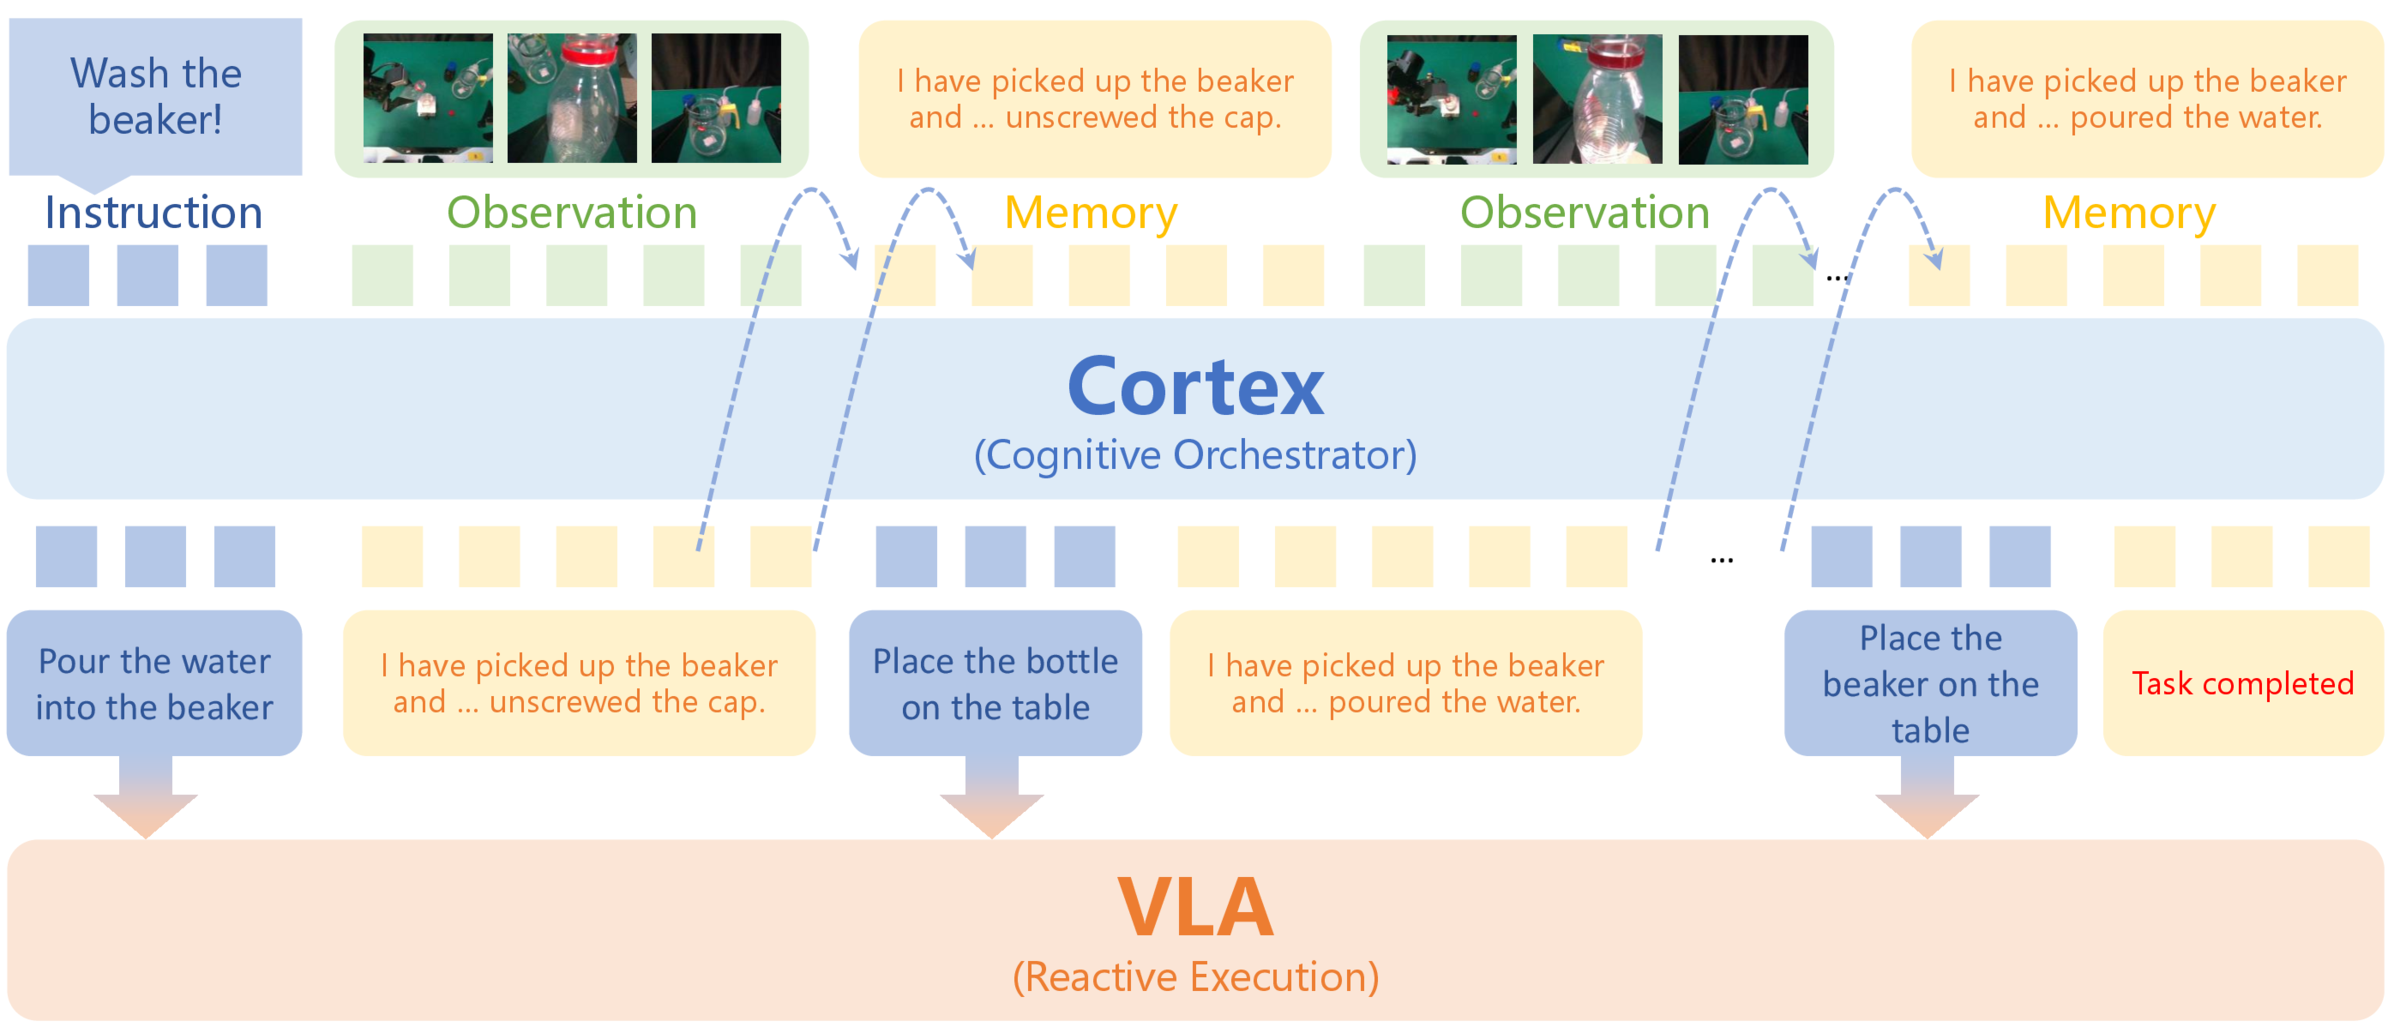
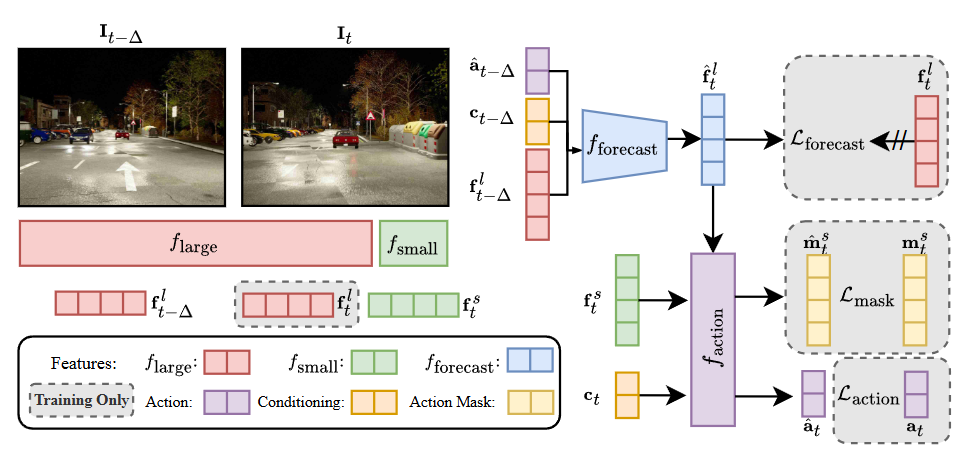
We propose "Efficiency through Thinking Ahead" (ETA), an asynchronous dual-system that pre-processes information from past frames using a large model in tandem with processing the current information with a small model to enable real-time decisions with strong performance.
News
[2025/06/10]ETA paper and code release!
Results
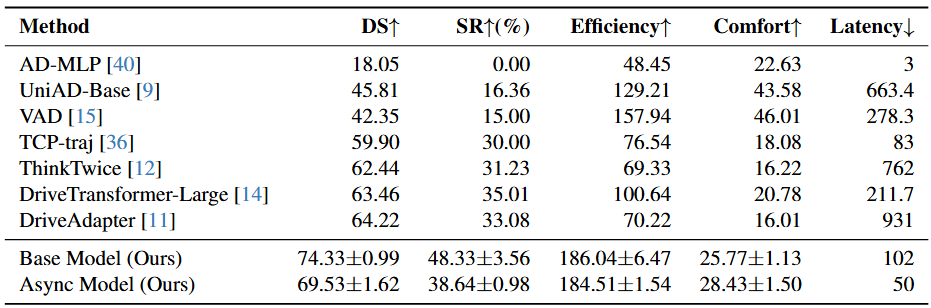
Table of Contents
Getting Started
To get started with ETA:
- Training
- Evaluation
TODO List
- ETA Training code
- ETA Evaluation
- Inference Code
- Checkpoints
Acknowledgements
This codebase builds on open sourced code from CARLA Garage and Bench2DriveZoo among others. We thank the authors for their contributions. This project is funded by the European Union (ERC, ENSURE, 101116486) with additional compute support from Leonardo Booster (EuroHPC Joint Undertaking, EHPC-AI-2024A01-060). Views and opinions expressed are however those of the author(s) only and do not necessarily reflect those of the European Union or the European Research Council. Neither the European Union nor the granting authority can be held responsible for them. This study is also supported by National Natural Science Foundation of China (62206172) and Shanghai Committee of Science and Technology (23YF1462000).
License and Citation
This project is released under the MIT License. If you find our project useful for your research, please consider citing our paper with the following BibTeX:
@article{hamdan2025eta,
  title={ETA: Efficiency through Thinking Ahead, A Dual Approach to Self-Driving with Large Models},
  author={Hamdan, Shadi and Sima, Chonghao and Yang, Zetong and Li, Hongyang and G{\"u}ney, Fatma},
  journal={arXiv preprint arXiv:2506.07725},
  year={2025}
}
Questions
What is ETA?
OpenDriveLab/ETA is a public repo on GitHub by OpenDriveLab. [ICCV 2025] ETA: Efficiency through Thinking Ahead, A Dual Approach to Self-Driving with Large Models.
Is ETA open source?
It declares the MIT license on GitHub.
Does ETA run on macOS, Windows or Linux?
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
How do I install ETA?
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Is ETA still maintained?
Its last change on GitHub was on 2025-07-02. Take My Repo does not judge from that whether it is maintained.
What do people who ran ETA say?
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.