transferlearning
Transfer learning / domain adaptation / domain generalization / multi-task learning etc. Papers, codes, datasets, applications, tutorials.-迁移学习
- 14k
- Python
- MIT
- 21 mo ago
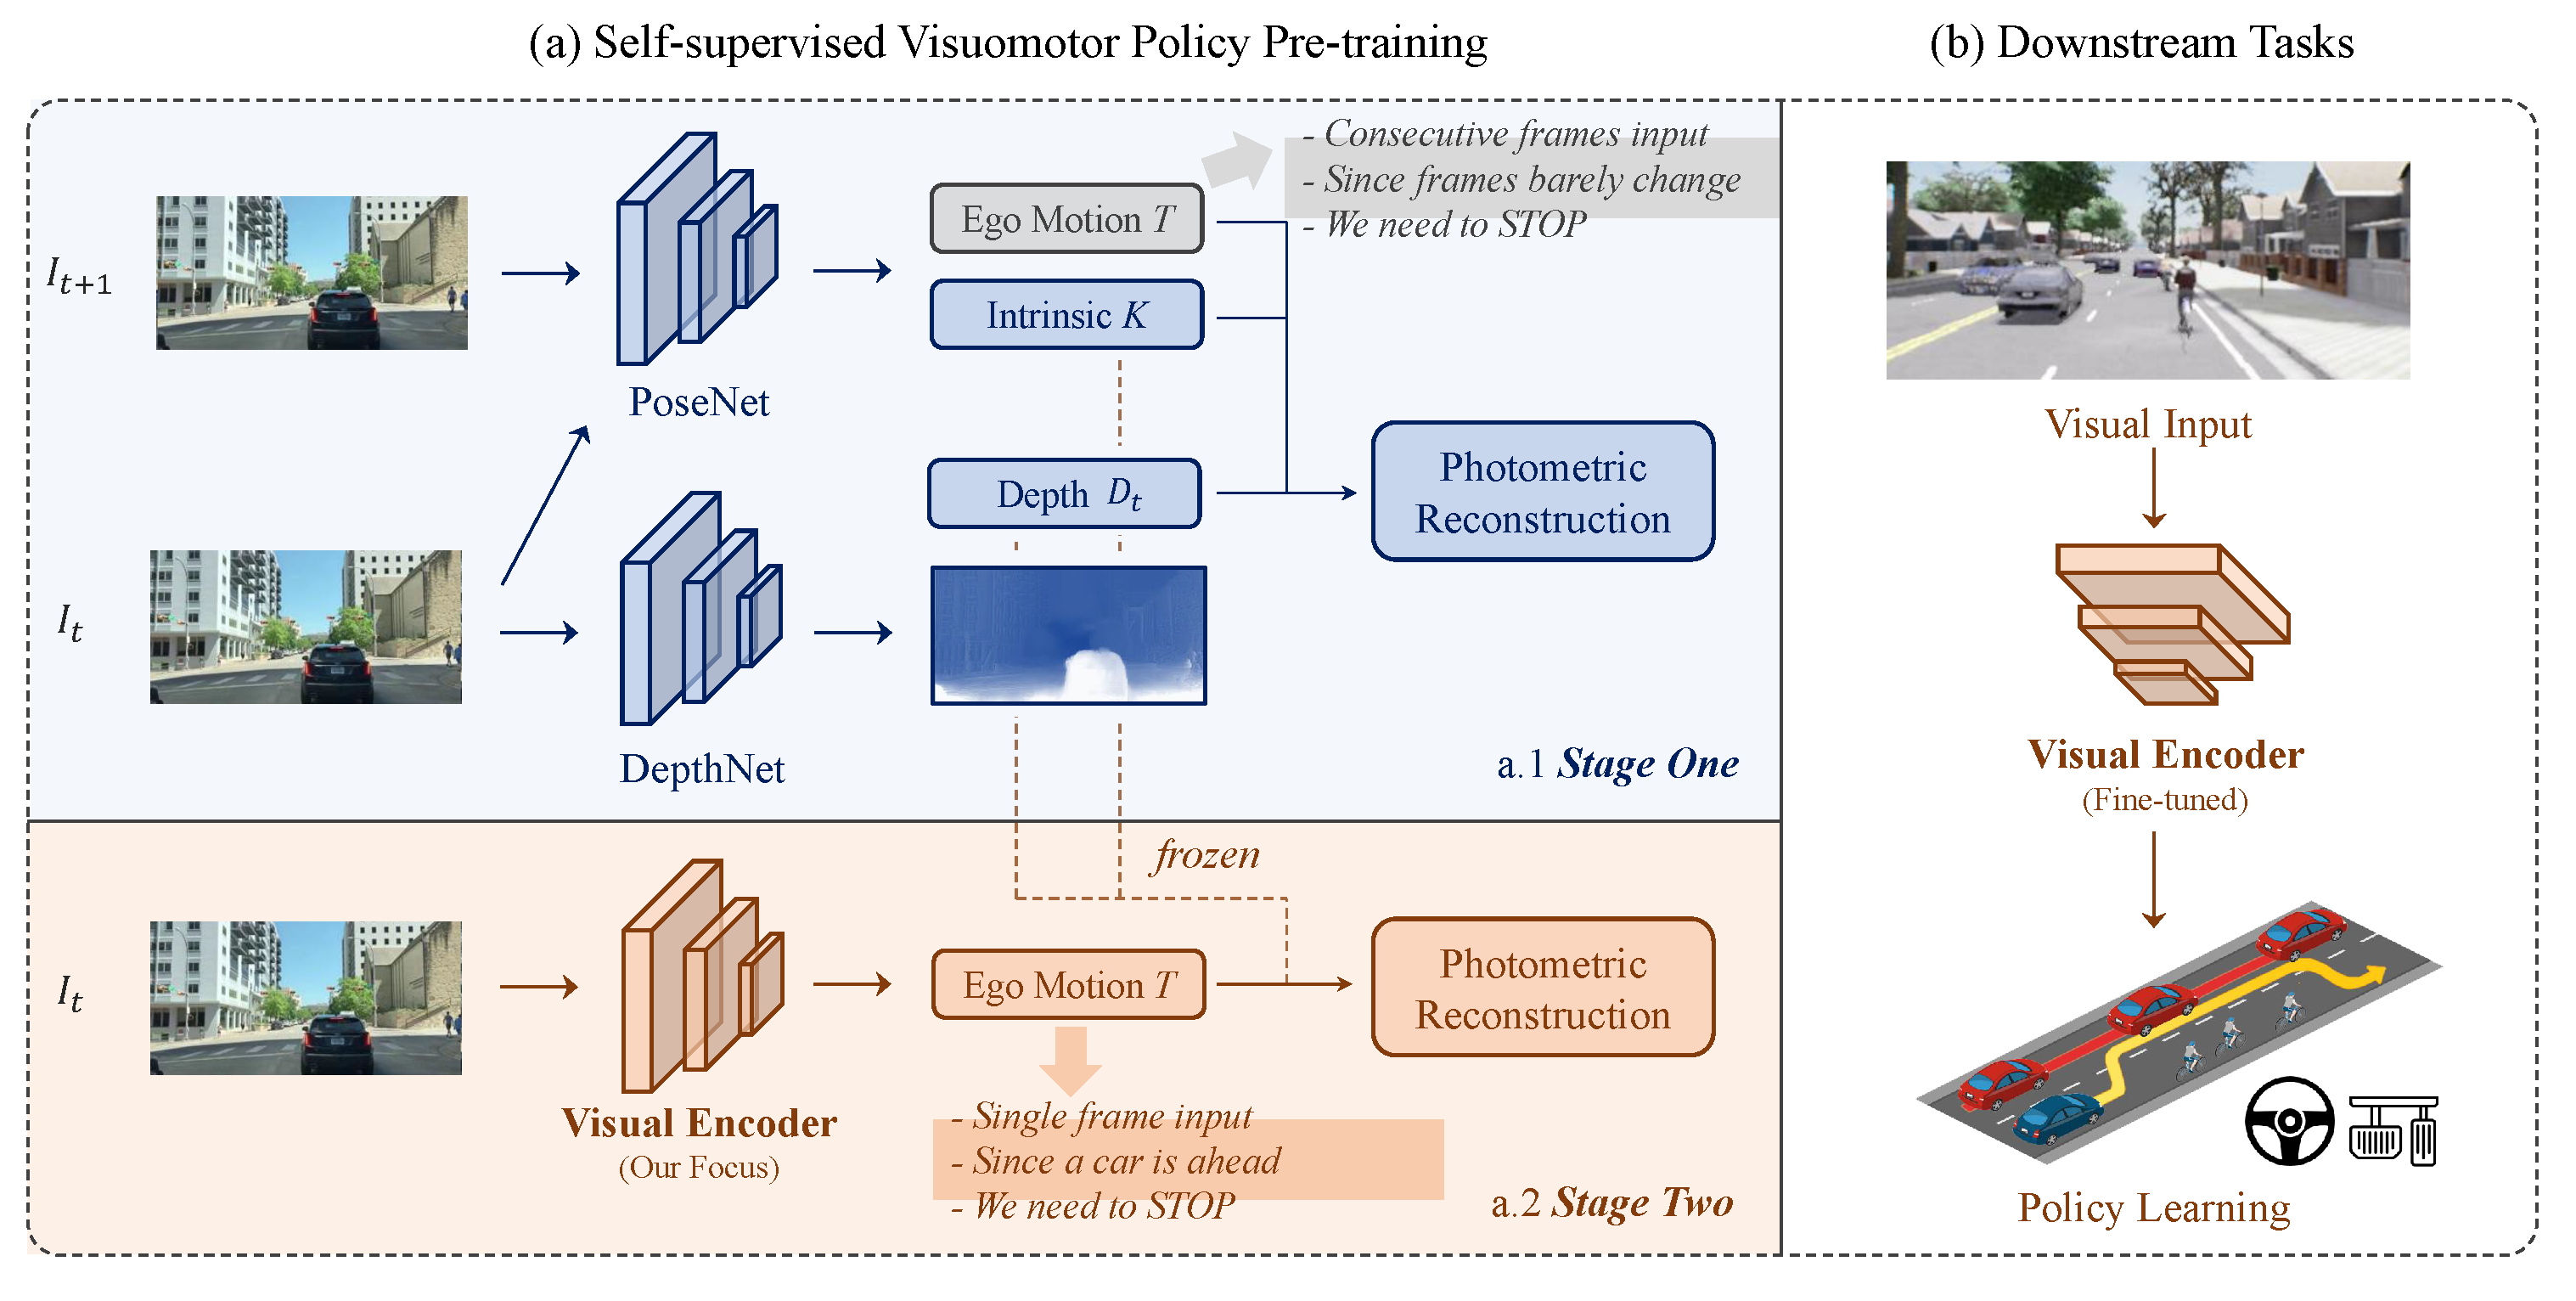
[ICLR 2023] Pytorch implementation of PPGeo, a fully self-supervised driving policy pre-training framework to learn from unlabeled driving videos.
Repo OpenDriveLab/PPGeo, read from GitHub 1 min ago. OpenDriveLab has not joined Take My Repo.
OpenDriveLab/PPGeo is a public repo on GitHub by OpenDriveLab. [ICLR 2023] Pytorch implementation of PPGeo, a fully self-supervised driving policy pre-training framework to learn from unlabeled driving videos. It declares the Apache-2.0 license on GitHub. It is written mainly in Python, has 137 stars and last changed on 2025-07-02. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-22.
Important
🌟 Stay up to date at opendrivelab.com!

Policy Pre-training for Autonomous Driving via Self-supervised Geometric Modeling
- Penghao Wu, Li Chen, Hongyang Li, Xiaosong Jia, Junchi Yan, Yu Qiao
- arXiv Paper | openreview, ICLR 2023
- video | blog
This repository contains the pytorch implementation for PPGeo in the paper Policy Pre-training for Autonomous Driving via Self-supervised Geometric Modeling. PPGeo is a fully self-supervised driving policy pre-training framework to learn from unlabeled driving videos.
| Model | Google Drive Link | BaiduYun Link |
|---|---|---|
| Visual Encoder (ResNet-34) | ckpt | ckpt (code: itqi) |
| DepthNet | ckpt | ckpt (code: xvof) |
| PoseNet | ckpt | ckpt (code: fp2n) |
git clone https://github.com/OpenDriveLab/PPGeo.git
cd PPGeo
conda env create -f environment.yml --name PPGeo
conda activate PPGeo
Download the driving video dataset based on the instructions in ACO.
Make a symlink to the dataset root.
ln -s DATA_ROOT data
python ytb_data_preprocess.py
python train.py --id ppgeo_stage1_log --stage 1 --epochs 30
python train.py --id ppgeo_stage2_log --stage 2 --epochs 20 --ckpt PATH_TO_STAGE1_CKPT
cd nuscenes_planning
cd data
ln -s nuScenes_data_root nuscenes
cd ..
python train_planning.py --pretrained_ckpt PATH_TO_STAGE2_CKPT
We use the DI-drive engine for IL data collection, IL training, IL evaluation, and PPO training following ACO with carla version 0.9.9.4. Some additional details can be found here.
We use the TCP codebase for training and evaluation with default setting.
If you find our repo or our paper useful, please use the following citation:
  @inproceedings{wu2023PPGeo,
    title={Policy Pre-training for Autonomous Driving via Self-supervised Geometric Modeling},
    author={Penghao Wu and Li Chen and Hongyang Li and Xiaosong Jia and Junchi Yan and Yu Qiao},
    booktitle={International Conference on Learning Representations},
    year={2023}
  }
All code within this repository is under Apache License 2.0.
Our code is based on monodepth2.
OpenDriveLab/PPGeo is a public repo on GitHub by OpenDriveLab. [ICLR 2023] Pytorch implementation of PPGeo, a fully self-supervised driving policy pre-training framework to learn from unlabeled driving videos.
It declares the Apache-2.0 license on GitHub.
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Its last change on GitHub was on 2025-07-02. GitHub counts 6 open issues and pull requests. Take My Repo does not judge from that whether it is maintained.
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.
Transfer learning / domain adaptation / domain generalization / multi-task learning etc. Papers, codes, datasets, applications, tutorials.-迁移学习
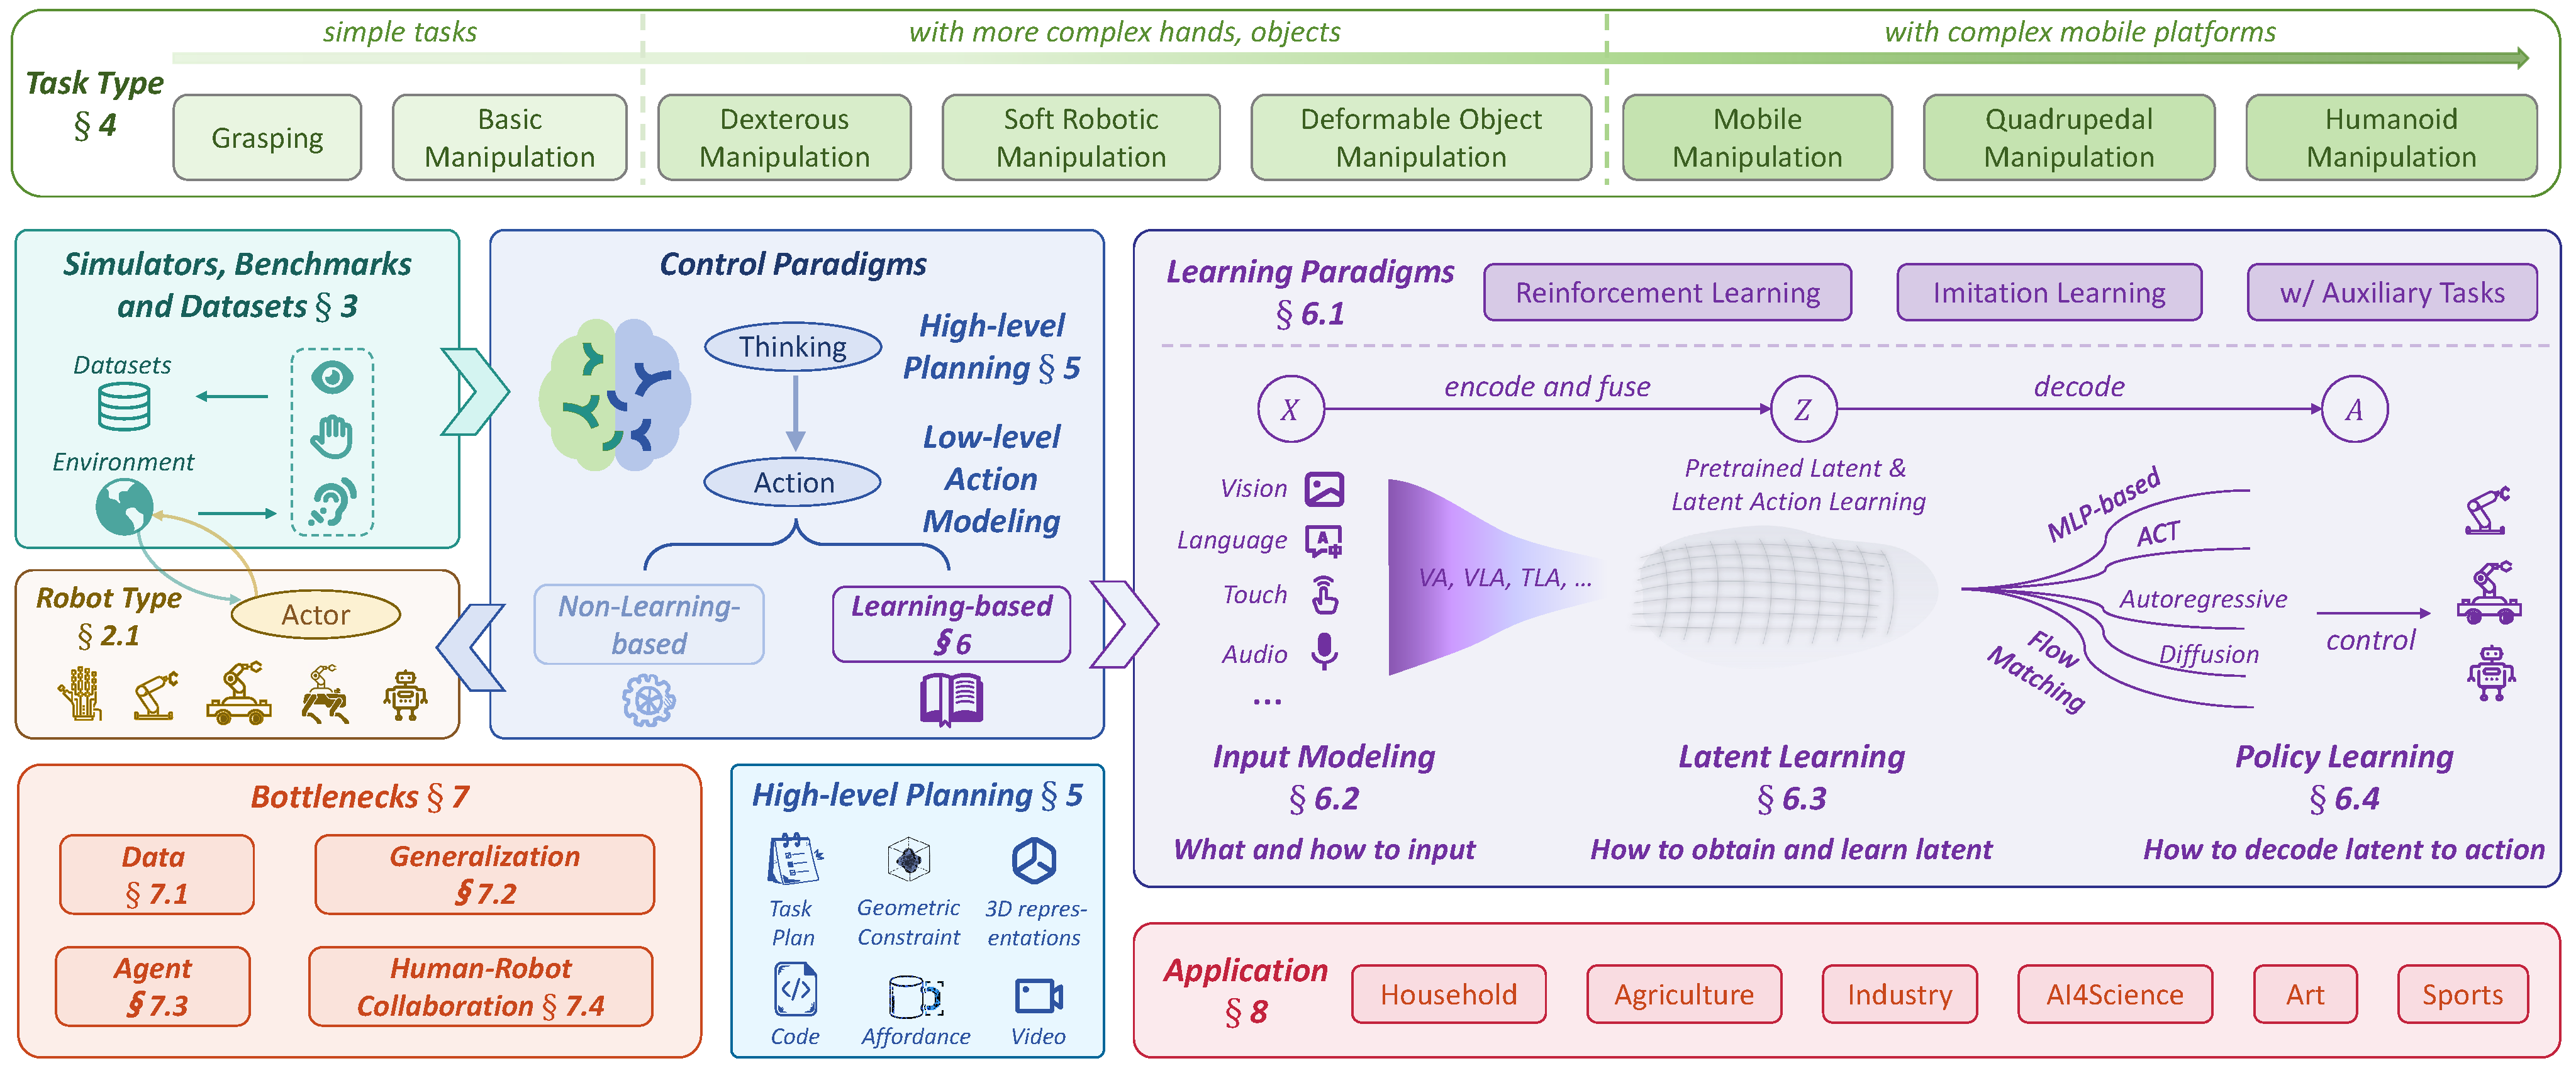
A comprehensive list of papers about Robot Manipulation, including papers, codes, and related websites.
Easy-to-use Speech Toolkit including Self-Supervised Learning model, SOTA/Streaming ASR with punctuation, Streaming TTS with text frontend, Speaker Verification System, End-to-End Speech Translation and Keyword Spotting. Won NAACL2022 Best Demo Award.
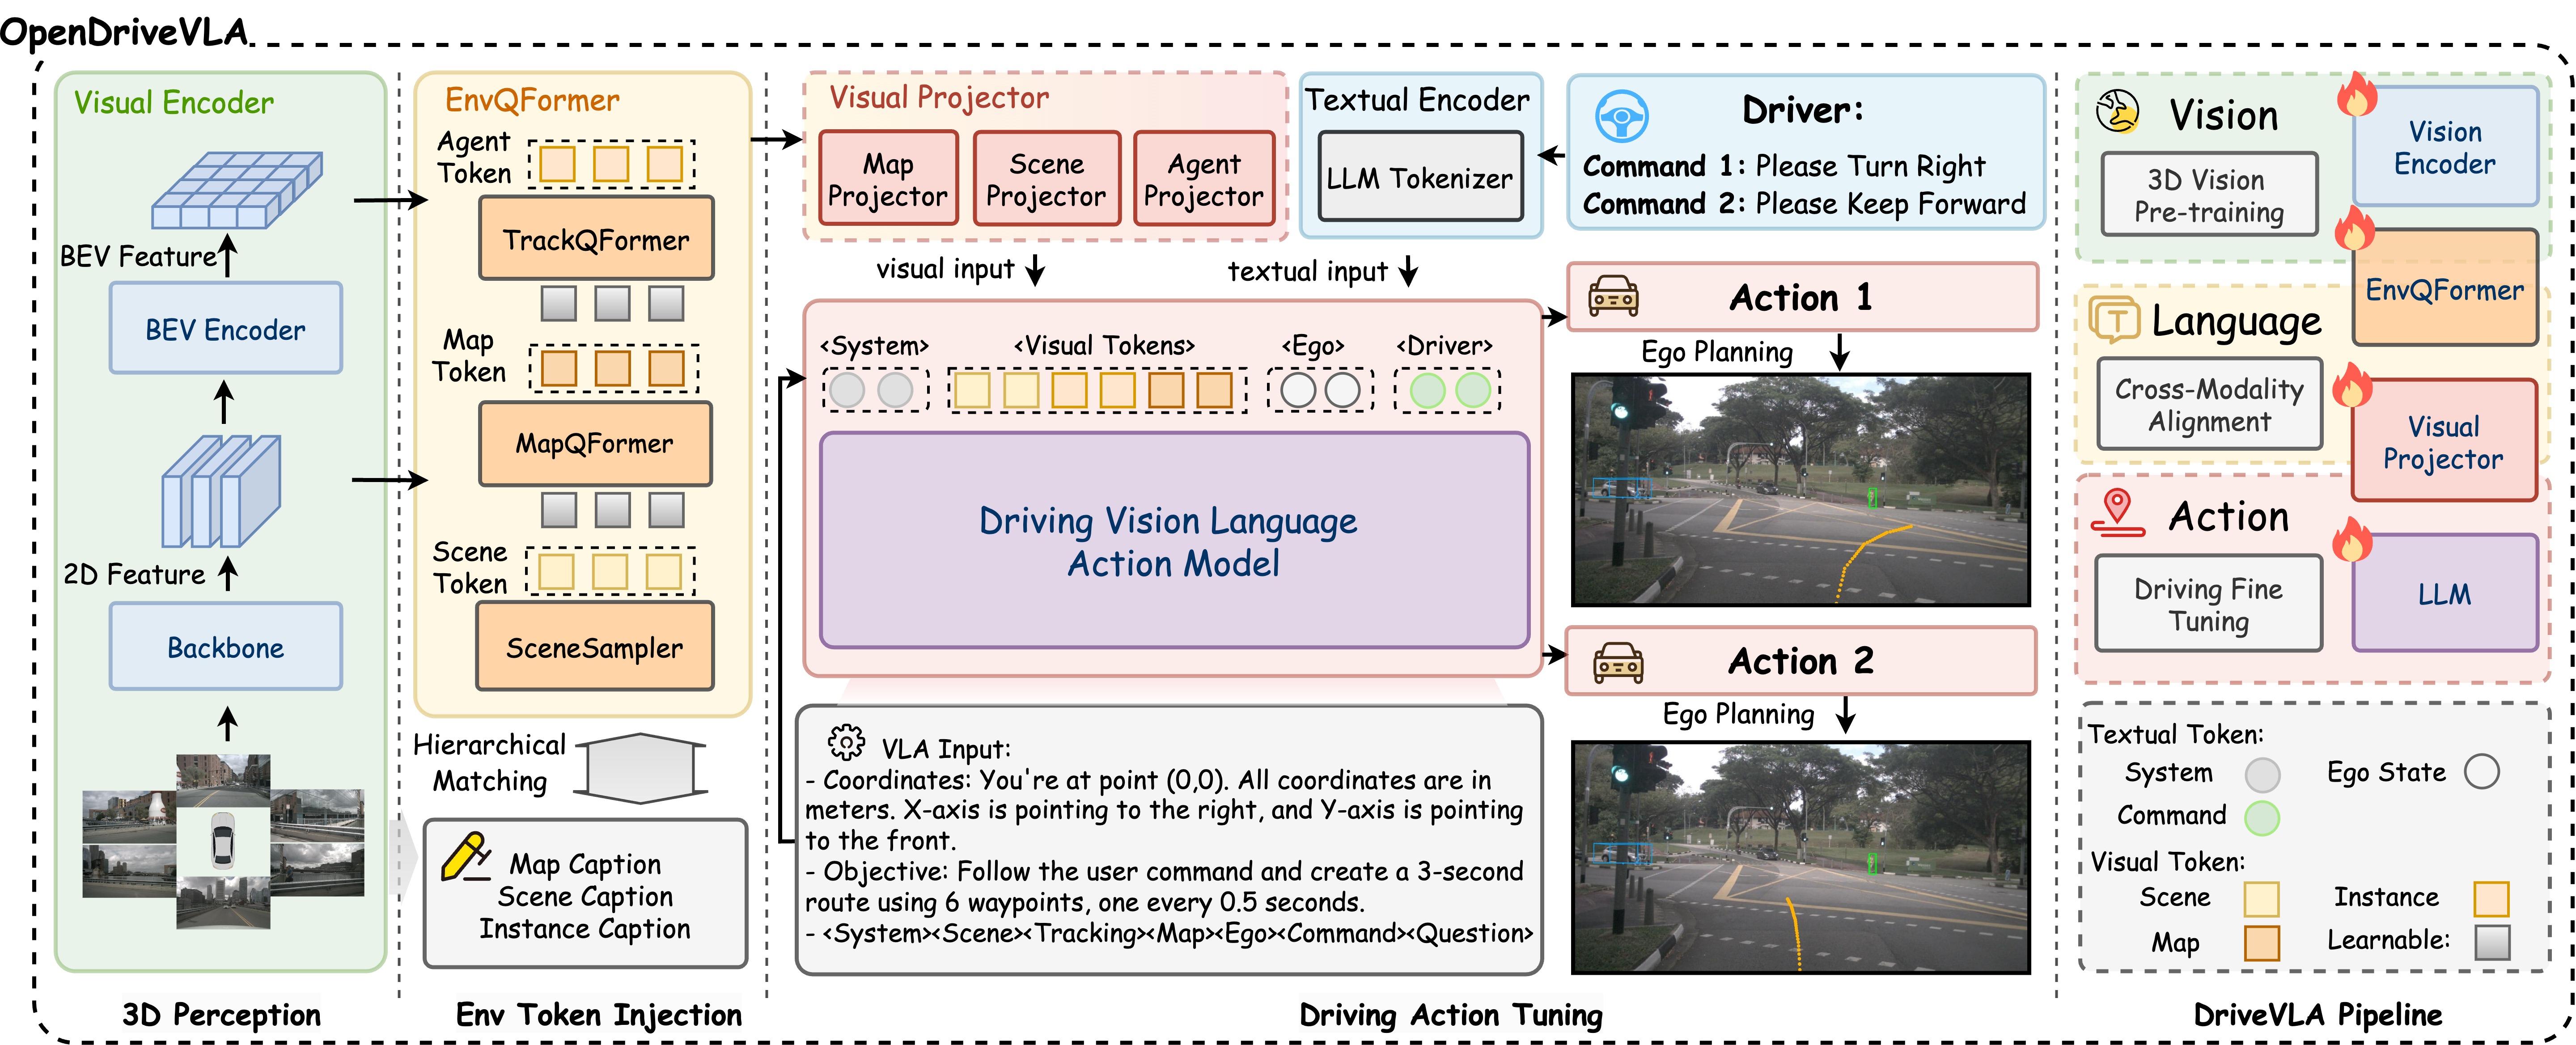
[AAAI 2026] OpenDriveVLA: Towards End-to-end Autonomous Driving with Large Vision Language Action Model
[IEEE T-PAMI 2024] All you need for End-to-end Autonomous Driving
[IROS 2025 Best Paper Award Finalist & IEEE TRO 2026] The Large-scale Manipulation Platform for Scalable and Intelligent Embodied Systems
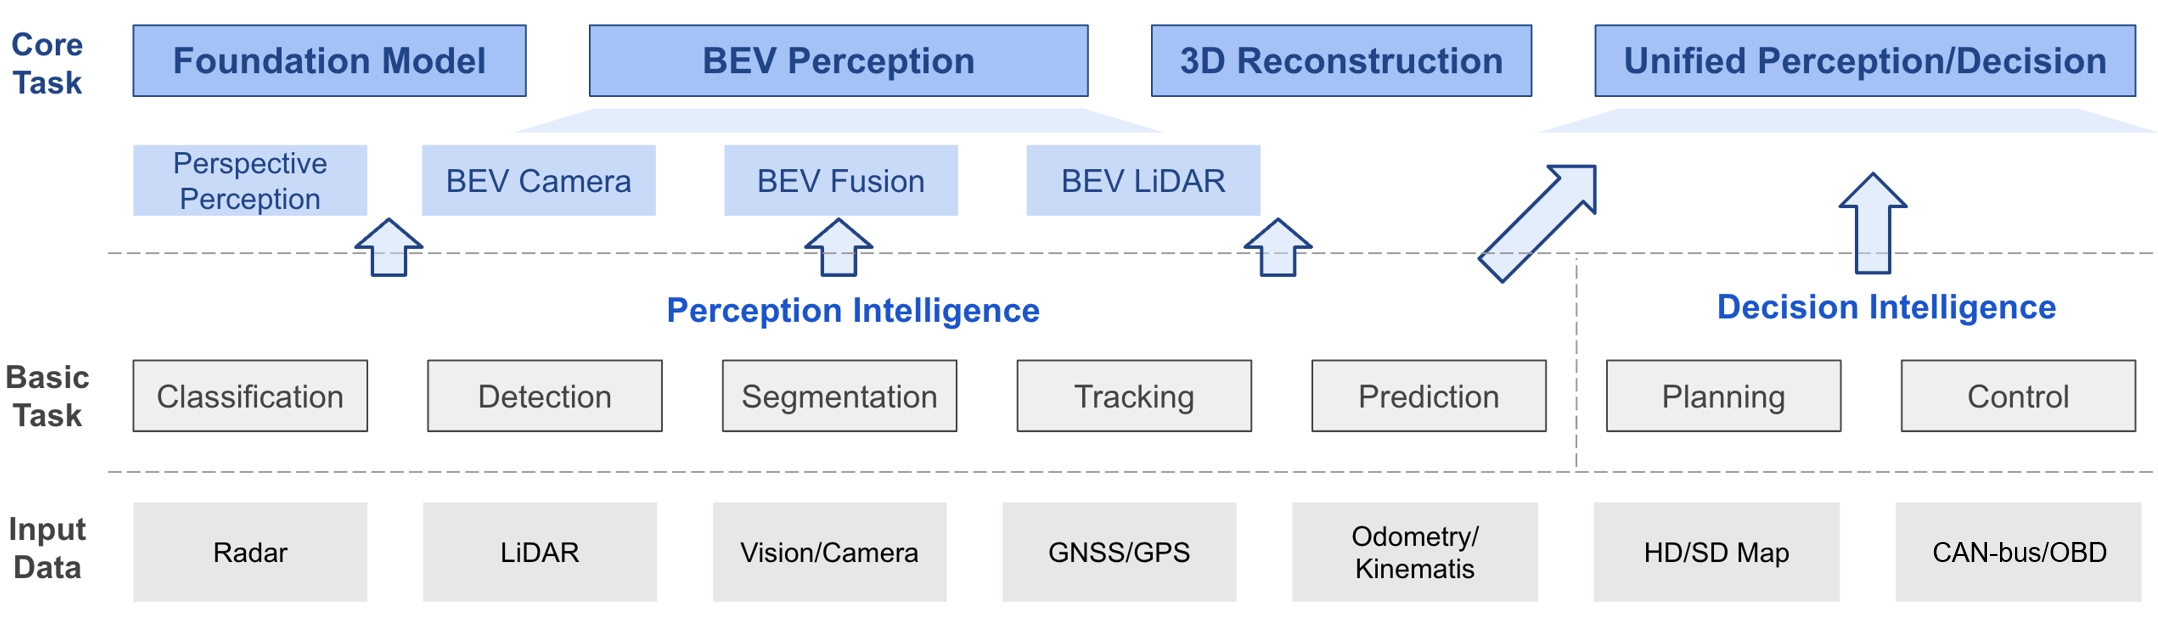
[IEEE T-PAMI 2023] Awesome BEV perception research and cookbook for all level audience in autonomous diriving
[ECCV 2024 Oral] DriveLM: Driving with Graph Visual Question Answering
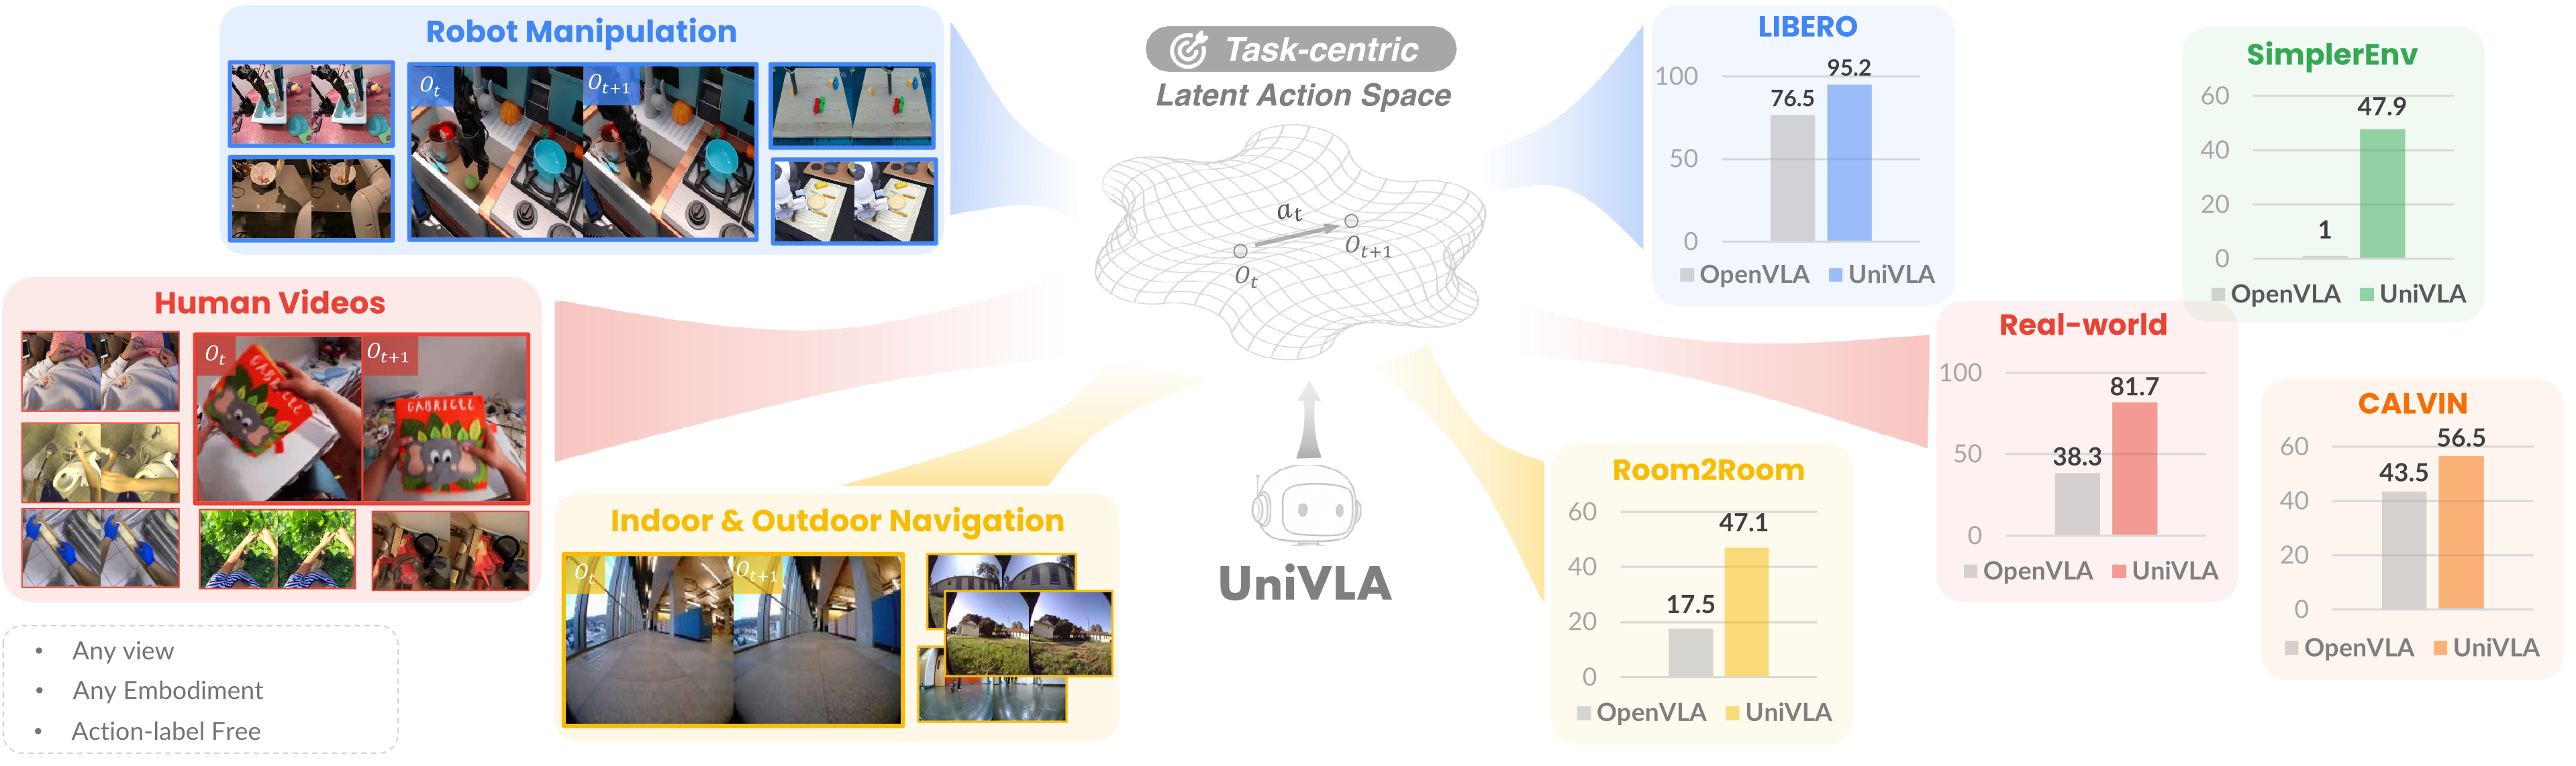
[RSS 2025] Learning to Act Anywhere with Task-centric Latent Actions