
Future-L1
[EMNLP 2026 Main] Imagine Before You Predict: Interleaved Latent Visual Reasoning for Video Event Prediction
- 39
- 2 mo ago
Repo OpenGVLab/Future-L1, read from GitHub 1 d ago. OpenGVLab has not joined Take My Repo.
In short
OpenGVLab/Future-L1 is a public repo on GitHub by OpenGVLab. [EMNLP 2026 Main] Imagine Before You Predict: Interleaved Latent Visual Reasoning for Video Event Prediction. It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it. It is written mainly in Python, has 39 stars and last changed on 2026-09-18. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-21.
💭 Imagine Before You Predict:
Interleaved Latent Visual Reasoning for Video Event Prediction
🎉 Accepted to EMNLP 2026 Main Conference
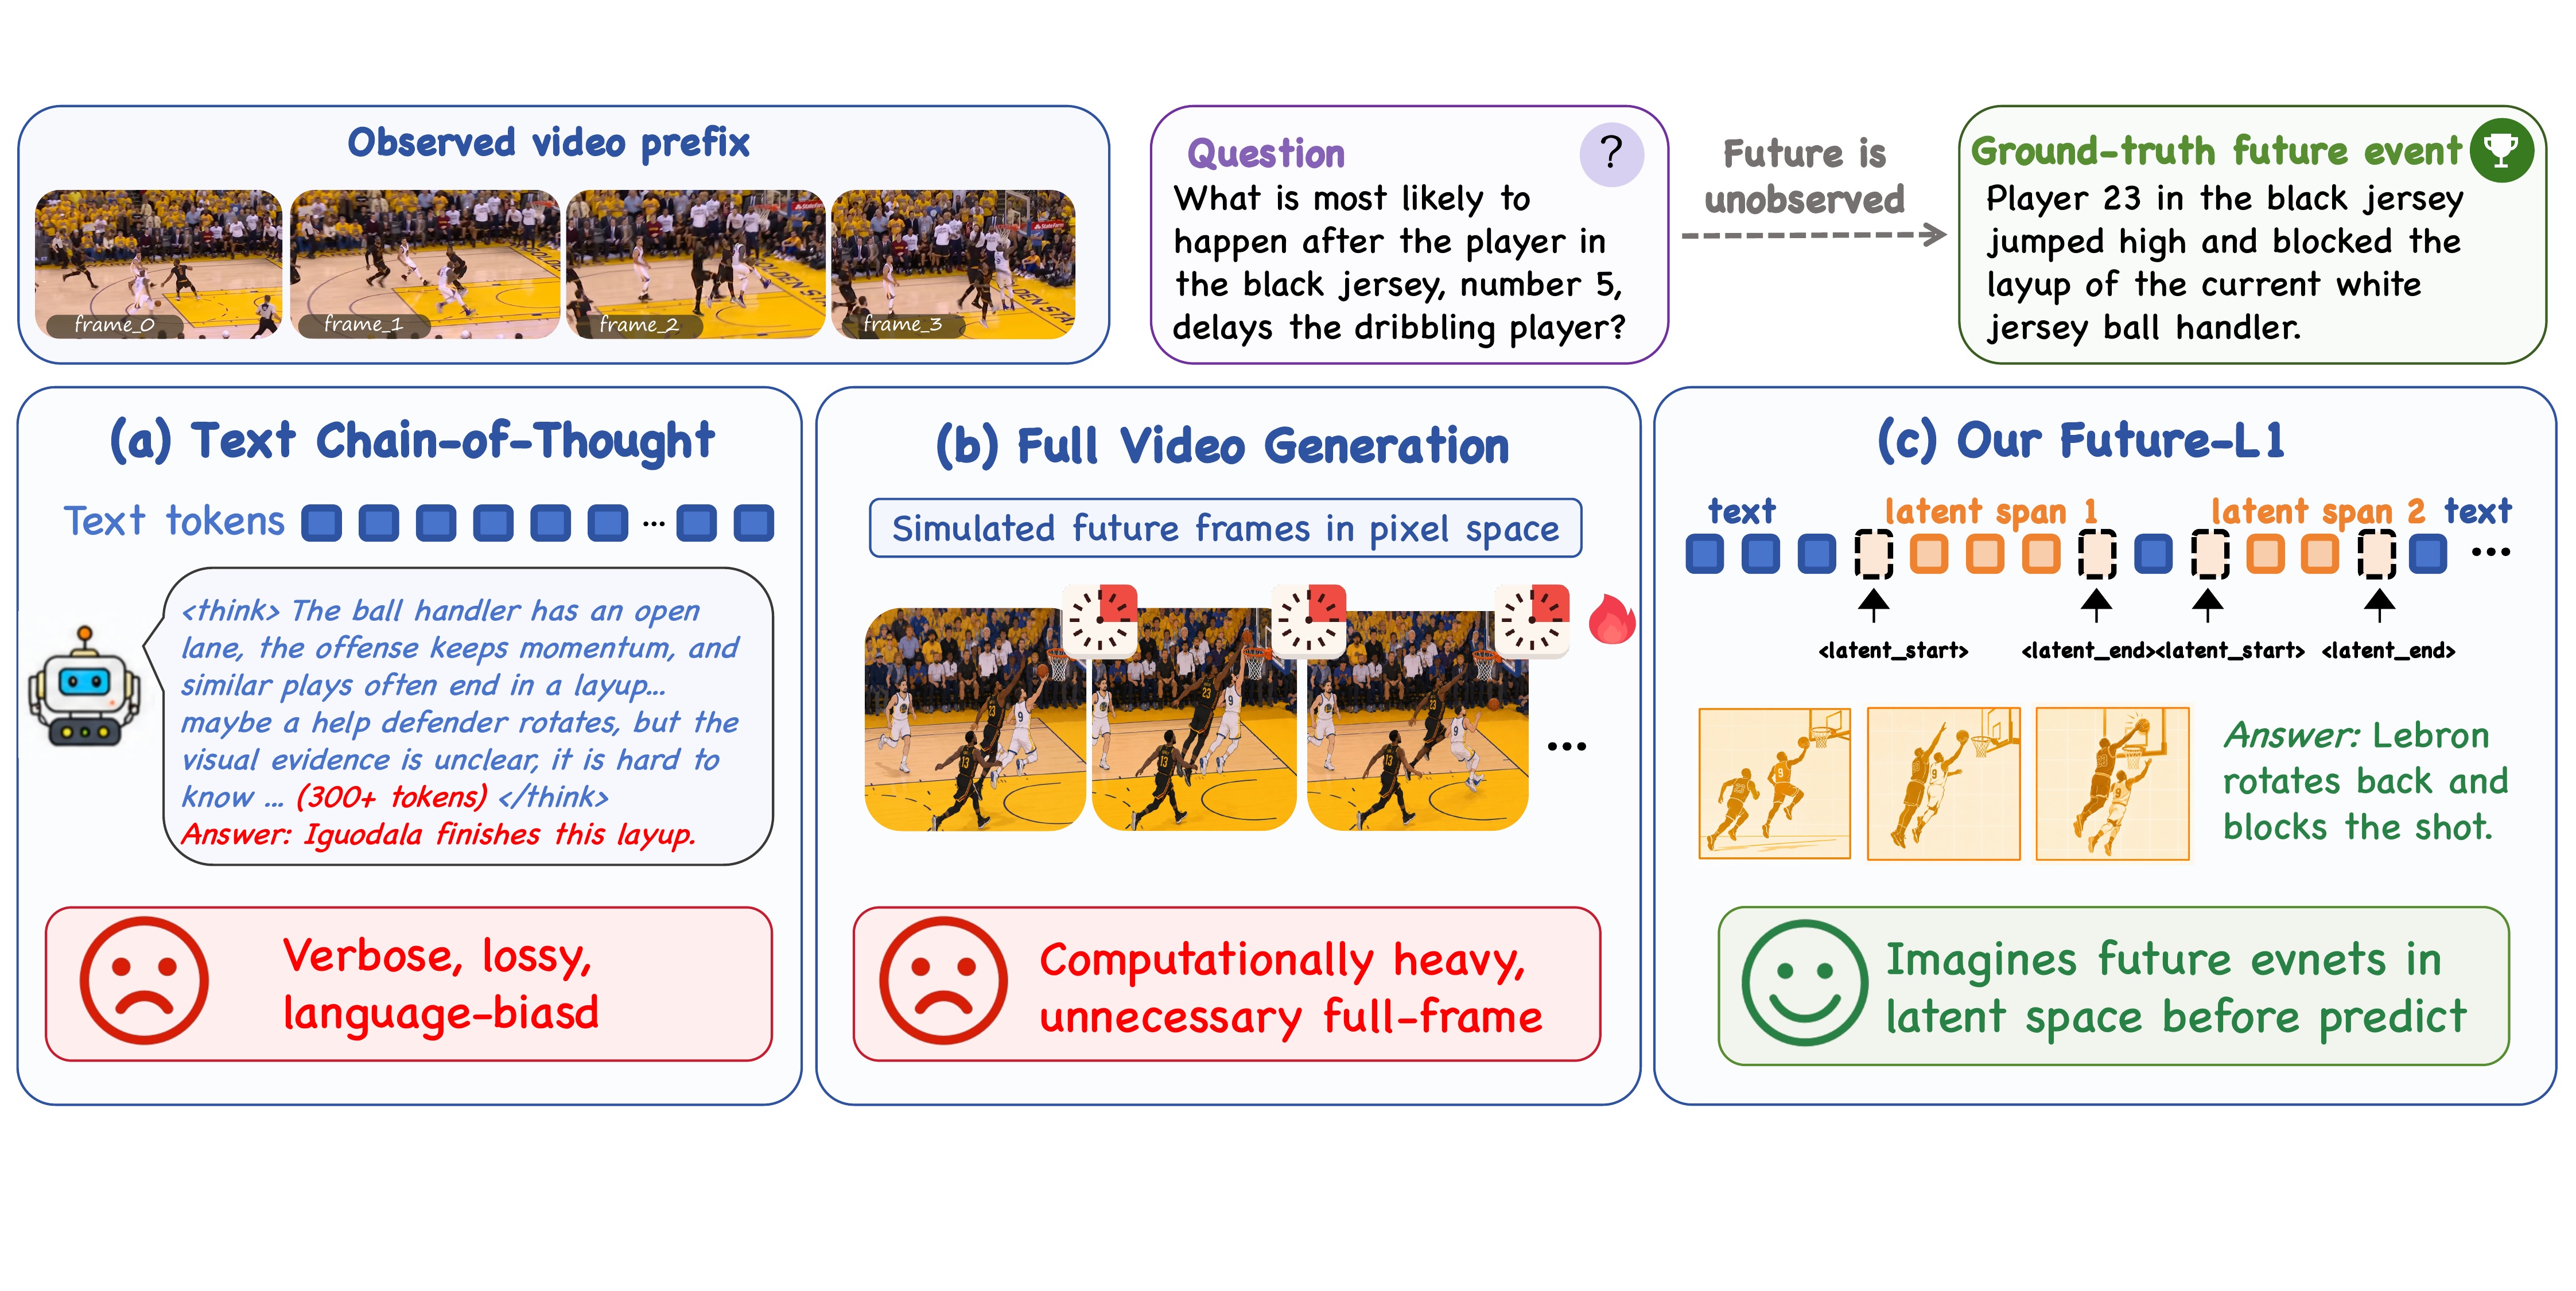
Future-L1 teaches multimodal LLMs to alternate between language tokens and continuous latent visual spans, enabling compact future-state imagination before answering video event prediction questions.
Figure 1. Text-CoT can be verbose and visually lossy, while pixel-space future simulation is computationally heavy. Future-L1 inserts compact latent visual spans that preserve dynamic future semantics without generating full frames.
✨ Highlights
- Interleaved latent visual reasoning. Future-L1 alternates between
<reason>text and bounded<|latent_start|>…<|latent_end|>spans during autoregressive decoding, keeping dynamic visual structure in a continuous channel instead of verbalizing every intermediate hypothesis. - 🤗 Future-L1-50K. We curate 50K high-utility examples from TwiFF-style trajectories by visual-gain selection: retain samples where intermediate future visual hints measurably improve prediction over a text-only baseline.
- LA-DAPO RL. A latent-aware extension of DAPO with outcome-contrastive (
R_ctr) and temporal-diversity (R_div) rewards that optimize sampled latent trajectories without intermediate-frame annotations at RL time. - State-of-the-art VEP performance. Future-L1-RL reaches 85.4% on FutureBench and 3.04 average score on TwiFF-Bench, with especially strong gains on multi-hop and non-consecutive future-event splits.
- Compact inference. Accuracy improves through latent visual computation rather than long text-only chains or multi-turn search.
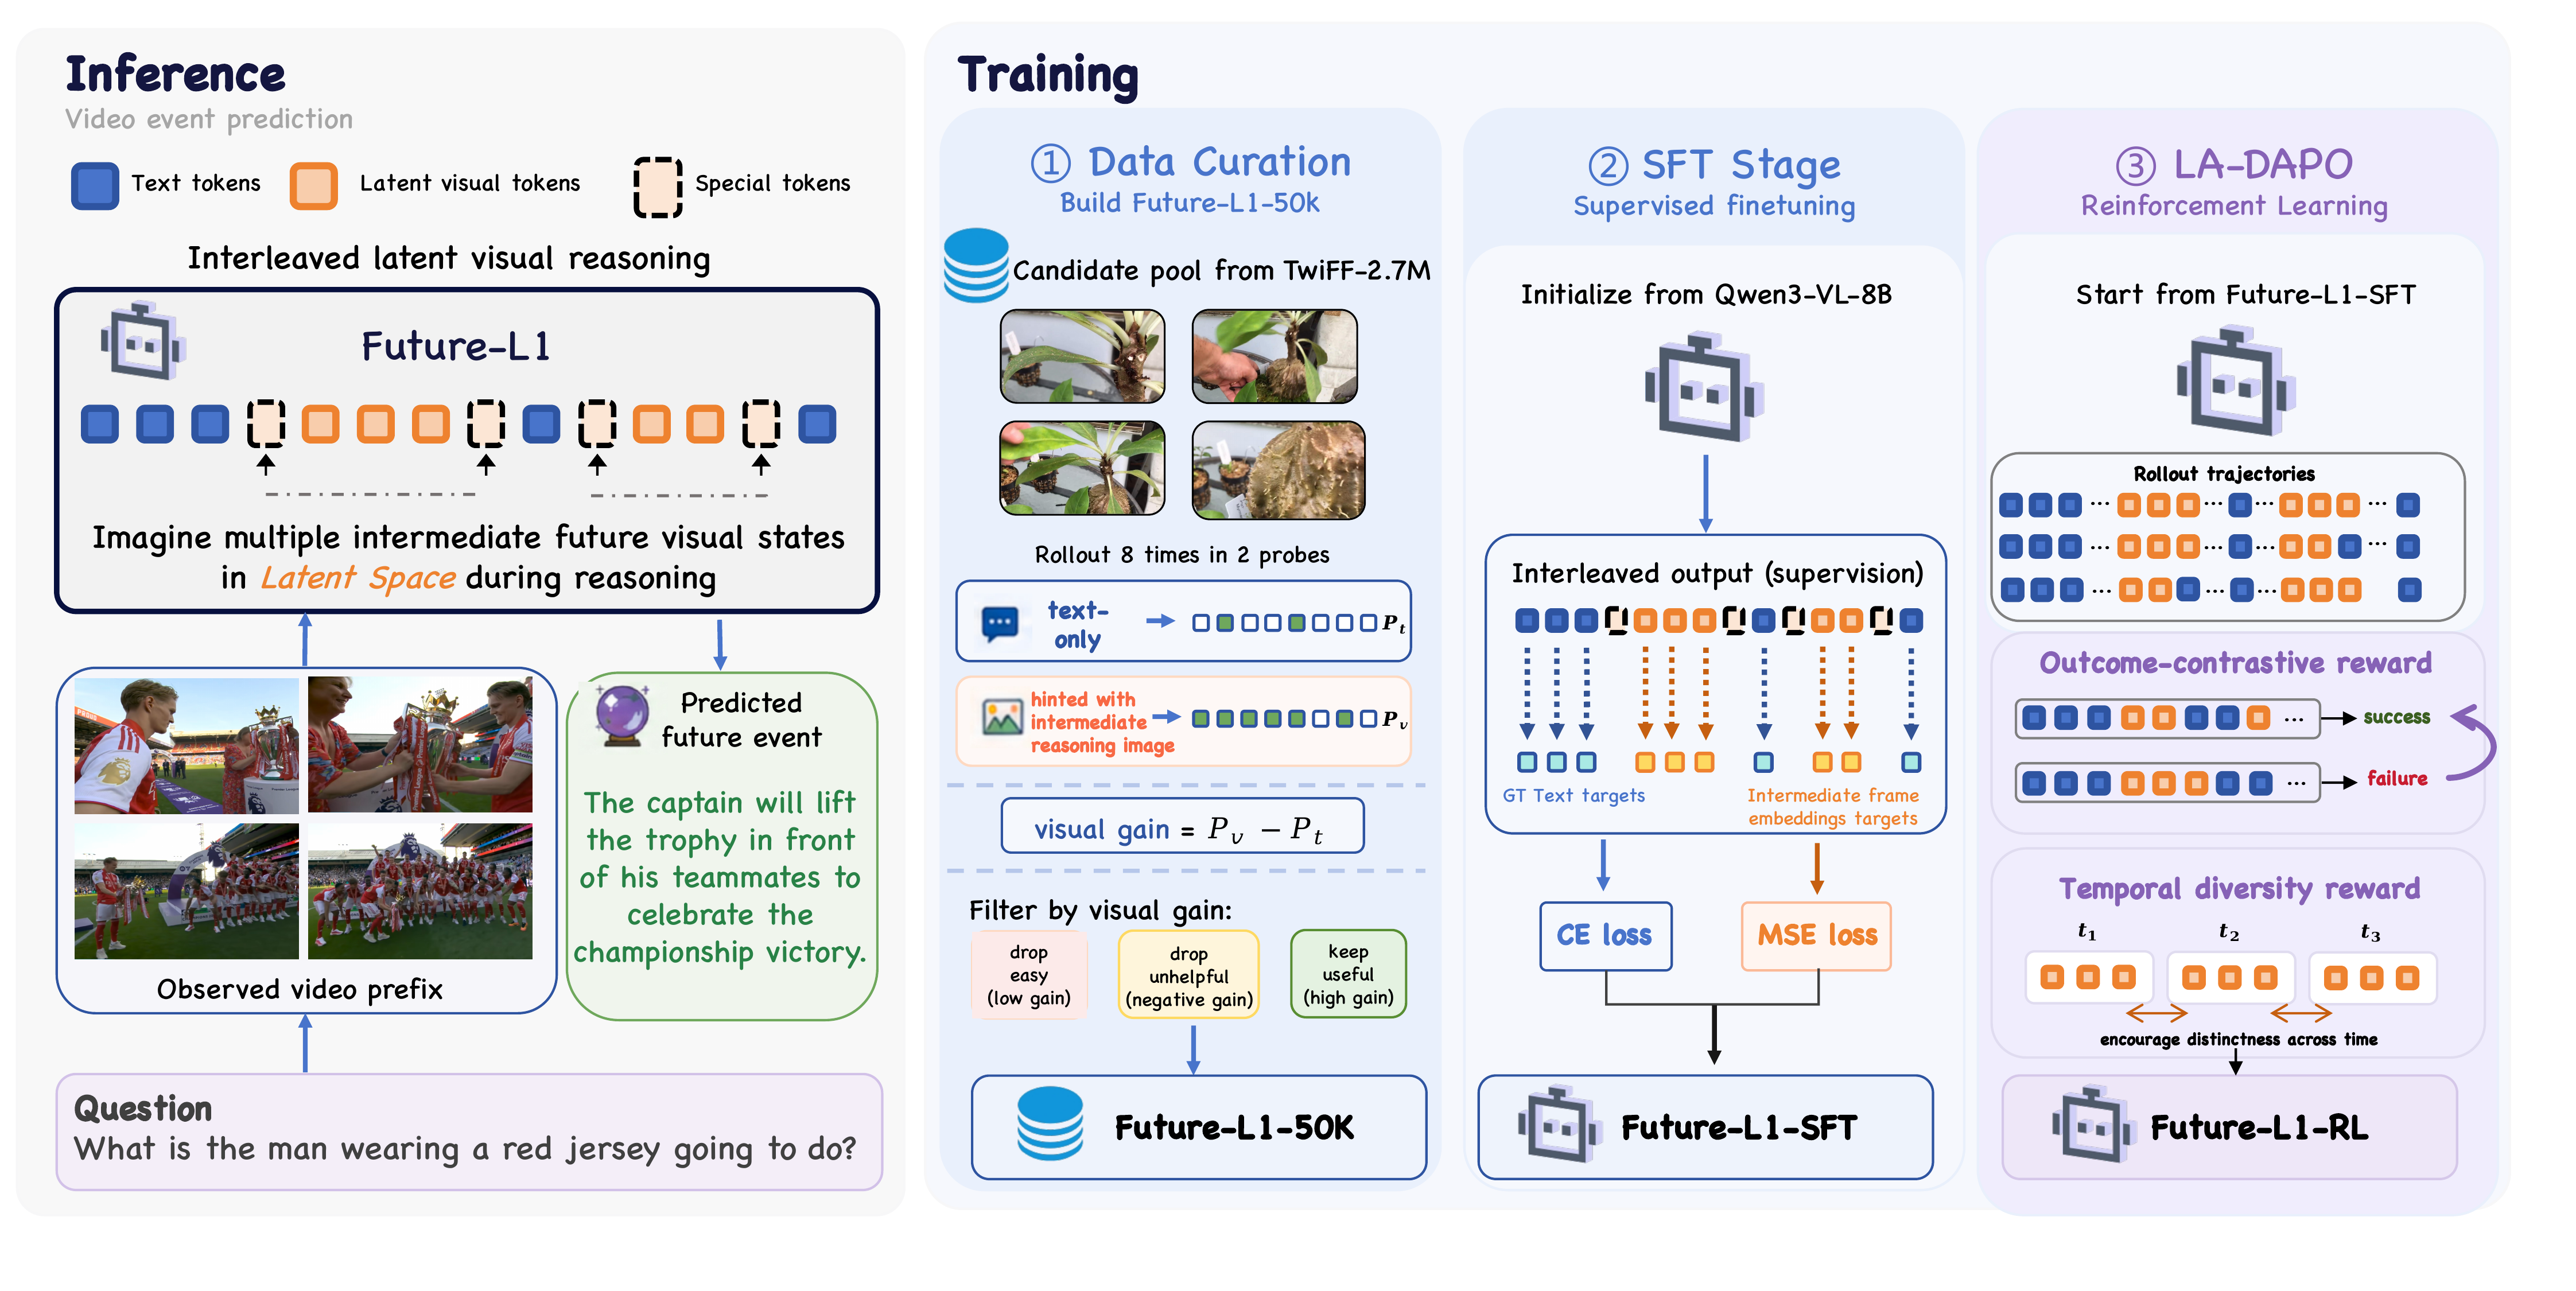
Figure 2. (Left) Future-L1-50K is built by ranking TwiFF candidates by visual gain pv − pt. (Center) SFT trains interleaved text–latent trajectories, aligning latent spans with future visual states. (Right) LA-DAPO further optimizes sampled trajectories with outcome-contrastive and temporal-diversity rewards.
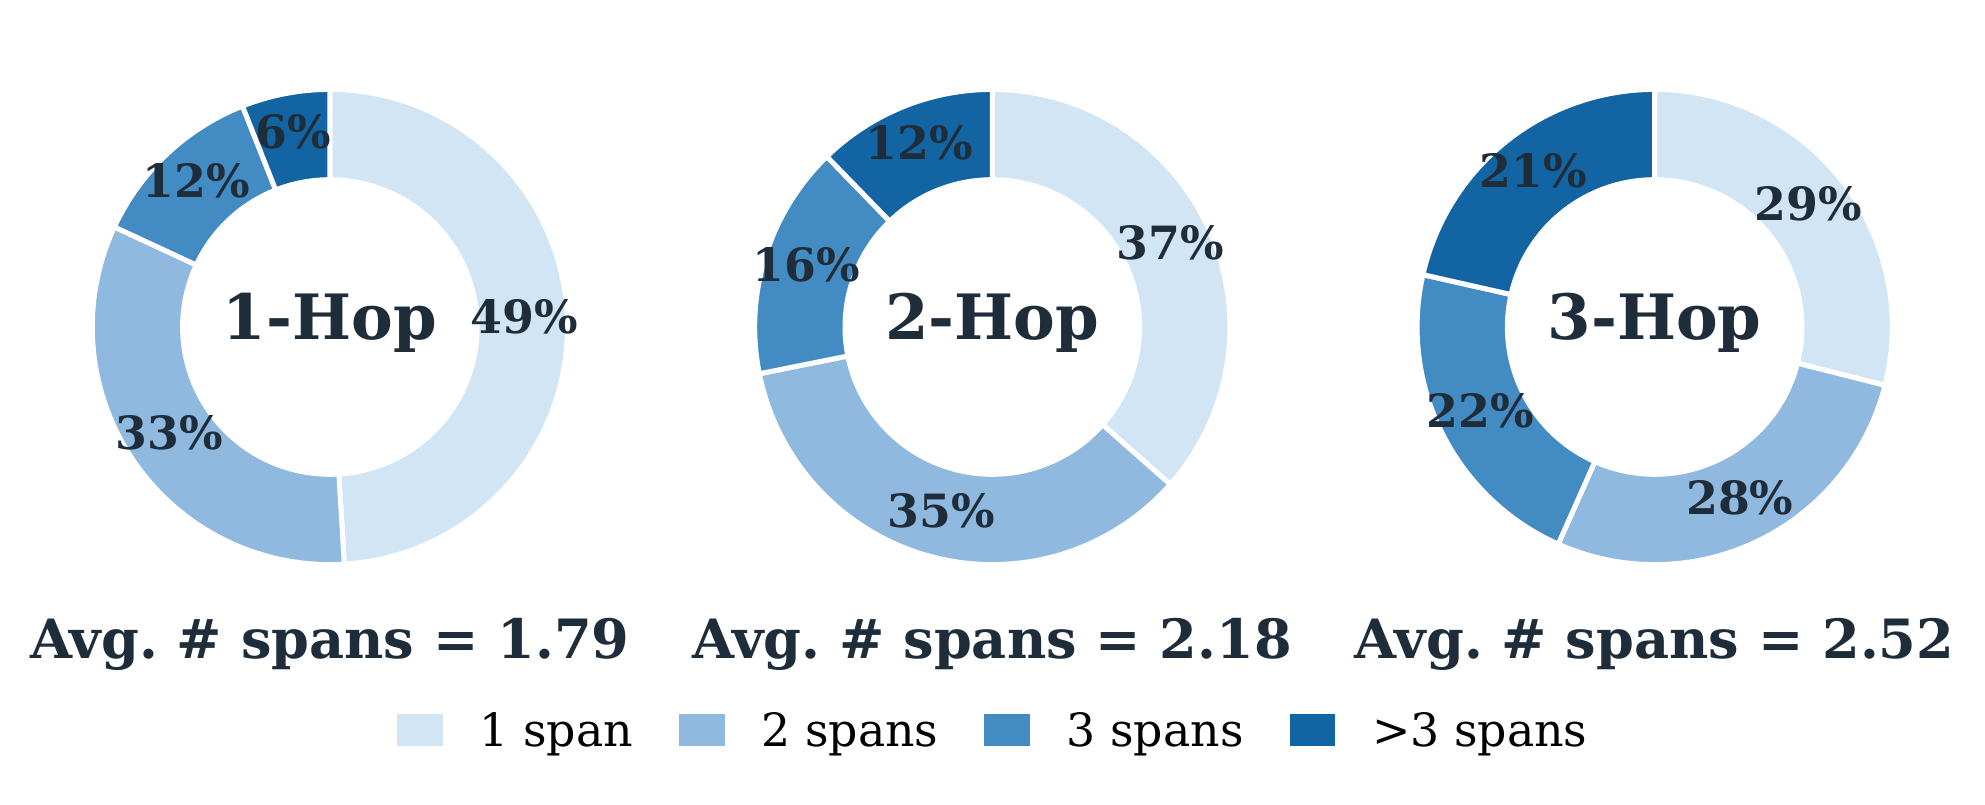
Figure 4. Latent-span usage by reasoning depth. Donuts show span-count distributions. |
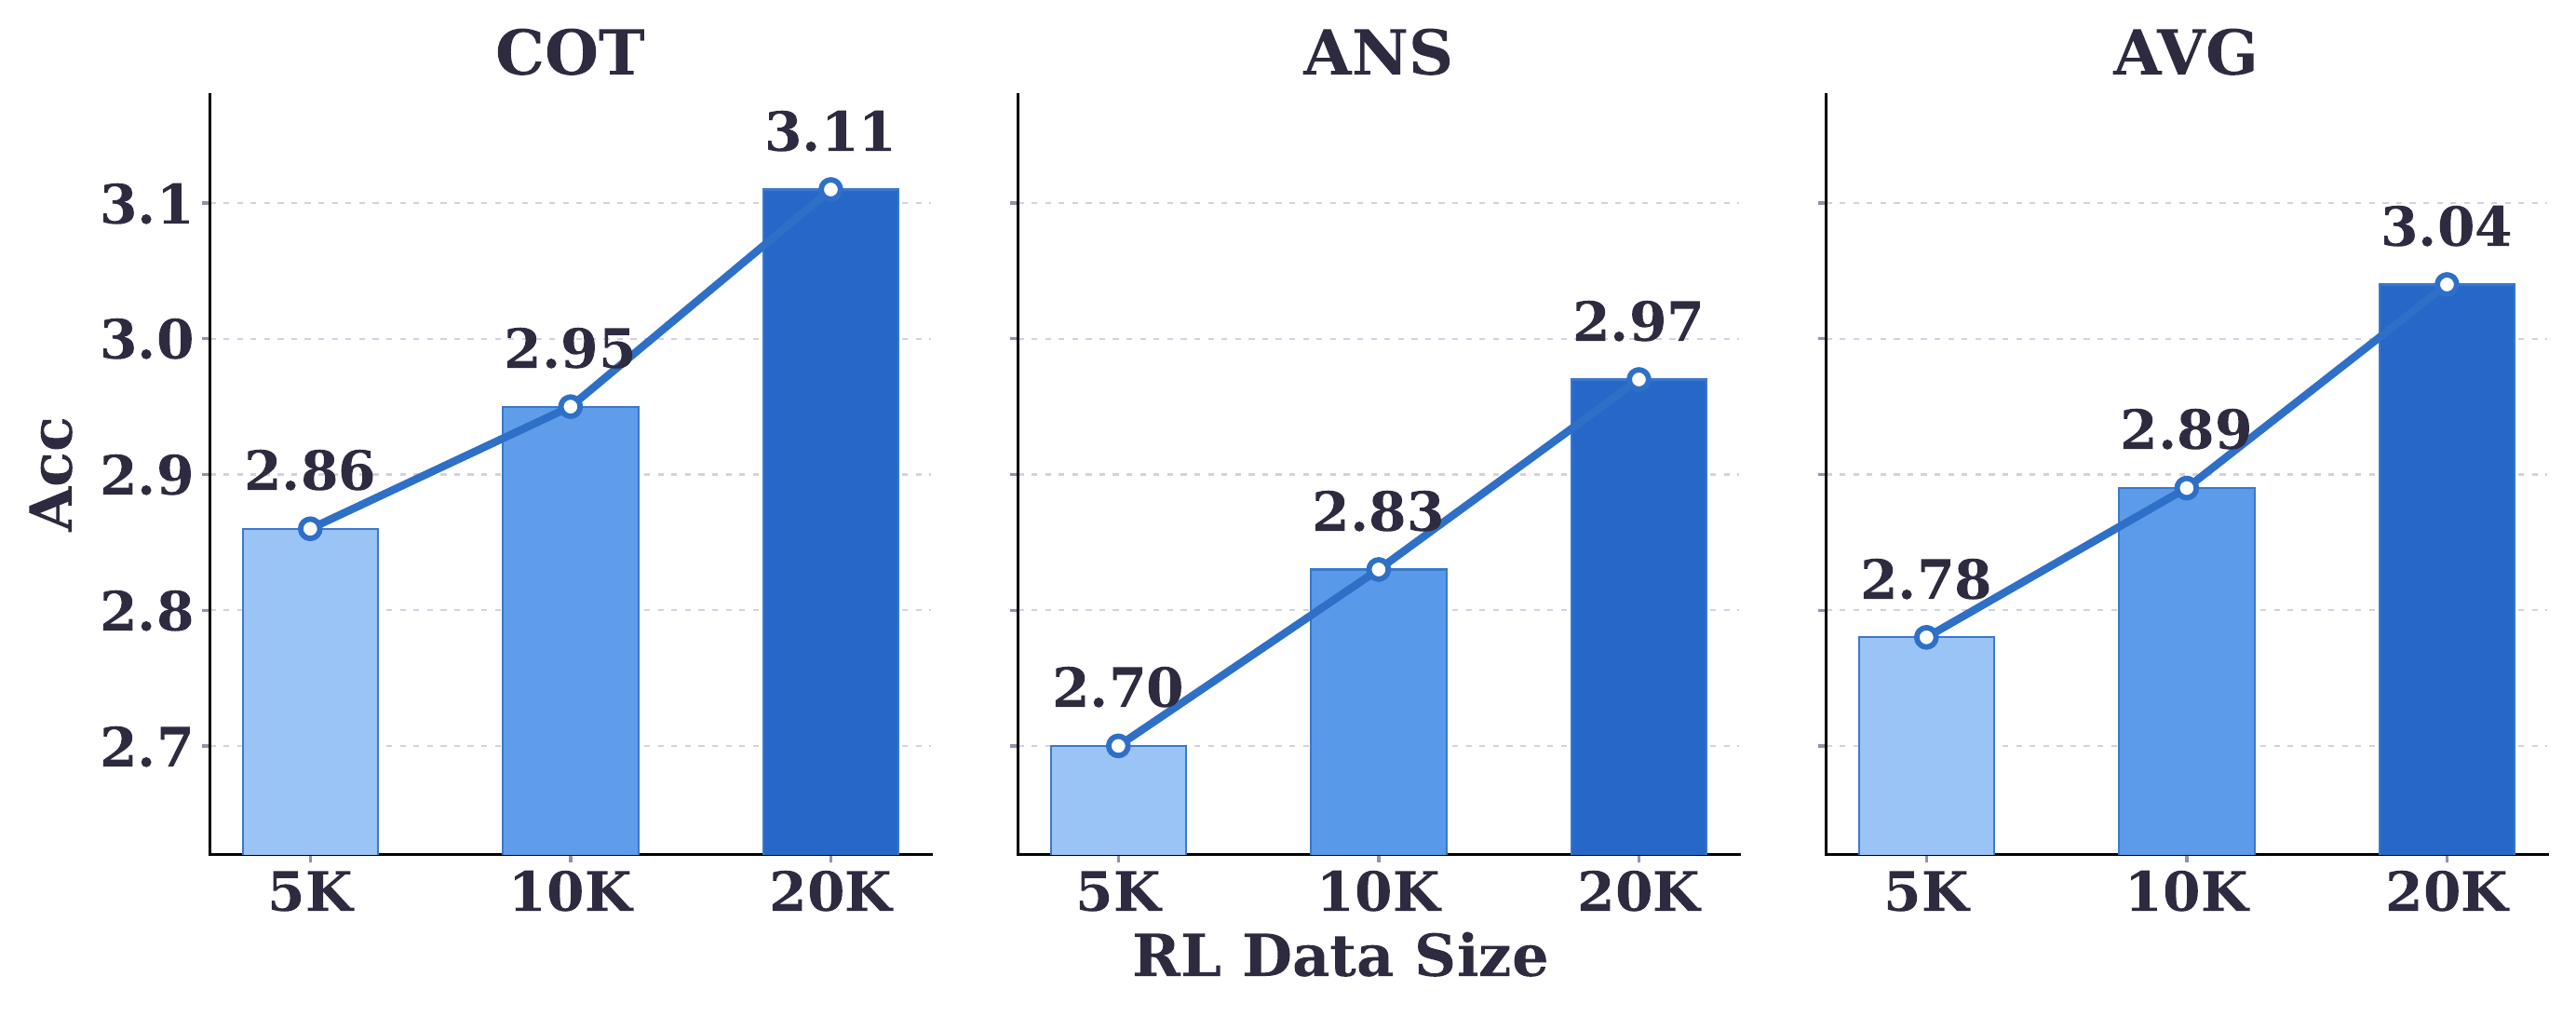
Figure 5. RL data scaling on TwiFF-Bench. Scores improve as LA-DAPO uses 5K, 10K, and 20K retained visual-gain samples. |
🚀 Getting Started
# Install
pip install -r requirements_sft.txt
pip install -r requirements_rl.txt
cd RL_v2 && pip install -e . && cd ..
cd lmms-eval && pip install -e . && cd ..

# Replace chat_template.json before training (once on the base Qwen3-VL checkpoint)
cp chat_template.json /path/to/Qwen3-VL-8B-Instruct/chat_template.json

# SFT — edit MODEL_NAME / DATA_PATH / OUTPUT_DIR in scripts/train_twiff.sh
bash scripts/train_twiff.sh

# RL — set checkpoint, data, and LLM-as-judge API (OpenAI-compatible, e.g. Qwen3.6-27B)
cd RL_v2
MODEL_PATH=/path/to/Future-L1-SFT \
TRAIN_FILES=/path/to/RL.json \
JUDGE_API_URL=http://localhost:8000/v1 \
JUDGE_API_NAME=your-judge-model \
JUDGE_API_KEY=your-api-key \
bash train.sh method

# Evaluation — edit model_path in the eval scripts; TwiFF-Bench also needs lmms-eval/.env
cd lmms-eval
cp .env.example .env   # fill OPENAI_API_KEY, OPENAI_API_BASE, LOCAL_LLM
bash examples/eval_futurebench_future_l1.sh
bash examples/eval_twiffbench_future_l1.sh
📖 Citation
@article{jiang2026imagine,
  title={Imagine Before You Predict: Interleaved Latent Visual Reasoning for Video Event Prediction},
  author={Jiang, Tianxiang and Wu, Linquan and Xia, Sheng and Li, Songze and Yan, Ziang and Yang, Haoyu and Qiao, Yu and Wang, Yi},
  journal={arXiv preprint arXiv:2606.05769},
  year={2026}
}
🙏 Acknowledgements
We gratefully acknowledge the contributions of the open-source community, particularly:
- Qwen-VL-Series-Finetune, Latent Visual Reasoning (LVR), SwimBird, EasyR1
- Previous Work: LaViT — Aligning latent visual thoughts for multi-modal reasoning via teacher-extracted visual thought trajectories.
Questions
What is Future-L1?
OpenGVLab/Future-L1 is a public repo on GitHub by OpenGVLab. [EMNLP 2026 Main] Imagine Before You Predict: Interleaved Latent Visual Reasoning for Video Event Prediction.
Is Future-L1 open source?
It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it.
Does Future-L1 run on macOS, Windows or Linux?
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
How do I install Future-L1?
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
Is Future-L1 still maintained?
Its last change on GitHub was on 2026-09-18. GitHub counts 0 open issues and pull requests. Take My Repo does not judge from that whether it is maintained.
What do people who ran Future-L1 say?
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.