EvolutionAquerium
:fish: :bug: Small Inteli Creatures Based On Steering Behaviours
- 197
- JavaScript
- MIT
- 5 y ago
An implementation of multi-UAV formation control with obstacle avoidance capability. Based on the paper [Flocking for Multi-Agent Dynamic Systems: Algorithms and Theory], this project provides formation control, target tracking and visualization tools for UAV swarm simulation.
Repo Ronchy2000/Flocking-Formation-Control, read from GitHub 4 h ago. Ronchy2000 has not joined Take My Repo.
Ronchy2000/Flocking-Formation-Control is a public repo on GitHub by Ronchy2000. An implementation of multi-UAV formation control with obstacle avoidance capability. Based on the paper [Flocking for Multi-Agent Dynamic Systems: Algorithms and Theory], this project provides formation control, target tracking and visualization tools for UAV swarm simulation. It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it. It is written mainly in Jupyter Notebook, has 22 stars and last changed on 2025-12-19. Nobody has reviewed it on Take My Repo yet, which says nothing about its quality. Read from GitHub on 2026-11-20.
GitHub is limiting requests or did not answer. The facts on this page still come from the last successful read.
Open on GitHubRonchy2000/Flocking-Formation-Control is a public repo on GitHub by Ronchy2000. An implementation of multi-UAV formation control with obstacle avoidance capability. Based on the paper [Flocking for Multi-Agent Dynamic Systems: Algorithms and Theory], this project provides formation control, target tracking and visualization tools for UAV swarm simulation.
It declares no license on GitHub. Public does not mean open source: without a license, nobody is granted the right to reuse it.
Its maker has not tagged a system, so it is unknown here. Its README says what it needs.
Open "Take it" on its page: Take My Repo writes an install plan for your machine and hands it to your AI agent (Claude Code, Codex or Cursor), which asks you before each step. Take My Repo has not tested it on any machine.
:fish: :bug: Small Inteli Creatures Based On Steering Behaviours
Its last change on GitHub was on 2025-12-19. Take My Repo does not judge from that whether it is maintained.
Nobody has reviewed it on Take My Repo yet, which says nothing about its quality.
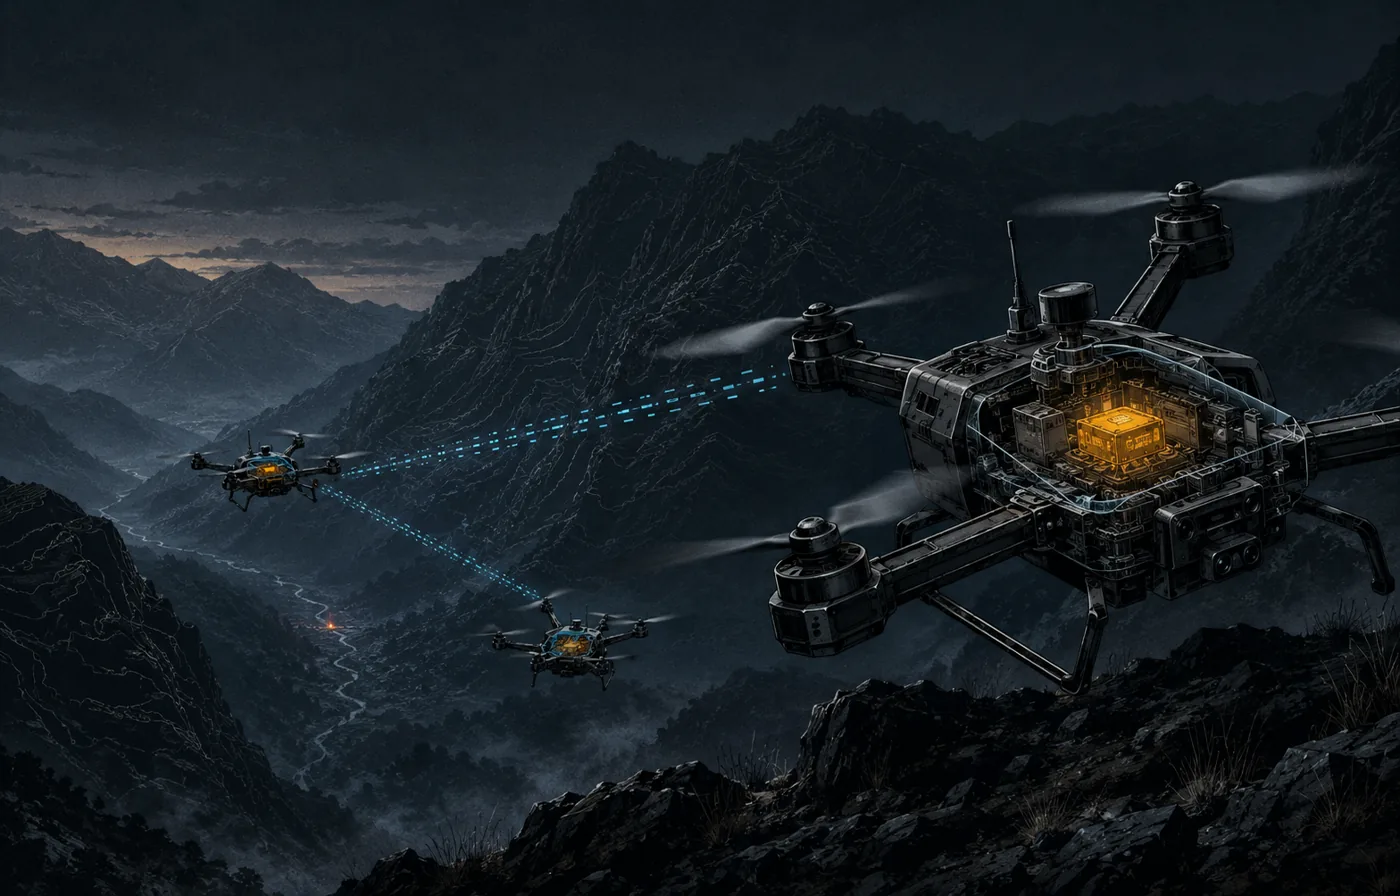
Industrial cooperative-UAV fleet coordination in Rust — formation keeping, Raft consensus, cooperative task allocation, RRT-APF collision avoidance & MAPPO navigation for civilian SAR / inspection / agriculture
🔥 CVPR 2025 (Nashville TN, USA) - The 4th Anti-UAV Workshop & Challenge 🥉
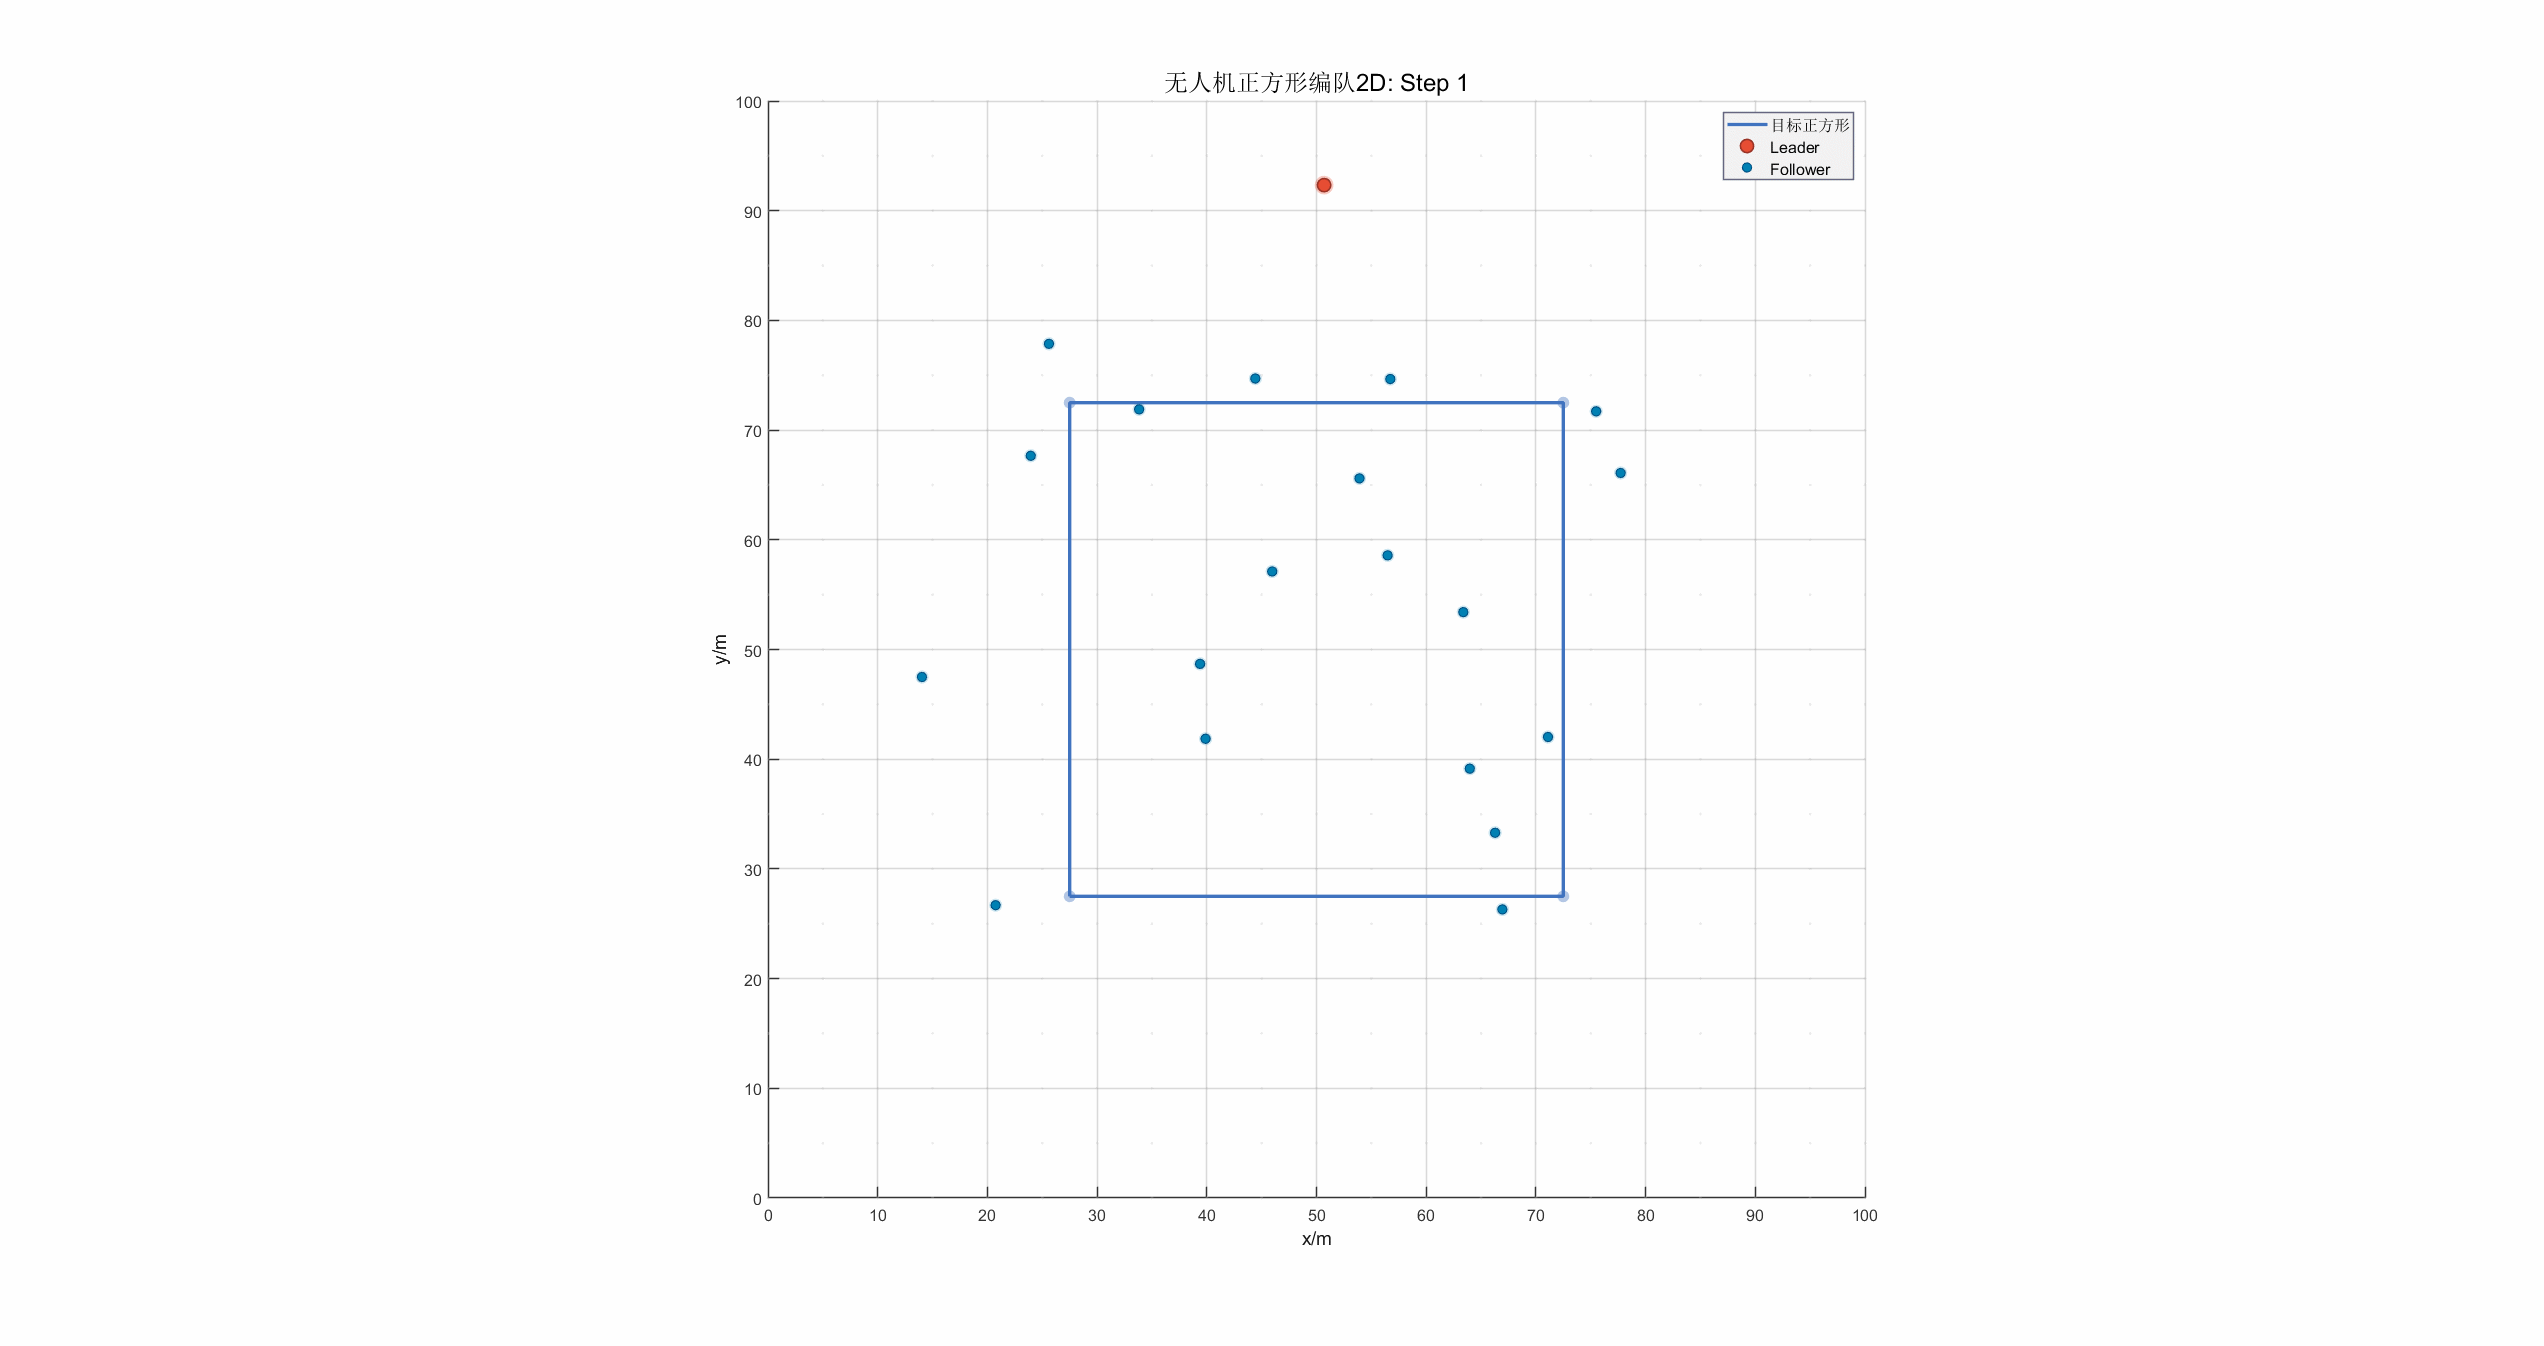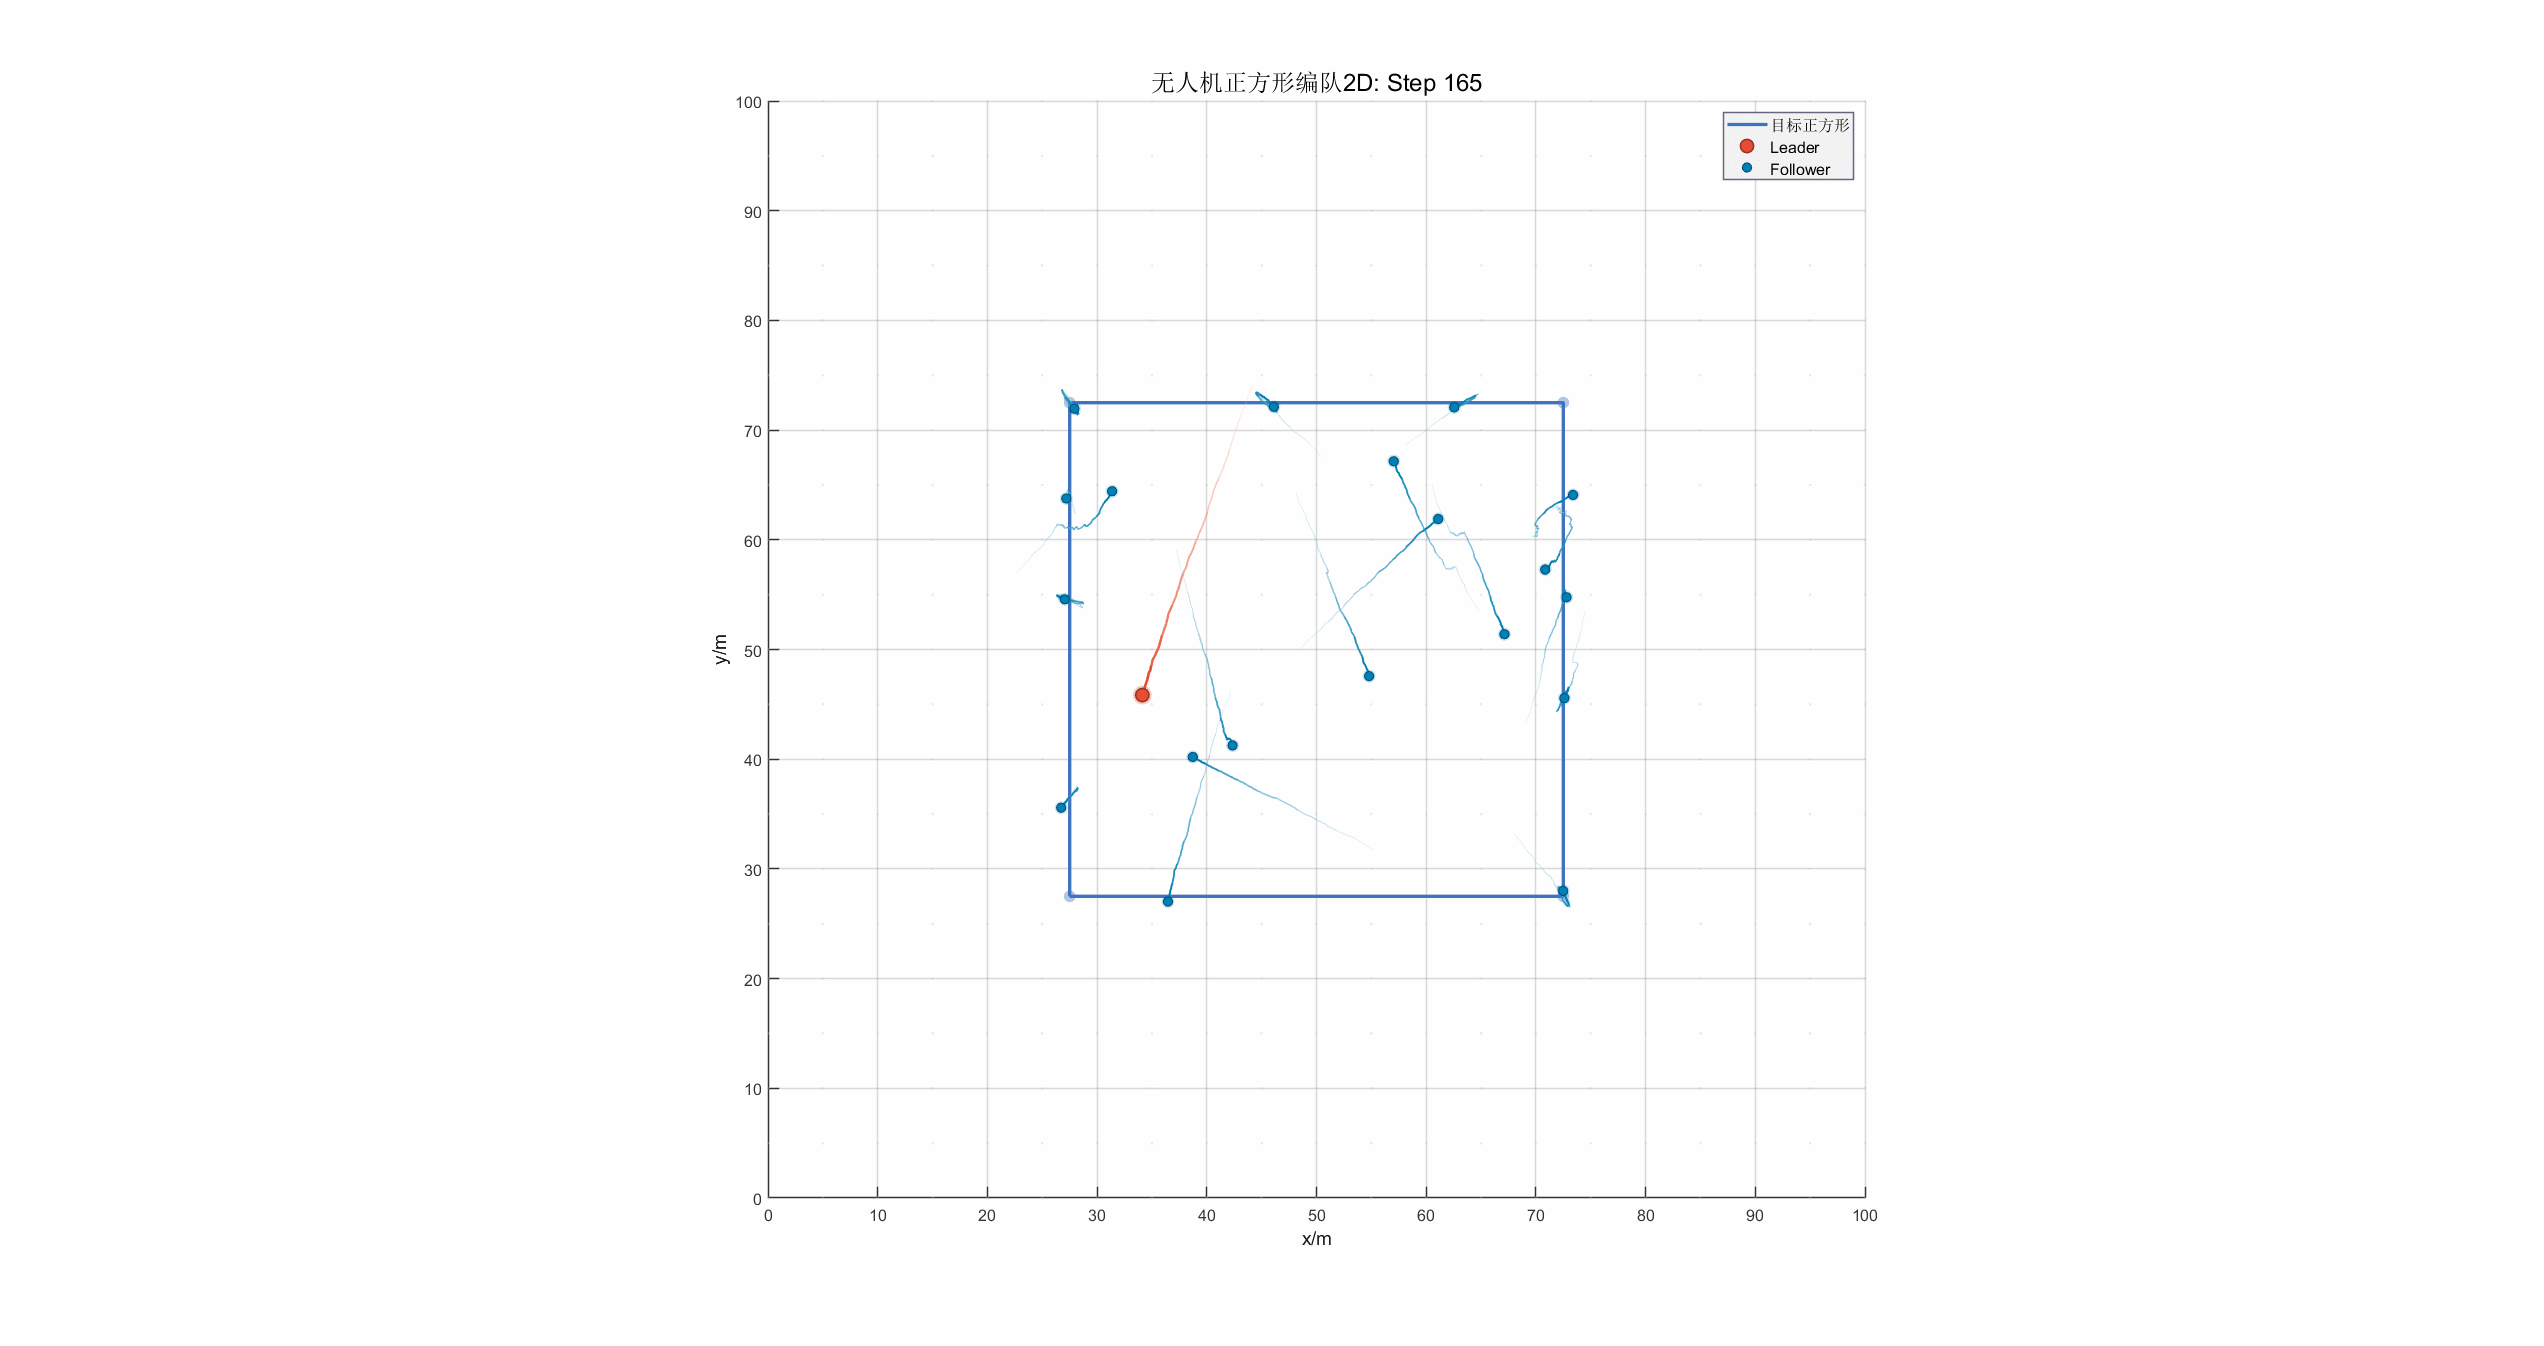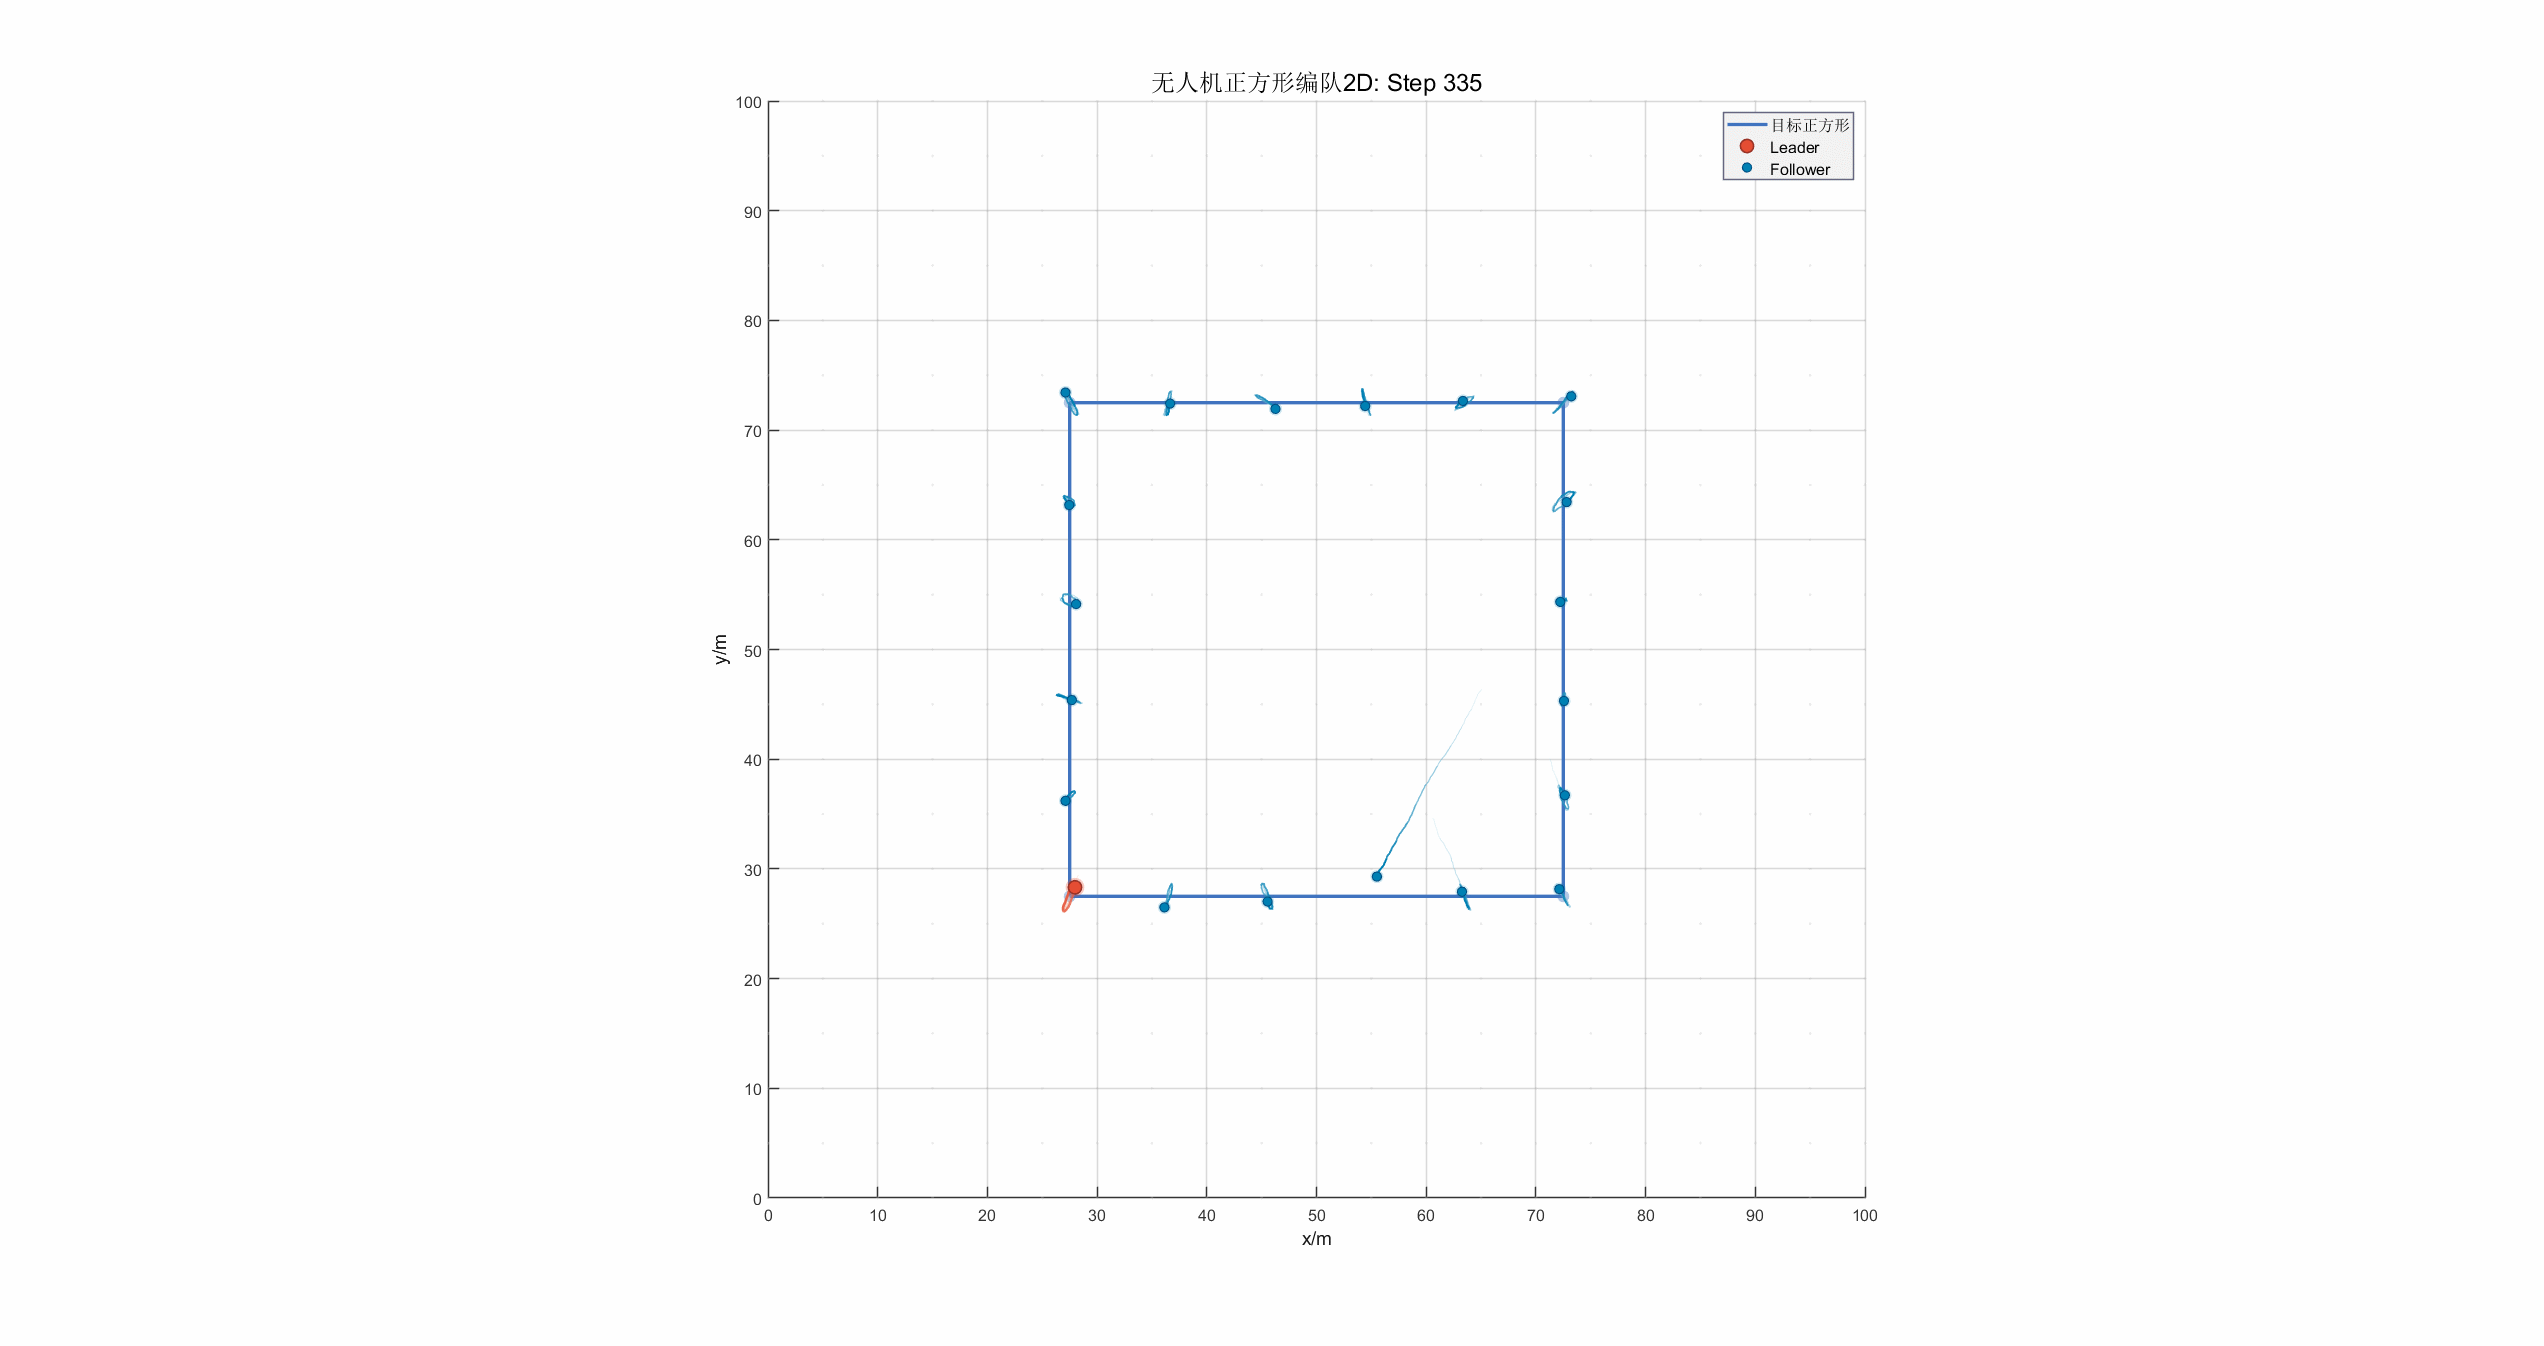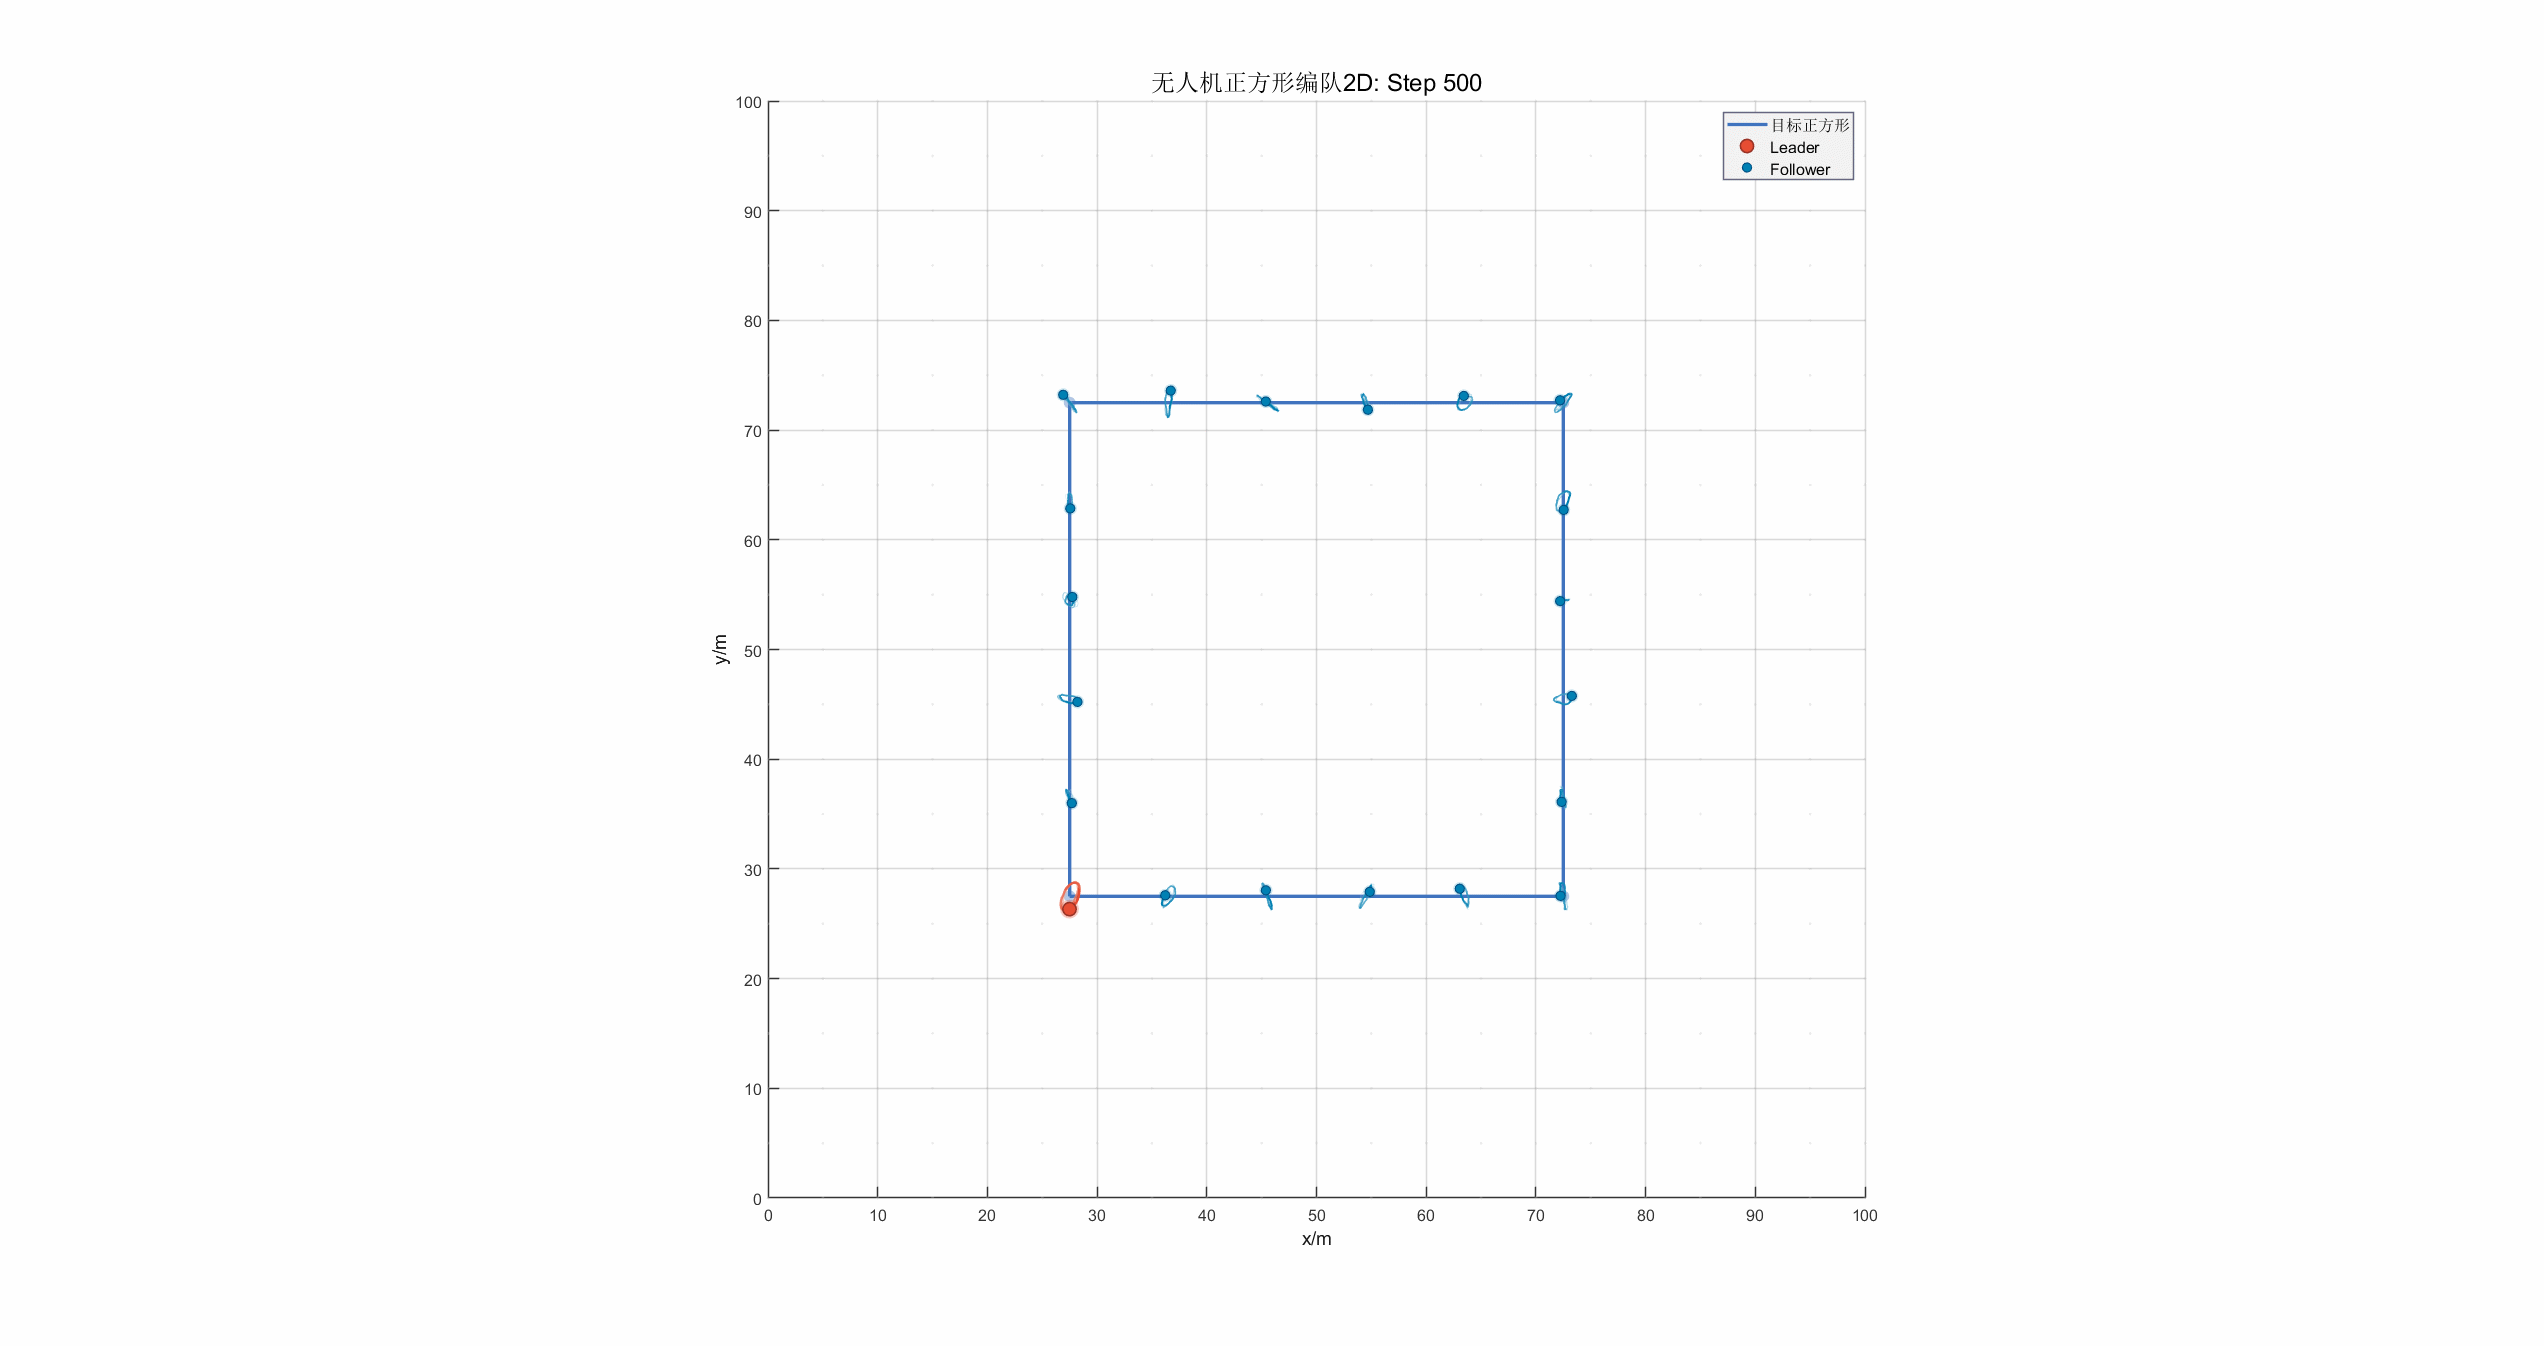
A MATLAB implementation of UAV square formation control using artificial potential fields, featuring autonomous organization, collision avoidance, and high-quality 2D/3D visualizations.
Open-source Autonomy Software in Rust-lang using gRPC for the Roomba series robot vacuum cleaners. Under development.
Projects from basic algorithms to MARL. Implements MADDPG,MATD3,MA/HAPPO in Predator-Prey pursuit games with PettingZoo MPE environments.
Automatically claim Epic Games weekly free titles with GitHub Actions and GLM-powered captcha solving.
Raspberry Pi OpenWrt/ImmortalWrt configuration guide. Full setup for OpenClash, DNS optimization, and network routing.
最新跨平台验证的西电学位论文模板,针对 macOS/Windows + TeX Live 2025 提供完整字体、编译与多版本管理流程。